Project
System level simulation of BAJA ATV(All terrain vehicle)ard
To carry out the system level simulation of an all terrain vehicle and analyse the model properties and results.
An all terrain vehicle is designed to be used in all terrains irrespective of nature of land.
Different models used here are CVT model(with and without dashboard and with look up table).
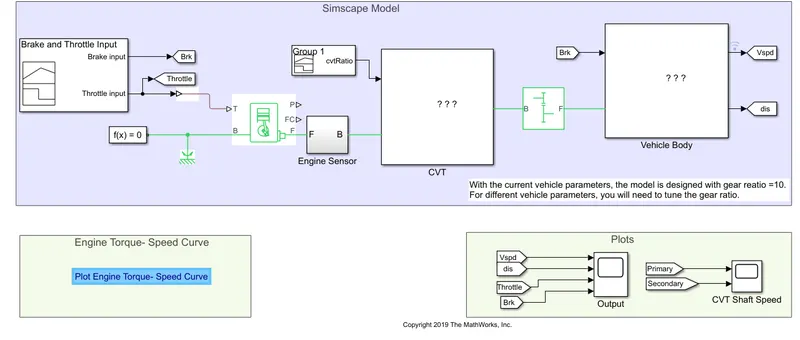
CVT model without dashboard(Original model).
This uses a signal builder as an input for brake and throttle.Other compenents include engine sensor,CVT gear ratio builder,CVT and vehicle body subsystem.
Throttle is used to adjust the rate of flow of the fuel to the engine which is connected to the engine sensor.
The generic engine block controls the torque delivered to the engine.
CVT subsystem.
The gear ratio is varied using the variable ratio gear which determines the rotation of the output shaft
The ideal rotational motion sensor generates an output control signal(angular velocity)when an input is fed.it determines primary and secondary velocity.
Vehicle body subsystem.
This determines the weight distribution between the axles depending on the road profile and acceleration.
Dashboard.
The brake and throttle input can be adjusted using the knob and variation is easy compared to signal builder.
The angular velocity as well as output speed can be measured easily.
Look up table
The brake and throttle inputs are fed using a pulse generator.The output speed is fed back to the input of CVT system.The CVT model works on a look up table which maps the i/p to o/p values.Lookup table is an array where the output is estimated for the corresponding input values while simulation is running.
The CVT gear ratio is calculated using this method.The engine torque and output velocity is dependent on gear ratio.SImulink takes the input (gear ratio) from table and updates the output.This helps to achieve maximum velocity.
Input output waveforms_with dashboard
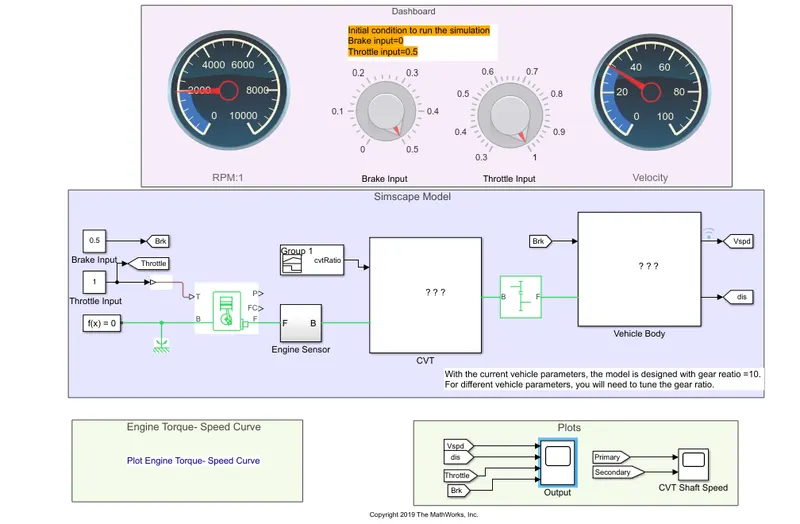
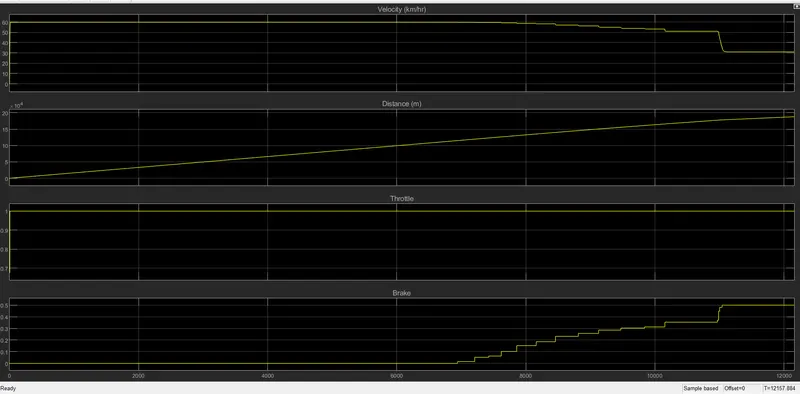
here the initial condition of zero braking is maintained.when braking is applied, the output acceleration decreases,indicates that they are inversely proportional.
Input output waveform without dashboard
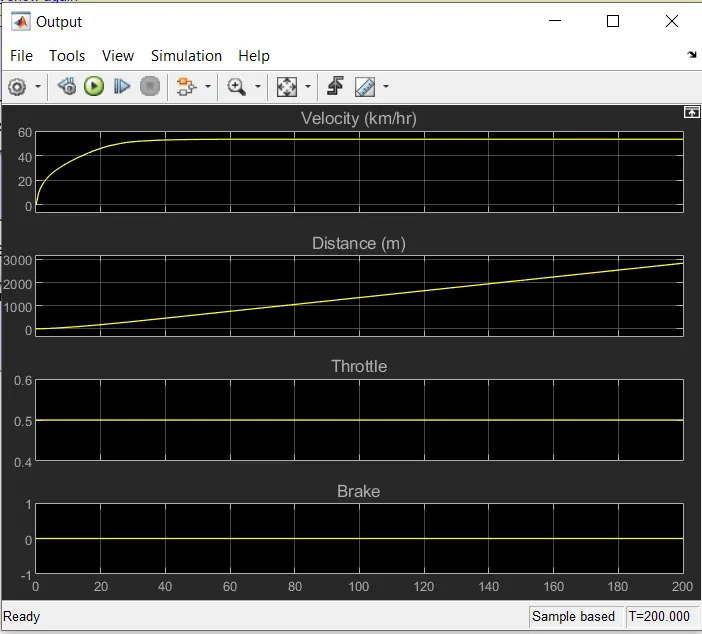
here the Velocity steadily increases for a constant value of throttle=0.5 and zero braking is maintained throughout.