Project
Aim:-
To study system-level simulation of an all-terrain vehicle under open loop and closed loop condition
Software:-
MATLAT 2021
APPARATUS REQUIRED:-
Laptop (or) Personal comperte with MATLAB installation
Objective:-
To prepare technical report of BAJA ATV model with and without dashboard
Theory:-
About all-terrain vehicle (ATV):-
All-terrain vehicle(ATV) is also known as light utility vehicle(LUV). It consists of low pressure tires. It is designed to handle a wider variety of terrain than most other vehicles.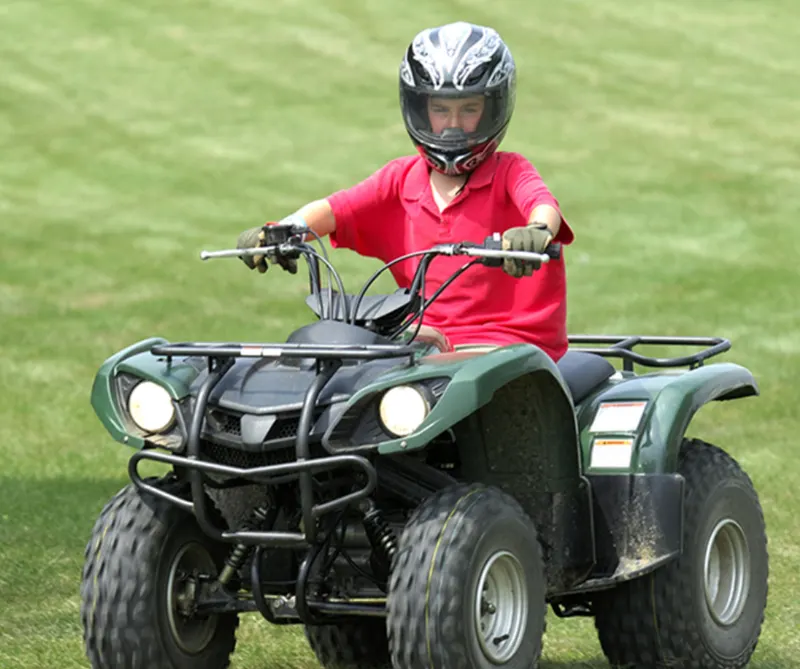
Figure 1
Figure 1 shows the one of the model of all-terrain vehicle
About BAJA ATV(SAE) vehicle:-
BAJA SAE Series is designed by engineering students, organized by Sociaty of Automative Engineers, USA in year 1976 at University of Carolina.
In this model BAJA ATV, the Engine is pre-set to run at 3300 rpm with the throttle value of '0.3'. And the velocity at 45 m/s.
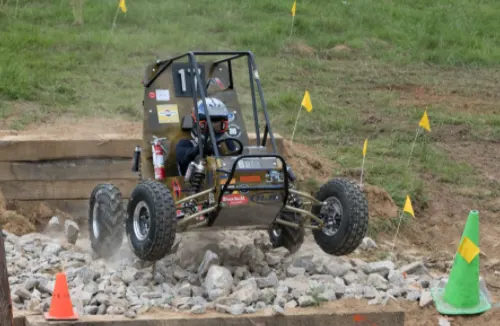
Figure 2
Figure 2 shows the BAJA ATV vehicle
Types of medel:-
BAJA ATV model with out dashboard
BAJA ATV model with dashboard
BAJA ATV model using lookup table with out dashboard
BAJA ATV model using lookup table with dashboard
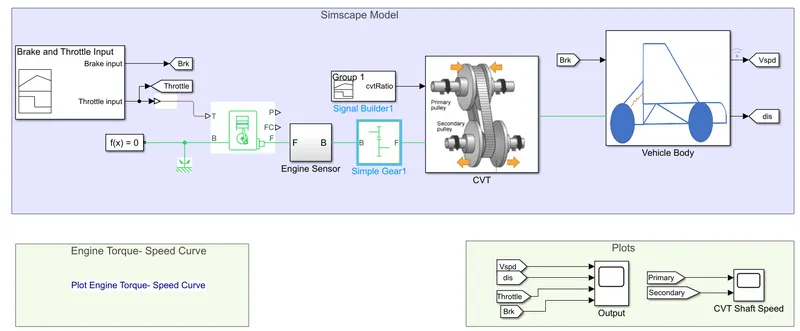
Figure 3
Figure 3 shows that model of BAJA ATV with out dash board
This model consists of
Break and throttle input
Engine sensor
CVT
Gear
Vehicle body
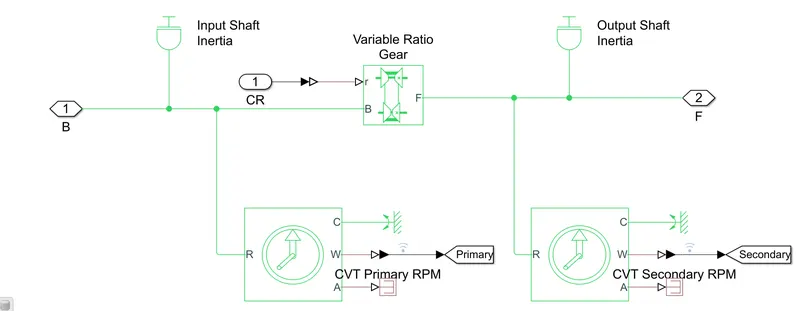
Figure 4
Figure 4 shows CVT model
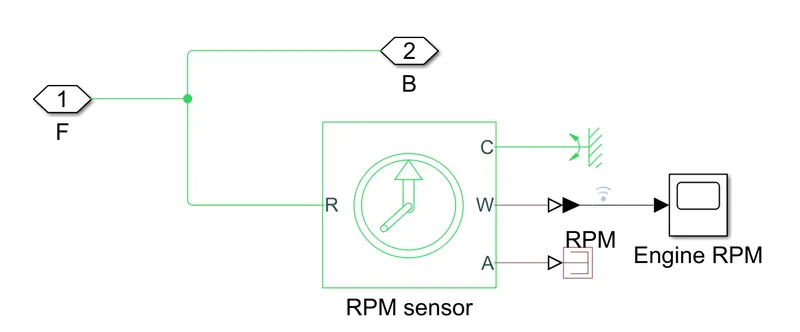
Figure 5
Figure 5 shows the engine sensor
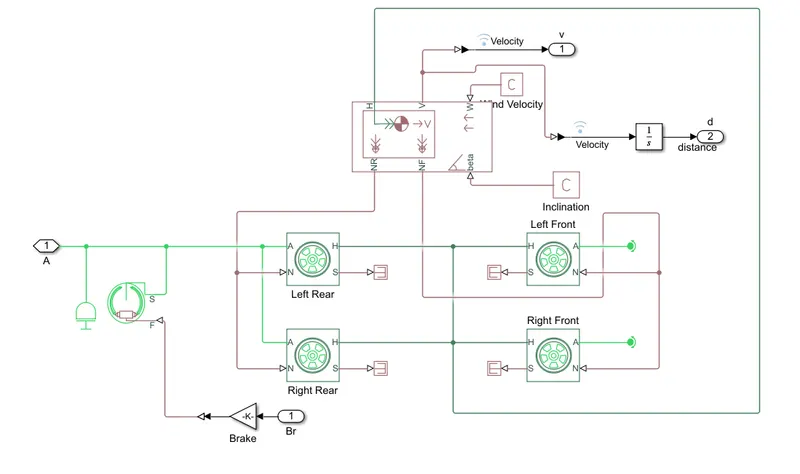
Figure 6
Figure 6 shows the vehicle body
Procedure:-
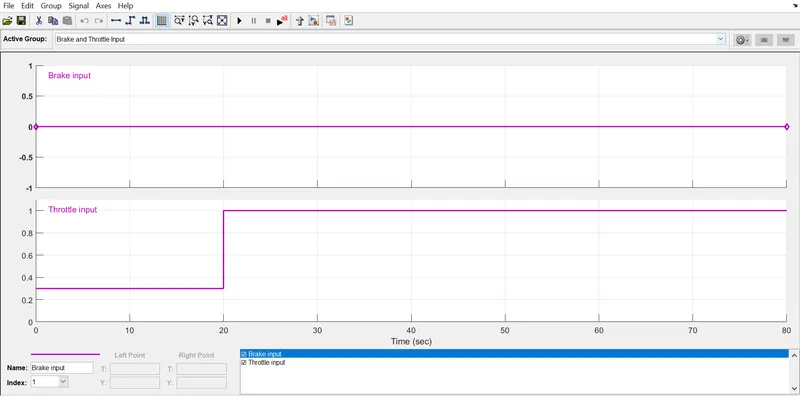
Figure 7
Figure 7 shows that input values of brake and throttle
Break = 0
throttle = 0.3 from 0 to 20 seconds & 1 from 20 to 80 seconds
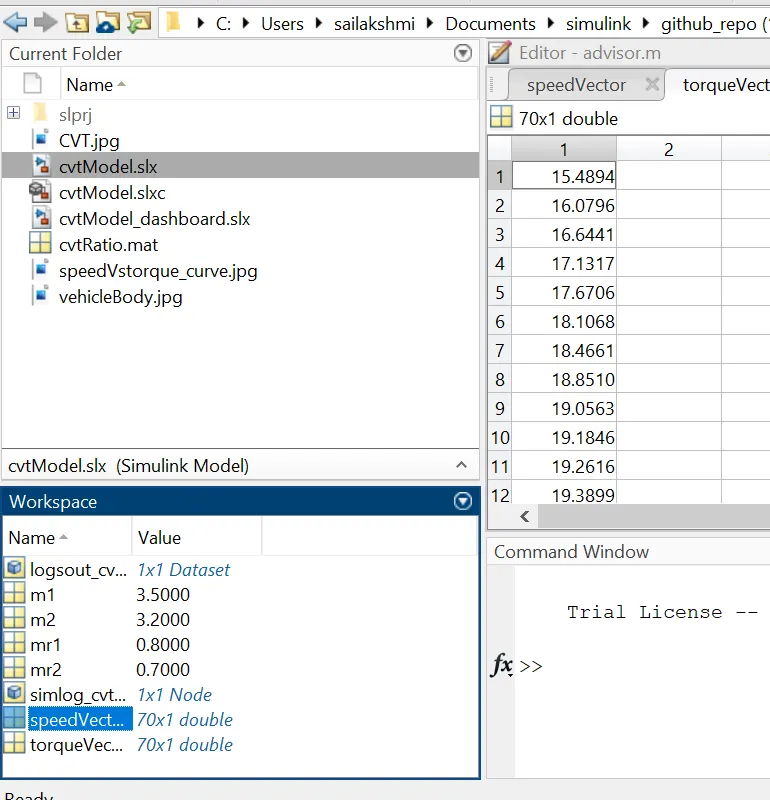
Figure 8
Figure 8 shows assigning input values of speed and torque from work space
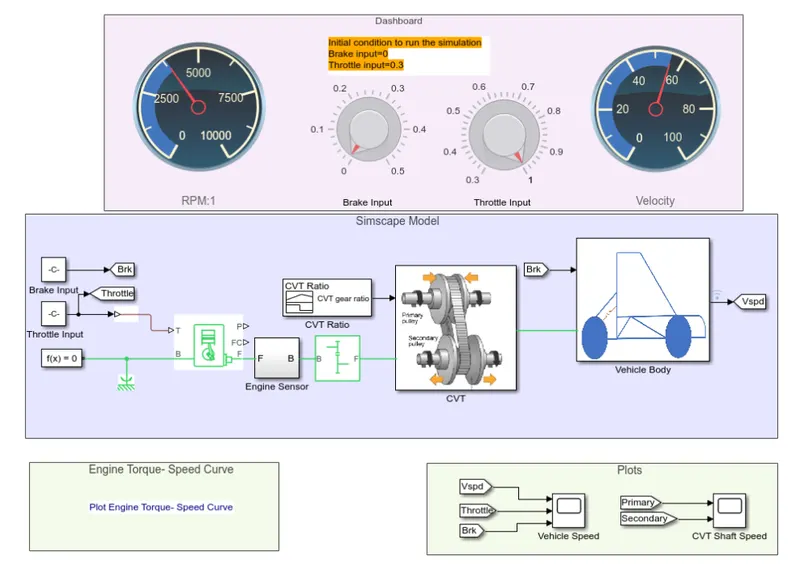
FIgure 9
Figure 9 shows the BAJA ATV model with dashboard
In the figure 9 instead of using signal builder, considered brake input and throttle input rest is same
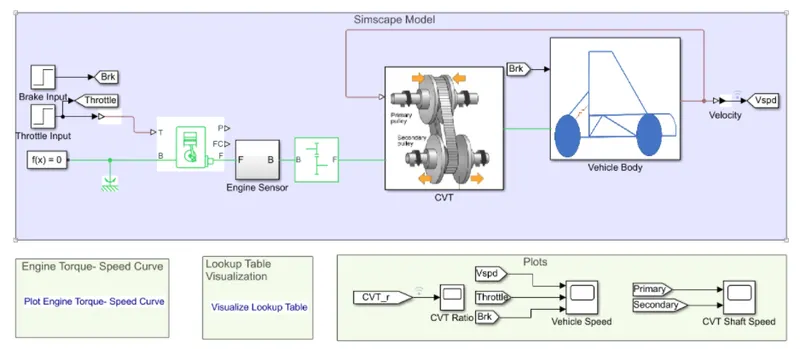
Figure 10
Figure 10 shows the BAJA ATV model using lookup table with out dashboard
Inthis case considered closed loop instead of open loop
Initial engine speed is 2100 rpm
mechanical rotation of driven pulley and driver pulley is 0.8 and 0.7
Vehicle mass is 250 kg
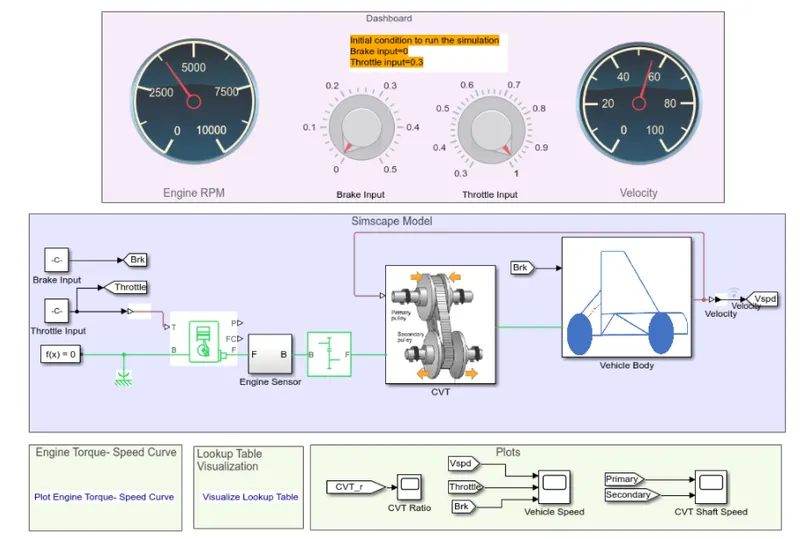
Figure 11
Figure 11 shows the BAJA ATV model using lookup table with dashboard
Results:-
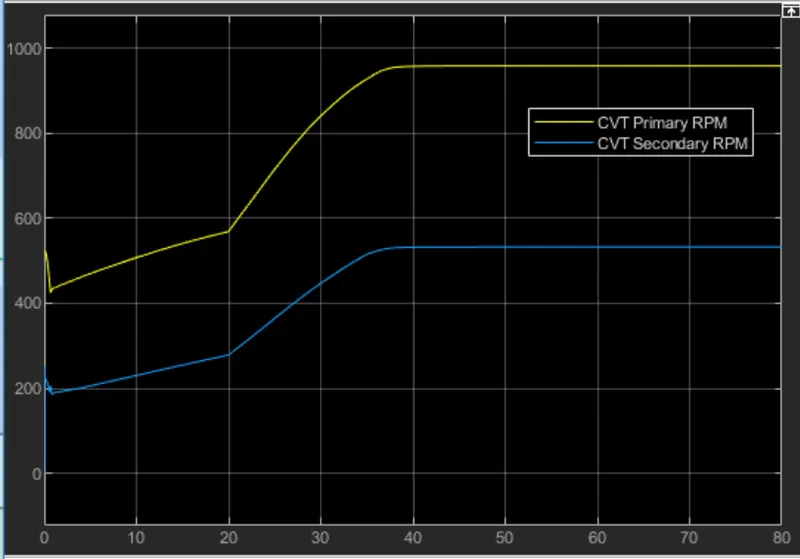
Figure 12
Figure 12 shows the CVT rpm primary and secondary for BAJA ATV model with out dashboard
The radius of the primary shaft is more than secondary shaft. As we know that if radius increases, then speed of the shaft also increases
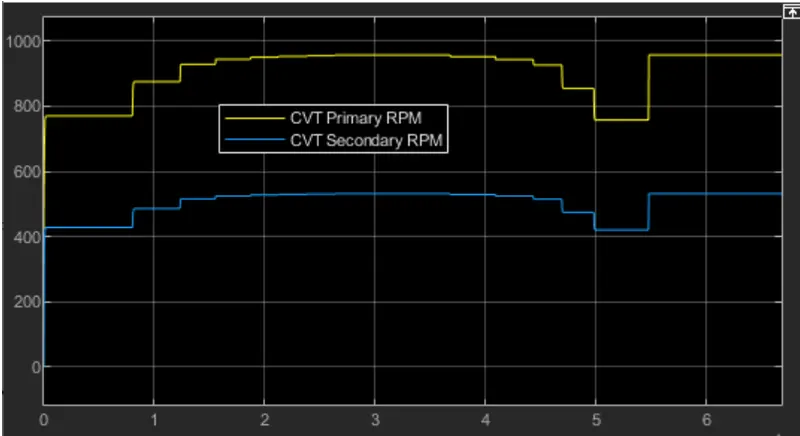
Figure 13
Figure 13 shows the CVT primary and secondary rpm of BAJA ATV model with dashboard
In this speed of the vehicle increased using throttle and speed of the vehicle decreased using braking. The radius of the primary shaft is more than secondary shaft. As we know that if radius increases, then speed of the shaft also increases.
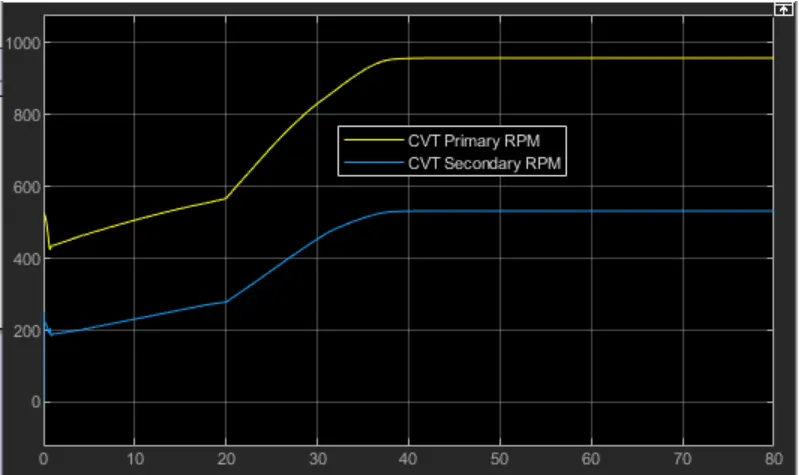
Figure 14
Figure 14 shows the CVT rpm primary and secondary for BAJA ATV model using lookup table with out dashboard.
The radius of the primary shaft is more than secondary shaft. As we know that if radius increases, then speed of the shaft also increases
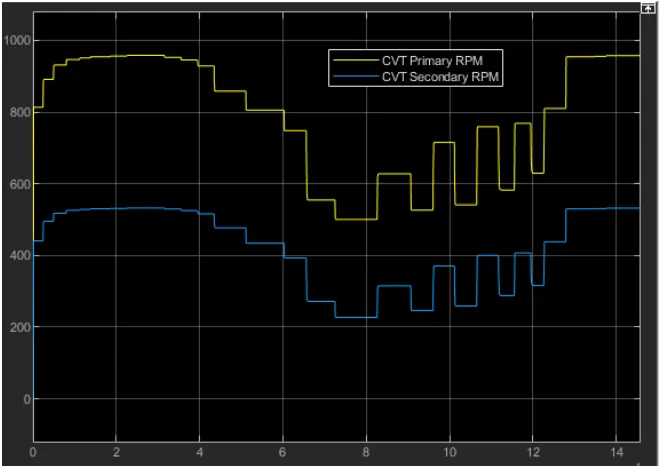
Figure 15
Figure 15 shows the CVT rpm primary and secondary for BAJA ATV model using lookup table with dashboard
In this speed of the vehicle increased using throttle and speed of the vehicle decreased using braking. The radius of the primary shaft is more than secondary shaft. As we know that if radius increases, then speed of the shaft also increases.
Conclusion:-
We can conclude that by increasing of throttle, the speed of the vehicle increases, and
by increasing brake, the speed of the vehicle decreases.
and also studied different models of BAJA ATV model.