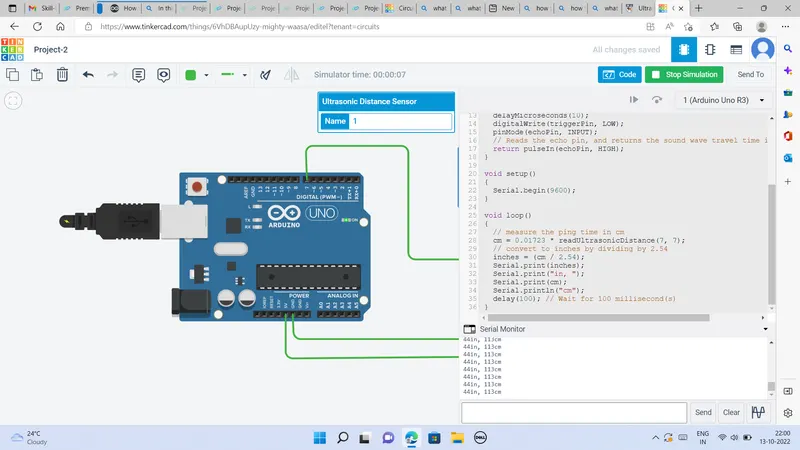
Project 2 - Measuring the distance of an object using ultrasonic sensor and also smoothen the sensor data using moving average filter
In this project the implementation of code for “Measuring distance of an object using ultrasonic distance sensor (28015 Ping) and also smoothen the sensor data using moving average filter”.
Ultrasonic Sensor:
Ultrasonic sensors are useful for measuring distances. Ultrasonic waves are transmitted and whenever these strike an obstacle and return back in the from of an echo.Difference of outgoing sound and returning echo gives us the distance.
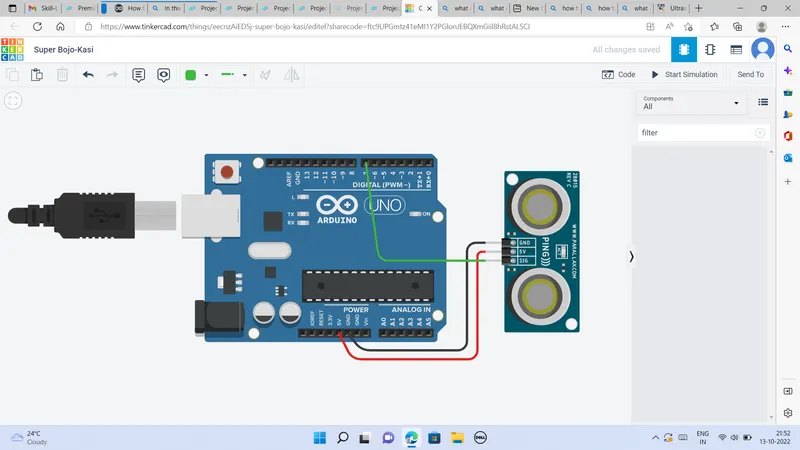
This sketch reads a PING ultrasonic rangefinder and returns the distance to the closest object in range.
To do this, it sends a pulse to the sensor to initiate a reading, then listens for a pulse to return.
The length of the returning pulse is proportional to the distance of the object from the sensor.
The circuit:
* +V connection of the PING))) attached to +5V
* GND connection attached to ground
* SIG connection attached to digital pin 7
int inches = 0;

int cm = 0;

long readUltrasonicDistance(int triggerPin, int echoPin)
{
  pinMode(triggerPin, OUTPUT);  // Clear the trigger
  digitalWrite(triggerPin, LOW);
  delayMicroseconds(2);
  // Sets the trigger pin to HIGH state for 10 microseconds
  digitalWrite(triggerPin, HIGH);
  delayMicroseconds(10);
  digitalWrite(triggerPin, LOW);
  pinMode(echoPin, INPUT);
  // Reads the echo pin, and returns the sound wave travel time in microseconds
  return pulseIn(echoPin, HIGH);
}

void setup()
{
  Serial.begin(9600);
}

void loop()
{
  // measure the ping time in cm
  cm = 0.01723 * readUltrasonicDistance(7, 7);
  // convert to inches by dividing by 2.54
  inches = (cm / 2.54);
  Serial.print(inches);
  Serial.print("in, ");
  Serial.print(cm);
  Serial.println("cm");
  delay(100); // Wait for 100 millisecond(s)
}OUTPUT: