Project 2 - Measuring distance of an object using ultrasonic sensor (HC-SR04)
Measuring distance of an object using ultrasonic distance sensor (HC-SR04):
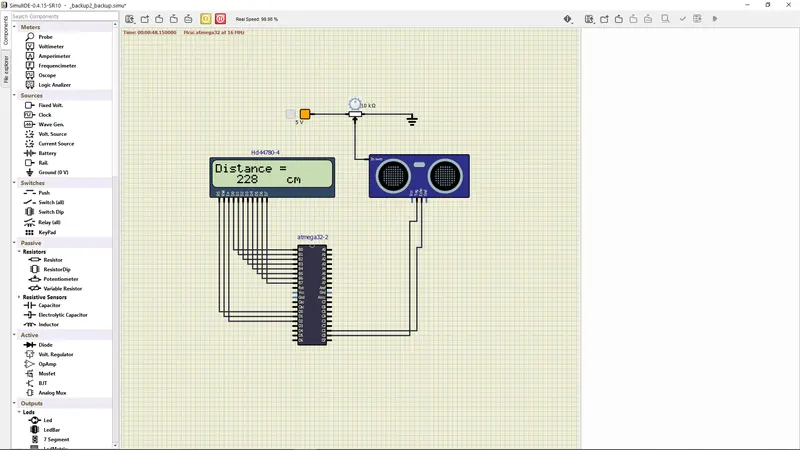
BY USING POTENTIO METER WE CAN ABLE TO SEE THE DISTANCE CHANGING IN LCD PANNEL:
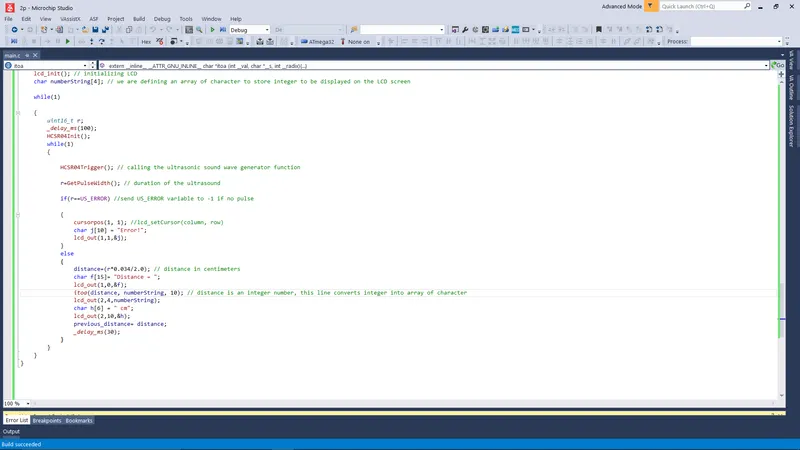
PROGRAM:
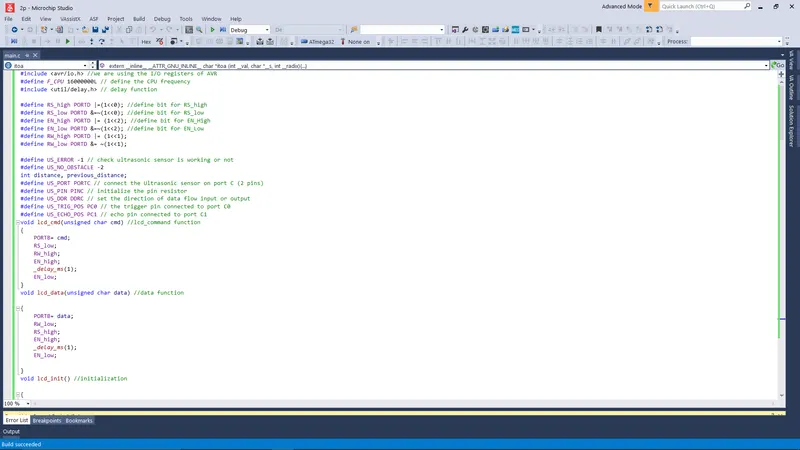
#include <avr/io.h> //we are using the I/O registers of AVR
#define F_CPU 16000000L // define the CPU frequency
#include <util/delay.h> // delay function
#define RS_high PORTD |=(1<<0); //define bit for RS_high
#define RS_low PORTD &=~(1<<0); //define bit for RS_low
#define EN_high PORTD |= (1<<2); //define bit for EN_High
#define EN_low PORTD &=~(1<<2); //define bit for EN_Low
#define RW_high PORTD |= (1<<1);
#define RW_low PORTD &= ~(1<<1);
#define US_ERROR -1 // check ultrasonic sensor is working or not
#define US_NO_OBSTACLE -2
int distance, previous_distance;
#define US_PORT PORTC // connect the Ultrasonic sensor on port C (2 pins)
#define US_PIN PINC // initialize the pin resistor
#define US_DDR DDRC // set the direction of data flow input or output
#define US_TRIG_POS PC0 // the trigger pin connected to port C0
#define US_ECHO_POS PC1 // echo pin connected to port C1
void lcd_cmd(unsigned char cmd) //lcd_command function
{
PORTB= cmd;
RS_low;
RW_high;
EN_high;
_delay_ms(1);
EN_low;
}
void lcd_data(unsigned char data) //data function
{
PORTB= data;
RW_low;
RS_high;
EN_high;
_delay_ms(1);
EN_low;
}
void lcd_init() //initialization
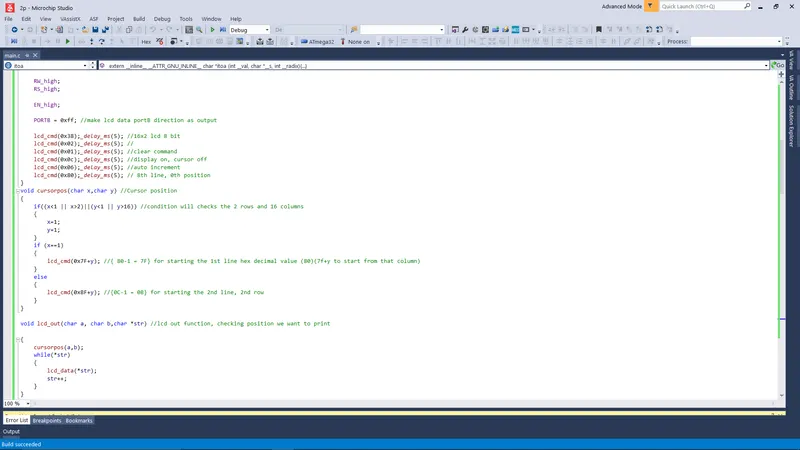
{
RW_high;
RS_high;
EN_high;
PORTB = 0xff; //make lcd data portB direction as output
lcd_cmd(0x38);_delay_ms(5); //16x2 lcd 8 bit
lcd_cmd(0x02);_delay_ms(5); //
lcd_cmd(0x01);_delay_ms(5); //clear command
lcd_cmd(0x0c);_delay_ms(5); //display on, cursor off
lcd_cmd(0x06);_delay_ms(5); //auto increment
lcd_cmd(0x80);_delay_ms(5); // 8th line, 0th position
}
void cursorpos(char x,char y) //Cursor position
{
if((x<1 || x>2)||(y<1 || y>16)) //condition will checks the 2 rows and 16 columns
{
x=1;
y=1;
}
if (x==1)
{
lcd_cmd(0x7F+y); //{ 80-1 = 7F} for starting the 1st line hex decimal value (80)(7f+y to start from that column)
}
else
{
lcd_cmd(0xBF+y); //{0C-1 = 0B} for starting the 2nd line, 2nd row
}
}
void lcd_out(char a, char b,char *str) //lcd out function, checking position we want to print
{
cursorpos(a,b);
while(*str)
{
lcd_data(*str);
str++;
}
}
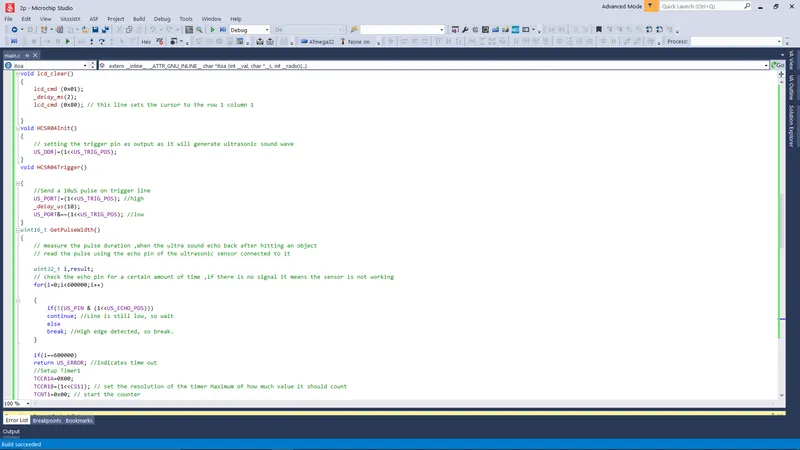
void lcd_clear()
{
lcd_cmd (0x01);
_delay_ms(2);
lcd_cmd (0x80); // this line sets the cursor to the row 1 column 1
}
void HCSR04Init()
{
// setting the trigger pin as output as it will generate ultrasonic sound wave
US_DDR|=(1<<US_TRIG_POS);
}
void HCSR04Trigger()
{
//Send a 10uS pulse on trigger line
US_PORT|=(1<<US_TRIG_POS); //high
_delay_us(10);
US_PORT&=~(1<<US_TRIG_POS); //low
}
uint16_t GetPulseWidth()
{
// measure the pulse duration ,When the ultra sound echo back after hitting an object
// read the pulse using the echo pin of the ultrasonic sensor connected to it
uint32_t i,result;
// check the echo pin for a certain amount of time ,if there is no signal it means the sensor is not working
for(i=0;i<600000;i++)
{
if(!(US_PIN & (1<<US_ECHO_POS)))
continue; //Line is still low, so wait
else
break; //High edge detected, so break.
}
if(i==600000)
return US_ERROR; //Indicates time out
//Setup Timer1
TCCR1A=0X00;
TCCR1B=(1<<CS11); // set the resolution of the timer Maximum of how much value it should count
TCNT1=0x00; // start the counter
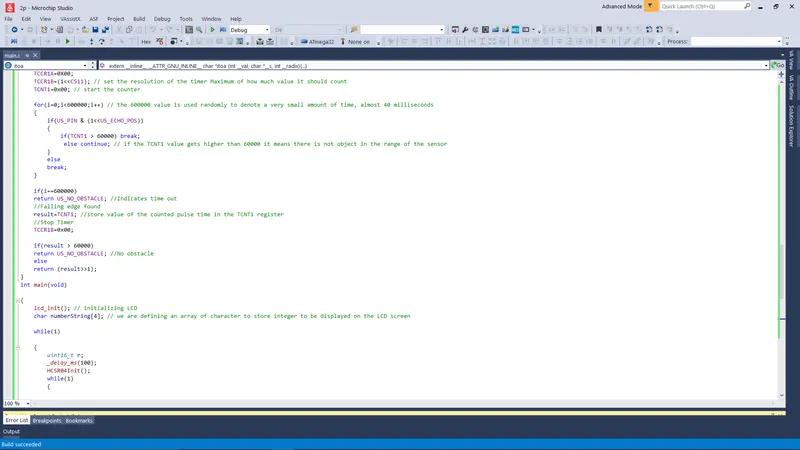
for(i=0;i<600000;i++) // the 600000 value is used randomly to denote a very small amount of time, almost 40 milliseconds
{
if(US_PIN & (1<<US_ECHO_POS))
{
if(TCNT1 > 60000) break;
else continue; // if the TCNT1 value gets higher than 60000 it means there is not object in the range of the sensor
}
else
break;
}
if(i==600000)
return US_NO_OBSTACLE; //Indicates time out
//Falling edge found
result=TCNT1; //store value of the counted pulse time in the TCNT1 register
//Stop Timer
TCCR1B=0x00;
if(result > 60000)
return US_NO_OBSTACLE; //No obstacle
else
return (result>>1);
}
int main(void)
{
lcd_init(); // initializing LCD
char numberString[4]; // we are defining an array of character to store integer to be displayed on the LCD screen
while(1)
{
uint16_t r;
_delay_ms(100);
HCSR04Init();
while(1)
{
HCSR04Trigger(); // calling the ultrasonic sound wave generator function
r=GetPulseWidth(); // duration of the ultrasound
if(r==US_ERROR) //send US_ERROR variable to -1 if no pulse
{
cursorpos(1, 1); //lcd_setCursor(column, row)
char j[10] = "Error!";
lcd_out(1,1,&j);
}
else
{
distance=(r*0.034/2.0); // distance in centimeters
char f[15]= "Distance = ";
lcd_out(1,0,&f);
itoa(distance, numberString, 10); // distance is an integer number, this line converts integer into array of character
lcd_out(2,4,numberString);
char h[6] = " cm";
lcd_out(2,10,&h);
previous_distance= distance;
_delay_ms(30);
}
}
}
}