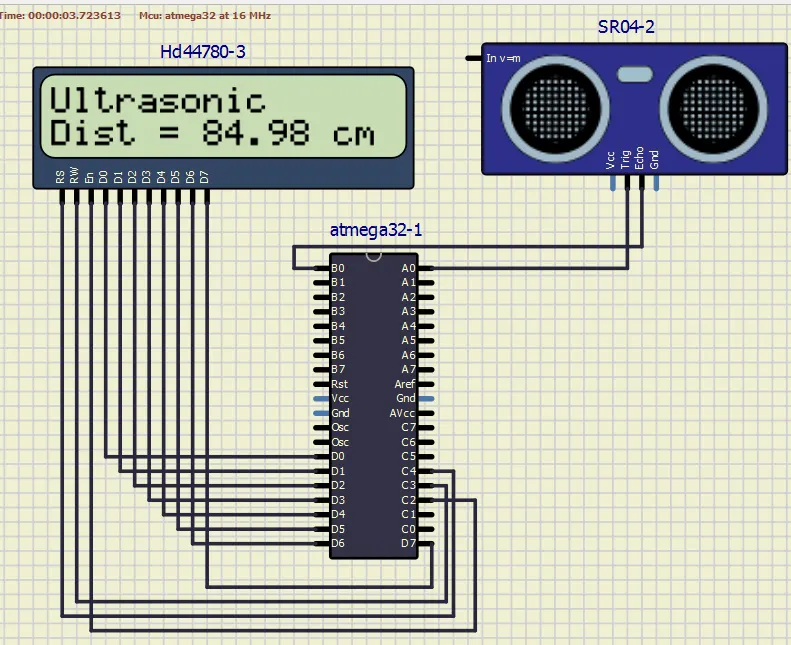
Project 2 - Measuring distance of an object using ultrasonic sensor (HC-SR04)
Implementation of code for “Measuring distance of an object using ultrasonic distance sensor (HC-SR04)
COMPONENTS
ultrasonic sensor
atmega32
lcd
CIRCUIT
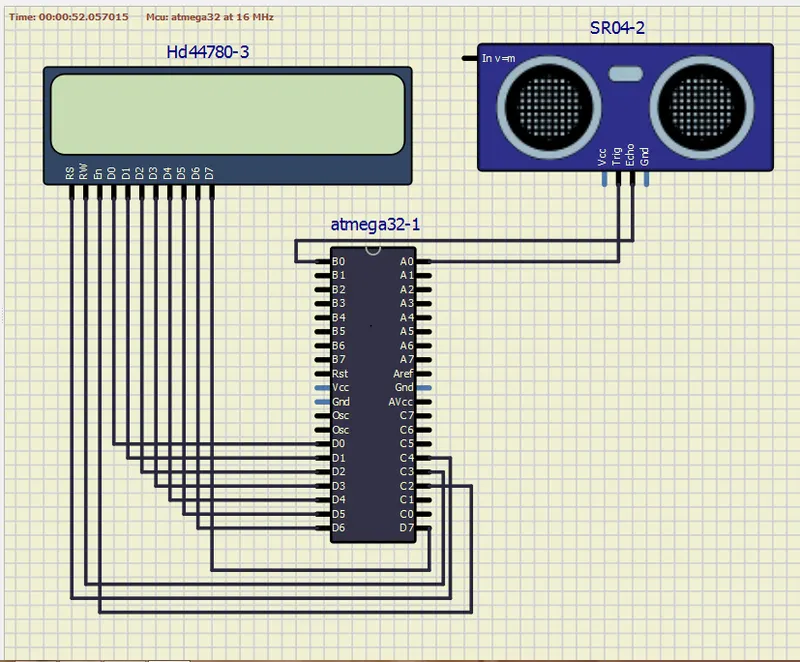
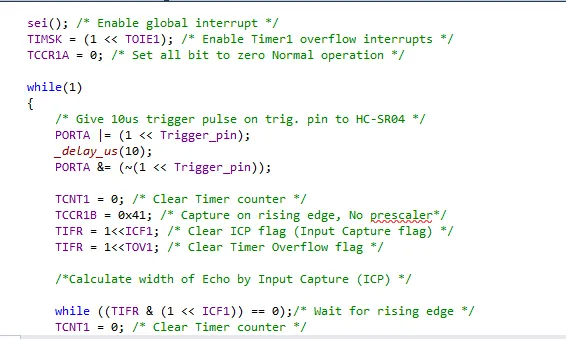
- ATmega16 microcontroller needs to transmit at least 10 us trigger pulse to the HC-SR04 Trig Pin.
- After getting a trigger pulse, HC-SR04 automatically sends eight 40 kHz sound waves and the microcontroller waits for rising edge output at the Echo pin.
- When the rising edge capture occurs at the Echo pin which is connected to an input of ATmega16, start Timer of ATmega16 and again wait for a falling edge on the Echo pin.
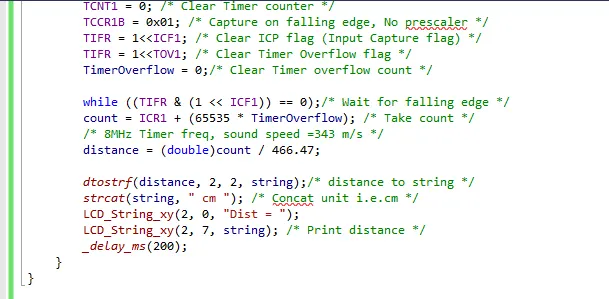
- As soon as the falling edge is captured at the Echo pin, the microcontroller reads the count of the Timer.
- This time count is used to calculate the distance to an object.
Calculation (distance in cm) (H1)
Sound velocity = 343.00 m/s = 34300 cm/s
The distance of Object (in cm) = Sound velocity *Timer/2
= 34300*Timer/2
= 17150*Timer
Now, here we have selected an internal 8 MHz oscillator frequency for ATmega16, with No-presale for timer frequency. Then time to execute 1 instruction is 0.125 us.
So, the timer gets incremented after 0.125 us time elapse.
= 17150 x (TIMER value) x 0.125 x 10^-6 cm
= 0.125 x (TIMER value)/58.30 cm
= (TIMER value) / 466.47 cm
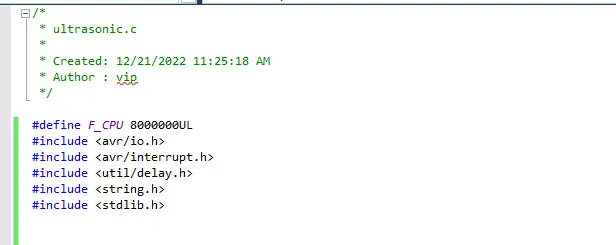
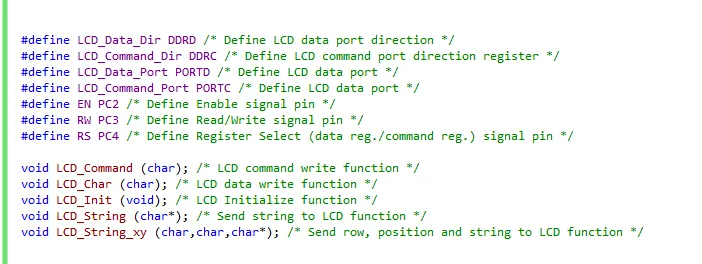
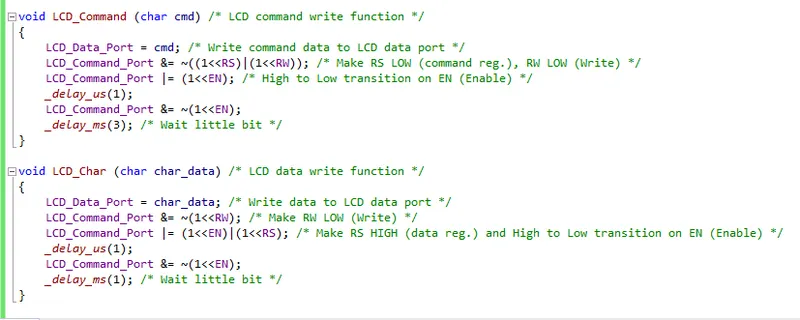
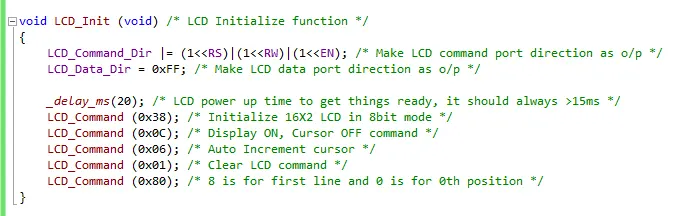
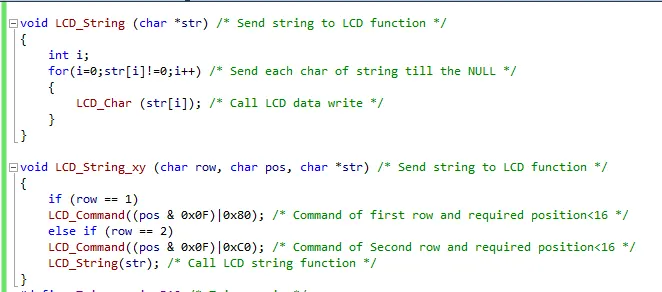
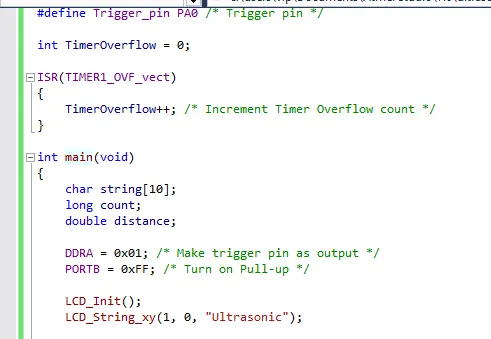
CODE
output