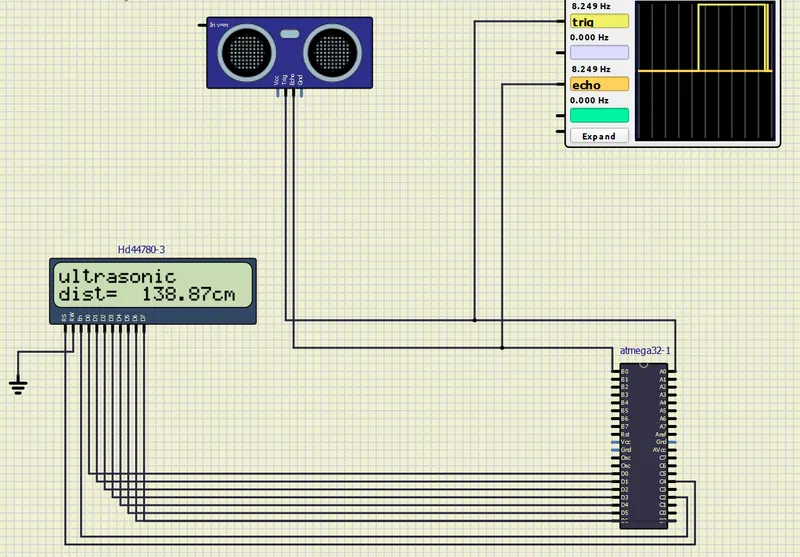
Project 2 - Measuring distance of an object using ultrasonic sensor (HC-SR04)
Project 2 - Measuring distance of an object using ultrasonic sensor (HC-SR04):-
CODE:-
#include <avr/io.h>
#define F_CPU 8000000ul
#include <util/delay.h>
#include <avr/interrupt.h>
#include <string.h>
#include <stdlib.h>
#define lcd_data DDRD
#define lcd_cmnd DDRC
#define lcd_data_port PORTD
#define lcd_cmd_port PORTC
#define EN PC2
#define RS PC4
void lcd_cmd(char);
void lcd_char(char);
void lcd_init(void);
void lcd_string(char*);
void lcd_string_xy (char,char,char*);
void lcd_cmd(char cmd)
{
lcd_data_port = cmd;
lcd_cmd_port&=~(1<<RS);
lcd_cmd_port|= (1<<EN);
_delay_ms(1);
lcd_cmd_port&=~(1<<EN);
_delay_ms(2);
}
void lcd_char(char char_data)
{
lcd_data_port= char_data;
lcd_cmd_port|=((1<<EN)|(1<<RS));
_delay_ms(1);
lcd_cmd_port&=~(1<<EN);
_delay_ms(1);
}
void lcd_init(void)
{
lcd_cmnd|= (1<<RS)|(1<<EN);
lcd_data= 0xff;
_delay_ms(20);
lcd_cmd(0x38);
lcd_cmd(0x0C);
lcd_cmd(0x06);
lcd_cmd(0x01);
lcd_cmd(0x80);
}
void lcd_string(char *str)
{
int i;
for(i=0;str[i]!=0;i++)
{
lcd_char (str[i]);
}
}
void lcd_string_xy(char row,char pos,char *str)
{
if (row == 1)
lcd_cmd((pos & 0x0f)|0x80);
else if (row == 2)
lcd_cmd((pos & 0x0f)|(0xC0));
lcd_string(str);
}
#define trigger_pin PA0
int TimerOverFlow = 0;
ISR(TIMER1_OVF_vect)
{
TimerOverFlow++;
}
int main (void)
{
char string[10];
long count;
double distance;
DDRA = 0x01;
PORTB = 0xff;
lcd_init();
lcd_string_xy(1,0,"ultrasonic");
sei();
TIMSK = (1<< TOIE1);
TCCR1A = 0;
while(1)
{
PORTA |= (1<< trigger_pin);
_delay_ms(10);
PORTA &=(~(1<< trigger_pin));
TCNT1 = 0;
TCCR1B = 0x41;
TIFR = 1<<ICF1;
TIFR = 1<<TOV1;
while ((TIFR & (1<<ICF1)) == 0);
TCNT1 = 0;
TCCR1B = 0x01;
TIFR = 1<<ICF1;
TIFR = 1<<TOV1;
TimerOverFlow = 0;
while ((TIFR & (1<< ICF1))== 0);
count = ICR1 +(65535 * TimerOverFlow);
distance = (double)count/466.47;
dtostrf(distance,2,2,string);
strcat(string,"cm");
lcd_string_xy(2,0,"dist=");
lcd_string_xy(2,7,string);
_delay_ms(200);
}
}
OUTPUT:-