Project 2 - Implement the Code for controlling the retraction and extension of Airplane’s landing gear
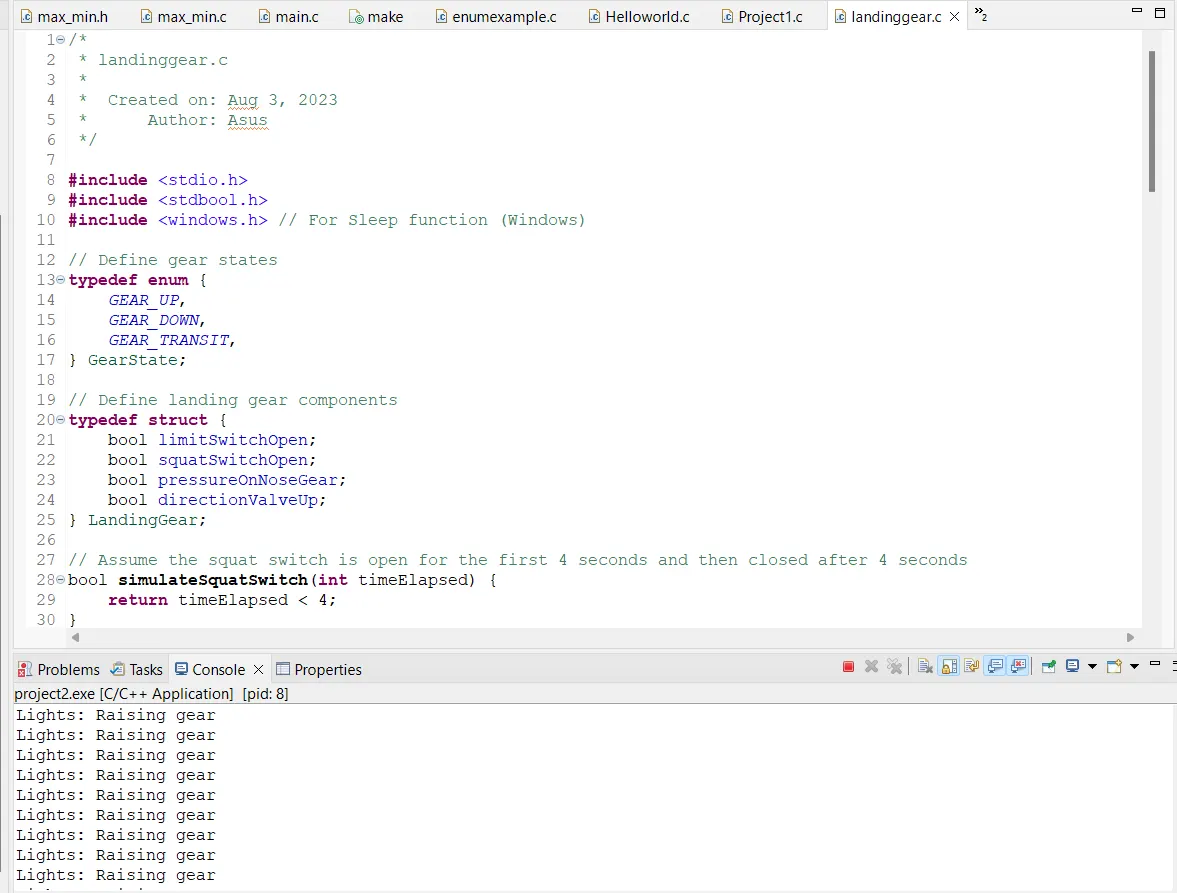
landinggear.c
*
* Created on: Aug 3, 2023
* Author: Asus
*/
#include
#include
#include
// Define gear states
typedef enum {
GEAR_UP,
GEAR_DOWN,
GEAR_TRANSIT,
} GearState;
// Define landing gear components
typedef struct {
bool limitSwitchOpen;
bool squatSwitchOpen;
bool pressureOnNoseGear;
bool directionValveUp;
} LandingGear;
// Assume the squat switch is open for the first 4 seconds and then closed after 4 seconds
bool simulateSquatSwitch(int timeElapsed) {
return timeElapsed < 4>}
// Function to check if squat switch is open for 4 seconds
bool checkSquatSwitch()
{
int timeElapsed = 0;
while (timeElapsed < 4> if (simulateSquatSwitch(timeElapsed)) {
timeElapsed++;
Sleep(1000); // Wait for 1 second (1000 milliseconds) - Windows
} else {
break;
}
}
return true;
}
// Function to handle landing gear transitions
void transitionGearState(GearState* currentState, LandingGear* gear)
{
switch (*currentState) {
case GEAR_UP:
if (!gear->squatSwitchOpen) {
gear->directionValveUp = false;
*currentState = GEAR_TRANSIT;
}
break;
case GEAR_TRANSIT:
if (gear->limitSwitchOpen) {
*currentState = GEAR_DOWN;
}
break;
case GEAR_DOWN:
if (gear->squatSwitchOpen) {
gear->directionValveUp = true;
*currentState = GEAR_TRANSIT;
}
break;
}
}
int main()
{
// Initialize landing gear components
GearState currentState = GEAR_UP;
LandingGear gear = {
.limitSwitchOpen = false,
.squatSwitchOpen = false,
.pressureOnNoseGear = false,
.directionValveUp = false,
};
while (1) {
// Simulate reading the actual hardware states
// For the simulation, we will set some dummy values
gear.limitSwitchOpen = true; // Assume the limit switch is open (gear down)
gear.squatSwitchOpen = true; // Assume the squat switch is open (airborne)
gear.pressureOnNoseGear = true; // Assume there's pressure on the nose gear
// Check if squat switch is open for 4 seconds before raising gears
if (currentState == GEAR_UP && gear.squatSwitchOpen && checkSquatSwitch()) {
gear.directionValveUp = true;
currentState = GEAR_TRANSIT;
}
// Handle gear transitions
transitionGearState(¤tState, &gear);
// Update lights based on gear state
if (gear.directionValveUp) {
// Set lights to indicate gears are raising
printf("Lights: Raising gear\n");
} else {
// Set lights to indicate gears are lowering
printf("Lights: Lowering gear\n");
}
// Control hydraulic pump based on gear state
// ...
// Simulate a delay for the loop (optional)
Sleep(100); // Sleep for 100 milliseconds (Windows) or use usleep(100000) for Unix-based systems
}
return 0;
}