Project 2 - Implement the Code for controlling the retraction and extension of Airplane’s landing gear
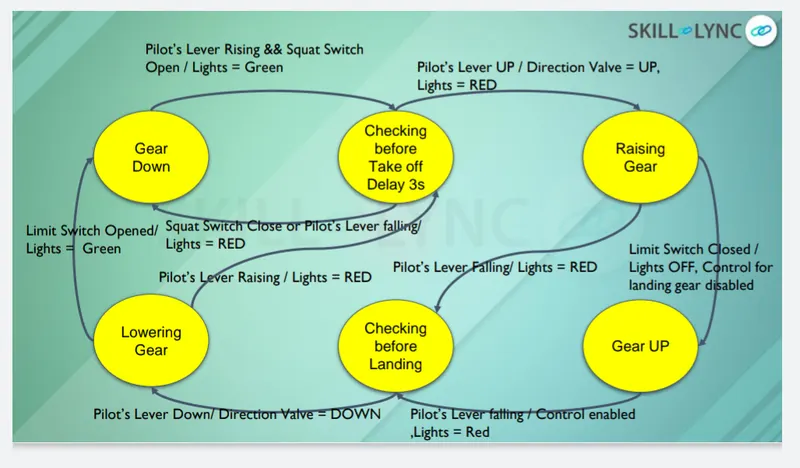
AIM :- Write a C for program controlling the retraction and extension of Airplane landing gear and this can be implement using finite state machine concept.
Theory :-
Actually an airplane has 3 gears for landing :
- Nose Gear
- Left Gear
- Right Gear
There is a hydraulic pump which is exerting pressure to the ears to bring it down or pull it up and that pump is electrically driven.
Limit switches:
Every leg of the gear has one limit switch .Nose gear has one extra Squat Switch to determine whether the airplane is in ground or not.
State Diagram :-
C CODE :-
#include  // Pre Processor Directives

typedef enum State // Defining enum for various state of aircraft
{
	GR_DWN,
	CHK_BFR_TKFF,
	RSING_GR,
	GR_UP,
	CHK_BFR_LND,
	LWRNG_GR,

}State_Type;

typedef enum Switch  // Defining enum for squat switch status of aircraft
{
	open,
	close

}Switch_Status;

typedef enum Pilot_Lever // Defining enum for pilot lever position
{
	Rising,
	Falling,
	Up,
	Down

}Pilot_Lever_Status;

typedef enum Hydraulic_Mechanism
{
	//Working = UP,
	//Malfunctioning = DOWN
	Malfunctioning,
	Working
}Hydraulic_Mechanism_Status;

// Creating variables of enums
static volatile Switch_Status squat_switch;
static volatile Switch_Status limit_switch;
static volatile Pilot_Lever_Status pilot_lever;
static volatile Hydraulic_Mechanism_Status hydraulic_mechanism;
State_Type current_state;

typedef struct // defining structure that contains pointer of char data type
{
	char *current_state_indication;
	char *light_status;
	char *direction_valve_status;
	char *hydraulic_pump_control_status;
	char *gas_pressurized_spring_status[2];

}State_Table;

// creating array of structures for state table
static State_Table State_Machine[6]={
		{"Gear Down","Green","Down","Enabled",{NULL,NULL}},
		{"Checking Before Take Off","Green","Down","Enabled",{NULL,NULL}},
		{"Raising Gear","Red","Up","Enabled",{"Disabled","Enabled"}},
		{"Gear Up","Off","Null","Disabled",{NULL,NULL}},
		{"Checking Before Landing","Red","Down","Enabled",{NULL,NULL}},
		{"Lowering Gear","Green","Down","Enabled",{"Disabled","Enabled"}}
};

// creating functions for the state of aircraft
void Gear_Down(void)
{
	printf("\n In Gear Down State");
	current_state = GR_DWN;
	printf("\n Enter the pilot lever position and Squat Switch Status :- ");
	fflush(stdout);
	scanf("%d %d",&pilot_lever,&squat_switch);
	if((pilot_lever == Rising) && (squat_switch == open))
	{
		current_state = CHK_BFR_TKFF;
		printf("\n current state: %s \n", State_Machine[current_state].current_state_indication);
		printf("\n Light Status:%s \n",State_Machine[current_state].light_status);
	}
	else
	{
		Gear_Down();
	}
}

void Checking_Before_Takeoff()
{
	current_state = CHK_BFR_TKFF;
	printf("\n Enter the pilots Lever Position and Squat Switch Status and Hydraulic Mechanism Status: ");
	fflush(stdout);
	scanf("%d %d %d",&pilot_lever,&squat_switch,&hydraulic_mechanism);
	printf("\n Wait for 3 seconds \n");
	if(pilot_lever == Falling || squat_switch == close)
	{
		Gear_Down();
	}
	else if (pilot_lever == Up && squat_switch == open && hydraulic_mechanism == Working)
	{
		current_state = RSING_GR;
		printf("\n current_state: %s \n", State_Machine[current_state].current_state_indication);
		printf("\n Light Status:%s \n",State_Machine[current_state].light_status);
		printf("Direction Valve Status:%s \n", State_Machine[current_state].direction_valve_status);
	}
	else if(pilot_lever == Up && squat_switch == open && hydraulic_mechanism == Malfunctioning)
	{
		current_state = RSING_GR;
		printf("\n current_state: %s \n", State_Machine[current_state].current_state_indication);
		printf("\n Light Status:%s \n",State_Machine[current_state].light_status);
		printf("Direction Valve Status:%s \n", State_Machine[current_state].direction_valve_status);
		printf("Gas Pressurized Spring System Status:%s \n", State_Machine[current_state].gas_pressurized_spring_status[hydraulic_mechanism]);
	}
}

void Raising_Gear()
{
	current_state = RSING_GR;
	printf("\n Enter the limit switch status and pilot_lever Status: ");
	fflush(stdout);
	scanf("%d %d", &limit_switch, &pilot_lever);
	printf("\n Wait for 1 seconds \n");
	if(pilot_lever == Falling && limit_switch == open)
	{
		current_state = CHK_BFR_LND;
		printf("\n current_state: %s \n", State_Machine[current_state].current_state_indication);
		printf("\n Light Status:%s \n",State_Machine[current_state].light_status);
		printf("Hydraulic Control for landing Gear Status:%s \n", State_Machine[current_state].hydraulic_pump_control_status);
	}
	else if(limit_switch == close && pilot_lever == Up)
	{
		current_state = GR_UP;
		printf("\n current_state: %s \n", State_Machine[current_state].current_state_indication);
		printf("\n Light Status:%s \n",State_Machine[current_state].light_status);
		printf("Hydraulic Control for landing Gear Status:%s \n", State_Machine[current_state].hydraulic_pump_control_status);
	}
	else
	{
		Raising_Gear();
	}
}

void Gear_up()
{
	current_state = GR_UP;
	printf("\n Enter the pilots Lever Position: ");
	fflush(stdout);
	scanf("%d",&pilot_lever);
	if(pilot_lever == Falling)
	{
		current_state = CHK_BFR_LND;
		printf("\n current_state: %s \n", State_Machine[current_state].current_state_indication);
		printf("\n Light Status:%s \n",State_Machine[current_state].light_status);
		printf("Hydraulic Control for landing Gear Status:%s \n", State_Machine[current_state].hydraulic_pump_control_status);
	}
	else
	{
		Gear_up();
	}
}

void Checking_Before_Landing()
{
	current_state = CHK_BFR_LND;
	printf("\n Enter the pilots Lever Position and Hydraulic Mechanism Status: ");
	fflush(stdout);
	scanf("%d %d",&pilot_lever,&hydraulic_mechanism);
	if(pilot_lever == Down && hydraulic_mechanism == Working)
	{
		current_state = LWRNG_GR;
		printf("\n current_state: %s \n", State_Machine[current_state].current_state_indication);
		printf("\n Light Status:%s \n",State_Machine[current_state].light_status);
		printf("Direction Valve Status:%s \n", State_Machine[current_state].direction_valve_status);
	}
	else if(pilot_lever == Down && hydraulic_mechanism == Malfunctioning)
	{
		current_state = LWRNG_GR;
		printf("\n current_state: %s \n", State_Machine[current_state].current_state_indication);
		printf("\n Light Status:%s \n",State_Machine[current_state].light_status);
		printf("Direction Valve Status:%s \n", State_Machine[current_state].direction_valve_status);
		printf("Gas Pressurized Spring System Status:%s \n", State_Machine[current_state].gas_pressurized_spring_status[hydraulic_mechanism]);
	}
	if(pilot_lever == (Up || Rising || Falling))
	{
		Checking_Before_Landing();
	}
}

void Lowering_Gear()
{
	current_state = LWRNG_GR;
	printf("\n Enter the pilots Lever Position and Limit Switch Status: ");
	fflush(stdout);
	scanf("%d %d", &pilot_lever, &limit_switch);
	if(pilot_lever == Rising)
	{
		current_state = CHK_BFR_TKFF;
		printf("\n current_state: %s \n", State_Machine[current_state].current_state_indication);
		printf("\n Light Status:%s \n",State_Machine[current_state].light_status);
	}
	if (pilot_lever == Down && limit_switch == open)
	{
		current_state = GR_DWN;
		printf("\n current_state: %s \n", State_Machine[current_state].current_state_indication);
		printf("\n Light Status:%s \n",State_Machine[current_state].light_status);
		printf("Hydraulic Control for landing Gear Status:%s \n", State_Machine[current_state].hydraulic_pump_control_status);
	}
	if(limit_switch == close)
	{
		Lowering_Gear();
	}
}

// creating function for initial state of the aircraft
void Init_State_Machine()
{
	current_state = GR_DWN; // by default we are initially considering gear down state
	printf("State Machine is Initialized and Program is in Gear Down state & Light Status is: Green\n");
}

int main()
{
	Init_State_Machine(); // calling initial state function
	while(1)
	{
		switch(current_state) // creating switch case to enter in a particular state
		{
		case 0: Gear_Down();
		break;
		case 1:Checking_Before_Takeoff();
		break;
		case 2:Raising_Gear();
		break;
		case 3: Gear_up ();
		break;
		case 4:Checking_Before_Landing();
		break;
		case 5: Lowering_Gear();
		break;
		default:break;
		}
	}
}
OUTPUT :-
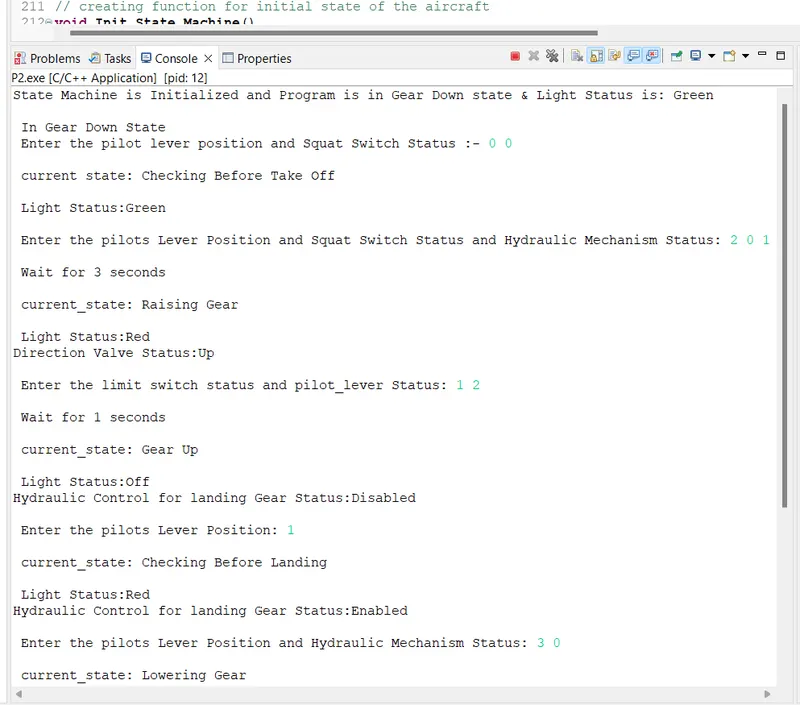
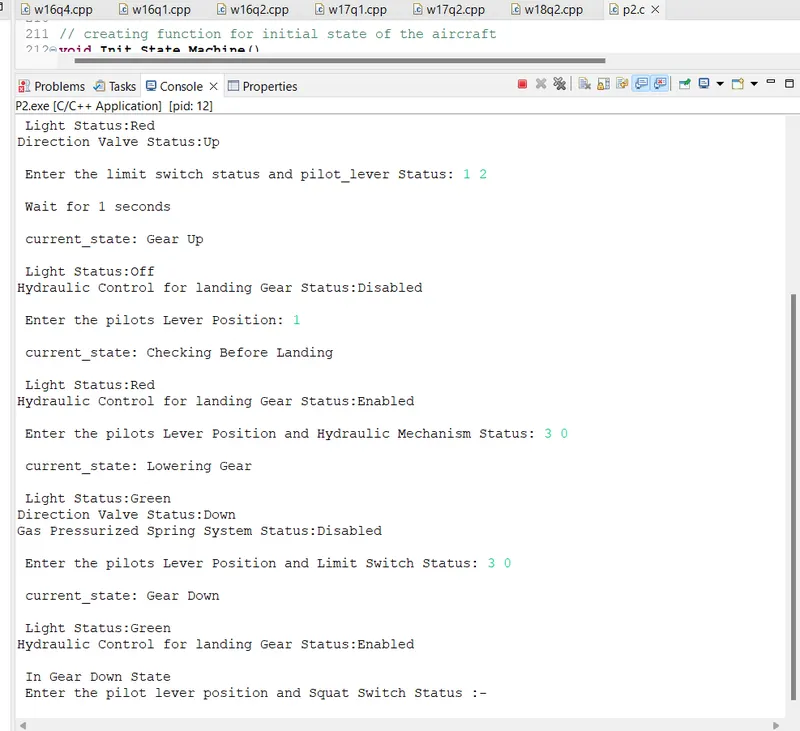
- Outputs using highlighters and underlines
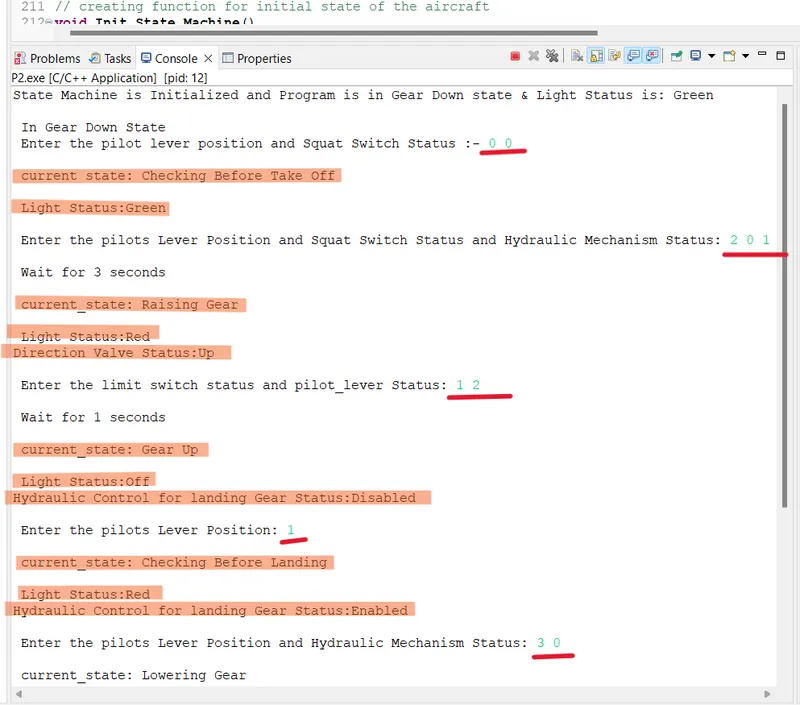
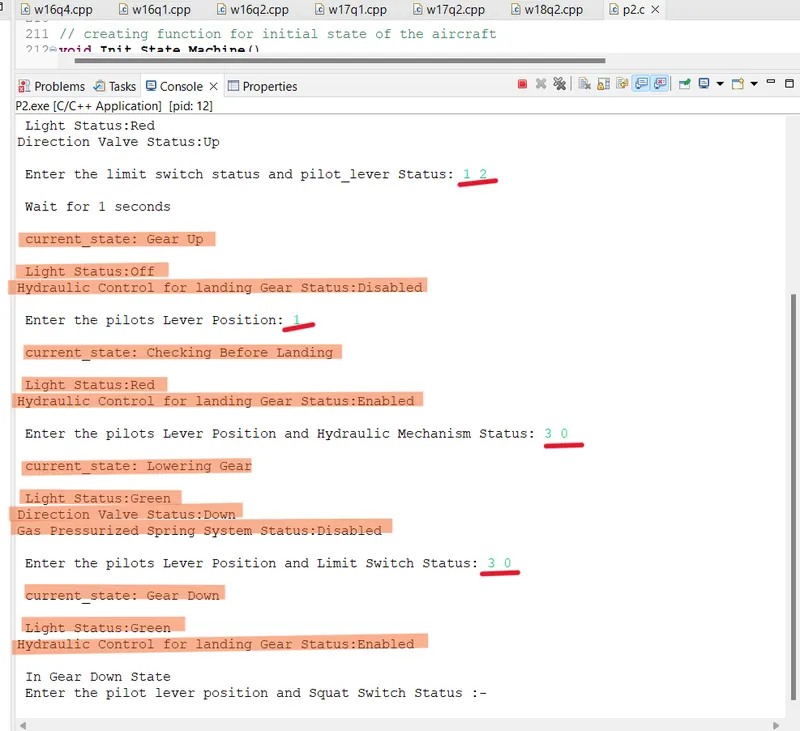
CONCLUSION :- We had created a C program using finite state machine(FSM) concept that works successfully for program controlling the retraction and extension of Airplane landing gear