Project 2 Adaptive Cruise Control
Adaptive Cruise Control (ACC)
To Develop Adaptive Cruise Control feature as per the requirement document using MATLAB Simulink.
Requirements:
Requirement 1– Lead Vehicle
Requirement 2 – Drive Vehicle
Requirement 3 – Adaptive Cruise Control Algorithm
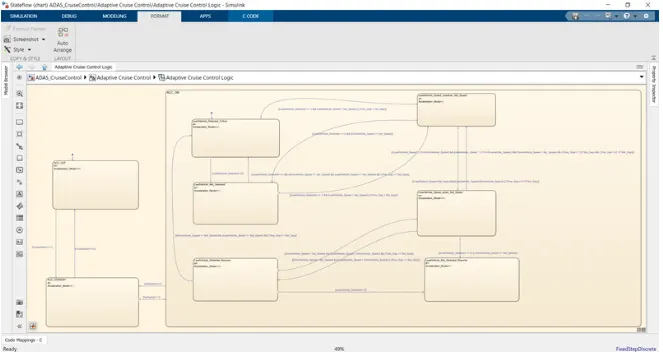
- Requirement 3a – ACC OFF MODE state logic:
- Requirement 3b – ACC STANDBY MODE state logic:
- Requirement 3c – ACC ON MODE state logic:
1. Requirement 3c (i) – LeadVehicle_Detected_Follow (ACC ON MODE):
2. Requirement 3c (ii) – LeadVehicle_Not_Detected (ACC ON MODE):
3. Requirement 3c (iii) – LeadVehicle_Detected_Resume (ACC ON MODE):
4. Requirement 3c (iv) - LeadVehicle_Not_Detected_Resume (ACC ON MODE):
5. Requirement 3c (v) - LeadVehicle_Speed_lessthan_Set_Speed (ACC ON MODE):
6. Requirement 3c (vi) - LeadVehicle_Speed_equal_Set_Speed (ACC ON MODE):
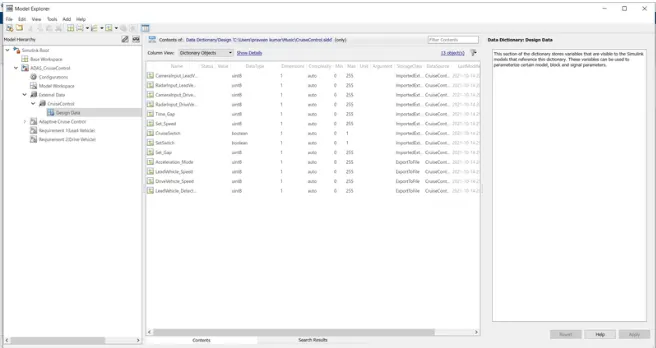
SLDD Requirements:
|
Signal / Calibration Name |
Signal Type |
Data Type |
Dimension |
Min |
Max |
Initial Value |
Units |
|
CameraInput_LeadVehicle |
Input |
Uint8 |
1 |
0 |
255 |
- |
- |
|
RadarInput_LeadVehicle |
Input |
Uint8 |
1 |
0 |
255 |
- |
- |
|
CameraInput_DriveVehicle |
Input |
Uint8 |
1 |
0 |
255 |
- |
- |
|
RadarInput_DriveVehicle |
Input |
Uint8 |
1 |
0 |
255 |
- |
- |
|
Time_Gap |
Input |
Uint8 |
1 |
0 |
255 |
- |
- |
|
Set_Speed |
Input |
Uint8 |
1 |
0 |
255 |
- |
- |
|
Set_Gap |
Input |
Uint8 |
1 |
0 |
255 |
- |
- |
|
CruiseSwitch |
Input |
Boolean |
1 |
0 |
1 |
- |
- |
|
SetSwitch |
Input |
Boolean |
1 |
0 |
1 |
- |
- |
|
Acceleration_Mode |
Output |
Uint8 |
1 |
0 |
255 |
- |
- |
|
LeadVehicle_Speed |
Output |
Uint8 |
1 |
0 |
255 |
- |
- |
|
DriveVehicle_Speed |
Output |
Uint8 |
1 |
0 |
255 |
- |
- |
|
LeadVehicle_Detected |
Output |
Uint8 |
1 |
0 |
255 |
- |
- |
Overall Model:
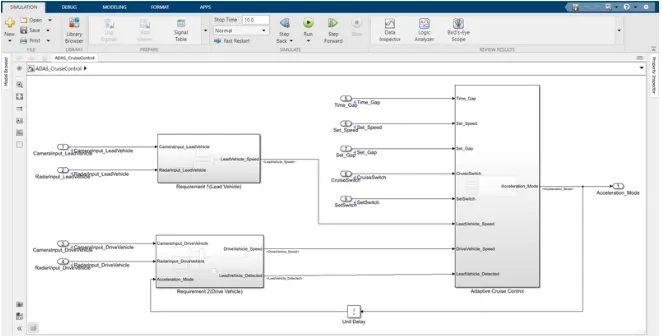
Requirement 1:
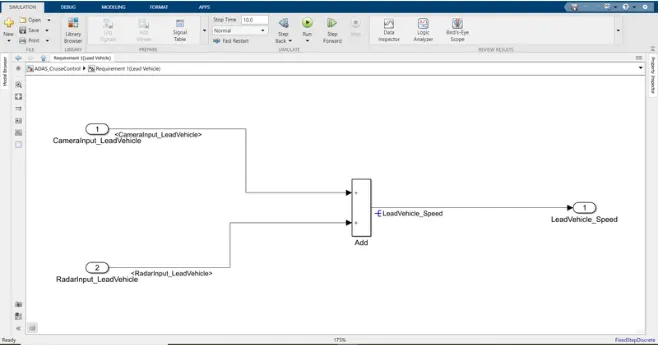
Requirement 2:
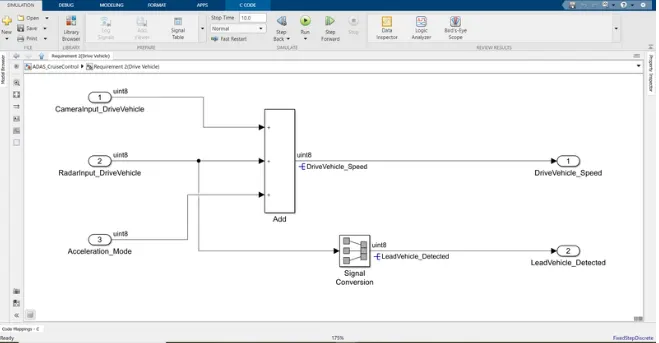
Requirement 3:
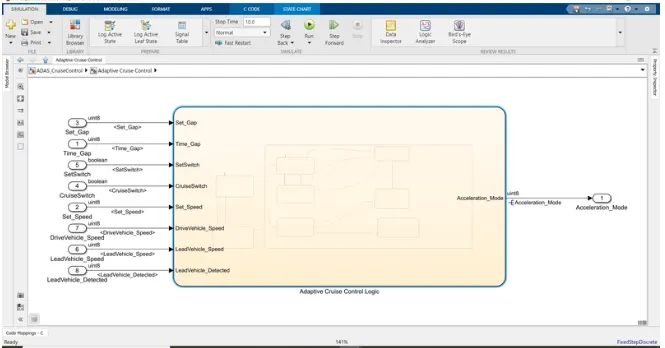
State flow logic(Adaptive Cruise Control Logic):
SLDD file creation:
Results:
After compiling the model we are getting nil errors on model creation justifies our logic on modelling for requirements are correct.