AIM:
The main goal of this project is to understand the functionality of a P1 hybrid and be able to model it.
Task:
The task of this project is to quantify the improvement in fuel economy numbers for the hybrid vehicle (kmpl), compared to the conventional vehicle, on the urban cycle (UDDS) and highway cycle (HWFET). Also, to analyze and understand the vehicle operating points in terms of engine and motor speed, torque, transmission speeds, pedal positions, gear, distance traveled, battery voltage, current, SoC etc.
OBJECTIVES FOR THE PROJECT:
a. Tabulate the fuel economy numbers (kmpl) for UDDS and HWFET cycle. Compare these numbers with the baseline numbers for conventional vehicle model from Project 1.
b. Plot the time trace for engine, transmission input, transmission output and wheel speed on one plot.
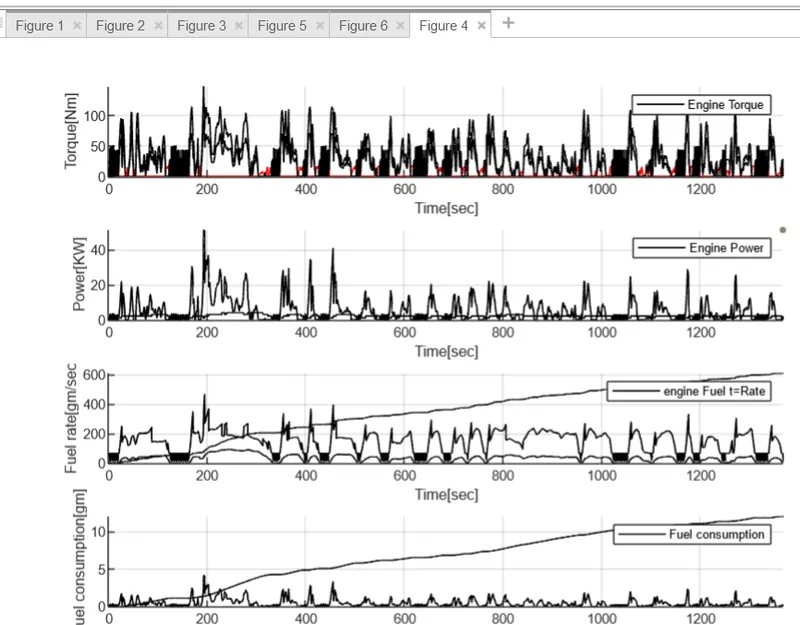
c. Plot engine torque, engine power, fuel rate and fuel consumption using subplots.
d. Plot accelerator and brake pedal, gear command, vehicle desired and actual speed, vehicle distance using subplots.
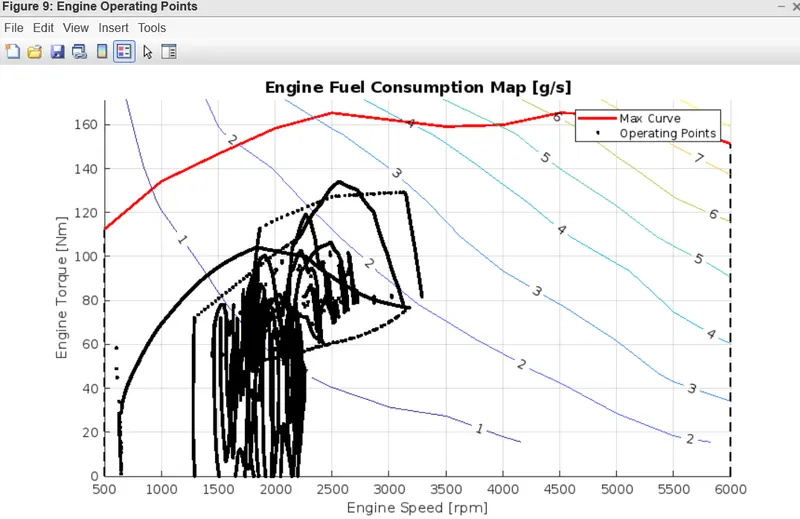
e. Plot the engine operating points on the engine fuel map.
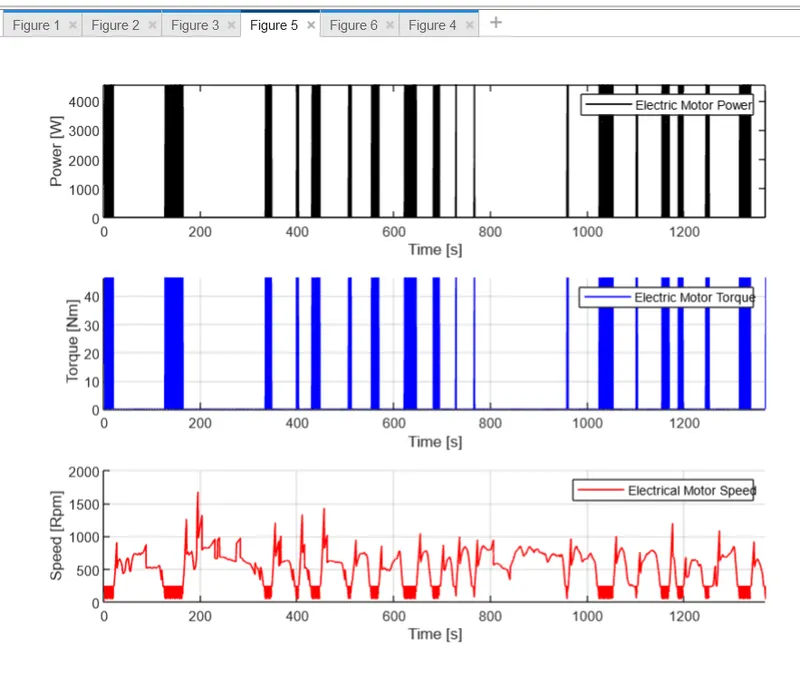
f. Plot motor speed, torque, motor input power using subplots.
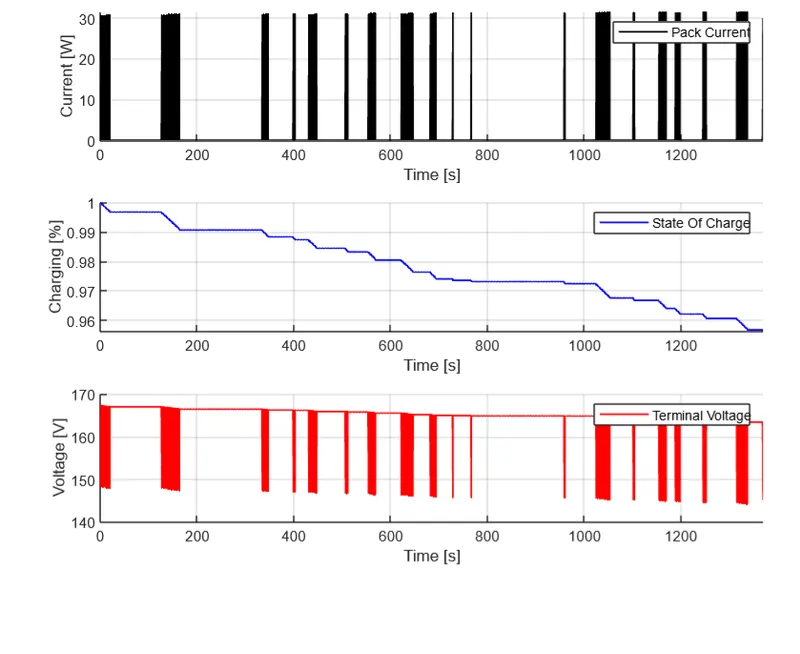
g. Plot pack voltage, current and SoC using subplots.
h. Plot the motor operating points on the motor input power map, with the motor max motoring and generating torque curves.
i. Write down appropriate brief comments on each of these plots, describing the vehicle behavior throughout the drive cycle.
j. Generate the plots for both drive cycles
P1 hybrid vehicle:
The P1 architecture, with the electric machine connected directly to the crankshaft, is the solution adopted by Honda on their first generation Integrated Motor Assist (IMA) technology. The electric motor functions as a generator, during vehicle deceleration, as an engine starter, and as a motor (to assist the engine) during vehicle accelerations. One of the biggest advantage of this solution is that the electric motor can provide higher torque than the BiSG, since there is no belt limitation (due to slip). However, since there is no speed / torque ratio between the electric machine and crankshaft, the torque requirements on the electric motor can be quite demanding.
Process for the project:
1) Load the Project2 folder as the Current Folder in Matlab.
2) Run the “Project2_InitFile.m” Matlab script.
3) Copy the Conventional vehicle Simulink model created for Project 1 in this folder. Figure 1: P1 Hybrid ArchitectureHybrid Drives Development
4) Modify this model into a hybrid vehicle model. The lecture presentations can be used as reference. Battery and Supervisory controller models developed in the assignments can be reused.
5) Add additional ‘To Workspace’ blocks for transferring the desired Simulink vehicle data into the Matlab workspace.
6) Simulate the hybrid model on the desired drive cycles.
After loading the Project2 folder as the Current folder in Matlab, run the Project2_InitFile.m” Matlab script .
The matlab script is
%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%
%% Skill-Lync -> Hybrid Drives Development
% Project 2- Hybrid Vehicle Model
% By - Ullekh Gambhira
% Description:
%% Initialization File
% Initialization file for loading the variables for the Conventional vehicle simulation model
%% Vehicle Parameters
M = 1500; % Vehicle weight [kg]
Cr = 0.015; % Rolling resistance coefficient
Rw = 0.35; % Rolling radius [m]
Cd = 0.33; % Drag coefficient
Af = 2; % Frontal area [m2]
rhoa = 1.225; % Air density [kg/m3]
Vwind = 0; % Wind velocity [kmph]
g = 9.81; % Gravitational acceleration [m/s2]
theta = 0; % Slope [deg]
myu_road_tire = 1; % Coefficient of friction between tire - road interface
load('ESS_NiMH6.mat');
%% Powertrain Parameters
FDR = 3.73; % Final Drive Ratio / Diff Ratio
DiffEff = 0.99; % Differential efficiency (assumed independent of operating conditions)
NumGear = 4; % Number of gears in transmission
TransGear = [1:NumGear]; % Transmission Gears
TransRatio = [3.06, 1.62, 1, 0.7]; % Corresponding Transmission ratios
TransEff = 0.90; % Transmission efficiency (assumed independent of operating conditions)
TC_SR = [0, .5, .6, .7, .8, .87, .92, .94, .96, .97, 1]; % Torque Converter Speed Ratio (Matlab default) -> TurbSpd/PumpSpd
TC_TR = [2.232, 1.5462, 1.4058, 1.2746, 1.1528, 1.0732, 1.0192, 1, 1, 1, 1]; % Torque Converter Torque Ratio (Matlab default) -> TurbTrq/PumpTrq
TC_Cf = 1e-4 * [.72558, .66322, .63463, .59042, .51331, .4144, .29287, .22444, .12186, .04386, 0]; % Torque Converter Capacity Factor (Matlab default) -> PumpTrq/PumpSpd^2 [Nm/rpm^2]
load Engine_data_1_9L_Saturn_95kW
load Trans_Shift_map
load EM_Honda_Insight_10kW
load ESS_NiMH6
ESS_init_soc = 0.8;
ESS_soc_max = 0.9;
ESS_soc_min = 0.6;
%% Driver Parameters
Kp = 10; % P gain for driver PI model
Ki = 1; % I gain for driver PI model
Drive_Cycle_Select = 1; % Drive cycle selection
% Drive cycle values in m/s
if Drive_Cycle_Select == 1
load UDDS;
elseif Drive_Cycle_Select == 2
load HWFET;
elseif Drive_Cycle_Select == 3
load FTP;
elseif Drive_Cycle_Select == 4
load US06;
elseif Drive_Cycle_Select == 5
load NEDC;
elseif Drive_Cycle_Select == 6
load WLTP;
end
time_end = cyc_time(end);
vel_end = cyc_vel(end);
After running this we need to create the simulink model for this project
SIMULINK MODEL:
BASIC VEHICLE MODEL:
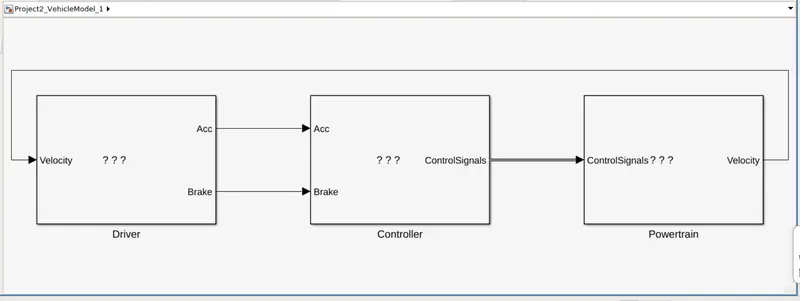
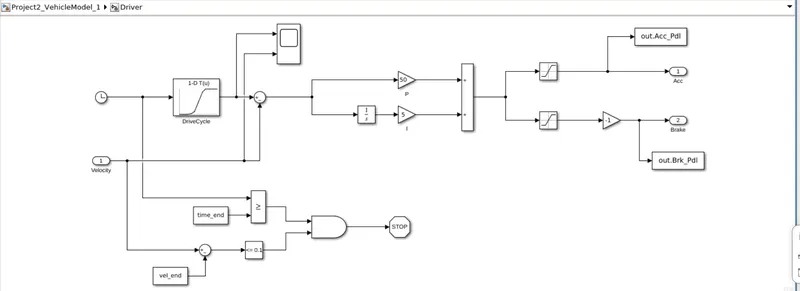
1.DRIVER:
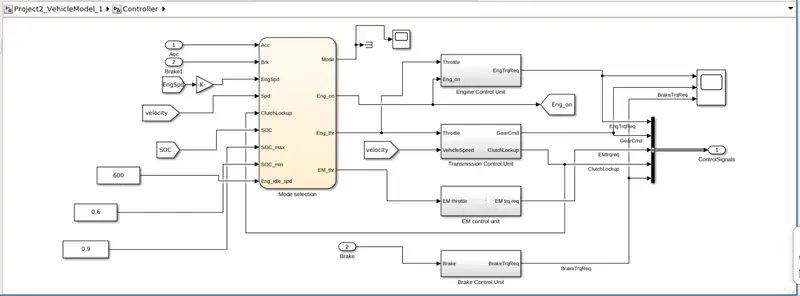
2.CONTROLLER:
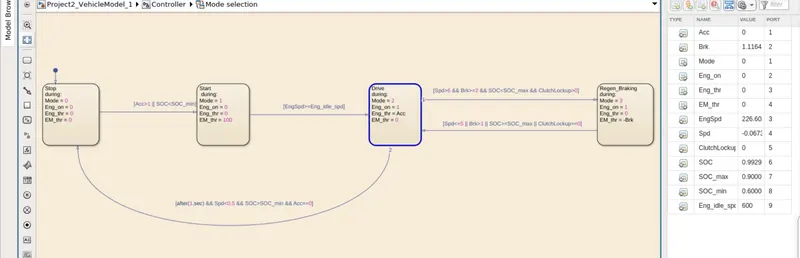
2A)MODE SELECTION:
2B) ENGINE CONTROL UNIT:
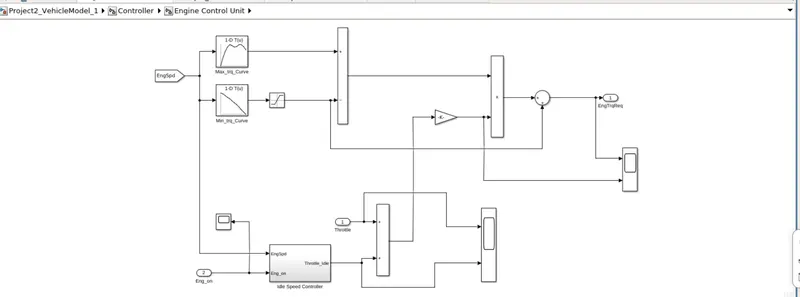
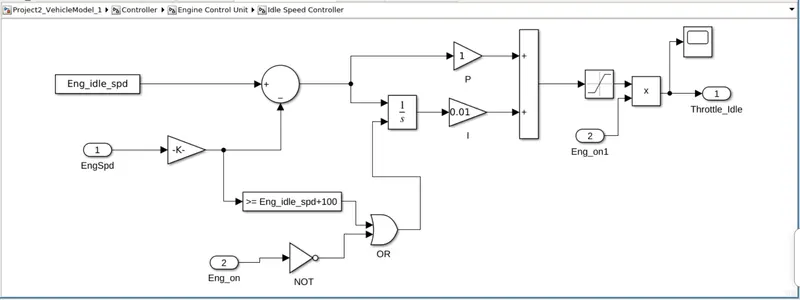
2B.a) IDLE SPEED CONTROLLER:
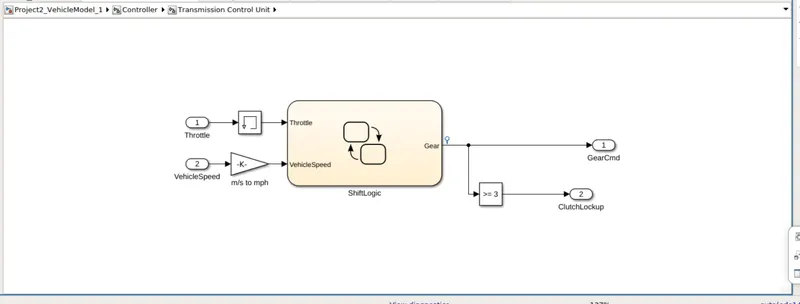
2C) TRANSMISSION CONTOL UNIT:
2C.a) SHIFT LOGIC OF TCU:
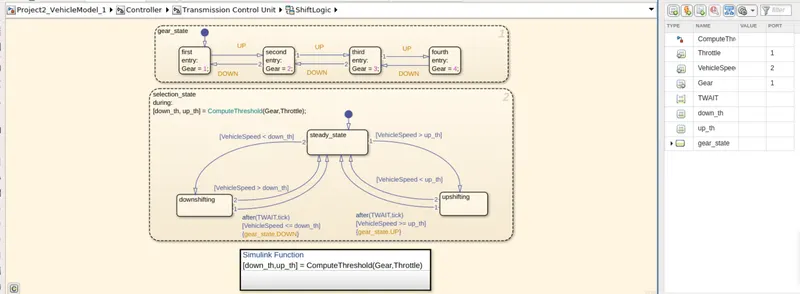
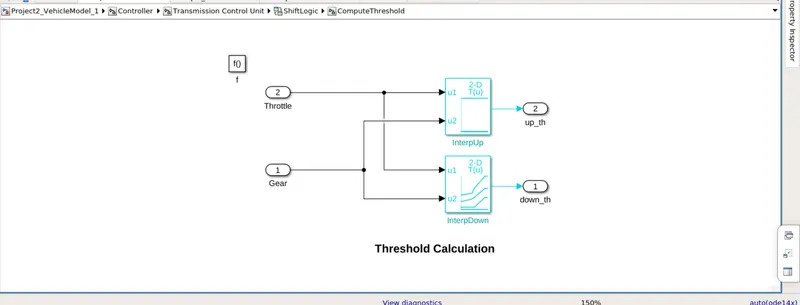
2C.a.a) COMPUTING THRESHOLD VALUE:
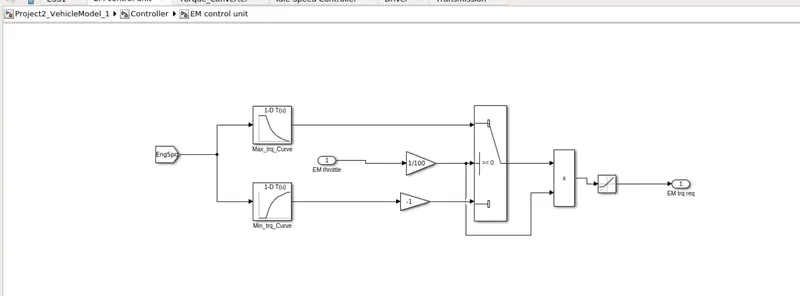
2D) EM CONTROL UNIT:
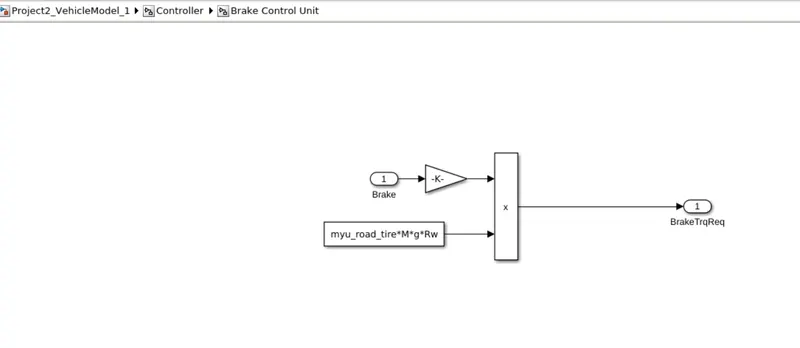
2E) BRAKE CONTROL UNIT:
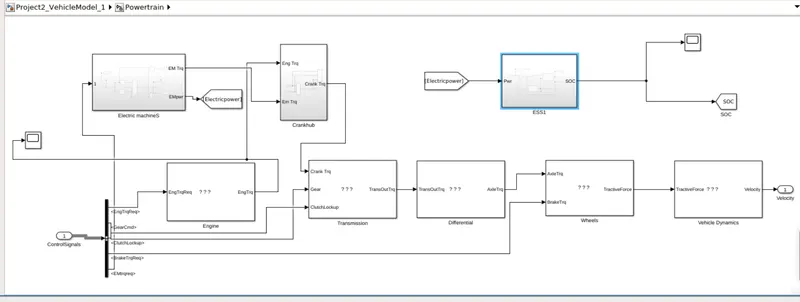
3) POWER TRAIN :
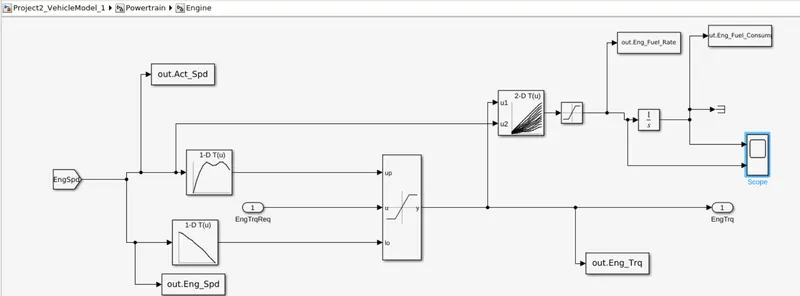
3.A) ENGINE :
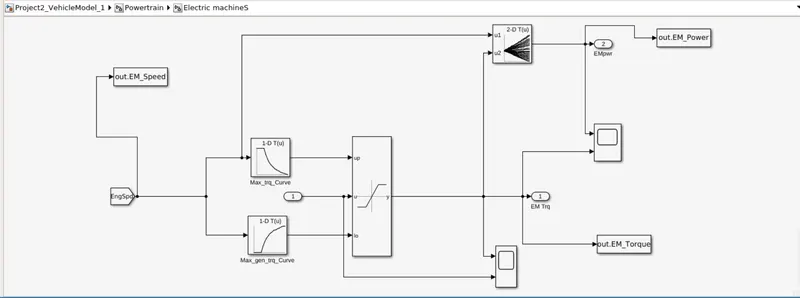
3.B) ELECTRIC MACHINE:
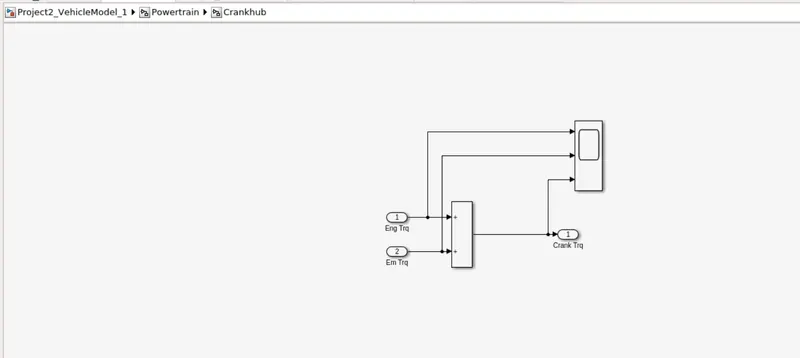
3.C) CRANK HUB :
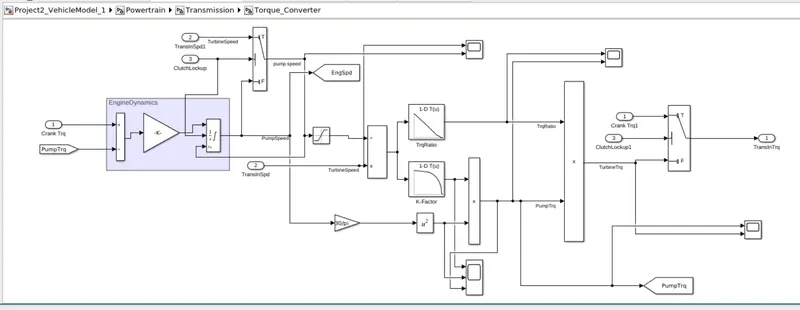
3.D) TRANSMISSION:
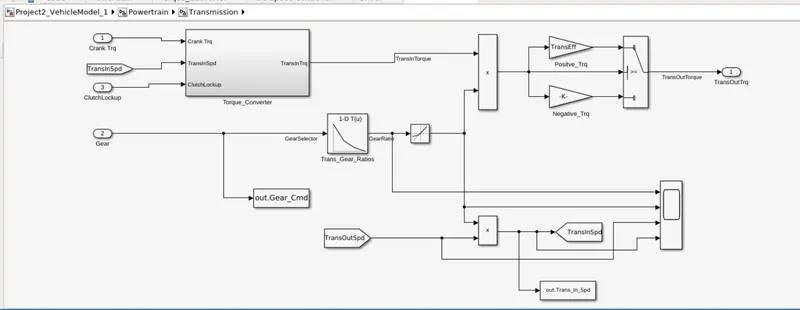
3.D.a)TORQUE CONVERTER :
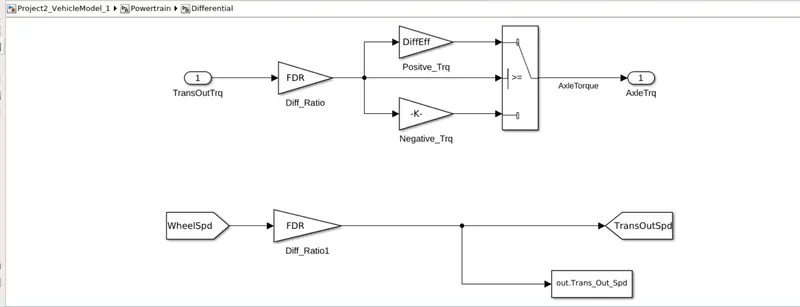
3.E) DIFFERENTIAL:
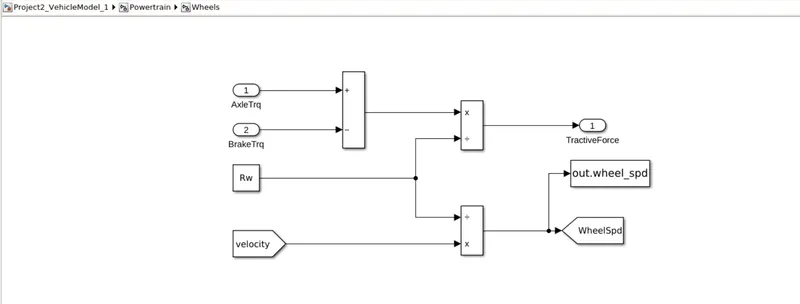
3.F) WHEELS :
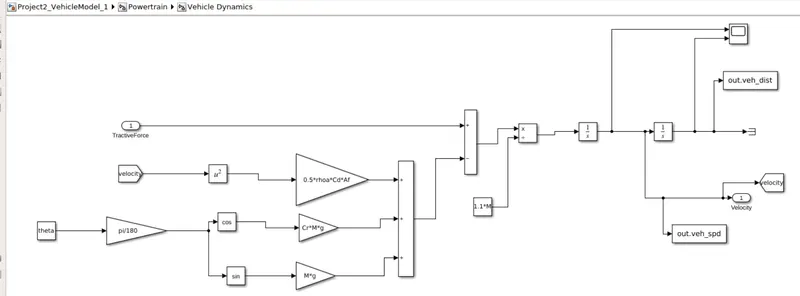
3.G) VEHICLE DYNAMICS :
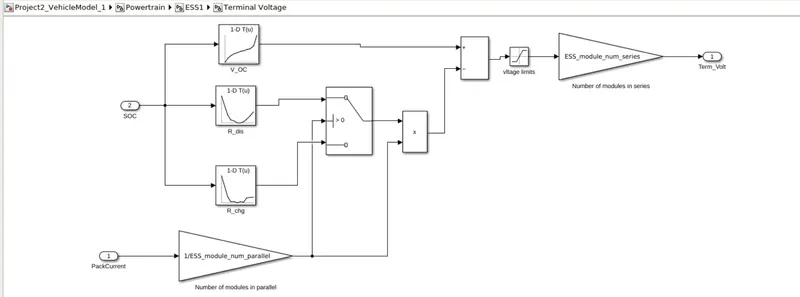
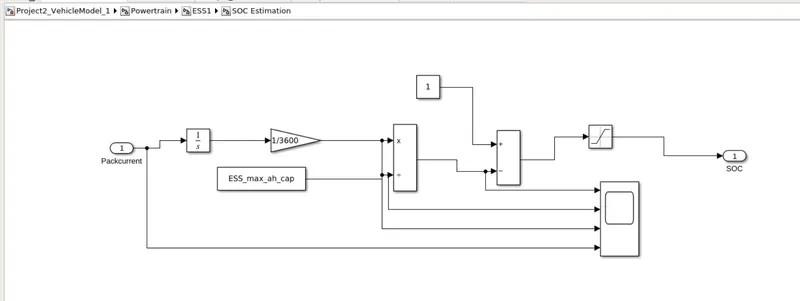
4. SIMULINK MODEL OF BATTERY :
4.A) ESS:
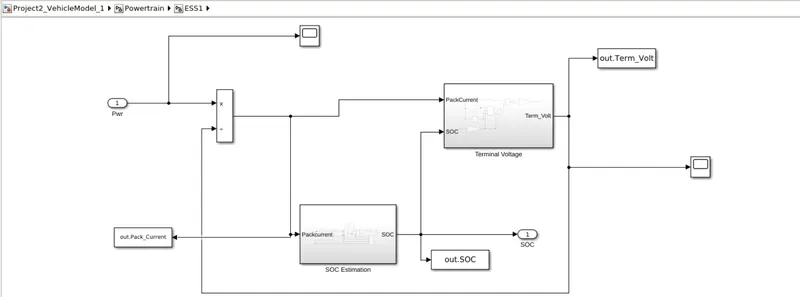
4.A.a) TERMINAL VOLTAGE :
4.A.b) STATE OF CHARGE ESTIMATION :
Now, we need to create processing file and necessary plots to achieve desired results.
%% Renaming variables
Time = out.tout;
Acc_Pdl = out.Acc_Pdl; % Accelerator pedal [%]
Brk_Pdl = out.Brk_Pdl; % Brake pedal [%]
Gear_Cmd = out.Gear_Cmd; % Transmission gear
Trans_In_Spd = out.Trans_In_Spd*30/pi; % Transmission input speed [rpm]
Trans_Out_Spd = out.Trans_Out_Spd*30/pi;% Transmission output speed [rpm]
Eng_Trq = out.Eng_Trq; % Engine brake torque [Nm]
Eng_Spd = out.Eng_Spd*30/pi; % Engine speed [rpm]
Eng_Fuel_Consump = out.Eng_Fuel_Consump; % Engine fuel consumption [g]
Veh_Dist = out.veh_dist/1000; % Distance traveled by vehicle [km]
Veh_Spd = out.veh_spd*18/5; % Vehicle speed [kmph]
Act_Spd = out.Act_Spd
EM_Speed = out.EM_Speed*18/5; % Electric Motor Speed
EM_Power = out.EM_Power; % Electric Motor Power
EM_Torque = out.EM_Torque; % Electric Motor Torque
Term_Volt = out.Term_Volt; % Terminal Voltage of battery
SOC = out.SOC; % State Of Charge
Pack_Current = out.Pack_Current; %Pack current of battery
wheel_spd = out.wheel_spd;
Eng_Fuel_Rate = out.Eng_Fuel_Rate;
%% Data Analysis
Eng_Pwr = Eng_Spd.*pi/30.*Eng_Trq/1000; % Engine brake power [kW]
rho_petrol = 0.7197; % Density of petrol [kg/L]
kmpl = Veh_Dist(end)/(Eng_Fuel_Consump(end)/1000/rho_petrol); % Fuel economy [kmpl]
%% plotting accelerator and brake pedal, gear command, vehicle desired and actual speed,
%% vehicle distance using subplots.
figure()
subplot(4,1,1)
hold on
grid on
plot(Time, Acc_Pdl, 'linewidth', 1, 'Color', 'black');
plot(Time, Brk_Pdl, 'linewidth', 1, 'Color', 'red');
ylabel('Pedal [%]')
xlim([0, Time(end)]);
legend('Accel','Brake');
subplot(4,1,2)
hold on
grid on
plot(Time, Gear_Cmd, 'linewidth', 1, 'Color', 'black');
xlim([0, Time(end)]);
xlabel('Time [s]');
ylabel('Gear');
subplot(4,1,3)
hold on
grid on
plot(Time, Act_Spd, 'linewidth', 1, 'Color', 'black');
plot(Time, Veh_Spd, 'linewidth', 1, 'Color', 'black');
xlim([0, Time(end)]);
xlabel('Time [s]');
ylabel('Speed');
legend('Actual speed','Vehcle speed')
subplot(4,1,4)
hold on
grid on
plot(Time, Veh_Dist, 'linewidth', 1, 'Color', 'black');
xlim([0, Time(end)]);
xlabel('Time [s]');
ylabel('Gear');
legend('Vehicle Distance')
%% Plotting vehicle characteristics time trace
figure(2)
plot(Time, Trans_In_Spd, 'linewidth', 1, 'Color', 'black');
plot(Time, Trans_Out_Spd, 'linewidth', 1, 'Color', 'red');
plot(Time, wheel_spd, 'linewidth', 1, 'Color', 'blue');
ylabel('Speed [rpm]')
xlim([0, Time(end)]);
ylim([0, 6000]);
legend('Trans Input','Trans Output','Wheel speed');
%% Plotting engine operating points on engine fuel map
figure(3)
figure('Name','Engine Operating Points');
hold on
grid on
title('Engine Operating Points','fontsize',12);
p1=plot(Eng_map_spd*30/pi,Eng_max_trq,'linewidth',2,'color','r');
p2=line([Eng_map_spd(end)*30/pi Eng_map_spd(end)*30/pi],[0 Eng_max_trq(end)]);
set(p2,'linewidth',1,'linestyle','--','color','k');
p3=line([Eng_map_spd(1)*30/pi Eng_map_spd(1)*30/pi],[0 Eng_max_trq(1)]);
set(p3,'linewidth',1,'linestyle','--','color','k');
[c,h] = contour(Eng_map_spd'*30/pi,Eng_map_trq,Eng_fuel_map');
clabel(c,h);
xlabel('Engine Speed [rpm]');
ylabel('Engine Torque [Nm]');
title('Engine Fuel Consumption Map [g/s]');
p4 = plot(Eng_Spd,Eng_Trq,'.','color','k');
legend([p1 p4],{'Max Curve','Operating Points'});
axis([Eng_map_spd(1)*30/pi Eng_map_spd(end)*30/pi 0 Eng_map_trq(end)]);
%% Plot engine torque, engine power, fuel rate and fuel consumption using subplots.
figure(4)
subplot(4,1,1)
hold on
grid on
plot(Time,Eng_Trq,'linewidth',1,'color','black')
xlim([0,Time(end)]);
xlabel('Time[sec]');
ylabel('Torque[Nm]');
legend('Engine Torque')
subplot(4,1,2)
hold on
grid on
plot(Time,Eng_Pwr,'linewidth',1,'color','black')
xlim([0,Time(end)]);
xlabel('Time[sec]');
ylabel('Power[KW]');
legend('Engine Power')
subplot(4,1,3)
hold on
grid on
plot(Time,Eng_Fuel_Rate,'linewidth',1,'color','black')
xlim([0,Time(end)]);
xlabel('Time[sec]');
ylabel('Fuel rate[gm/sec');
legend('engine Fuel t=Rate')
subplot(4,1,4)
hold on
grid on
plot(Time,Eng_Fuel_Consump,'linewidth',1,'color','black')
xlim([0,Time(end)]);
xlabel('Time[sec]');
ylabel('Fuel consumption[gm]');
legend('Fuel consumption')
%% Motor Speed, Torque, Motor input power with respect to Time
figure(5)
hold on
grid on
subplot(3,1,1)
plot(Time,EM_Power,'linewidth',1,'color','black')
xlim([0, Time(end)]);
xlabel('Time [s]')
ylabel('Power [W]')
legend('Electric Motor Power ')
subplot(3,1,2)
hold on
grid on
plot(Time,EM_Torque,'linewidth',1,'color','blue')
xlim([0, Time(end)]);
xlabel('Time [s]')
ylabel(' Torque [Nm]')
legend('Electric Motor Torque')
subplot(3,1,3)
hold on
grid on
plot(Time,EM_Speed,'linewidth',1,'color','red')
xlim([0, Time(end)]);
xlabel('Time [s]')
ylabel('Speed [Rpm]')
legend('Electrical Motor Speed')
%% State of Charge, Pack Current, And Terminal Voltage with respect to Time
figure(6)
subplot(3,1,1)
hold on
grid on
plot(Time,Pack_Current,'linewidth',1,'color','black')
xlim([0, Time(end)]);
xlabel('Time [s]')
ylabel('Current [W]')
legend('Pack Current')
subplot(3,1,2)
hold on
grid on
plot(Time,SOC,'linewidth',1,'color','blue')
xlim([0, Time(end)]);
xlabel('Time [s]')
ylabel('Charging [%]')
legend('State Of Charge')
subplot(3,1,3)
hold on
grid on
plot(Time,Term_Volt,'linewidth',1,'color','red')
xlim([0, Time(end)]);
xlabel('Time [s]')
ylabel('Voltage [V]')
legend('Terminal Voltage')
%% Plotting EM Operating Points on motor input power Map
figure('Name','Electric Motor Operating Points');
hold on
grid on
title('Electric Motor Operating Points','fontsize',12);
p1=plot(EM_map_spd*30/pi,EM_max_trq,'linewidth',2,'color','r');
p2=line([EM_map_spd(end)*30/pi EM_map_spd(end)*30/pi],[0 EM_max_trq(end)]);
set(p2,'linewidth',1,'linestyle','--','color','k');
p3=line([EM_map_spd(1)*30/pi EM_map_spd(1)*30/pi],[0 EM_max_trq(1)]);
set(p3,'linewidth',1,'linestyle','--','color','k');
[c,h] = contour(EM_map_spd'*30/pi,EM_map_trq,EM_inpwr_map');
clabel(c,h);
xlabel('Motor Speed [rpm]');
ylabel('Motor Torque [Nm]');
title('Motor Input Power Map [g/s]');
legend([p1 p3],{'Max Curve','Operating Points'});
axis([EM_map_spd(1)*30/pi EM_map_spd(end)*30/pi 0 EM_map_trq(end)]);
After running this processing file we get below plots according to our requirement.
Q1)Tabulate the fuel economy numbers (kmpl) for UDDS and HWFET cycle. Compare these numbers with the baseline numbers for conventional vehicle model from Project 1.
PROJECT 2: FUEL ECONOMY FOR UDDS = 14.034 kmpl
FUEL ECONOMY FOR HWFET = 17.374 kmpl
PROJECT 1: FUEL ECONOMY FOR UDDS = 13 kmpl
FUEL ECONOMY FOR HWFET = 16 kmpl
Q2.Plot engine torque, engine power, fuel rate and fuel consumption using subplots.
UDDS DRIVE CYCLE:
HWFET DRIVE CYCLE:
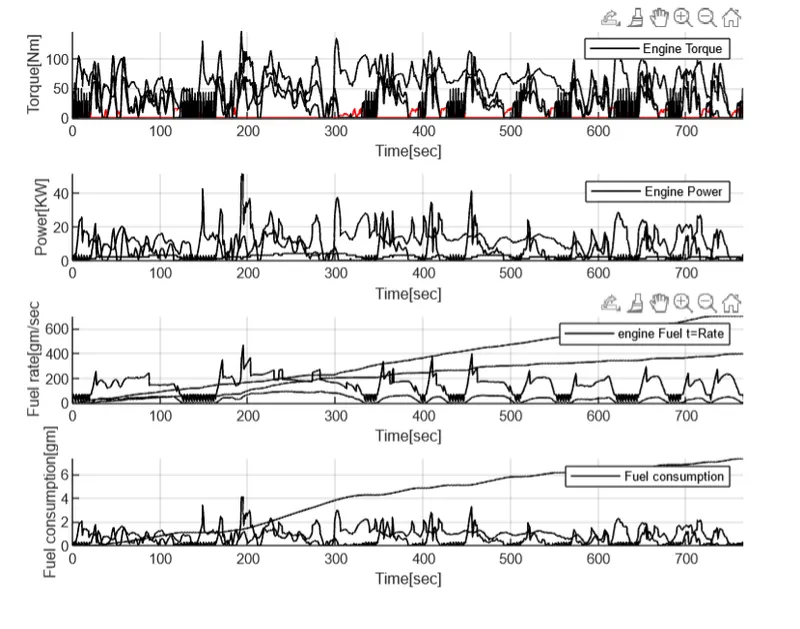
Vehicle cosumed more power in UDDS drive cycle bacause in urban area the vehicle runs on very slow speeds and frequent changing of gears and brake so it required more power compred to HWFET.
Due to smooth dirving in HWFET drive cycle it requires less torque than UDDS drive cycle as seen in the above plots.
Engine is high in UDDS drive cycle compred to HWFET drive cycle because the starting from rest the vehicle requires more torque to overcome the static friction.
The fuel rate is high in HWFET drive cycle compared to UDDS drive cycle because it will be in continues movement so it consumes more fuel.
The fuel economy is high in HWFET because In UDDS cycle speed variation is very frequent and the engine will be in idle postion for more time so UDDS consumes more fuel .
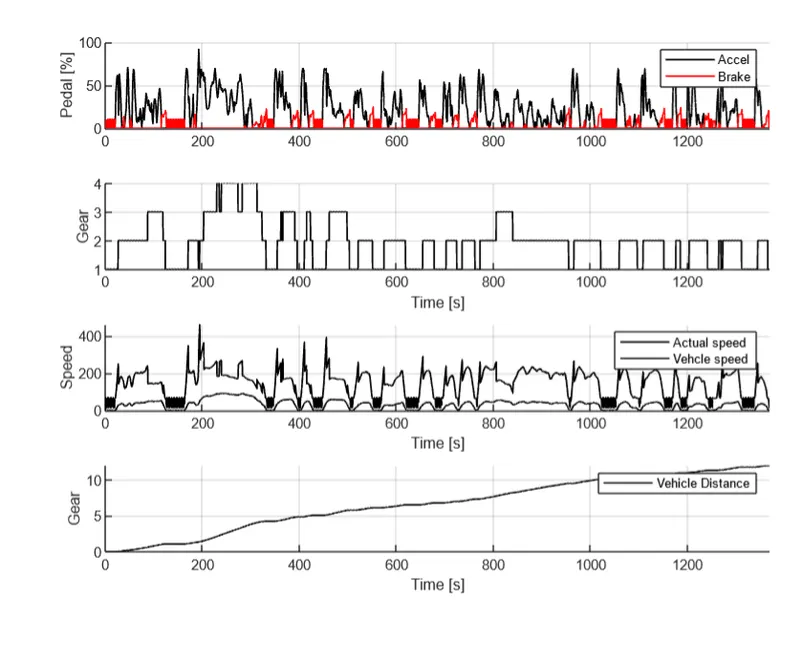
Q3.Plot accelerator and brake pedal, gear command, vehicle desired and actual speed, vehicle distance using subplots.
UDDS DRIVE CYCLE:
HWFET DRIVECYCLE:
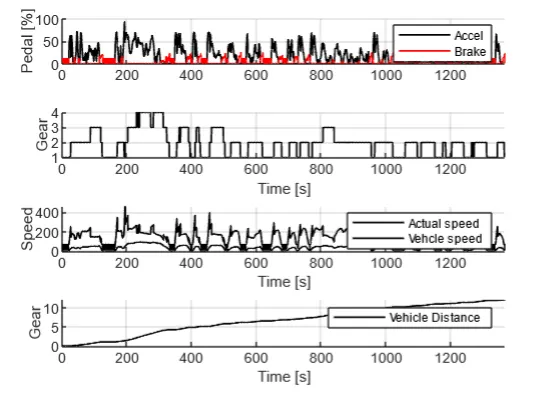
In UDDS drive cycle the acceleratior and brake pedal have more fluctuations because of frequent variation in speeds but in HWFET the brake pedal fluctuations are very less becaue there will be no much variation in speeds.
Normally UDDS cycle mostly runs on 1st and 2nd gears and uses the 3rd and 4th gears are rarely so it does not achieve high speed . but in HWFET cycle the vehicle mostly run on 3rd and 4th gears so it operates at high speeds.
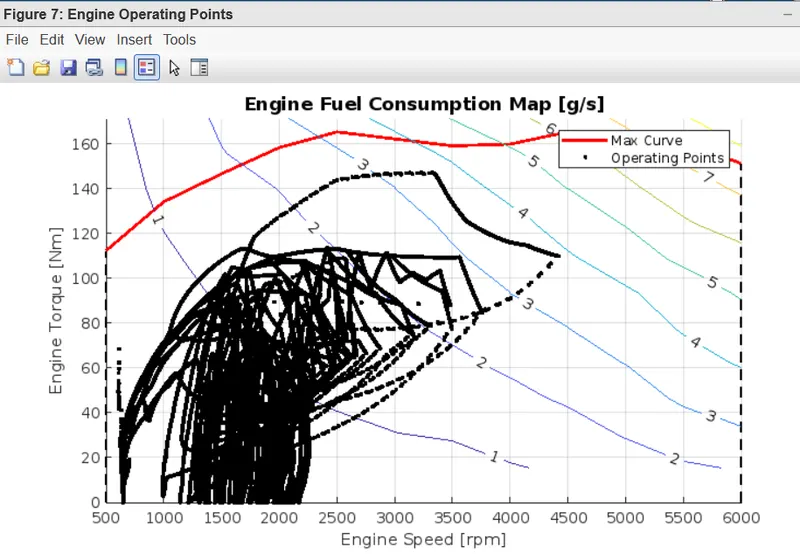
Q4.Plot the engine operating points on the engine fuel map.
UDDS DRIVECYCLE:
HWFET DRIVECYCLE :
Q5.Plot motor speed, torque, motor input power using subplots.
UDDS DRIVECYCLE:
HWFET DRIVE CYCLE:
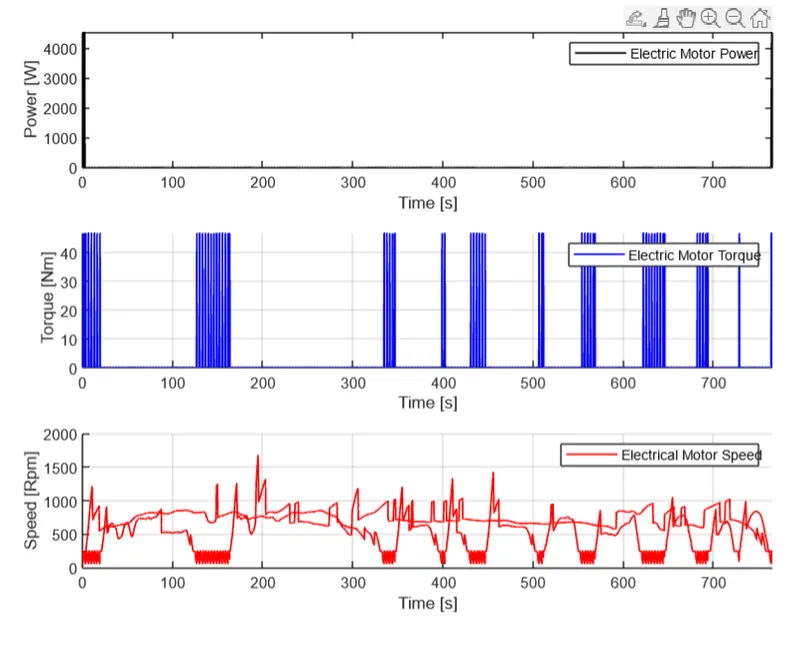
The speed variations are more in UDDS cycle compared to HWFET cycle because UDDS has to stop and go. it will have more idle time.so here we are introducing p1 motor .Hybrid is initiation of crank rotation and they are more in UDDS cycle when compared to HWFET cycle.
We can observe that the motor power and torque are very high in HWFET at the start and they are almost zero after few seconds but in UDDS it has continuod fluctuations this is because of frequent braking in UDDS.
Q6.Plot pack voltage, current and SoC using subplots.
UDDS DRIVE CYCLE :
HWFET DRIVECYCLE :
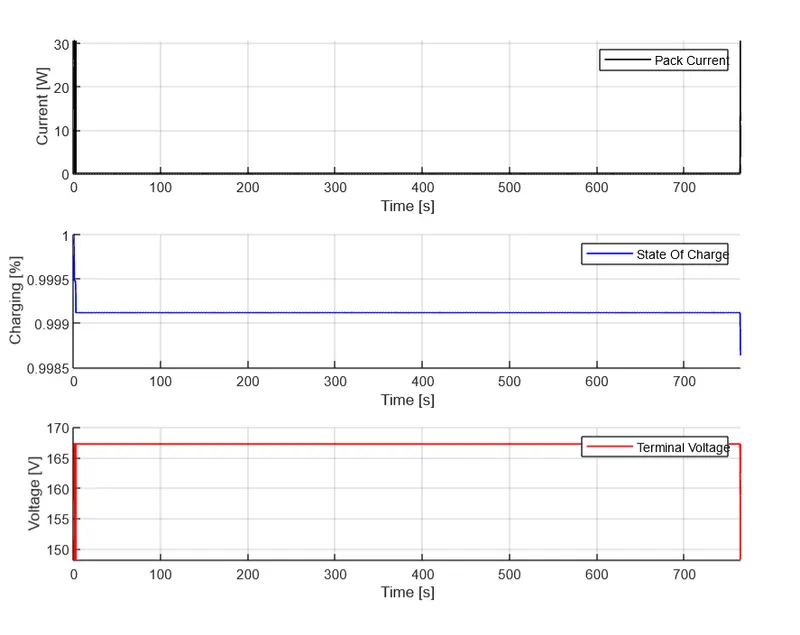
The pack voltage and current will have more fluctuations in UDDS as compared to HWFET cycle because of the more idle time and frequent changing of gears throughout the drive and the battery has to provide the energy everytime when the car is starting from the idle position.
SOC decreased in the UDDS cycle with time but it has increased in HWFET cycle. It is because in UDDS we have more idle time and frequent changing of gearsand battery has to provide the energy evertytime when the car is starting from the idle position and the SOC decreases but in HWFET cycle The Vehicle will be moving continuously without braking frequently and the alternator is utilised to transfer some engine power to the battery through motor so SOC increase in the HWFET cycle.
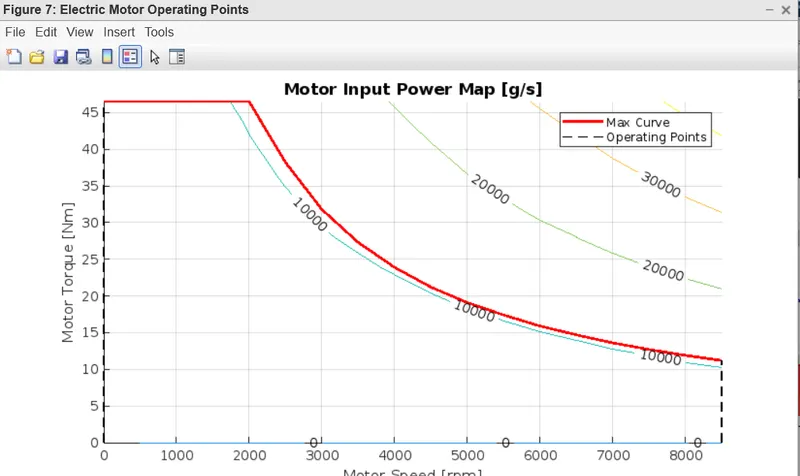
Q7.Plot the motor operating points on the motor input power map, with the motor max motoring and generating torque curves.
UDDS DRIVE CYCLE :
HWFET DRIVECYCLE :
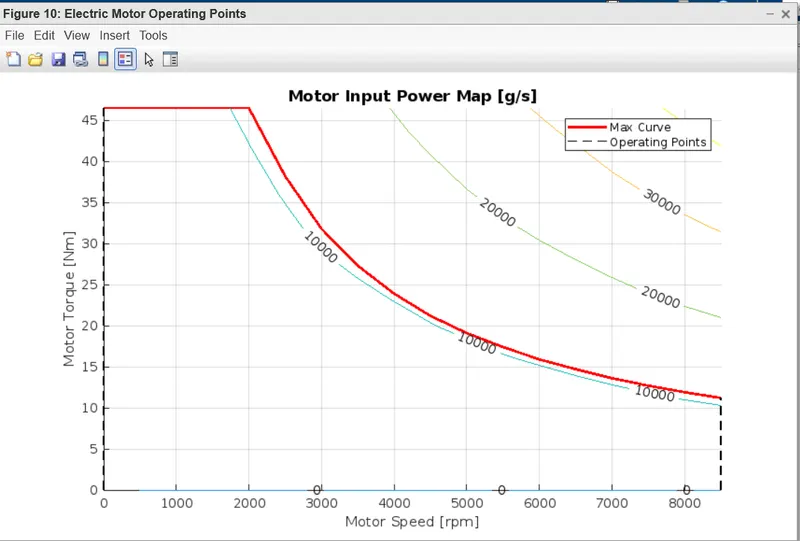
All the characteristics and operating points of UDDS drive cycle and HWFET drive cycle are analysed and the graphs are plotted
- Time trace for engine, Transmission input, Transmission output and wheelspeed with respect to time.
- Engine torque, Engine power, Fuel rate and Fuel consumption with respect to time.
- Accelerator and brake pedal, gear command and vehicle desired, actual speed, vehicle distance with respect to time.
- Engine operating points on the engine fuel map with respect to time.
- Motor speed, Torque, Motor input power with respect to time.
- Pack voltage, Current and State of charging with respect to time.
- The motor operating points on the motor input power map with respect to time.
and also it comparing with HWFET drive cycle and their numbers also compared.