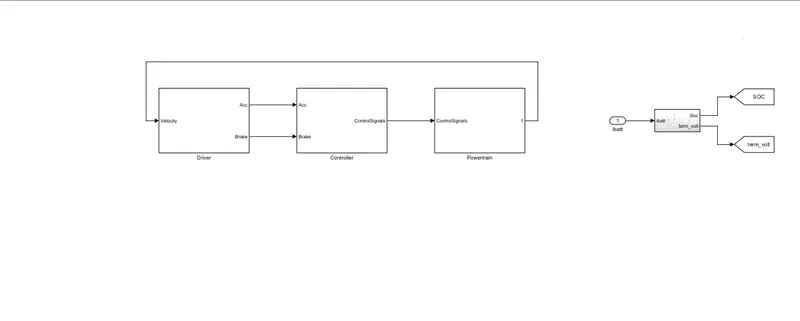
Aim to find the task of project 2
To find the figures first we have to use the initial mscript from attached files to get the variables for simulink model to run and to get the figure of the model
%% Skill-Lync -> Hybrid Drives Development
% Project 1 - Conventional Vehicle Model
% By - Guberan
% Description:
%% Initialization File
% Initialization file for loading the variables for the Conventional vehicle simulation model
%% Vehicle Parameters
M = 1500; % Vehicle weight [kg]
Cr = 0.015; % Rolling resistance coefficient
Rw = 0.35; % Rolling radius [m]
Cd = 0.33; % Drag coefficient
Af = 2; % Frontal area [m2]
rhoa = 1.225; % Air density [kg/m3]
Vwind = 0; % Wind velocity [kmph]
g = 9.81; % Gravitational acceleration [m/s2]
theta = 0; % Slope [deg]
myu_road_tire = 1; % Coefficient of friction between tire - road interface
%% Powertrain Parameters
FDR = 3.73; % Final Drive Ratio / Diff Ratio
DiffEff = 0.99; % Differential efficiency (assumed independent of operating conditions)
NumGear = 4; % Number of gears in transmission
TransGear = [1:NumGear]; % Transmission Gears
TransRatio = [3.06, 1.62, 1, 0.7]; % Corresponding Transmission ratios
TransEff = 0.90; % Transmission efficiency (assumed independent of operating conditions)
TC_SR = [0, .5, .6, .7, .8, .87, .92, .94, .96, .97, 1]; % Torque Converter Speed Ratio (Matlab default) -> TurbSpd/PumpSpd
TC_TR = [2.232, 1.5462, 1.4058, 1.2746, 1.1528, 1.0732, 1.0192, 1, 1, 1, 1]; % Torque Converter Torque Ratio (Matlab default) -> TurbTrq/PumpTrq
TC_Cf = 1e-4 * [.72558, .66322, .63463, .59042, .51331, .4144, .29287, .22444, .12186, .04386, 0]; % Torque Converter Capacity Factor (Matlab default) -> PumpTrq/PumpSpd^2 [Nm/rpm^2]
load Engine_data_1_9L_Saturn_95kW
load Trans_Shift_map
load EM_Honda_Insight_10kW
load ESS_NiMH6
ESS_init_soc = 0.8;
ESS_soc_max = 0.9;
ESS_soc_min = 0.6;
%% Driver Parameters
Kp = 10; % P gain for driver PI model
Ki = 1; % I gain for driver PI model
Drive_Cycle_Select = 2; % Drive cycle selection
% Drive cycle values in m/s
if Drive_Cycle_Select == 1
load DriveCycles/UDDS;
elseif Drive_Cycle_Select == 2
load HWFET;
elseif Drive_Cycle_Select == 3
load DriveCycles/FTP;
elseif Drive_Cycle_Select == 4
load DriveCycles/US06;
elseif Drive_Cycle_Select == 5
load DriveCycles/NEDC;
elseif Drive_Cycle_Select == 6
load DriveCycles/WLTP;
end
time_end = cyc_time(end);
vel_end = cyc_vel(end);
Simulink model
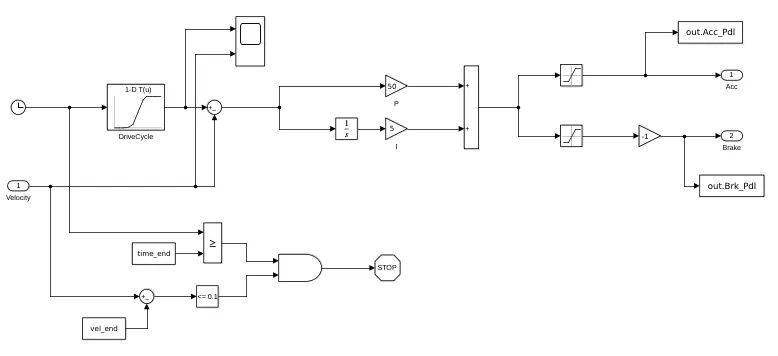
Driver model
the driver model is used to control for the pedals of both accelerator and brakes and the input of velocity and time is given
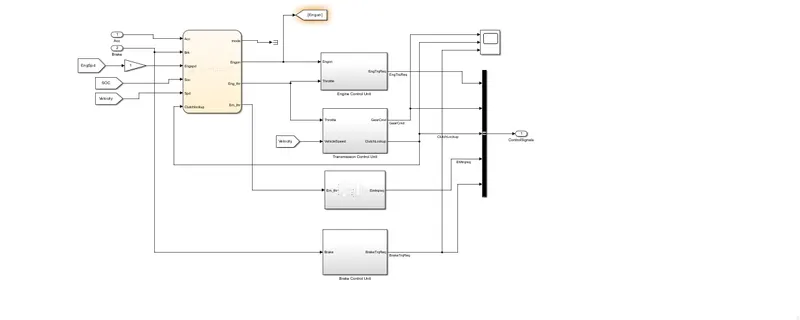
Controller Block
The controller block which is used control the engine, transmission, brake control unit
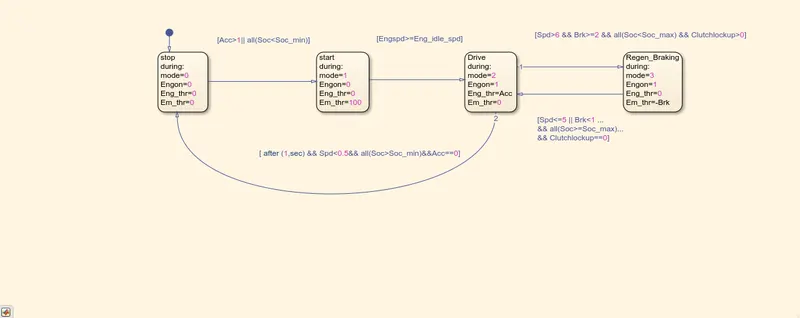
A state flow machine is used to represent the supervisory control unit, which decides the operationg mode.
while it is start/stop mode or cruising mode or regen braking mode. for each modes the Engine drive and the
motor drive are controlled.
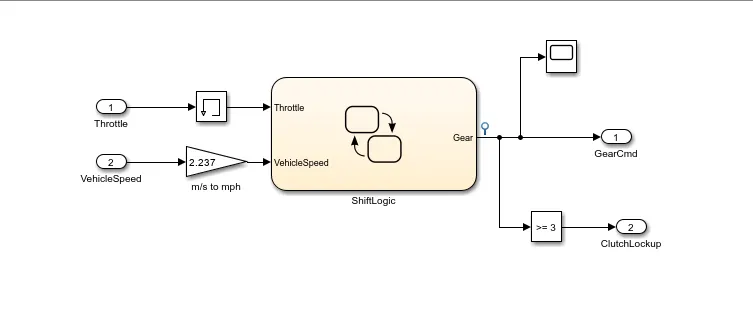
Shift logic block
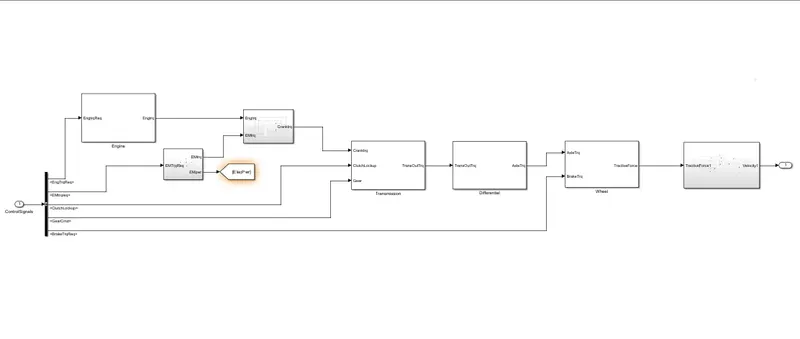
Powertrain model
the powertrain model of the vehicle is consist of the controls of engine, transmission,differential,wheels anf vehicle dynamics of the vehicle which used to run the vehicle
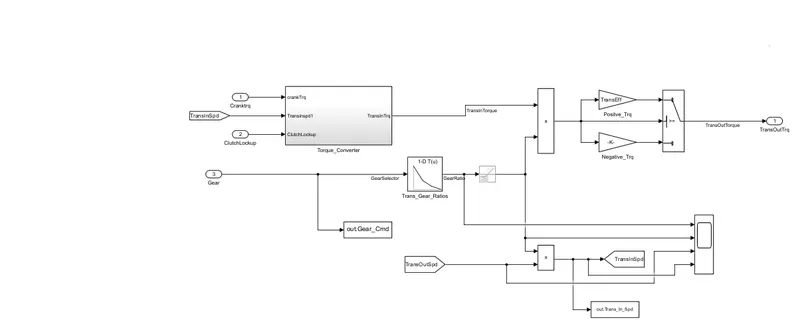
Transmission Block
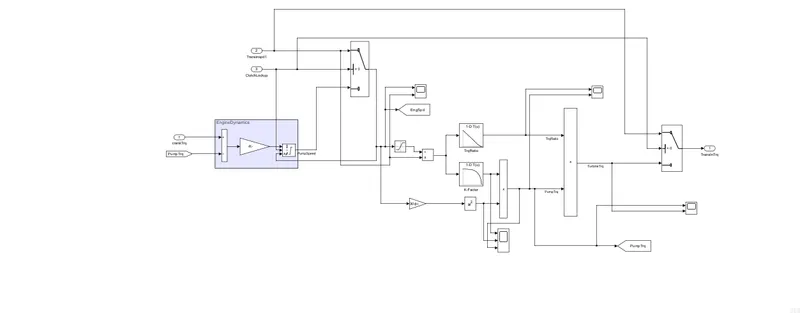
Torque Converter
EM motor subsystem
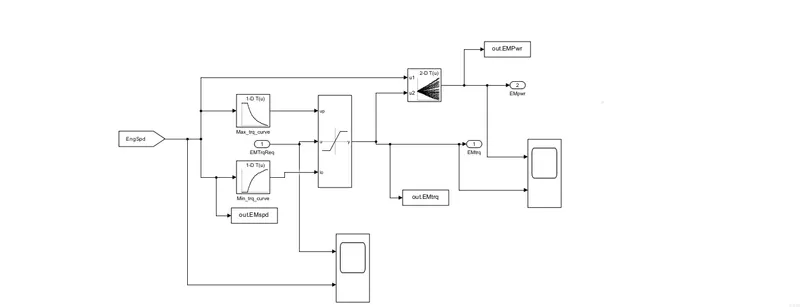
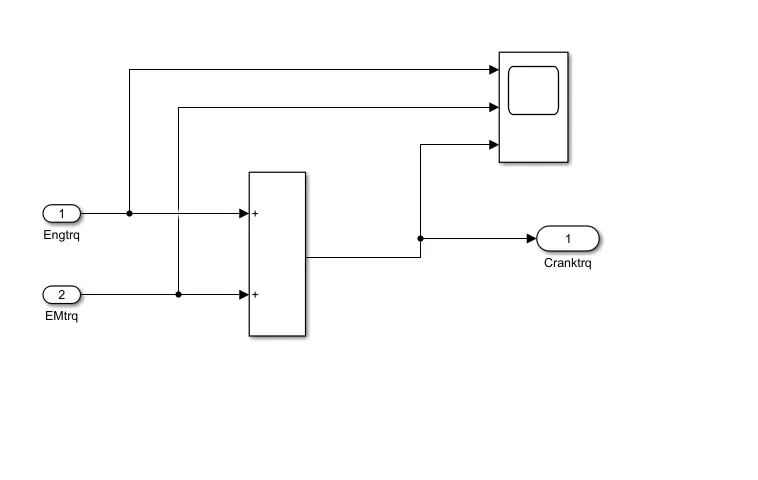
Crank Subsystem
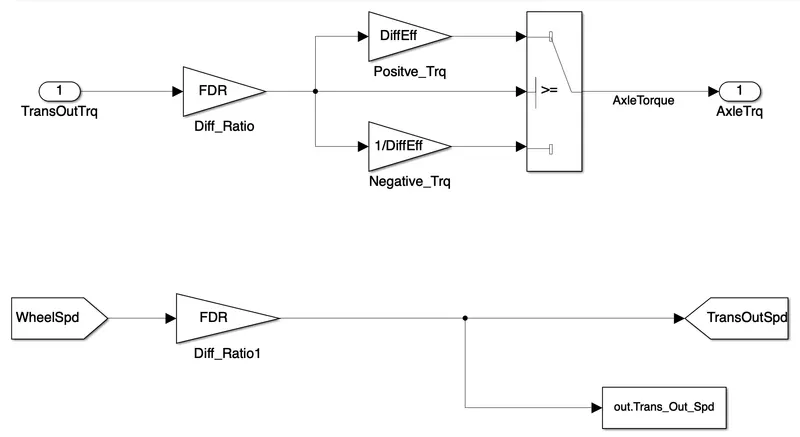
Differential Model :
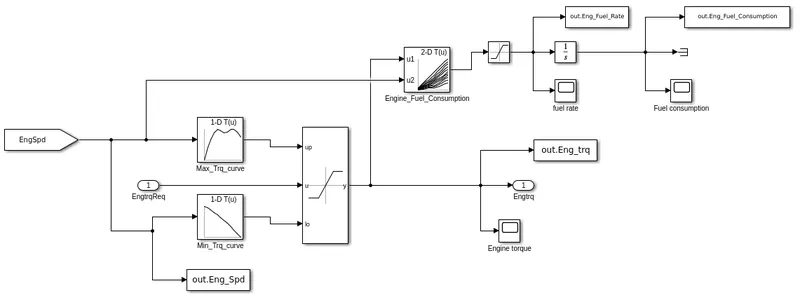
Engine block
the engine of a vehicle is one of the main components to run the vehicle the engines are run on fossil fuels in IC engines and EV's are run with batteries the two types of IC's are(Diesel, and Petrol)
vehicle dynamics Block
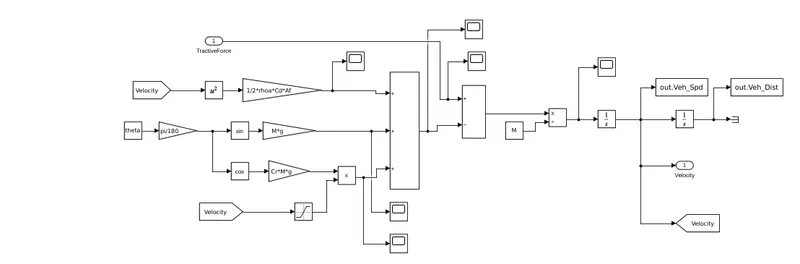
after moduling the both engine and vehicle dynamics model we can run the model respected model then we have to select the postprocessing script file to plot the output figures of the model
after run the model we can get the variables for the post processing script
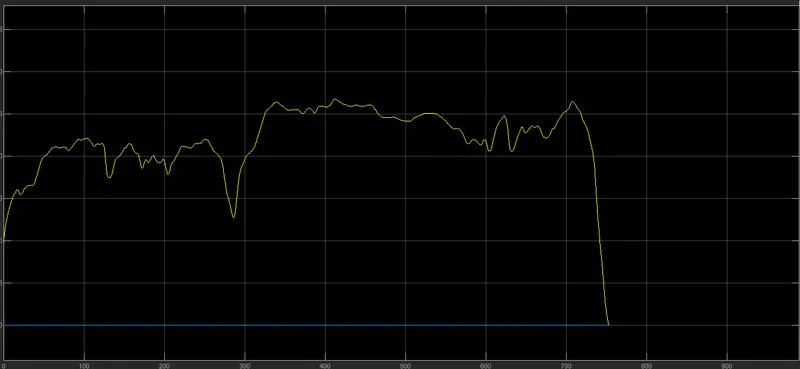
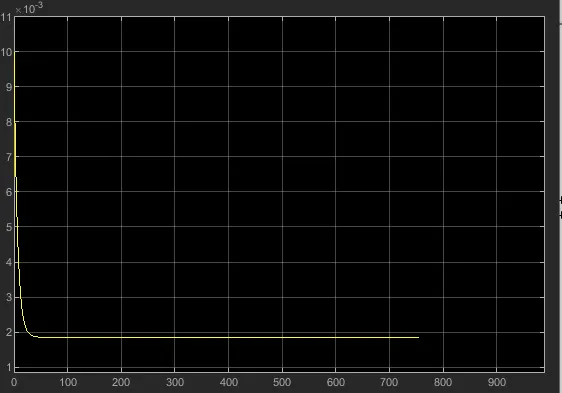
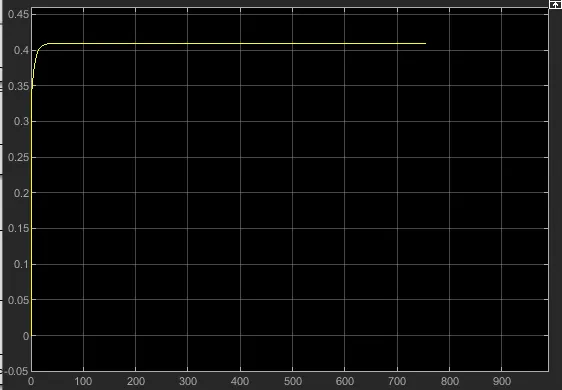
the screenshot of the scope are attached