Project
ALL TERRAIN VEHICLE
An all-terrain vehicle, also known as a light utility vehicle, a quad bike, or simply a quad, as defined by the American National Standards Institute; is a vehicle that travels on low-pressure tires, with a seat that is straddled by the operator, along with handlebars for steering control. As the name implies, it is designed to handle a wider variety of terrain than most other vehicles.
AIM OF THE PROJECT:- to carryout a system level simulation of an all terran vehicle and provide a detailed report on it.
PHYSICAL COMPONENTS USED:-
- vehicle body
- suspension
- tire
- engine
- CVT
SIMSCAPE MODEL OF VEHICLE:-(BASIC)
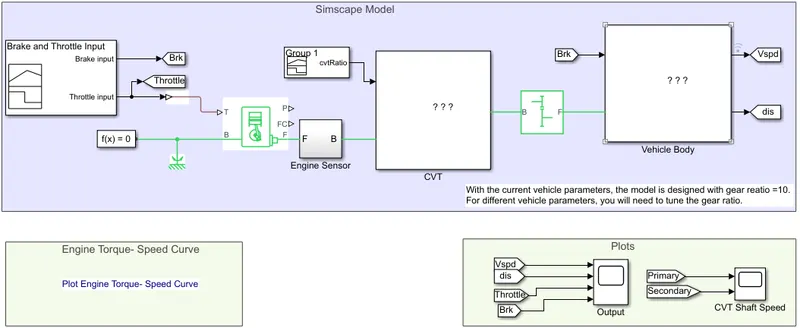
The above figure is the basic simscape model, where the model consists of:-
- signal builder
- engine
- engine sensor
- CVT
- simple gear
- vehicle body
We can change change the input of throttle and brake from signal builder.
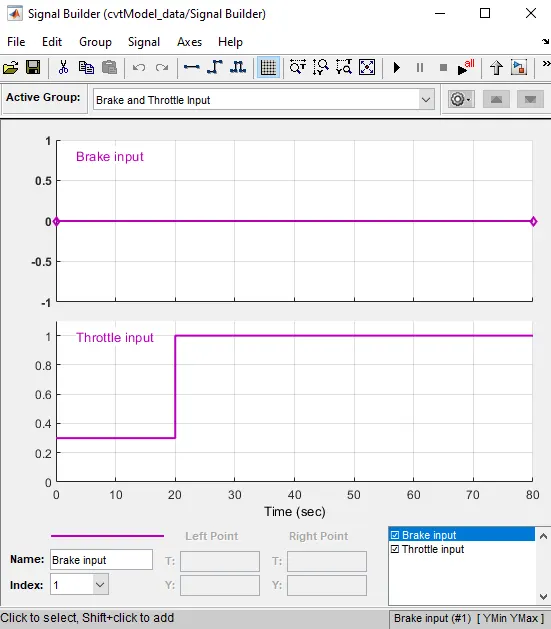
Now, let us run the simulation and see the resultant graphs.
Results:-(velocity and throttle)
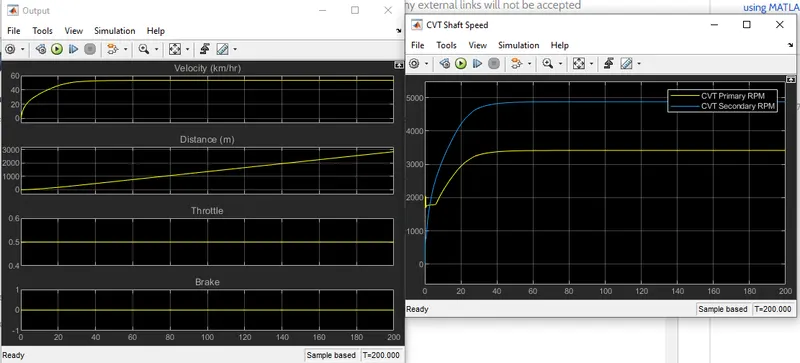
In results we can see the velocity generated by all terran vehicle after applying throttle and keeping braking at 0.
Important note:-
If any graph is been given to us in the form of image and we have to replicate exact output in our model, we could feed the data in grneric engine with the help of a add on application in matlab i.e GRABIT.
lets take the example of a simple image below:-
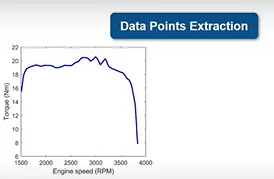 So, with the help of grabit we can easily cover all the points and replicate the image as our output.
So, we have done the basic modelling but for changing the acceleration and braking we always need to use signal builder, so to avoid this hard work we could do smart work and connect blocks for braking and throttle. So that it will be easier to visualise the output and make our model more attractive.
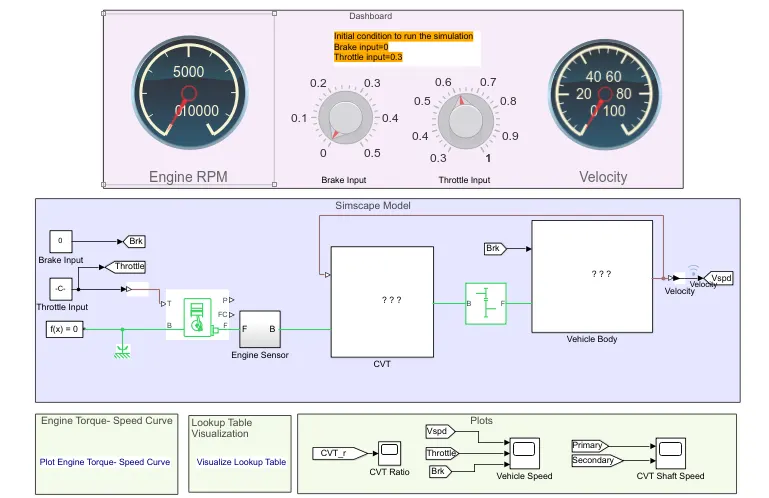
Here, what the BAJA team has done, they connected engine rpm and total velocity acquired as analog display, and added two on display inputs for throttle and brake.
CVT:-(Continuously variable transmission)
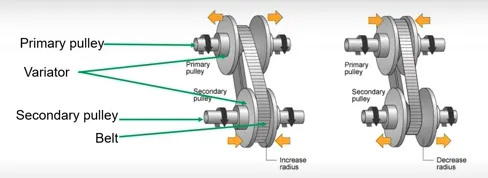
Its just the mechanical gear which gives continuous variable transmission.
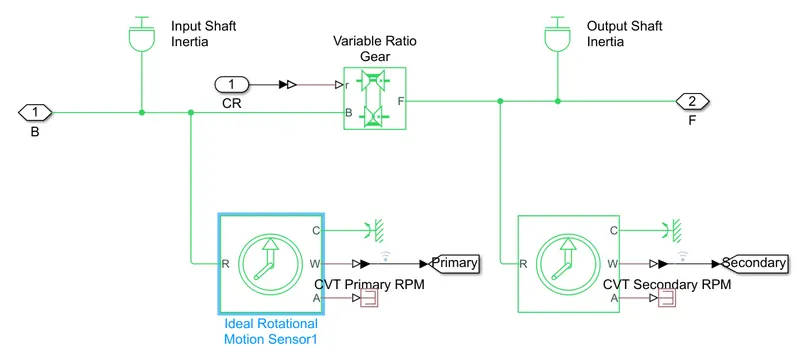
Vehicle body:-
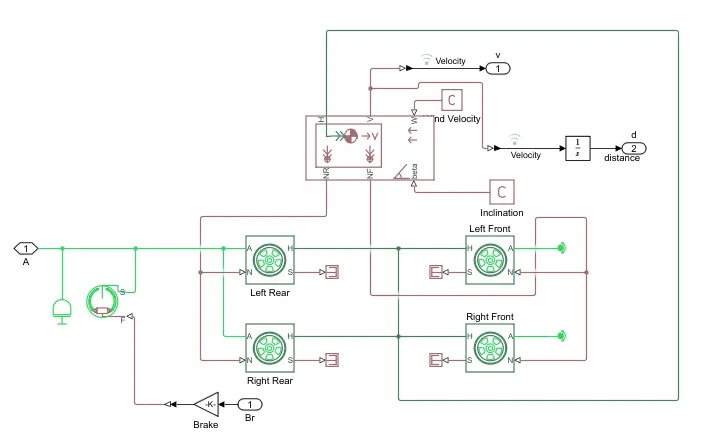
Above is the full body parts of the vehicle,where we can see all the four wheels sensors brake etc.
So lets run the model and try to use all the given components.
Results:-
Here, we have given a certain throttle and left no brake(as an example)
but we can give any sort of throttle and brake accordingly.
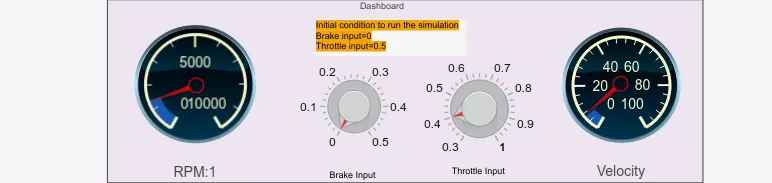
Display of inputted data.
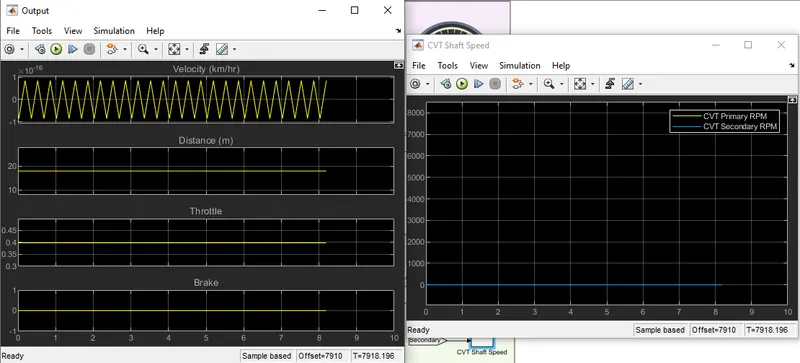
As we can see that output is found according to input.
The above result is just an example, we can change the values and go for different results, and compare the resultant graph.
Conclusion:-
we have learnt how to construct an all terran vehicle with the help of basic blocks and run the vehicle accorging to our control.