BAJA ATV model with Continuously Variable Transmission(CVT).
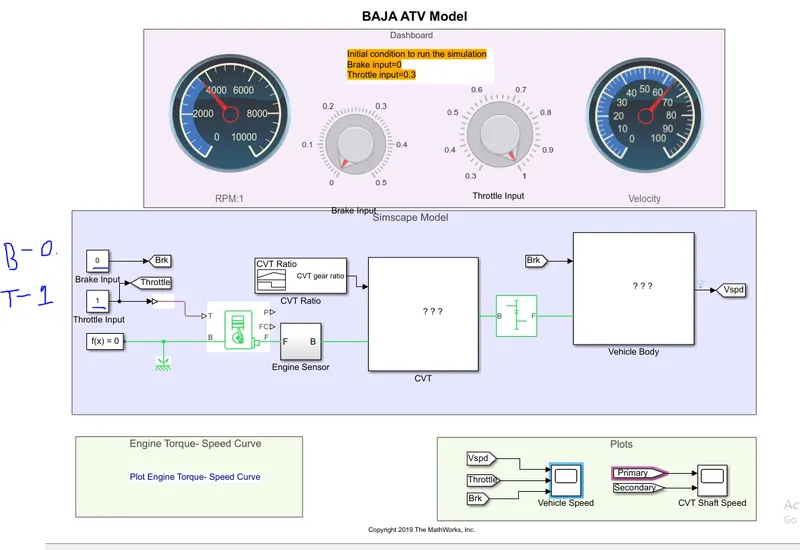
AIM: To perform the simulink BAJA ATV vehical model by changeing the parameter like throtal, brake and observe the variations.
DISCRIPTION:
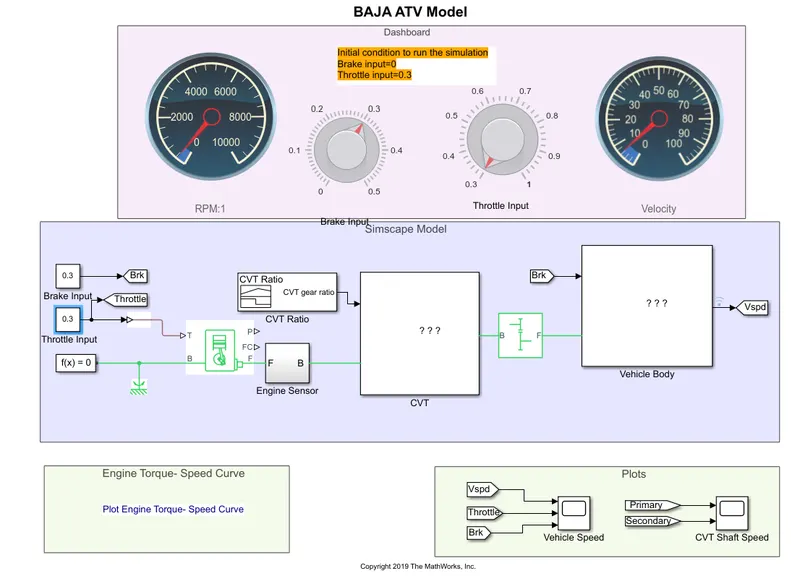
As per the queation the model of BAJA ATV model with Continuously Variable Transmission(CVT):
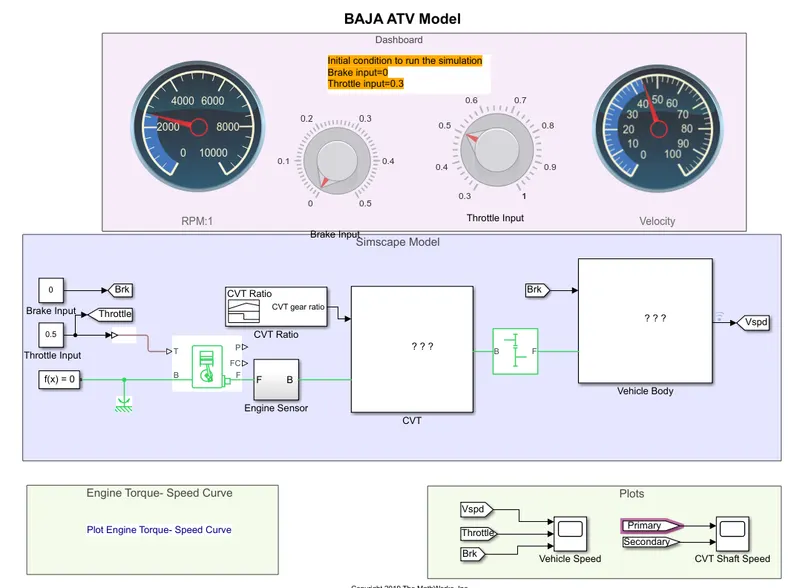
MOdel with initial input:
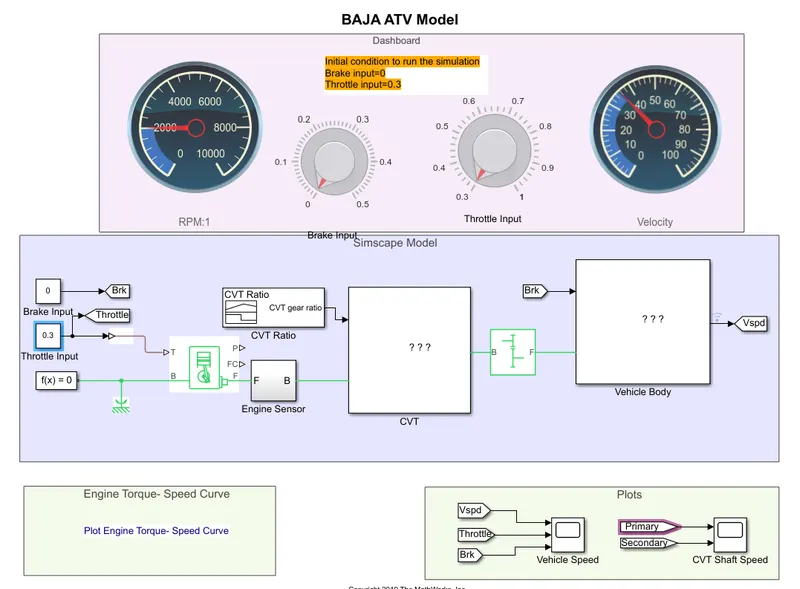
In this model our i sow the following points:
1) Components of a baja ATV
2) Vechical model
3) Effects of parameter variatins like throttle and brak
* Components of a baja ATV :
1) CVT(continuously variable transmission.
2) Vechical body.
3) Generic Engine.
4) Some fundamental components.
simulink blocks with thir function:
1) CVT:
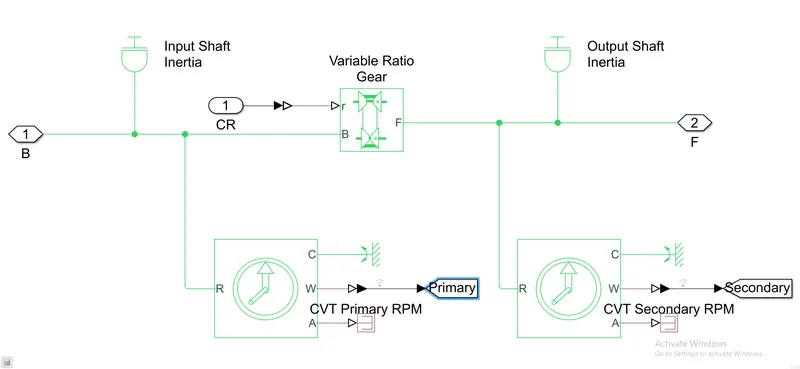
block used:
1) VAriable Ratio transmission: The Variable Ratio Transmission block represents a gearbox that dynamically transfers motion and torque between the two connected driveshaft axes, base and follower.
2) Inertia: The block represents an ideal mechanical rotational inertia used as the primary pully and secondary pully.
3) Ideal rotationl motion sensor: This block measures angular velocity or angle in a mechanical rotational network.
In CVT when primery pully get outwords then secondary pully get invward that time speed reduction happen. When primery pully get inwords then secondary pully get outvward that time speed overdrive happen
for 1st condition Rs> Rp- Speed reduction.
for 2nd condition Rp> Rs- overdrive.
secondary pully is connected to rear wheel.
2) Vehicle body:
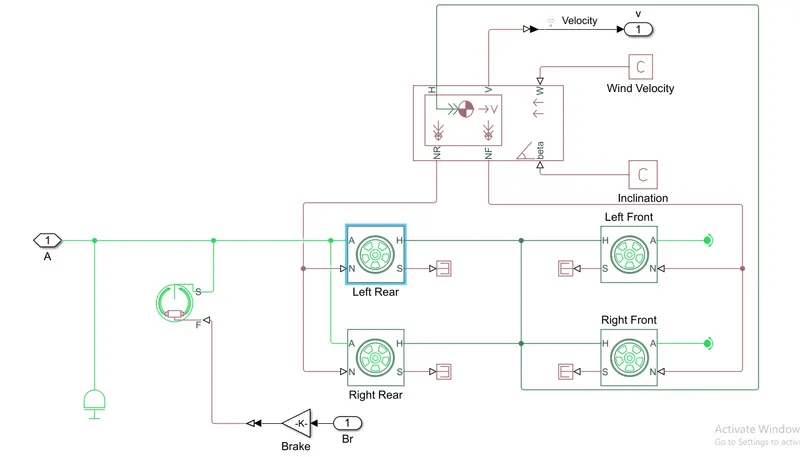
block used:
1) Vehicle body:The Vehicle Body block represents a two-axle vehicle body in longitudinal motion.
2) Tire: The Tire block models a tire with longitudinal behavior given by the Magic Formula , an empirical equation based on four fitting coefficients.
3) Double shoe break: Represents a brake arranged as two pivoted rigid shoes symmetrically installed inside or outside a drum and operated by one actuator.
4) some funadametal block.
3) Generic Engine:
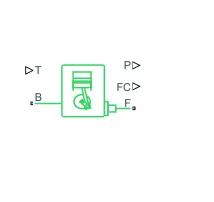 Function: Represents a system-level model of spark-ignition and diesel engines suitable for use at initial stages of modeling when only the basic parameters are available. Optional idle speed and red line controllers are included.
To connect the CVT and engine we get simple gear ratio.
4)Dashbord:
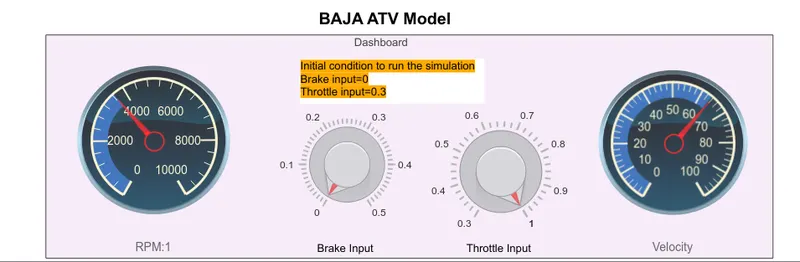
it is used for indications of speed, rpm, breek input, throttle input.
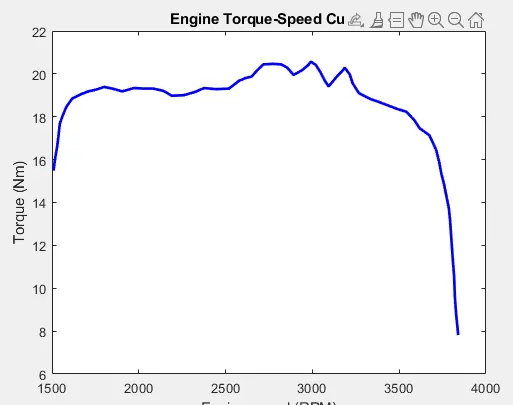
In this model used speed torque curve:
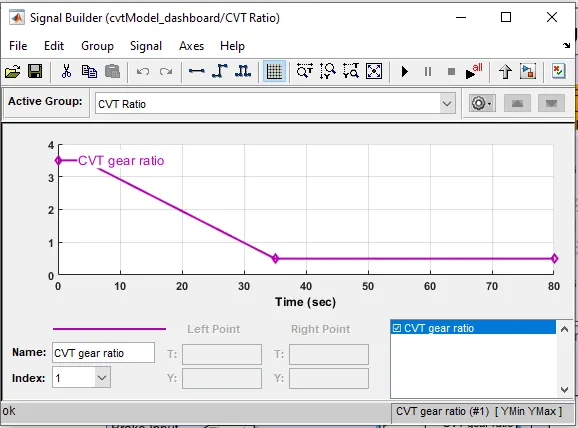
Signal builder: It is used for to set ratio of CVT gear
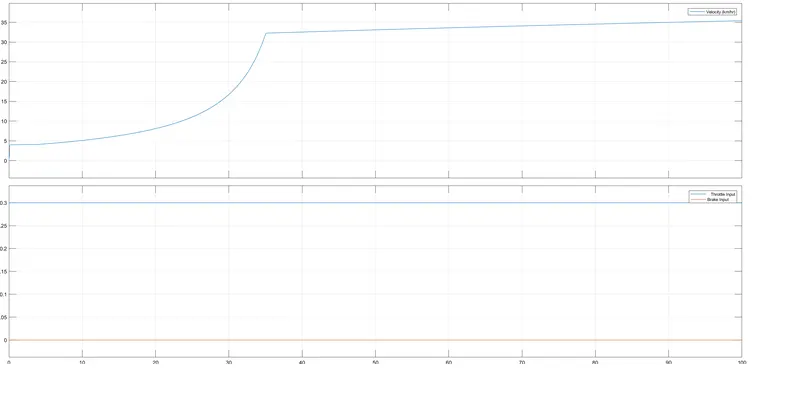
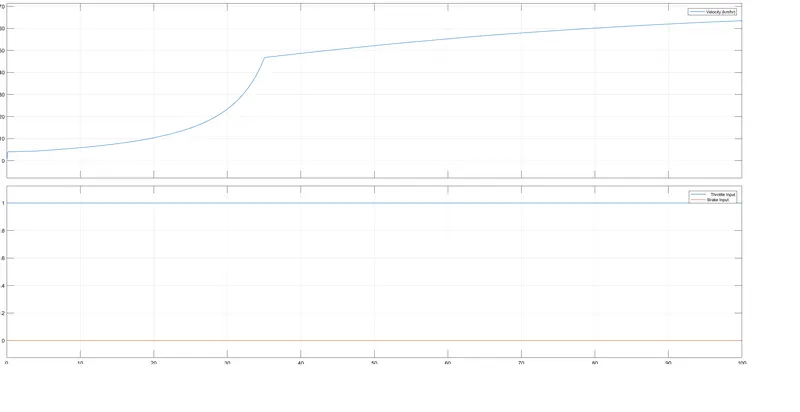
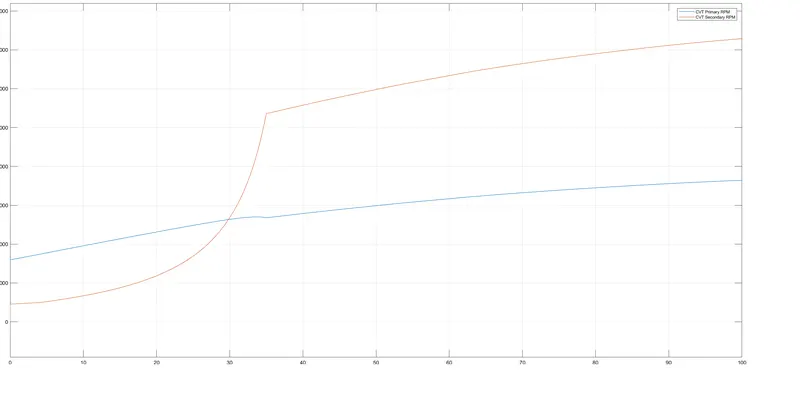
As per in aim we changed the parameters like throttle and brake and we get following outputs speed, shaft speed. The similation is run for 100 sec
We observed following parameteres:
mAX SPEED
TABLE NO1.
| Throtle | brake | Max speesd (t=100)km/h |
| 0.3 | 0 | 35 |
| 1 | 0 | 63 |
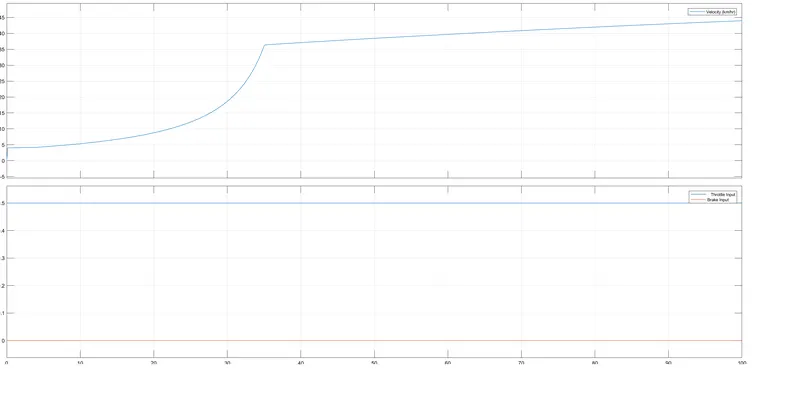
| 0.5 | 0 | 44 |
| 0.3 | 0.3 | 6.2 |
| 0 | 0.3 | 0 |
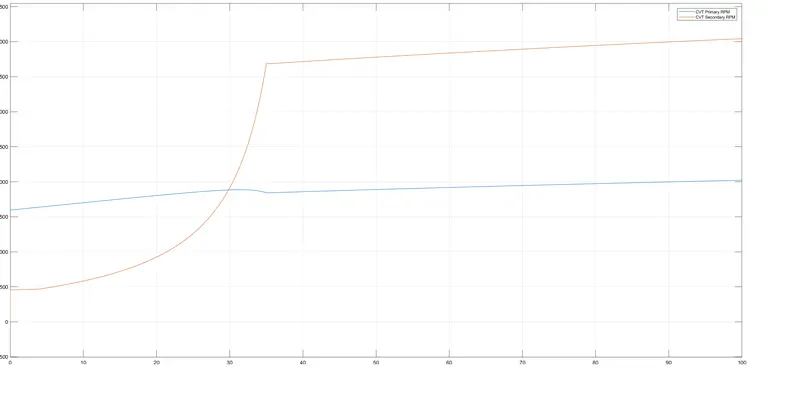
SHAFT SPEED:
TABKE NO2.
| Throtle | brake | primary shaft speed | secondary shaft speed |
| 0.3 | 0 | 2024 | 4045 |
| 1 | 0 | 3643 | 7290 |
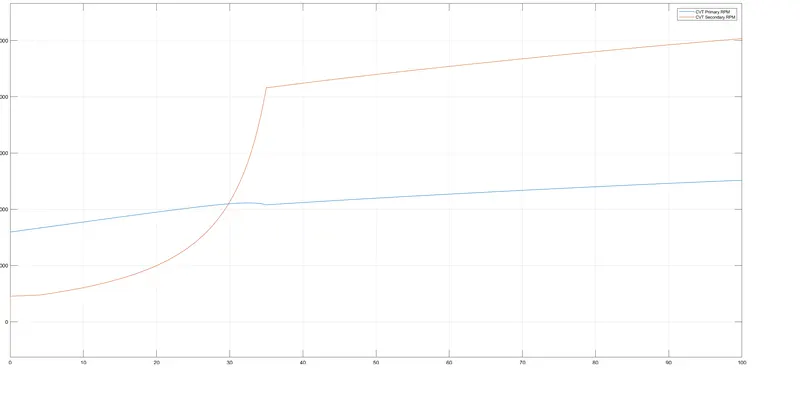
| 0.5 | 0 | 2515 | 5500 |
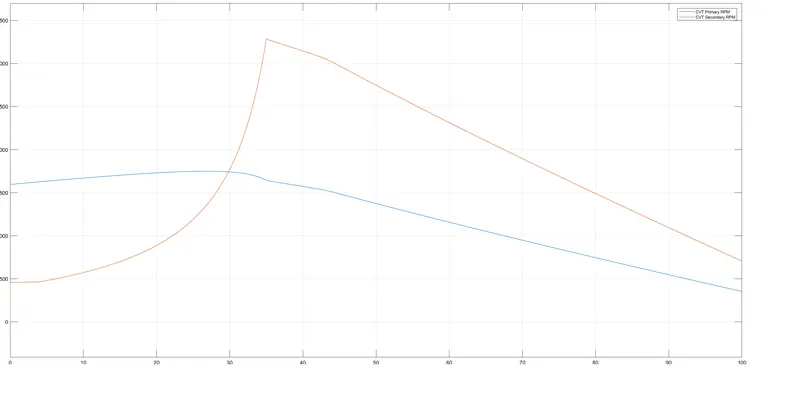
| 0.3 | 0.3 | 352.2 | 705 |
| 0 | 0.3 | 0 | 0 |
MODEL WITH THROTLE-0.3, BRAKE-0
SPEED CURVE:
SHAFT SPEED CURVE:
MODEL WITH THROTLE-1, BRAKE-0:
SPEED CURVE:
SHAFT CURVE:
MODEL WITH THROTLE-0.5, BRAKE-0:
SPEED CURVE:
SHAFT SPEED:
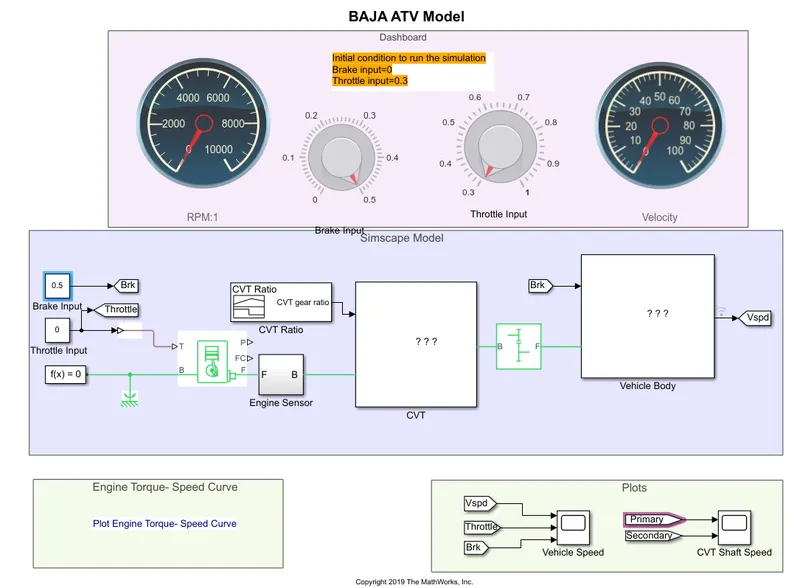
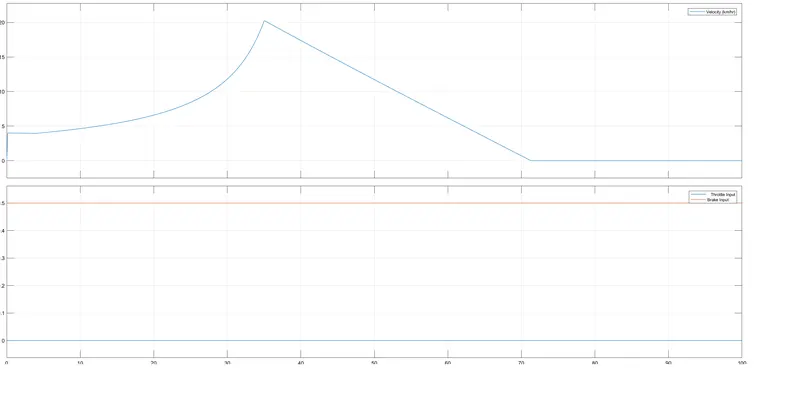
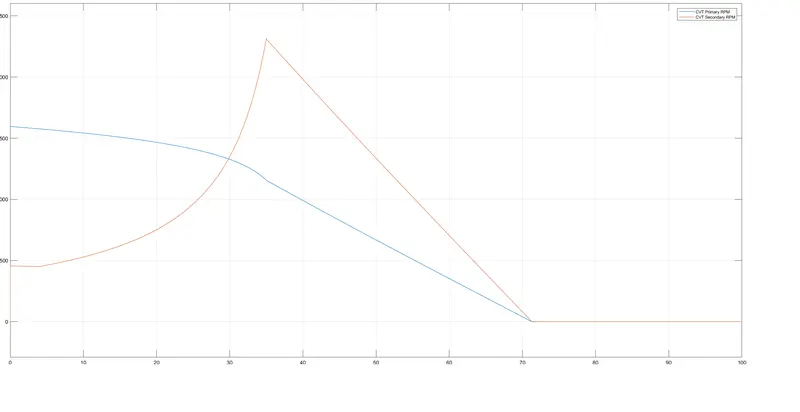
MODEL WITH THROTLE-0, BRAKE-0.5:
SPEED CURVE:
SHAFT SPEED CURVE:
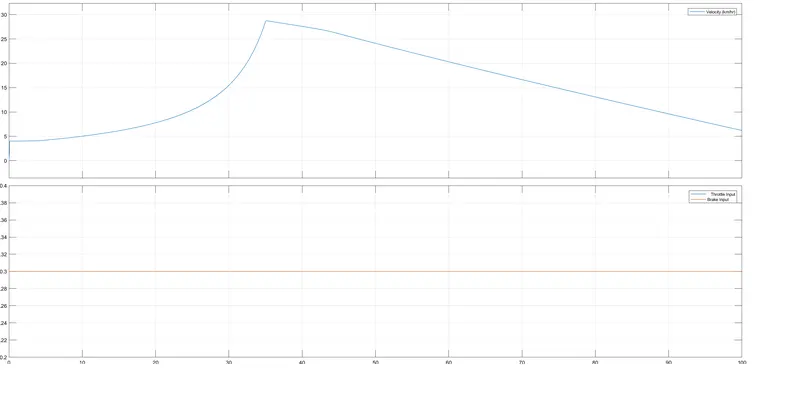
MODEL WITH THROTLE-0.3, BRAKE-0.3:
SPEED CURVE:
SHAFT SPEED:
RESULT:
mAX SPEED
TABLE NO1.
| Throtle | brake | Max speesd (t=100)km/h |
| 0.3 | 0 | 35 |
| 1 | 0 | 63 |
| 0.5 | 0 | 44 |
| 0.3 | 0.3 | 6.2 |
| 0 | 0.3 | 0 |
SHAFT SPEED:
TABKE NO2.
| Throtle | brake | primary shaft speed | secondary shaft speed |
| 0.3 | 0 | 2024 | 4045 |
| 1 | 0 | 3643 | 7290 |
| 0.5 | 0 | 2515 | 5500 |
| 0.3 | 0.3 | 352.2 | 705 |
| 0 | 0.3 | 0 | 0 |
END