Project
Aim: To prepare a technical report of Simulation of BAJA All-Terrain Vehicle (ATV).
Objectives: Carry out a system-level simulation of an all-terrain vehicle and prepare a technical report explaining the model properties & comments on the results.
Defination of ALL TERRAIN VEHICLE:
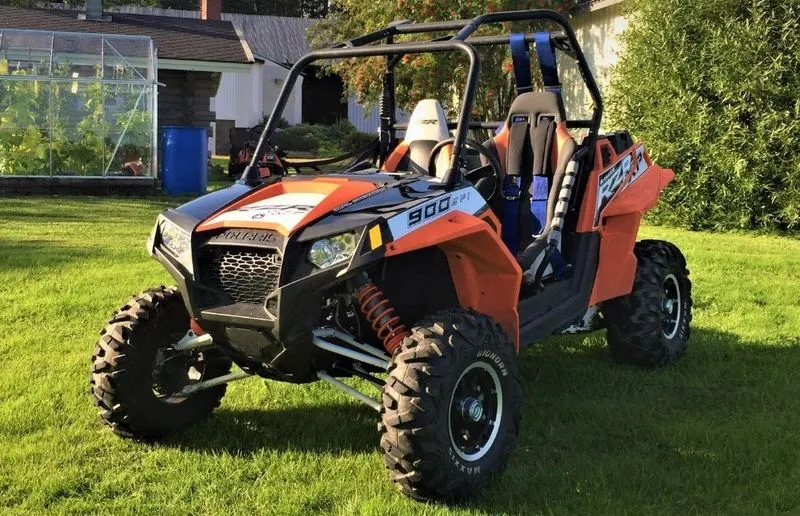
An all-terrain vehicle (ATV), also known as a quad, quad bike, three-wheeler, four-wheeler, or quadricycle is defined by the American National Standards Institute (ANSI) as a vehicle that travels on low-pressure tires, with a seat that is straddled by the operator, along with handlebars for steering control. As the name.
we have done multiple case studies to observe the outputs w.r.t to inputs provided in the model.
Case Study 1-
SIMULINK MODEL FOR BAJA ATV WITH CVT:
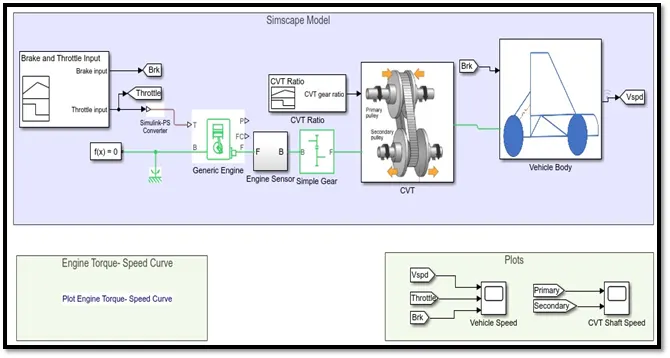
Components used to make model following are-
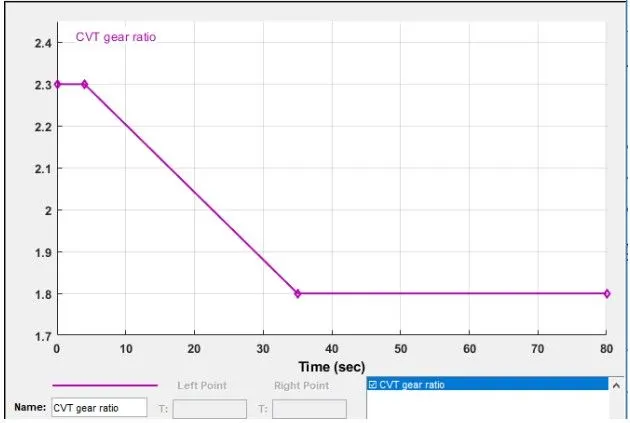
1. continuously variable transmission (CVT) is an automatic Transmission that can change seamlessly through a continuous range of gear ratios. This contrasts with other transmissions that provide a limited number of gear ratios in fixed steps. The flexibility of a CVT with suitable control may allow the engine to operate at a constant RPM while the vehicle moves at varying speeds.
CVTs are used in Automobiles, Tractors, Motor Scooter, snowmobiles, bicycles and Earthmoving.
The most common type of CVT uses two pulleys connected by a belt or chain; however, several other designs have also been used at times
In our case- It is better to have more gears in a transmission, since it can optimize engine speed in a variety of driving conditions. That means low gears can provide better acceleration while higher gears can maximize fuel economy. CVTs differ from traditional automatic transmissions in that they don't have gears that provide "steps" between low- and high-speed operations. Instead, the majority of them work via a pair of variable-diameter, cone-shaped pulleys connected by a steel or composite belt. The halves of each pulley are aligned with the pointed ends of the cones touching. These form a V-shaped groove in which the connecting belt rides. One side of the pulley is fixed, and the other side is movable, actuated by a hydraulic cylinder. The cylinder can increase or decrease the amount of space between the two sides of the pulley. This allows the belt to ride lower or higher along the walls of the pulley, depending on driving conditions, thereby changing the "gear" ratio.
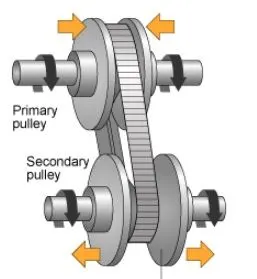
- CVT Block:
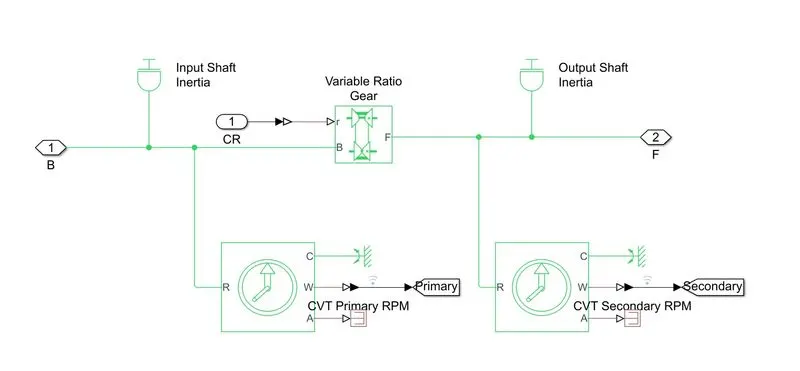
- VARIABLE TRANSMISSION RATIO:
Represents a variable ratio gearbox such as implemented by mechanical belt CVT, electric, or hydraulic transmissions. The physical signal input r defines the ratio of input to output angular shaft velocities.
Connections B (base) and F (follower) are mechanical rotational conserving ports. Specify the relation between base and follower rotation directions with the Output shaft rotates parameter.
The Variable Ratio Transmission block represents a gearbox that dynamically transfers motion and torque between the two connected driveshaft axes, the base and the follower. When you choose to have the block ignore the dynamics of transmission compliance, it constrains the driveshafts to corotate with a variable gear ratio that you control.
2. Engine:
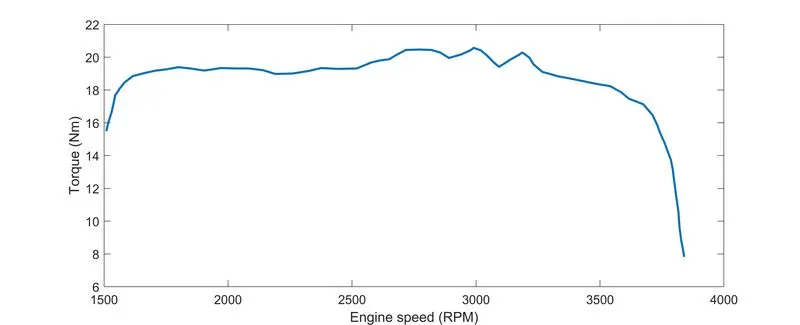
Engine block is used as a system-level model of spark-ignition and diesel engines suitable for use at initial stages of modelling when only the basic parameters are available. Optional idle speed and red line controllers are included. Inside of block parameter controls The throttle input signal T lies between zero and one and specifies the torque demanded from the engine as a fraction of the maximum possible torque.
Connections F and B are mechanical rotational conserving ports associated with the engine crankshaft and engine block, respectively. Connections P and FC are physical signal output ports through which engine power and fuel consumption rate are reported.
3. Input Signal:
A signal builder is used to create signals for brake and throttle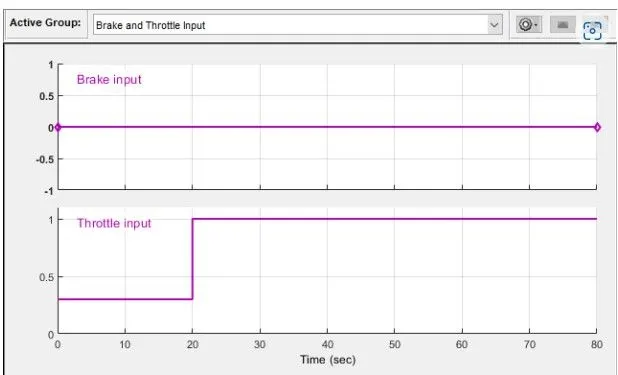
CVT GEAR RATIO INPUT:
Torque Vs Engine input Speed Input:
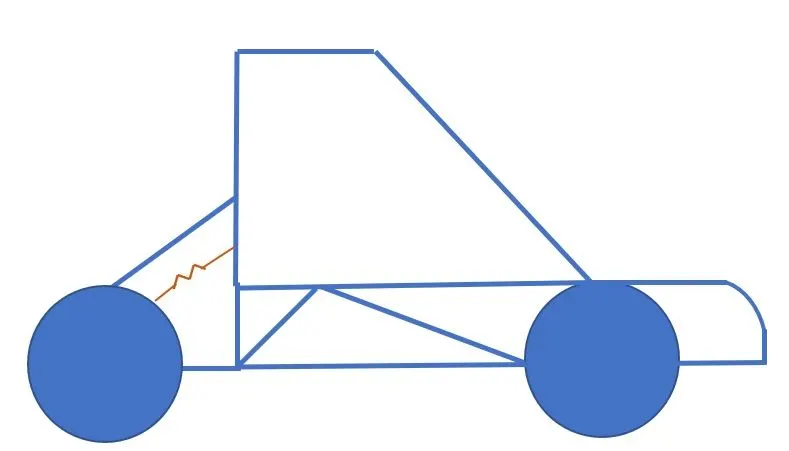
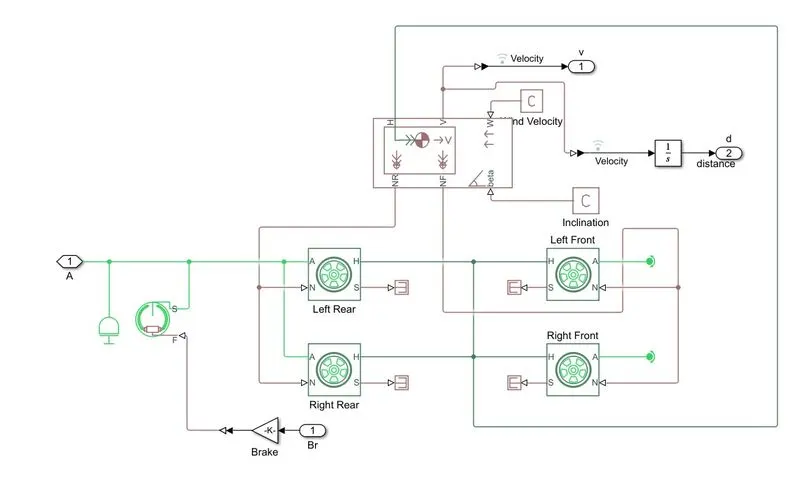
Vechile Body:-
Simulink Model of Vechile Body:
OUTPUT of CASE 1:
VEHICLE SPEED PLOT:
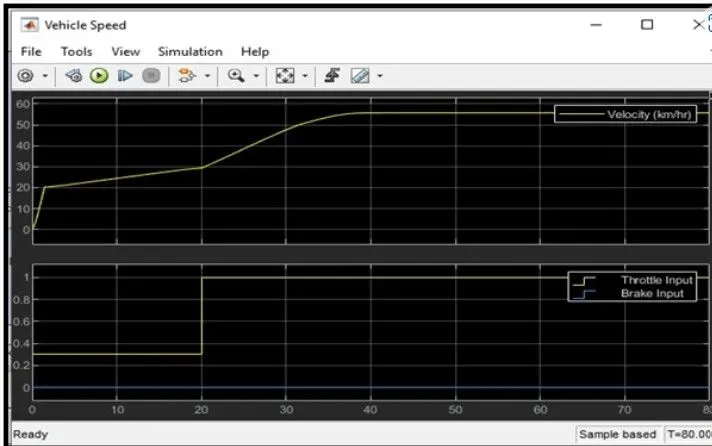
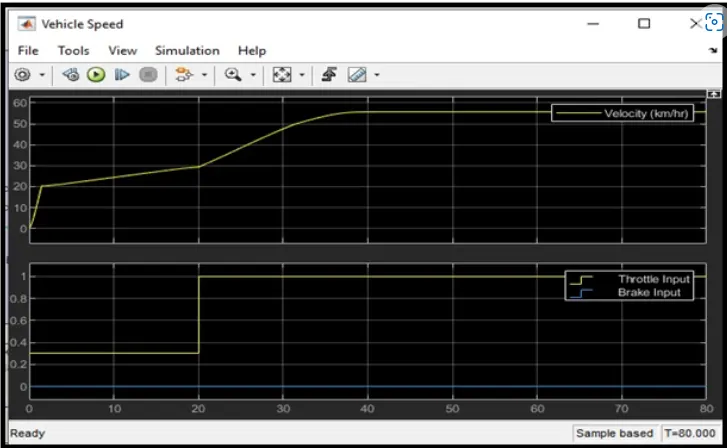
It is clear from the graph that the vehicle attains its maximum speed (V = 55km/hr) at full throttle = 1 after 30 seconds and then remains constant. The brake input value is zero, hence it has no effect on velocity.
CVT SHAFT RPM:
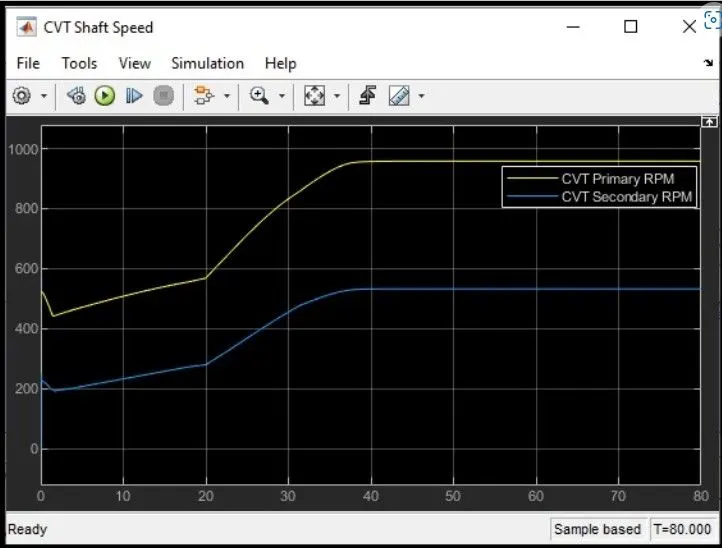
From above results we can conclude that the Both results are same as that of the first case: - SIMULINK MODEL FOR BAJA ATV WITH CVT since the input parameters are same.
Case Study 2:
SIMULINK MODEL FOR BAJA ATV WITH CVT USING DASHBOARD
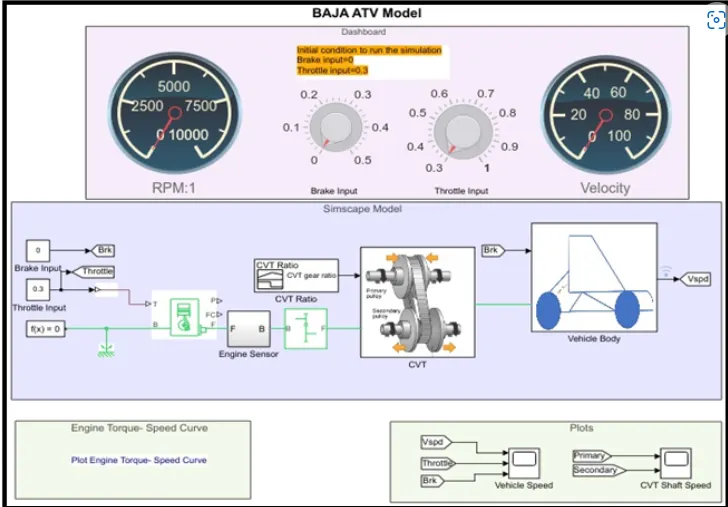
In this model we have a dashboard which contains knobs to control the inputs (Automation). In this case, the inputs- ‘Throttle’ & ‘Brake’ are not provided using signal builder. A knob is provided to control both the parameters in real-time for the user.
Output Plots:
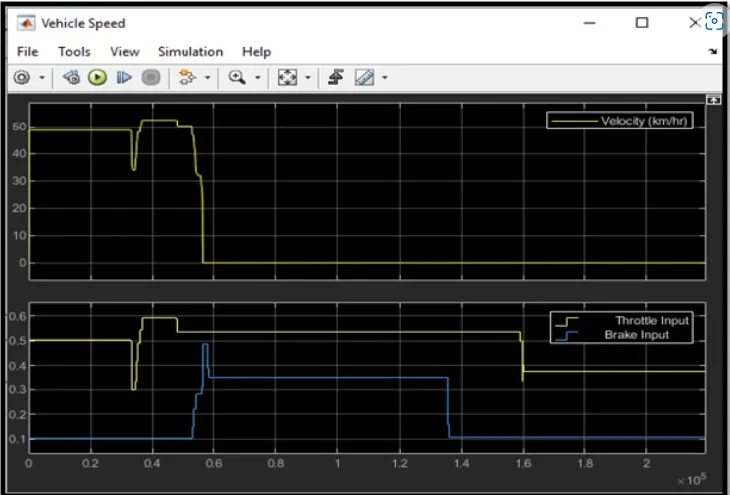
From above graph plot we can conclude that the velocity of the vehicle increases drastically from 0 to 50kmph when throttle value is 0.5 & brake input is 0. while braking value increases from 0.1 to 0.5, then the velocity of the vehicle decreases to 0 at constant throttle value. This explains the direct relation of vehicle velocity with respect to throttle and brake inputs.
Case Study 3:
SIMULINK MODEL FOR BAJA ATV WITH CVT USING LOOKUP TABLE:
CVT Block:
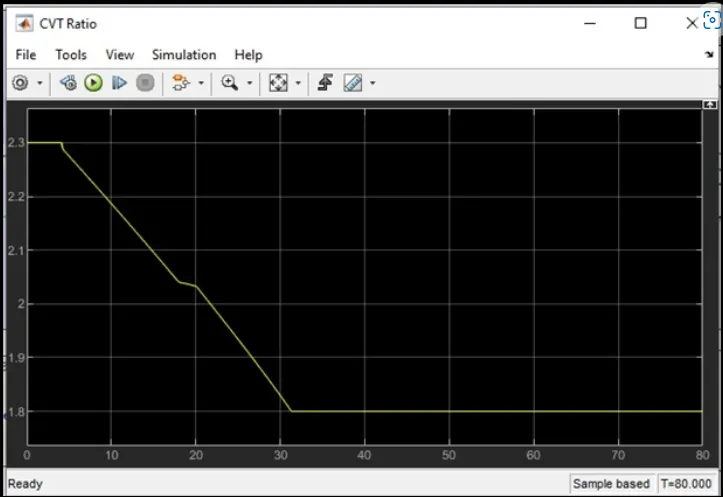
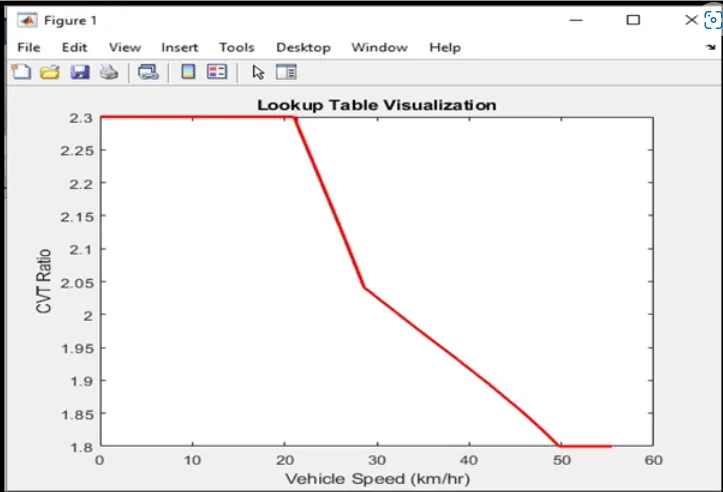
The only Difference between this model and the first model is that in this model, the gear ratio input to CVT is provided using a lookup table rest details and bocks used in the previous case study are same.
CVT Gear Ratio Graph Plot:-
Look-up Table Graph Plot Results:
OUTPUT for CASE 1: comparison
VEHICLE SPEED:
CVT SHAFT RPM:
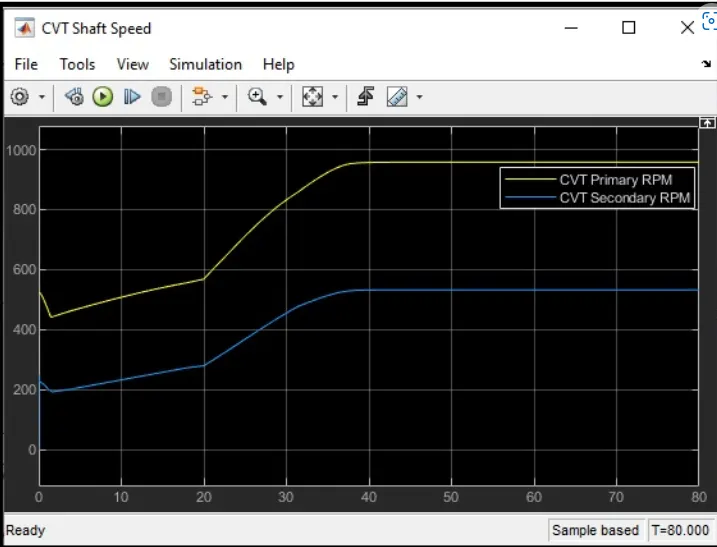
Both results are same as that of the first case: -
SIMULINK MODEL FOR BAJA ATV WITH CVT since the input parameters are same.
CASE STUDY 4:
SIMULINK MODEL FOR BAJA ATV WITH CVT USING LOOKUP TABLE & DASHBOARD
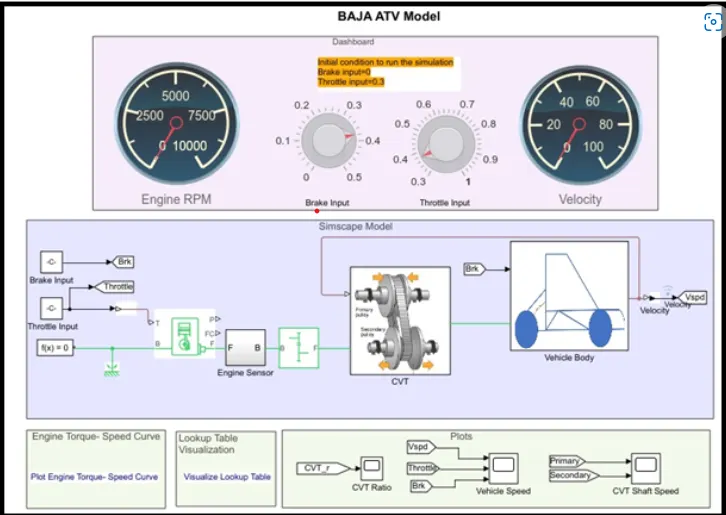
In this model a dashboard is used to control the inputs- ‘Throttle’ & ‘Brake’ with knobs.
OUTPUT GRAPH PLOTS for CASE 4:
VEHICLE SPEED:
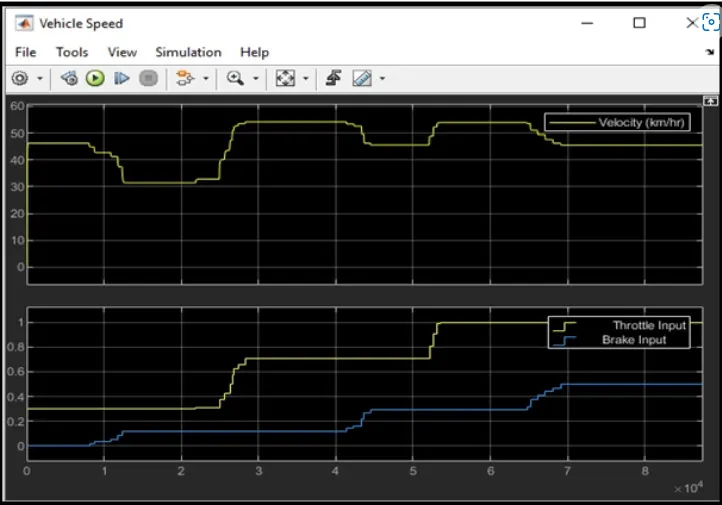
This graph is similar to that of cvt dashboard case. The variation in vehicle velocity can be observed with change in throttle and brake inputs. With increase in braking value, the speed of vehicle decreases. On the other hand, increasing the throttle leads to increased vehicle velocity.
CVT SHAFT RPM:
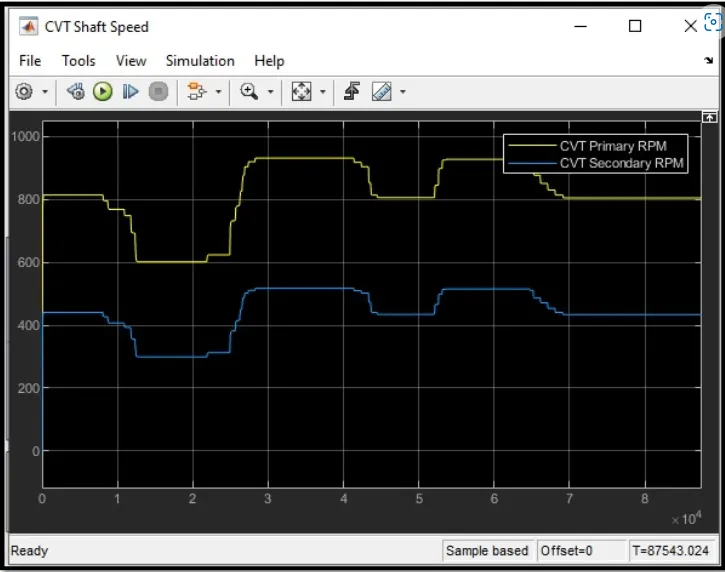
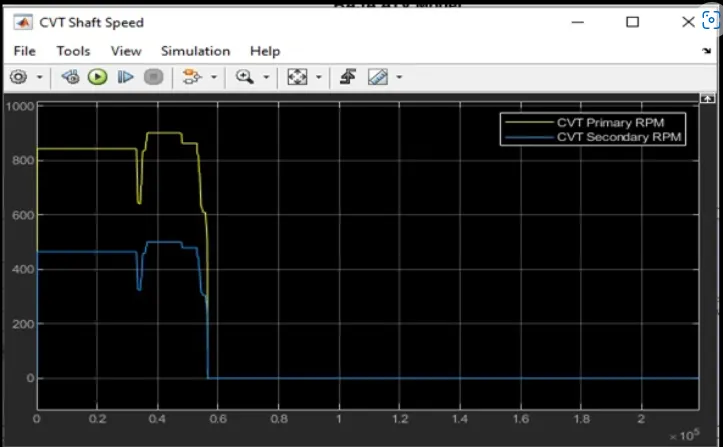
This graph indicates the variation in rpm of primary and secondary shafts with respect to input parameters.
REPORT CONCLUSION:
As we we have successfully analysed 4 different models of BAJA ATV WITH CVT and recorded the outputs: - (Vehicle velocity & CVT shaft rpm) with respect to variations in input throttle and brake.