Project 1 - Wiper control system and Vehicle speed calculation for ABS using Wheel Speed sensor
Question - 1 - Wiper control system
Develop Simulink/state flow model for wiper control system based on the given conditions.
Description of Challenge:
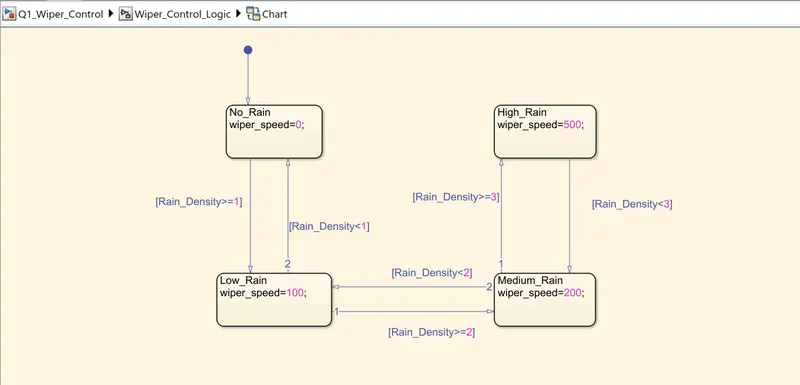
- If the density of the rain is low, then wiper rotates with low speed & the output signal should be 100rpm
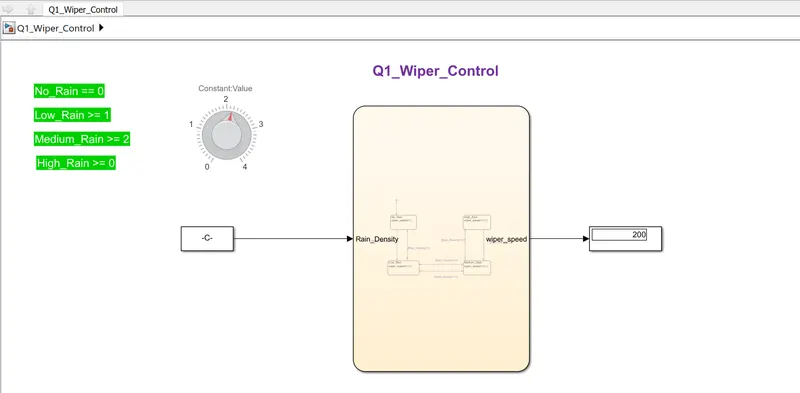
- If the density of the rain is medium, then wiper rotates with medium speed & the output signal should be 200rpm
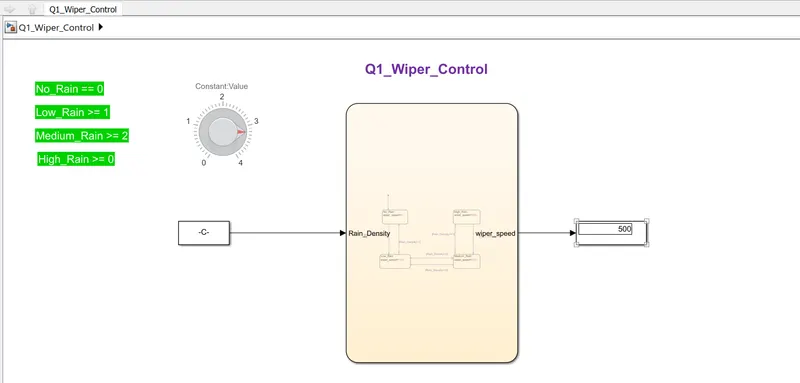
- If the density of the rain is high, then wiper rotates with high speed & the output signal should be 500rpm
Note: Rain density input comes from the external sensor, for the simulation purpose constant block with knob can be taken.
SOLUTION
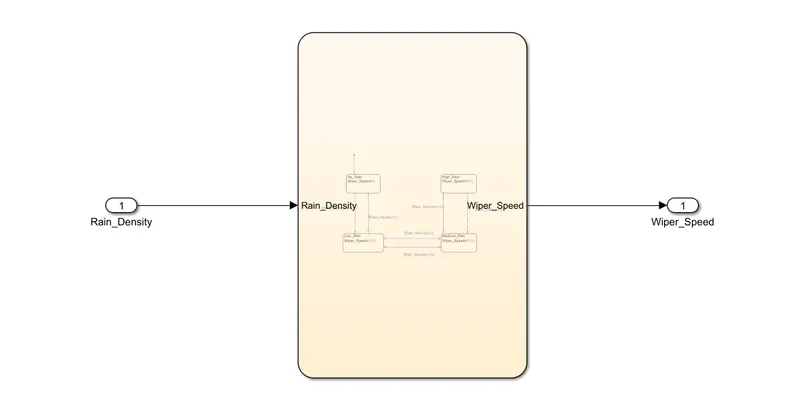
FINAL SIMULINK MODEL
Condition-1. If the density of the rain is low, then wiper rotates with low speed, the output signal should be 100 rpm
Here we taken,
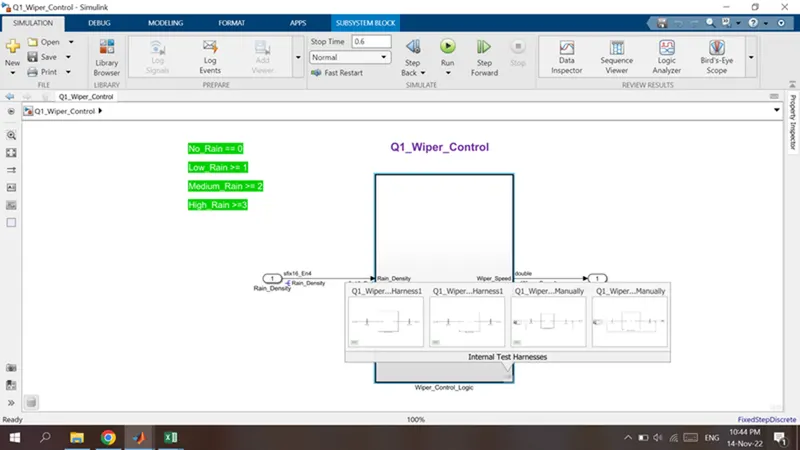
- No_Rain >= 0
- Low_Rain >= 1
- Medium_Rain >= 2
- High_Rain >= 3
Condition-2. If the density of the rain is medium, then wiper rotates with low speed, the output signal should be 200 rpm
Condition-3. If the density of the rain is high, then wiper rotates with low speed, the output signal should be 500 rpm
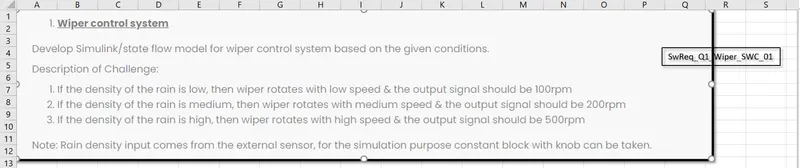
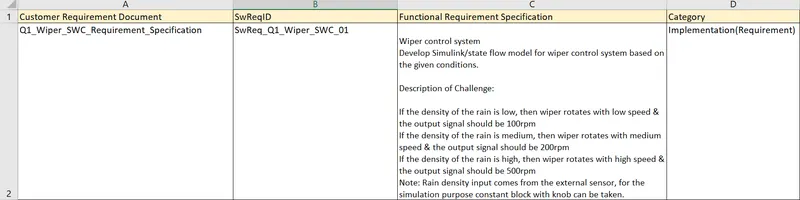
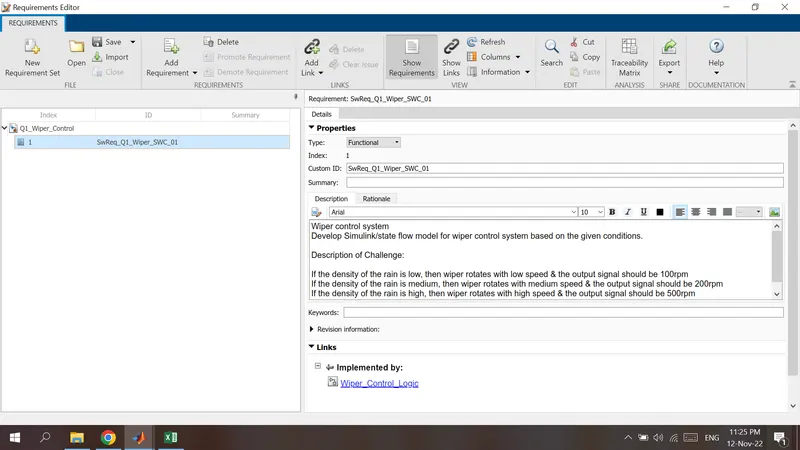
REQUIREMENT TAGGING & REPORT
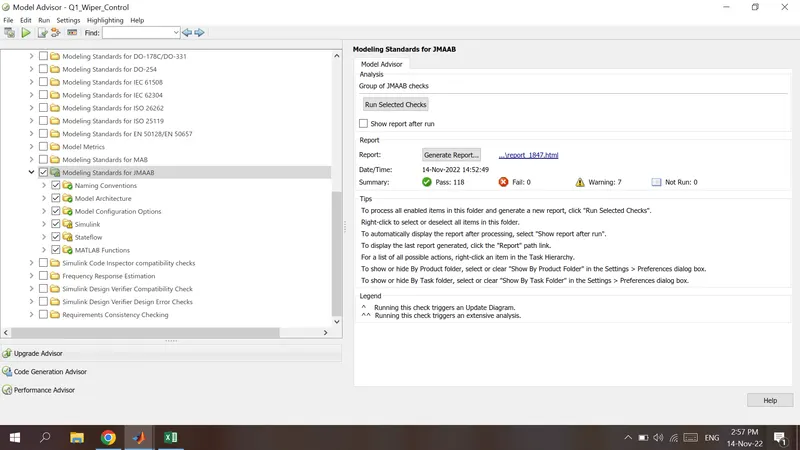
Model Advisor - JMAAB compliance report
FIXED POINT TOOL
We will Apply Proposed Data Types Proposed by Fixed Point Tool
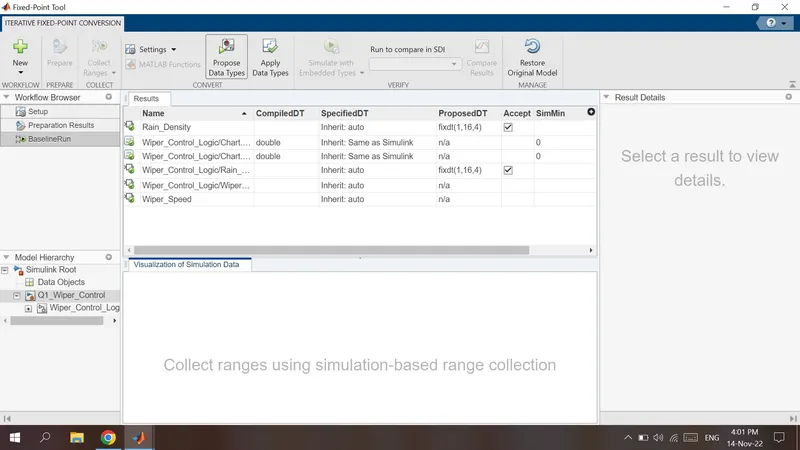
DATA TYPES ARE APPLIED AS BELOW
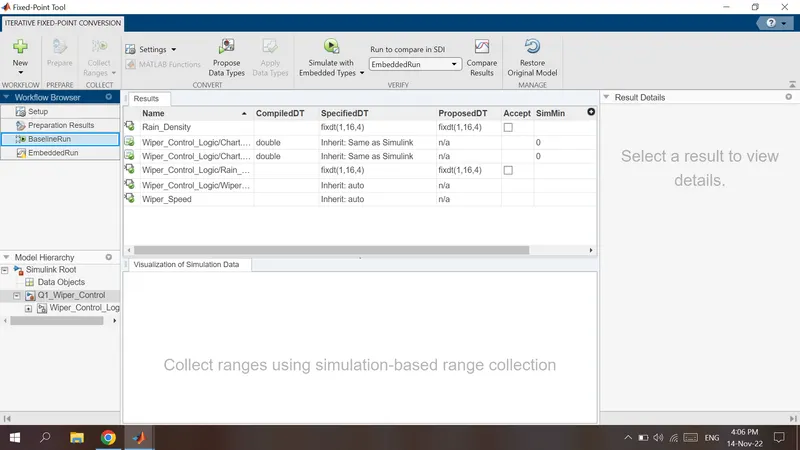
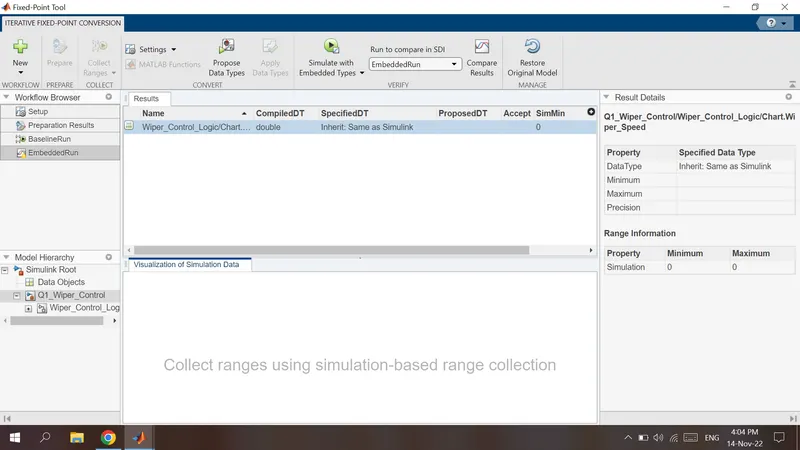
AFTER SIMULATE WITH EMBEDDED TYPES AS BELOW
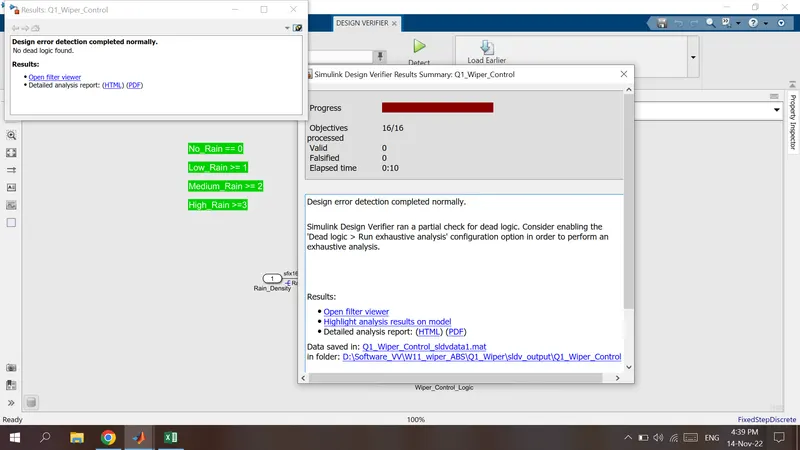
SLDV Design error detection report
SLDV Test Generation Report
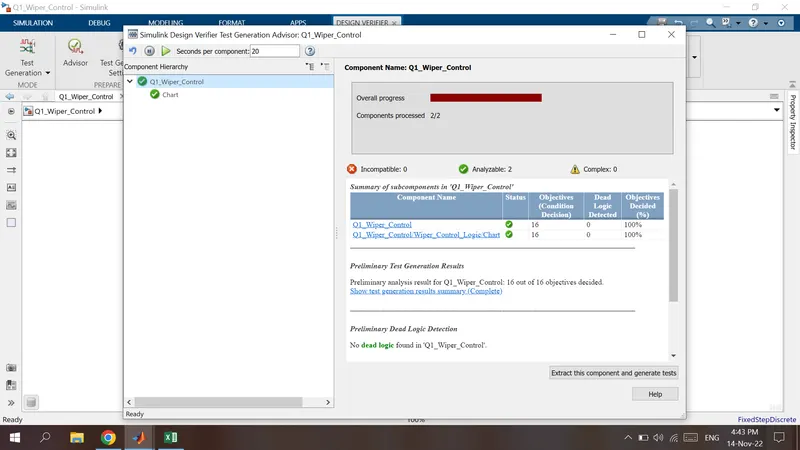
ADVISOR Shows all things are Analyzable
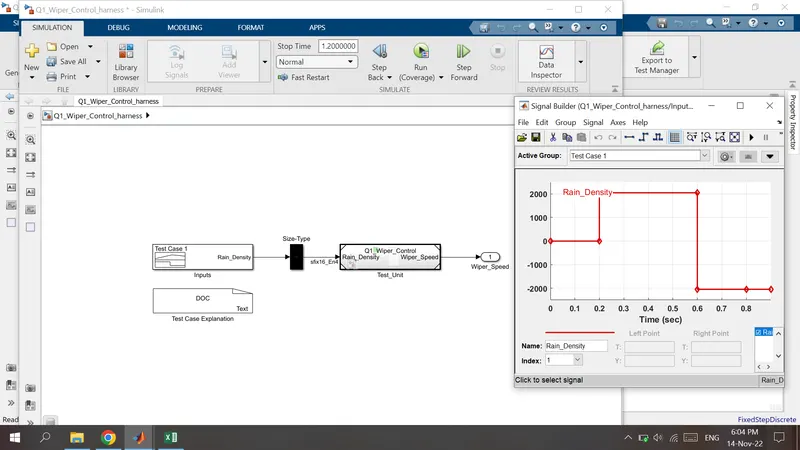
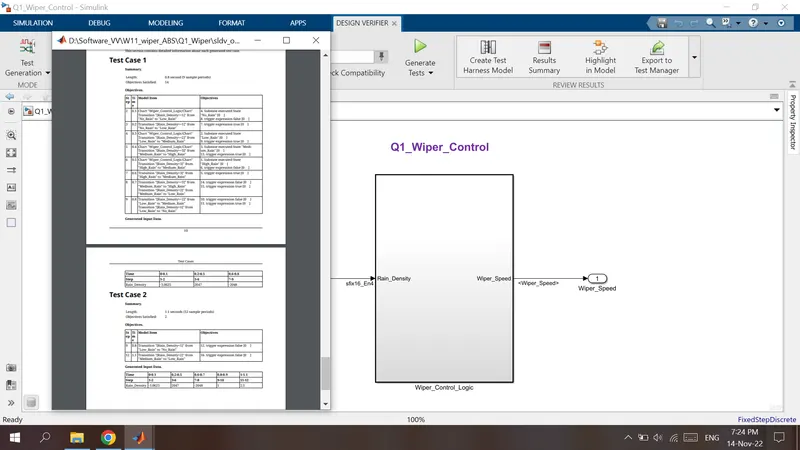
Generated Test Case
There are 2 test cases generated. and we can see it in PDF report.
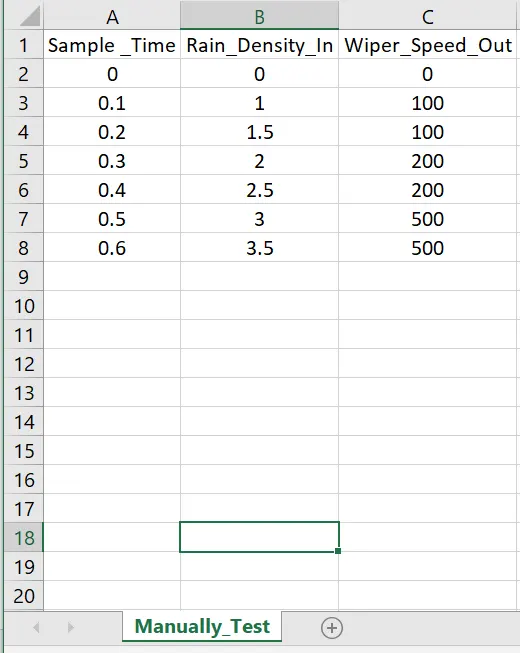
MANUALLY WRITTEN FUNCTIONAL TEST CASE
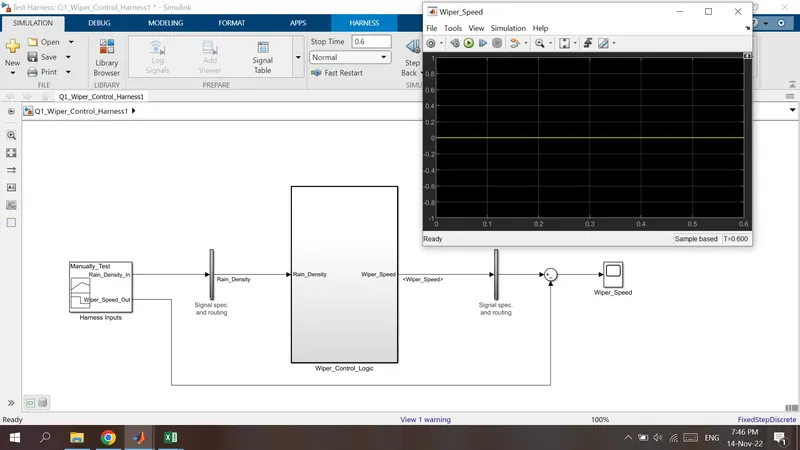
MIL TEST HARNESS OUTPUT
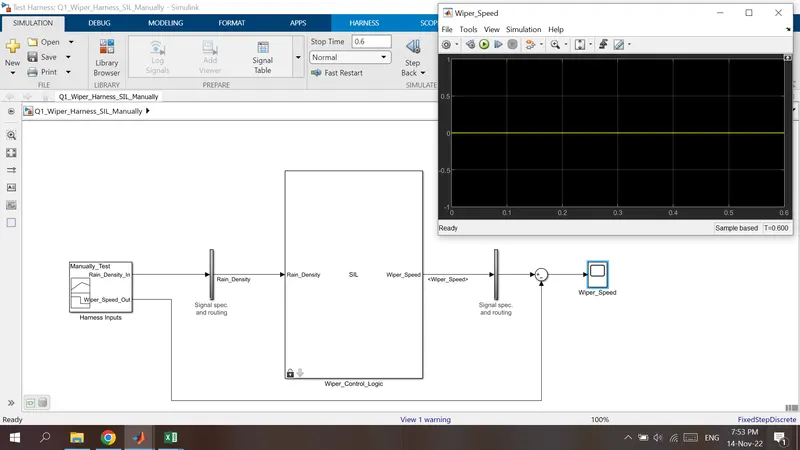
SIL TEST HARNESS OUTPUT
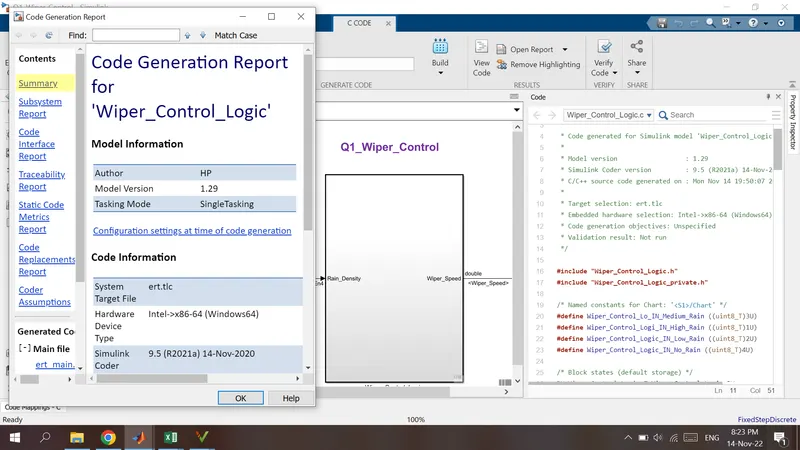
AUTO CODE GENERATION REPORT
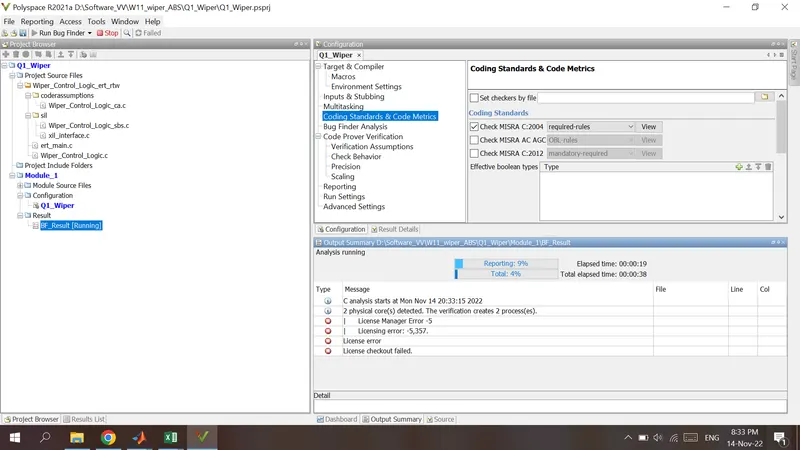
POLYSPACE STATIC ANALYSIS REPORT
We have to Purchase the PolySpace Licence Seperately to Get the full Execution.
Steps :
- Open Polyspace Software
- Start new Project and give name and set storage location
- Project Include Folders >> Select the folder where project(.c) files are saved...
Then, Ensure the Parameter Settings
- Target & Compiler >> Target Processor Type >> x86_64
- Coding Standards and Code Metrices >> Check MISRA C : 2004
- Bug Finder Analysis >> Default
- Reporting >> Generate Report
Then, SAVE & RUN......
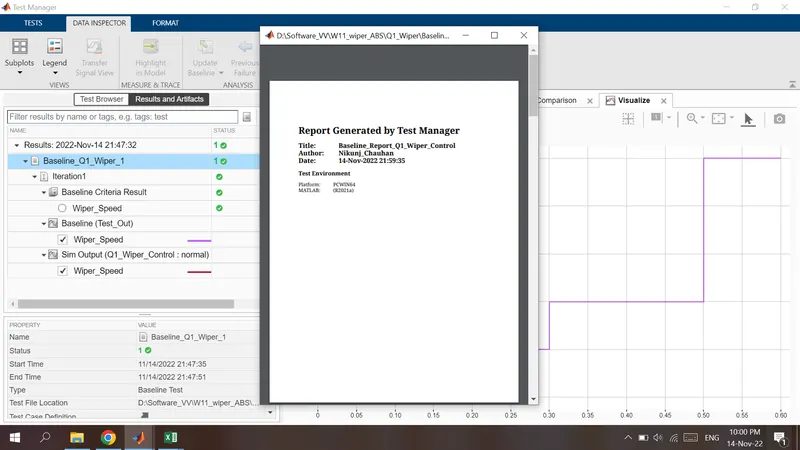
SIMULINK TEST MANAGER REPORT
BASELINE TEST
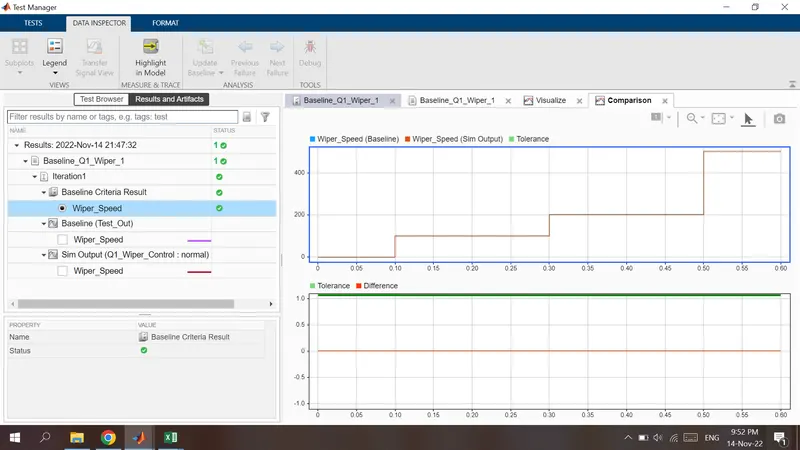
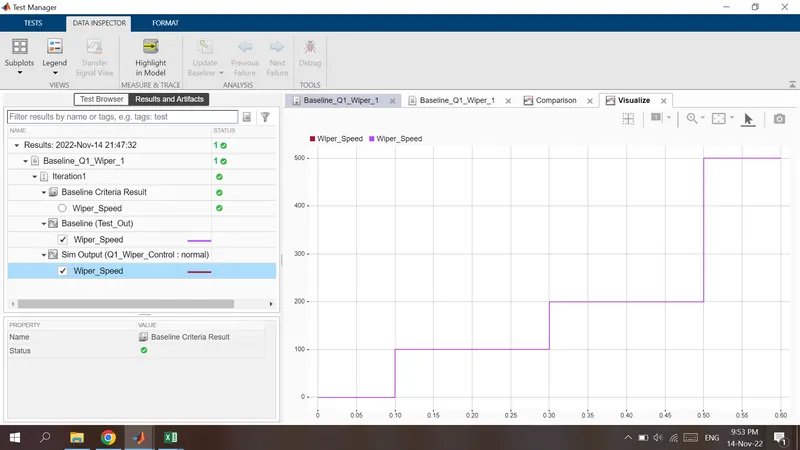
We got the Same Result as per,
Baseline(Test_Out) and Sim_Out
BACK TO BACK TEST
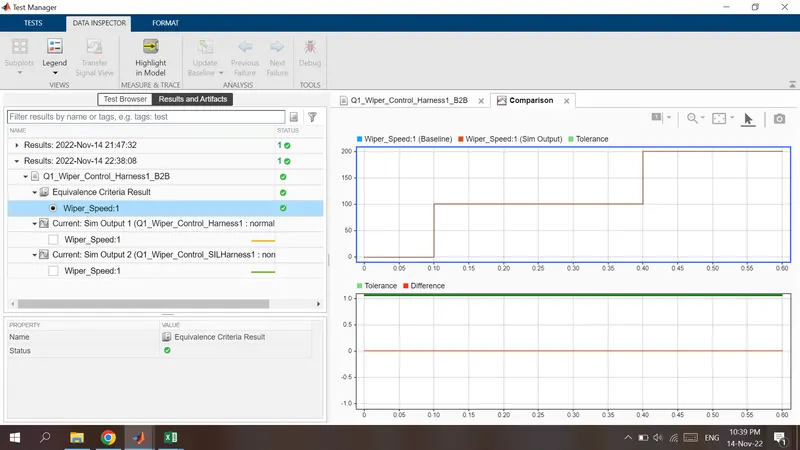
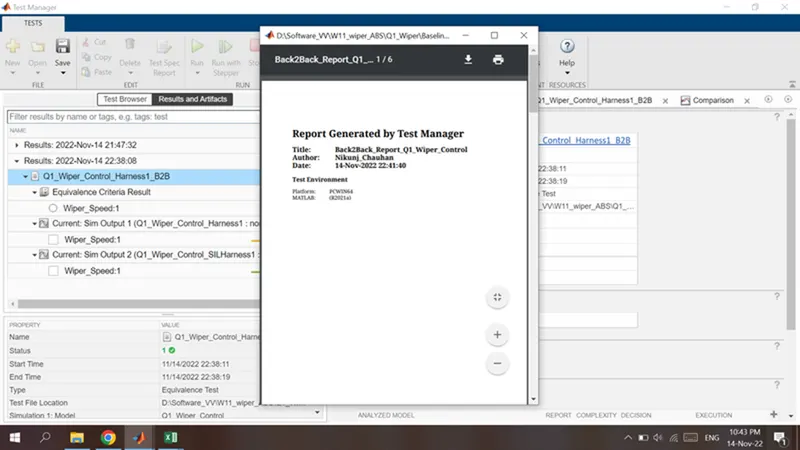
Here Showing 4 harness Models
2 nos are Manually Created for Challenge
2 nos Automatically Generated By Back to Back Test...
.....................................Q1........end...............................................
Question - 2 - Vehicle speed calculation for ABS using Wheel Speed sensor
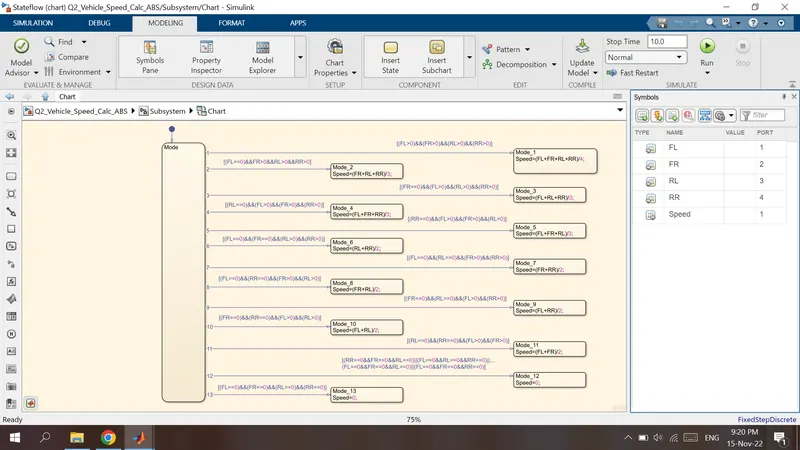
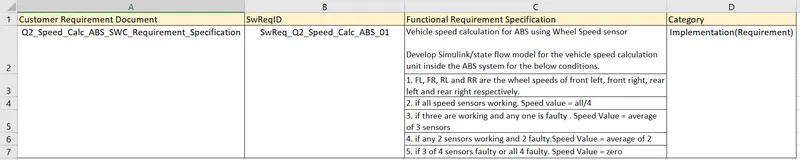
Develop Simulink/state flow model for the vehicle speed calculation unit inside the ABS system for the below conditions.
Description of Challenge:
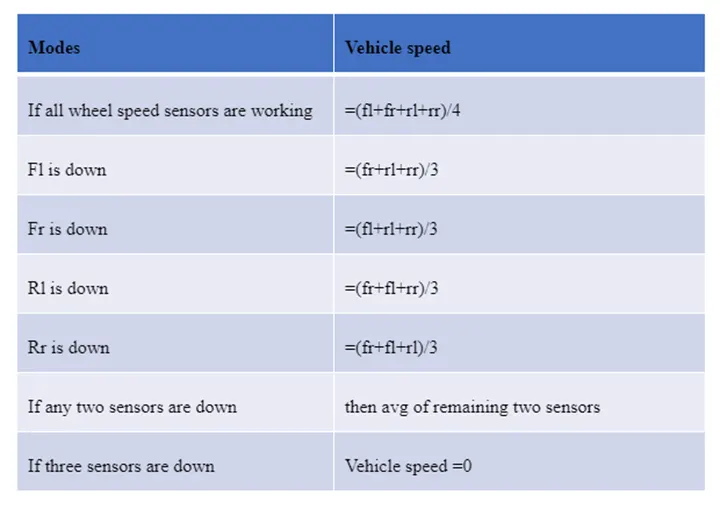
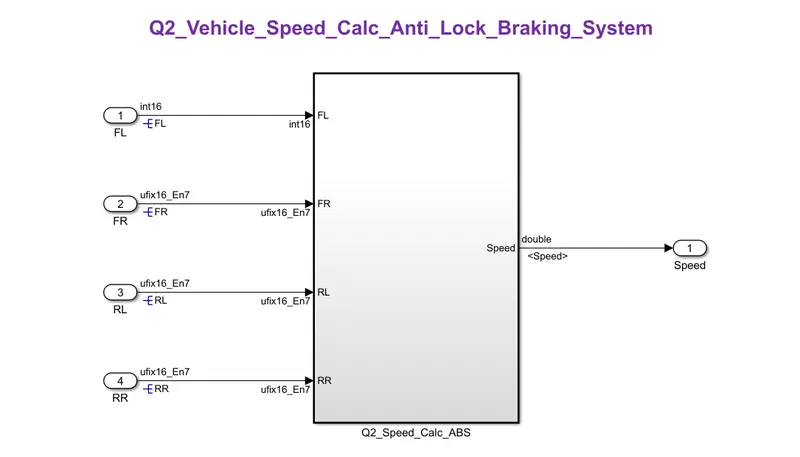
fl, fr, rl and rr are the wheel speeds of front left, front right, rear left and rear right respectively.
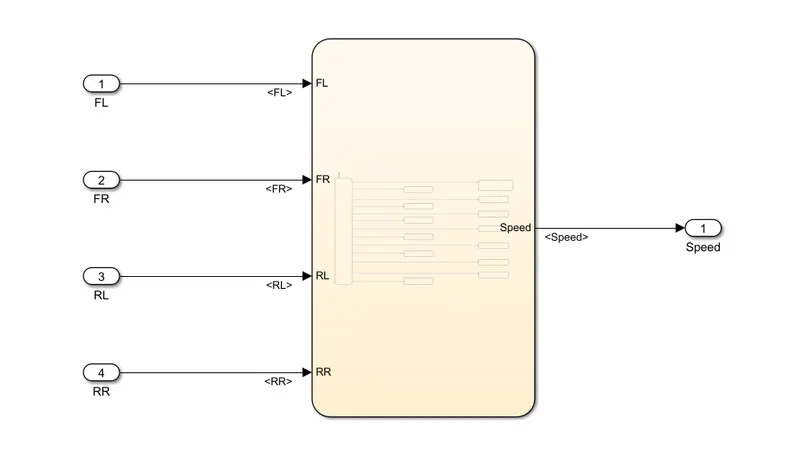
FINAL SIMULINK MODEL
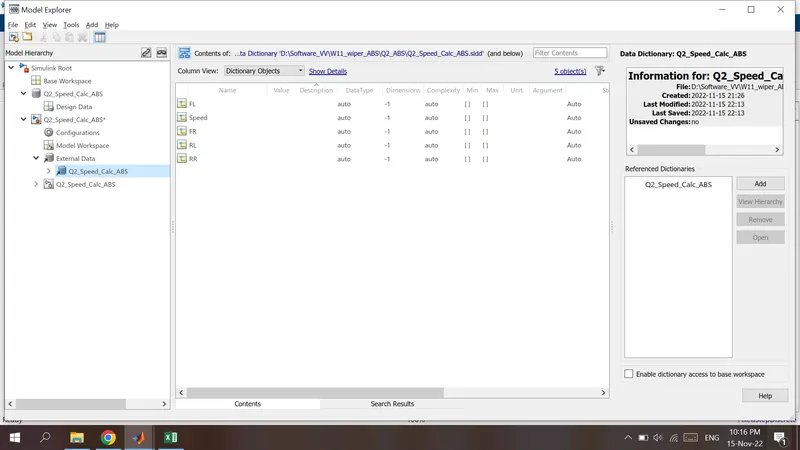
SLDD FILE
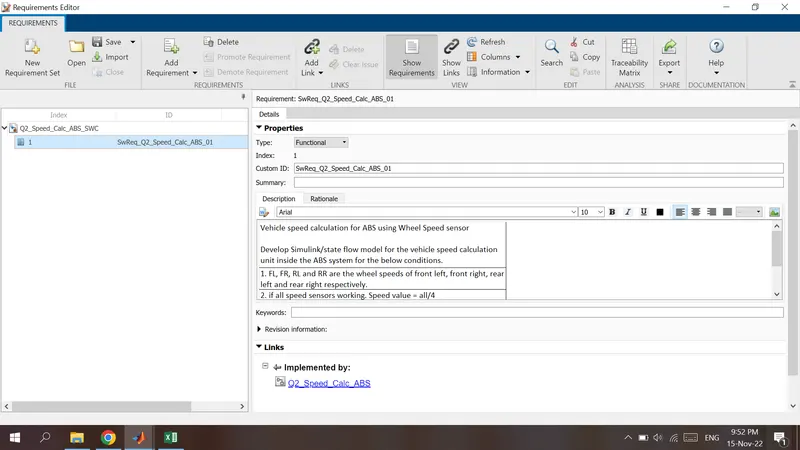
REQUIREMENT TAGGING & REPORT
Model Advisor - JMAAB compliance report
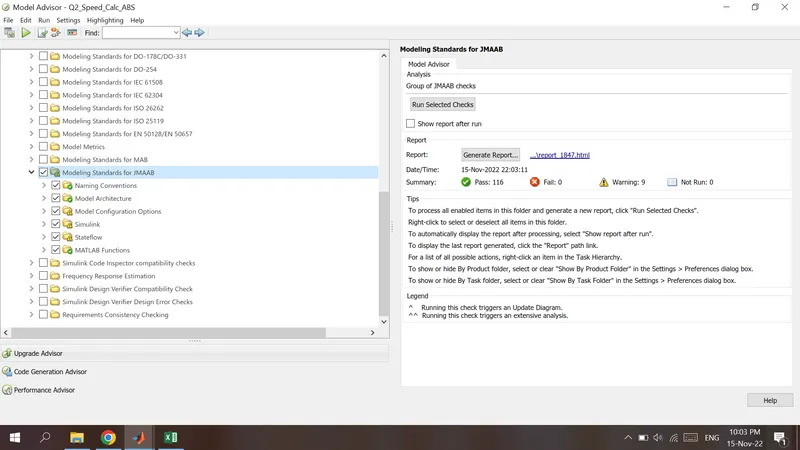
FIXED POINT TOOL
PROPOSED DATA TYPES
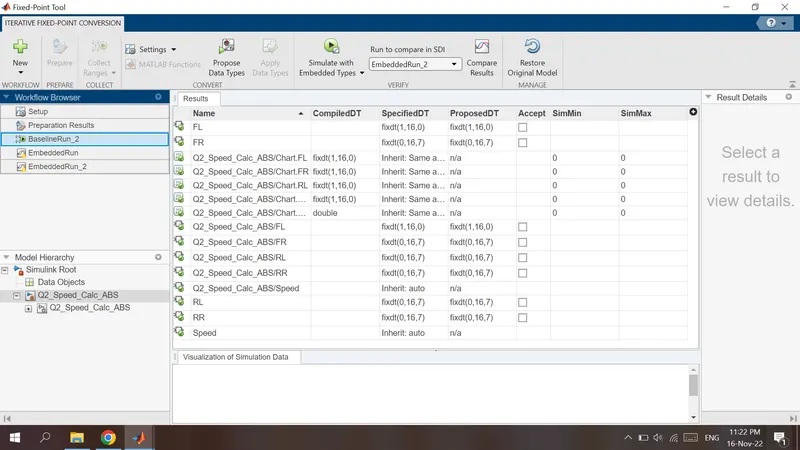
After Simulating with Embedded Types
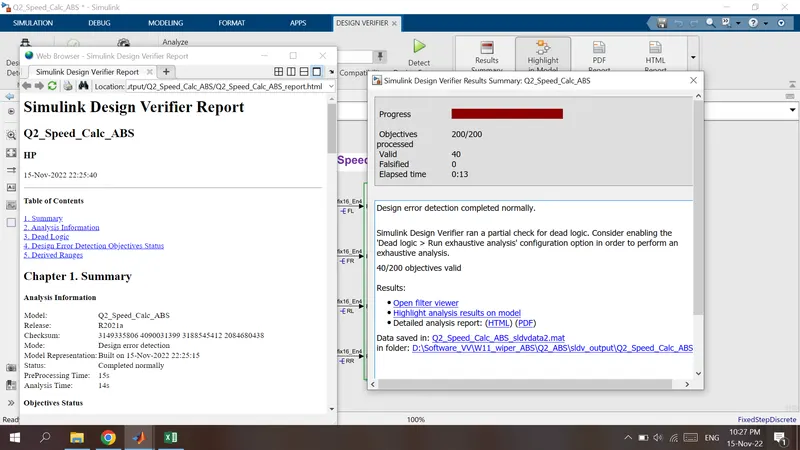
SLDV Design error detection report
SLDV Test Generation Report
Test Advisor
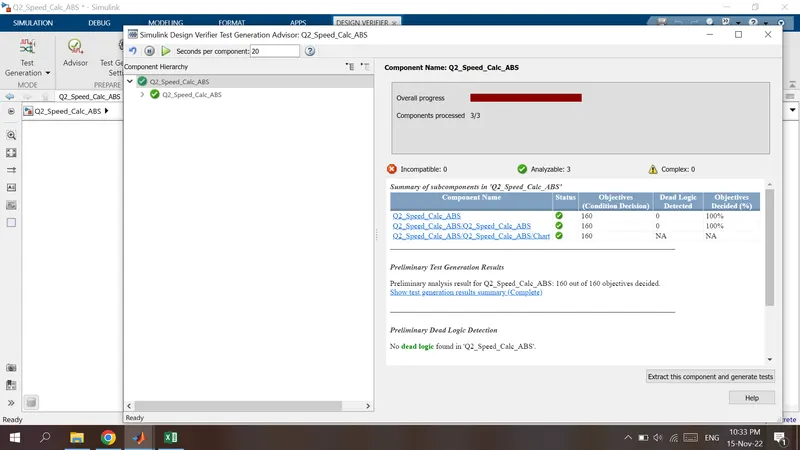
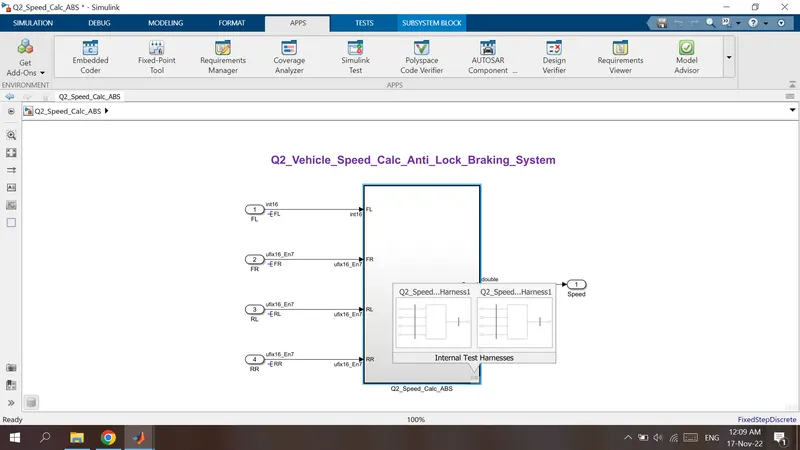
Generated Test Cases and Harness
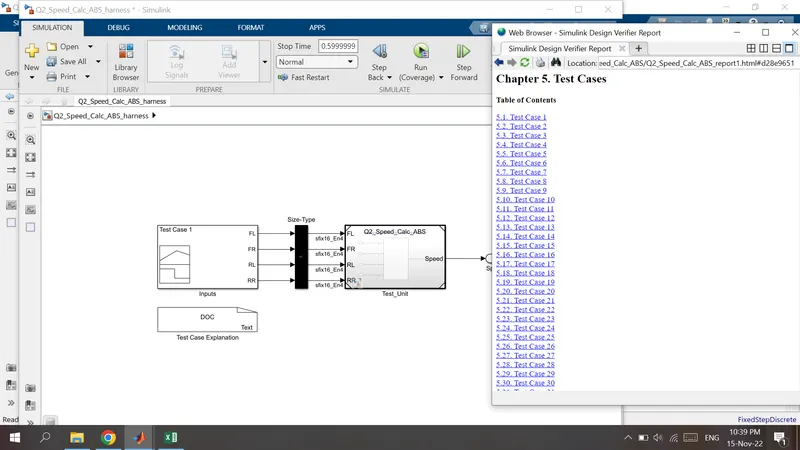
SIMULINK TEST MANAGER REPORT
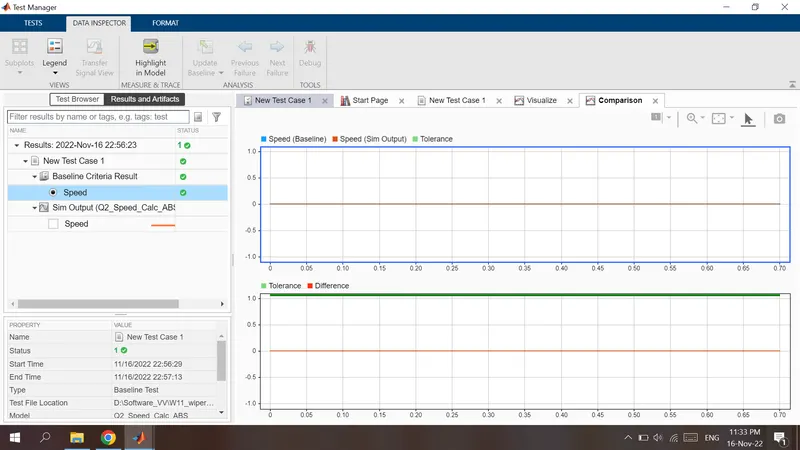
BASELINE TEST
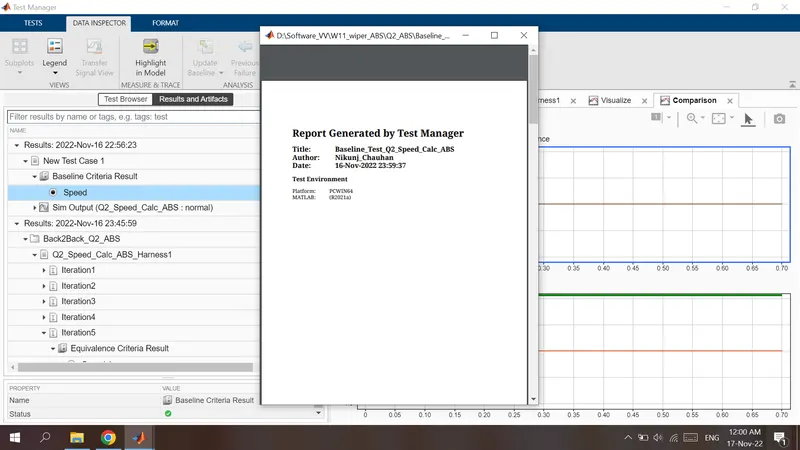
BACK TO BACK TEST
Total 23 Iterations(Test) is Executed Successfully
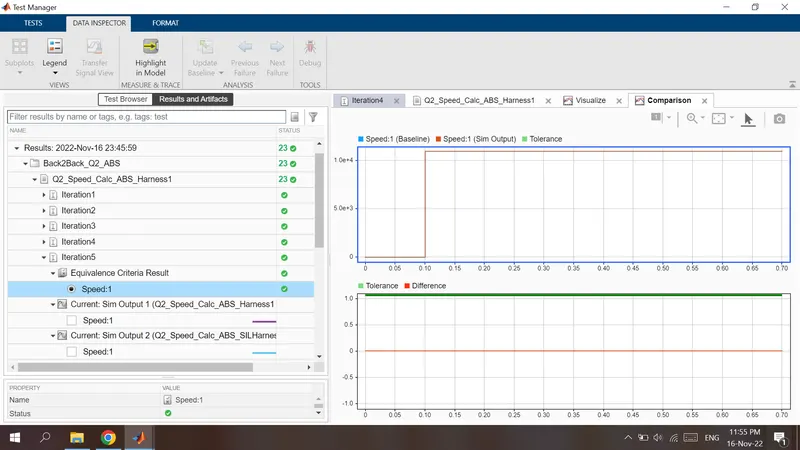
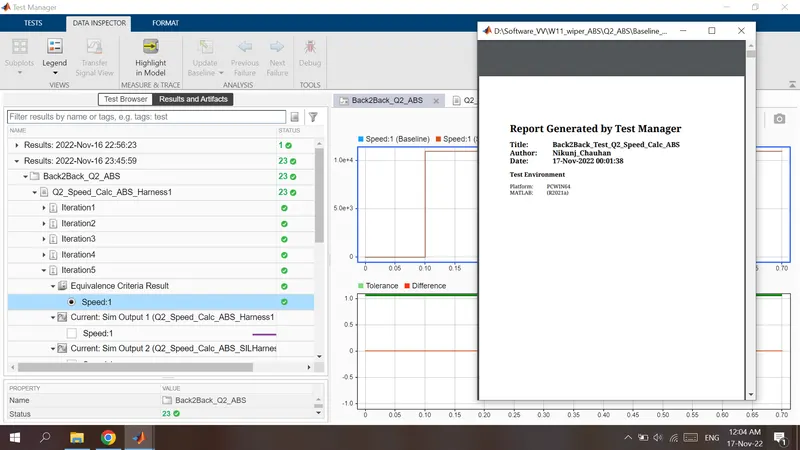
Automatically MIL and SIL Models are Generated
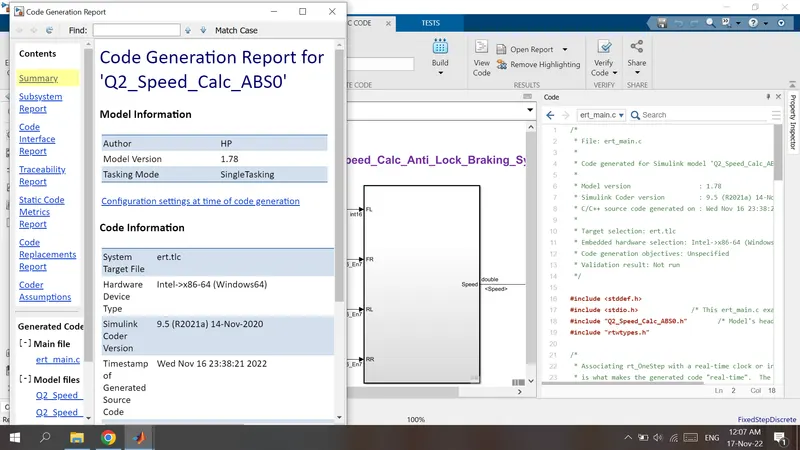
AUTO CODE GENERATION REPORT
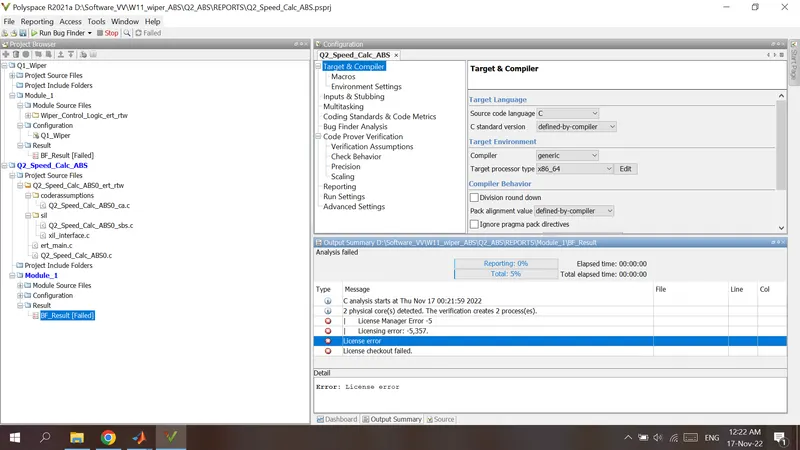
POLYSPACE STATIC ANALYSIS REPORT
We have to Purchase the PolySpace Licence Seperately to Get the full Execution.
...............................................THANK...YOU................................................