Project 1- Traffic Jam Assistant Feature
Data Dictionary:
A data dictionary is a persistent repository of data that are relevant to your model.
we can also use the base workspace to store design data that are used by your model during simulation.
However, a data dictionary provides more capabilities.
The dictionary stores design data, which define parameters and signals, and include data that define the behavior of the model.
The dictionary does not store simulation data, which are inputs or outputs of model simulation that enter and exit Inport and Outport blocks.
In the Current Folder pane of the MATLAB Command Window, navigate to the location of the data dictionary. Double-click the name of the dictionary. In the Model Explorer,
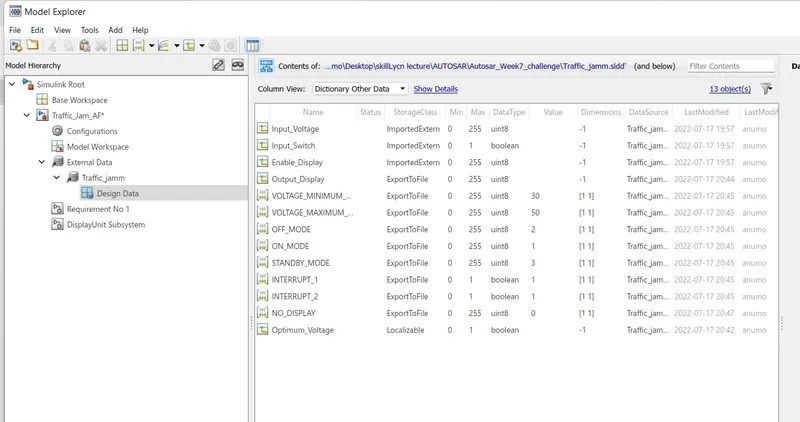
you will see this window .
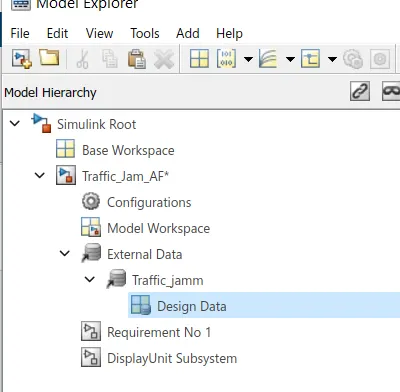
right-click the name of the data dictionary.
here is one file will show by name design data , after click on you we get new blank window .
for creating the comstant and signal , click on add block pop-up window will appers
To add a new Parameter or Signal object to the data dictionary
select Add-> Add Custom... from the Model Explorer menu, and in the dialog box, specify the name of the variable and the class of the variable , as shown below.
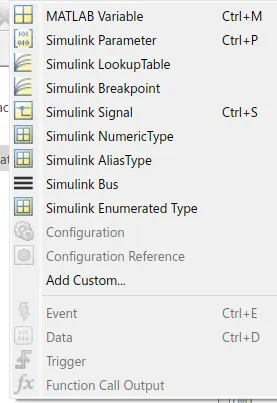
by using simulink parameter we can create const
by using simulink signal we can create signal.and after creating the signal and const with according to the required properties such as min, max, unit then easily create the data dictionary in simulink.
If you have made changes to the dictionary, in the context menu, select Save Changes.
According to the quetions
i have dawnload the attached folder . and created the data dictionary file. the file extension is sldd.
also attched .
Data dictionary columns
| Column | Description |
|---|---|
| Name | The name of the data dictionary entry. The name must conform to the naming convention detailed in Section 8.2.5, “Naming rules”. |
| Value | The value of a calibration constant, 1d or 2d map. A value should not be created for a Simulink signal. |
| Units | The engineering units for this entry (can be restricted to a set of possibilities with a units file (Section 4.2.2.3, “Units file”)). |
| Description | A description of the data dictionary entry. Must not contain single or double quotes. |
| Type | Any one of int8_T, uint8_T, int16_T, uint16_T, int32_T uint32_T, real_T or bool. The type must match the type assigned to the signal by Simulink. |
| Accuracy | The number of decimal digits to display when viewing the data dictionary entry with a calibration tool. For instance, 1 shows no digits after the decimal point, 0.01 shows two digits after the decimal point. |
| Min | The minimum expected value for this data dictionary entry. |
| Max | The maximum expected value for this data dictionary entry. |
| Scale | This column is optional. It specifies the amount by which the displayed value will be scaled from the raw value read from the ECU. |
| Offset | This column is optional. It specifies the amount by which the displayed value will be offset from the raw value read from the ECU. |
| Enums | A comma separated list of data dictionary entries which provide the possible values this data dictionary entry can be. This column is optional. |
| Defn | This column is optional. It specifies the file in which the equivalent C variable for the DDE will be defined. Only applicable when using RTW Embedded Coder, the column is ignored for other auto-coders. |
| Decl | This column is optional. It specifies the file in which the equivalent C variable for the DDE will be declared. Only applicable when using RTW Embedded Coder, the column is ignored for other auto-coders. |
Traffic Jam Assistant Feature
Introduction to the Feature:
Traffic Jam Assistant is one of the most common feature in Advanced Driver Assistance System. Traffic Jam Assistant helps the driver arrive more relaxed at their destination, even in dense traffic or in traffic jams. As a partially automated comfort function, the system takes over the longitudinal & lateral guidance of the vehicle. This means that the car can drive off, accelerate & brake automatically, as well as steer the vehicle within certain constraints. The driver has to permanently supervise the system & be ready to take over the complete control of the vehicle at any time.
Traffic Jam Assistant system helps to avoid rear end collisions in dense traffic conditions & traffic jams. In Traffic jams, the vehicle takes over driving off, acceleration, braking and steering within same lane.
Basic Working Principle:
Traffic Jam Assistant is based on the sensors and the functionality of the Adaptive Cruise Control (ACC) with stop & go and Lane Keeping Support (LKS). When ACC ‘Stop & Go’ is turned ON, the Traffic Jam Assistant continuously analyses the speed of the surrounding vehicles and compares it with the own driving speed. If the system detects dense traffic or a traffic jam at speeds less than 60 kmph, the driver can activate the functionality by press of a button. The vehicle will now automatically follow the vehicle in front, takes over driving off, acceleration, braking and steering within same lane.
Information regarding the Traffic Jam Assistant will be available to be displayed to the driver in the Instrument Panel Cluster (IPC). The Algorithm which the students need to implement here in this project is predominantly based on IPC units.
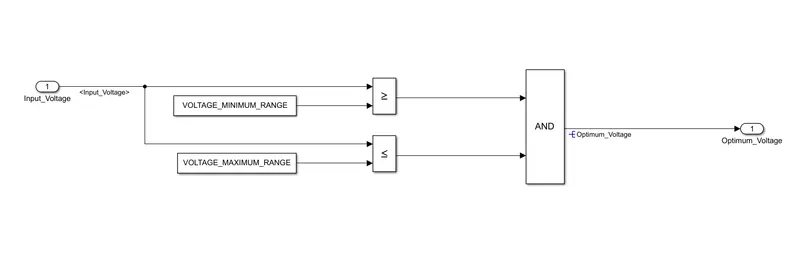
Requirement No 1:
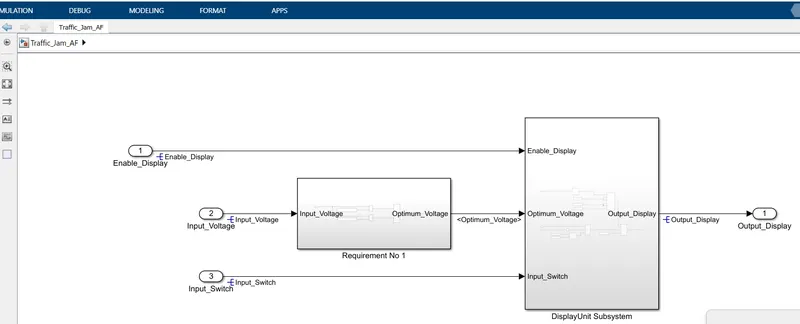
- Input Signal “Input_Voltage” is compared against voltage values “VOLTAGE_MINIMUM_RANGE” & “VOLTAGE_MAXIMUM_RANGE”.
- Incoming input signal “Input_Voltage” must be greater than – equal to “VOLTAGE_MINIMUM_RANGE” and less than – equal to “VOLTAGE_MAXIMUM_RANGE”.
- Output signal from here is “Optimum_Voltage” which will be one of the inputs to the subsystem “DisplayUnit”.
Requirement No 2 (DisplayUnit Subsystem):
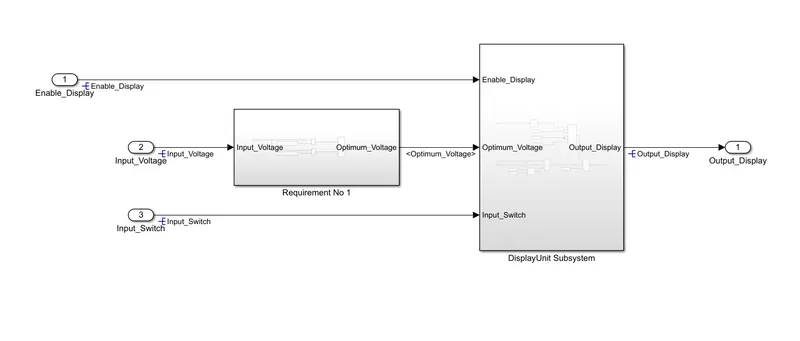
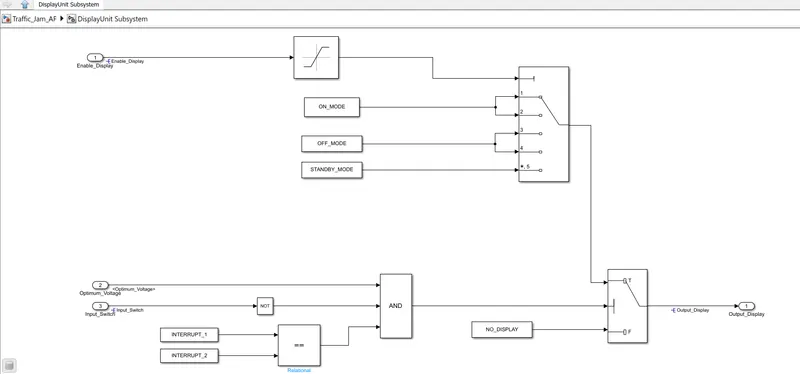
- Input Signals are “Optimum_Voltage”, “Input_Switch”,“Enable_Display”. Signal “Enable_Display” must be saturated between the range 0 – 7. Output signal from the subsystem is “Output_Display”.
- Input Signal “Enable_Display” is compared against pre – defined set of values in a multiport switch. Total data ports in the multiport switch is 5.
- Multiport switch inputs 1 & 2 is connected to calibration signal “ON_MODE”, Multiport switch inputs 3 & 4 is connected to calibration signal “OFF_MODE” while Multiport switch input 5 is connected to calibration signal “STANDBY_MODE”.
- The output from Multiport switch is connected to the first input port of the Switch block. The third input port of the Switch block is connected to the calibration signal “NO_DISPLAY”.
- Meanwhile NOT value of input signal “Input_Switch” is compared in an AND gate against input signal “Optimum_Voltage” and the output from comparing if calibration signals “INTERRUPT_1” & “INTERRUPT_2” are equal. The output of the AND gate is the second input of the switch block.
- The output from the switch block is “Output_Display”.
after that i have attached word document.
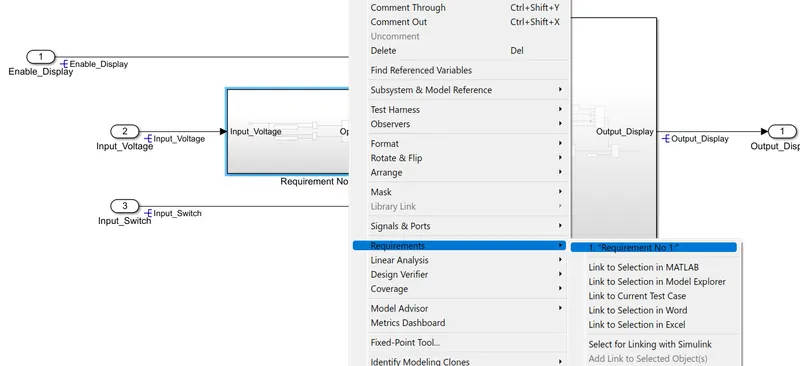
main model