Project-1: Modelling an electric Car with Li-ion battery
ANSWER
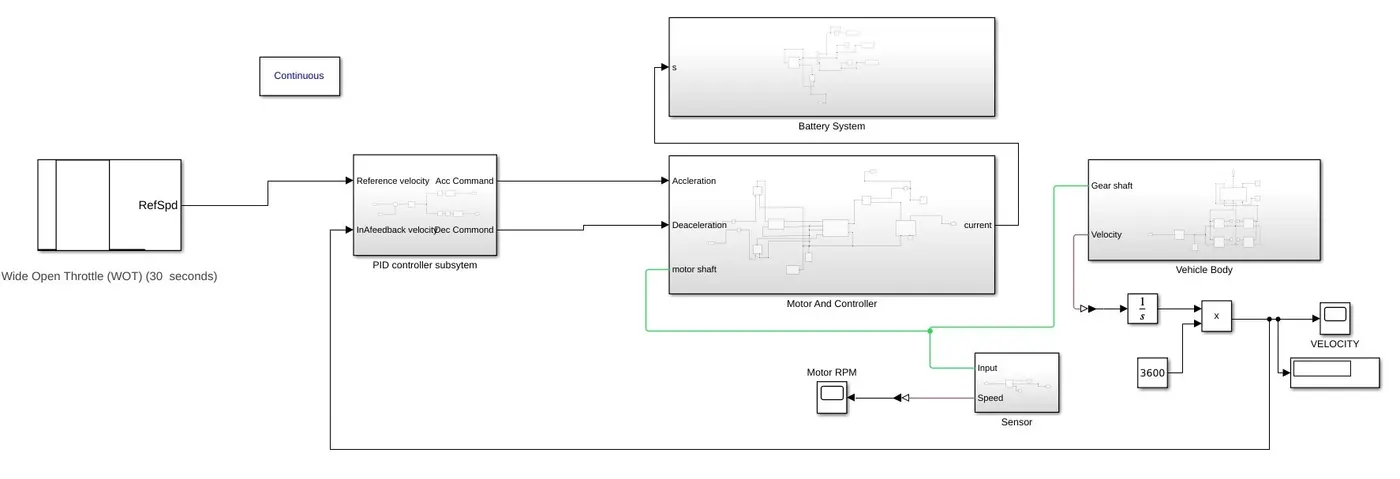
System level configuration:
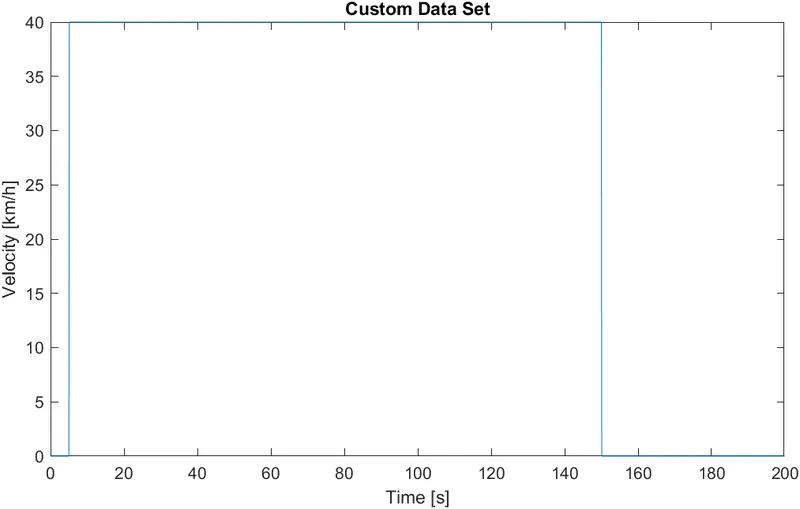
Drive cycle:
PID controller subsystem:
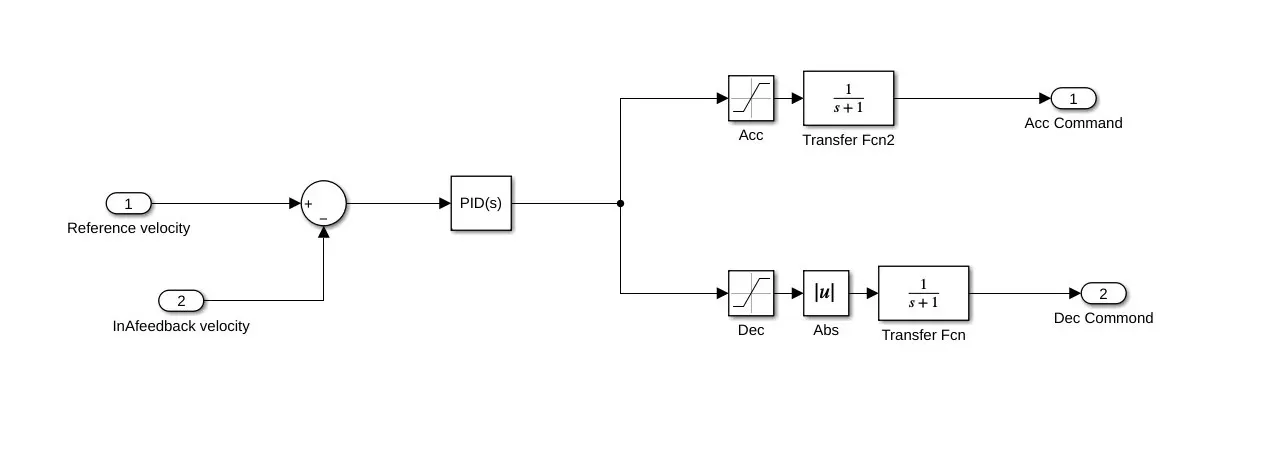
This Sum block subtracts feedback velocity from reference velocity and then output is given to pid controller.The output from the sum block is given to PID controller block, the output is generated.
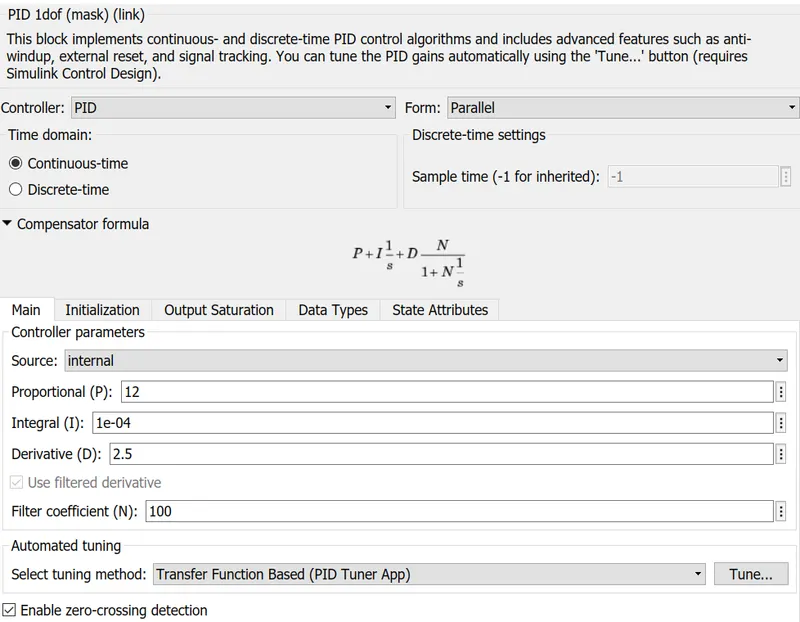
PID Controller:
PID Controller parameter:
Saturation Block:
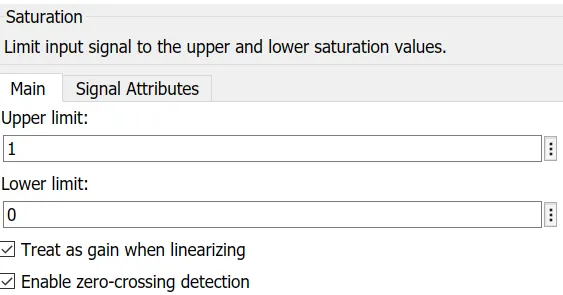
Acceleration Parameters:
Deceleration Parameters:
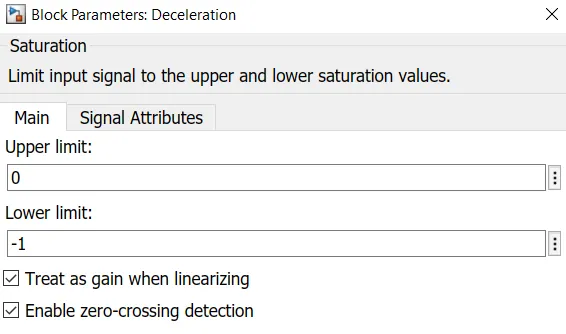
This block helps to limit the output signal from pid controller and separate deceleration and acceleration values.
The output from these blocks is sent to a transfer function then these are provided to motor controller block.
Motor Controller Subsystem:
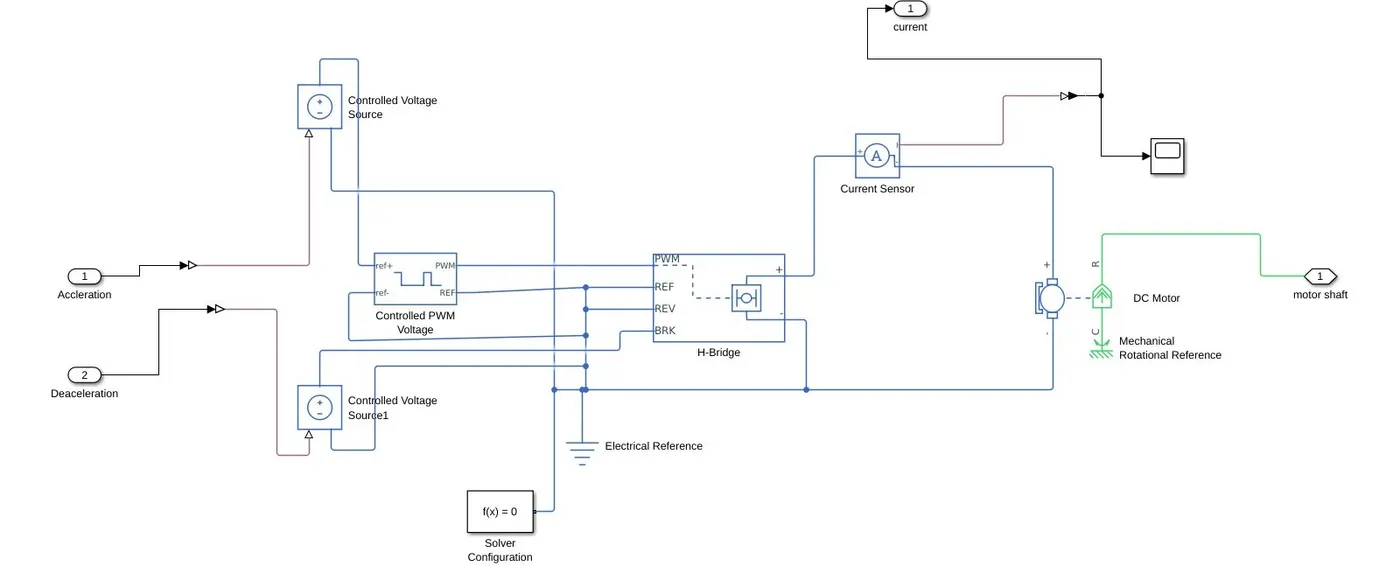
- Controlled Voltage Source:
-
The Controlled Voltage Source block represents an ideal voltage source that is powerful enough to maintain the specified voltage at its output regardless of the current flowing through the source.
-
The output voltage is V = Vs, where Vs is the numerical value presented at the physical signal port.
-
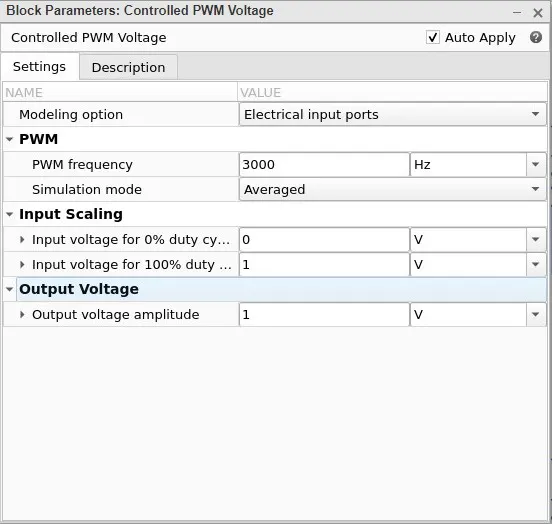
- Controlled PWM Voltage:
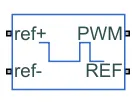
- The Controlled PWM Voltage block represents a pulse-width modulated (PWM) voltage source. The block has two modeling variants,
-
Electrical input ports — The block calculates the duty cycle based on the reference voltage across its ref+ and ref- ports. This modeling variant is the default.
-
PS input — Specify the duty cycle value directly by using an input physical signal port.
-
For the Electrical input ports variant of the block, the demanded duty cycle is
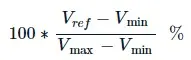
where:
-
Vref is the reference voltage across the ref+ and ref- ports.
-
Vmin is the minimum reference voltage.
-
Vmax is the maximum reference voltage.
PWM parameter:
H BRIDGE:
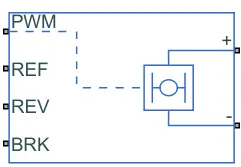
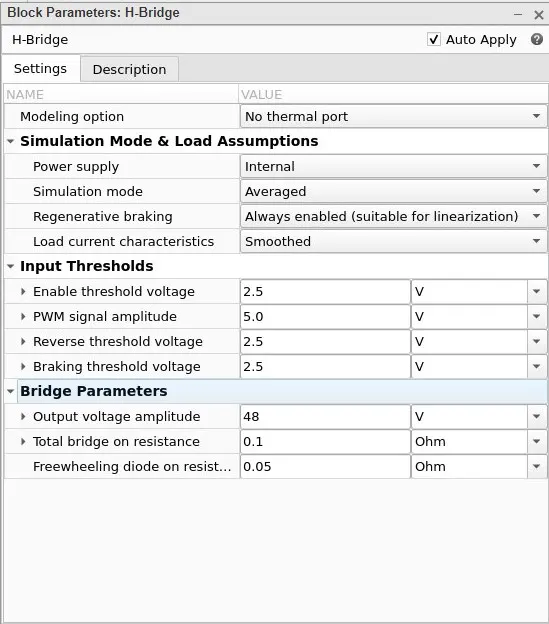
This block is used to change the polarity of the voltage applied across the DC motor so as to run the motor in forward and reverse direction as per the input command.
H BRIDGE Parameter:
Current Sensor:
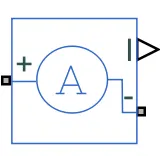
This block is used to measure the flow of current through a circuit.
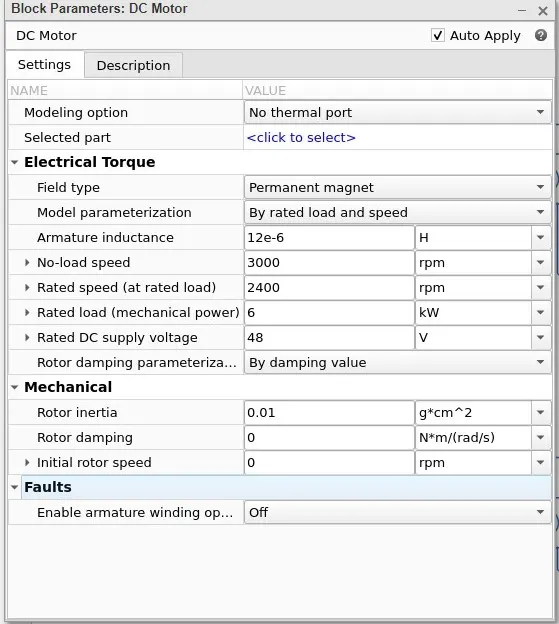
DC Motror:
Sensor:
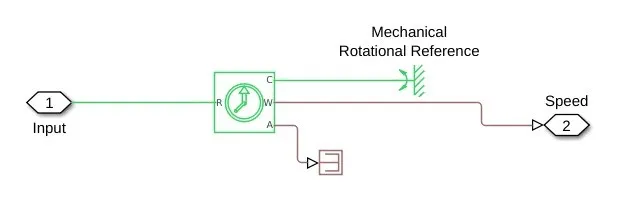
Ideal Rotational Motion Sensor Block:

The output from this block is in rad/sec. so, unit conversion is done in ps-simulink converter block.
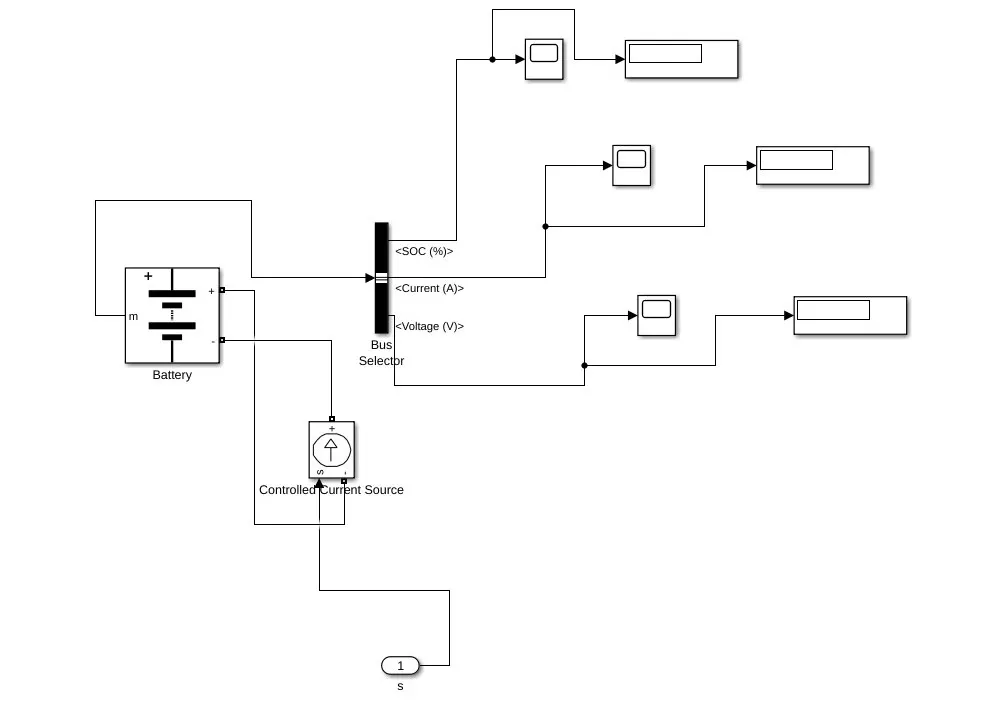
Battery Subsystem:
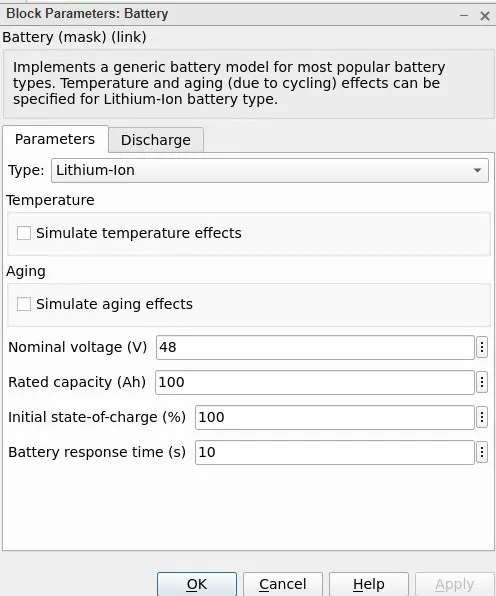
Battery Parameter:
Controlled Current Source:
- The Controlled Current Source block converts the Simulink input signal into an equivalent current source. The generated current is driven by the input signal of the block.
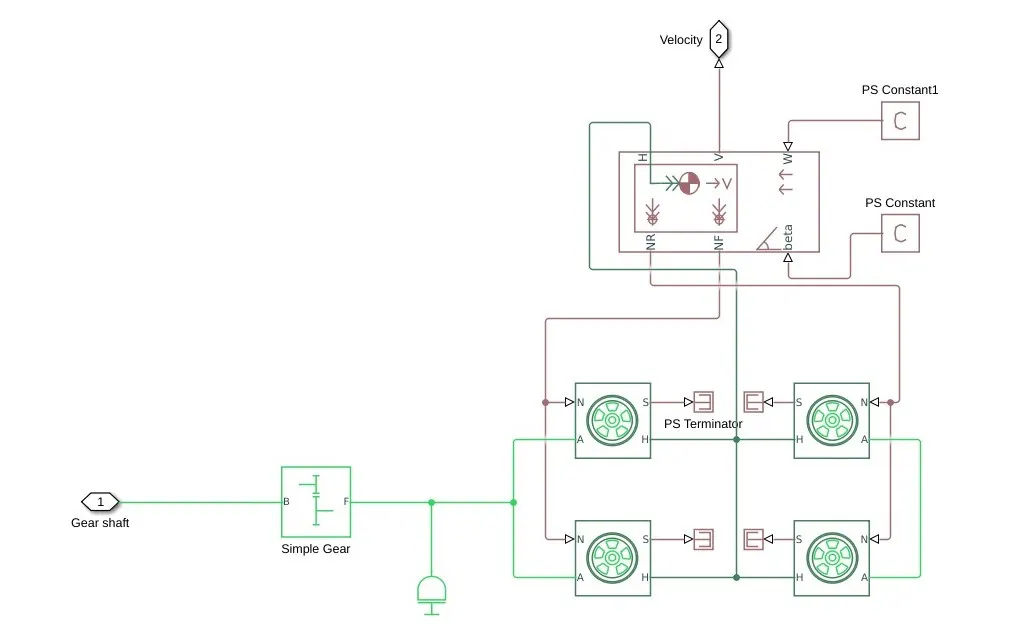
Vehicle Body Subsystem:
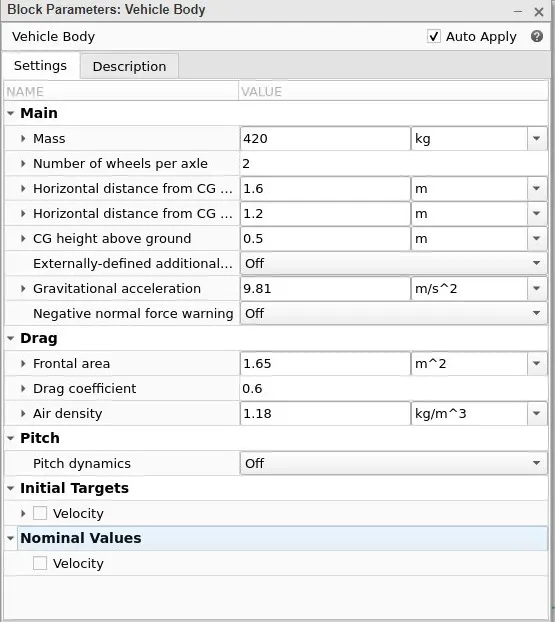
Vehicle Parameter:
- The Vehicle Body block represents a two-axle vehicle body in longitudinal motion. The vehicle can have the same or a different number of wheels on each axle. For example, two wheels on the front axle and one wheel on the rear axle. The vehicle wheels are assumed identical in size. The vehicle can also have a center of gravity (CG) that is at or below the plane of travel.
- The block accounts for body mass, aerodynamic drag, road incline, and weight distribution between axles due to acceleration and road profile. Optionally include pitch and suspension dynamics. The vehicle does not move vertically relative to the ground.
- The block has an option to include an externally-defined mass and an externally-defined inertia. The mass, inertia, and center of gravity of the vehicle body can vary over the course of simulation in response to system changes.
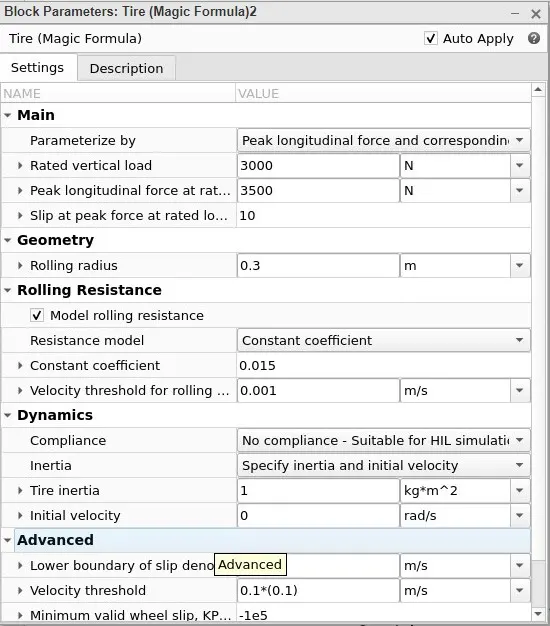
Tire Parameter:
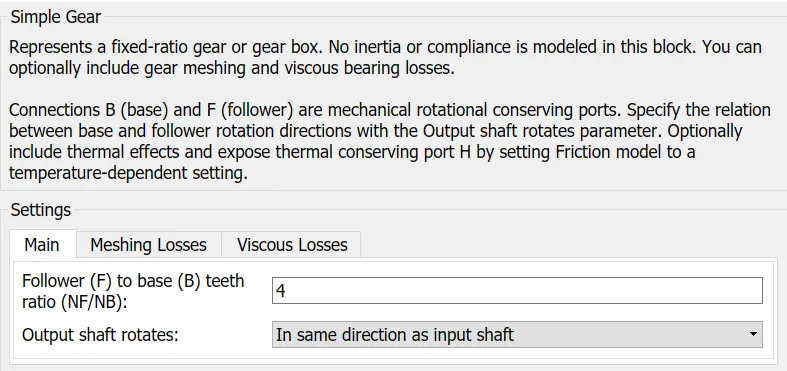
Fixed Gear:
- The Simple Gear block represents a gearbox that constrains the connected driveline axes of the base gear, B, and the follower gear, F, to corotate with a fixed ratio that is specified.
Distance Travelled (km):
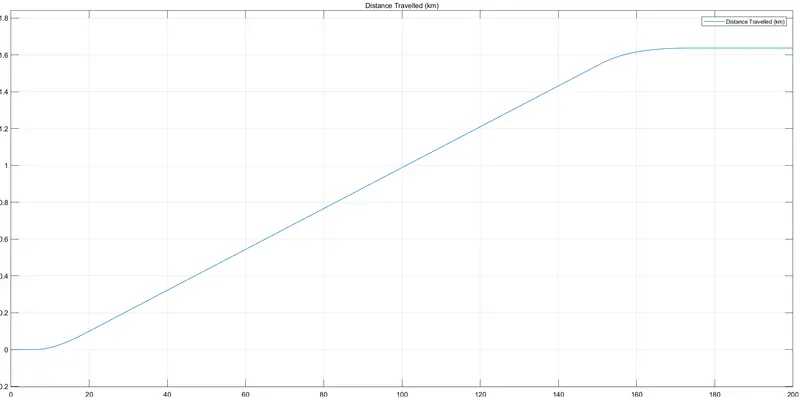
Distance Travelled is 1.64km
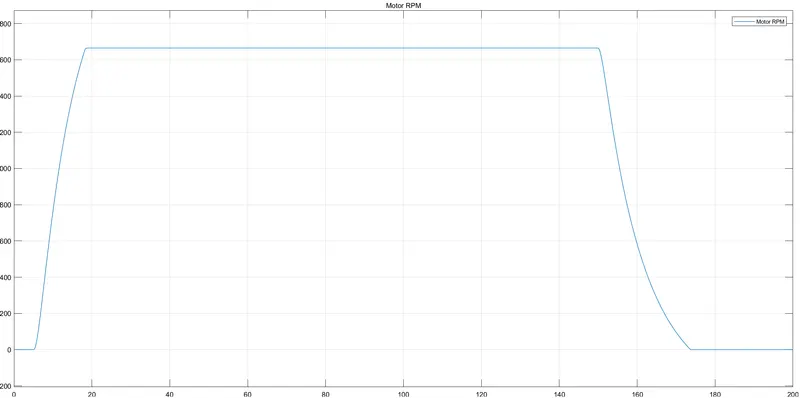
Motor RPM:
SOC (%):
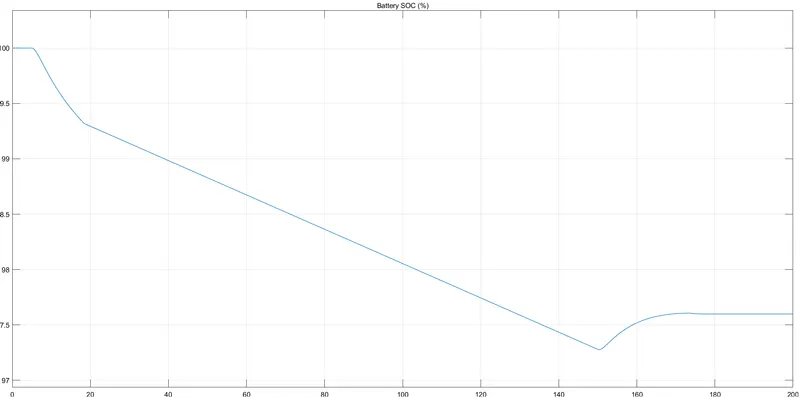
Battery SOC dropped to 97.25%
Conclusion:
MATLAB model of electric car which uses lithium-ion battery and suitable motor is created.