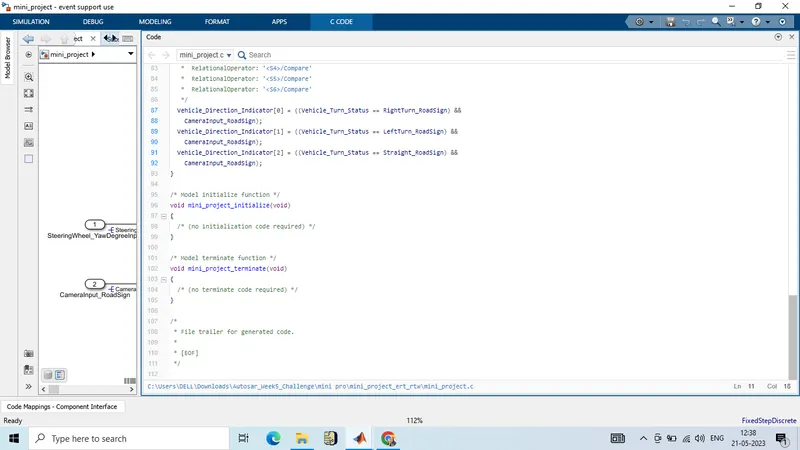
Project 1 (Mini Project on Vehicle Direction Detection
Overview:
Identifying the direction of the vehicle is one of the important & diverse features in Autonomous driving & Advanced Driver Assistance Features. This particular sub-feature of identifying the direction of vehicle is basically identifying the direction the vehicle is taking based on the camera input.
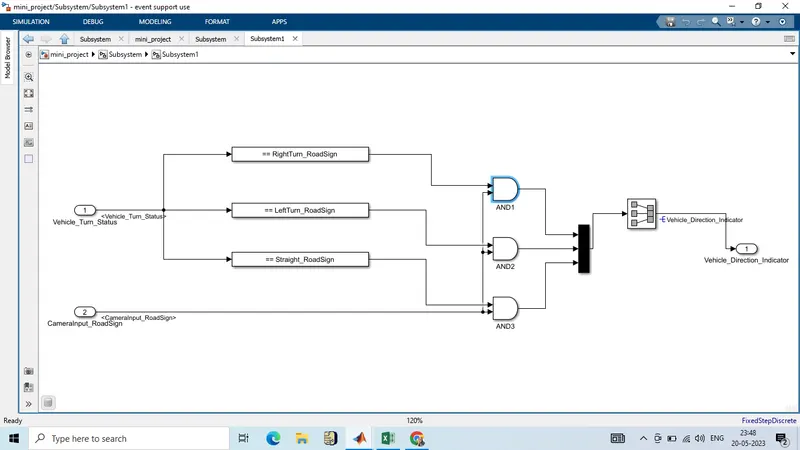
Camera reads the road signs & stores into its memory with unique values for left turn, right turn & straight drive. Depending on the direction it is taking, final indication is given to the driver – as an indication if he is driving in the recommended direction or not.
Vehicle Direction Determination can also be coupled along - side features like GPS systems to identify whether the vehicle is reaching its destination in an optimized manner. This sub feature can also be used along with Lane Detection, Highway Warning, Ramp Entry / Exit in Wrong Way Detection etc.
Objective of Mini Project:
- Development of MATLAB Simulink model as per requirement.
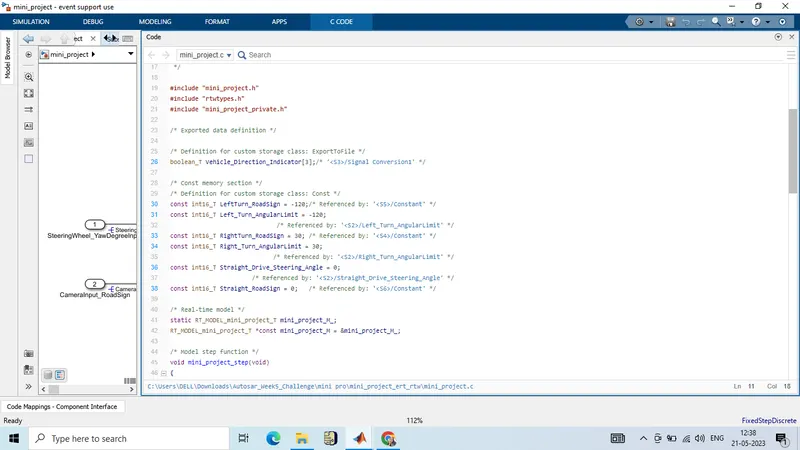
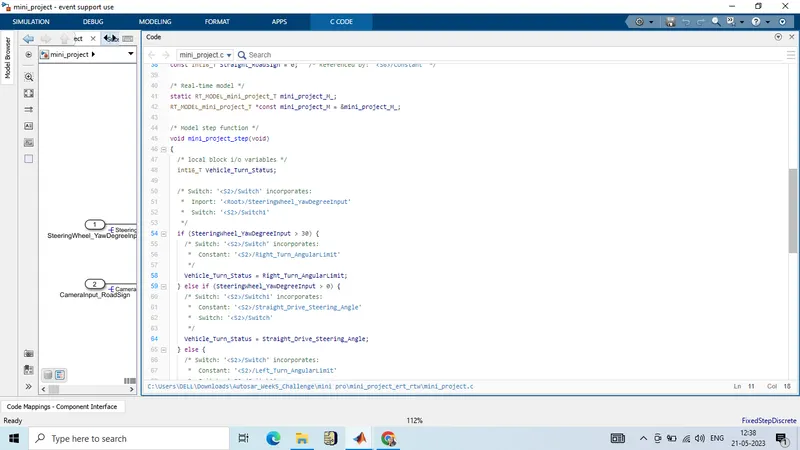
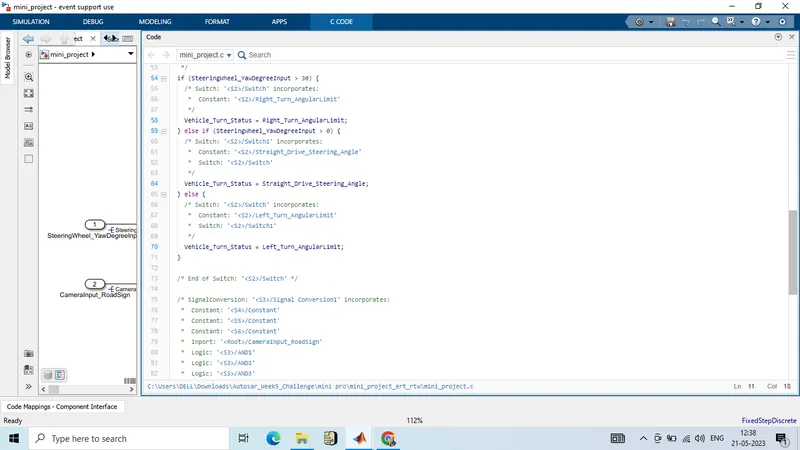
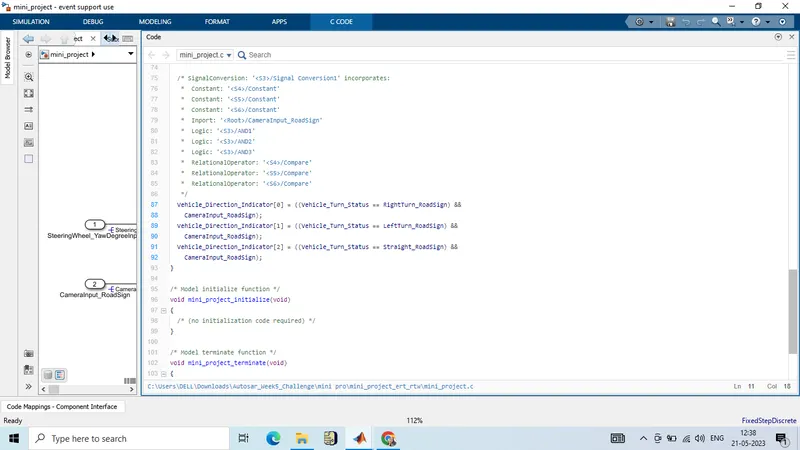
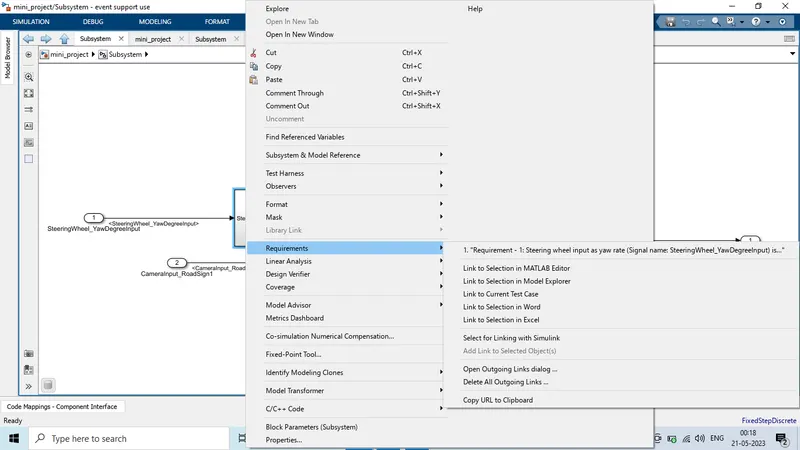
- Tag the requirements to the simulink model; tagging requirement 1 & requirement 2 to their corresponding subsystems is fine.
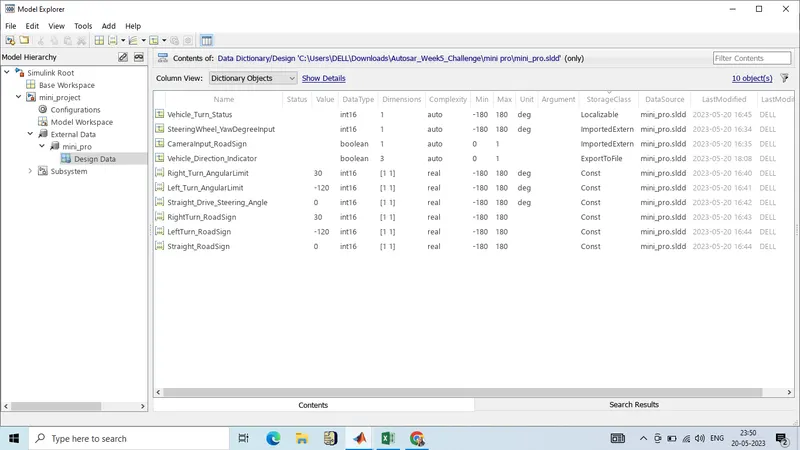
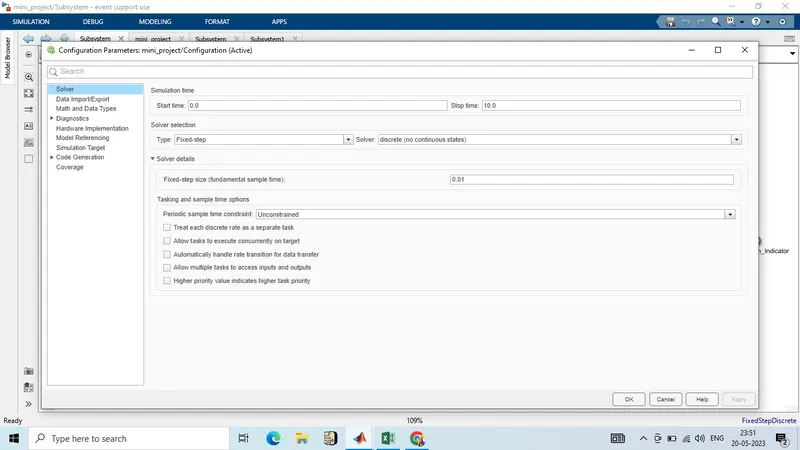
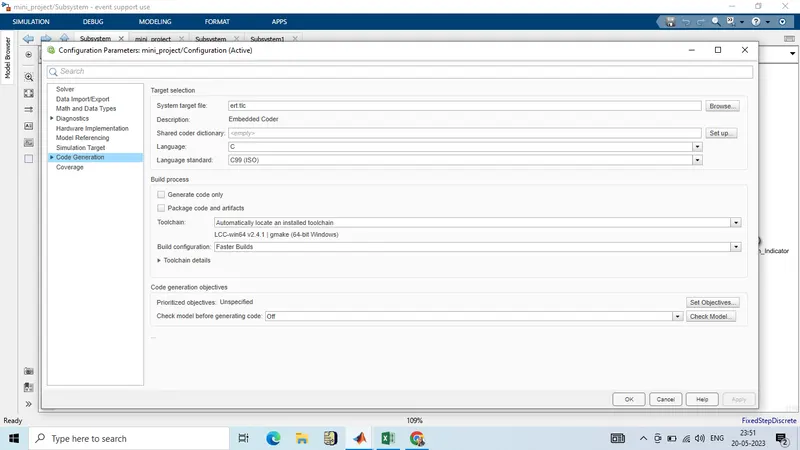
- MBD compliant changes, Data Dictionary creation & code generation is added advantage, and that is not scope of this project.
About Vehicle Direction Determination: When a vehicle has an accident and takes pictures of the damage, in most cases the damage of the vehicle cannot be clearly judged by only one picture, so it is often necessary to take pictures of the vehicle from multiple directions and angles.
Intelligent damage assessment according to these pictures to restore the damage of the vehicle. Vehicle detection and direction determination can determine the position and bearing of the vehicle in the uploaded accident image, which will be helpful to identify the damage of parts and give specific maintenance plans.
To solve this problem: Firstly, The dataset of the model is constructed by manual marking and data augmentation. Secondly, we built the detection model based on the deep convolutive neural network and combining resnet-101 +FPN main trunk network and RetinaNet. Thirdly, we carry out research on vehicle detection and direction determination of the directions of frontal, lateral-frontal, lateral, lateralback and back.
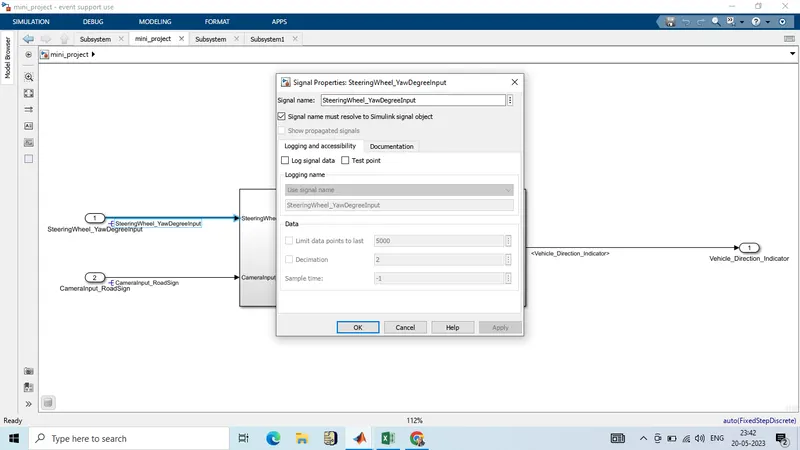
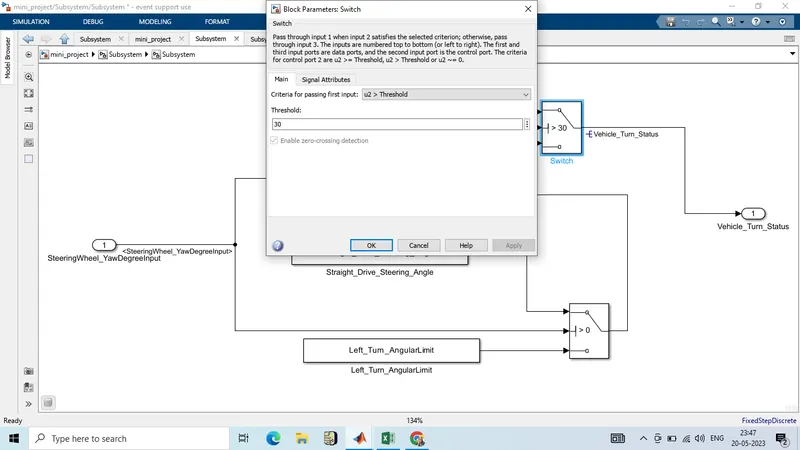
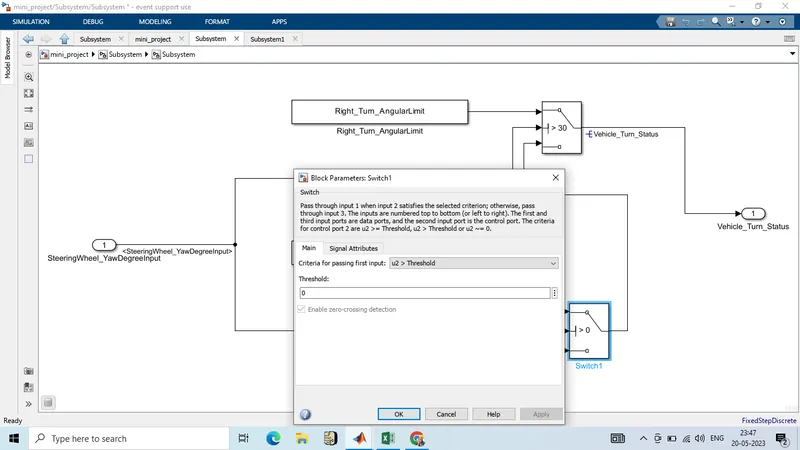
Simulink Model
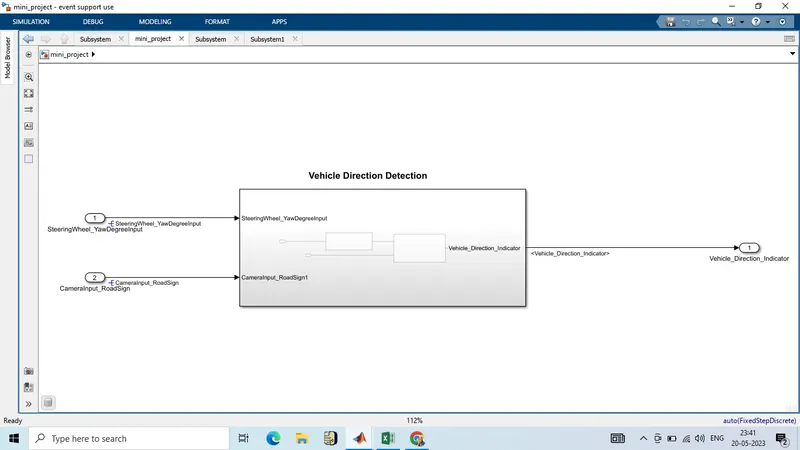
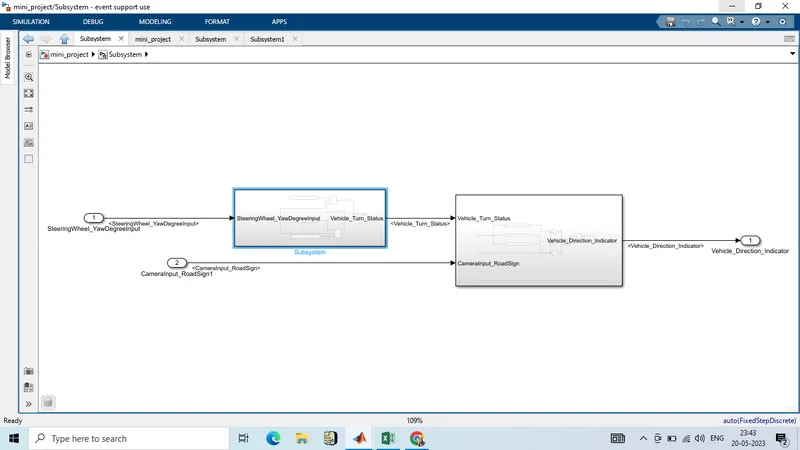
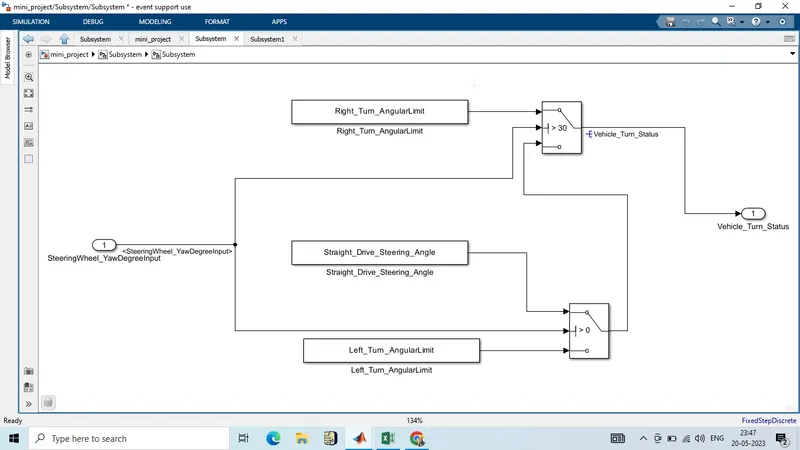
Result