Project 1 (Mini Project on Vehicle Direction Detection
Aim:
- Development of MATLAB Simulink model as per requirement.
- Tag the requirements to the simulink model; tagging requirement 1 & requirement 2 to their corresponding subsystems is fine.
- MBD compliant changes, Data Dictionary creation & code generation is added advantage, and that is not scope of this project.
- If choosing code generation, Storage class for Input signals: ImportedExtern; Storage class for Output signal: Export to File; Storage class for local signals: localizable; Storage class for calibration signals: Const.
- Choose sample time for all signals as 0.01s.
Requirement - 1:
- Steering wheel input as yaw rate (Signal name: SteeringWheel_YawDegreeInput) is the input for this system.
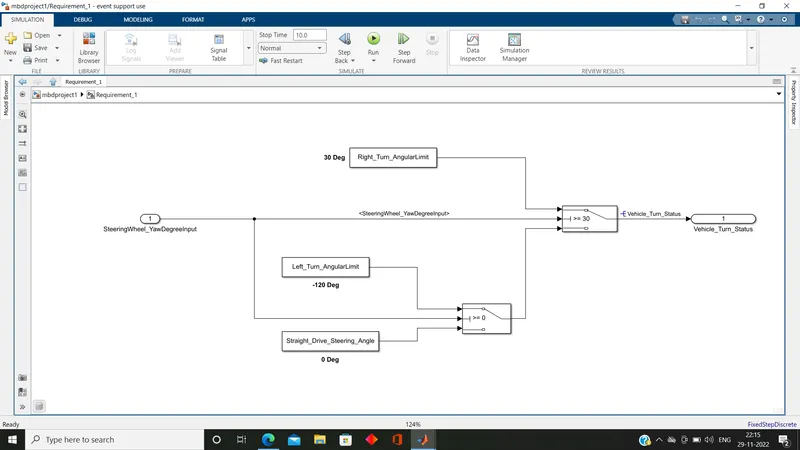
- This is compared against 3 angular values, one each for left turn, right turn & straight drive (Calibration Values: Right_Turn_AngularLimit, Left_Turn_AngularLimit, Straight_Drive_Steering_Angle) to say which specific direction the steering wheel is turning towards.
- Use switch blocks to compare & develop this requirement. Keep this requirement in a subsystem & output of this requirement is a local signal (Signal Name: Vehicle_Turn_Status).
Steps Performed
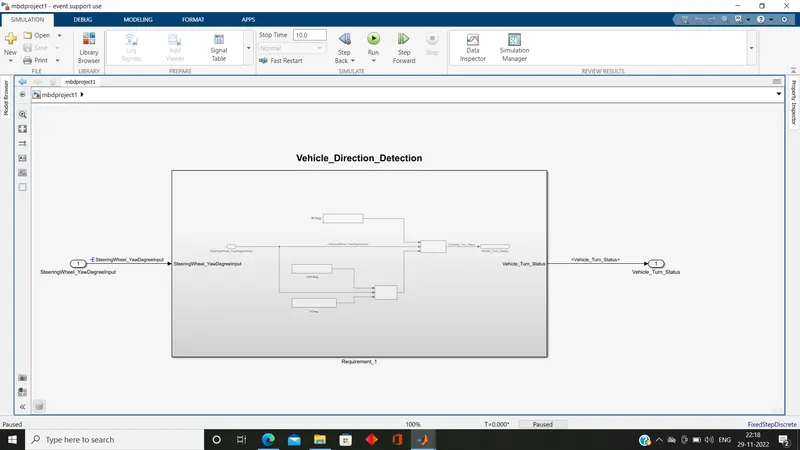
(i)Created a Subsystem and named it as requirement_1
(ii)Build the logic as per requirement-1 and made the connection.
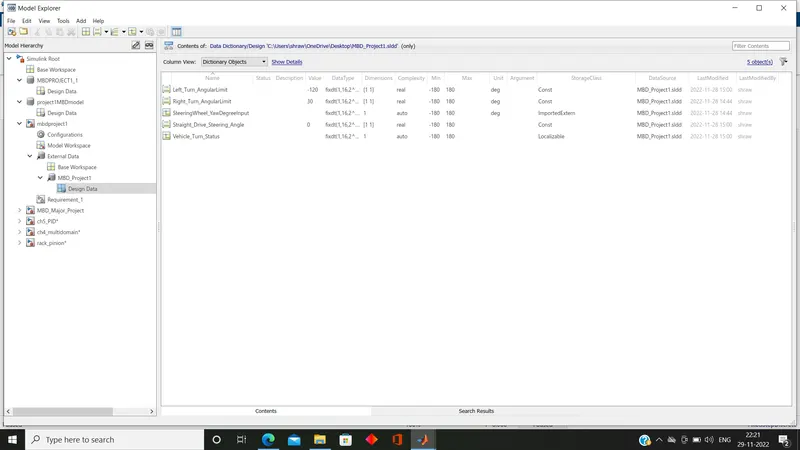
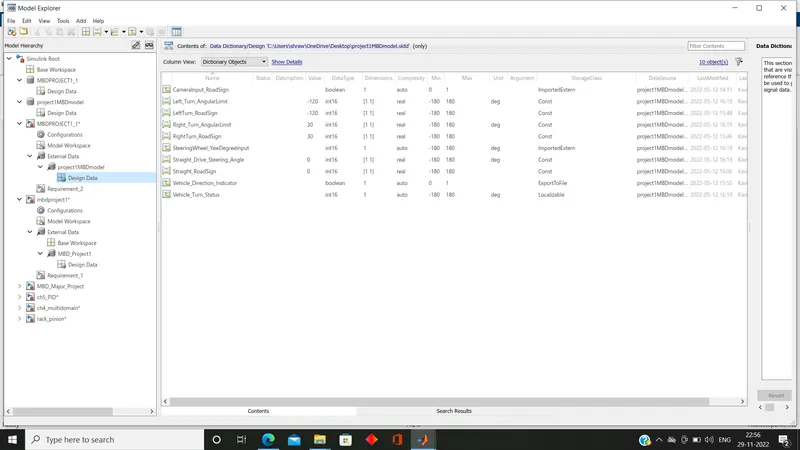
(iii)Created a SLDD using given signals & calibration Data List. (Under model explorer tab open linked to data dictionary and named the SLDD file as MBD_Project1 and saved it.)
(iv)Requirement Tagging:
(a)Pasted given Requirement-1 in a Word Document and saved it
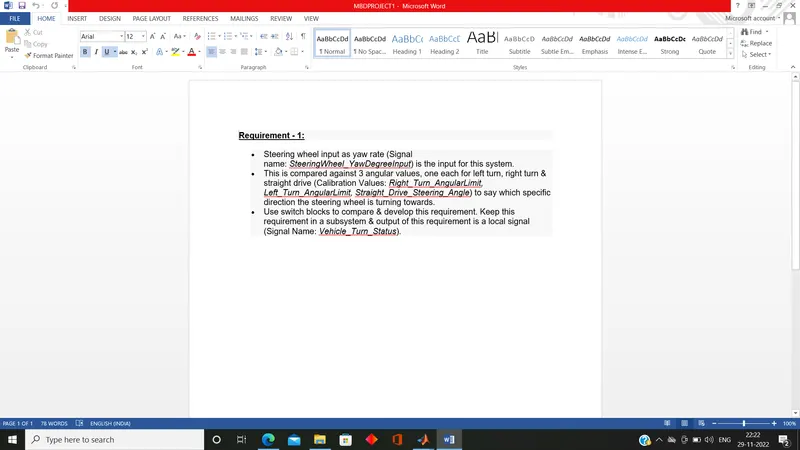
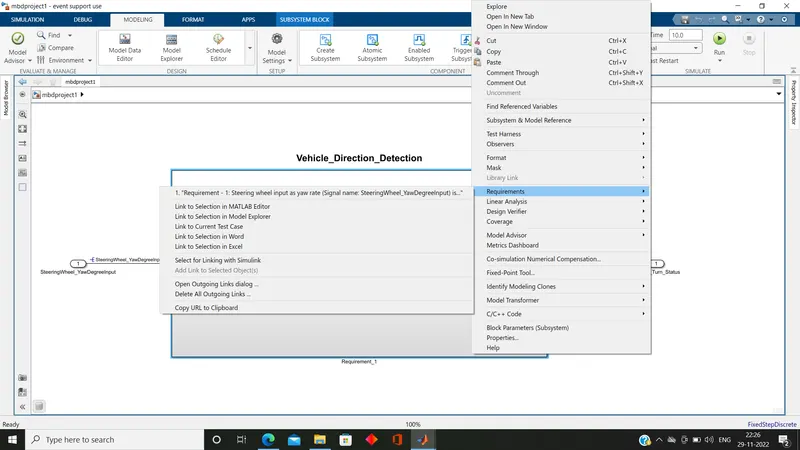
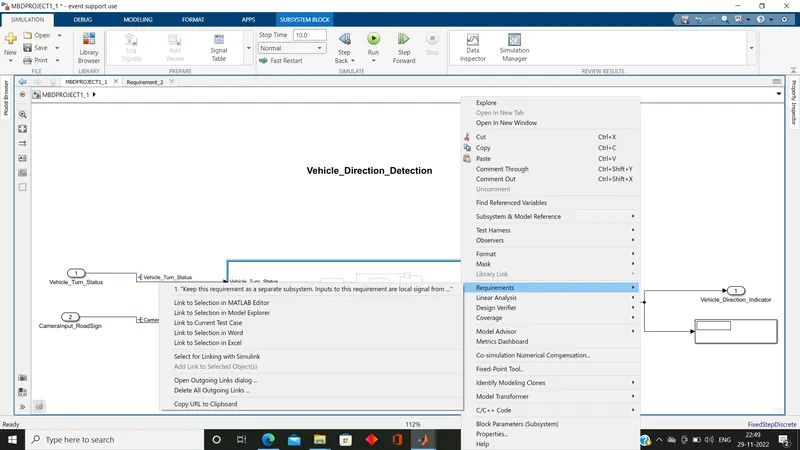
(b)Taggigng Requirement in Model: Select the model and press the right click, went into requirement and chose link to selection in word.
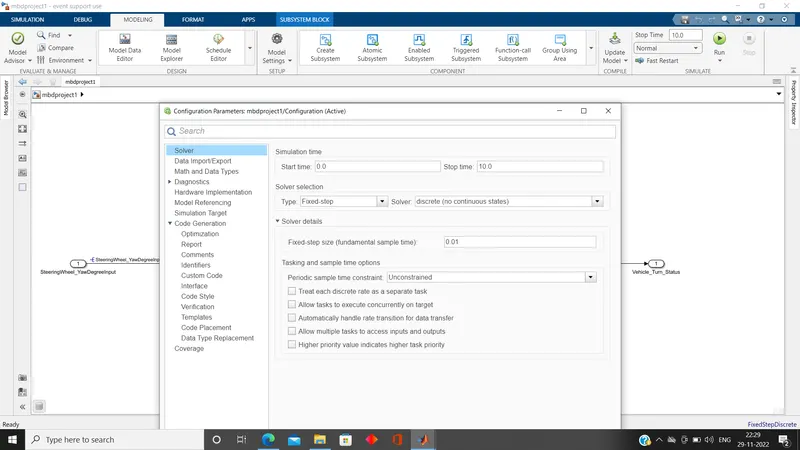
(v)Solver Setting: Opened the solver configuration using Ctrl+E and select the fixed step and step size as 0.01.
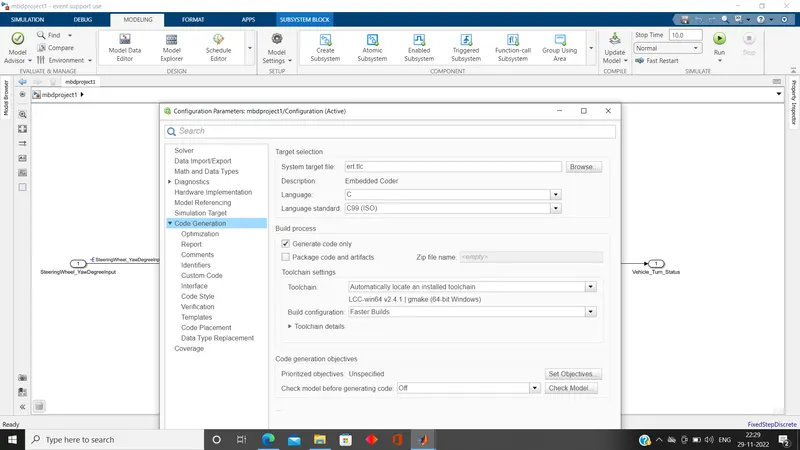
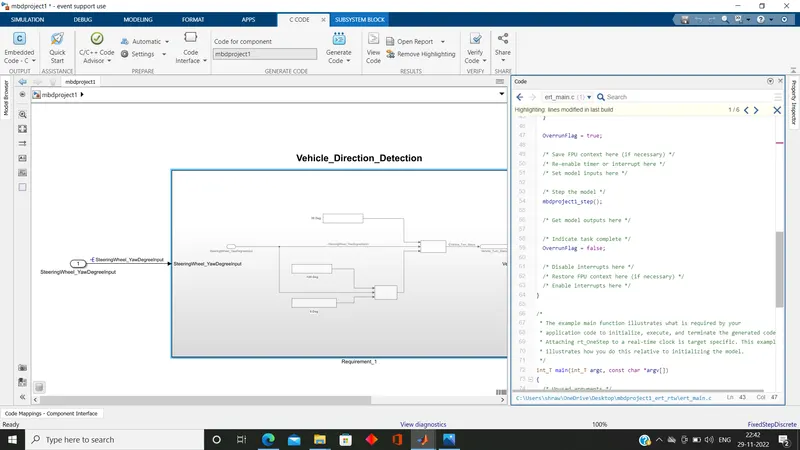
(vi)Embedded Coder Setting: Under code generation selected system target file as embedded coder.
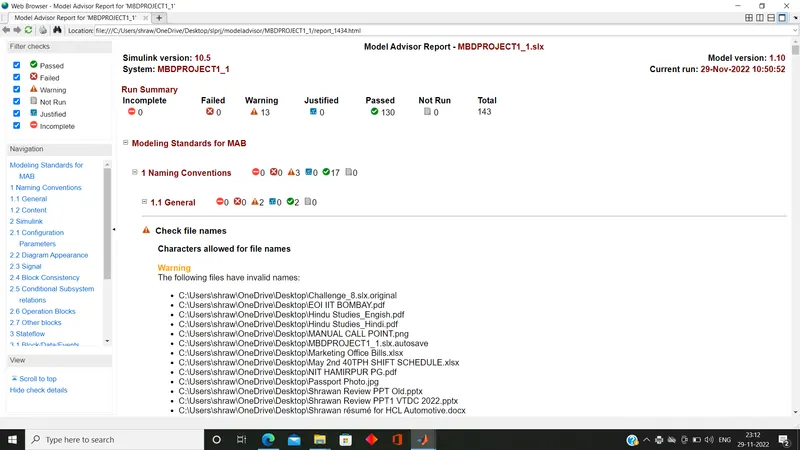
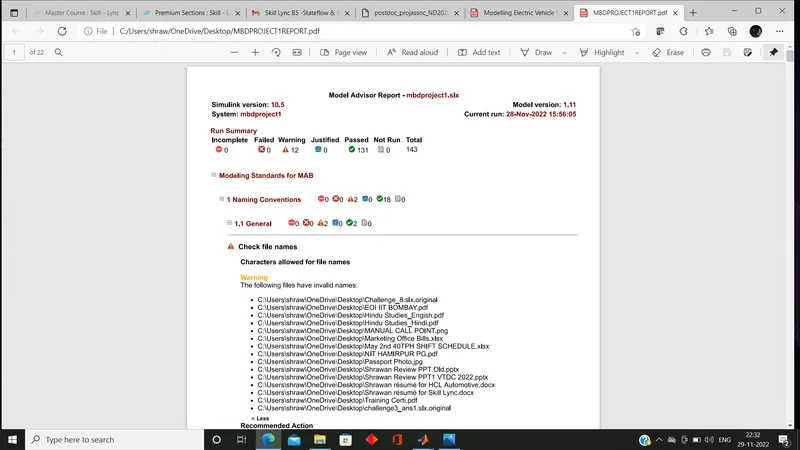
(vii)Model Advisor Report: Hit on the model advisor and created report using generated link and saved it in a pdf.
Code Generation: under APP tab went into embedded coder select the code generation and generated code.
Requirement – 2:
- Keep this requirement as a separate subsystem. Inputs to this requirement are local signal from requirement 1 (Signal Name: Vehicle_Turn_Status) & an input signal from camera (Signal Name: CameraInput_RoadSign), which confirms the occurrence of a road sign.
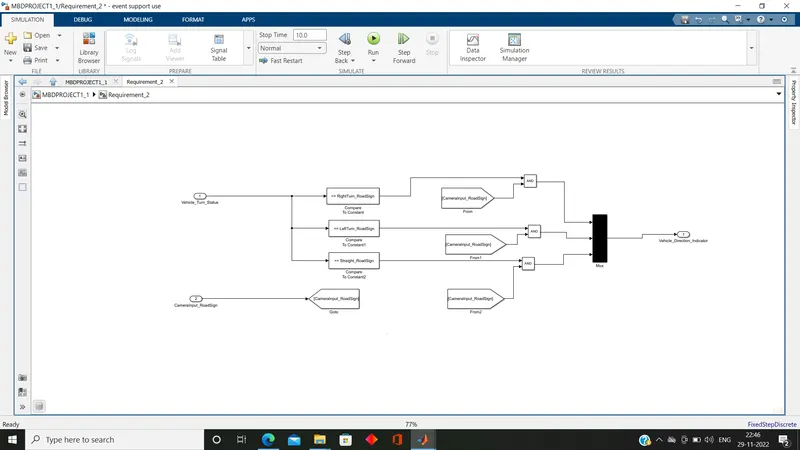
- Signal Vehicle_Turn_Status is compared against calibration values (Calibration Values: RightTurn_RoadSign, LeftTurn_RoadSign, Straight_RoadSign), if each of them is found equal, then each of the three corresponding output is compared against the camera input signal,
- Using a logical operator block, only one among them is finally given as output signal (Signal Name: Vehicle_Direction_Indicator).
Steps Performed
(i)Created a Subsystem and named it as requirement_1
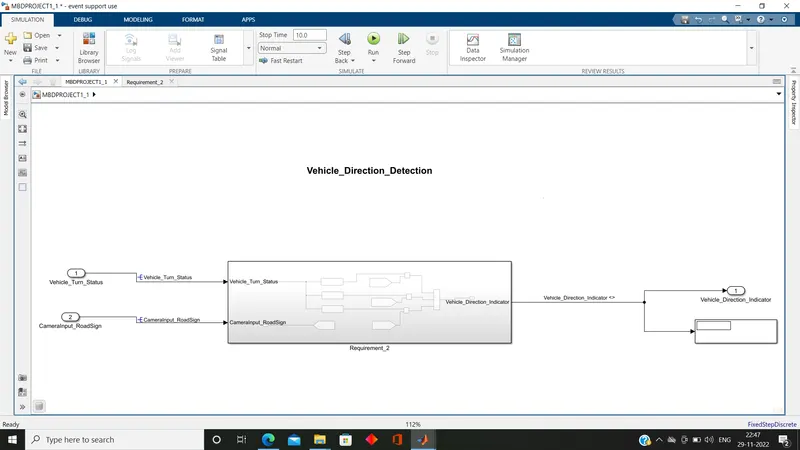
(ii)Build the logic as per requirement 2 and made the connections.
(iii)Created a SLDD using given signals & calibration Data List. (Under model explorer tab open linked to data dictionary and named the SLDD file as project1MBDmodel and saved it.)
(iv)Requirement Tagging:
(a)Pasted given Requirement-2 in a Word Document and saved it.
(b)Taggigng Requirement in Model: Select the model and press the right click, went into requirement and chose link to selection in word.
(v)Solver Setting: Opened the solver configuration using Ctrl+E and select the fixed step and step size as 0.01.
(vi)Embedded Coder Setting: Under code generation selected system target file as embedded coder.
(vii)Model Advisor Report: Hit on the model advisor and created report using generated link and saved it in a pdf.