Project 1 (Mini Project on Vehicle Direction Detection
NAME: MADHU D
BATCH: 07
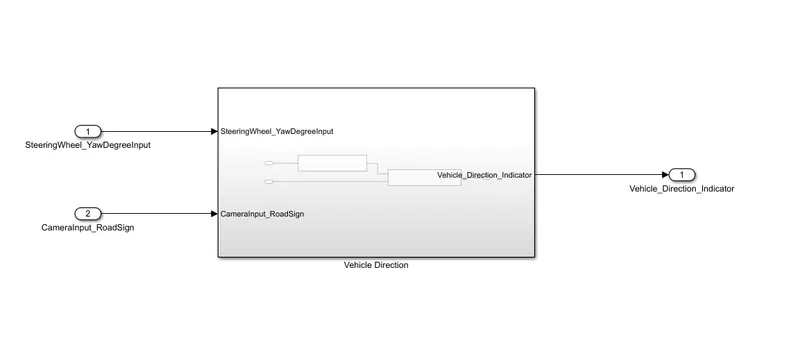
AIM: To development a Vehicle Direction Detection MATLAB Simulink model as per requirement.
MODEL:
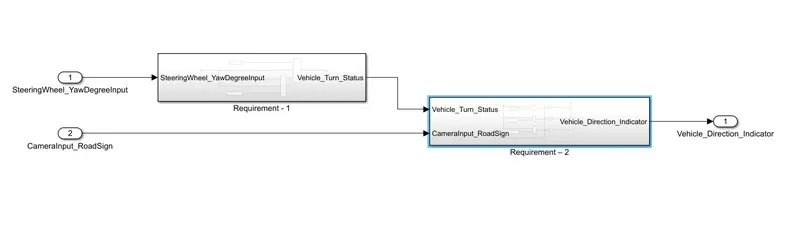
Requirement - 1:
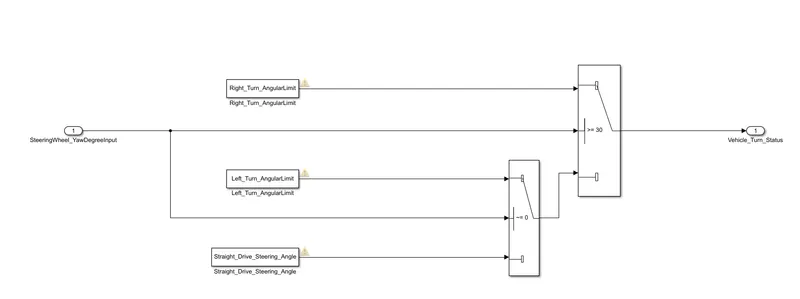
- Steering wheel input as yaw rate (Signal name: SteeringWheel_YawDegreeInput) is the input for this system.
- This is compared against 3 angular values, one each for left turn, right turn & straight drive (Calibration Values: Right_Turn_AngularLimit, Left_Turn_AngularLimit, Straight_Drive_Steering_Angle) to say which specific direction the steering wheel is turning towards.
- Use switch blocks to compare & develop this requirement. Keep this requirement in a subsystem & output of this requirement is a local signal (Signal Name: Vehicle_Turn_Status).
Requirement – 2:
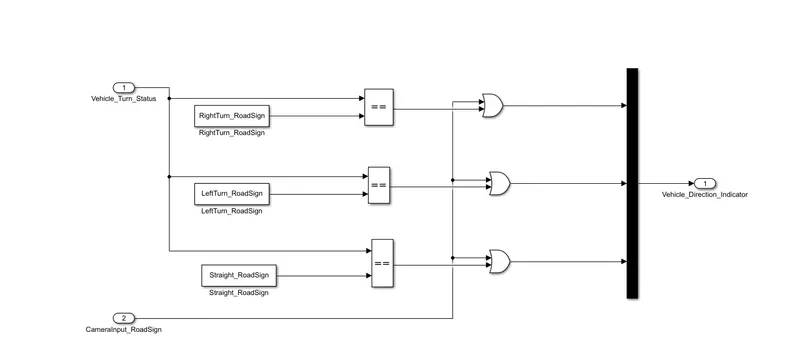
- Keep this requirement as a separate subsystem. Inputs to this requirement are local signal from requirement 1 (Signal Name: Vehicle_Turn_Status) & an input signal from camera (Signal Name: CameraInput_RoadSign), which confirms the occurrence of a road sign.
- Signal Vehicle_Turn_Status is compared against calibration values (Calibration Values: RightTurn_RoadSign, LeftTurn_RoadSign, Straight_RoadSign), if each of them is found equal, then each of the three corresponding output is compared against the camera input signal,
- Using a logical operator block, only one among them is finally given as output signal (Signal Name: Vehicle_Direction_Indicator)
Code is generated and files are uploaded
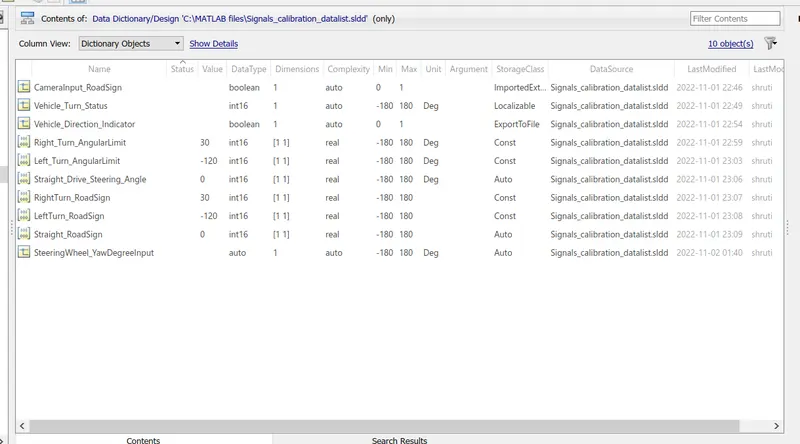
SLDD(Simulink Data Dictionary)
To make model's data accessible, here the data has been made available for model by using SLDD
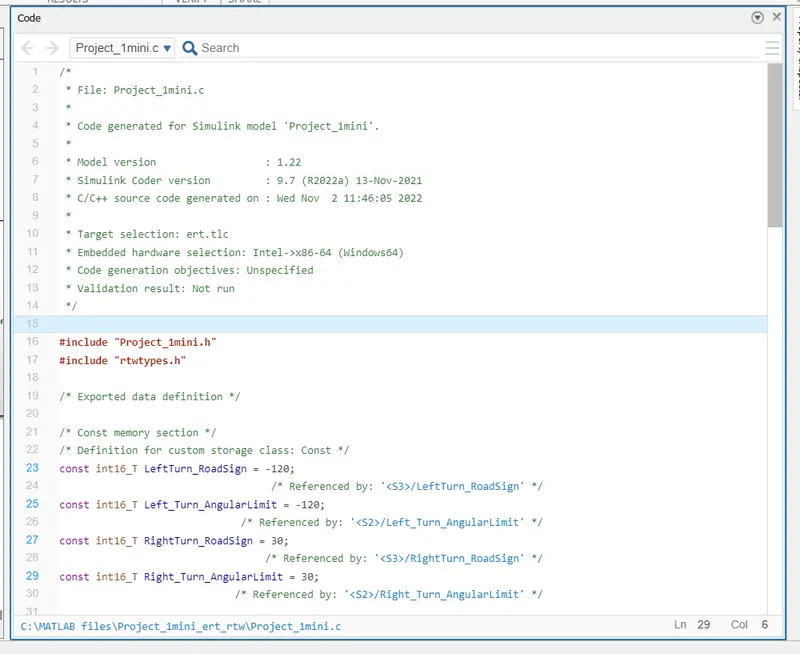
CODE is generated for this model
MODEL advisory checks are runned and report is uploaded.
Requirement are tagged in a word file which is uploaded: right click on subsystem -> Requirement-> requirement tag
RESULT:
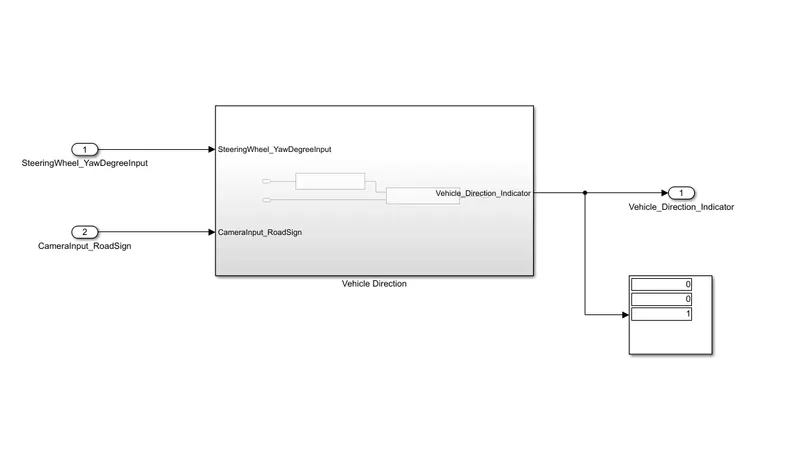
After running this developed model by looking the output on display, this tells the result that vehicle direction is at Straight_RoadSign