Project 1 (Mini Project on Vehicle Direction Detection
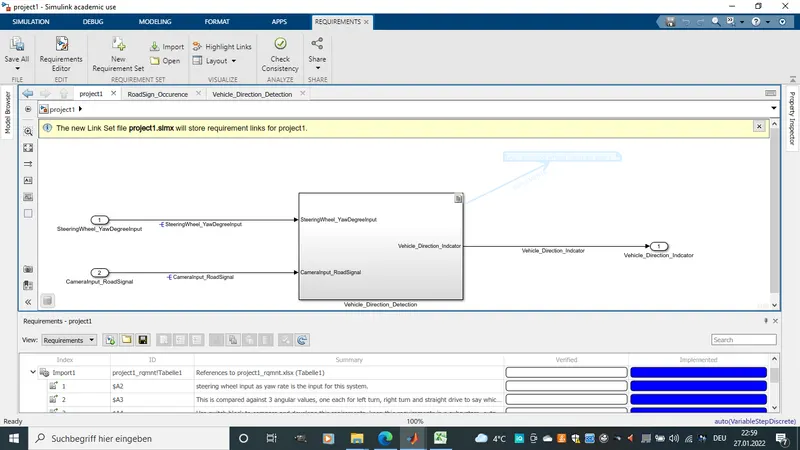
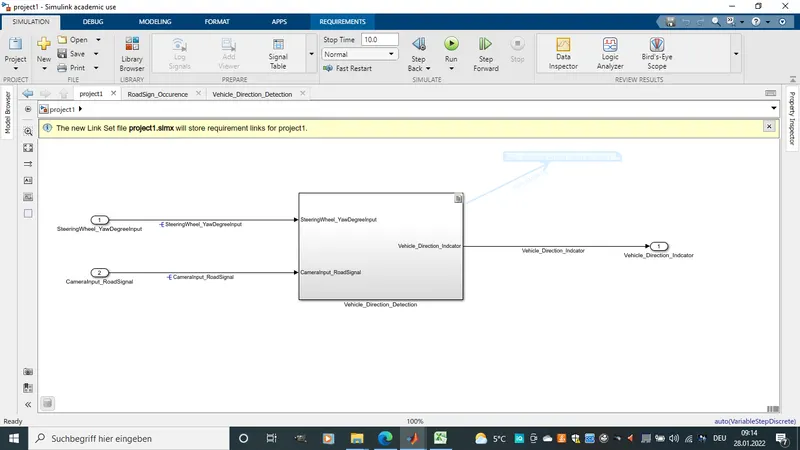
1) Here SteeringWheel_YawDegreeInput and CameraInput_RoadSign is given as input to Vehicle_Direction_Detection. Vehicle_Direction_Indcator is given as Output.
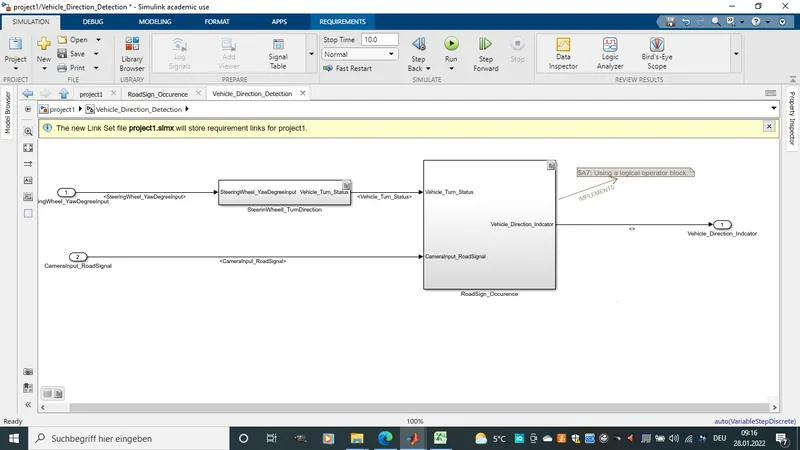
2)In Vehicle_Direction_Detection subsystem i build 2 Different subsystems for requirement1 and requirement2.
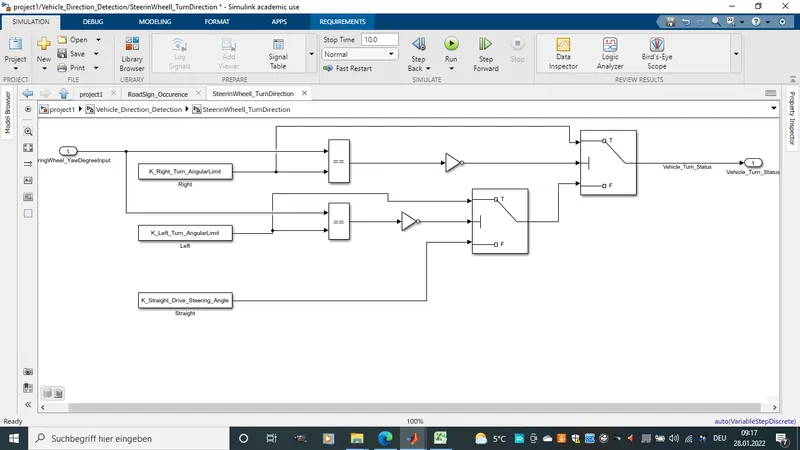
3)In Requirement1 in oder to determine in wgich direction the vehicle is moving, SteeringWheel_YawDegreeInput is compared to 3 Angularvalues using equal blocks and switch blocks.
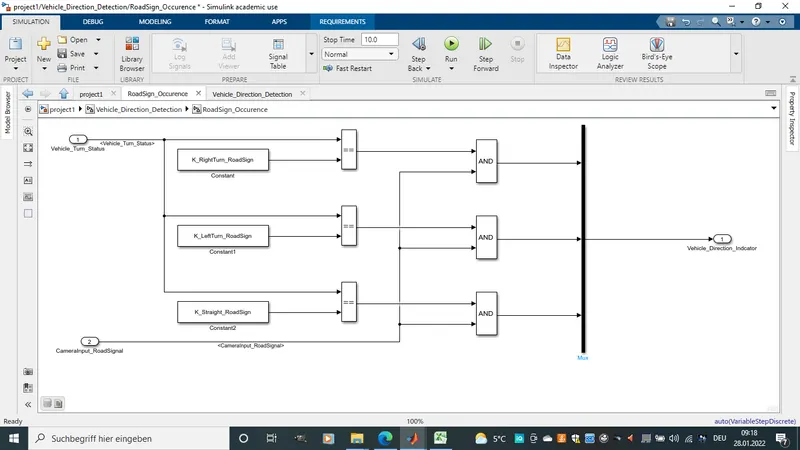
4)In Requirements2 the output from Requirement1 is used as local input and compared against Calibration roadTurn signals and later compared to camera input.
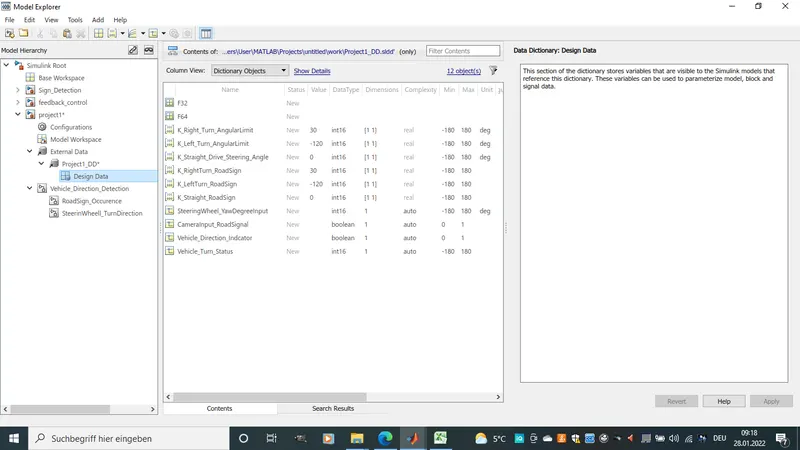
5) DataDictionary
6) Requirement Tagging