Project 1
ANSWER:
Hydraulic Actuators:
Hydraulic actuators use liquid as a means to apply pressure to the actuator’s mechanical components. They can exert a large amount of force because liquid is not compressible but are generally limited in acceleration and speed. Hydraulic actuators are available in spring-return and double-acting designs.
Double Acting Actuators:
Double-acting actuators have air or liquid supplied to both sides of the piston with one side at higher pressure, which achieves the movement required to actuate the valve. This configuration uses pneumatic or hydraulic pressure of the air or liquid energy to open and close the valve.
Mechanical System Subsystem:
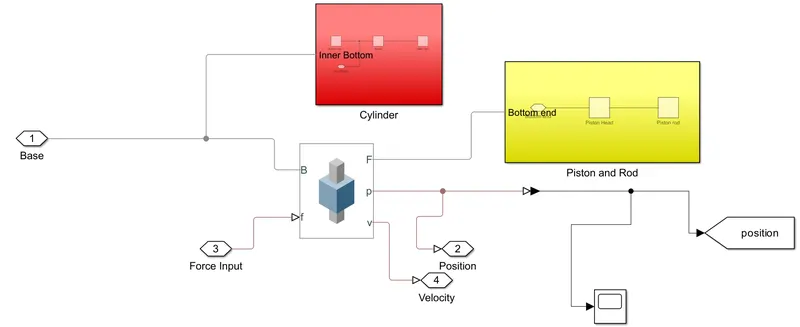
In mechanical subsystem, model is build using the MBD blocks, cylinder blocks like head,bottom caps and barrel is modeled and piston and rod is model and both is connected with the prismatic joint.
Here, we use the Reloved Solid (Simscape Multibody) and Cylindrical Solid (Simscape Multibody) blocks to model the cylinder and piston
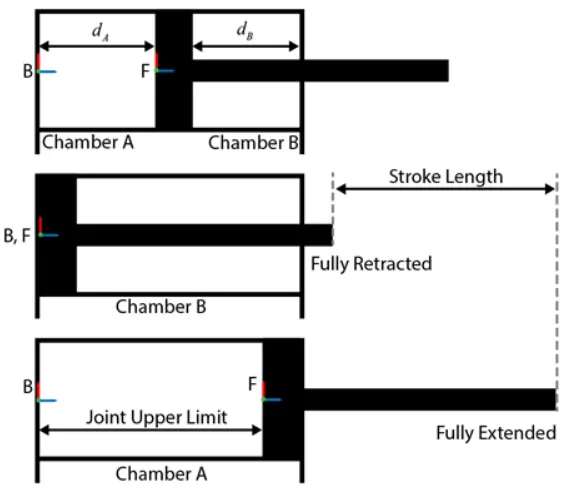
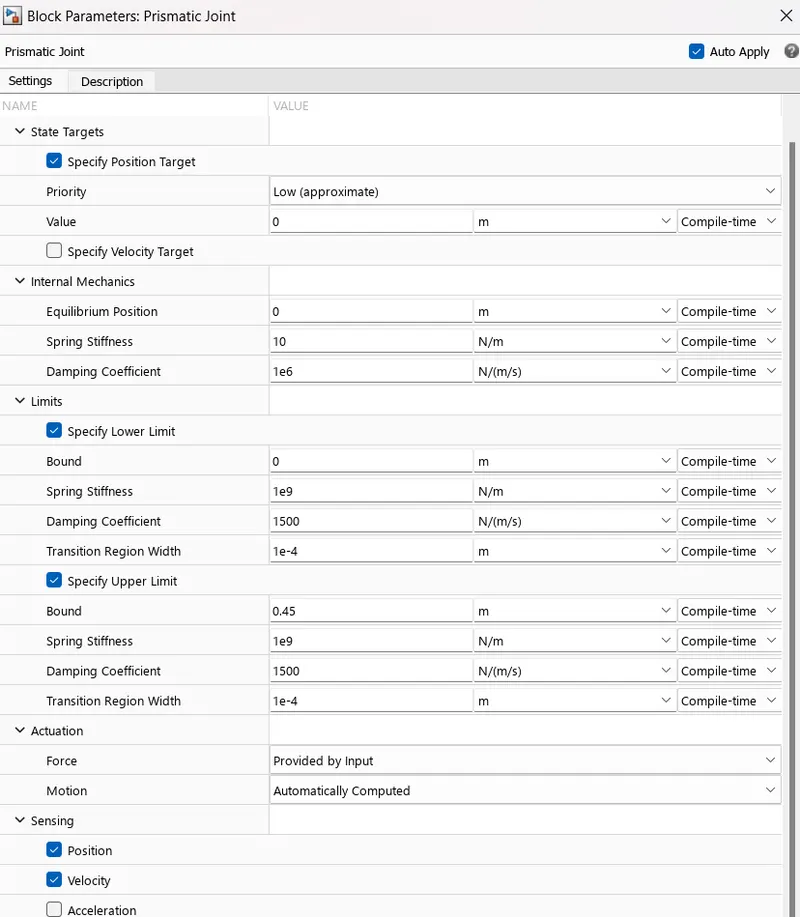
To provide the translational degree of freedom for the piston, use a Prismatic Joiunt(Simscape Multibody) block. To easily calculate the lengths of the chambers A and B, you can attach the base frame (B) and follower frame (F) of the joint to the centers of the left inner surface of the chamber A and the left surface of the piston, respectively. Make sure that the Z-axes of the B and F frames are aligned and both point toward chamber B.
Using this convention, the length of the chamber A, dA, is the position output of the joint block, and the length of the chamber B, dB, equals the difference of the stroke length and dA. To ensure that the piston does not travel beyond the ends of the cylinder, you can specify the upper and lower position limits of the Prismatic Joint block.
Cylinder Subsystem:
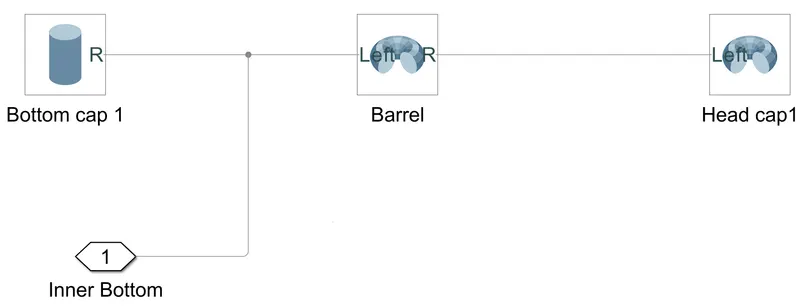
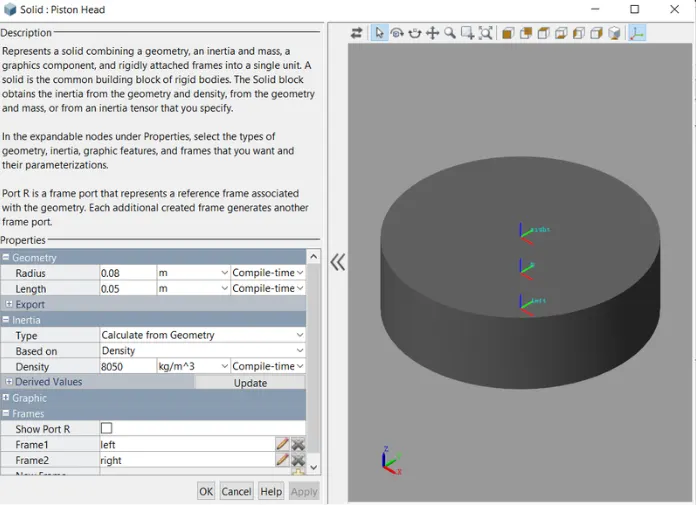
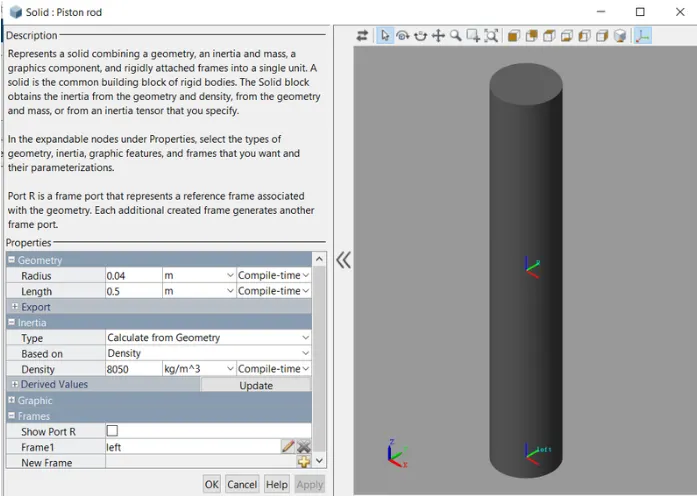
The solid blocks are used here, radius ,length and cross section area is given in the geometry of the solid blocks and the frames are selected on z axis and left right frames are carefully designed.
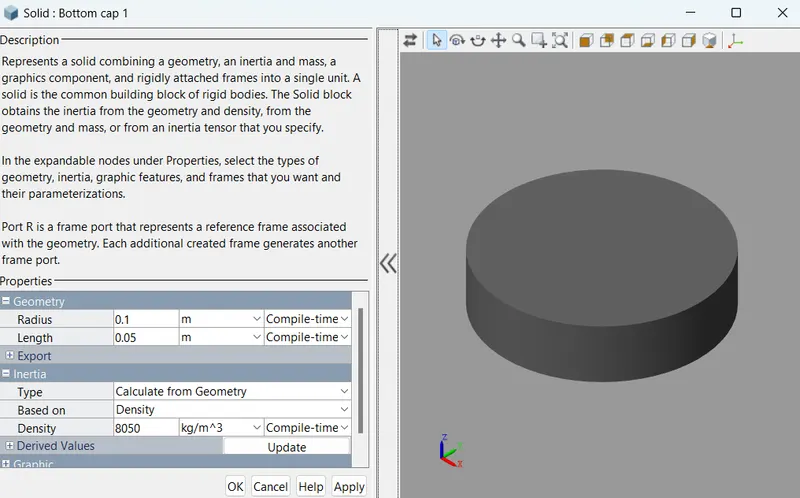
Barrel cap:
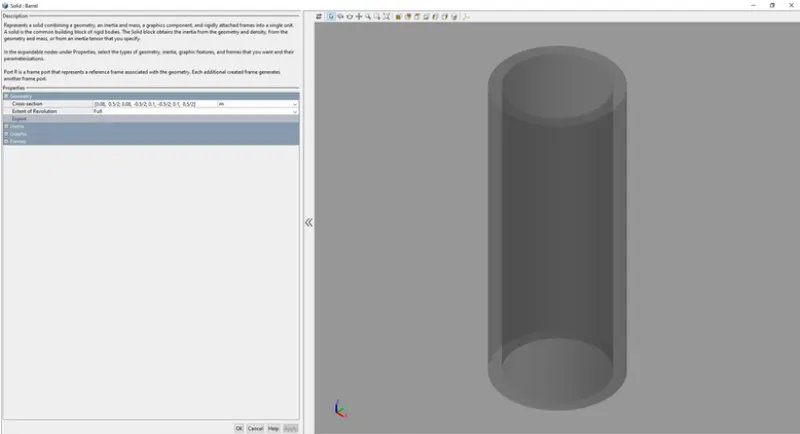
Head Cap:
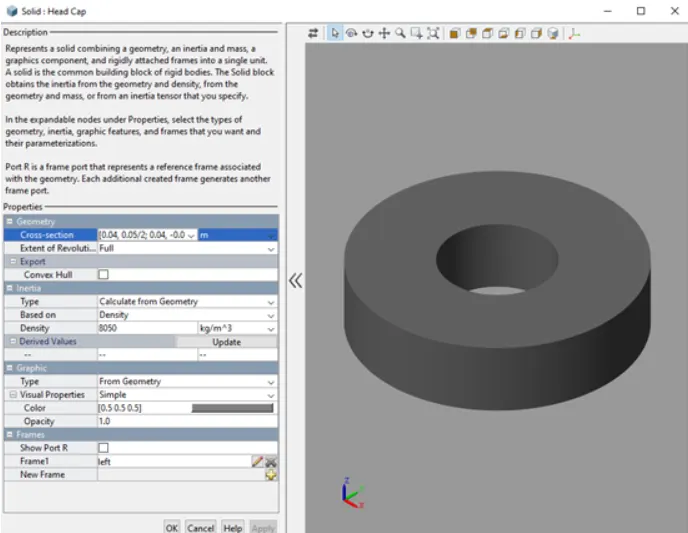
Piston:
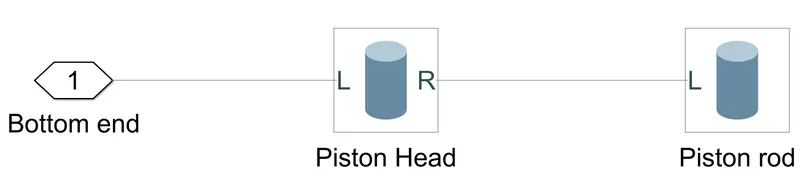
Piston Head:
Piston Rod:
Prismatic Joint:
A prismatic joint is often called a slider — for example, a “crank-slider linkage.” This is a type of kinematic pair and an idealized way to describe how motions are constrained within machines.
There are several physical embodiments of a prismatic joint, such as slideways. Rectangular cross-sections may be used in combination with plain or rolling bearings to enable linear motion while preventing rotation about the axis of movement.
Hydraulic and pneumatic cylinders are typically modeled as prismatic joints although they may also permit rotation about their axis. Kinematic pairs are classified as higher pairs and lower pairs. Higher pairs involve point or line contact, such as a ball or roller that’s rolling over a surface. Lower pairs can be visualized as surface contact.
Translational Multibody Interface:
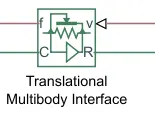
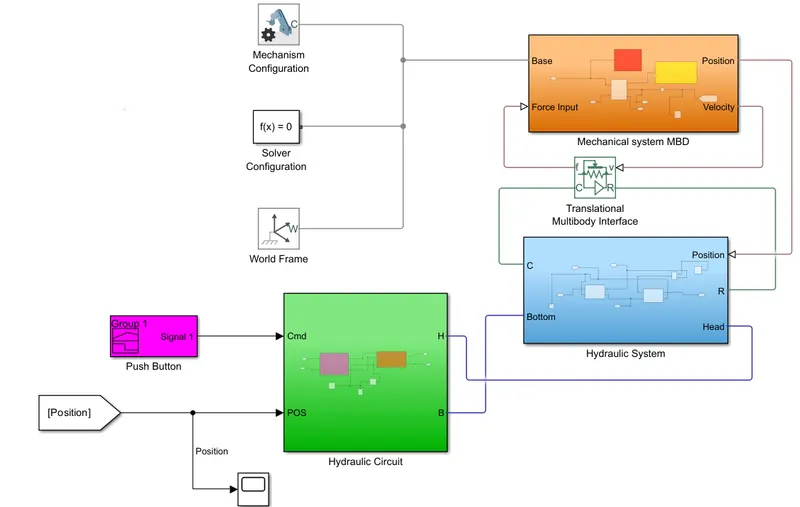
This block is an interface between a Simscape Multibody joint and a Simscape mechanical translational network. Ports R and C are mechanical translational conserving ports that connect to the two nodes in the mechanical translational network which share the same force and relative velocity as a primitive in the Multibody joint. Ports v and f are physical signal ports that connect to the Multibody joint. Input port v accepts the relative velocity sensing output from the joint primitive. Output port f provides the force actuation input to the joint primitive.
Hydraulic System Subsystem:
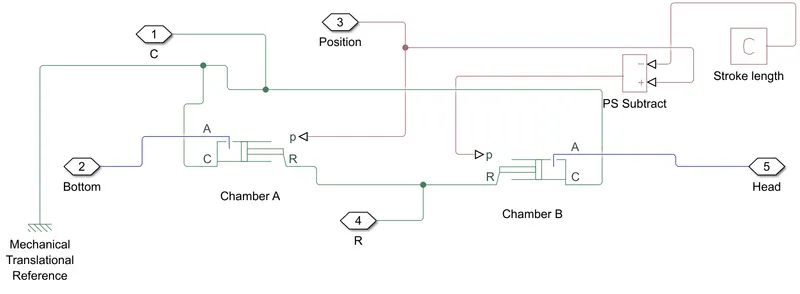
Chamber A:
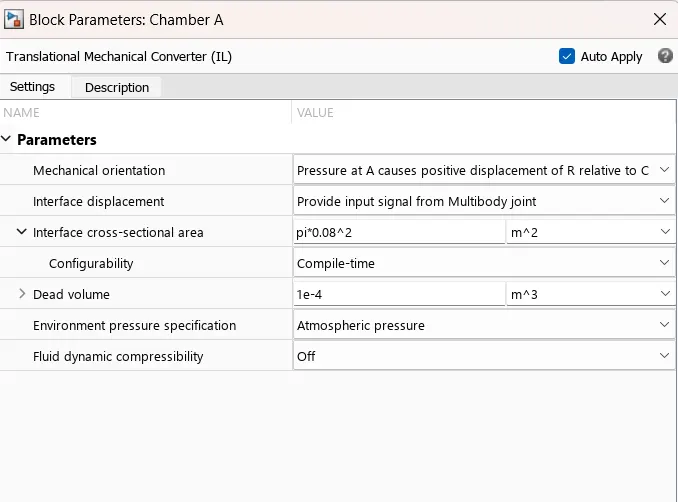
Chamber B:
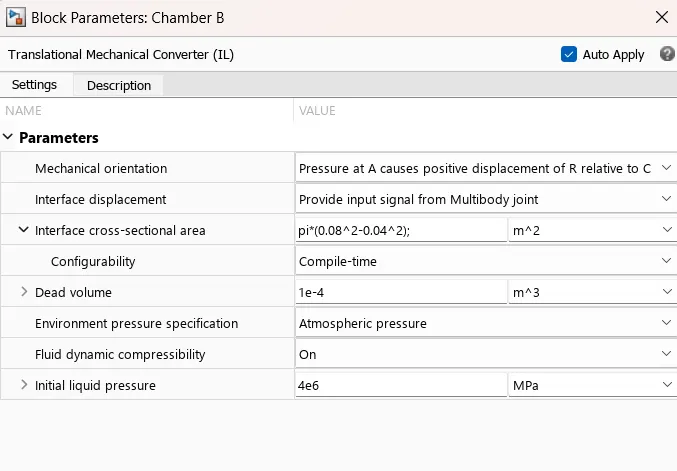
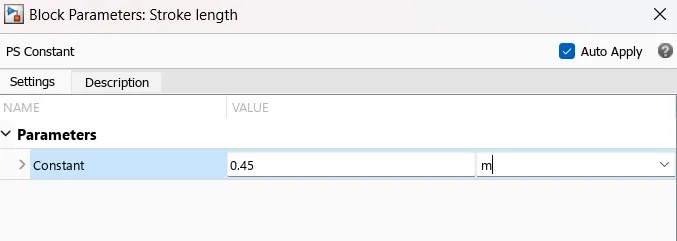
PS Constant (C):
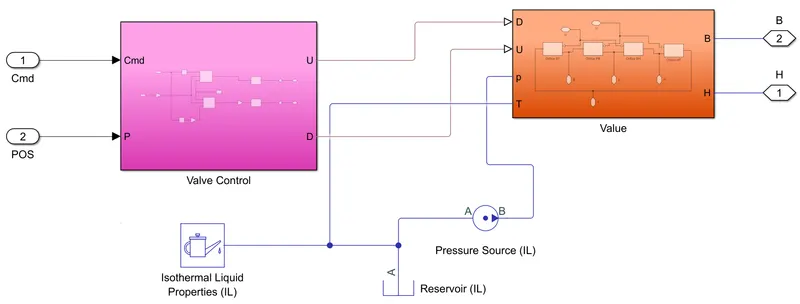
Hydraulic Cirucit :
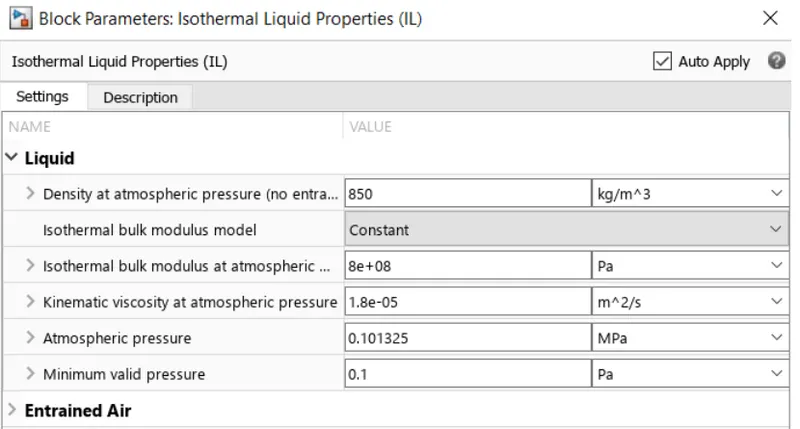
Isothermal Liquid properties:
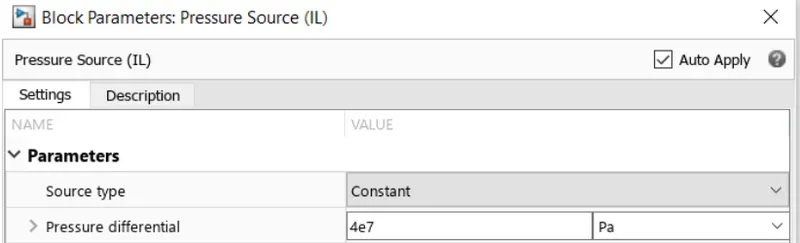
Pressure source:
This block represents an ideal mechanical energy source in an isothermal liquid network that can maintain a constant or controlled pressure differential regardless of the flow rate. The source does not generate any losses due to friction.
Reservoir:
This block sets a constant or controlled boundary condition in an isothermal liquid network. The volume of liquid inside the reservoir is assumed infinite. Therefore, the flow is assumed quasi-steady. Liquid leaves and enters the reservoir at the reservoir pressure.
Valve :
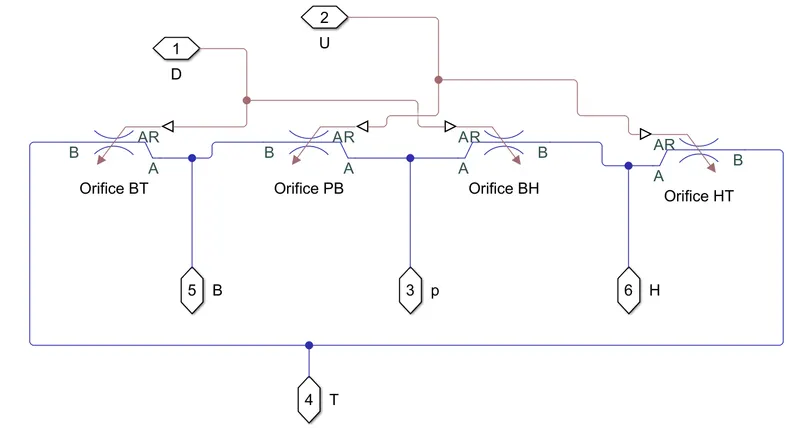
The 4 orifices are selected,One for fluid input from pump P,fluid exhaust to the tank T,port for Bottom of the cylinder B,port for head of the cylinder H.
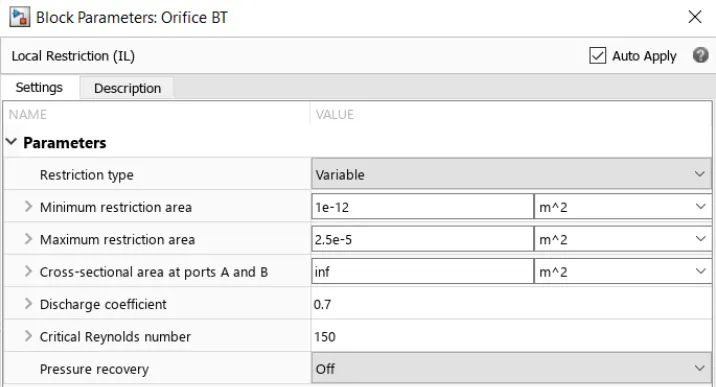
Valve control:
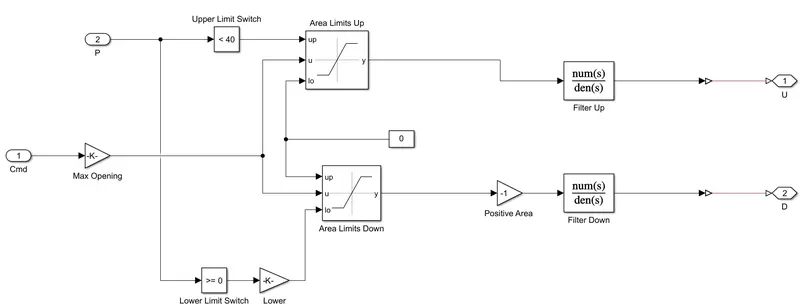
The valve control get the position feedback and input command open the orifices accordingly to make the piston movement inside the cylinder barrel. It uses the transfer function based controller to control the valve dynamics.
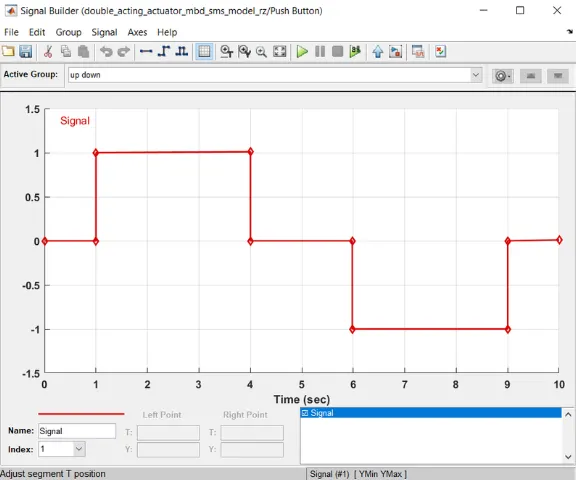
Signal builder block:
Mechanics Explorer Result: The animation of the acutuator can be observed while running the Simulink file attached below.