Project 1
Double-acting actuator model:
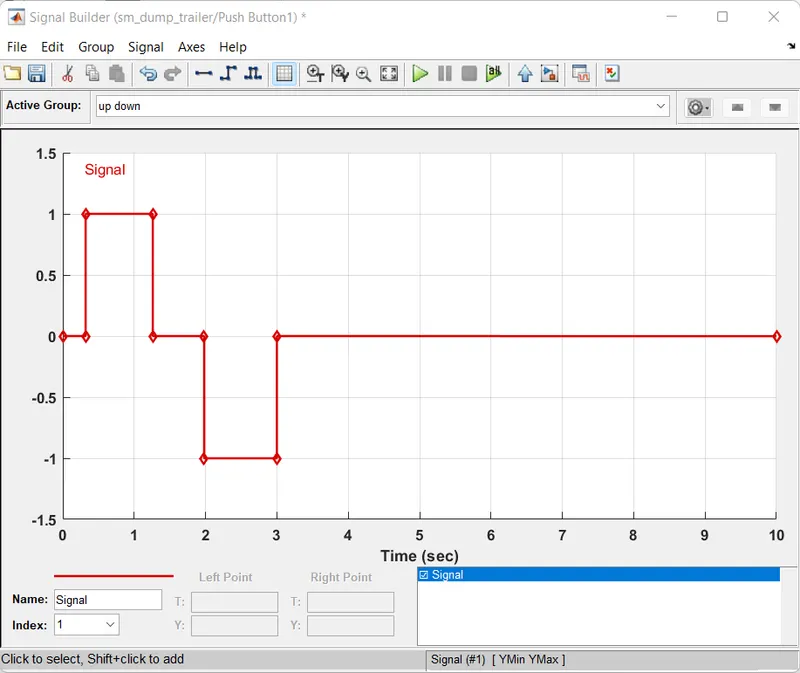
The input data for building the model was taken from the reference. But the input signal was modified in the Signal builder block to move the actuator up and down to understand the multibody model better.
Model:
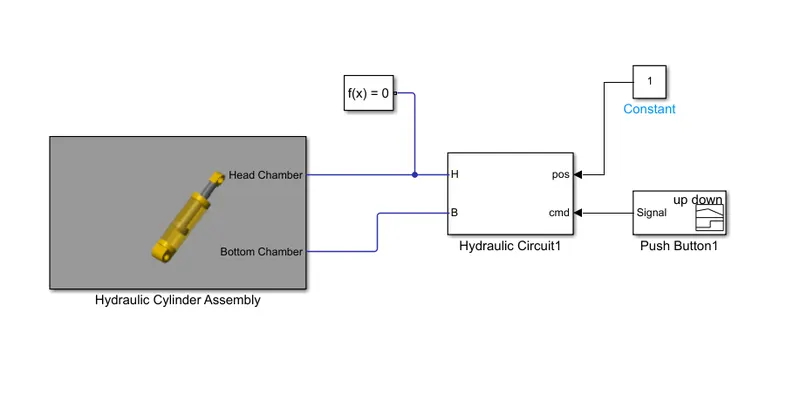
Hydraulic Cylinder Assembly:
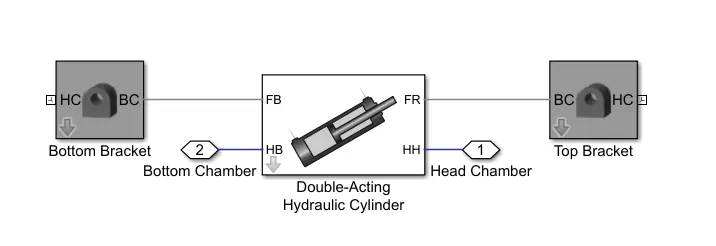
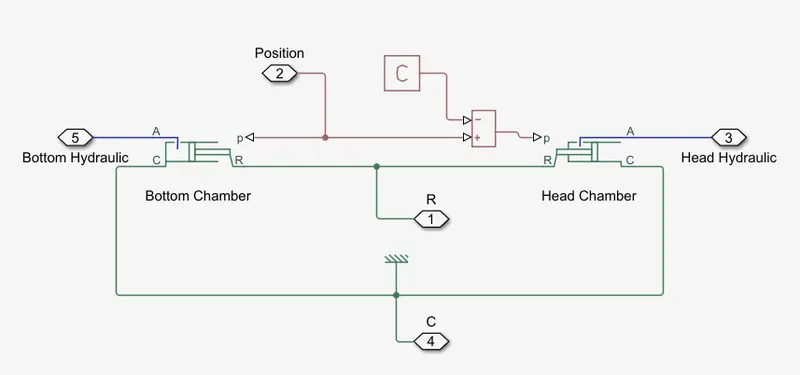
Subsystem: Double Acting Hydraulic cylinder
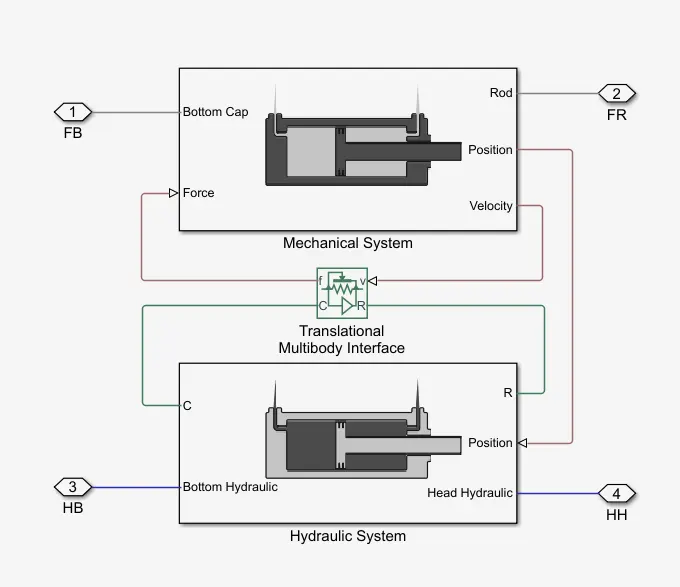
Subsystem: Mechanical system
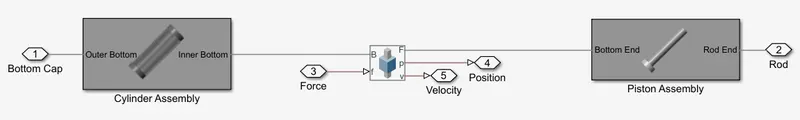
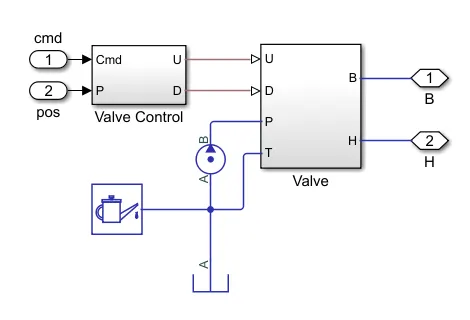
Subsystem: Hydraulic System
Hydraulic circuit:
Input Signal - Signal builder
Results:
Multibody model:
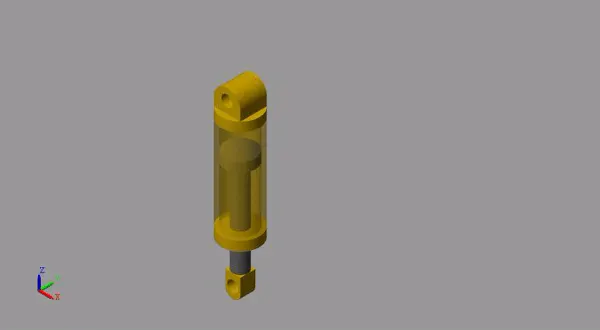
The above gif shows that the required motion for the double-acting actuator is achieved.
Summary:
First, the reference model dump trail was observed and the model was run many times by modifying input signals for better understanding. Then, the hydraulic cylinder block was built in reference to the MatLab model with the inputs to be given for the head and bottom chambers. Next, the hydraulic circuit was built in reference to the same, and from this block, the inputs for the head and bottom chambers are given. A signal builder block was used to provide input to the hydraulic circuit. The signal was modeled such that the actuator moves up and moves down within the required time. The simulation time was set as 3secs and the model was run. The required multibody model output was achieved.