Project 1
OBJECTIVE: To develop a forward energy-based fuel consumption model of a conventional vehicle using matlab and simulink to analyze data and generate plots.
THEORY:
In a conventional vehicle the power is generated by an Internal Combustion Engine that converts the chemical energy to mechanical energy.
This mechanical energy reach the wheels through a drive train which contains the transmission, differential components.
A four-stroke (also four-cycle) engine is an (IC) engine in which the completes four separate strokes while turning the crankshaft. A stroke refers to the full travel of the piston along the cylinder, in either direction. The four separate strokes are termed:
Intake: Also known as induction or suction. This stroke of the piston begins at top dead center (T.D.C.) and ends at bottom dead center (B.D.C.). In this stroke the intake valve must be in the open position while the piston pulls an air-fuel mixture into the cylinder by producing vacuum pressure into the cylinder through its downward motion. The piston is moving down as air is being sucked in by the downward motion against the piston.
Compression: This stroke begins at B.D.C, or just at the end of the suction stroke, and ends at T.D.C. In this stroke the piston compresses the air-fuel mixture in preparation for ignition during the power stroke (below). Both the intake and exhaust valves are closed during this stage.
Combustion: Also known as power or ignition. This is the start of the second revolution of the four stroke cycle. At this point the crankshaft has completed a full 360 degree revolution. While the piston is at T.D.C. (the end of the compression stroke) the compressed air-fuel mixture is ignited by a spark plug (in a gasoline engine) or by heat generated by high compression (diesel engines), forcefully returning the piston to B.D.C. This stroke produces mechanical work from the engine to turn the crankshaft.
Exhaust: Also known as outlet. During the exhaust stroke, the piston, once again, returns from B.D.C. to T.D.C. while the exhaust valve is open. This action expels the spent air-fuel mixture through the exhaust valve.
The different types of efficiencies are:
(a) Mechanical efficiency. It is the ratio of brake power (B.P.) to the indicated power (I.P.).
(b) Overall efficiency. It is the ratio of the work obtained at the crankshaft in a given time to the energy supplied by the fuel during the same time.
(c) Indicated thermal efficiency. It is the ratio of the heat equivalent to one kW hour to the heat in the fuel per I.P. hour.
(d) Brake thermal efficiency. It is the ratio of the heat equivalent to one kW hour to the heat in the fuel per B.P. hour.
(e) Volumetric efficiency. It is the ratio of the actual volume of charge admitted during the suction stroke at N.T.P to the swept volume of the piston.
MODEL: INITIAL MATLAB CODE:
A matlab code “Project1_InitFile.m” was created to load the variable to the workspace. In this project, a typical midsize car with a 1.9L engine and a 4-speed automatic transmission is considered. Data is taken from ADVISOR data base developed by NREL, USA. Transmission shift map and controller is taken from Matlab/Simulink example database. The model developed has the capability to simulate the vehicle on different drive cycles like UDDS, HWFET,FTP,NEDC,etc
THE CODE:
%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%
%% Skill-Lync -> Hybrid Drives Development
% Project 1 - Conventional Vehicle Model
% By - GOWTHAM
% Description:
%% Initialization File
% Initialization file for loading the variables for the Conventional vehicle simulation model
%% Vehicle Parameters
M = 1500; % Vehicle weight [kg]
Cr = 0.015; % Rolling resistance coefficient
Rw = 0.35; % Rolling radius [m]
Cd = 0.33; % Drag coefficient
Af = 2; % Frontal area [m2]
rhoa = 1.225; % Air density [kg/m3]
Vwind = 0; % Wind velocity [kmph]
g = 9.81; % Gravitational acceleration [m/s2]
theta = 0; % Slope [deg]
myu_road_tire = 1; % Coefficient of friction between tire - road interface
%% Powertrain Parameters
FDR = 3.73; % Final Drive Ratio / Diff Ratio
DiffEff = 0.99; % Differential efficiency (assumed independent of operating conditions)
NumGear = 4; % Number of gears in transmission
TransGear = [1:NumGear]; % Transmission Gears
TransRatio = [3.06, 1.62, 1, 0.7]; % Corresponding Transmission ratios
TransEff = 0.90; % Transmission efficiency (assumed independent of operating conditions)
TC_SR = [0, .5, .6, .7, .8, .87, .92, .94, .96, .97, 1]; % Torque Converter Speed Ratio (Matlab default) -> TurbSpd/PumpSpd
TC_TR = [2.232, 1.5462, 1.4058, 1.2746, 1.1528, 1.0732, 1.0192, 1, 1, 1, 1]; % Torque Converter Torque Ratio (Matlab default) -> TurbTrq/PumpTrq
TC_Cf = 1e-4 * [.72558, .66322, .63463, .59042, .51331, .4144, .29287, .22444, .12186, .04386, 0]; % Torque Converter Capacity Factor (Matlab default) -> PumpTrq/PumpSpd^2 [Nm/rpm^2]
load Vehicle_Data/Engine_data_1_9L_Saturn_95kW
load Vehicle_Data/Trans_Shift_map
%% Driver Parameters
Kp = 10; % P gain for driver PI model
Ki = 1; % I gain for driver PI model
Drive_Cycle_Select = 1; % Drive cycle selection
% Drive cycle values in m/s
if Drive_Cycle_Select == 1
load DriveCycles/UDDS;
elseif Drive_Cycle_Select == 2
load DriveCycles/HWFET;
elseif Drive_Cycle_Select == 3
load DriveCycles/FTP;
elseif Drive_Cycle_Select == 4
load DriveCycles/US06;
elseif Drive_Cycle_Select == 5
load DriveCycles/NEDC;
elseif Drive_Cycle_Select == 6
load DriveCycles/WLTP;
end
time_end = cyc_time(end);
vel_end = cyc_vel(end);
THE SIMULINK MODEL:
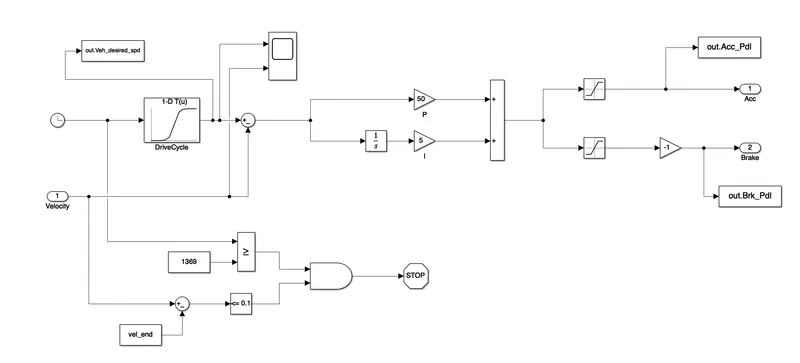
- In this model using a driver block to calculate the acceleration & brake pedal output to match the desired actual vehicle speeds.
- The acceleration and brake pedal data is calculated using the drive cycle data is feed in the 1-D look up table.
DRIVER BLOCK:
CONTROLLER BLOCK:
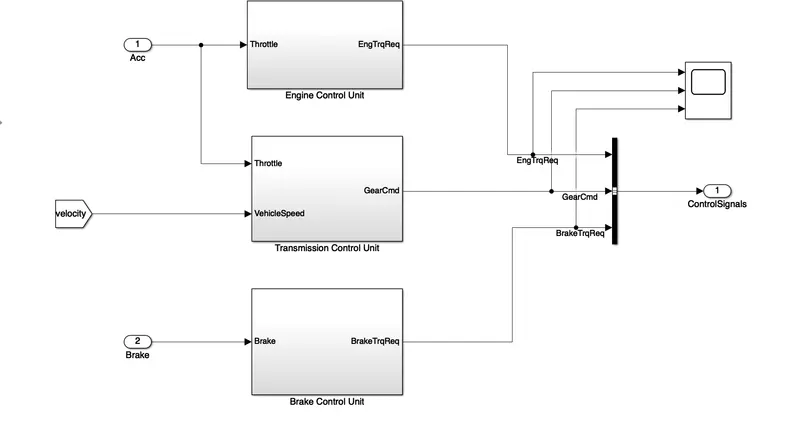
- Next to driver block controller block is connected. The controller block is the brain of the vehicle it gives the electrical signal out. Based on the driver inputs, it generates desired engine torque and transmission and brake torque
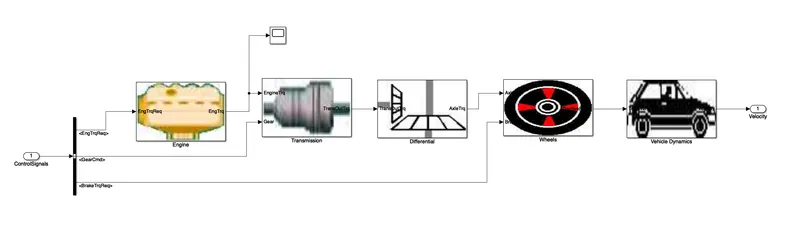
The data inputs are fed to the ‘Powertrain’ block which represents the drivetrain of the vehicle. It consists of an ‘Engine’ connected to the ‘Automatic Transmission’ through a ‘Torque Converter’. The output of the transmission is connected to the ’Differential’, which powers the ‘Wheels’, that provides the tractive force for vehicle acceleration. The longitudinal dynamics of the vehicle along with the road load is represented in the ‘Vehicle Dynamics’ block. The solver selected is ode3 with a fixed step size of 0.01 sec.
POWER TRAIN:
THE ENGINE BLOCK:
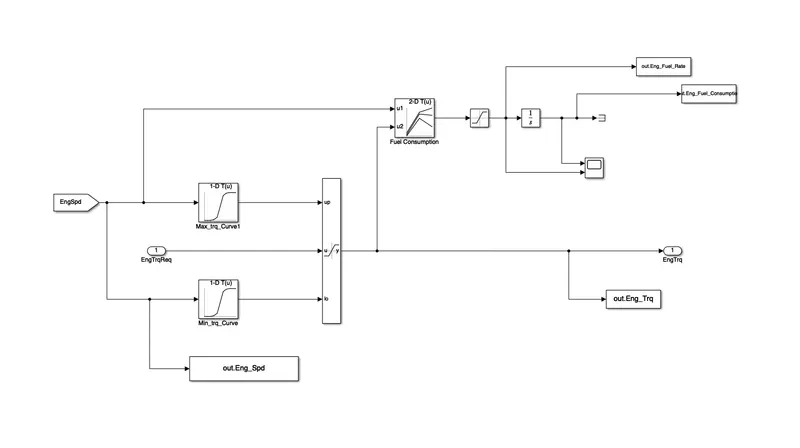
THE TRANSIMISSION BLOCK:
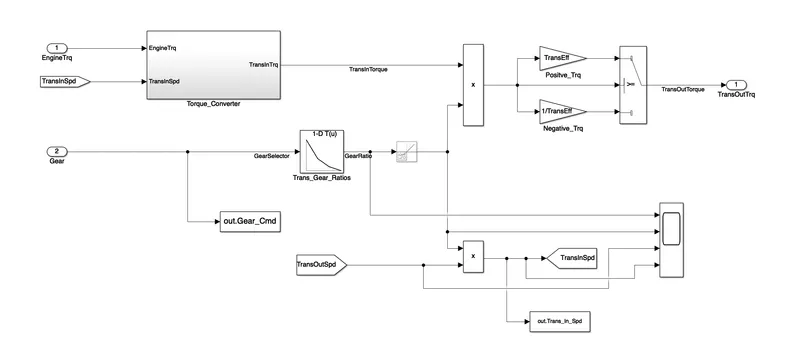
THE DIFFERENTIAL BLOCK:
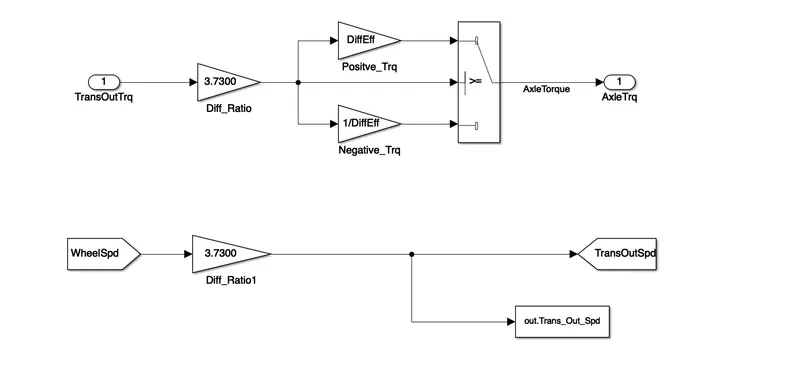
THE WHEEL BLOCK:
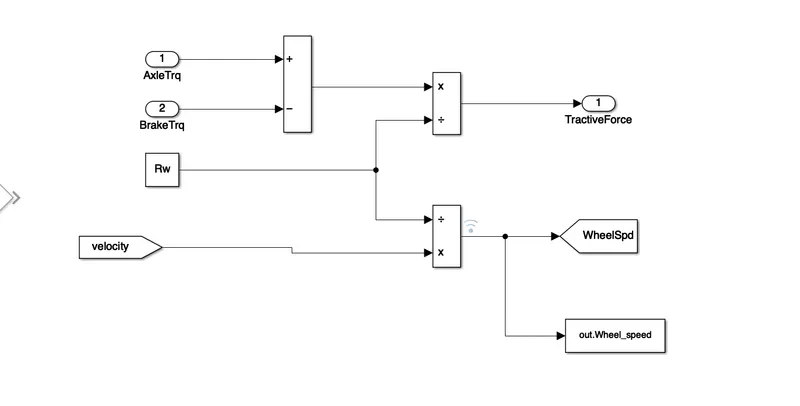
THE VECHICLE DYNAMICS BLOCK:
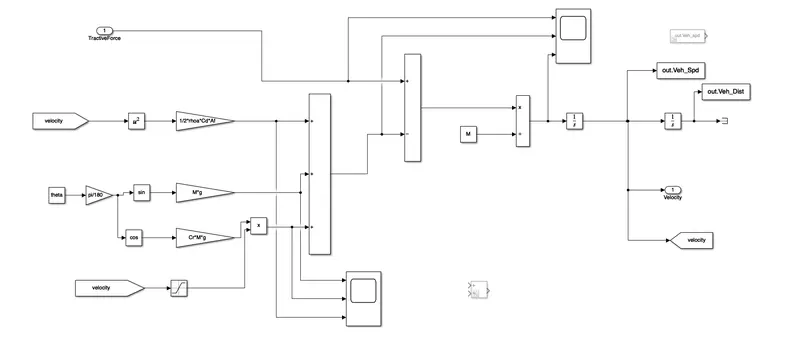
THE FORMULA USED
% calculation
Vveh = sqrt((efft*ratio/Rw*Tm - Cr*M*g)*2/rhoa/Af/Cd)
%vehical velocity
Vveh_kmp = Vveh*18/5
% road load
Fnload = 1/22^rhoa*Cd*Af*(Vveh + Vwind).^2 + Cr*M*g*cosd(theta) + M*g*sind(theta)
Tload = Fnload*Vveh/1000
% powertrain speed
speed = ratio*Vveh/Rw;
speed_rpm = speed*30/pi
POST PROCESSING:
- The data from the Simulink model we are transferring the data to the matlab workspace using block called ‘to workspace’
- The matlab code is used to generate the necessary plots.
THE CODE:
%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%
%% Skill-Lync -> Hybrid Drives Development
% Project 1 - Conventional Vehicle Model
% By - gowtham
% Description:
% The following file is to used with the Initialization file and Simulink
% results for post-processing of the data.
% The file is incomplete, has some examples of how the data is imported
% into a readable format, data analysis and plotting examples.
% Based on the project task, use commands in a similar format as given
% below, to analyse the data and generate required plots.
% You can change variable names if desired
%% Post-Processing File
% File for post-processing the Conventional vehicle simulation model data
%% Renaming variables
Time = out.tout;
Acc_Pdl = out.Acc_Pdl; % Accelerator pedal [%]
Brk_Pdl = out.Brk_Pdl; % Brake pedal [%]
Gear_Cmd = out.Gear_Cmd; % Transmission gear
Trans_In_Spd = out.Trans_In_Spd*30/pi; % Transmission input speed [rpm]
Trans_Out_Spd = out.Trans_Out_Spd*30/pi;% Transmission output speed [rpm]
Eng_Trq = out.Eng_Trq; % Engine brake torque [Nm]
Eng_Spd = out.Eng_Spd*30/pi; % Engine speed [rpm]
Eng_Fuel_Consump = out.Eng_Fuel_Consumption; % Engine fuel consumption [g]
Veh_Dist = out.Veh_Dist/1000; % Distance traveled by vehicle [km]
Veh_Spd = out.Veh_Spd*18/5; % Vehicle speed [kmph]
Wheel_speed = out.Wheel_speed.Data; % Wheel speed [kmph]
Eng_Fuel_rate = out.Eng_Fuel_Rate; % Engine Fuel Rate [%]
Veh_Desired_Sped = out.Veh_desired_spd; % Desired Vehicle Speed [kmph]
%% Data Analysis
Eng_Pwr = Eng_Spd*pi/30*Eng_Trq/1000; % Engine brake power [kW]
rho_petrol = 0.7197; % Density of petrol [kg/L]
kmpl = Veh_Dist(end)/(Eng_Fuel_Consump(end)/1000/rho_petrol); % Fuel economy [kmpl]
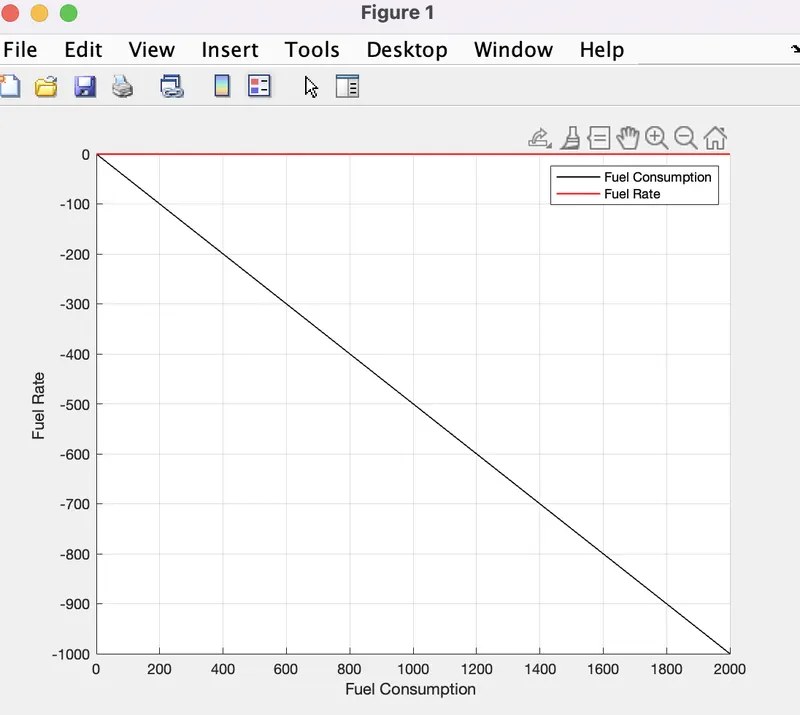
%% PLotting Fuel Consumption vs Fuel Rate
figure(1)
hold on
grid on
plot(Time, Eng_Fuel_Consump.Data, 'linewidth', 1, 'Color', 'black');
plot(Time, Eng_Fuel_rate.Data, 'linewidth', 1, 'Color', 'red');
xlabel('Fuel Consumption ')
ylabel('Fuel Rate ')
xlim([0, Time(end)]);
legend('Fuel Consumption','Fuel Rate');
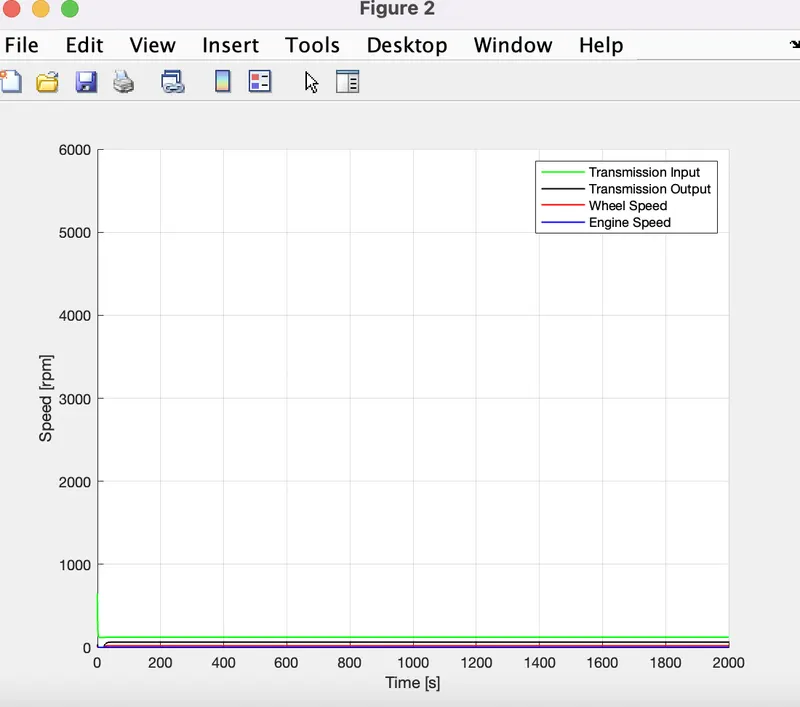
%% Plotting vehicle characteristics time trace Engine,Transmission Input, Transmission Output and Wheel Speed
figure(2)
hold on
grid on
plot(Time,Eng_Spd.Data,'LineWidth',1,'Color','g');
plot(Time,Trans_In_Spd,'LineWidth',1,'Color','black');
plot(Time,Trans_Out_Spd,'LineWidth',1,'Color','red');
plot(Time,Wheel_speed,'LineWidth',1,'Color','blue');
xlabel('Time [s]')
ylabel('Speed [rpm]')
xlim([0, Time(end)]);
ylim([0, 6000]);
legend('Transmission Input','Transmission Output','Wheel Speed','Engine Speed');
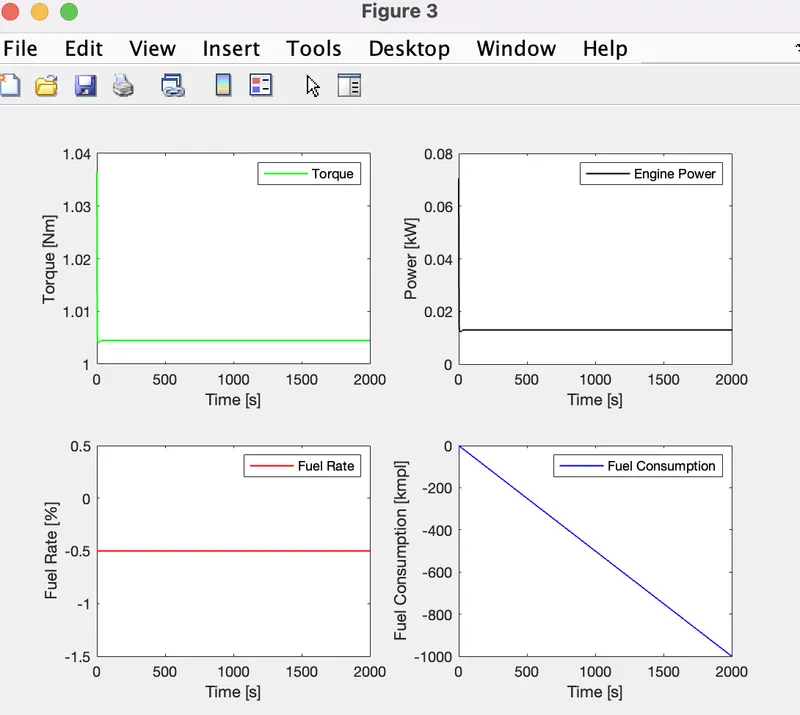
%% Plotting vehicle characteristics time trace engine torque, engine power, fuel rate and fuel consumption
figure(3)
subplot(2,2,1)
plot(Time,Eng_Trq.Data,'LineWidth',1,'Color','g')
xlabel('Time [s]')
ylabel('Torque [Nm]')
legend('Torque')
subplot(2,2,2)
plot(Time,Eng_Pwr.Data,'LineWidth',1,'Color','black')
xlabel('Time [s]')
ylabel('Power [kW]')
legend('Engine Power')
subplot(2,2,3)
plot(Time,Eng_Fuel_rate.Data,'LineWidth',1,'Color','red')
xlabel('Time [s]')
ylabel('Fuel Rate [%]')
legend('Fuel Rate')
subplot(2,2,4)
plot(Time,Eng_Fuel_Consump.Data,'LineWidth',1,'Color','blue')
xlabel('Time [s]')
ylabel('Fuel Consumption [kmpl]')
legend('Fuel Consumption')
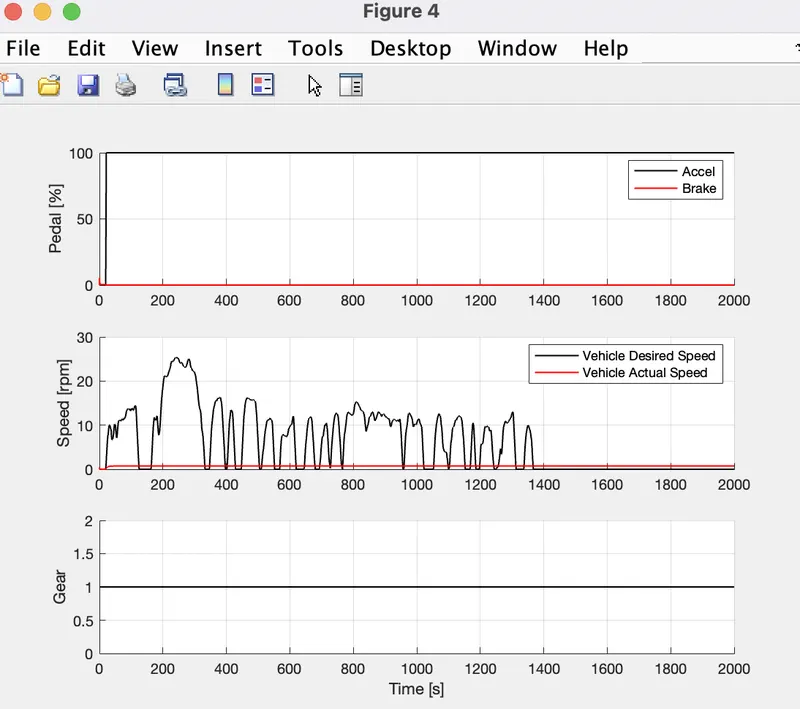
%% Plotting vehicle characteristics time trace accelerator and brake pedal, gear command, vehicle desired and
%actual speed.
figure(4)
subplot(3,1,1)
hold on
grid on
plot(Time, Acc_Pdl, 'linewidth', 1, 'Color', 'black');
plot(Time, Brk_Pdl, 'linewidth', 1, 'Color', 'red');
ylabel('Pedal [%]')
xlim([0, Time(end)]);
legend('Accel','Brake');
subplot(3,1,2)
hold on
grid on
plot(Time,Veh_Desired_Sped.Data, 'linewidth', 1, 'Color', 'black');
plot(Time,Veh_Spd.Data, 'linewidth', 1, 'Color', 'red');
ylabel('Speed [rpm]')
xlim([0, Time(end)]);
legend('Vehicle Desired Speed','Vehicle Actual Speed');
subplot(3,1,3)
hold on
grid on
plot(Time, Gear_Cmd, 'linewidth', 1, 'Color', 'black');
xlim([0, Time(end)]);
xlabel('Time [s]');
ylabel('Gear');
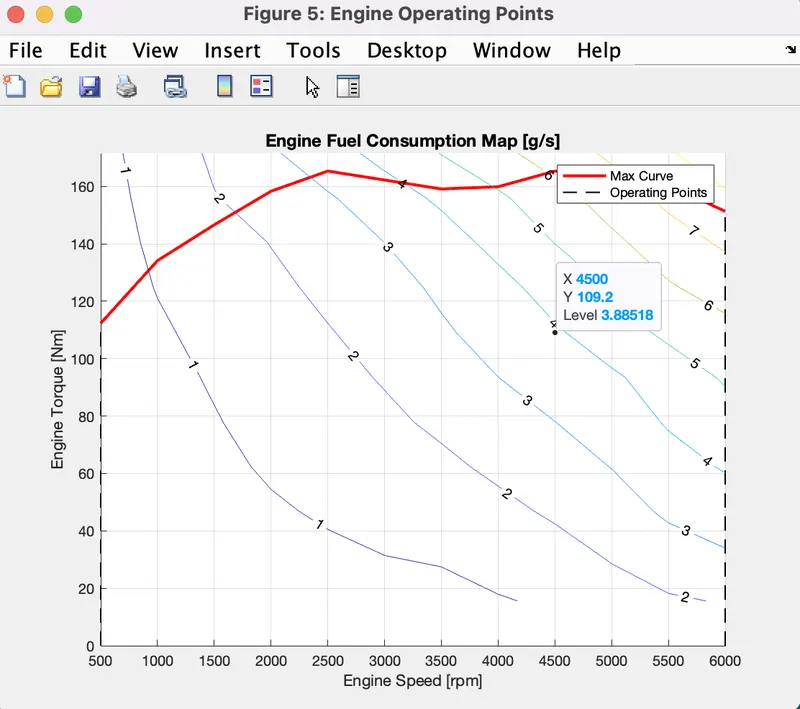
%% Plotting engine operating points on engine fuel map
figure('Name','Engine Operating Points');
hold on
grid on
title('Engine Operating Points','fontsize',12);
p1=plot(Eng_map_spd*30/pi,Eng_max_trq,'linewidth',2,'color','r');
p2=line([Eng_map_spd(end)*30/pi Eng_map_spd(end)*30/pi],[0 Eng_max_trq(end)]);
set(p2,'linewidth',1,'linestyle','--','color','k');
p3=line([Eng_map_spd(1)*30/pi Eng_map_spd(1)*30/pi],[0 Eng_max_trq(1)]);
set(p3,'linewidth',1,'linestyle','--','color','k');
[c,h] = contour(Eng_map_spd'*30/pi,Eng_map_trq,Eng_fuel_map');
clabel(c,h);
xlabel('Engine Speed [rpm]');
ylabel('Engine Torque [Nm]');
title('Engine Fuel Consumption Map [g/s]');
%p4 = plot(Eng_Spd,Eng_Trq,'.','color','k');
legend([p1 p3],{'Max Curve','Operating Points'});
axis([Eng_map_spd(1)*30/pi Eng_map_spd(end)*30/pi 0 Eng_map_trq(end)]);
PLOT: