Project 1
Develop a double-acting actuator model using Simscape Multibody and Simscape components. The mechanical system of the cylinder needs to be built using Simscape Multibody library components/blocks, and the hydraulic system needs to be modeled using Simscape library physical components.
Answer:-
Below shows the Double acting cylinder in three configurations: half-retracted, fully retracted and fully extended.
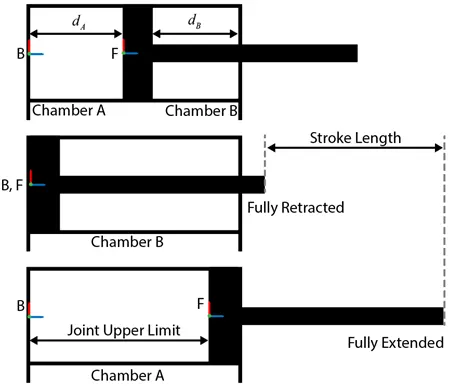
You can model the mechanical part of the system in Simscape Multibody. For example, to model the cylinder and piston, you can use the Revolved Solid (Simscape Multibody) and Cylindrical Solid (Simscape Multibody) blocks. To provide the translational degree of freedom for the piston, use a Prismatic Joint (Simscape Multibody) block. To easily calculate the lengths of chambers A and B, you can attach the base frame (B) and follower frame (F) of the joint to the centers of the left inner surface of chamber A and the left surface of the piston, respectively. Make sure that the Z-axes of the B and F frames are aligned and both point toward chamber B.
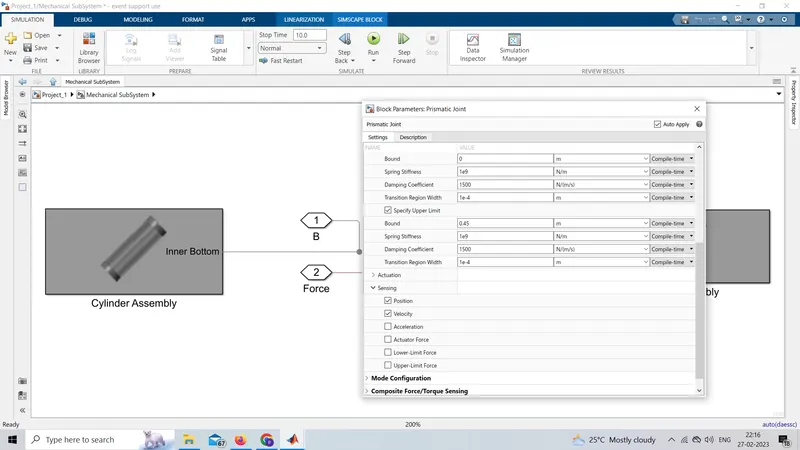
Using this convention, the length of chamber A, dA, is the position output of the joint block, and the length of chamber B, dB, equals the difference in the stroke length dA. To ensure that the piston does not travel beyond the ends of the cylinder, you can specify the upper and lower position limits of the Prismatic Joint block.
The below figure shows the block diagram of the double-acting cylinder model described above.
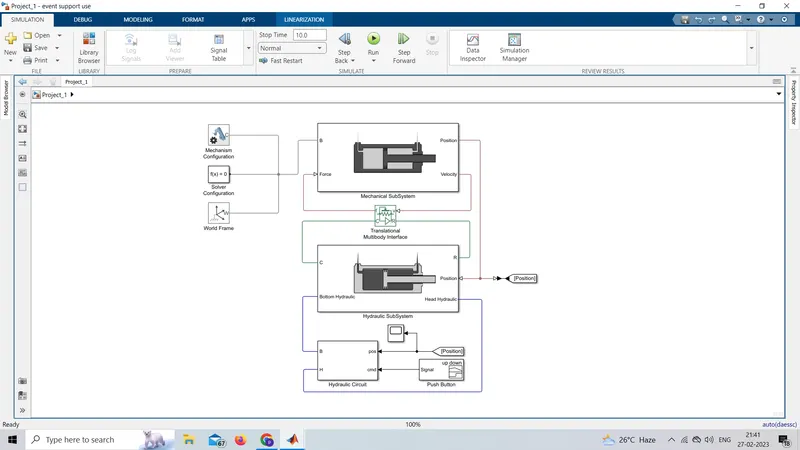
Mechanical SubSystem
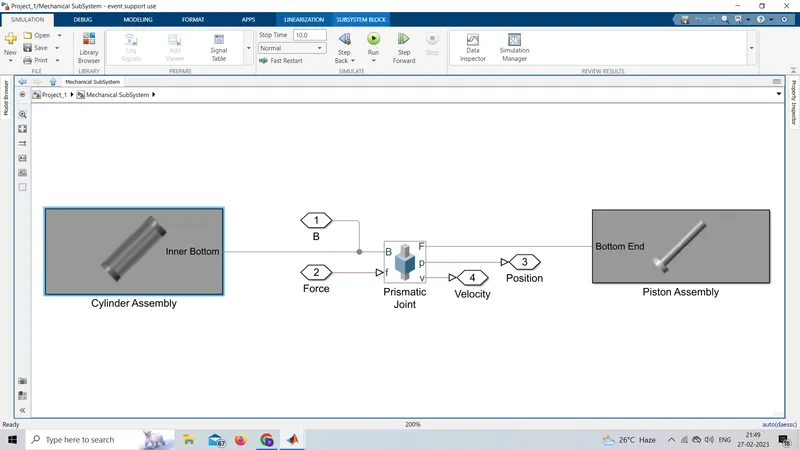
Cylinder Assembly
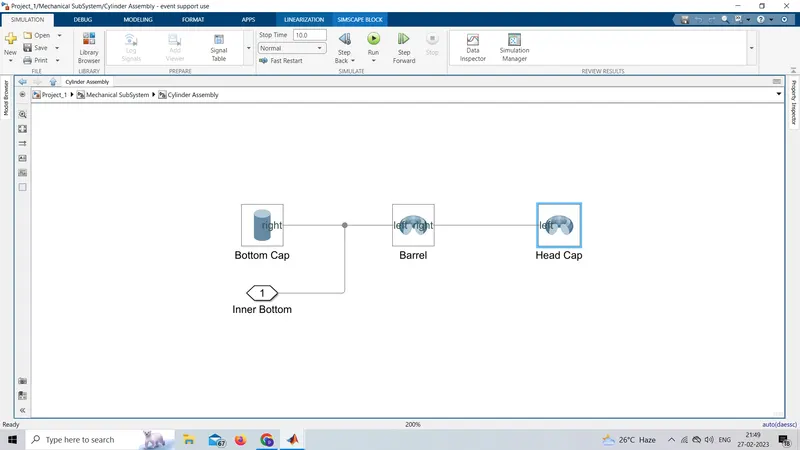
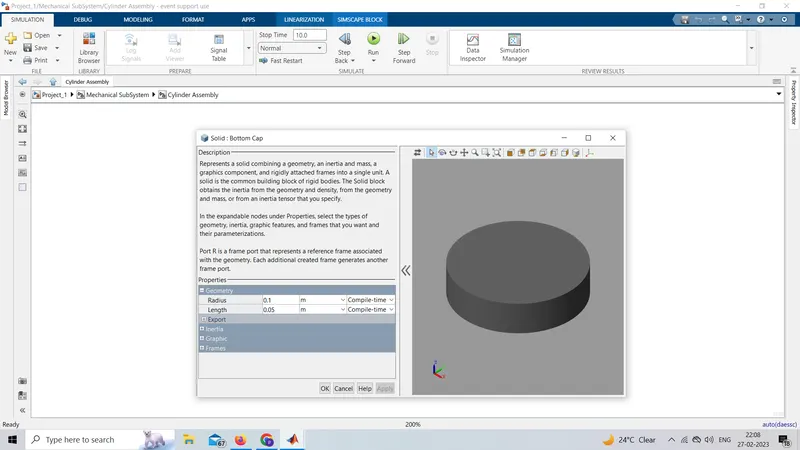
Bottom Cap
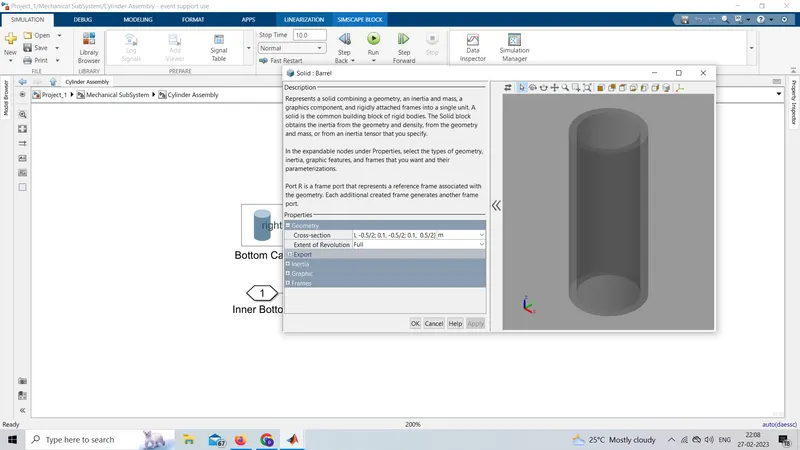
Barrel
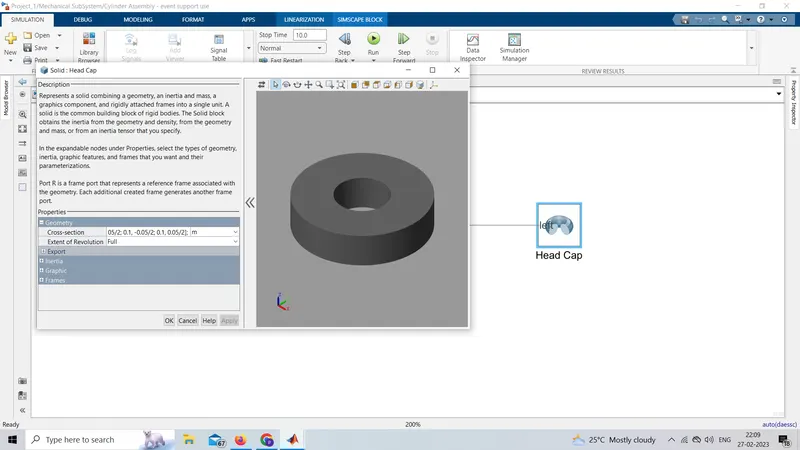
Head Cap
Prismatic Joint
Piston Assembly
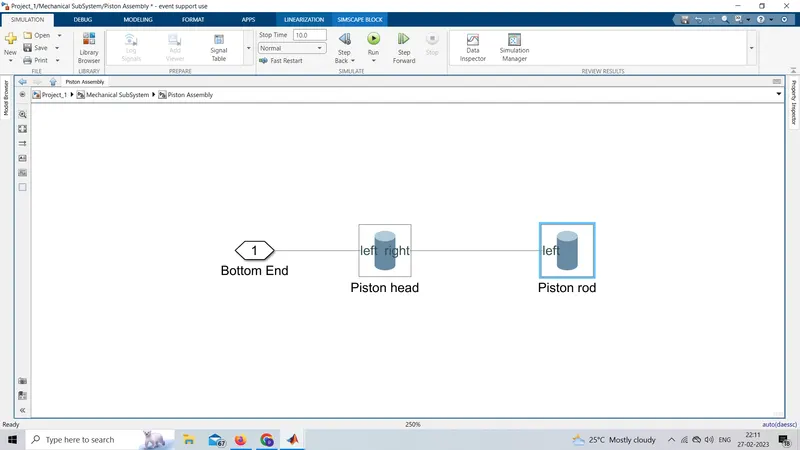
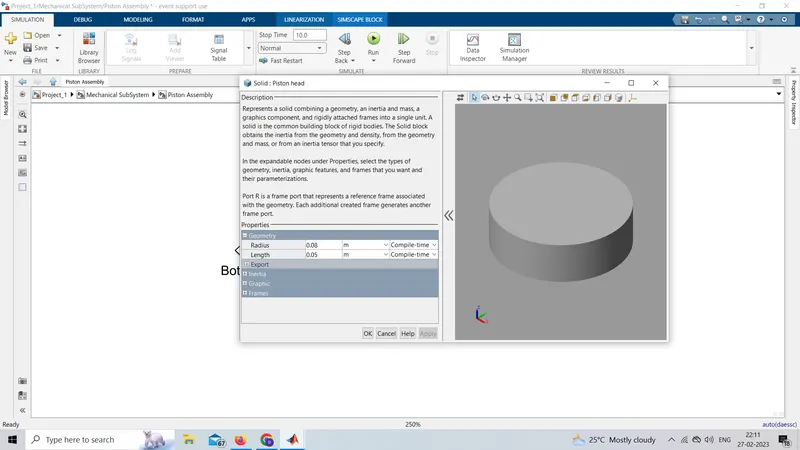
Piston head
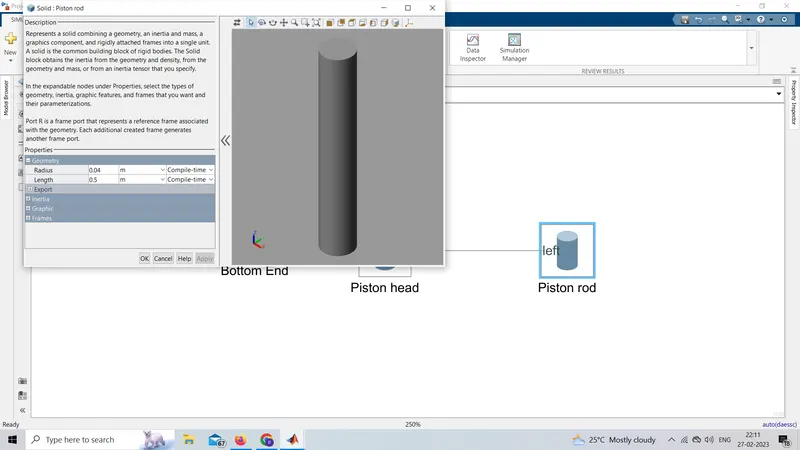
Piston rod
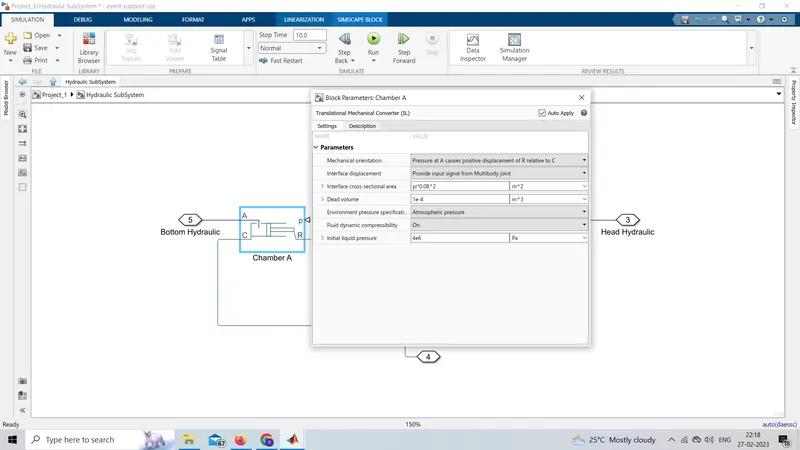
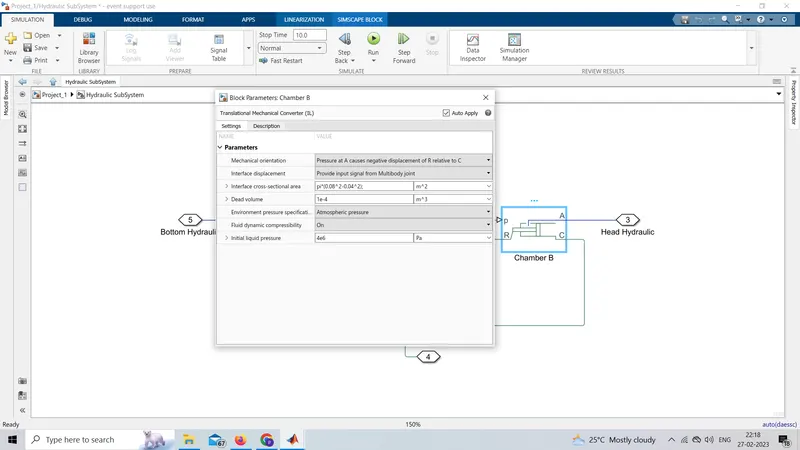
Hydraulic SubSystem
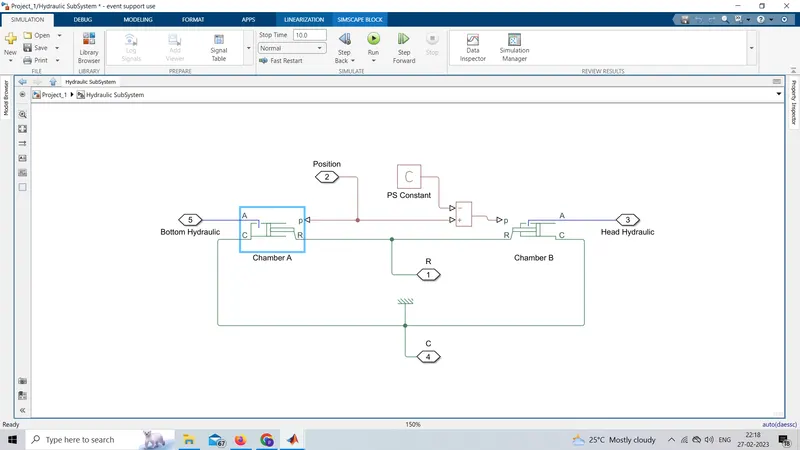
Chamber A
Chamber B
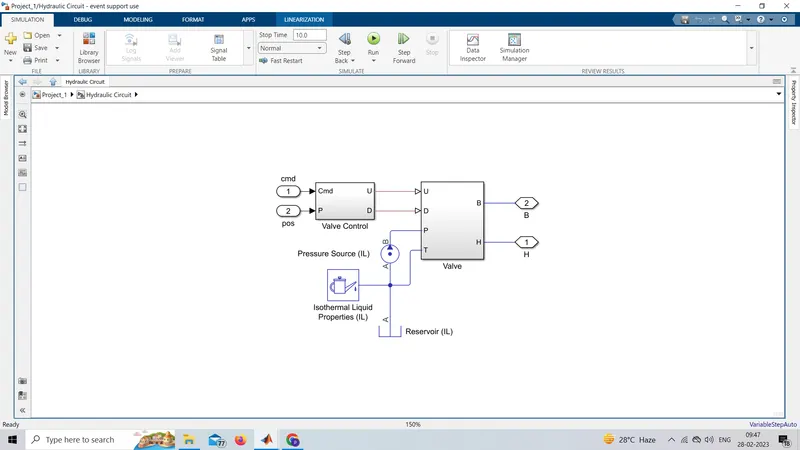
Hydraulic Circuit
Valve
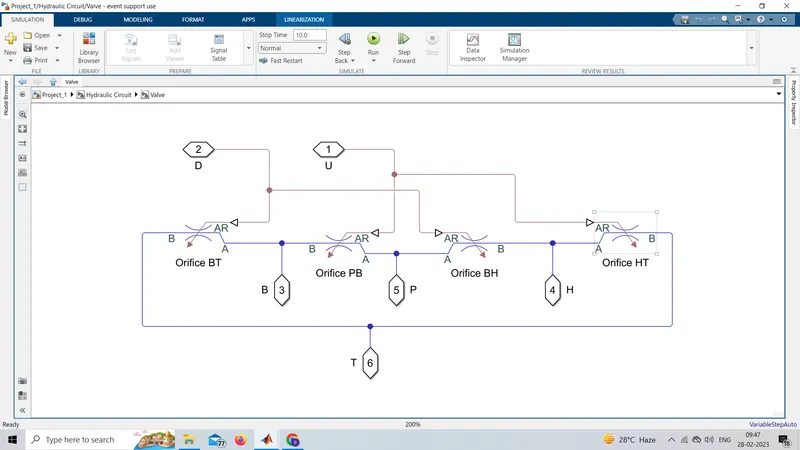
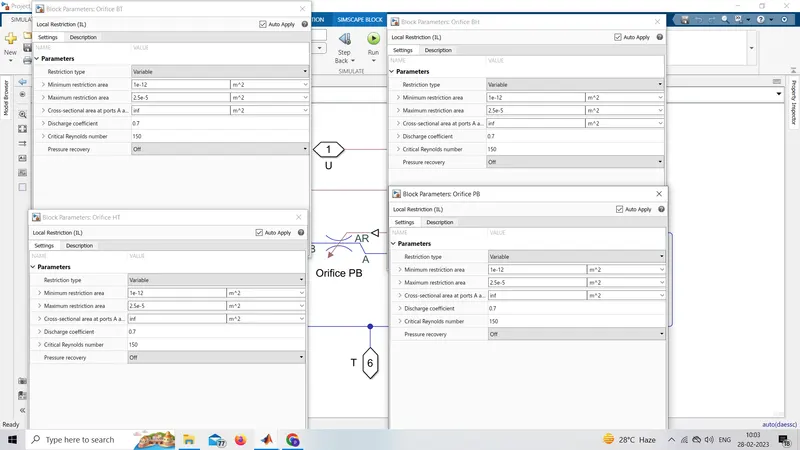
Orficies parameters
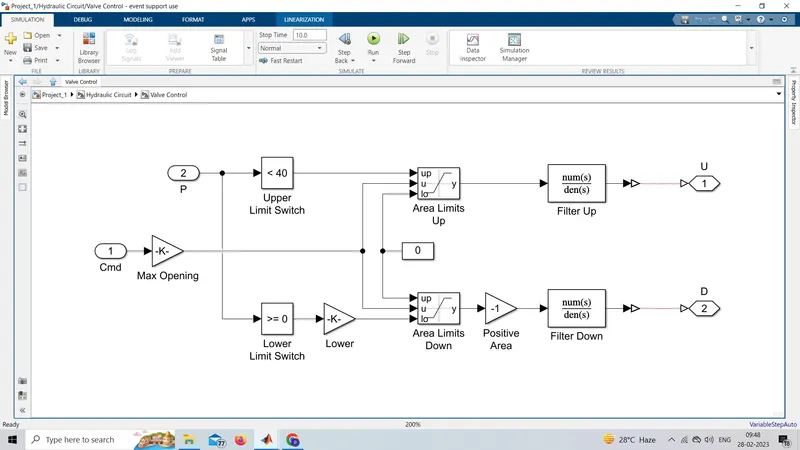
Valve Control
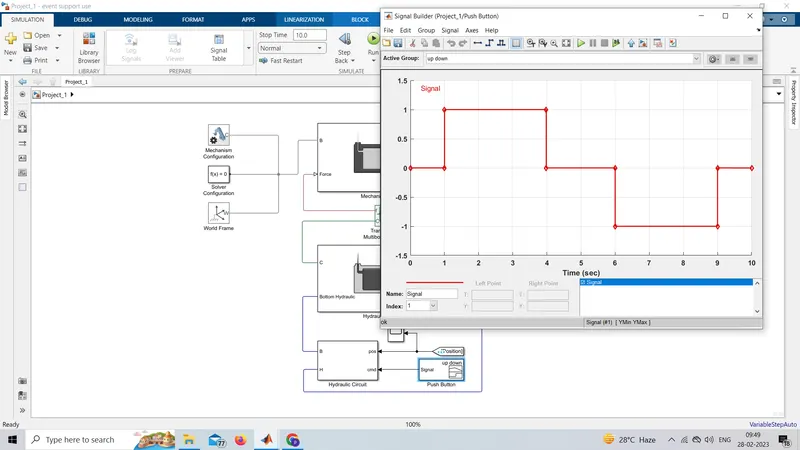
Input signal named as a Push Button
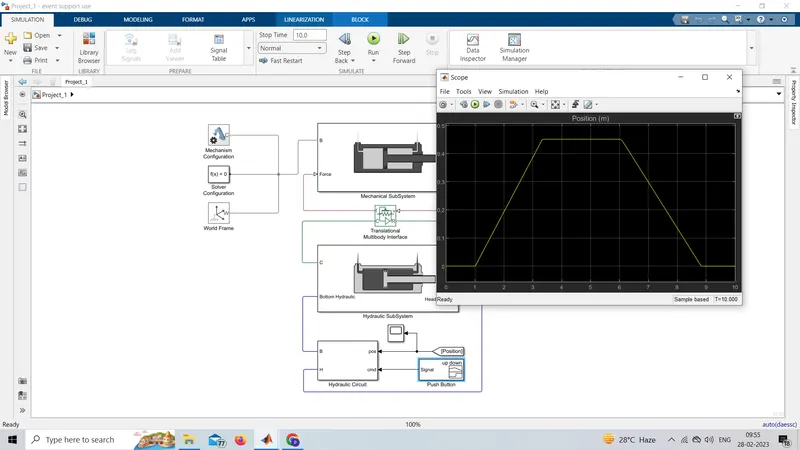
Output results screenshots are shown below
Scope output
Mechanical Explorer output
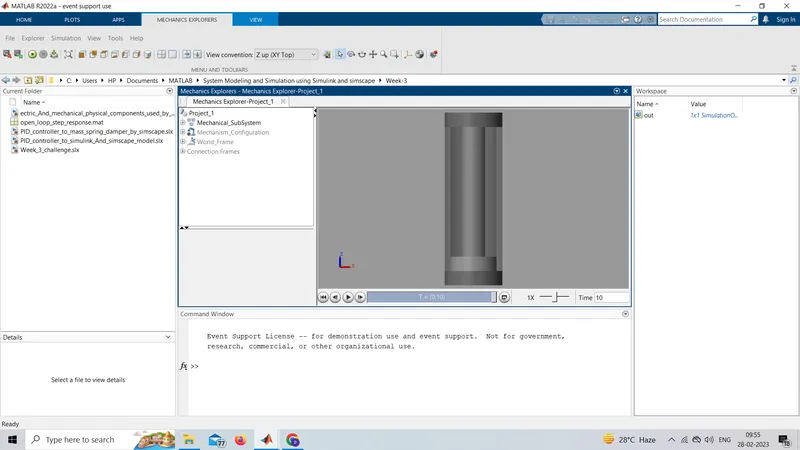
(Note:- The animation video of the double-acting actuator can be observed while running the Simulink file attached below.)