Project 1
Aim:
Develop a double-acting actuator model using Simscape Multibody and Simscape components.
Objective:
The mechanical system of the cylinder needs to be built using Simscape Multibody library components/blocks, and the hydraulic system needs to be modelled using Simscape library physical components.
Modelling of a Double-Acting Actuator:
This example shows how to model a double-acting actuator with Simscape Multibody and Simscape. Simscape Multibody models the mechanical system of the cylinder, and Simscape models the hydraulic system. You can use Translational Multibody Interface block to connect the two systems.
Cylinder Model
The schematics show the cylinder in three configurations: half-retracted, fully retracted, and fully extended.
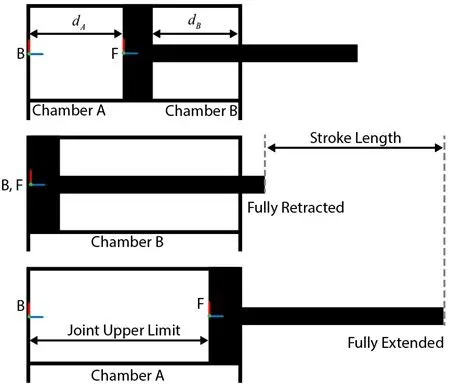
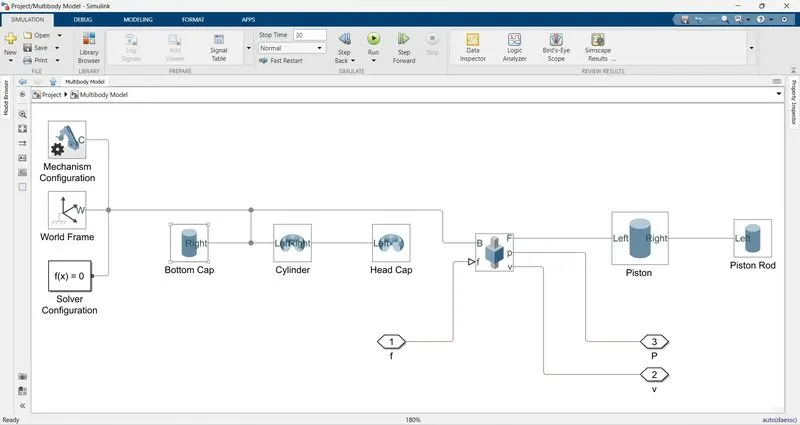
You can model the mechanical part of the system in Simscape Multibody. For example, to model the cylinder and piston, you can use the Revolved Solid (Simscape Multibody) & Cylindrical Solid (Simscape Multibody) blocks. To provide the translational degree of freedom for the piston, use a Prismatic Joint (Simscape Multibody) block. To easily calculate the lengths of the chambers A and B, you can attach the base frame (B) and follower frame (F) of the joint to the centres of the left inner surface of the chamber A and the left surface of the piston, respectively. Make sure that the Z-axes of the B and F frames are aligned and both point toward chamber B.
Using this convention, the length of the chamber A, dA, is the position output of the joint block, and the length of the chamber B, dB, equals the difference of the stroke length and dA. To ensure that the piston does not travel beyond the ends of the cylinder, you can specify the upper and lower position limits of the Prismatic Joint block.
The model of double acting cylinder as follows:
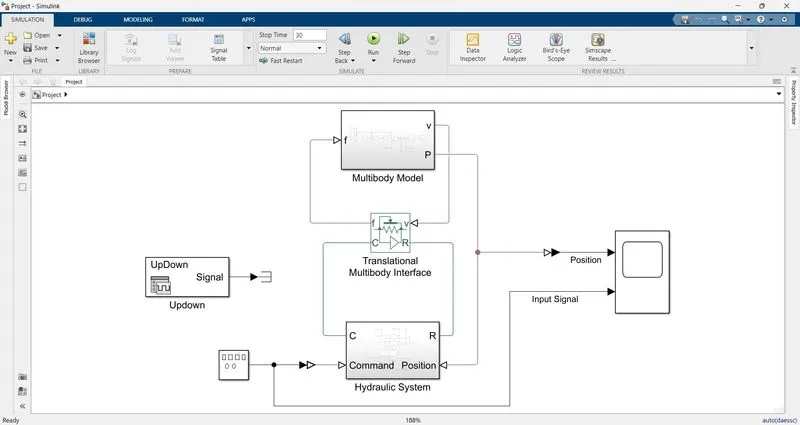
In above model the hydraulic system and multibody model is connected by translational multibody interface block. This block is an interface between a Simscape Multibody joint and a Simscape mechanical translational network. Ports R and C are mechanical translational conserving ports that connect to the two nodes in the mechanical translational network which share the same force and relative velocity as a primitive in the Multibody joint. Ports v and f are physical signal ports that connect to the Multibody joint. Input port v accepts the relative velocity sensing output from the joint primitive. Output port f provides the force actuation input to the joint primitive.
The Simscape Multibody model:
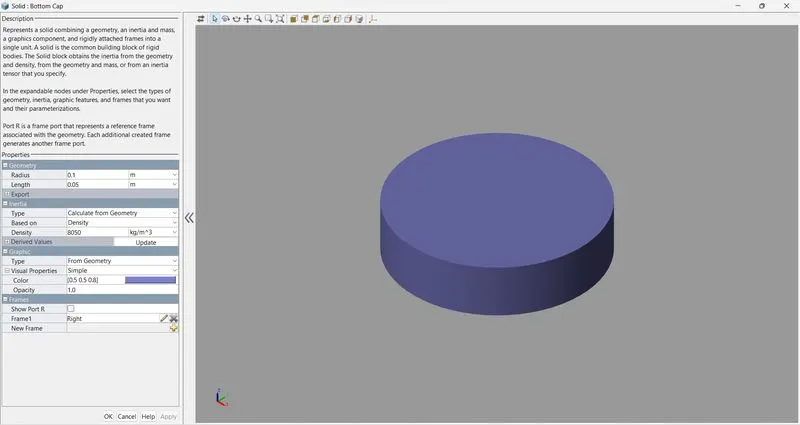
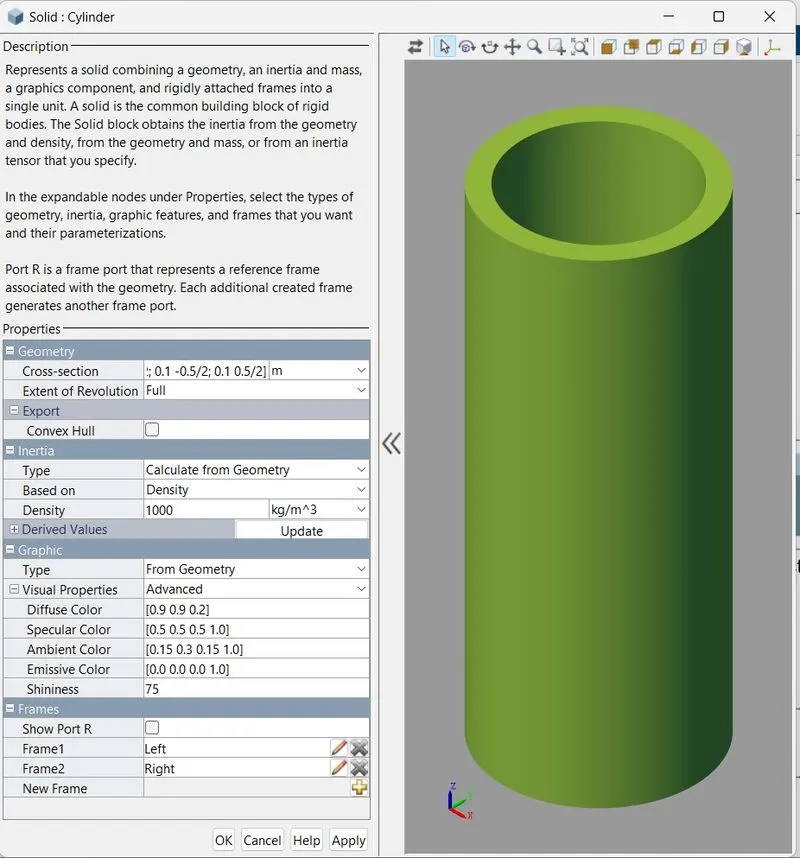
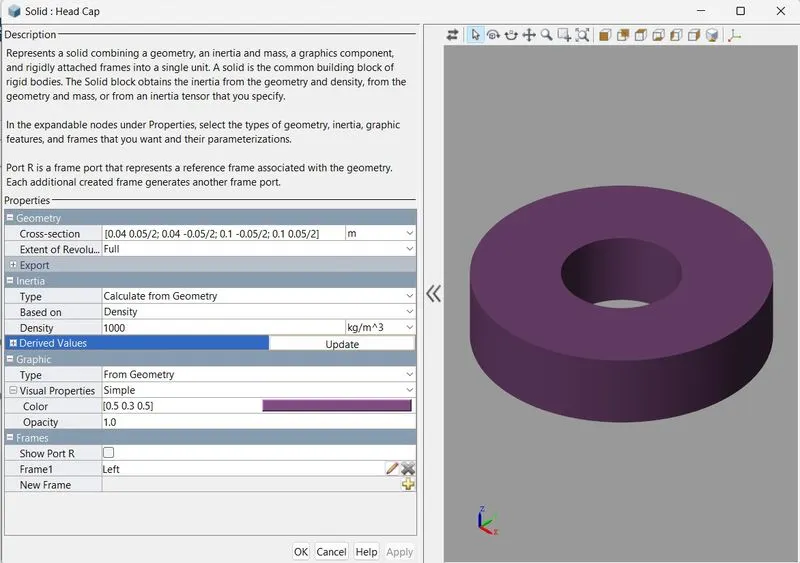
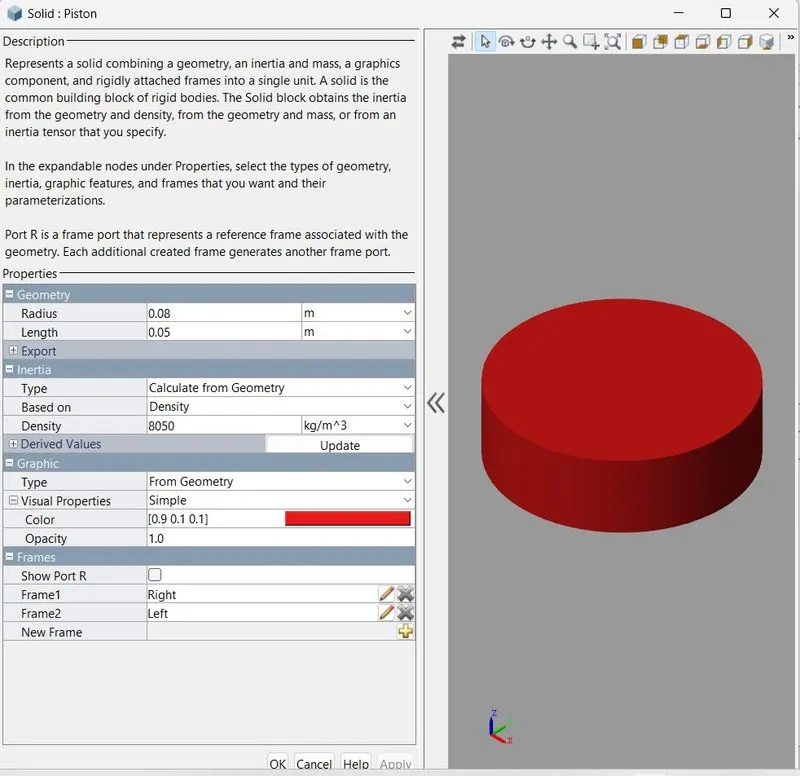
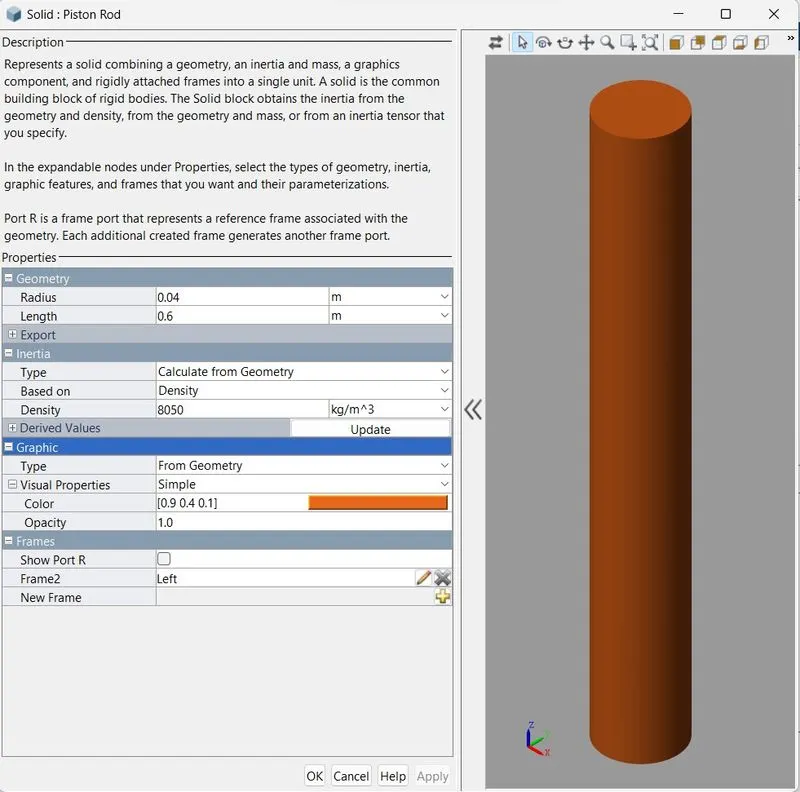
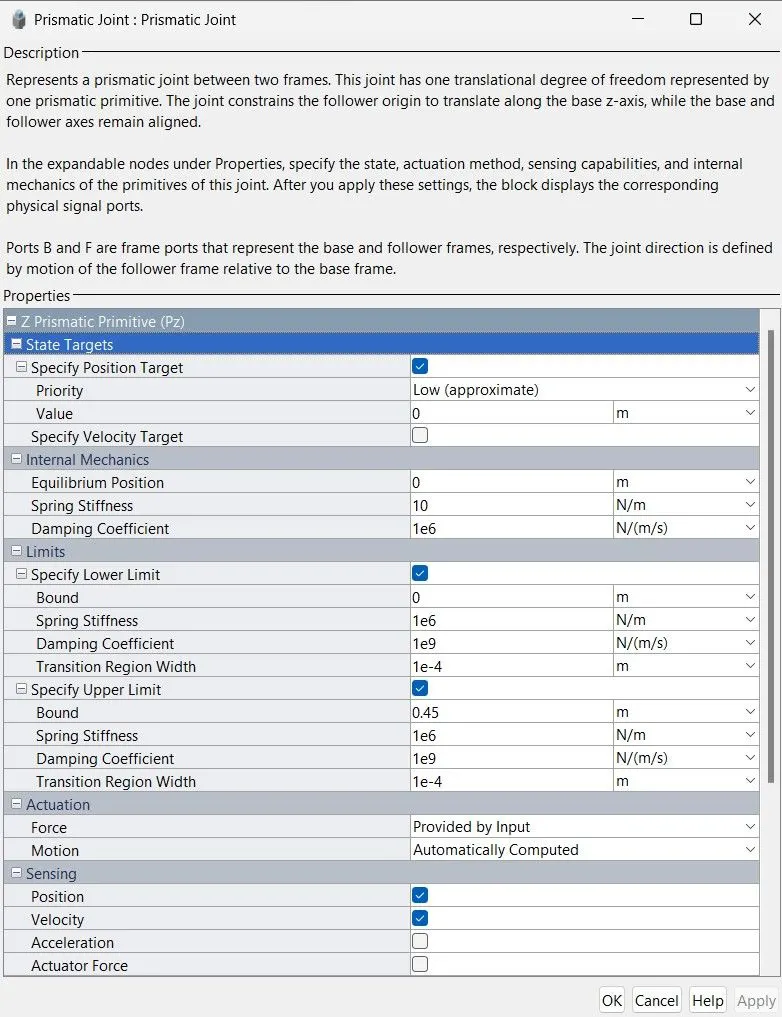
The Hydraulic system of Double acting cylinder model as follows:
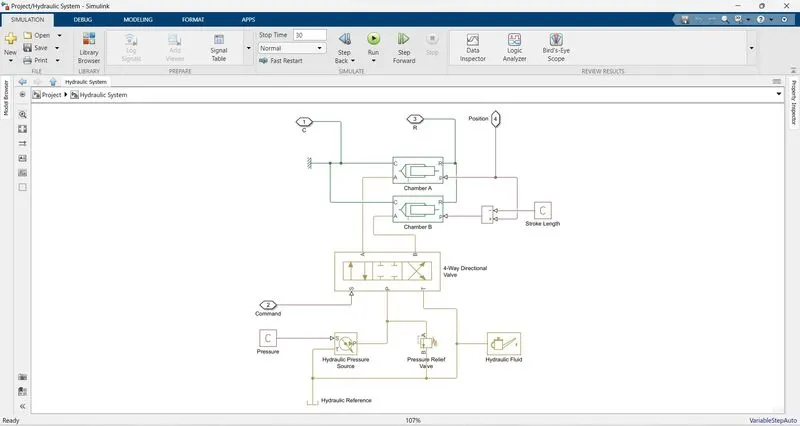
In the above model 4-way valve is one of the most commonly used pneumatic components for directional control. By providing four distinct flow paths, these valves make it easy to reverse the motion of a cylinder or motor.
Pressure relief valves (safety relief valves) are designed to open at a pre-set pressure and discharge fluid until pressure drops to acceptable levels.
A hydraulic fluid or hydraulic liquid is the medium by which power is transferred in hydraulic machinery. Common hydraulic fluids are based on mineral oil or water.
The Translational Hydro-Mechanical Converter block (Chamber A or B) models are an ideal transducer that converts hydraulic energy into mechanical energy, in the form of translational motion of the converter output member, and vice versa. The compressibility option makes the converter account for dynamic variations of the fluid density.
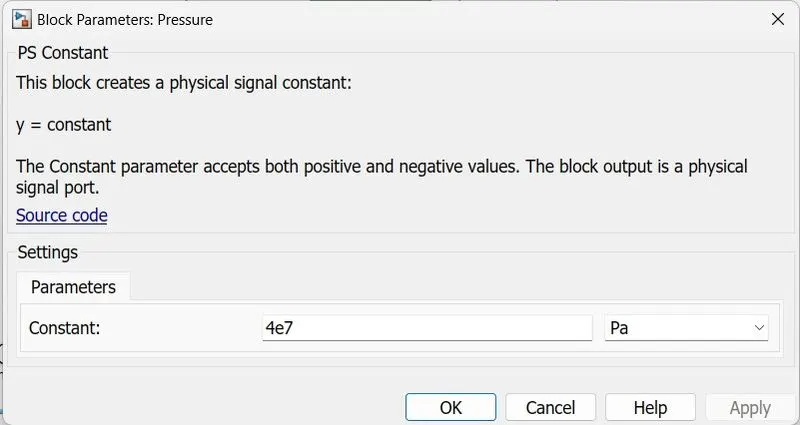
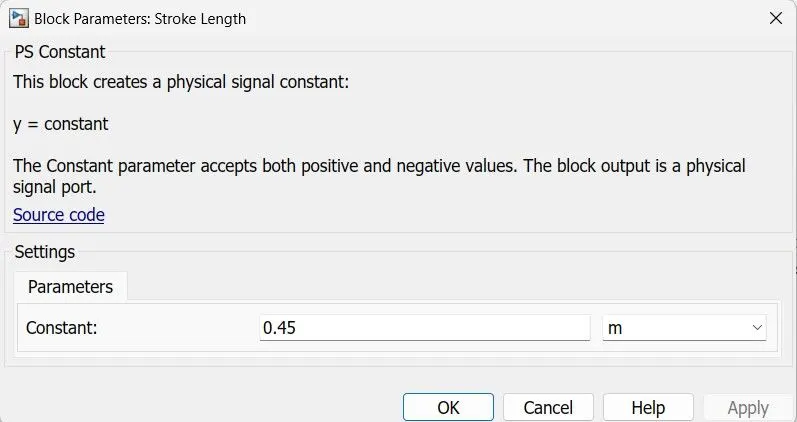
The above 2 constant blocks are used in the above model, one is for supply pressure & second one indicates stroke length.
The Hydraulic Pressure Source block represents an ideal source of hydraulic energy that is powerful enough to maintain specified pressure at its outlet regardless of the flow rate consumed by the system.
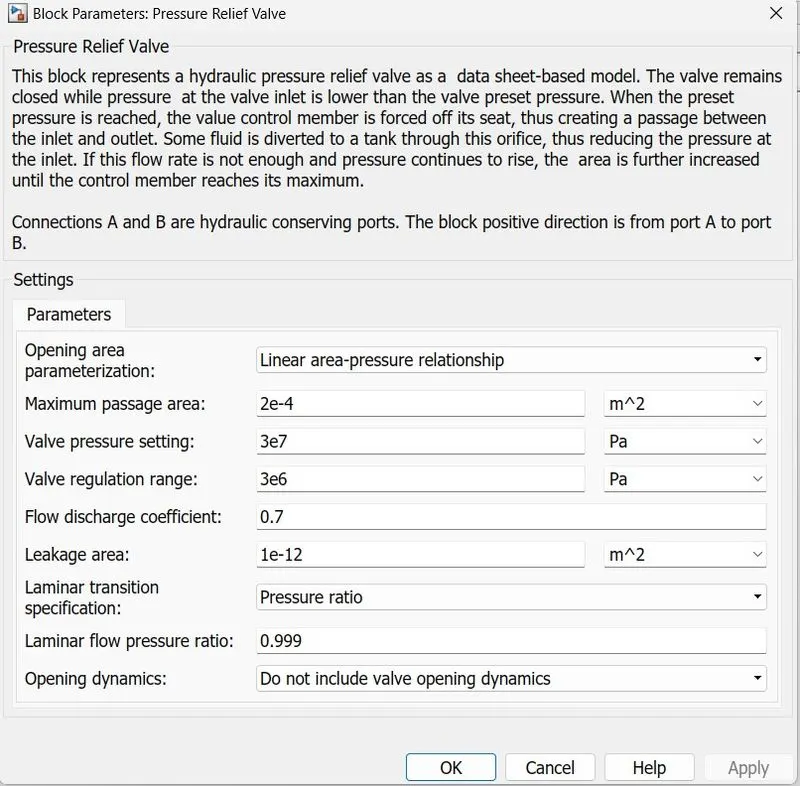
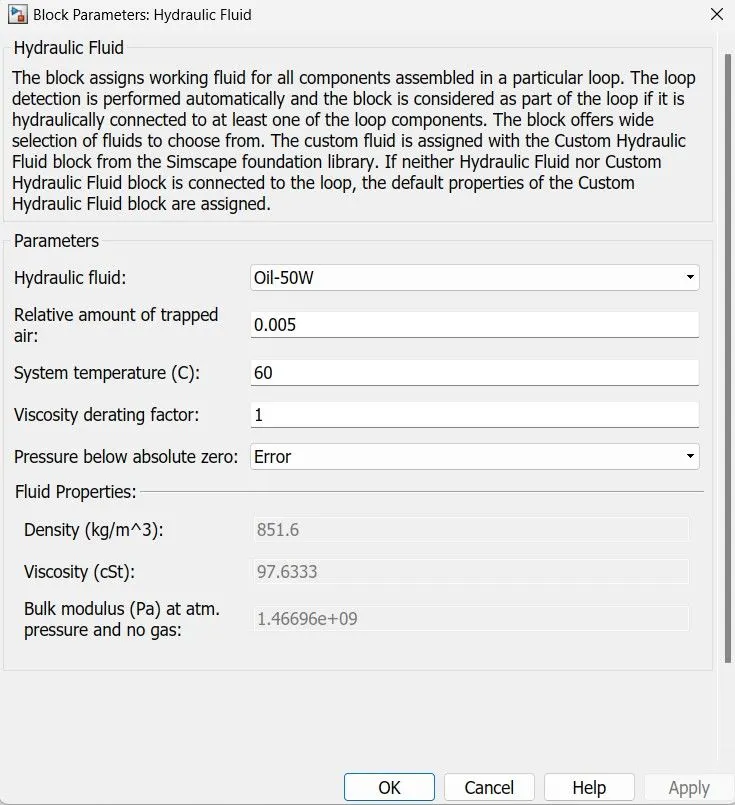
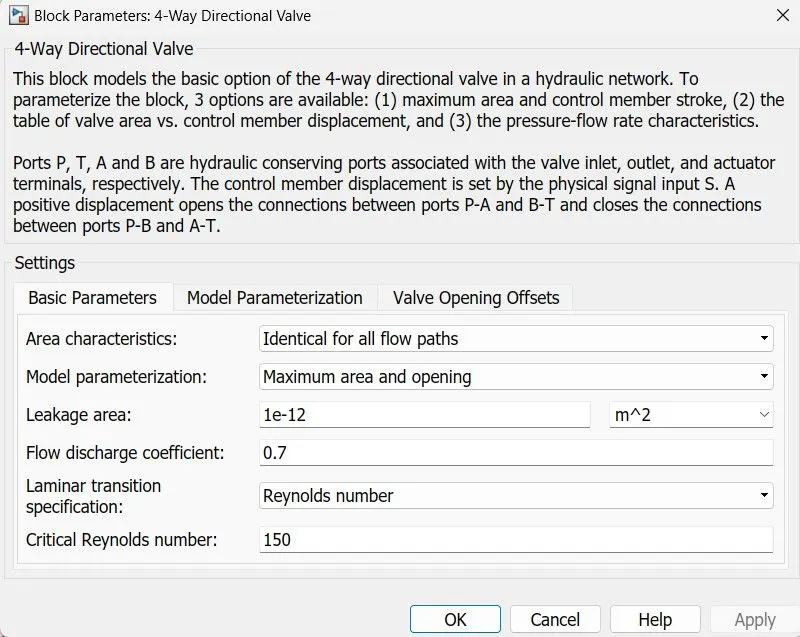
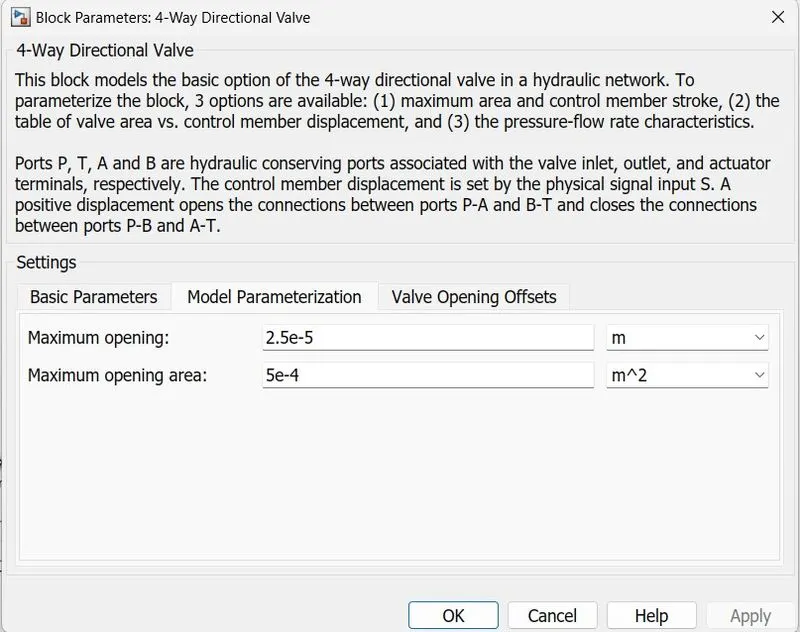
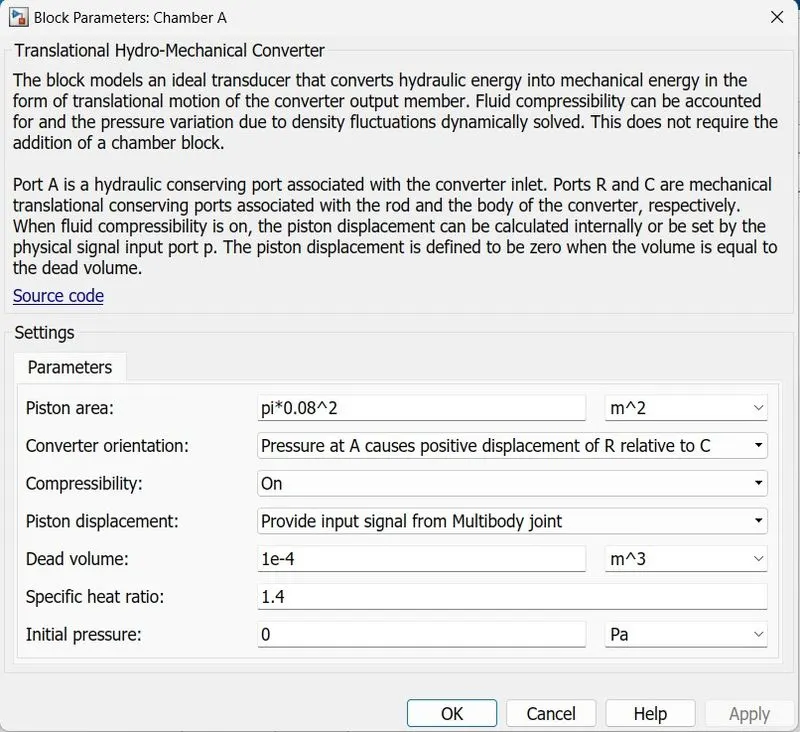
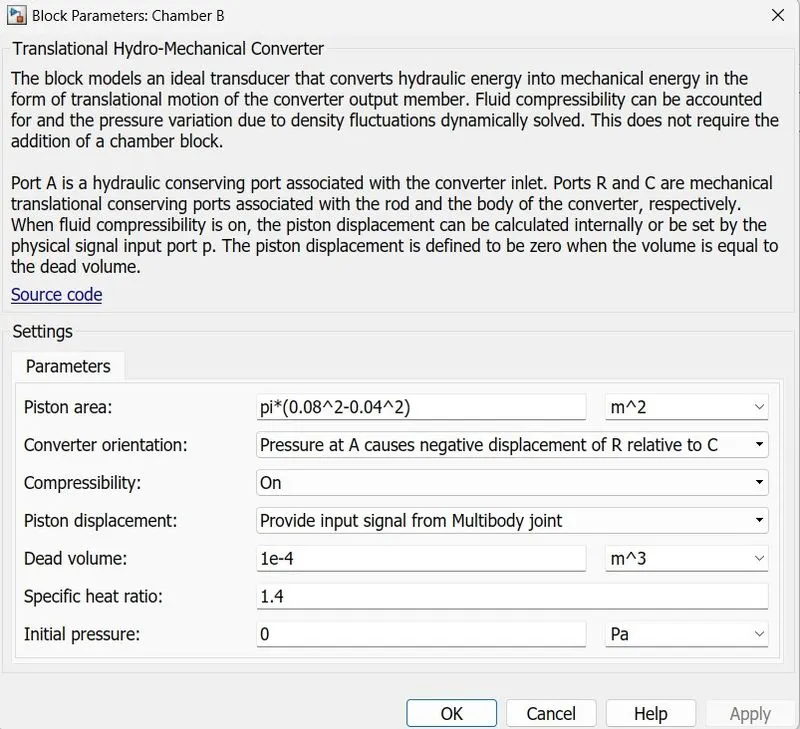
Chamber A is used for forward and chamber B is for reverse displacement of the piston.
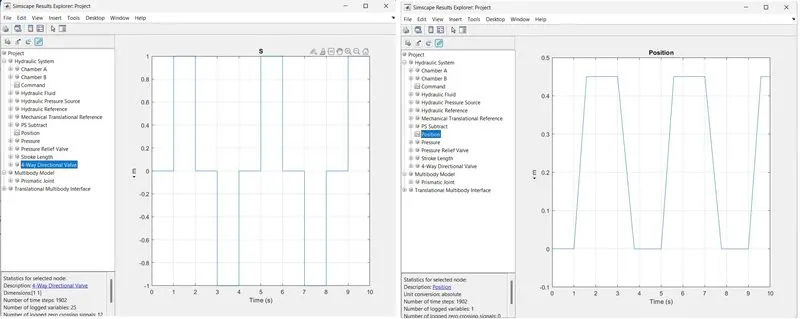
In this model me used 2 types of signals one is unlimited time another one is custom type which is limited time given by user.
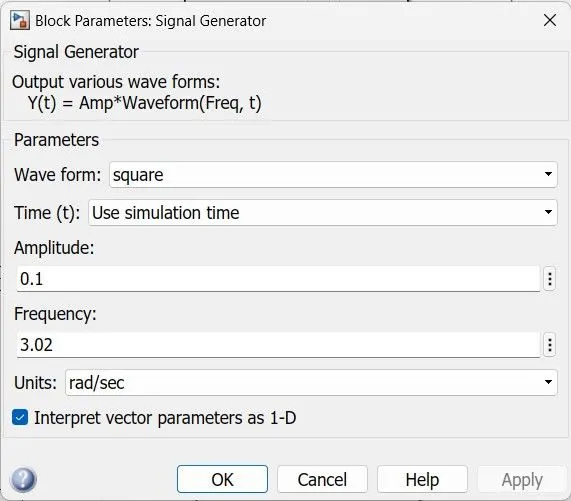
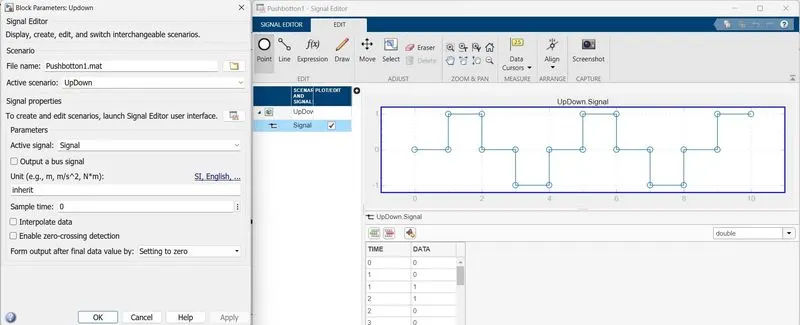
The Results are as follows:
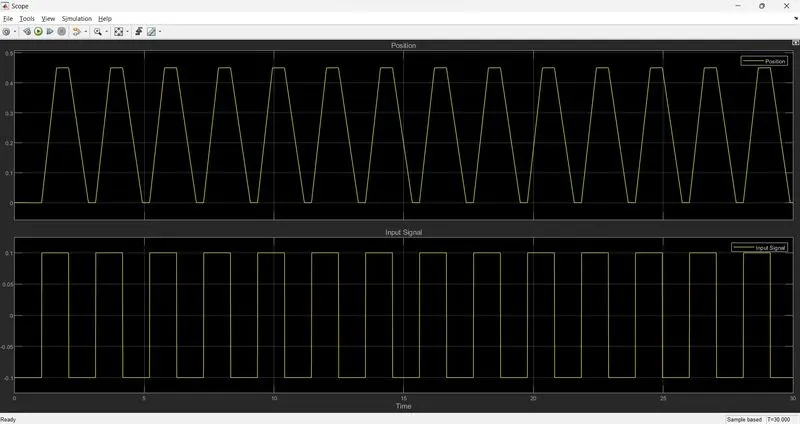
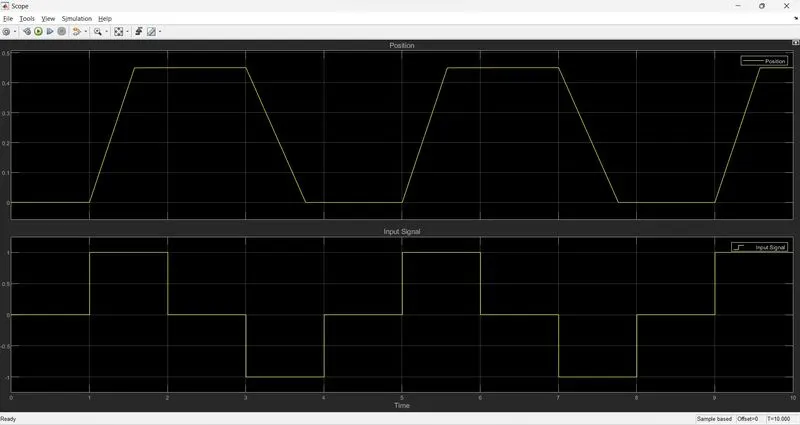
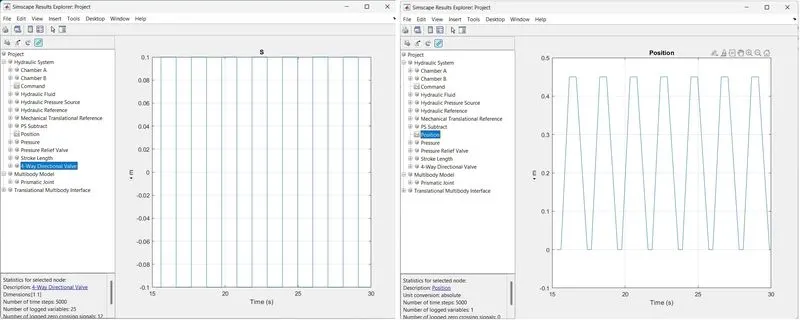
The first scope results are generated by automated signal for 30secs. The second scope results are generated by custom signal for 10 seconds. The mechanics results are attached as .AVI file for both signals.
The mechanisms block looks as follows and cylinder customized to show the inner mechanism.
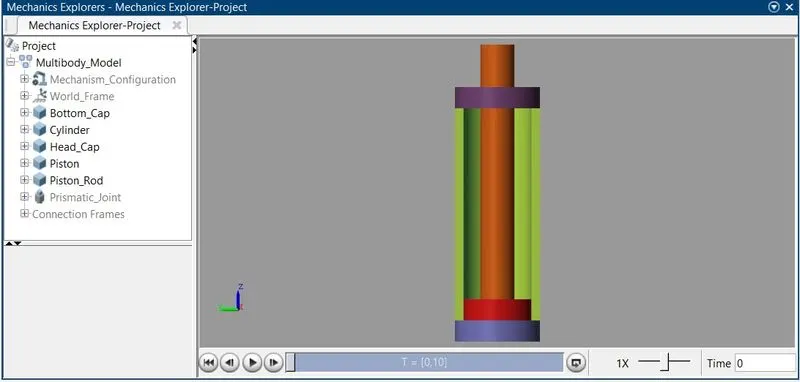
Simscape results:
The results of Cutom signal of 4way valve(input signal) and piston position
The results of automated signal of 4way valve(input signal) and piston position