Final Project: Electric Rickshaw modelling
FINAL PROJECT: ELECTRIC RICKSHAW MODEL.
Aim:
to Create a detailed MATLAB model of an electric rickshaw (three wheel passenger vehicle) as per details below:
Rear wheels driven by PM brushed type motor
Assume efficiency points of motor controller and motor
Make an excel sheet of all input and assumed data
Results: For any three standard driving cycles show energy consumption, temperature rise of motor and controller for 100 km constant speed driving at 45 kmph.
INTRODUCTION:
Electric rickshaws (also known as electric tuk-tuks or e-rickshaws or toto or e-tricycles) are small 3-wheeled vehicles powered by an electric motor and battery ranging from 650 to 1400 Watts. They save on fuel costs compared to auto rickshaws while offering greater ease-of-use than pulled rickshaws. This has led to their popularity and widened-acceptance in some cities since 2008.
If introduced in a systematic manner, electric rickshaws could be a low-emitter complementary transport for low-income people who suffer most from a lack of transport facility.They are mostly manufactured in India and China.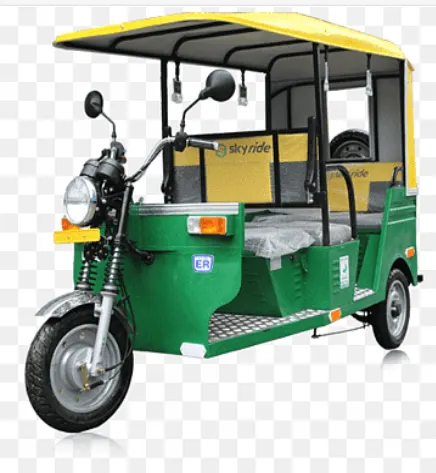
design and construction:
These rickshaws have a mild steel tubular chassis, consisting of three wheels with a differntial mechanism at the rear wheels. The motor is a brushless DC motor. The electrical system used in Indian versions is 48V and in Bangladesh is 60V. The body design from the most popular Chinese version is of very thin iron or aluminum sheets. Bodies made of fiberglass are also popular because of their strength and durability, resulting in low maintenance. Body design is varied from load carriers, passenger vehicles with no roof, to full body with windshields for drivers' comfort.
It consists of a controller unit. They are sold on the basis of voltage supplied and current output, also the number of mosfet (metal oxide field effect transistors) used. The vehicle's batteries are typically lead acid with a lifespan of 6–12 months.deep cycle batteries designed for electric vehicles are rarely used. Weight of the electric car has also been a recurring design difficulty in them.
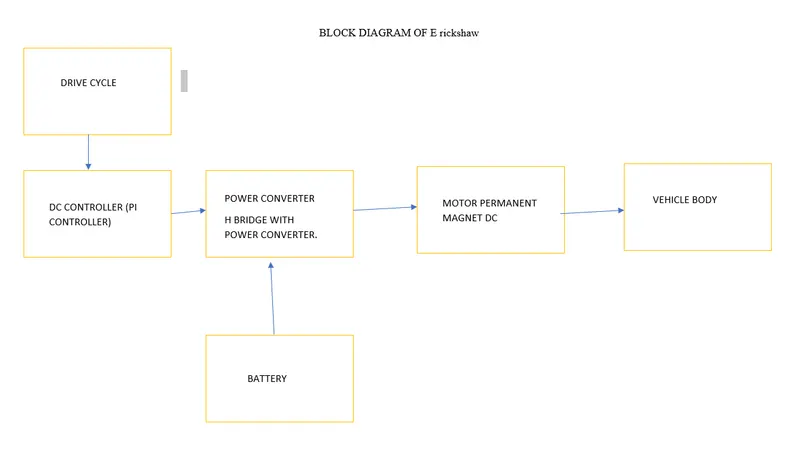
BLOCK DIAGRAM:
DRIVE CYCLE:
A drive cycle is typically represented by a series of data points which plots vehicle speed against time. Driving cycles are produced to assess the performance of vehicles in various ways, including fuel consumption and pollutant emissions.
PI CONTROLLER:
A P.I Controller is a feedback control loop that calculates an error signal by taking the difference between the output of a system, which in this case is the power being drawn from the battery, and the set point.
POWER CONVERTER:
Power converters are components needed for converting the AC power from the grid into something that can be used for the storage process, and vice versa. This can be, for instance, mechanical power for pumping of compressing gases or DC power for charging batteries.
MOTOR:
A DC motor is an electrical machine that converts electrical energy into mechanical energy. In a DC motor, the input electrical energy is the direct current which is transformed into the mechanical rotation.
BATTERY:
battery is a device that converts chemical energy contained within its active materials directly into electric energy by means of an electrochemical oxidation-reduction (redox) reaction. This type of reaction involves the transfer of electrons from one material to another via an electric circuit.
VEHICLE BODY:
Motor Vehicle Body means that portion of the Motor Vehicle mounted on the chassis or frame or unibody, including fenders, bumpers, windshields, glass and similar components of motor vehicle bodies as distinguished from the chassis, seats, motor, transmission, air conditioning condenser, radiator and other accessories.
BLOCK USED:
Drive cycle
FTP 75 :
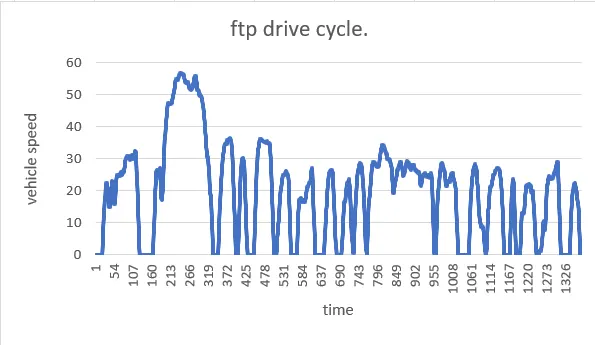
Generates a standard or user-specified longitudinal drive cycle. The block output is the vehicle longitudinal speed. You can import drive cycles from :
- Predefined sources
- Workspace variables, including arrays and time series objects
- mat, xls, xlsx, or txt files
Use the fault tracking parameters to identify drive cycle faults within specified speed and time tolerances.
Wide Open Throttle (WOT) :
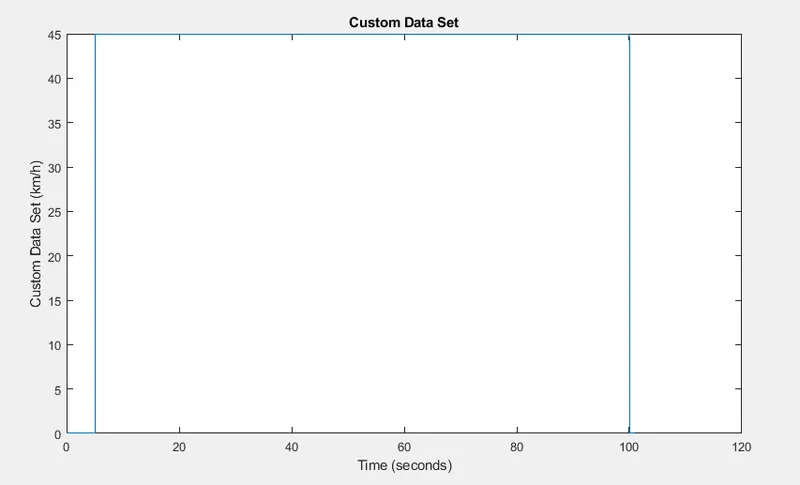
Manually prepared Drive Cycle :
https://drive.google.com/file/d/1K_vVNEHEJGpsqfI8G0H0G0il6wqWwiJ_/view?usp=sharing
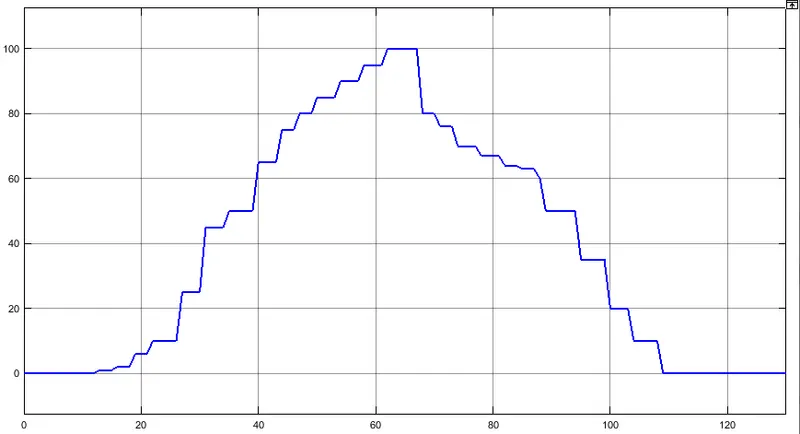
- All 3 Drive cycles are controlled by the controller provided above by constant through Multi-port switch.
MODELLING OF VEHICLE BODY SYSTEM:
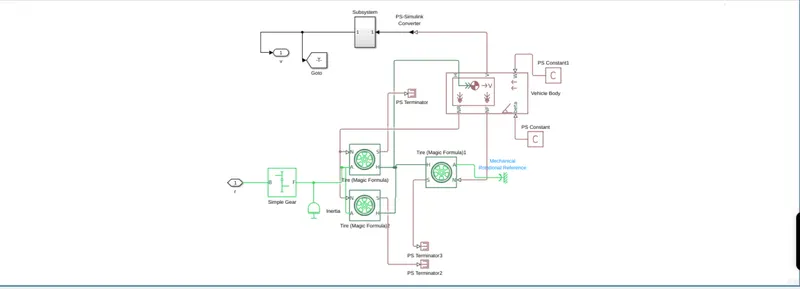
The above figure highlights the vehicle body for electric rickshaw which is having rear axle drive. The Vehicle Body block represents a two-axle vehicle body in longitudinal motion.
The block consists of body mass, aerodynamic drag, road incline, and weight distribution between axles due to acceleration and road profile. In optionally we can include pitch and suspension dynamics.
In a given block
- NR: It is a physical signal output which is connected to the rear wheel axel. For this model, it is connected with a normal force of rear tire.
- NF: It is a physical signal output which is connected to front-wheel axel and for this particular model it is connected with the normal force acting on a front-wheel tire.
- Beta: Beta is basically a road incline angle. Here we can define a constant value for road angle inclination.
- H: This port is a horizontal motion of the vehicle body. This connection will be connected with all four Hub of the wheel for finding the thrust generated by the tire.
- V: This port is the vehicle longitudinal velocity.
- W: It is a headwind speed. Basically, we will define a particular wind speed by adding constant block.
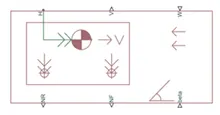
- For setup of vehicle body just double click on the vehicle body and enter as per requirement.
- Here I have done some changes in vehicle configuration, Basically, I changed the vehicle mass, length and frontal area.
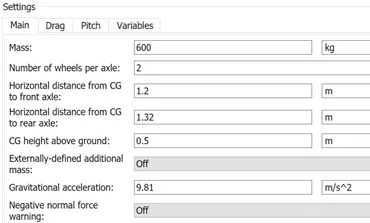
- Detail input of Vehicle Body
Main Settings
- Mass: 600 Kg
- Number of wheels per axle: 2
- The horizontal distance from CG to front axle: 1.2 m
- The horizontal distance from CG to the rear axle: 1.32 m
- CG height above ground: 0.5 m
- Externally-defined additional mass: OFF
- Gravitational acceleration: 9.81 m/s^2
- Negative normal force warning: OFF
Drag Settings
- Frontal area: 1.91 m^2
- Drag coefficient: 0.19
- Air density: 1.25 kg/m^3
Pitch Setting
- Pitch dynamics: OFF
Variable Settings
- Beginning Value of Velocity: 0 m/s
Other connected detail
- Wind Velocity: 2.22222 m/s
- Road Incline: 0
For calculating the velocity here, we have created a subsystem i.e LOG mph, this block basically consists of PS Simulink converter, Gain, Zero order Hold.
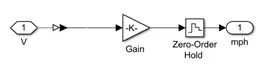
- Gain Block: 1.61 and it multiply input value with constant input.
- Zero-order Hold: 0.01, The Zero-Order Hold block holds its input for the sample period you specify.
TIRE MODELLING
The Tire (Magic Formula) block models a tire with longitudinal behaviour given by the Magic Formula, an empirical equation based on four fitting coefficients. The block can model tire dynamics under constant or variable pavement conditions.
The Tire (Magic Formula) block models the tire as a rigid wheel-tire combination in contact with the road and subject to slip. When torque is applied to the wheel axle, the tire pushes on the ground (while subject to contact friction) and transfers the resulting reaction as a force back on the wheel. This action pushes the wheel forward or backwards. If you include the optional tire compliance, the tire also flexibly deforms under load.
The figure shows the forces acting on the tire.
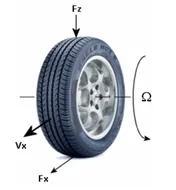
Were,
Fx = Longitudinal force exerted on the tire at the contact point
Fz = Vertical load on the tire
Ω = Wheel angular velocity
Vx = Wheel hub longitudinal velocity
In the particular block
- N: Normal force acting on the tire and connected with NR of the vehicle body.
- S: Slip between the tire and road and connected with Goto block
- H: Hub and it is used to find the thrust created by the tire and it is connected with H input of vehicle body also including all four Hub of the wheel.
- A: Axel and rear axle are connected with the (Simple Gear) final drive system and the front axle is connected with the left and right wheel.
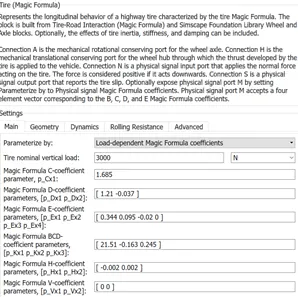
In Tire block, we can change the parameter
Main Settings
- Parameterize by: Load-dependent Magic Formula coefficients, it is basically specifying the parameters that define the load-dependent.
- Tire nominal vertical load – This is basically a normal force on the tire (Fz0). So, for this particular model, the normal force I have taken is 3000 N.
- Magic formula C, D, E, BCD, H and V are default. Basically, It is a load-dependent Magic Formula Coefficient.
Geometry Setting
- Rolling radius: 0.32, it is Unloaded tire-wheel radius, rw
Dynamic Settings
- Inertia: No Inertia
Rolling Resistance Setting
- Rolling resistance: On, Basically, it includes the rolling resistance.
- Resistance model: By using Constant Coefficient we are Neglect rolling resistance.
- Constant coefficient: 0.015 the value should be greater than 0 and it is a coefficient that sets the proportionality between the normal force and the rolling resistance force.
- Velocity threshold: 0.001 m/s basically this input is a velocity at which the full rolling resistance force is transmitted to the rolling hub.
Advance setting
- Velocity threshold: 0.1 m/s as I keep this value as default and this value should be positive because it is wheel hub velocity Vth below which the slip calculation is modified to avoid singular evolution at zero velocity.
INERTIA
This block generally represents the mechanical rotational element.

Where,
T = Inertia torque
J = Inertia
Ω = Angular velocity
T = Time
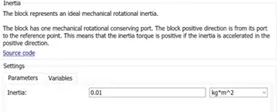
So here the inertia value is 0.01 kg×m^2 and this block is connected with rear axle and (Simple Gear) final drive ratio to find the inertia because axel and gear are a mechanical rotating device.
SIMPLE GEAR
Simple Gear is a Final drive ratio which is a gearbox that constrains the connected driveline axes of the base gear and the follower gear.
B: The output B, base gear is connected with the input of DC motor R. It is a Rotational mechanical conserving port.
F: The output of F, follower gear is connected with the rear axle. It is also a Rotational mechanical conserving port.
In Simple Gear Block we can also do some changes according to our need.
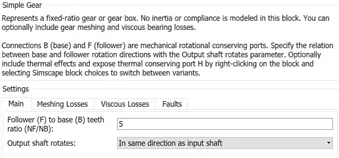
Main Setting
- Follower (F) to base (B) teeth ratio (NF/NB): 5, The value should be in Positive and it is a fixed ratio gFB of the follower gear to the base gear.
- Output shaft rotates: In the same direction as the input shaft, it is depending upon the direction of follower and base gear.
Meshing Losses
- Friction model: From drop-down, we can select Constant efficiency which calculates the Reduce torque transfer by a constant efficiency factor.
- Efficiency: 0.86, here we can change the efficiency depending upon our need, basically it is a Torque transfer efficiency between base gear shaft to the follower gear shaft.
- Follower power threshold: 0.001 W, it is an absolute value of the follower shaft power above which the full efficiency factor is in effect.
GOTO
GoTo block is used to display the vehicle speed.
battery

battery
This block models a battery. If you set the Battery charge capacity parameter to Infinite, the block models the battery as a series internal resistance and a constant voltage source. If you set the Battery charge capacity parameter to Finite, the block models the battery as a series internal resistance plus a charge-dependent voltage source defined by:
V = Vnom*SOC/(1-beta*(1-SOC))
where SOC is the state of charge and Vnom is the nominal voltage. Coefficient beta is calculated to satisfy a user-defined data point [AH1,V1].
GAIN BLOCK
The Gain block multiplies the input by a constant value (gain). The input and the gain can each be a scalar, vector, or matrix.
Here Gain value is the multiplication element and the input is 1/(50×3600), where 50is battery ampere and 3600 is second.
SUM BLOCK
The Sum block performs addition or subtraction on its inputs.
In this block, the negative terminal will be connected with discrete-time integrator and positive terminal with constant.
DC MOTOR WITH TEMPERATURE CALCULATION
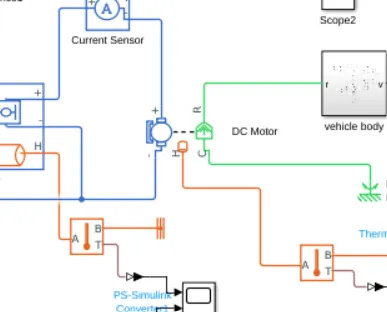
The DC Motor block represents the electrical and torque characteristics of a DC motor using the following equivalent circuit model:
Here in this system, the positive terminal is connected with the current sensor negative terminal and negative terminal is connected with the negative terminal of H-Bridge.
R is DC motor rotor which connected with mechanical rotational port i.e. simple gear whereas C is DC motor case and it is connected with mechanical rotational reference.
A basic configuration of the DC motor is as follow:
Here for the particular model, I configure in DC Motor and try to change a basic setting in electrical torque.
- No-load Speed: 5000 rpm, this is the speed of the motor when not driving a load.
- Rated speed (at load): 1500 rpm, this is the speed of the motor at rated mechanical power level.
- Rated load (mechanical Power): 9.72 kW
Another Mechanical detail of DC motor is as follow
- Rotor Inertia: It’s a resistance of the rotor to change in motor motion.
- Rotor Damping: It should be zero because it is energy dissipated by the motor.
- Initial Rotor Speed: This is a starting speed of the motor that at what speed the motor will start.
Temperature Dependency
- Resistance temperature coefficient:93e-3 1/K
- Measurement temperature: 25 deg C
Thermal Port
- Thermal mass: 20000 J/K
- Initial temperature: 25 deg C
Thermal Port is connected with Temperature sensor Block to measure the motor temperature. Also, Ideal Rotational Motion Sensor is used to measure the motor speed.
H-BRIDGE & MOTOR CONTROLLER
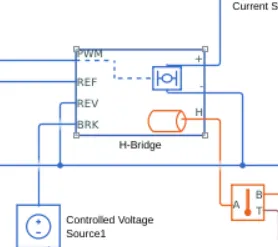
The H-Bridge block represents an H-bridge motor driver.
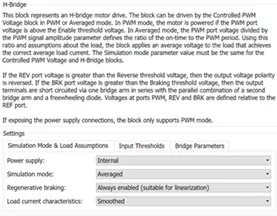
Simulation mode and Load Assumption Settings
- Power Supply: The power supply is default mode i.e. Internal.
- Simulation Mode: Here I selected Averaged mode and this mode has two Load current characteristics options:
Smoothed
Unsmoothed or discontinuous
- Regenerative Braking: Always enabled (suitable for linearization), this option can be used when the controller always sets the REV flag to ensure regenerative braking.
- Load Current Characteristics: Smoothed, it’s a default option and it assumes that the current is practically continuous due to load inductance.
Input Thresholds
- Enable threshold voltage: 1.5 V, this is the above value of PWM at which H-Bridge start.
- PWM signal amplitude: 5.0 V, this is the amplitude of the signal at the PWM input. Here I used it as the default mode.
- Reverse threshold voltage: 1.5 V, here I changed this value.
- Braking threshold voltage: 2.5 V
Bridge Parameters
- Output voltage amplitude: 60.8 V, this parameter will be active only when we select Internal for Power Supply mode and it’s an amplitude of the voltage across the H-Bridge.
- Total bridge on resistance: 0.1 ohms,
- The freewheeling diode on resistance: 0.05 ohm
- Measurement Temperature: 25 degC
Temperature Dependency
- Total bridge on resistance at second measurement temperature:00001 ohm
- Freewheeling diode on resistance at second measurement temperature: 001 ohm
- Second measurement temperature:15 degC
Thermal Port
- Thermal mass: 20000 J/k
- Initial temperature: 25 degC
Detail about connection
- PWM: Pulse-width modulated signal.
- REF: Reference, it is an electrical conversing port associated with the floating zero volts.
- REV: Reverse, it is an electrical conserving port associated with the voltage that controls when to reverse the polarity of the H-Bridge block output.
- BRK: BRK, it is an electrical conserving port associated with the voltage that controls when to short circuit the H-Bridge block output.
Here PWM output port is connected with PWM input port of controlled PWM voltage. The REF and REV port are connected with REF port of controlled PWM voltage port. The BRK port is connected with a controlled voltage source.
The positive (+) terminal is connected with the positive (+) port of current sensor and negative (-) port is connected with the negative (-) port of DC motor.
Thermal port (H) is connected with temperature sensor to measure the temperature of controller.
CONTROLLED PWM VOLTAGE

The Controlled PWM Voltage block represents a pulse-width modulated (PWM) voltage source. The input detail is as given below.
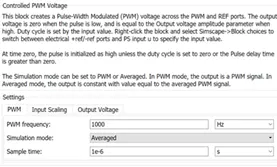
Detail about the connection
- ref+ — Positive terminal, this port is a positive electrical reference and connected with controlled voltage source positive terminal.
- ref- — Negative terminal, this port is a negative electrical reference and connected with the negative terminal of the controlled voltage source.
- PWM — Pulse-width modulated signal, this port is electrical reference port and connected with PWM port of H-Bridge.
- REF — Floating zero-volt reference, this port is connected with REF and REV of H-Bridge port.
PWM Setting
- PWM frequency: 1000 Hz
- Sample time: 1e-6 s
- Input voltage for 100% duty cycle: 2 V
- Output voltage amplitude: 60.8 V
CONTROLLED VOLTAGE SOURCE

The Controlled Voltage Source block represents an ideal voltage source that is powerful enough to maintain the specified voltage at its output regardless of the current flowing through the source.
The block has one physical signal input port and two electrical conserving ports associated with its electrical terminals.
SOLVER CONFIGURATION

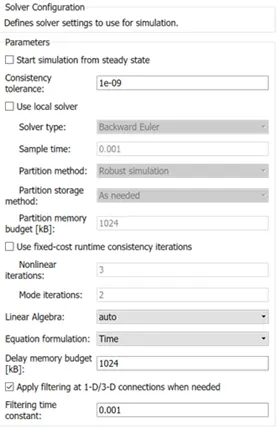
Solver configuration is used to begin the simulation and it is needed to solve the Simulink model. Here it is connected with controlled PWM voltage and H-Bridge negative connection by combination with electrical reference i.e ground signal.
DISTANCE CALCULATION
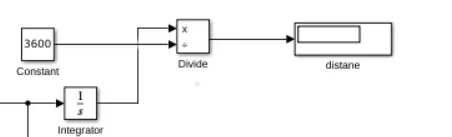
- Here the main block is an integrator, Divide, time block and for the result we have to use display block that will display the distance.
- Detail about connection:
- Integrator
- The output port of the vehicle body is connected with the integrator block.
- Divide
- The output of the integrator block is connected with divide where it will be divided by time to get the final output.
- Time
- The output of time block is connected with the divide block. Here time is taken as 3600 s.
simulink model:
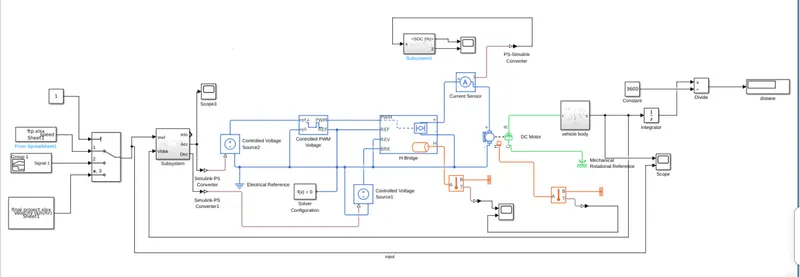
procedure:
first open the matlab and click on the simulink.
then create a new blank sheet.
now create a model like the above model.
then run the model for 120 sec.
and with the scope we can estimate the value of the soc,speed, energy,and temperature.
Output Plots :
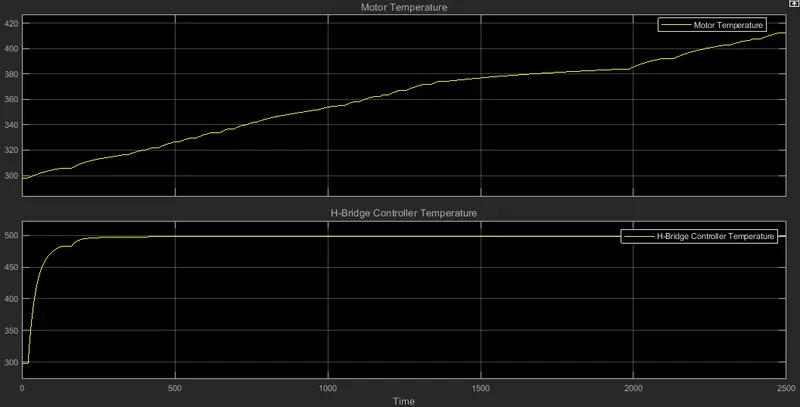
1. For FTP75 Drive Cycle :
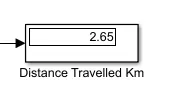
- By running the Vehicle with FTP75 Drive cycle for 2474 sec. the distance travelled is 19.44km.">19.44km.
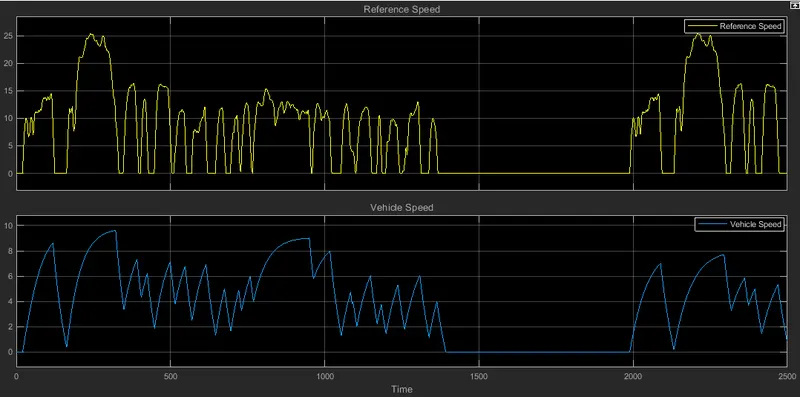
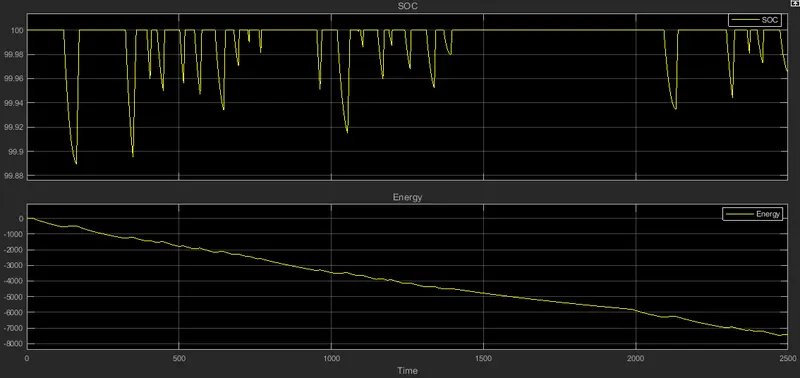
- The actual Speed is approximately followed the 90% of reference Drive cycle.
- The Temperature of Motor is increased to 4150C.">4150C.
- The Temperature of Controller is ≈5000C">≈5000C
- .
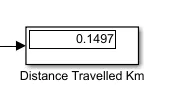
2. For WOT Drive Cycle :
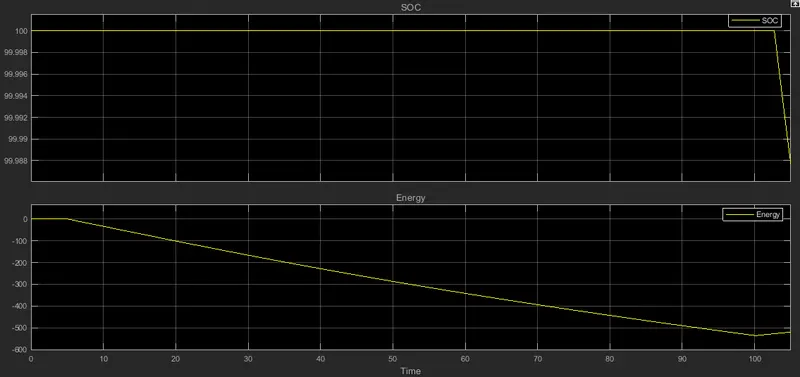
- By running the Vehicle with WOT Drive cycle for 200 sec. the distance travelled is 0.1497km.">0.1497km.
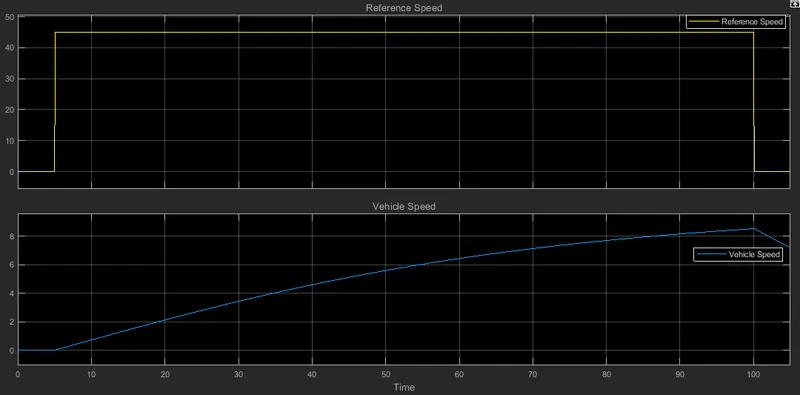
- The actual Speed is approximately followed the 85% of reference Drive cycle.
- The SoC% of the battery is reduced to ≈91%">≈91%
- at 100th sec and after that 100 to 200 sec., the battery get charged by by back EMF.
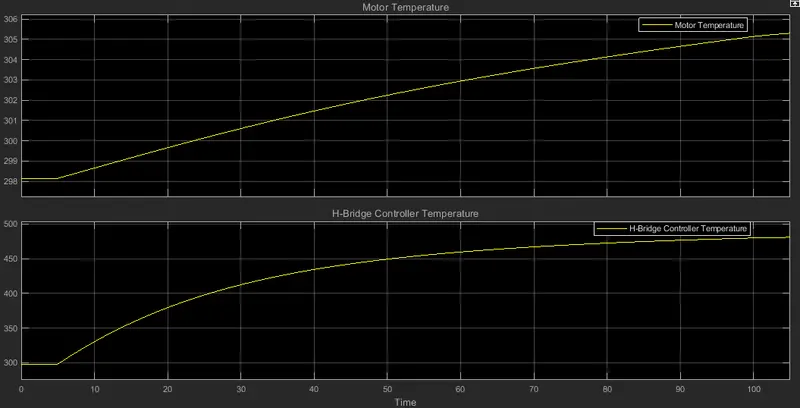
- The Temperature of Motor is increased to 3050C">3050C
- .
- The Temperature of Controller is ≈4800C">≈4800C
- .
3. For Manually prepared Drive Cycle :
- To increase the speed of the vehicle, the output voltage amplitude is applied to 400 V.
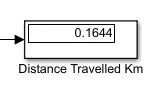
- By running the Vehicle with Manually prepared Drive cycle for 120 sec. the distance travelled is 0.1644km.">0.1644km.
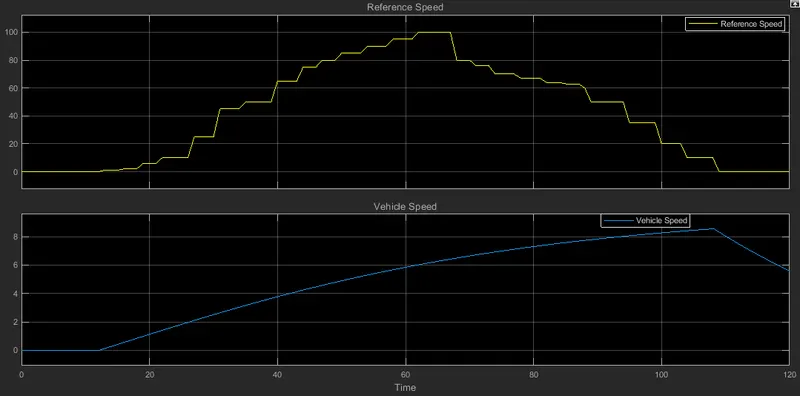
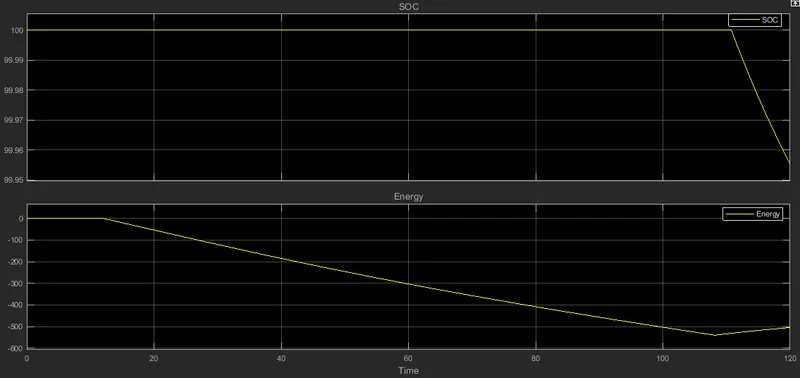
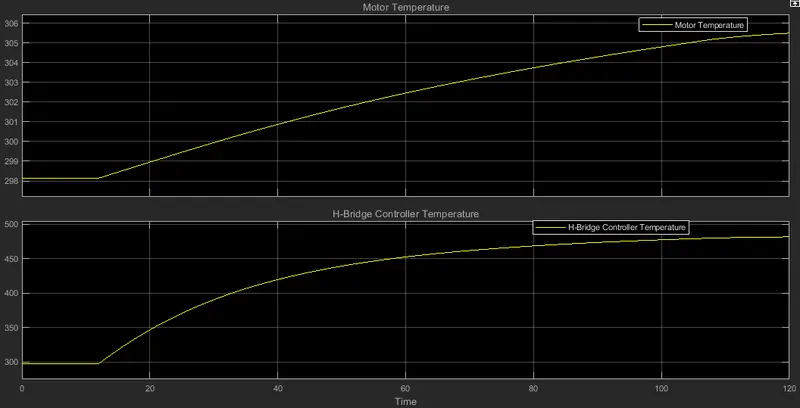
- The actual path of the speed is approximately followed the of reference Drive cycle as above.
- The SoC% of the battery is reduced to ≈94.2%">≈94.2%
- .
- The Temperature of Motor is increased to ≈3050C">≈3050C
- .
- The Temperature of Controller is ≈4800C">≈4800C
CONCLUSION :
- Here I have compromised with the temperature of Motor and controller to achieve vehicle speed is near to reference speeds. Since I haven’t used any cooling system in the model. In the real time application, the motor temperature is less than 100 C.
- In the real time application, the motor, battery & controller temperature is controlled by air cooling. Hence, the temperature of this components is not increased to this extent.
- Hence, Created a MATLAB model of an Electric Rickshaw (three wheel passenger vehicle) by using Li-ion battery, PM Brushed DC Motor.
- Detremined the variations of Temperature of Motor and controller, SoC% and Energy consumed by the by vehicle for all the three Reference Drive cycles (i.e.; FTP75, WOT, Manually prepared).
- This Battery powered Rickshaw will be the most popular mode of transport in the future.
REFERANCE:
1. https://en.wikipedia.org/wiki/Electric_rickshaw
2. https://in.mathworks.com/help/matlab/
3. https://skill-lync.com/student-projects/final-project-electric-rickshaw-modelling-34
4. https://www.youtube.com/watch?v=tM9Akdo8QeA
------------------------------ thank you---------------------------------------------