Final Project: Electric Rickshaw modelling
MODELLING OF ELECTRIC AUTORICKSHAW
INTRODUCTION
The rickshaw plays an important role in public transportation in India. The 'rickshaw' in japanese means man-powered vehicle. The modified version of rickhaws are autorickshaw which runs over non-renewable fuels. Autorickshaws are an important part of urban mobility and a step toward bettering both sustainable transportation and quality of life in Indian cities. The addition of auto-rickshaw services as a feeder mode to public transit networks ensures connectedness and ease of access across the city.
The autorickshaws runs over the petroleum fuels like petrol, diesel and CNG. As the emmissions are low but in cities there is a huge penetration of autorickshaws, so taking the sum of pollutions emitted by all rickshaws in cities it will be a large amount. So converting an oil operated rickshaw to electric operated rickshaw will be a huge step in controlling the pollutions in cities, towns, etc.
The electric rickshaw came in India at 1990s, but the high cost and battery life also low fuel rate made less impact in Indian economy, but now it's not the case. India is going for green protocol and enhancing e-mobility, also the daily increase in fuel price makes the customers to go for e-auto. So there is a huge scope and demand for electric vehicle specially electric rickshaw in Indian market.vThe e-rickshaw can replace the man-powered rickshaw as the effort required by the driver is reduced and can work for more time and long distance.
In India there are some rules and regulations for e-rickshaw. The Ministry of Road Transport & Highways vide notification G.S.R.709(E) dated 08 09.2014 has notified E-rickshaw and E-cart as separate categories of transport vehicles As per the notification G.S.R.709(E), dated 08.10.2014, of the Ministry of Road Transport & Highways, New Delhi and Section 2A of Motor Vehicle (Amendment) Act 2015 read with notification dated 20.03.2015 " E- rickshaw means a special purpose battery powered vehicle of power not exceeding 4000 watts, having three wheels for carrying goods or passengers, as the case may be for hire or reward, manufactured, constructed or adapted to carry not more than 04 passengers, excluding the driver, and not more than 40 Kilograms luggage in total, equipped and maintained in accordance with specification as may be prescribed in this behalf and the maximum speed of the vehicle is not more than twenty-five kilometer per hour ".
The e-rickshaws can be veryusefull in controlling the air pollution and sound pollution as it can also replace the auto-rickshaw.
OBJECTIVES
The main objectives includes
- To design and model the e-rickshaw under Government's guideline.
- To make the controller and motor operating temperature below its maximum limit.
- To match the performance of vehicle with desired performance.
- To model the e-rickshaw considering the cost.
METHODOLOGY
To design the e-rickshaw following steps are to be followed
- Estimate the total load and kerb load acting on the vehicle.
- Estimate the environmental factors affecting the vehicle.
- Calculate the total load/force acting on the vehicle.
- Selection of motor.
- Battery selection.
- Power controller designing.
- Modelling of e-vehicle in Simulink.
- Performance of e-vehicle is evaluated through simulation.
- Configuration of model if required.
The project can be sectionized into three parts designing, modelling and simulation results. At the end of designing section all the data required for modelling will be availabale. And at the end of modelling section a complete virtual model of the vehicle will be made, In simulation section the vehicle performance is being evaluated and if any neccessary the model is configured and run again.
DESIGNING
1. Estimating the total physical parameters of vehicle
In this a rough vehicle model is made to know about the load and kerb weight.
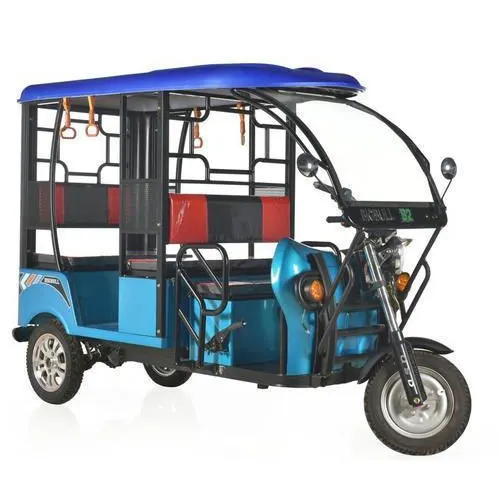
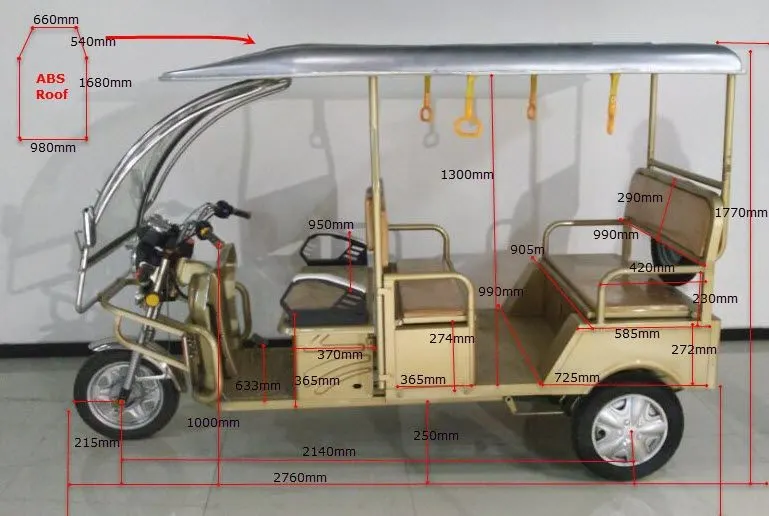
The battery is stored under the seat in middle. hence the center of gravity lies near to the center, which helps in better riding comfort and stablity of the vehicle.
The physical parameters of the vehicle are
- Kerb weight 180 kg
- Max passenger 4 nos.
- Max payload 300kg.
- Distance between front axle and CG = 1380mm
- Distance between rear axle and CG = 1380mm
The other parameters like coefficient of drag, rolling resistance, etc are from the reference: Design of an Electrically Powered Rickshaw, for Use in India
| Sl no. | Parameter | Value |
| 1 | Coefficient of drag, `C_d` | 0.842 |
| 2 | Frontal Area, `A_f` | 1.168 |
| 3 | Coefficient of rolling friction, `C_R` | 0.014 |
As per the Ministry of Road Transport & Highways vide notification G.S.R.709(E) dated 08 09.2014 has notified E-rickshaw should have only maximum speed of 25 kmph.
With these datas, the power required by the axle to support the vehicle motion is given from the vehicle power calculator.
a. Vehicle with max payload at 0 gradeability
In this condition, the vehicle acquire max speed of 25kmph in 10s. Also taken gradeability to be zero.
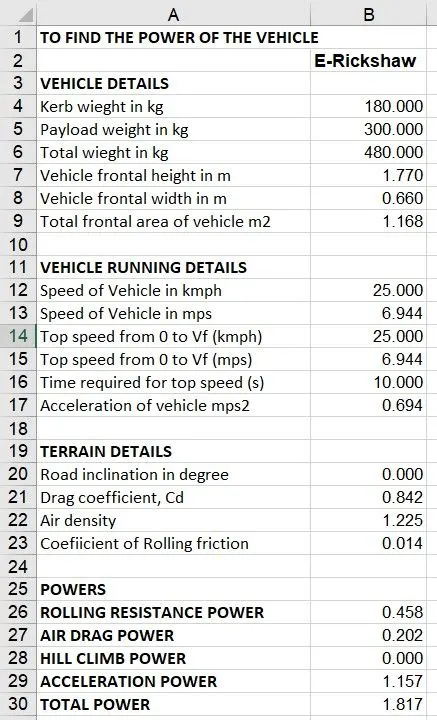
With this condition the vehicle requires 1.817kW power to run in this condition. If we keep all other parameters same and increasing the gradeability the power required will be increasing. According to the rule the maximum power of motor should be less than 4kW.
If we keep high rated motor the battery capacity also needs to be increased which will effect the cost of the vehicle, so an optimum power rating is taken to keep the cost, size and weight optimum.
2. Selection of motor
From the above optimal constrain we keep the rated power of motor to be 2kW. With this 2kW motor engine its possible to take full payload at a speed of 25kmph in 10s. Which is a good performance.
The motor for this project is a 2kW BLDC motor, the motor parameters are given as
| Parameter | |
| Type | PMDC |
| Voltage (V) | 48 V |
| No load Current (A) | 5 |
| Rated Current (A) | 45 |
| Rated Speed (RPM) | 4000 |
| Rated Torque (Nm) | 7.6 |
| Max. Output Torque (Nm) | 22 |
| Rated Power (W) | 2000 |
| Max. Rated Power (W) | 3000 |
| Efficiency | >83% |
| No. of Poles | 8 |
| Motor diameter (mm) | 145 |
| Insulation Class | Class B |
3. Selection of Battery
The battery is selected based on the hours of operation required. If the vehicle runs at rated power for 4 hrs it require 4x2kW = 8kWh battery.
As 8kWh battery will be of high cost, by considering the cost the battery we selected is of nearly 5kWh. The parameter of selected battery are
| Parameter | |
| Type | Li-ion |
| Capacity | 4.8kWh |
| Nominal Voltage (V) | 48 |
| Ampere-hour (Ah) | 100 |
| Cycle life | >2000 |
4. Controller designing
The controller is required to drive the motor taking power from the battery. A motor controller is a device or group of devices that can coordinate in a predetermined manner the performance of an electric motor. A motor controller might include a manual or automatic means for starting and stopping the motor, selecting forward or reverse rotation, selecting and regulating the speed, regulating or limiting the torque, and protecting against overloads and electrical faults. Motor controllers may use electromechanical switching, or may use power electronics devices to regulate the speed and direction of a motor.
In EV the motor controller is a micro-controller based controller. The MCU consist of
- Microcontroller
- Micro processor
- PWM generator
- ADC
- Tx/Rx
- DC-DC converter (H-bridge)
- Feedback loop
H-bridge
An H-bridge is an electronic circuit that switches the polarity of a voltage applied to a load. These circuits are often used in robotics and other applications to allow DC motors to run forwards or backwards.
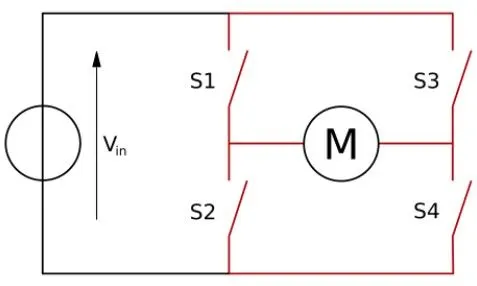
The H-bridge arrangement is generally used to reverse the polarity/direction of the motor, but can also be used to 'brake' the motor, where the motor comes to a sudden stop, as the motor's terminals are shorted, or to let the motor 'free run' to a stop, as the motor is effectively disconnected from the circuit.
The PWM signals helps in controlling the ON and OFF of the SC switches. By controlling the switches H-Bridge can control the output voltage and current flow direction, so it can act as a DC-DC bidirectional converter.
The microprocessor process the inputs to generate the PWM signals, these PWM signals controlls the DC-DC converter to control the voltage, current or power output. A feedback circuit is given from output DC to controller input to make the output stable, which is achieved by a PID controller inside the microcontroller.
MODELLING
A neat model has to be build incorporating the above design value. An e-rickshaw model has made in MATLAB Simulink as shown below
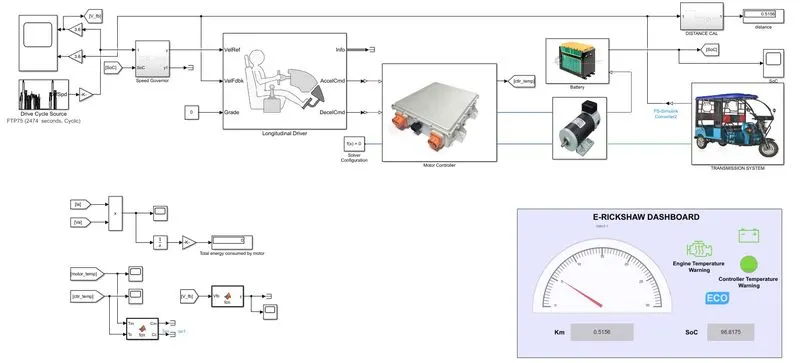
The model consist of
- Drive Cycle - a cycle representing speed v/s time plot, which act as the driver input command.
- Speed Governor - The speed governor helps in maintaining the speed under 25kmph as per rule.
- Longitudnal Driver - these block is a micro-controller block, it intakes the command and process the output whether acceleration or decceleration required, it uses PID controller to process the output.
- Motor controller - motor controller is an essential part, as it controlls the motor input power based on the command signal from longitudnal driver.
- Motor unit - It consist of the driving motor/engine.
- Battery - Consist of the battery for powering the engine and auxillary parts.
- Transmission system - These block represent the physiscal model of the e-rickshaw.
- Dashboard - It shows the real time speed, distance covered, SoC of battery, driving mode and overheat indicators.
a. Modelling of transmission system
In this the rickshaw physical parameters are modelled including the environmental fastors like wind speed, gradeability, rolling resistance etc.
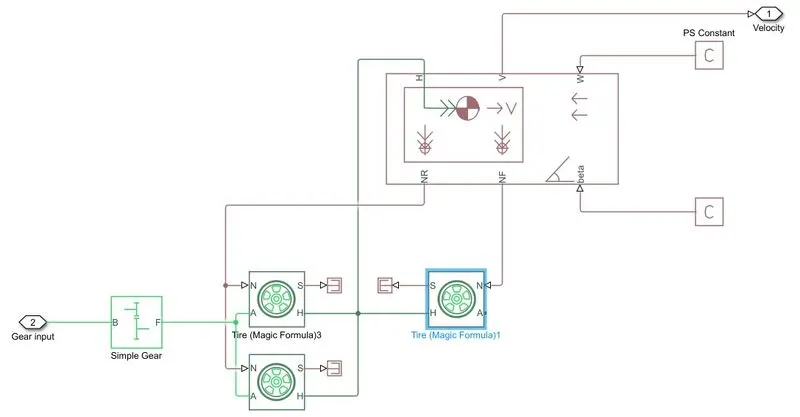
The vehicle is rear axle drive, so the gear is connected to the rear axle/wheel.
- Simple gear NF/NB = 5
Tire is modelled using the block 'Tire magic formula', in that the parameter entered are
- Main
- Rated vertical load = 3000 N
- Peak longitudnal force at rated load = 3500 N
- Slip at peak force at rated load = 10 %
- Geometry
- Rolling radius = 0.3m
- Rolling resistance
- Constant coefficient = 0.014
The vehicle parameters and enivironmental factors are added in the 'vehicle body' block.
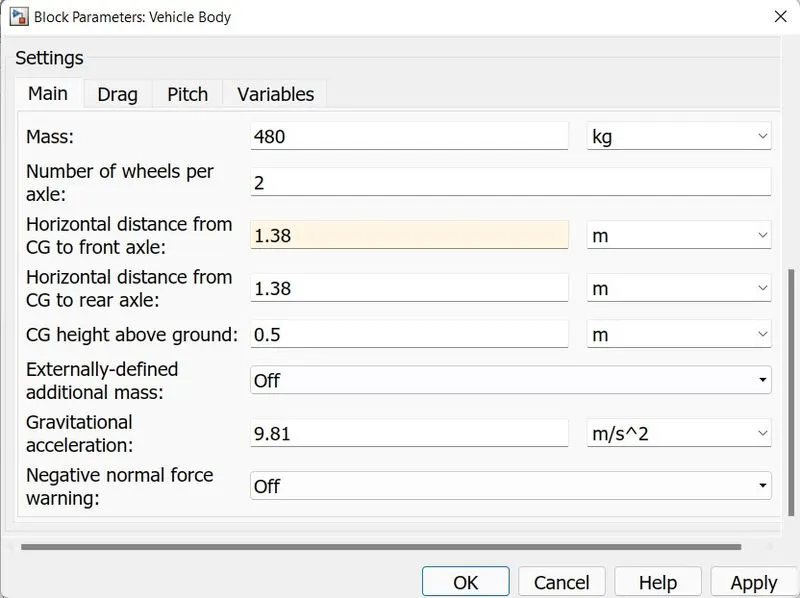
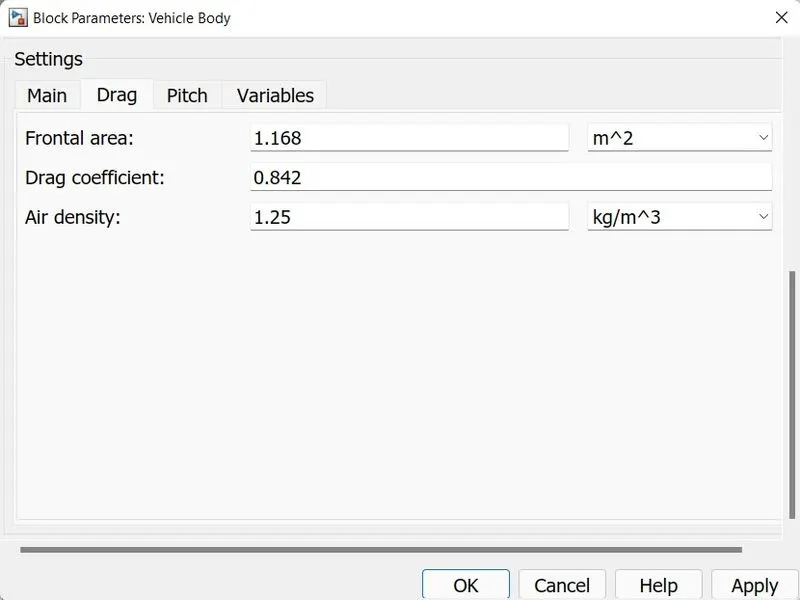
The wind and grade of road is added externally. The final velocity of the vehicle is obtained from the block.
b. Modelling of Motor
The motor is modelled by a 'DC motor' block. It consist of two parts electrical and mechanical part. The electrical part is connected to the output of the Motor control unit and mechanical part is connected to the rear axle via gear.
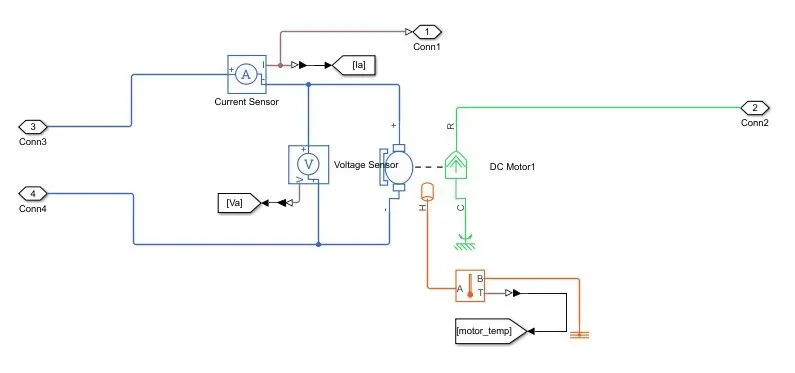
The designed rating of motor has discussed earlier, with the same rated parameters the DC motor is modelled.
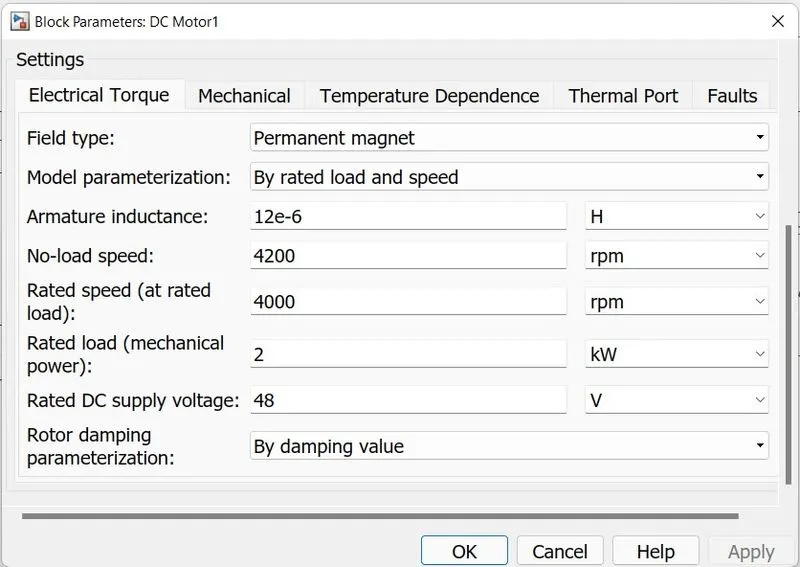
At first the thermal port will not be visible, to enable the thermal port follow the steps
- Right click on the DC motor block
- Select Simscape
- Select block choices
- Select 'Show thermal port'
The thermal port is connected to the Temperature sensor to detect the temperature rise in the DC motor while running. The thermal parameters are given as
- Thermal mass: 20000 J/K
- Initial temperature: 25 degC
c. Modelling Battery
Battery is the main source of the power for the EV, so earlier we designed the battery required for the e-rickshaw. The battery pack includes a battery and a SoC estimater.
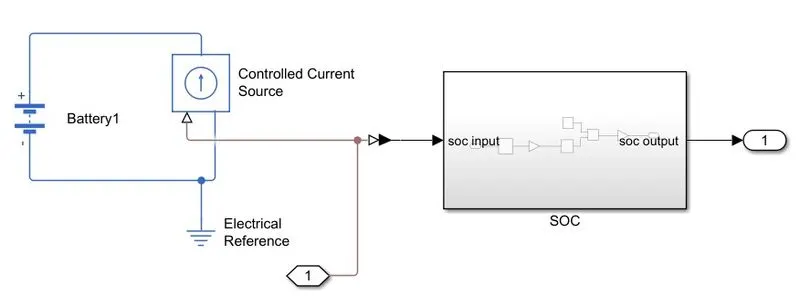
The battery parameters include
- Nominal voltage: 96V
- Ampere-hour rating: 50Ah
d. Modelling of MCU (Motor Control Unit)
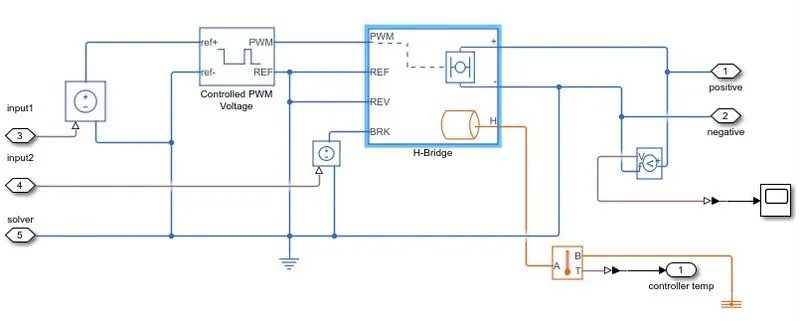
MCU is the most important part of EV which connects Battery and Motor. The amount of power given to motor is determined by the controlling signals from the Longitudnal driver controller.
Modelling of MCU include as a bidirectional DC-DC converter (H-Bridge), which helps in transferring power from battery to motor while accelerating and motor to battery while deccelerating.
The H-Bridge works based on PWM signals, the PWM signals are generated by the PWM generator based on the control signal from the longitudnal driver controller.
e. Longitudnal Driver
The block 'Longitudnal driver' is a pre defined blockset consisting of PID controller.
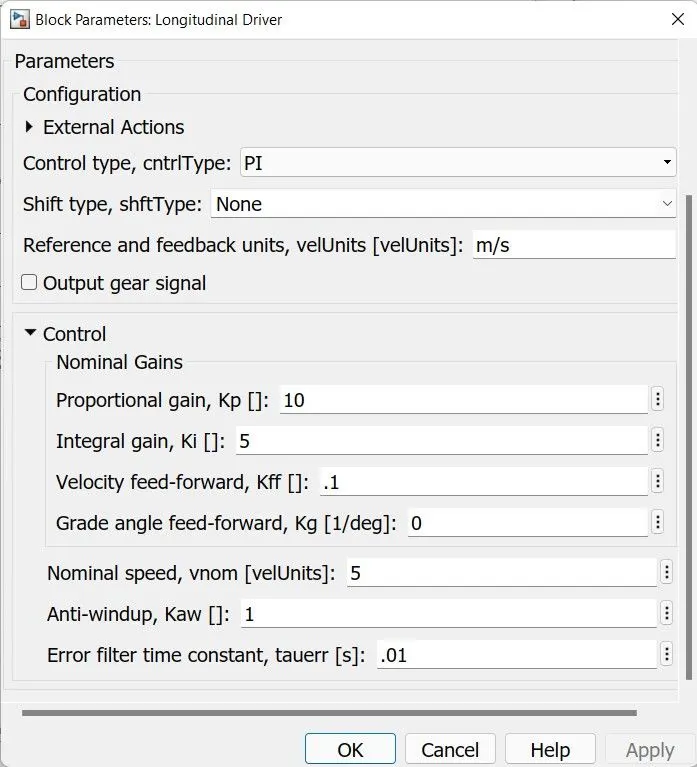
The block produce control signals like acceleration and decceleration signal which is fed to PWM gen, when during acceleration signal is fed to MCU the power is transferred from battery to motor and when decceleration signal is fed to MCU the power is transferred from motor to battery.
The block has 3 inputs output velocity of vehicle, reference velocity and grade. Considering these three inputs the signal is generated.
f. Speed Governor
According to the rules and regulations for the e-rickshaw the maximum speed is limited to only 25kmph, so for this speed is to be regulated to 25kmph. For this a MATLAB function model is created such that the input velocity above 25kmph is treated as 25kmph only. This function is added with a saturation limiter.
g. Drive Cycle
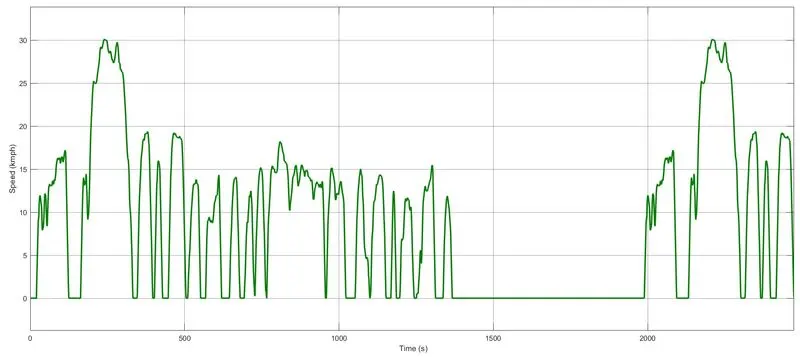
Drive cycle determines the pattern by which the e-rickshaw is travelled, in this model to simulate we required a drive cycle, so in this simulation FTP-75 drive cycle is selected.
As FTP75 is for EV Cars, the FTP75 is scaled down such that maximum speed is 30kmph.
h. Dashboard
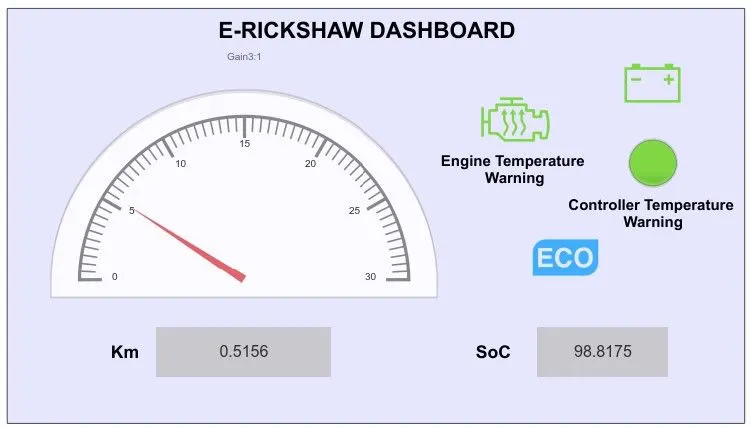
The dashboard is an important part of vehicle, it is the way by which vehicle interacts with the driver about the running status of the vehicle. It includes
- Speedometer
- Odometer
- SoC meter
- Alarm for Engine overheat
- Alarm for Controller overheat
- Driving mode indicator
- Blue - underpower
- Green- ratedpower- greater efficiency
- Orange - overpower
SIMULATION AND RESULTS
With the above parameters and drive cycle lets run the simulation.
Condition 1:
Considering a FTP75 cycle to check whether the vehicle follows the FTP drive cycle pattern.
a. Speed response
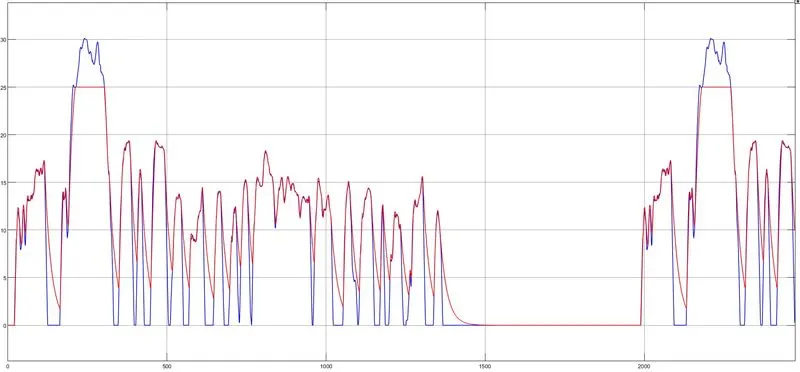
In this output it can see that the vehicle follows the FTP75 drive pattern. The following observation can be made from above results
- Vehicle acceleration requirement is met and no time lag in reaching the maximum speed is observed.
- The decceleration is met by regenerative braking.
- The decceleration is lagging due to lack off mechanical brake.
- The maximum speed of vehicle is 25kmph by considering the rules and regulations of e-rickshaw.
b. Energy consumption
The energy consumed by the motor can be calculated in two part
- Energy consumed during acceleration
- Energy conserved during regenrative braking
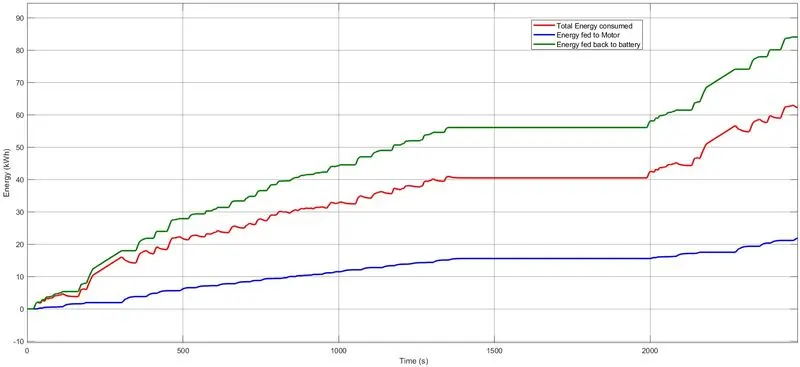
From the above result the following observation can be made
- Energy required to drive the vehicle = 84.04kWh
- Energy conserved during regenrative braking = 21.88kWh
- Total Energy required = 62.16kWh
- By having regenerative braking the Energy required by the vehicle can be reduced. In this 21.88kWh energy has saved by regenerative braking and thus the range of vehicle is extended.
c. Temperature
The temperature is an important factor, the vehicle controller, battery and engine temperature has to be kept below its maximum operating temperature. The temperature rise of the motor and controller is
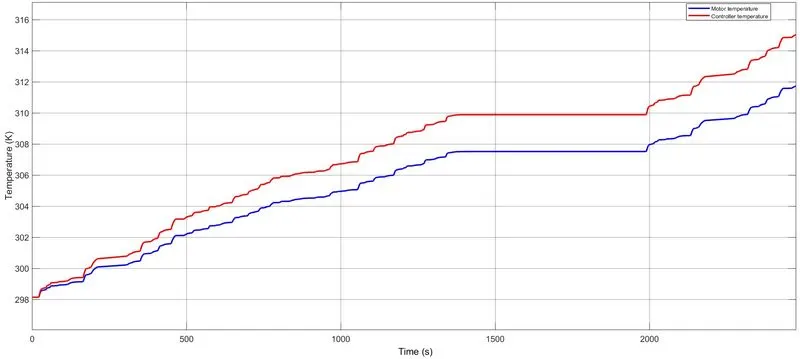
In this it can see that the temperature of controller and motor remains under maximum operating temperature (`40^o` C). The following observation can be made
- The temperature is rising in nature as it doesn't have any cooling system.
- The rise of temperature depends upon the thermal mass of the system, more thermal mass less rise in tempertaure while operating.
- The tempertaure rise of controller is more compared to motor, having same thermal mass, because loss in controller is more.
d. Dashboard details
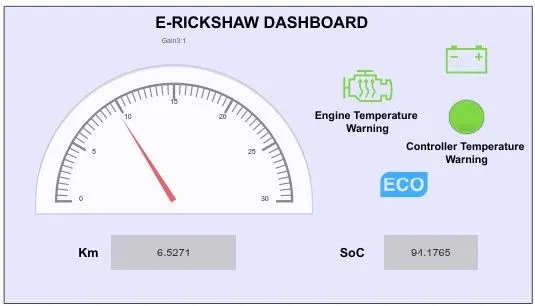
The dashboard shows the distance travelled by the vehicle during FTP75 driving cycle.
- Total distance travelled = 6.52 km
- Engine temperature and Controller temperature below maximum operating range (shown in green)
- Battery SoC level is healthy shown in green
- Final SoC level is 94.176%.
Condition 2: WOT till SoC is 0%
The model is simulated for WOT at 25kmph (max speed of e-rickshaw) till the SoC becomes zero.
a. Speed response
The speed is made 25 kmph at starting testing with WOT.
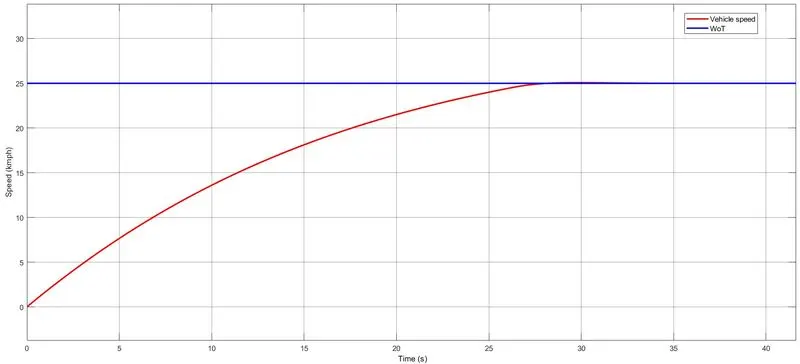
The vehicle takes 27s to reach maximum speed of 25kmph. The simulation is made run to 10950 second with constant velocity input of 25kmph.
b. Energy consumption
As the vehicle is made to move at constant velocity there will be no decceleration and the acceleration command is given to vehicle by the cintroller to keep the velocity at 25kmph to overcome the rolling, air drag and grading resistance. The power consumed by motor is constant as the resistance parameter is constant, so the energy rise is at a constant rate.
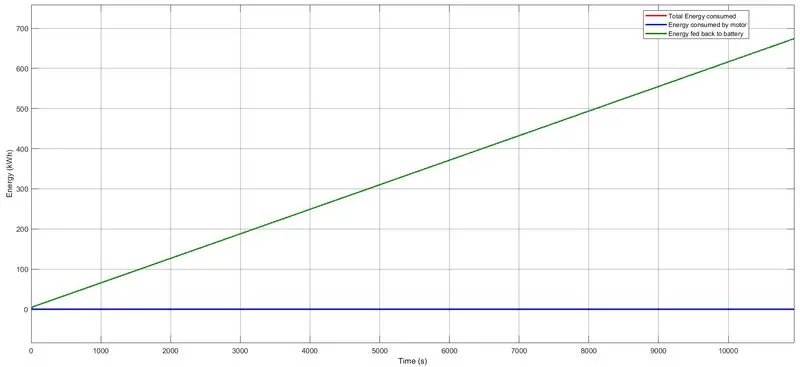
From the above result it is clear that the energy consumed by motor and total energy consumed is same. the regenerative energy (blue) is zero, as there is no braking in this simulation has done.
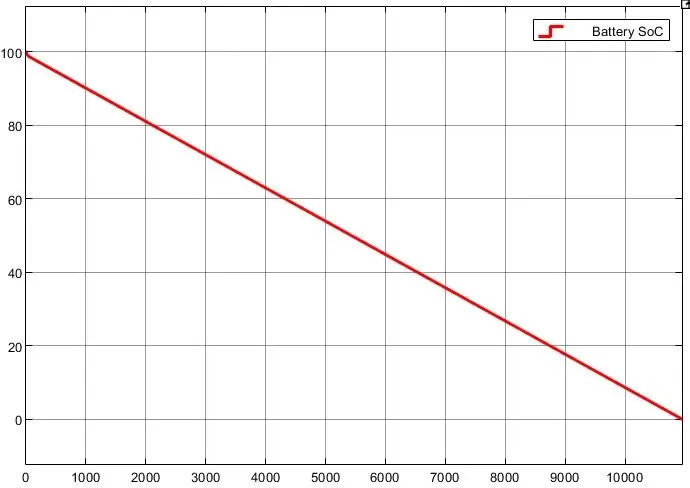
c. SoC of battery
As there is no regenerative energy, the battery will be only in discharging mode.
d. Temperature
Case1: Thermal mass of controller = 10 kJ/K and Thermal mass of motor = 10 kJ/K
The temperature rise during the above condition is given as
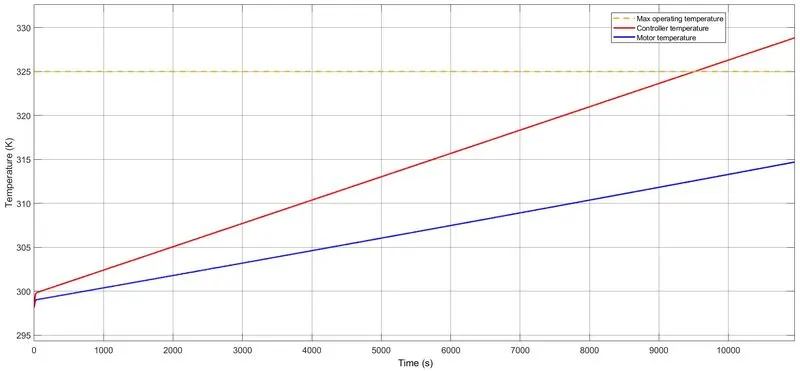
It can be seen that the temperature of the controller (329 K) goes above max. operating temperature ( 325 K). And the dashboard gives the alarming sign by turning controller temperature indicator to orange. The motor temperature is within limit (315 K).
Case 2: Thermal mass of controller = 15 kJ/K and Thermal mass of motor = 10 kJ/K
The temperature rise during the above condition is given as
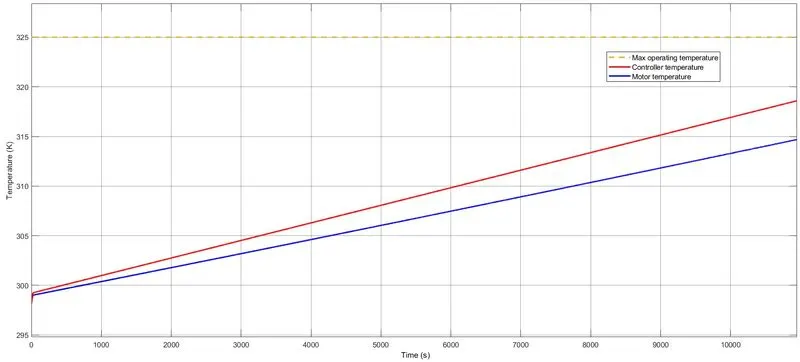
It can be seen that the temperature of both controller (318 K) and motor (315 K) remains under maximum operating temperature. Thus during designing the thermal mass of the controller and motor should be properly chosen. Now th dashboard indicator shows green light for both controller and motor temperature indicator.
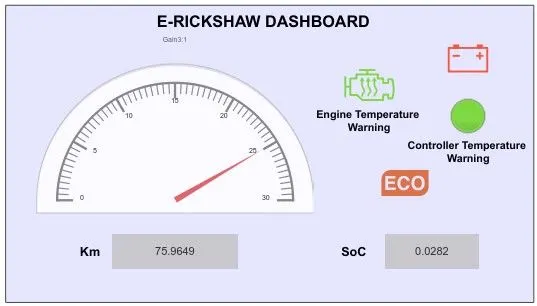
e. Dashboard
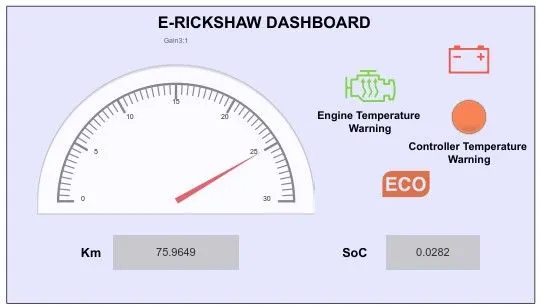
The dashboard readings at ending of the simulation is shown as
From the dashboard following inference can be made.
- The ECO is in orange color, because the speed is at maximum.
- The battery sign is in red colour, because the SoC of the battery is below 10%.
- Motor and Controller operating temperature is within limits shown in green.
- Total distance travelled by the vehicle is 75.96km.
- Final SoC is 0%.
CONCLUSION
E-rickshaw has designed and modelled using MATLAB Simulink. According to rules and regulations for e-rickshaw the motor power has been limited to 2kW (below 4kW) and the maximum speed is upto 25kmph.
The speed of the e-rickshaw has followed the input drive cycle and from the model with maximum payload the vehicle can reach its maximum speed of 25kmph at 27s, which is good performance.
The vehicle can travel at maximum speed of 25kmph continously for nearly 3hrs and covering a distance of nearly 75km, so the battery performance is good considering the cost. To extend the range of vehicle battery with more Ah or kWh can be taken but cost should be compromised.
The temperature of the controller has gone up in first case, in second case by increasing the thermal mass of the controller the temeperature has kept under rated operating range. In this model no external cooling is considered so in real life the temperature rise will be less than that obtained from this simulation.
The regenerative braking technology in this e-rickshaw has increased the range of the vehicle by conserving the enrgy during braking.
Thus the performance of e-rickshaw is evaluated and matching with the desired performance.