Final Project: Design of an Electric Vehicle
Aim: Create a MATLAB model of electric car which uses a battery and a DC motor. Choose suitable blocks from Powertrain block set. Prepare a report about your model including following:
Objective:
1. System-level configurations
2. Model parameters
3. Results
4. Conclusion
Theory:
A new study associated with Vehicle/Automobile engineering says that by returning 2025, there'll be a significant transformation within the automobile sector. several automakers square measure operating to vary the vehicle technologies, the foremost space is to decrease the pollution and use electrification within the approaching vehicles. The researchers and automakers square measure unendingly operating to cut back dioxide emissions.
New technology like high capability Li kind battery are going to be a significant energy supply for the propulsion of electrical vehicles.
At present, with the new technologies, some manufacturer has launched its merchandise that square measure Tesla, nark Bolt energy unit and Nisan leaf that square measure totally electrical battery-based automotive.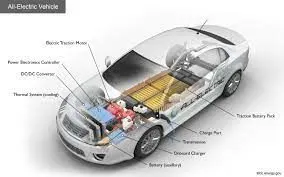
The power and performance of electrical vehicles is relying upon the 2 machines i.e. a brushless DC motor (BLDC) or Associate in Nursing induction motor. The DC (direct current) is replaced by DC brushless motors and Induction motors. Also, the lead-acid accumulator is replaced by lithium-ion batteries for EVs. as a result of the longer term of each the elements induction or brushless DC motors depends upon their demands and uses.
The most vital elements of electrical vehicle areas:
Auxiliary Battery: In an electrical drive vehicle, the auxiliary battery provides electricity to power vehicle accessories.
Traction Battery Pack: Traction battery pack is additionally called electrical Vehicle Battery (EVB) that is employed to store the electricity.
Some samples of traction battery energy storage systems square measure as given:
Lithium-Ion
Nickel-Metal binary compound
Lead-Acid
Ultra-Capacitors
DC/DC Converter: essentially, DC/DC device is Associate in Nursing device that is employed to converts higher-voltage DC power from the traction battery pack to the lower-voltage DC power. The born-again power is employed to run the vehicle accessories. it's additionally accustomed recharge the auxiliary battery.
Electric Traction Motor: Another vital element is electrical traction motor and this device is employed to supply locomotion to the wheels.
Onboard charger: Takes the incoming AC electricity provided via the charge port and converts it to DC power for charging the traction battery. It monitors battery characteristics like voltage, current, temperature, and state of charge whereas charging the pack.
Power physical science controller: This unit manages the flow of voltage delivered by the traction battery, dominant the speed of the electrical traction motor and also the force it produces.
Charge port: The charge port permits the vehicle to attach to Associate in Nursing external power provide so as to charge the traction battery pack.
Thermal system (cooling): this technique maintains a correct operational temperature vary of the electrical motor, power physical science, and alternative elements.
Matlab design:
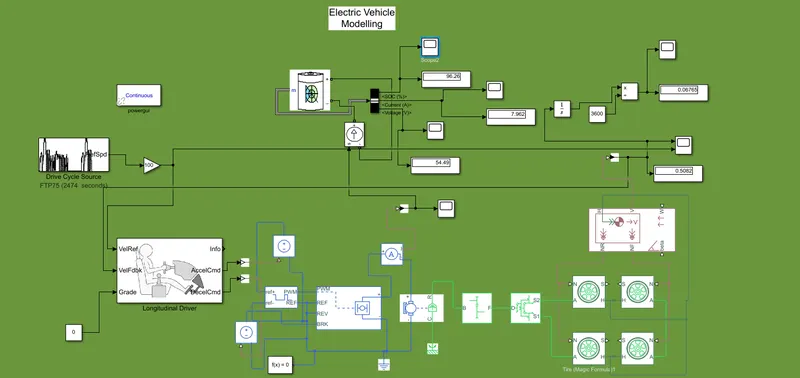
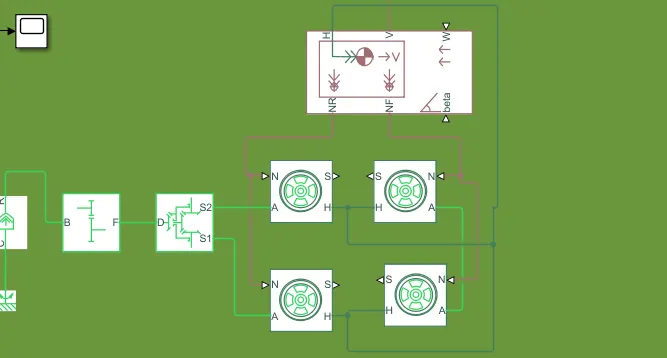
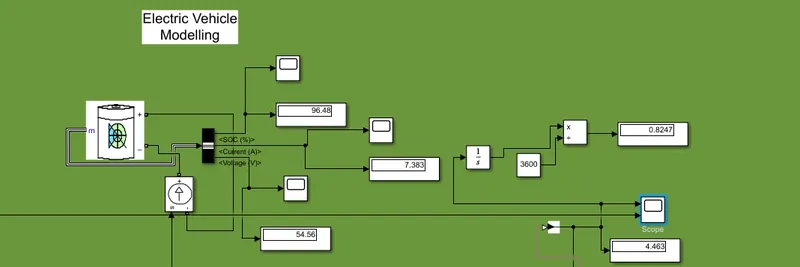
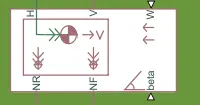
The Vehicle Body block represents a two-axle vehicle body in longitudinal motion. The vehicle will have constant or a distinct variety of wheels on every shaft.
The block consists of body mass, mechanics drag, road incline, and weight distribution between axles thanks to acceleration and road profile. In optionally we will embrace pitch and suspension dynamics.
The block has AN choice to embrace AN externally-defined mass and externally-defined inertia. The mass, inertia, and centre of gravity of the vehicle body will vary over the course of simulation in response to system changes.
In a given block
NR: it's a physical signal output that is connected to the rear wheel axel. For this model, it's connected with a traditional force of rear tire.
NF: it's a physical signal output that is connected to front-wheel axel and for this specific model it's connected with the traditional force functioning on a front-wheel tire.
Beta: Beta is essentially a road incline angle. Here we will outline a relentless worth for road angle inclination.
H: This port may be a horizontal motion of the vehicle body. This affiliation are going to be connected with all four Hub of the wheel for locating the thrust generated by the tire.
V: This port is that the vehicle longitudinal speed.
W: it's a current of air speed. Basically, we are going to outline a specific wind speed by adding
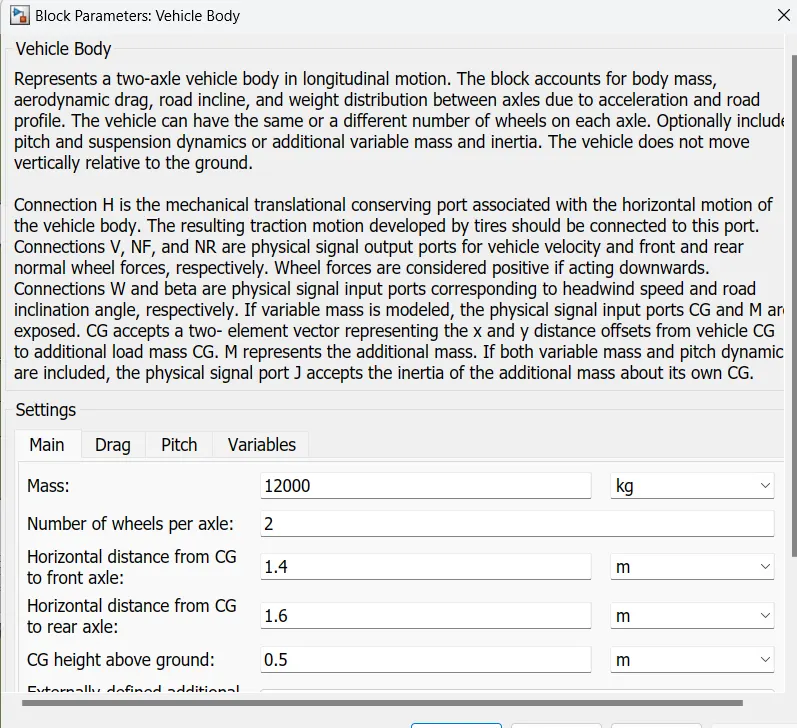
Detail input of car Body
Main Settings
Mass: 1147 metric weight unit
Number of wheels per axle: a pair of
The horizontal distance from CG to front axle: one.854 m
The horizontal distance from CG to the rear axle: a pair of.2730 m
CG height on top of ground: zero.5 m
Externally-defined extra mass: OFF
Gravitational acceleration: nine.81 m/s^2
Negative traditional force warning: OFF
Drag Settings
Frontal area: a pair of.21 m^2
Drag coefficient: zero.20
Air density: one.18 kg/m^3
Pitch Setting
Pitch dynamics: OFF
Variable Settings
Beginning price of Velocity: zero m/s
Other connected detail
Wind Velocity: a pair of.22222 m/s
Road Incline: zero
For calculative the rate here, we've got created a system i.e LOG mph, this block essentially consists of notation Simulink device, Gain, Zero order Hold.
The Tire (Magic Formula) block models a tire with longitudinal behaviour given by the Magic Formula, Associate in Nursing empirical equation supported four fitting coefficients. The block will model tire dynamics below constant or variable pavement conditions.
The Tire (Magic Formula) block models the tire as a rigid wheel-tire combination in-tuned with the road and subject to slide. once force is applied to the wheel shaft, the tire pushes on the bottom (while subject to contact friction) and transfers the ensuing reaction as a beat back on the wheel. This action pushes the wheel forward or backwards. If you embrace the optional tire compliance, the tire conjointly flexibly deforms below load.
The figure shows the forces working on the tire.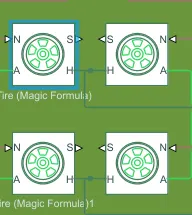
Where,
Fx = Longitudinal force exerted on the tire at the contact purpose
Fz = Vertical load on the tire
Ω = Wheel angular rate
Vx = Wheel hub longitudinal rate
In the specific block
N: traditional force working on the tire and connected with NR of the vehicle body.
S: Slip between the tire and road and connected with Goto block
H: Hub and it's accustomed notice the thrust created by the tire and it's connected with H input of car body conjointly together with all four Hub of the wheel.
A: Axel and rear shaft area unit connected with the (Simple Gear) final drive system and therefore the front shaft is connected with the left and right wheel.
In Tire block, we will modification the parameter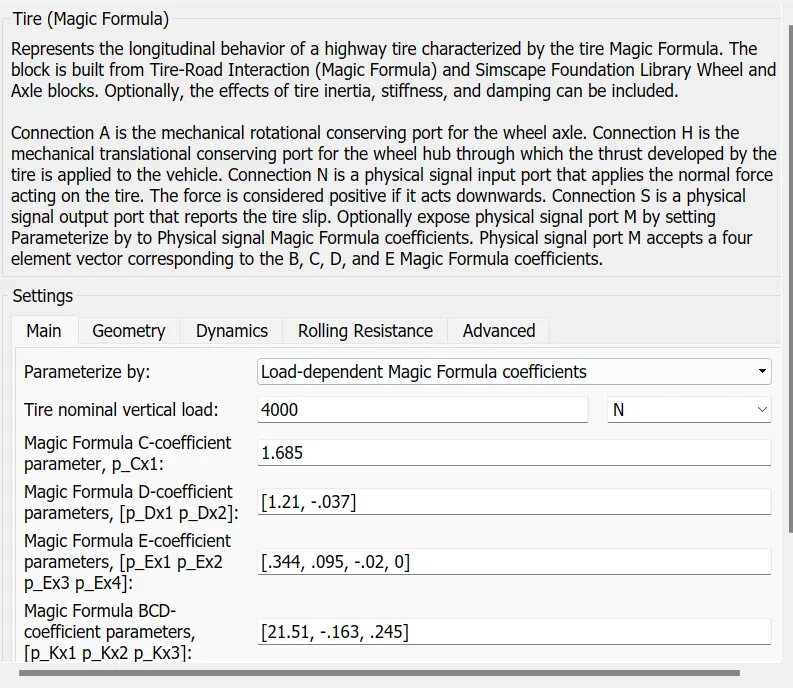
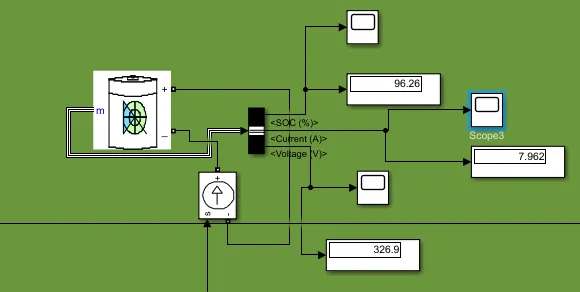
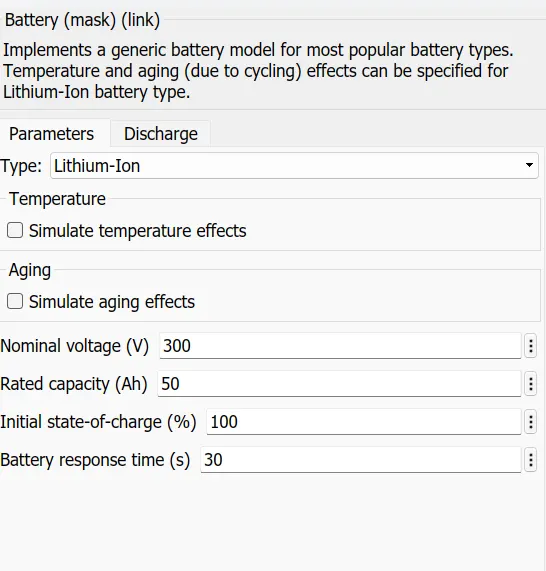
Battery:
Main Settings
Parameterize by: Load-dependent Magic Formula coefficients, it's essentially specifying the parameters that outline the load-dependent.
Tire nominal vertical load – this can be essentially a standard force on the tire (Fz0). So, for this specific model, the conventional force I actually have taken is 4000 N.
Magic formula C, D, E, BCD, H and V area unit default. Basically, it's a load-dependent Magic Formula constant.
Geometry Setting
Rolling radius: zero.32, it's blank tire-wheel radius, rw
Dynamic Settings
Inertia: Specify inertia and initial rate that depends upon stiff, dampened spring and deforms below load.
Tire inertia: zero.5 kg*m^2 and it's motion inertia warfare of the wheel-tire assembly.
Initial rate: zero revolutions per minute Associate in Nursingd it's an Initial angular velocity, Ω(0), of the tire.
Rolling Resistance Setting
Rolling resistance: On, Basically, it includes the rolling resistance.
Resistance model: By mistreatment Constant constant we tend to area unit Neglect rolling resistance.
Constant coefficient: zero.015 the worth ought to be larger than zero and it's a constant that sets the quotient between the conventional force and therefore the rolling resistance force.
Velocity threshold: 1e-3 m/s essentially this input could be a rate at that the total rolling resistance force is transmitted to the rolling hub.
Advance setting
Velocity threshold: zero.1 m/s as I keep this price as default and this price ought to be positive as a result of it's wheel hub rate Vth below that the slip calculation is changed to avoid singular evolution at zero rate.
INERTIA
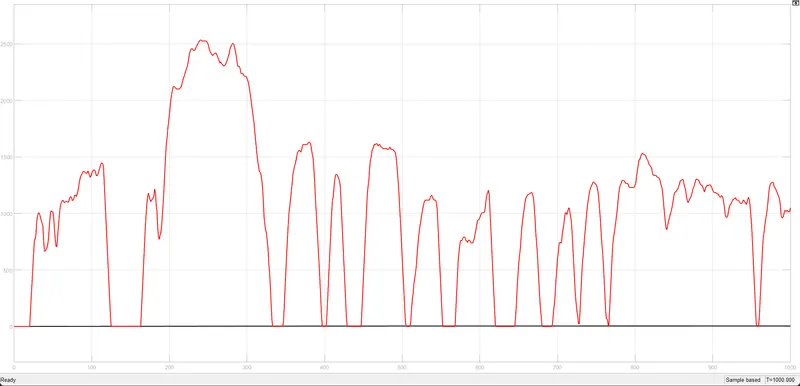
Results:
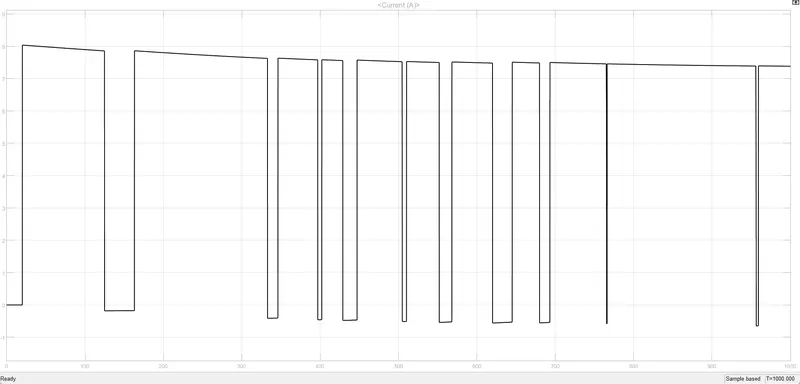
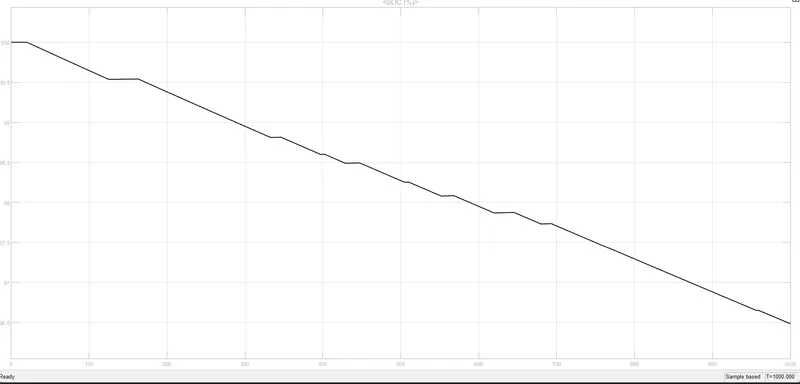
SOC:
Speed:
Conclusion:
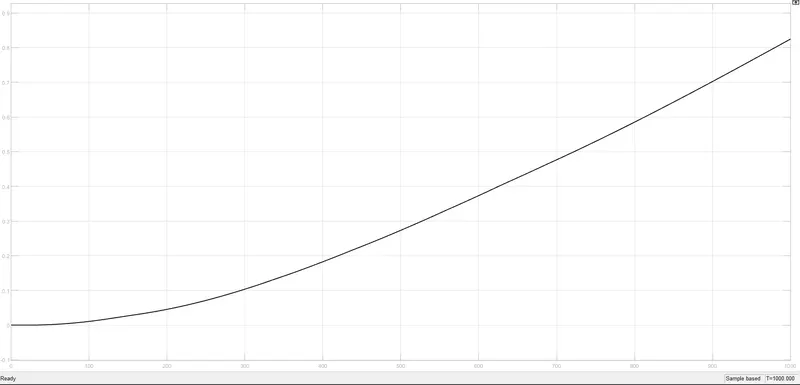
The total distance move vehicle is five.318 m/s or nineteen.1448 kmph relying upon the FTP75 drive cycle and therefore the total time for simulation was 2474 sec.
The battery has three hundred V that could be a nominal voltage and therefore the battery ampere per hour rating is fifty by that we have a tendency to calculated the SOC (state of charge) of battery.
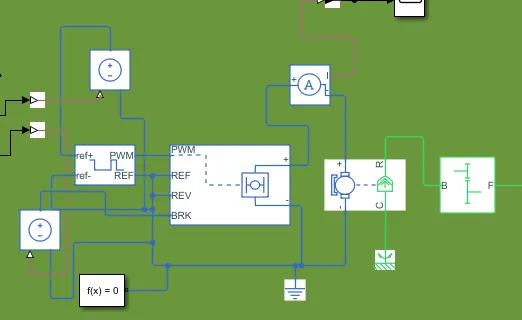
The DC motor is employed to run the Rear axel of the vehicle and once the automotive is with no load condition then the motor in operation rev is 11000 and once the automotive is running at some load or we are able to say that some rated speed then the motor rev is taken as 10500. The voltage offer to DC motor is three hundred V.