Final Project: Design of an Electric Vehicle
THEORY:
An electric car is a vehicle that is propelled by one or more electric motors, using energy stored in rechargeable battery packs. These are eco-friendly and has higher efficiency compared to ICE cars. An electric vehicle is 69-72% efficient when counted against stored chemical energy and around 59-62% efficient when counted against required energy to recharge. They use electric motors for propulsion. The most common types of motors used are Permanent Magnet Synchronous Motor (PMSM) and three phase induction motor.
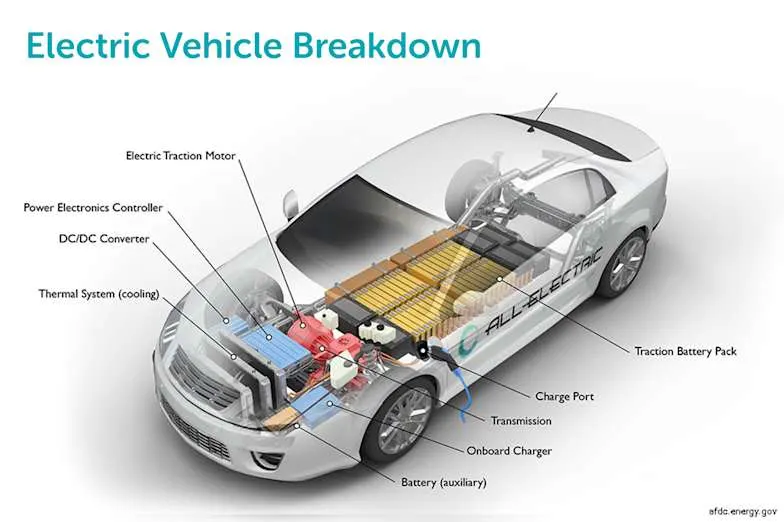
The battery packs are recharged using AC/DC charging technologies. AC charging is slow as it has to be converted to DC. Hence for fast charging DC chargers are used. The charging sockets has different standards as shown below,
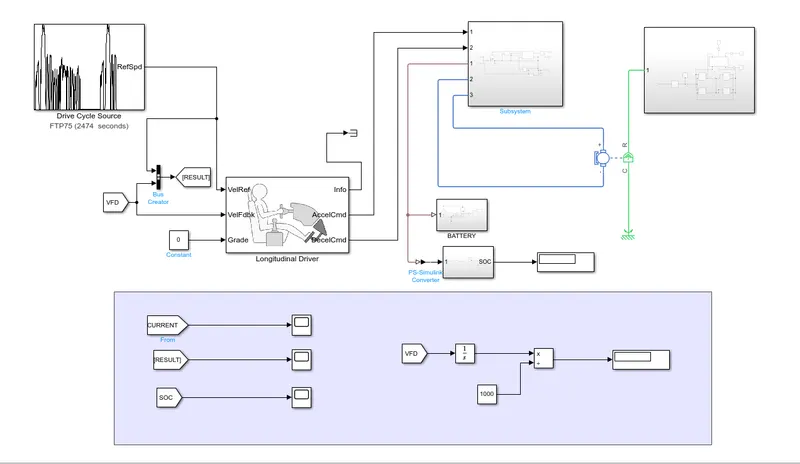
The block diagram for an Electric vehicle which uses a battery and a DC motor is shown below,
Block Diagram:
Drive Cycle block:
Block Parameter:
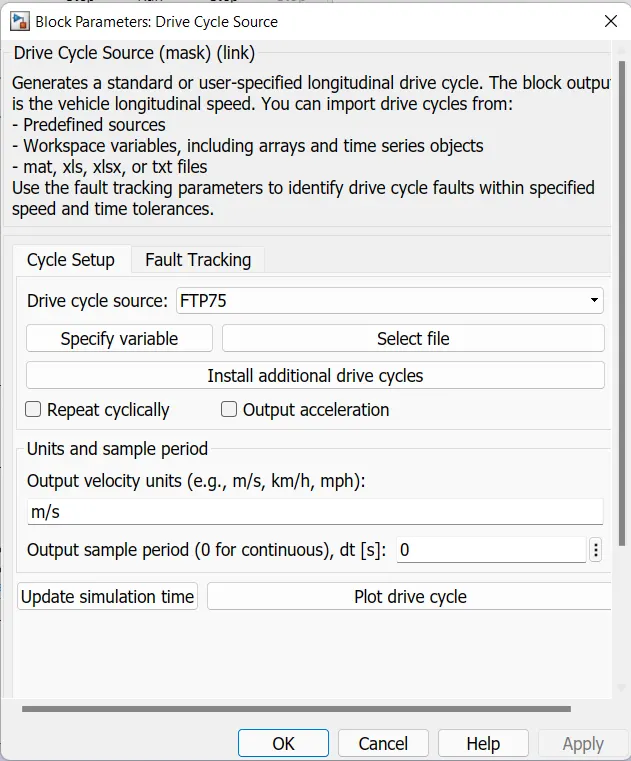
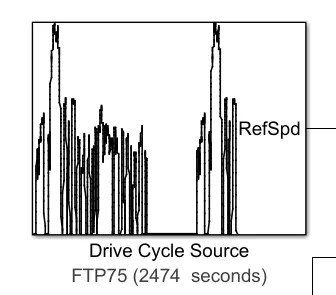
This block will help us in inputting the drive cycle data, whether it is built in or custom made by the user. That is we can use custom made drive cycle data in excel sheet using this block.
For this model we have used FTP 75 drive cycle, which is built-in in this block.
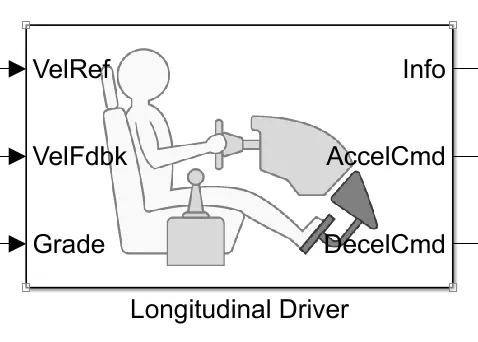
*Longitudinal driver
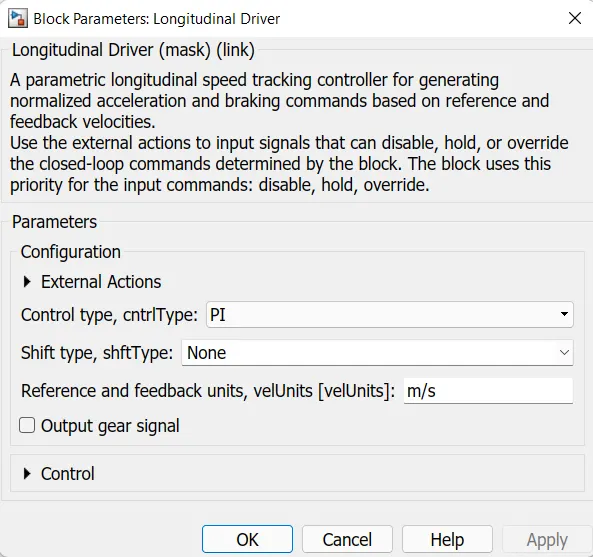
This block is used to create a longitudinal speed-tracking controller and it is based on reference and feedback velocities, the block generates normalized acceleration and braking commands that can vary from 0 through 1. We can use this block to model the dynamic response of a driver or to generate the commands necessary to track a longitudinal drive cycle.
Longitudinal Driver:
Block Parameter:
Power control unit:
This subsystem has the blocks which are used to create the voltage signals to control the motor speed as per the input drive cycle data.
This subsystem is connected to the longitudinal driver block output ports namely acceleration command and deceleration command.
This subsystem will convert this acceleration and deceleration command into voltage signals using two controlled voltage source block, controlled PWM voltage block, a H-bridge and a current sensor.
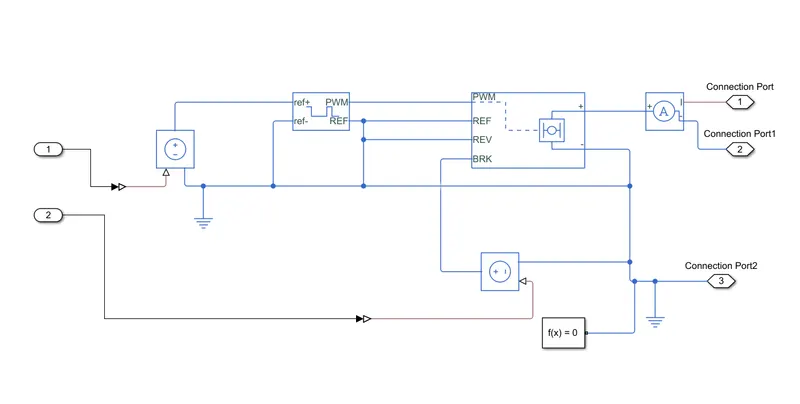
Controlled Voltage source:
The block parameters is shown below,
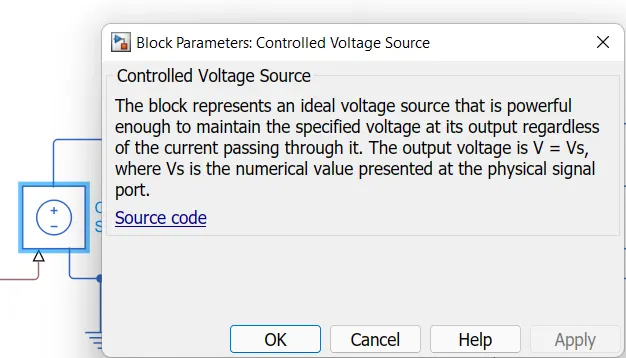
This block is used to maintain the specified voltage at its output regardless of the current flowing through the source.
Controlled PWM Voltage:
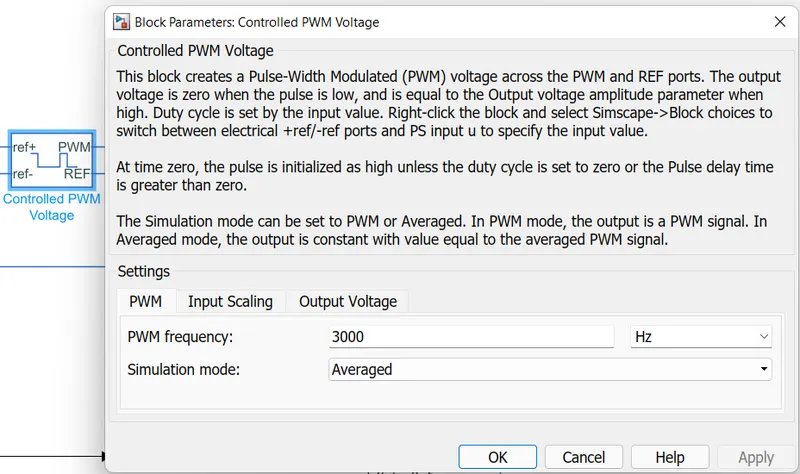
This block is used to create the pulse-width modulated (PWM) voltage.
Electrical input ports:- The block calculates the duty cycle based on the reference voltage across its ref+ and ref- ports. This modeling variant is the default.
The value of the Output voltage amplitude parameter determines amplitude of the output voltage.
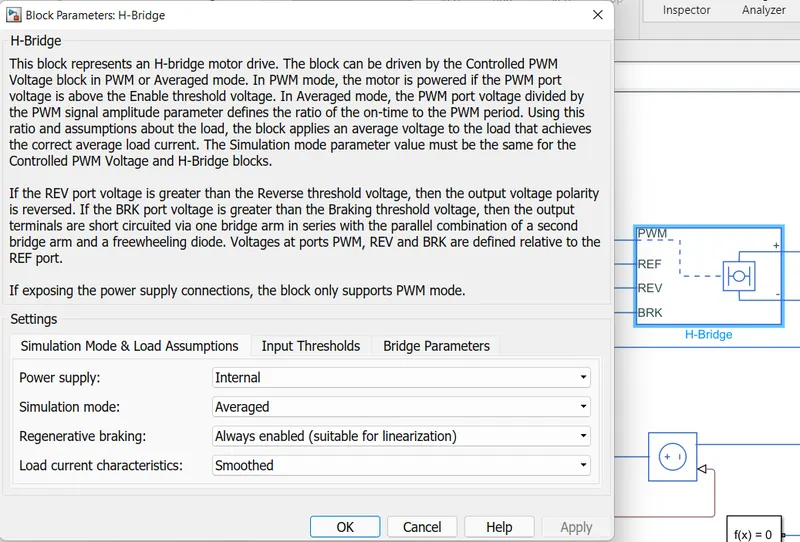
H-Bridge:
This block is used to change the polarity of the voltage applied across the DC motor so as to run the motor in forward and reverse direction as per the input command.
The block and its parameters are shown below,
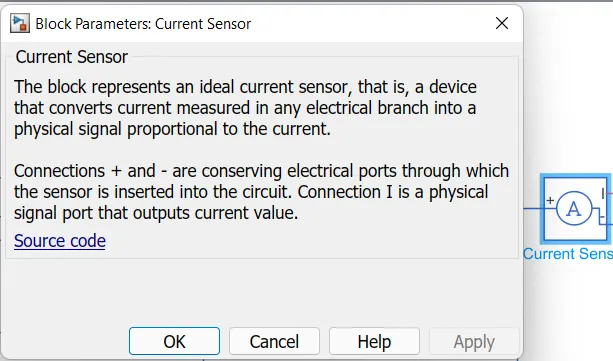
Current Sensor:
This is used to measure the current flowing through the H-bridge.
The block and its parameters is shown below,
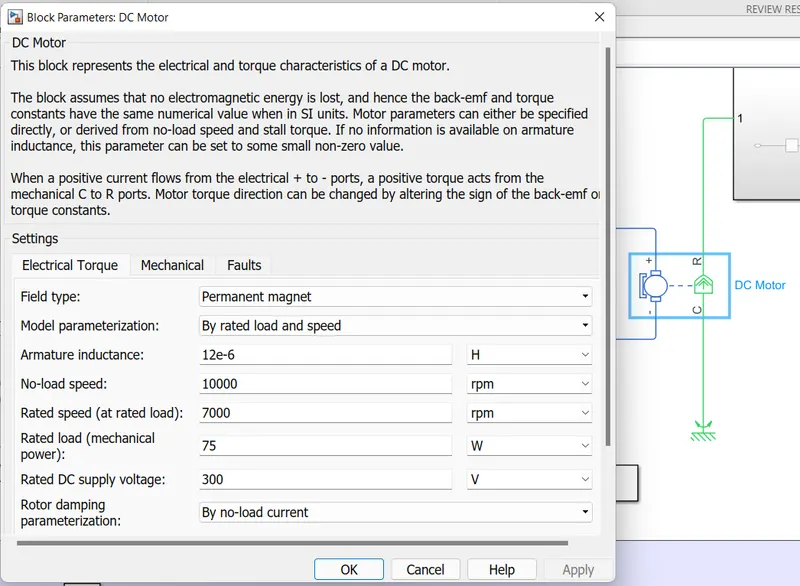
DC motor:
To convert the electrical energy to mechanical energy we use motors. In this electric vehicle model we have used DC motor. This motor can act as a generator also in case of regenerative braking.
The motor block and its parameters are shown below,
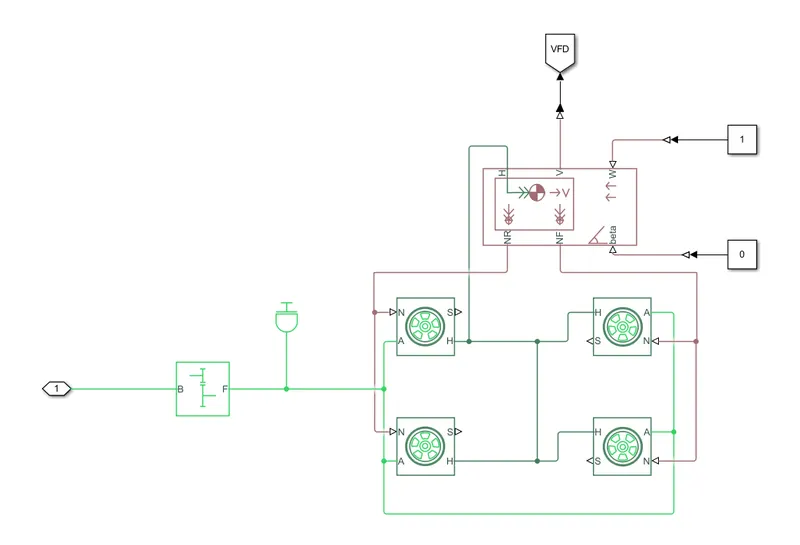
Vehicle body subsystem:
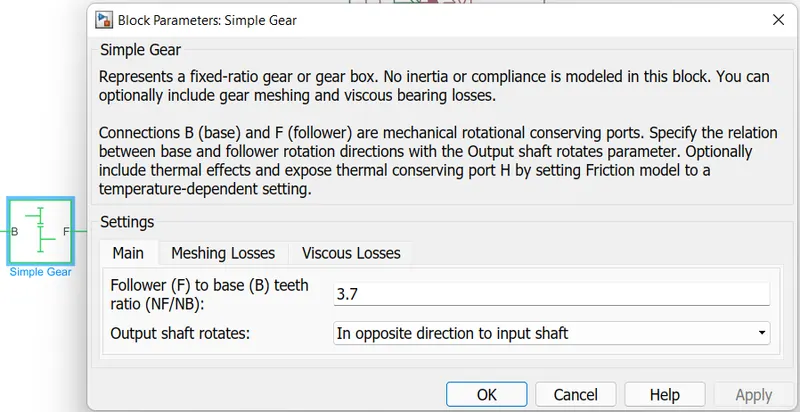
Simple Gear:
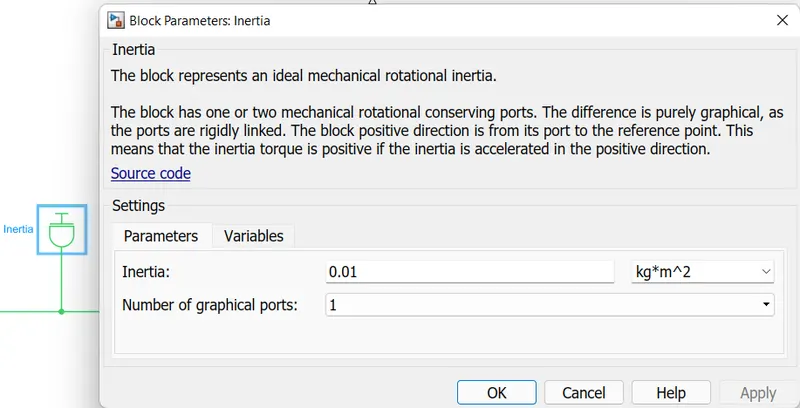
Inertia Block:
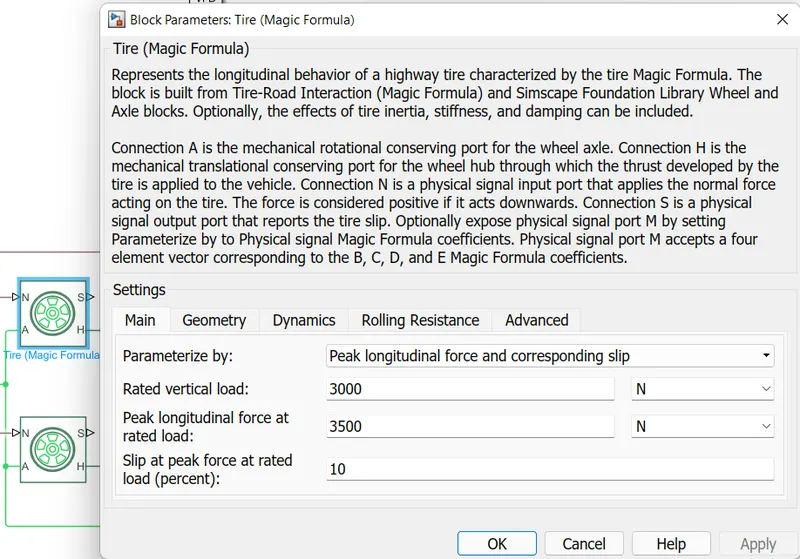
Tire Block:
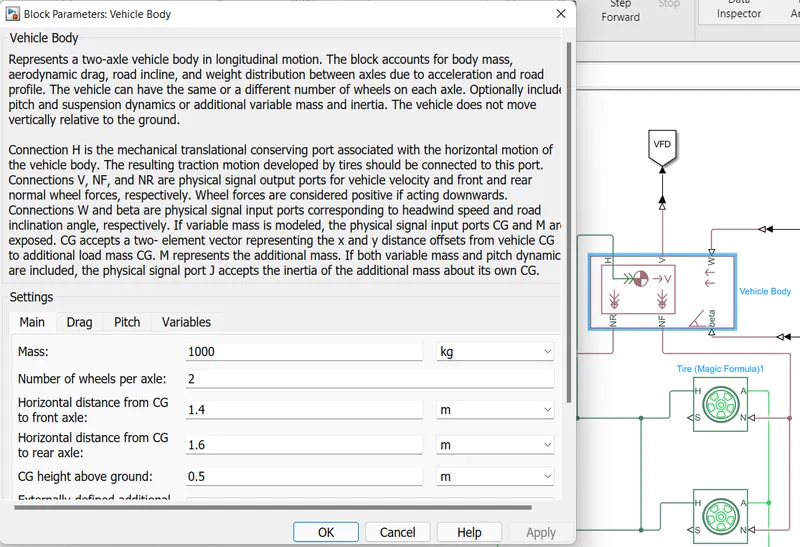
Vehicle Body:
SOC subsystem(State of charge calculation):
The block diagram of the subsystem is as shown below,
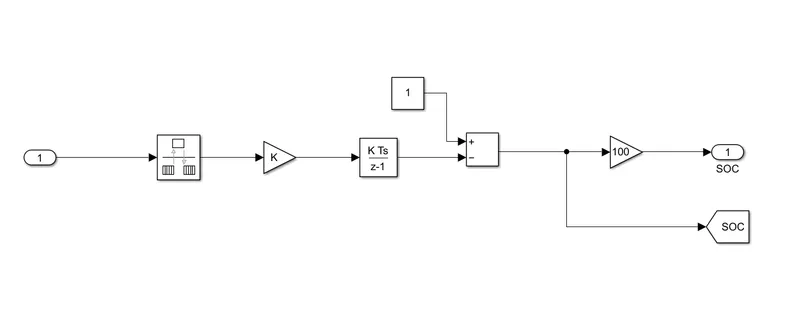
The input for this is from the current sensor.
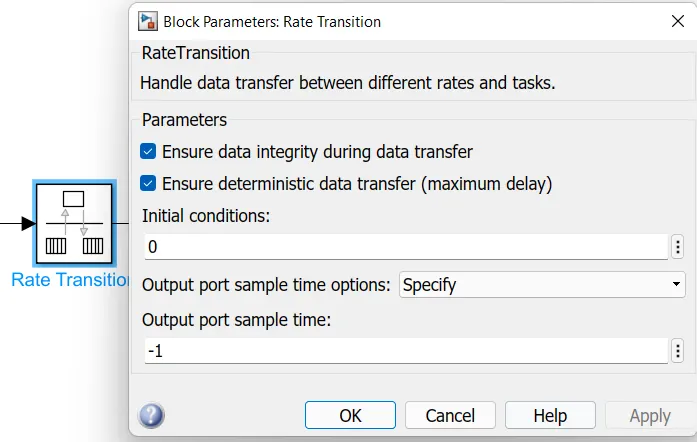
Now this is connected to the rate transition block. This handles the transfer of data between blocks operating at different rates. The block and its parameters are shown below,
Rate Transition:
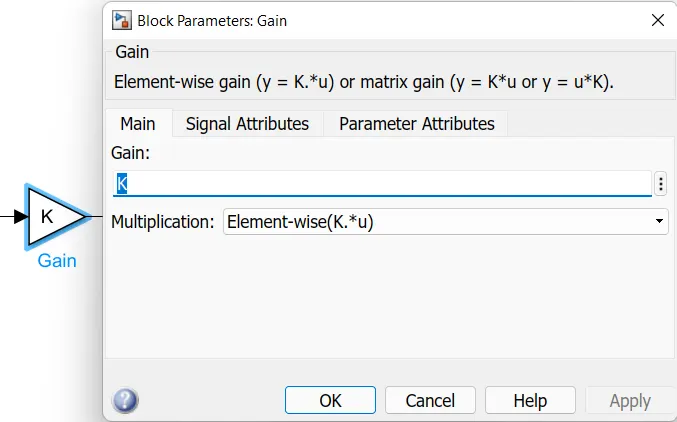
Gain Block:
Then a gain block is connected to it. This gain will multiply the value of k= 1/A.sec value of the battery. , where A-sec is the ampere second
In this case the battery capacity is in Ahr, which is ampere hour.
To convert,
A sec =A * hr * (3600)
Discrete-Time Integrator:
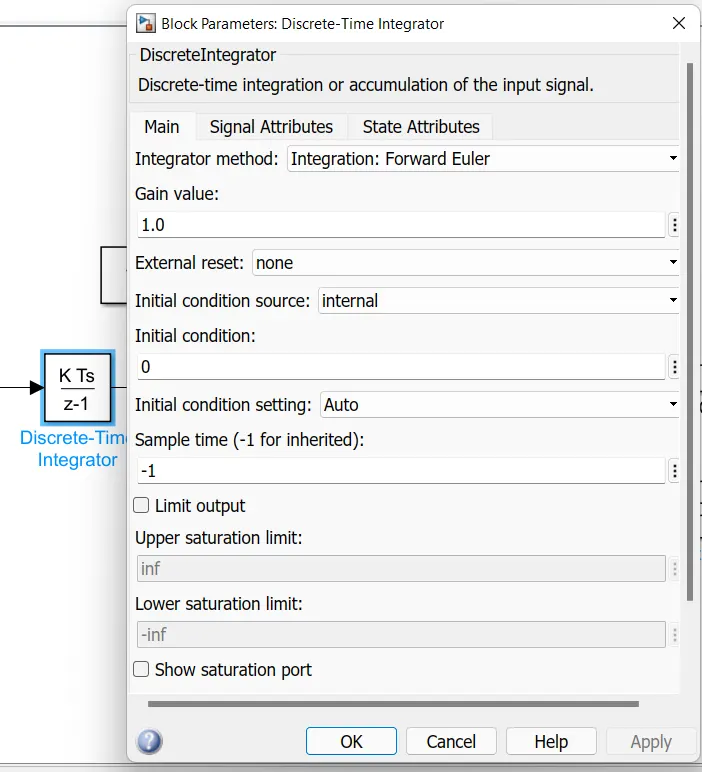
Then to add all these values with respect to time, we have used a Discrete-time integrator. This block will accumulate the input signal. The block and its parameters are shown below,
Now this summed value is subtracted from 1, which will give us the remaining State Of Charge. To convert this to percentage, we have multiplied by 100 using another gain block.
Also a Goto block is used here to get SOC values.
The output from this subsystem is connected to a displaye block, which will display the Battery Percentage as shown below,
Battery Subsystem:
In this subsystem we have a battery block, a controlled current source block and a goto block.
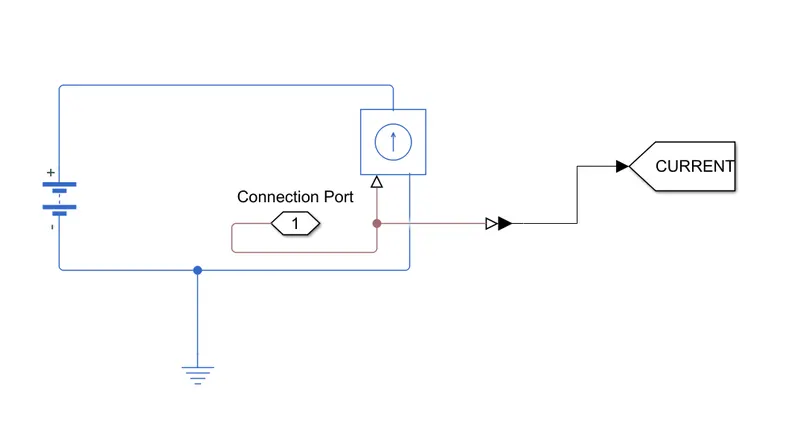
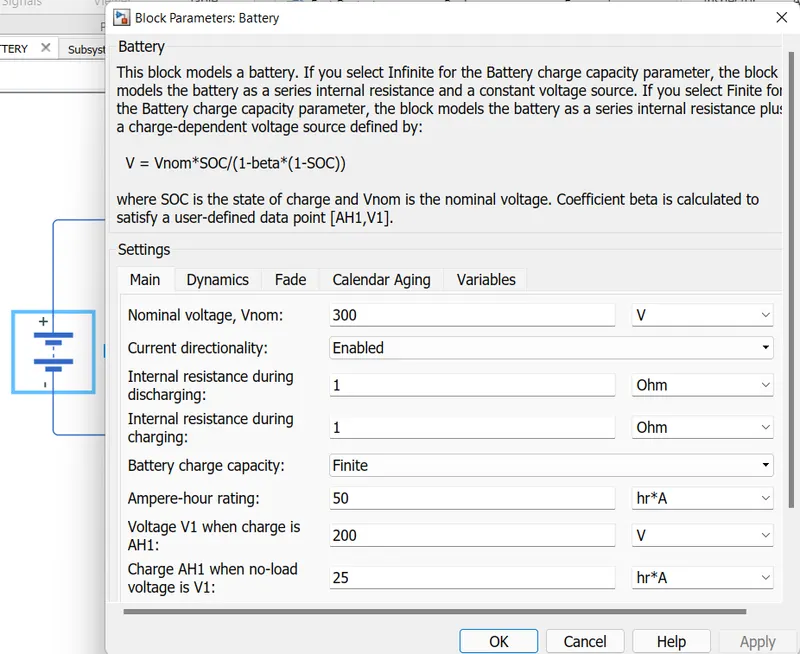
This battery block represents a simple battery model. The block models the battery as a series internal resistance and a constant voltage source.
The block and its parameters are shown below,
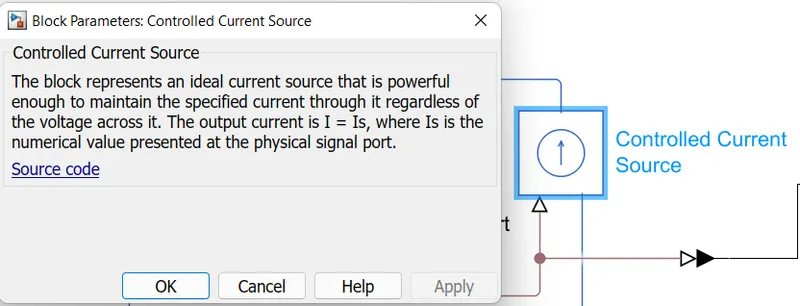
Controlled current source:
It is used to pass values to the 'From block' so that this value can be accessed from anywhere in the Simulink diagram. This input can be a real or complex valued signal or vector of any data type. This 'From block' and 'Goto block' allows us to pass a signal from one block to another without actually connecting them.
The block diagram & parameters of Goto block is shown below,
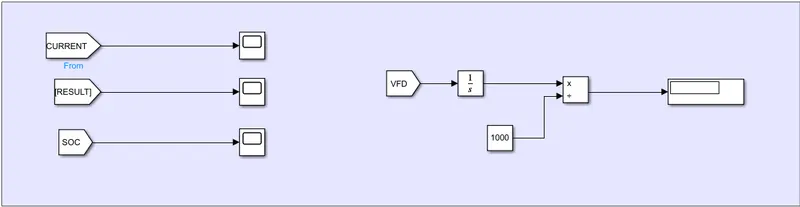
Result:
For current-
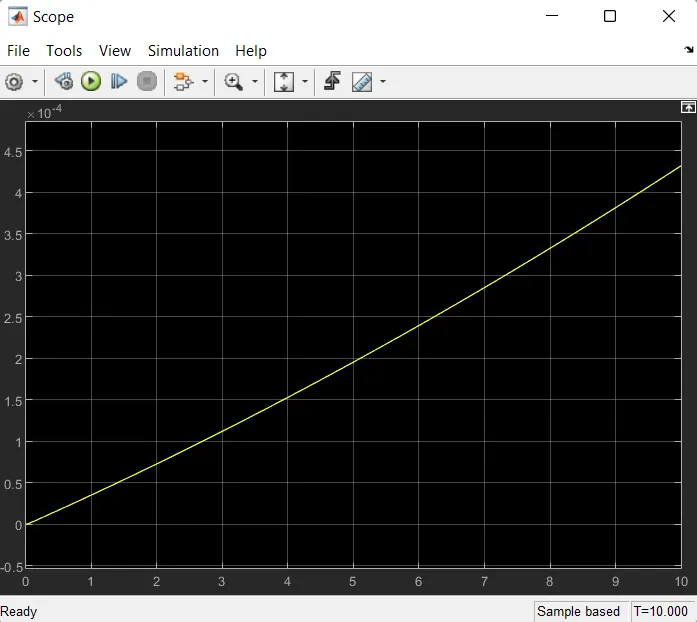
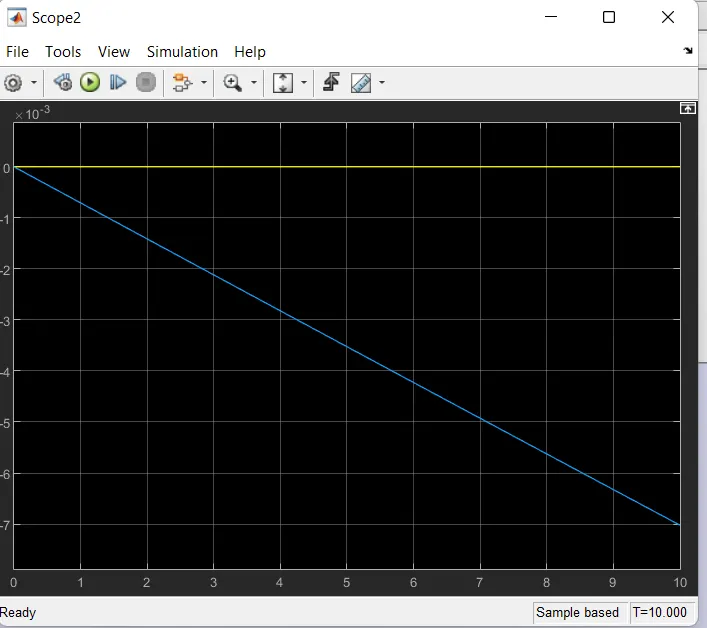
For result-
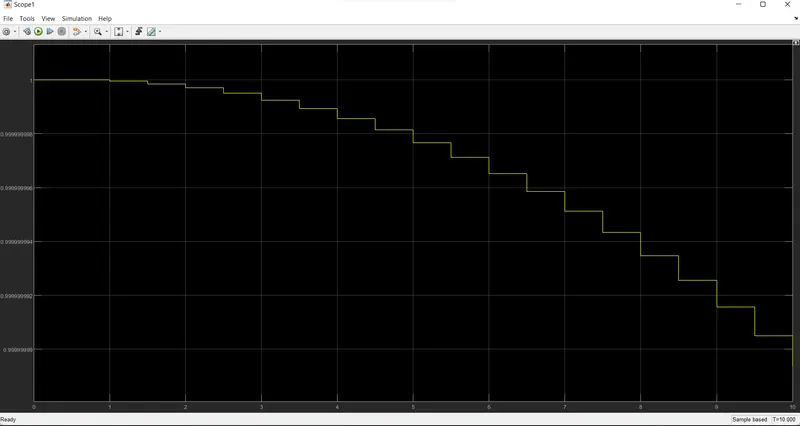
SOC-
Conclusion:
The MATLAB model of an electric car which uses a battery and a DC motor has been successfully made by choosing suitable blocks from powertrain block set and following conclusions has been drawn from the results.
From the input vs output velocity graph we can see that the EV model that we designed have traced the FTP 75 drive cycle very closely. Only when the speed suddenly drops to 0 in the FTP 75 drive cycle, the model takes time to catch up.
On all other occasions the model traced the drive cycle closely. Now looking at the SOC graph we can see that almost 50% of the capacity is used for compleating this drive cycle. And also we can see sudden spikes in that graph,these spikes represents the regenerative braking region. During which the SOC value increases.