Final Project: Design of an Electric Vehicle
Create a MATLAB model of electric car which uses a battery and a DC motor. Choose suitable blocks from Powertrain block set. Prepare a report about your model including following:
Objectives:
1. System level configurations
2. Model parameters
3. Results
4. Conclusion
ans- An ev is a vehicle that is moved by a motor conneted to vehicle body (tyre etc) with gear box. motor is powered by a battery. speed is controled by varying voltage or frequency. input is a drive cycle controlled by a longitudinal driver.
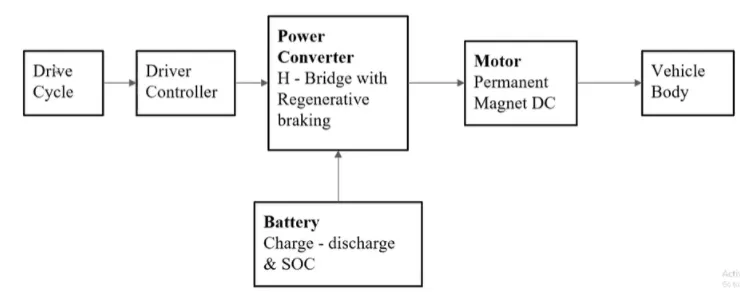
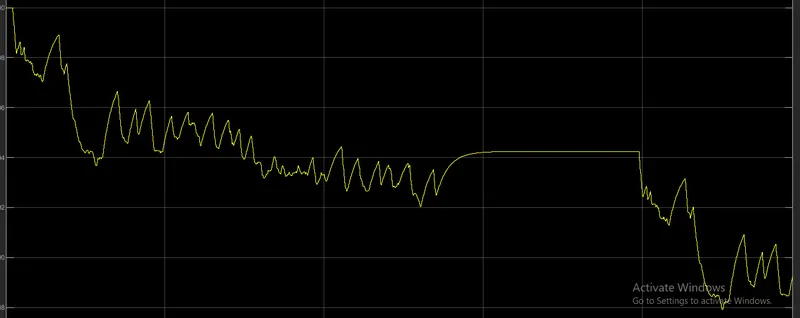
based on above diagram we make a model of EV. WE GIVES input by drive cycle connected with driver. we give three input with signal builder and slider gain using multiport switch. after running we see the state of charge of battery.we see the input velocity and output velocity has negligible difference. we use a permanent magnet brush type DC motor.
simulink design parameter
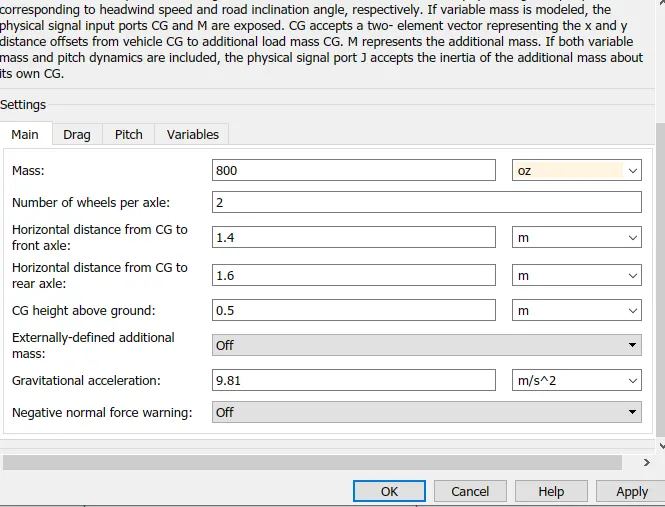
mass of vehicle-800 kg
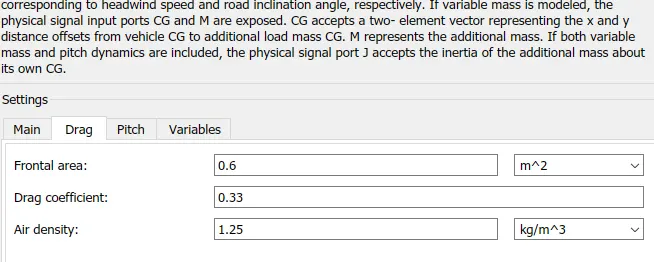
frontal area=0.6 m2
drag coefficient-0.33
radius of wheel- 0.3 m
rolling resistance coefficient-off
cell voltage- 48v
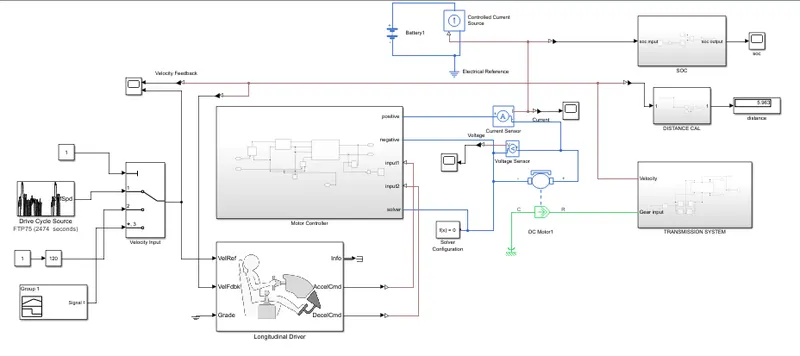
block used-
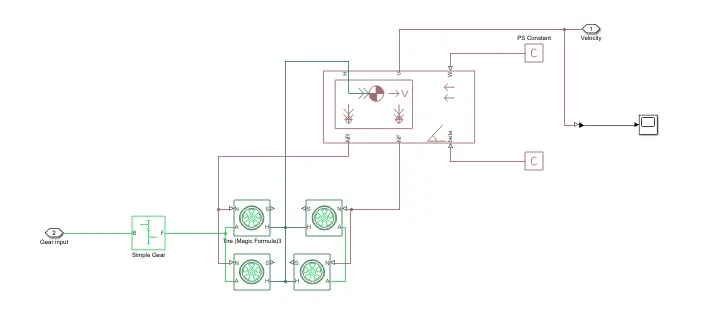
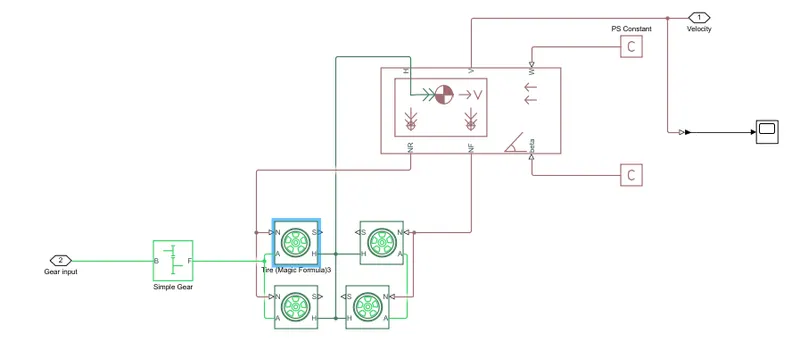
vehicle body-our vehicle is two axle vehicle body having 4 tyres.
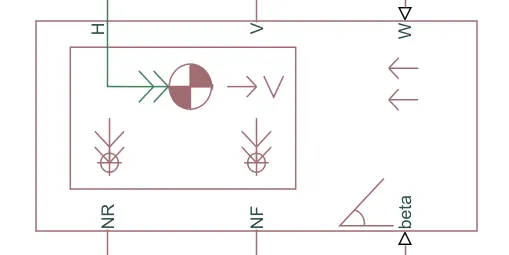
w-signalport for headwind speed
beta-port for inclination angle
v-optpur [ort for longitudinal speed
nf-normal force on front axle
nr-normal force on rear axle
h-for horizontal motion of vehicle body
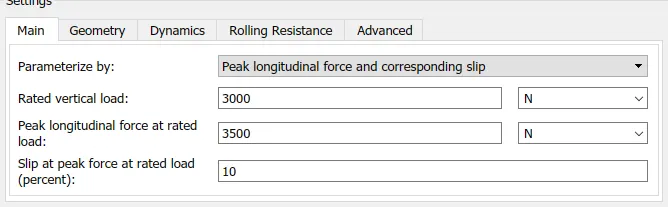
tire-it deals with longitudinal behavior by magic formula. it is empirical equation by four fitting coefficient. tire dynamic constant or pavement condition. tire is contact with road and subject to slip. when torque is aplied on tire it pushes the ground and ration happens so tire moves forward or backward,
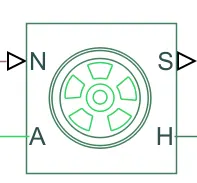
n-normal force acting on tire.
a=mechanical rotational part.
h-mechanical translational part
s-relative slip between tire and road.
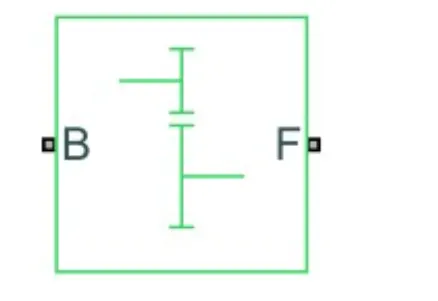
simple gear-it is gear box connected with rear wheel axle.
B-rotational mechanism associated with input shaft
F-ROTATIONAL MECHANISM ASSOCIATED WITH OUT PUT SHAFT
DC MOTOR-it provides torque to vehicle subsystem throgh gear box.
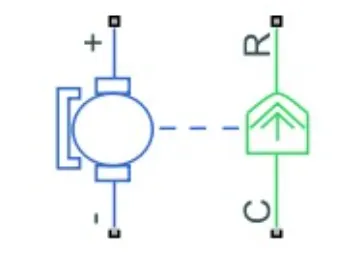
positive and negative terminal.
R-mechanical rotation part associated with dc rotor.
C-rotation part with dc motor case.
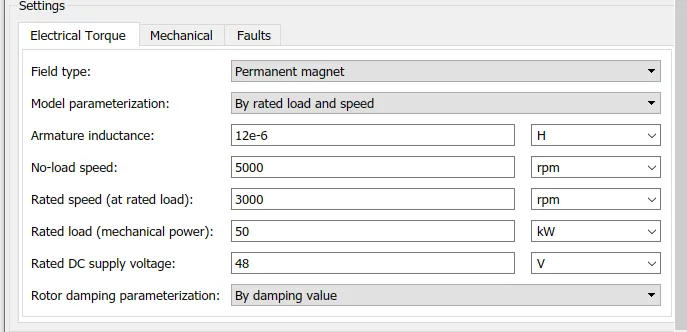
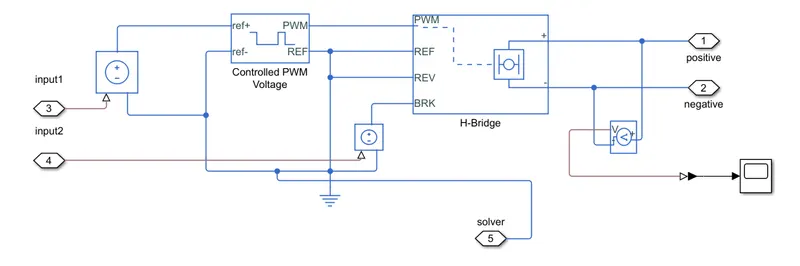
PWM- pulse width moduation is used to control motor output from given duty cycle.
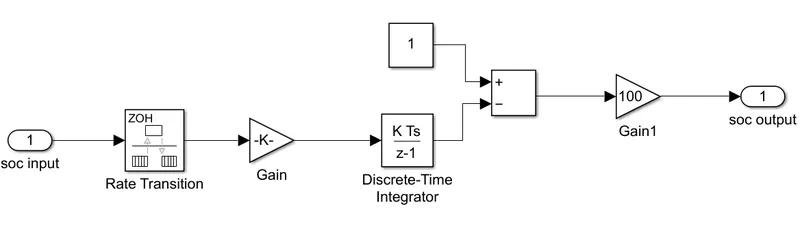
bateery-battery is equivalent circuit of many cells. they are connected in series or parallel in a battery pack. soc(state of charge) calculation is used to measure the amount of batteryc charge available.
results-
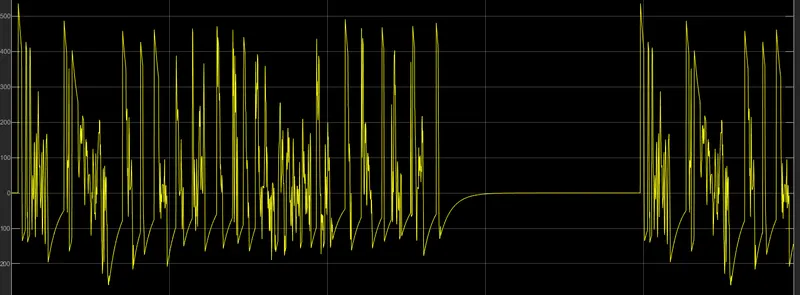
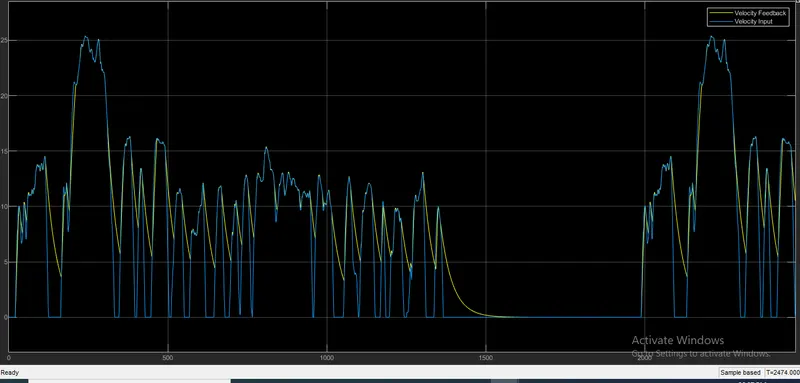
velocity
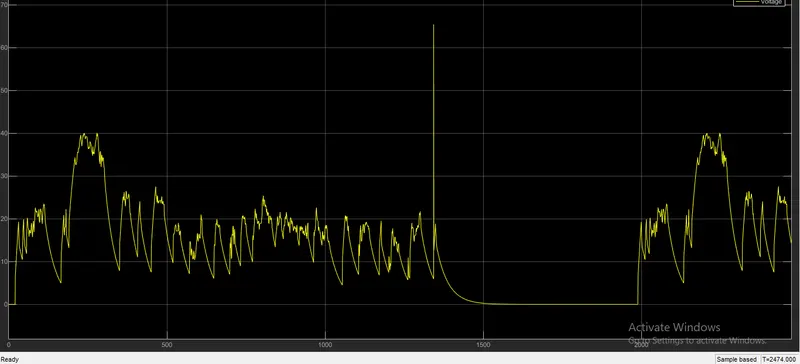
voltage