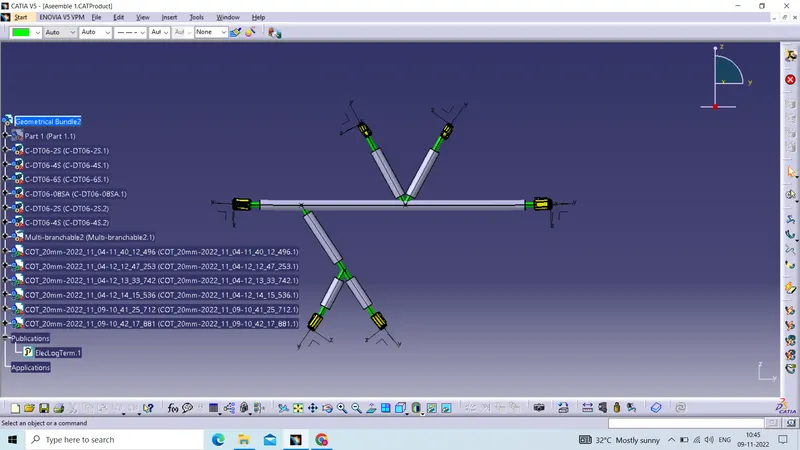
Wiring harness design in CATIA V5 - 3D modeling Week 4 Challenge
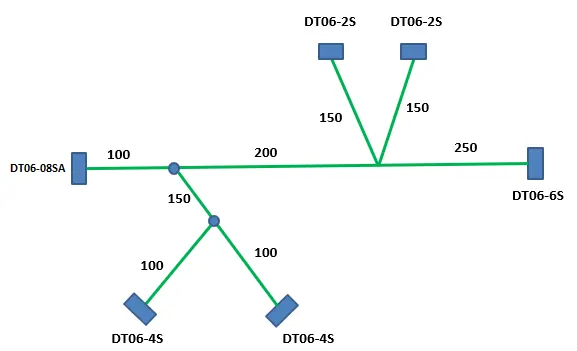
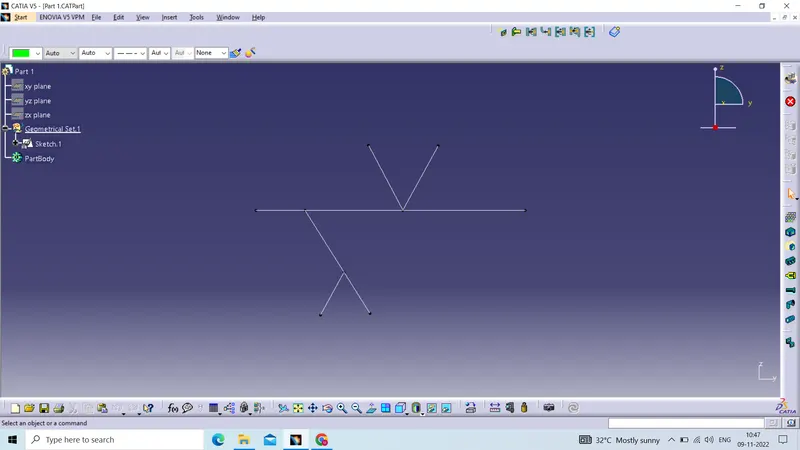
Q1. Route the following harness layout in Electrical workbench. Make assumption for harness bundle diameters. Use Following connectors as shown in layout diagram.
Add protective covering on all branches connected to DT06-2S & DT06-4S connectors. Keep end extremity at 30mm (from connectors end)
- DT06-4S
- DT06-6S
- DT06-2S
- DT06-08SA
DT06-2S :-
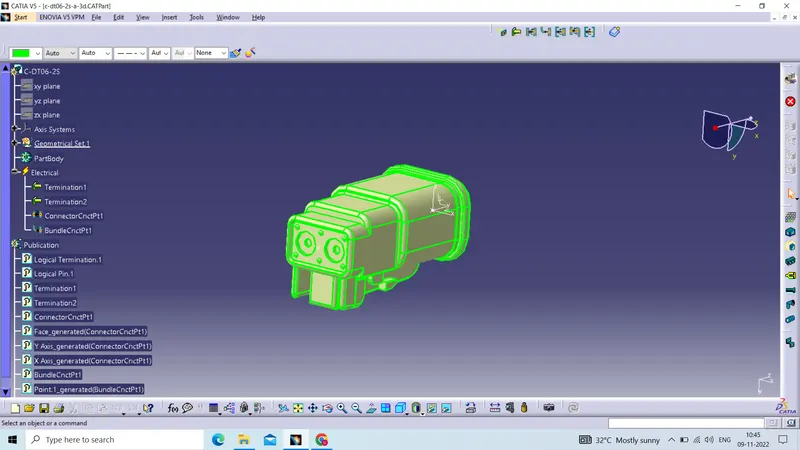
First imported models from given link. Open mechanical part desing, Defined the middle point with of the mide point, On the connector sdie and bundle side.
Given axis system to connector side, Rotated X Axis and given the 90 degree y axis the n coincidence now changing the work bench electrical part design.
The defined the connector side as the connector connection point, It is as define bundle connection side as a bunedle coneection point.
DT06-4S :-
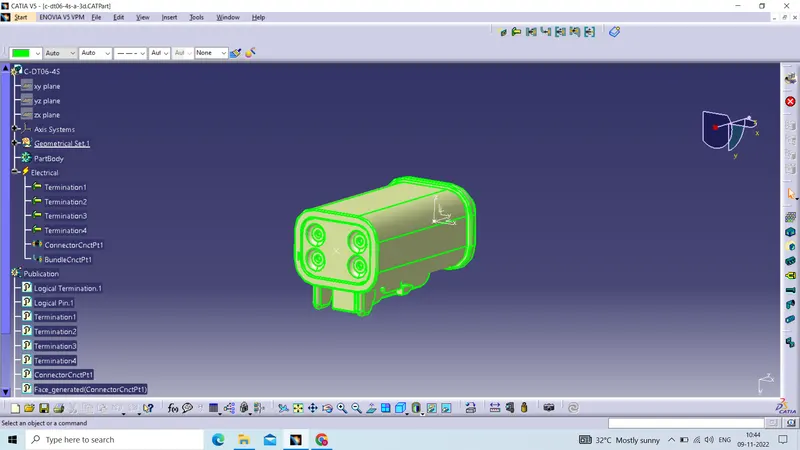
First impot model from given link open mechanica part design, and define the middle point with help of the mid point on the connector side and bundle side.
GIven axis system to connector side, rotated axis 90 degree for y axis coincidence, now changing the workbench with 4 termination.
It define the connector connection point, and the bunde connection side as a bundle connection point.
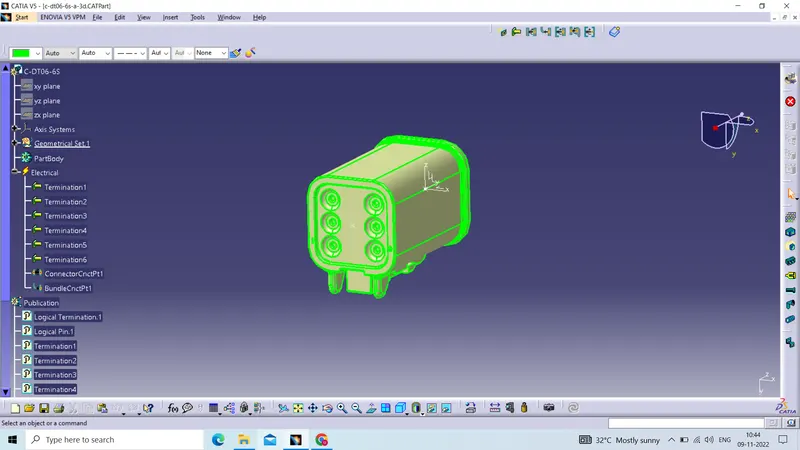
DT06-6S :-
First imported models from given link, Open mechanical part design, defined the middle point with help of the mid point, on the connector side and bundle side.
Given axis system to connector side, rotated x axis 90 degree for y axis coincidence now changing the workbench electrical part design.
The defined the connector side as the connector connection point, defined imported models from given link open mechanical part .
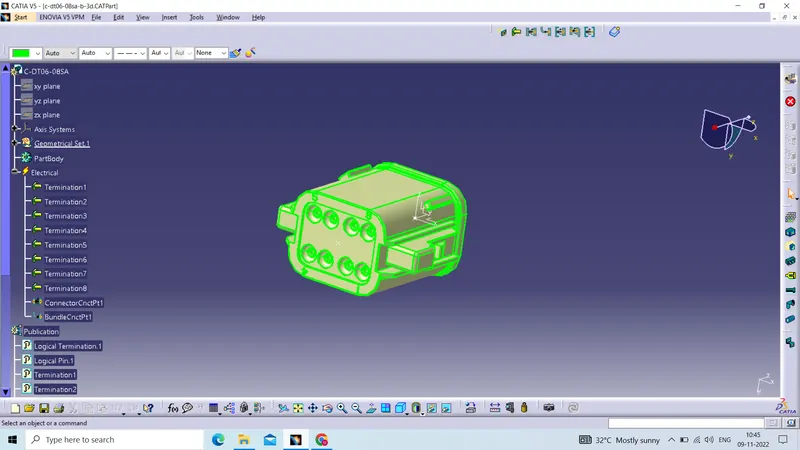
DT06-08SA :-
First imported models from given link, Open mechanical part design, defined the middle point with help of the mid point, on the connector side and bundle side.
Given axis system to connector side, rotated x axis 90 degree for y axis coincidence now changing the workbench electrical part design.
The defined the connector side as the connector connection point, defined imported models from given link open mechanical part .
Part :-
Position Part :-
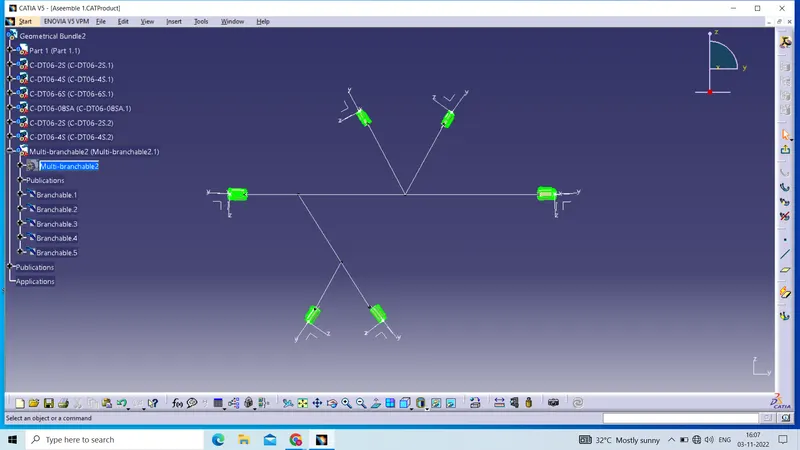
Assembly :-