Simulating Frequency control of an Induction motor and explaining the equivalent circuit of an induction motor
Explaning the equivalent circuit network of induction motor MATLAB model.
Induction motors are frequently used in both industrial and domestic applications.
Within the induction motor, an electrical current in the rotor is induced by a varying magnetic field in the stator winding. The rotor current produces it's own magnetic field, which then interacts with the stator field to produce torque and rotation.
Equivalent circuit is one of the ways to study and analyse the working of an Induction motor.
This is an equivalent circuit of an induction motor for single phase alone. All the three phases have similar equivalent ciruit.
R1 - resistance of the stator winding
X1 - stator leakage reactance (flux that does not link with the air gap and rotor). Xm
Xm - Magnetising reactance required to cross the air gap
Rc. - core losses (hysteresis and eddy current)
R2 - rotor resistance (resistance load value)
X2 - rotor reactance (dependant on the frequency of the inductor rotor emfs. )
An ideal transformer of N1 and N2 turns respectively represents the air gap. For the rotor side, the induced emf is affected by the slip (as the rotor gains speed, slip reduces and less emf is induced).
Rotor current I2
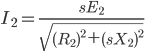
which can be rewritten as:
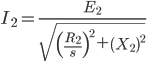
By the above equality the circuit can be drawn as
The equivalent circuit shown above has removed the dependence on slip for determining the secondary voltage and frequency.
Consequently the circuit can be simplified by eliminating the ideal transformer and referring the rotor's resistance and reactance to the stator values. (denoted by ′).
Thus in the equivalent ciruit the behaviour of stator side resistance and reactance, air gap resistance and reactance and rotor side reactance and resistance in an induction motor.
are shown clearly.
The main key point is that the rotor state parameters are expressed in terms of stator values.
In most of the cases the Rc is neglected in calculations due to its small magnitude.
Electrical supply is given to stator windings and the stator current Is seperates into I0 (magnetizing current) and I2 (rotor current).
2) Torque calculation of an Induction motor.
Number of phases = 3
Frequency = 50Hz
equivalent circuit constants X1 = X2 = 0.1 ohm and R1 = R2 = 0.2 ohm
Calculate the ratio of starting torque at half voltage & frequency to rated values.
clear all
close all
clc

nph = 3;                % number of phases

x1 = 0.1;               % Stator leakage reactance (ohm)
x2 = 0.1;               % Rotor leakage reactance  (ohm)
r1 = 0.2;               % Resistance of the stator winding (ohm)
r2 = 0.2;               % Resistance of the rotor winding (ohm)

s = 1;                  % slip value
poles = 4;              % number of pole pairs

Z1eq = r1+1i*x1;
R1eq = real(Z1eq);
X1eq = imag(Z1eq);

% Rated values
E =  230/sqrt(3);                       % Rated Phase voltage
f = 50;                                 % Rated Frequency of supply voltage in Hz
omegas = 4*pi*f/poles;
I = abs(E/(Z1eq + 1i*x2 + r2/s));
T1 =  nph*I.^2*r2/(s*omegas);

% Reduced Torque
E2 = 115/sqrt(3);                      % Reduced Phase voltage
f2 = 25;
omegas2 = 4*pi*f2/poles;               % Rated Frequency of supply voltage in Hz
I2 = abs(E2/(Z1eq + 1i*x2 + r2/s));
T2 =  nph*I2.^2*r2/(s*omegas2);


disp(['Starting Torque with reduced voltage and frequency = ' num2str(T2) ' Nm'])
disp(['Starting Torque with rated voltage and frequency   = ' num2str(T1) ' Nm'])
disp(['Ratio (Reduced torque/Rated torque) = ' num2str(T2/T1)])
Output
The matlab script uses basic formula for calculating starting torque of an induction motor at rated voltage, frequency values and half rated voltage, frequency values.
3) MATLAB script file which will plot speed torque characteristics for frequency control method.
A matlab script is written to map the Torque of an induction motor along the Y axis and Rotor Speed(rpm) along X axis at various frequency values.
clear all
close all
clc
% Input values
v1 = 230/sqrt(3);
nph = 3;
poles = 4;
R1 = 0.095;
R2 = 0.23;
X1 = 0.680;
X2 = 0.672;
Xm = 18.7;

% Calculate the Stator equivalent
Z1eq = 1i*Xm*(R1+1i*X1)/(R1+1i*(X1+Xm));
R1eq = real(Z1eq);
X1eq = imag(Z1eq);
V1eq = abs(v1*1i*Xm/(R1 + 1i*(X1+Xm)));


s = 1:-0.001:0;   % slip values
Torque=[];
speed=[];
curve={};

for fe = round(linspace(50,100,6))  % frequency
     omegas = 4*pi*fe/poles;
     ns = 120*fe/poles;
     rpm = ns*(1-s);
     I2 = abs(V1eq./(Z1eq + 1i*X2 + R2./s));
     Torque(:,end+1)= nph*I2.^2*R2./(s*omegas);
     curve{end+1} = strcat('fe = ', num2str(fe), ' Hz');
     speed(:,end+1) = rpm;
end


plot(Torque,speed,'LineWidth',2)
yticks(speed(end,:))
title('Torque Speed characteristics');
ylabel('Speed (rpm)');
xlabel('Torque (Nm)'); legend(curve)
The output plot gives the Torque and speed variation curve at 6 different values of frequency.
Here 50 is the rated frequency.
From the observation it can be observed that increasing the frequency of the current with constant stator voltage, the Toruqe value decreases and rotor speed value increases
4) Working of a Brushless DC motor (BLDC motor)
Brushed dc motor produce sparks and noise which are undesired results.
To avoid these Brushless dc motors used, which have a smooth and silent operation.
The two types of BLDC motor based on rotor position are
Inrunner motor - rotor is placed inside
Outrunner motor - rotor is place outside
Rotor - It has two permanent magnets placed opposite to each other with opposite polarities.
Stator - Has number of copper coils wounded which act as electromagents on passing electric current through them.
Stator coils get excited and produce magnetic field such that it attracts the permanent magnets of rotor and when the rotor is about to reach the excited coil, the next coil is excited and thus the rotor continously follows the coils which are excited.
Single coil excitation
In this method only one coil is excited and two coils are idle at any given time, this produces less torque.
Double coil excitation
To improve the torque, two coils are excited such that one coil's magnetic field repels the permanent magnets of rotor and the other coil's magnetic field attracts the permanent magnets of rotor. Hence torque value is high and constant torque is possible.
The sequence and timing of excitation is controlled by an electronic control system.
Two methods are used for controlling they are 1) using sensor and 2) sensorless method
1) Sensored BLDC motor
The most common sensor method uses three Hall-effect sensors embedded in the stator and arranged at equal intervals, typically 60° or 120°.
In a sensor-equipped BLDC motor, each Hall-effect sensor is combined with a switch which generates a logic “high” (for one magnetic pole) or “low” (for the opposite pole) signal. The commutation sequence is determined by combining the logic signals from the Hall-effect sensors and associated switches. At any time, at least one of the sensors is triggered by one of the rotor’s magnetic poles and generates a voltage pulse.
The below figure shows the status of the phase windings in relation to the Hall-effect sensor signals for the anti-clockwise spinning motor.
2) Sensorless BLDC motor
A sensorless BLDC motor makes use of the electromotive force (EMF) that gives rise to a current in the windings of any DC motor with a magnetic field that opposes the original change in magnetic flux as described by Lenz’s Law. The EMF tends to resist the rotation of the motor and is therefore referred to as “back” EMF. For a given motor of fixed magnetic flux and number of windings, the EMF is proportional to the angular velocity of the rotor.