Week 8 - Simulating Cyclone separator with Discrete Phase Modelling
Cyclone seperators or simply cyclones are separation devices that use the principle of interia to remove particulate matter from flue gases. Cyclone seperators is one of many air pollution control devices known as precleaners since they generally remove larger pieces of particulate matter. This prevents finer filteration methods from having to deal with large, more abrasive particles later on. In addition, several cyclones seperators can operate in parallel , and this system is known as a multicyclone.
Four Empirical models used for Cyclone Seperator Efficiency :
Lapple Model :
Lapple model was developed based on the force balance without considering the flow resistance. Lapple assumed that a particle entering the cyclone is evenly distributed across the inlet opening. The particle that travels from the inlet half width to the wall in the cyclone is collected with 50% efficiency.
It ignores flow resistance in the force balance. This model is based on the following assumption:
(i) The particle entering the cyclone separator are evenly distributed across the inlet.
(ii) The particle that travels from inlet half-width to the cyclone wall is collected with 50% efficiency.
Li and Wang Model :
It takes into account the following effects at the cyclone separator wall :(i) particle bounce (ii) Turbulent duffusion. The model is based on the following assumption :
(i) For uncollected particles in the separator, the radial velocity profile and the radial concentration profile are not constant.
Koch and Licht model :
It is describes the motion of particles near the entry and collection regions, based on the following assumptions :
(i) There is no slip between the particles and gas along the tangential direction i.e the tangential velocity of a particle is equal to the tangential velocity of the gas flow.
(ii) The tangential velocity is related to the radius of the cyclone.
Lozia and Leith model:
It is a logidtic model based on the force balance and assumes that a particle under the influence of the vortex experiences two forces :centrifugal force and flow resistance.
Boundary Conditions:-
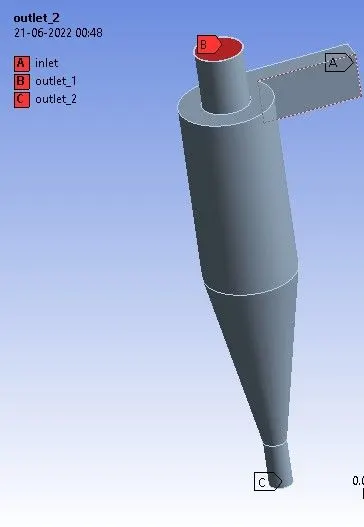
Inlet and Wall : Reflect
Outlet(Top) : Escape
Outlet(Bottom) : Trap
I am going to simulate the cyclone seperator for 2 cases
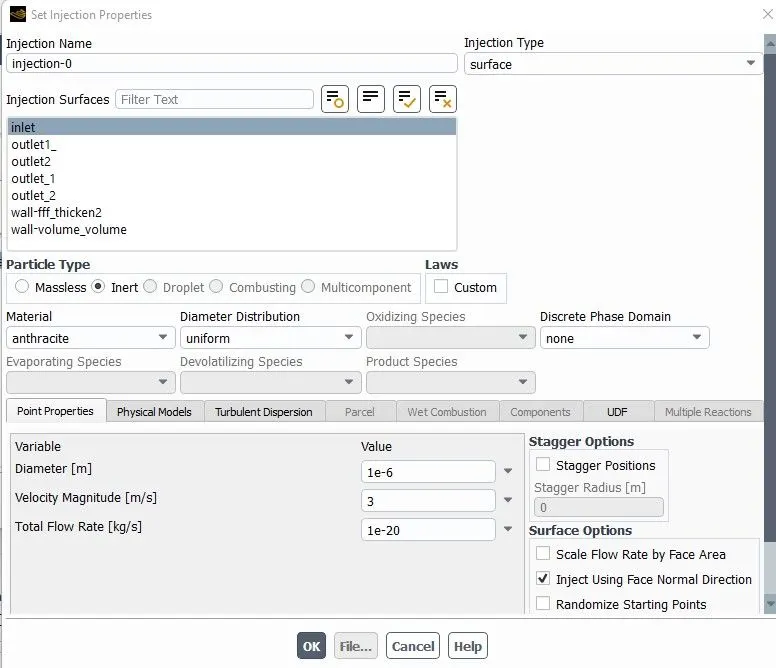
CASE 1 : varrying particle diameter from `1 mum`- `5mum`with velocity as 3m/s
CASE 2 : Varying velocities from 1m/s - 5m/s with particle diameter as `5mum`
Simulator Procedure :
Geometry
1. Import the geometry.
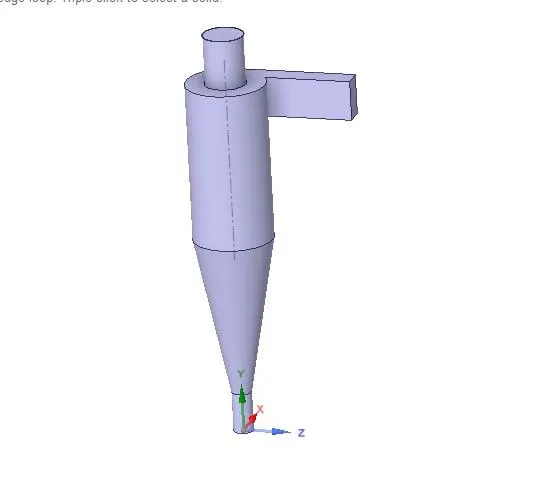
2. Extract the fluid Volume & check for any extra edges so the fluid volume dont't get obstruct.
3. Suppress the outer geometry.
4. This completes the geometry section.
Mesh
Open the mesh section.
Name the faces like inlet,outlet-1,outlet-2.
Then right click on mesh and insert the method in order to generates the mesh.
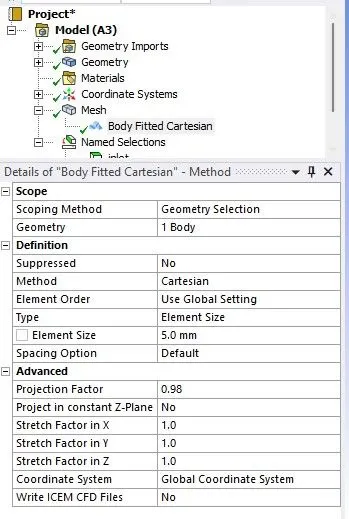
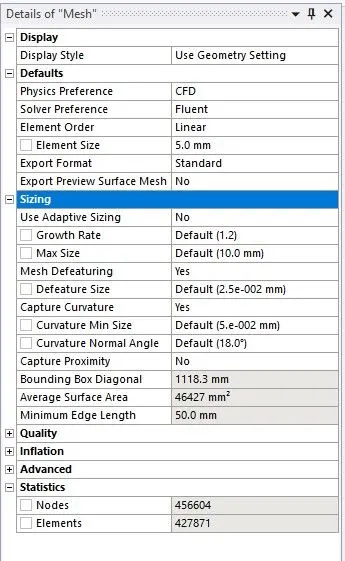
Then generates the mesh.
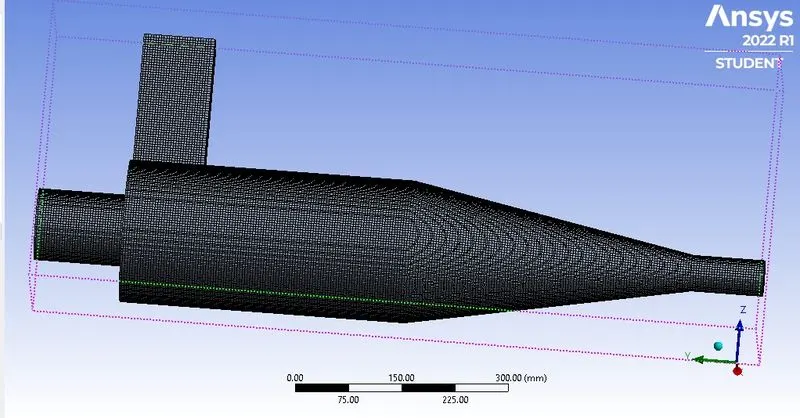
Setup :
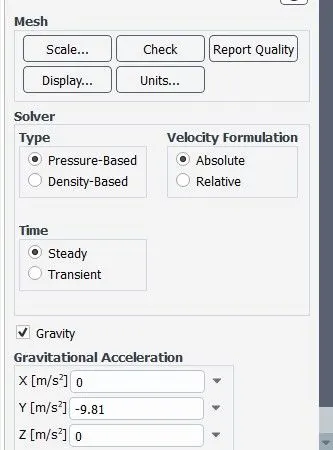
1. Perform mesh check
2. Set up the gravity
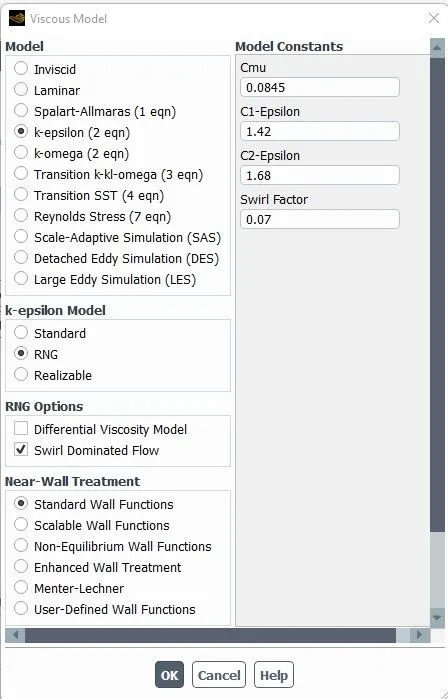
3. Turn on the turbulence model, in our case we are using K-epsilon RNG model as it is good for swirl domination flows.
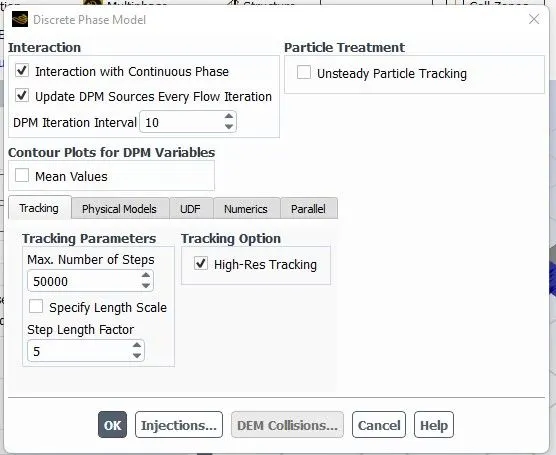
4. Set up the Discrete Phase model and DPM iteration interval.
5. Then add injections to inlet surface and set up point properties like particular velocity, Diameter and flow rate.
6. Set up the boundary conditions.
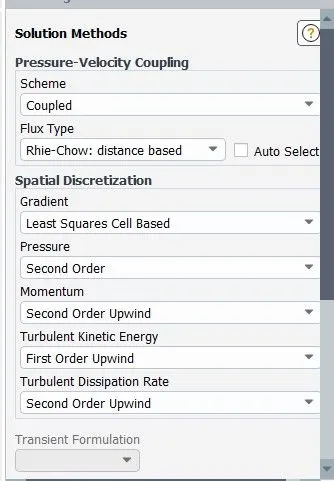
7. Set up the solution method and relaxation factors.
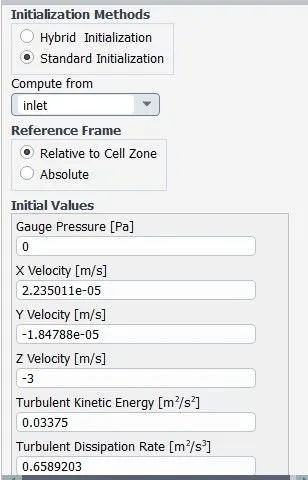
8. Finally initialize and run the setup.
9. Export the particle History.
Results :
1. Make the fluid volume visible.
2. import the particle data.
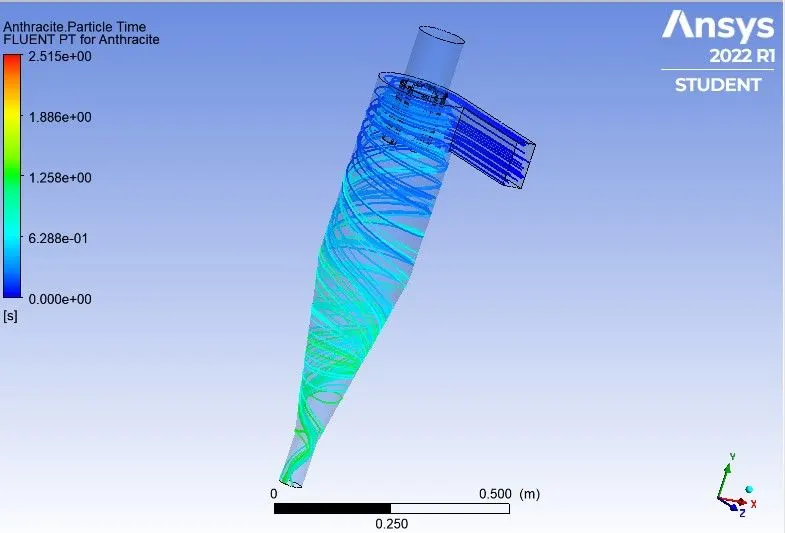
3. Set the particle tracks and color them with required variables.
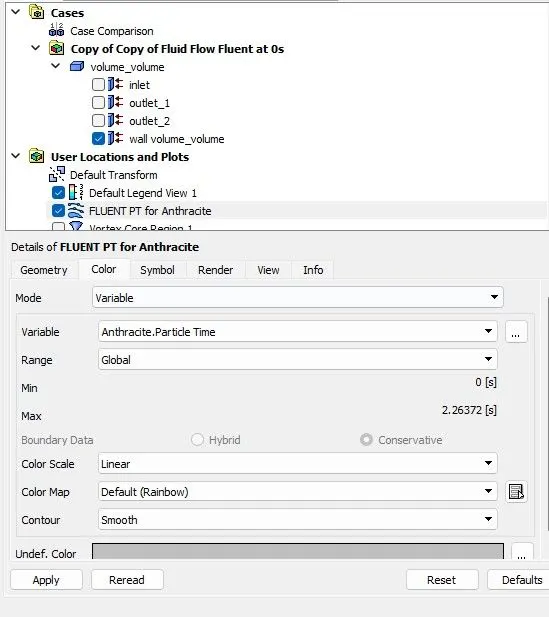
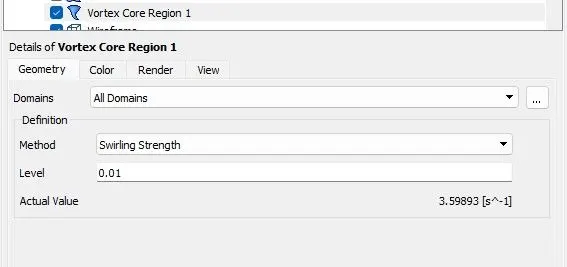
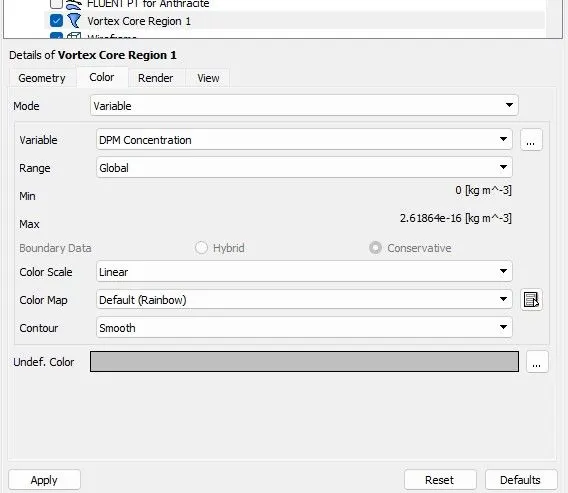
4. Set up Sweep animation and observe the particle flow.
Mesh Input :
1. Element size = 5mm
2. Total Element = 427871
Setup Inputs :-
1. Solver - Pressure Based Steady
2. Viscous Model - K-epsilon RNG(Swirl Domination Flow)
3. Particles - Anthracite
4. Fluid - air
5. DPM Boundaries - Inlet = Reflect
Outlet 1 = Escape
Outlet 2 = Trap
6. Solution Method - Simple(first order)
7. No. of DPM tracking steps - 50000
Outputs :
CASE I - Simulation on varrying particle Diameter from 1`mum`- `5mum`and keep the flow velocity as 3m/s and calculate the separation efficiency for each case.
[1] For particular Dia. = `1mum`
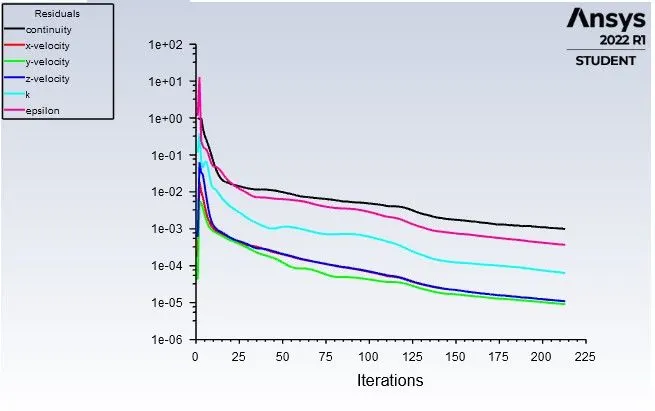
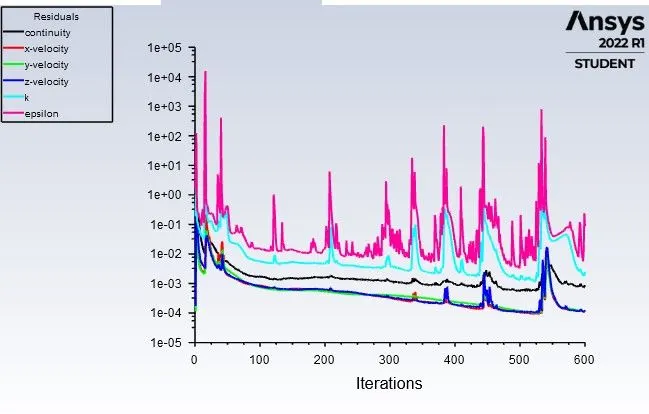
Residuals
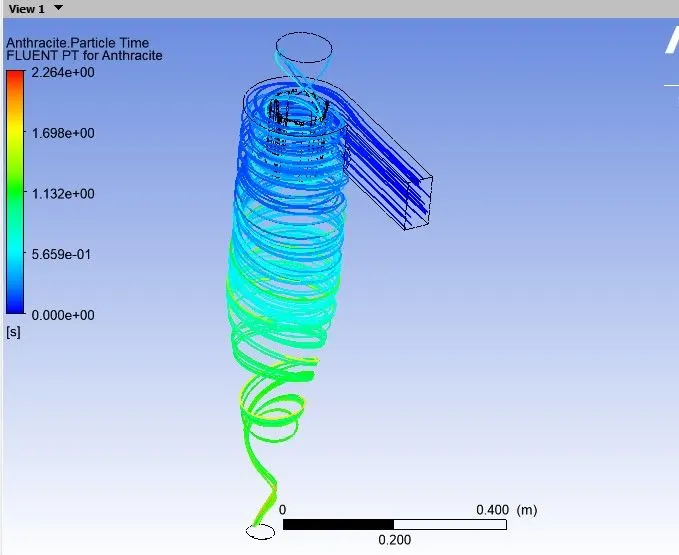
Particle Time
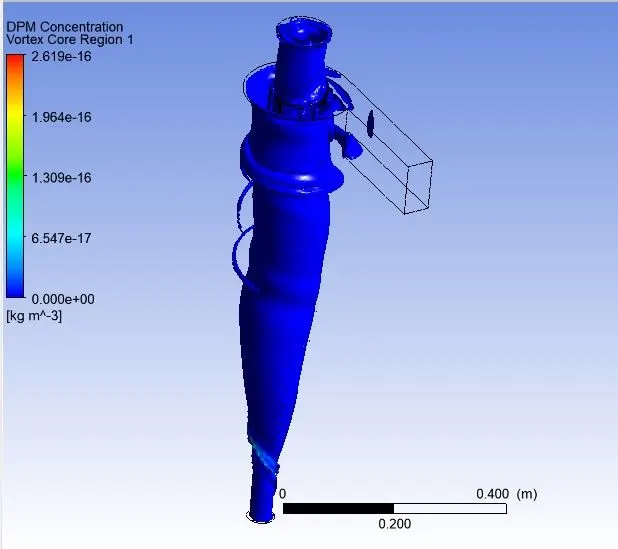
Basic Vortex Region
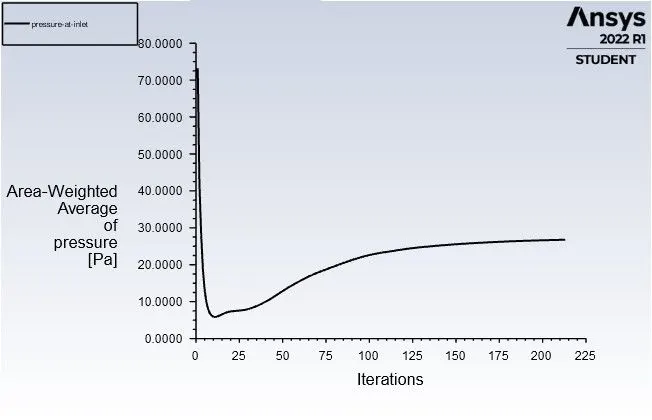
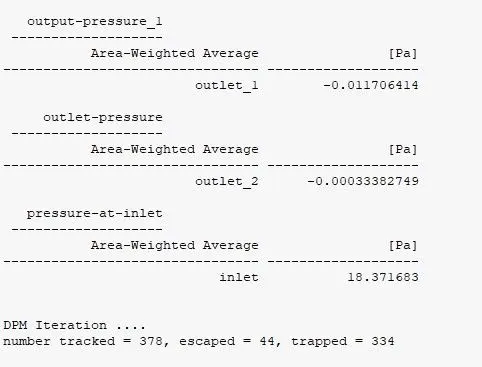
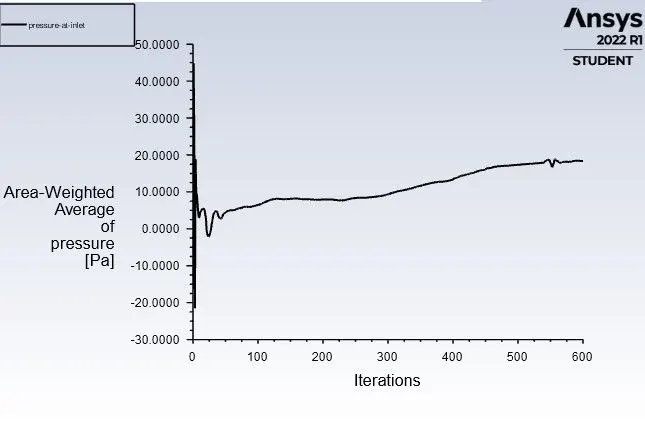
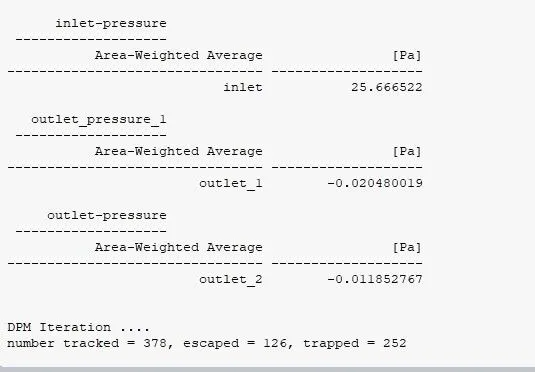
Pressure at inlet
Pressure at outlet_2
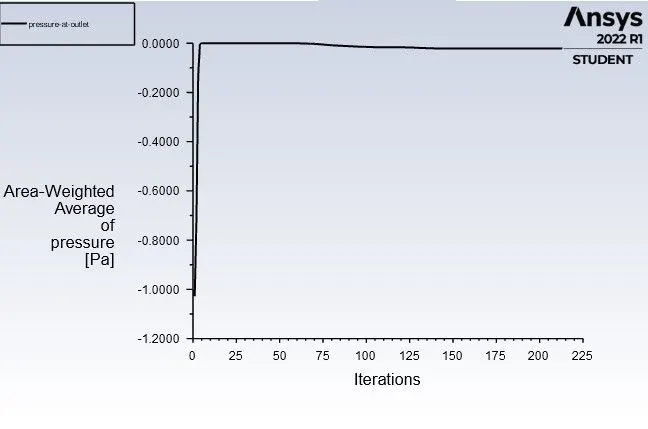
Particle History
Particle Animation
[2] For particular Dia. = `2mum`
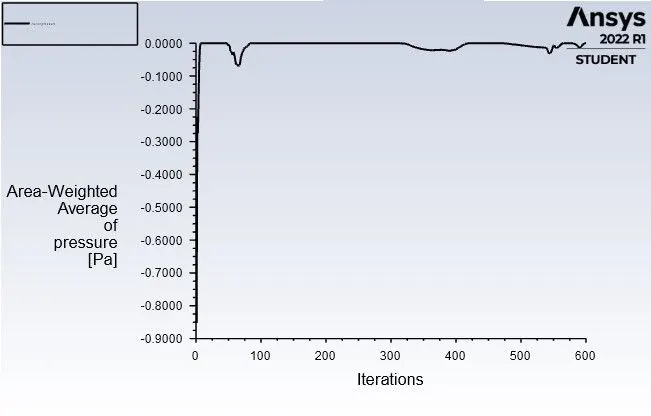
Residuals
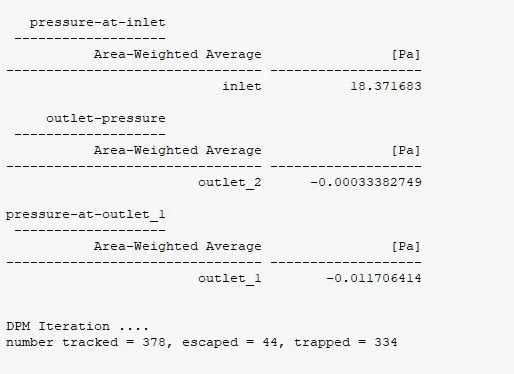
Pressure at inlet
Pressure at outlet_2
Particle Time
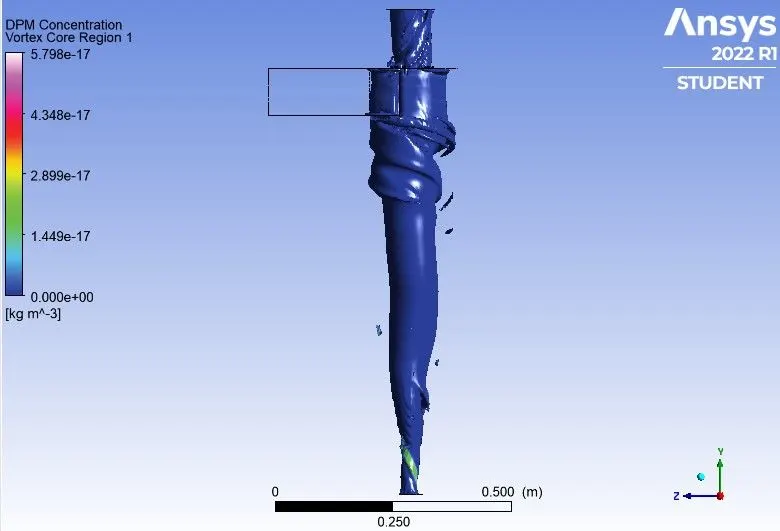
Basic Vortex Region
Particle History
Particle Animation
https://youtu.be/IfYEJaLT__o
[3] For particular Dia. = `3mum`
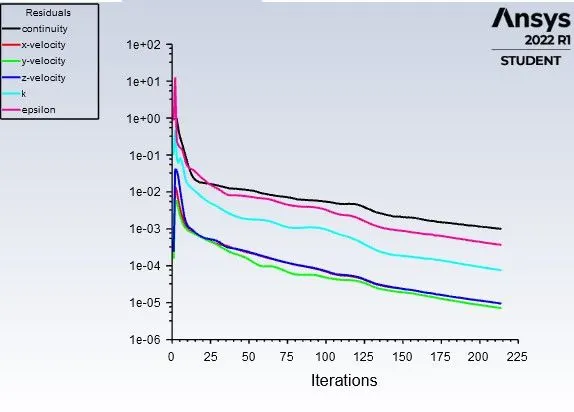
Residuals
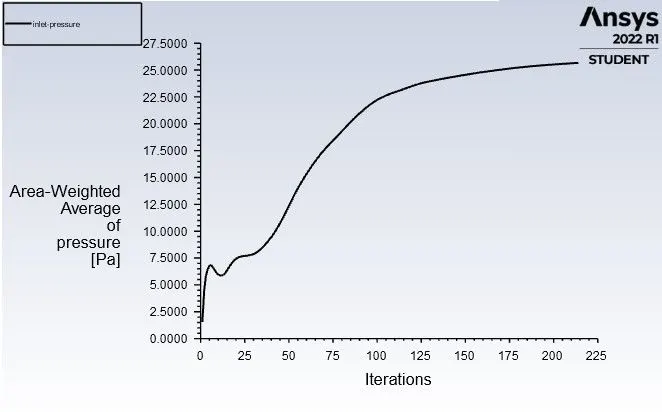
Pressure at inlet
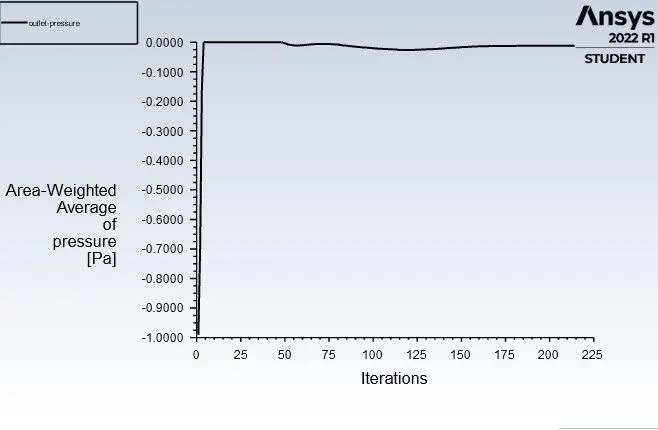
Pressure at outlet_2
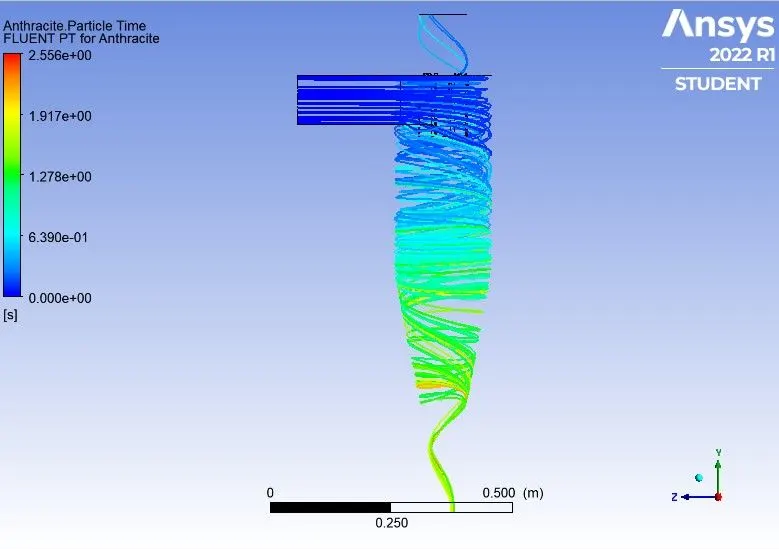
Particle Time
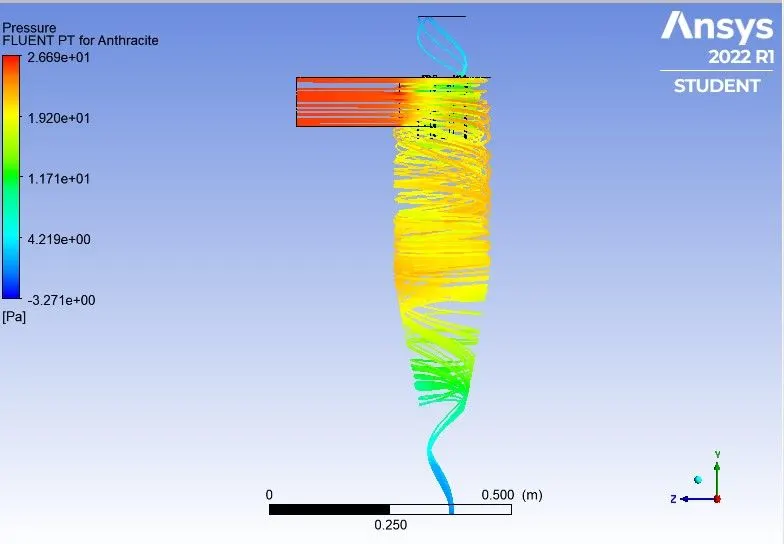
Pressure
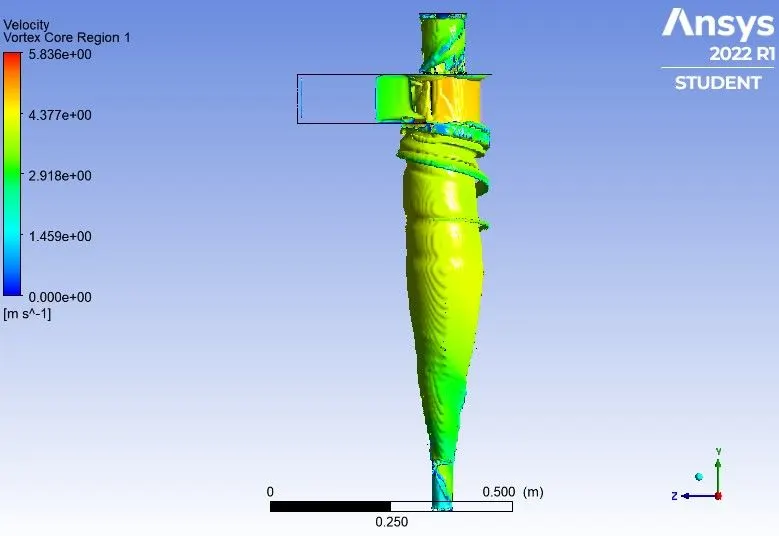
Velocity
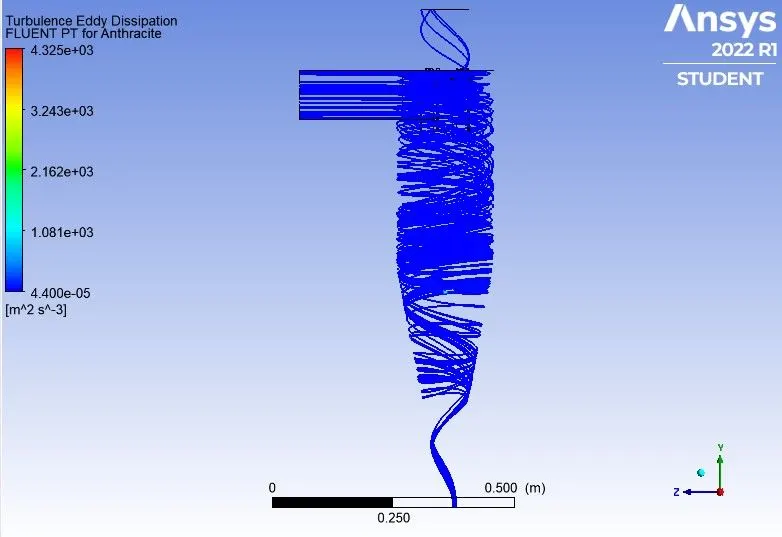
Turbulence Eddy Dissipation
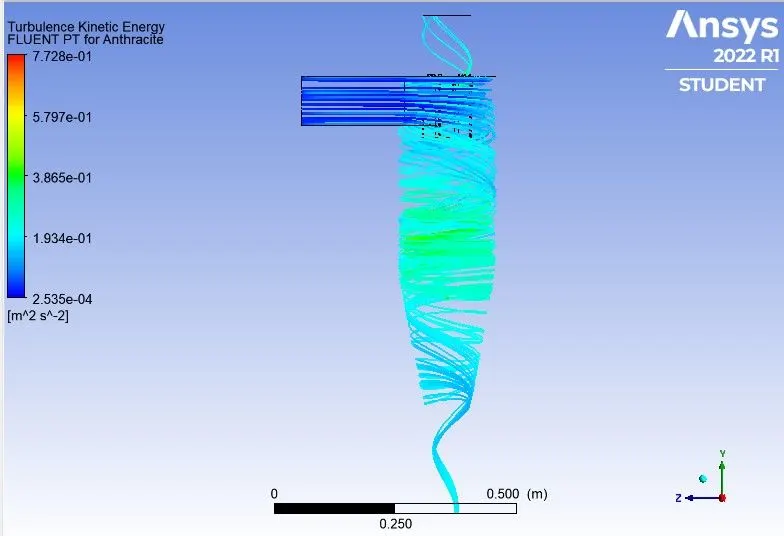
Turbulence Kinetic Energy
Basic Vortex Region
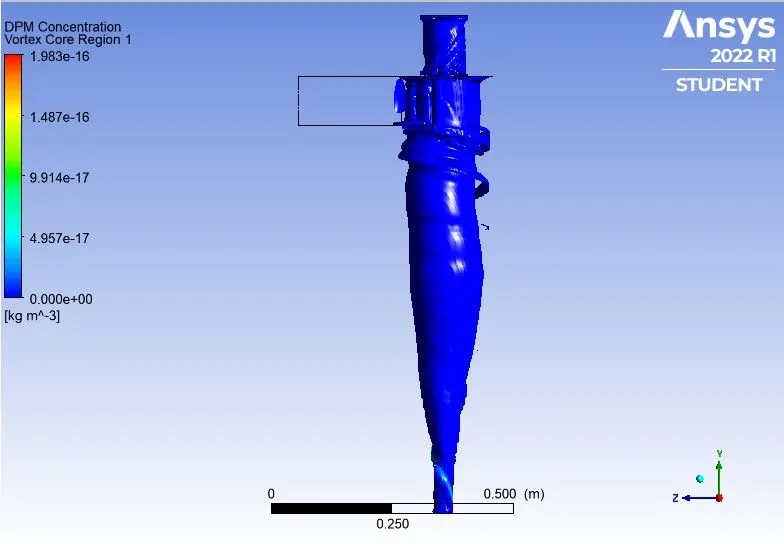
Particle Time
Particle Animation
[4] For particular Dia. = `4mum`
Residuals
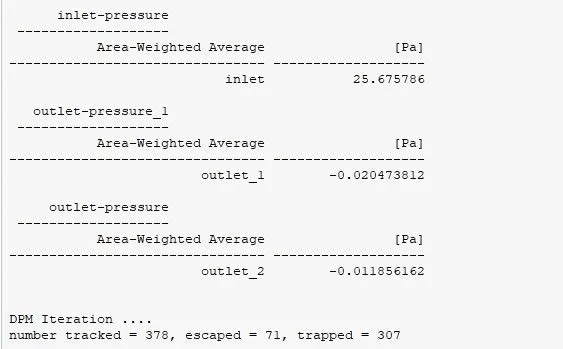
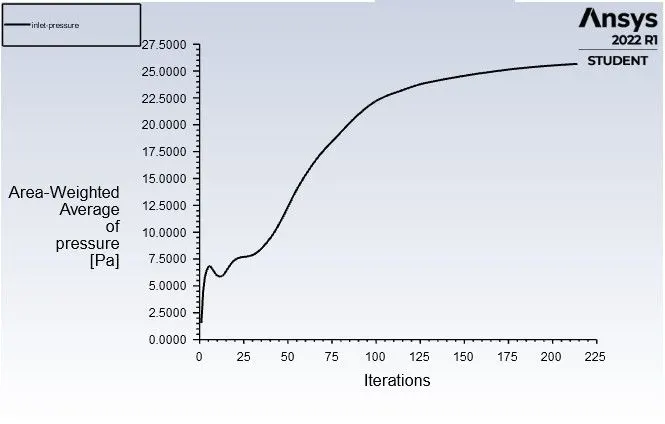
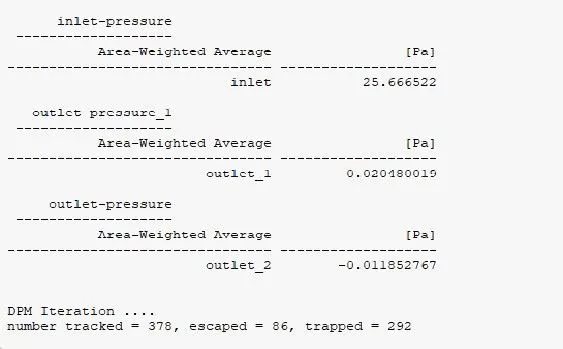
Pressure at Inlet
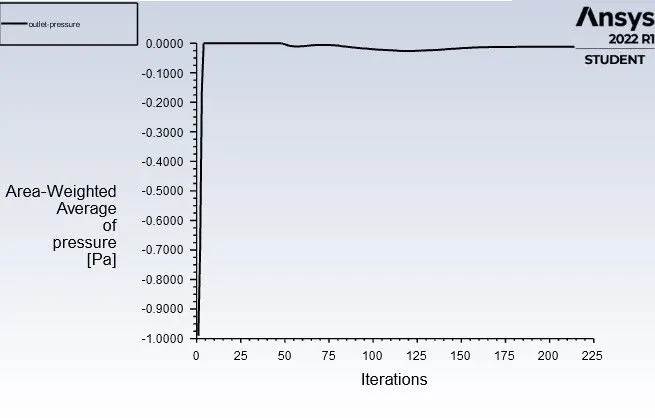
Pressure at Outlet
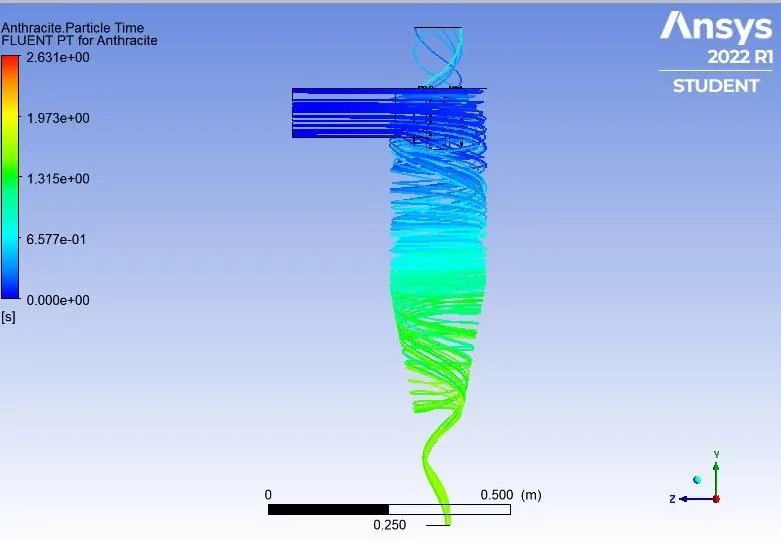
Particle Time
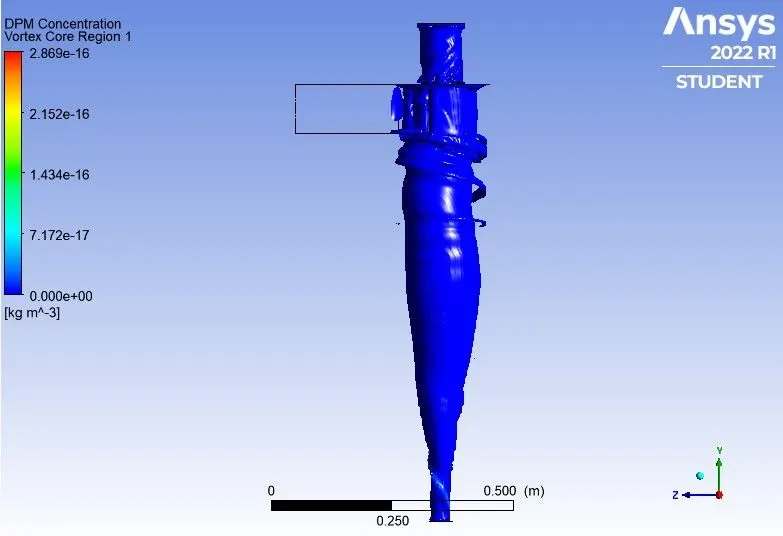
Basic Vortex Region
Particle Time
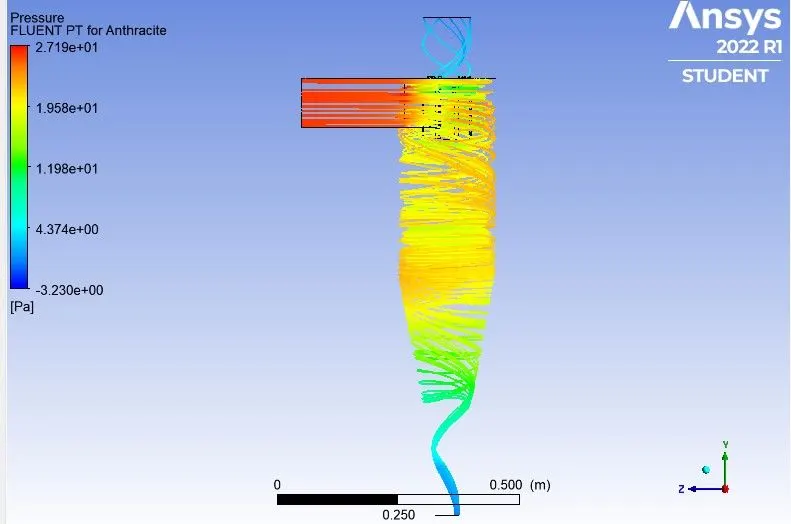
Pressure
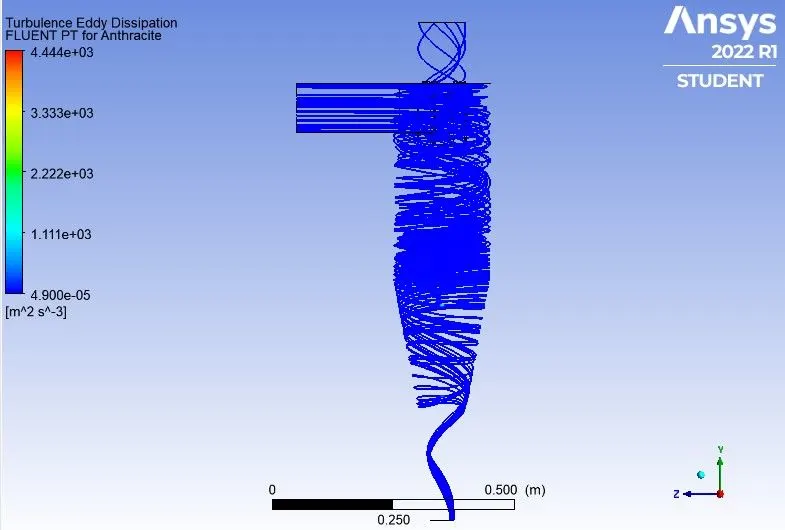
Turbulence Eddy Dissipation
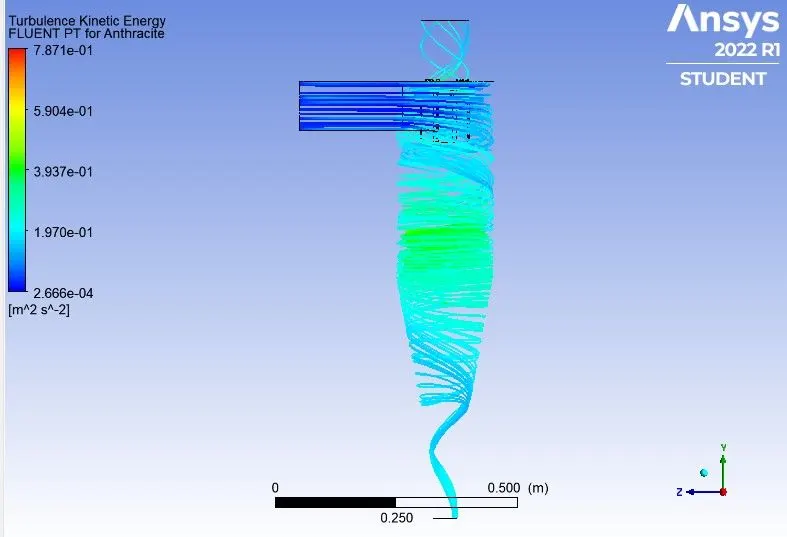
Turbulence Kinetic Energy
Particle Animation
[5] For particular Dia. = `5mum`
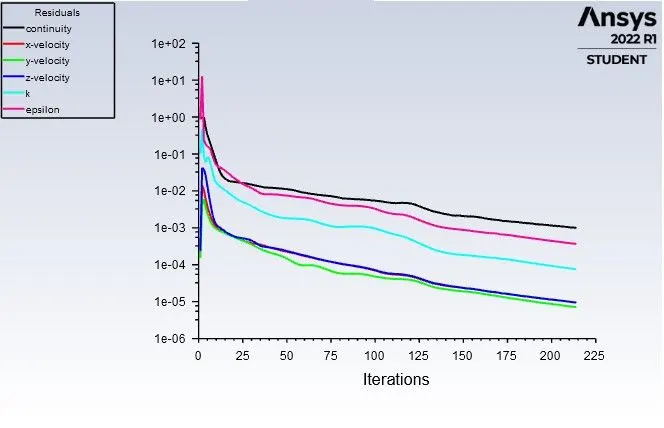
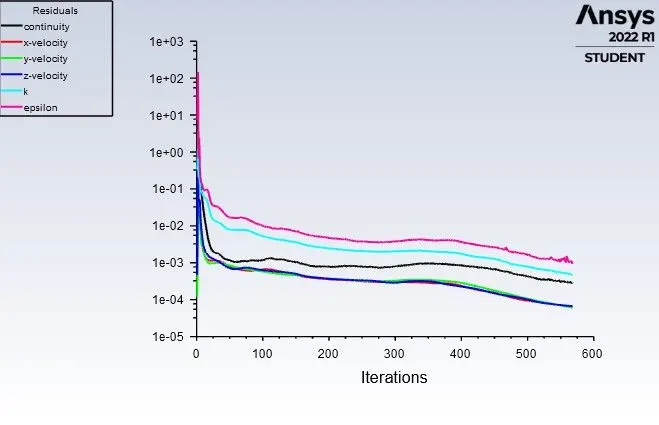
Residuals
Pressure at inlet
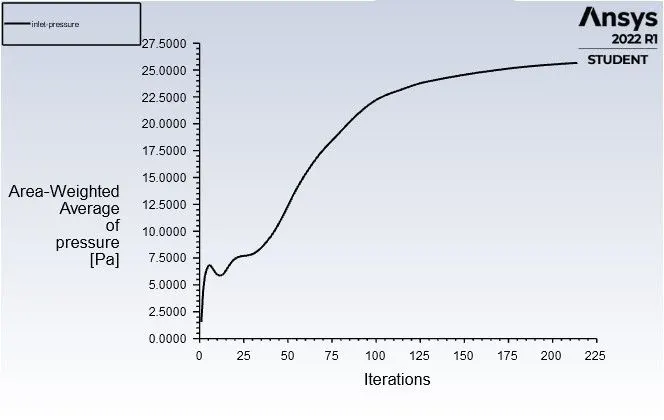
Pressure at outlet_2
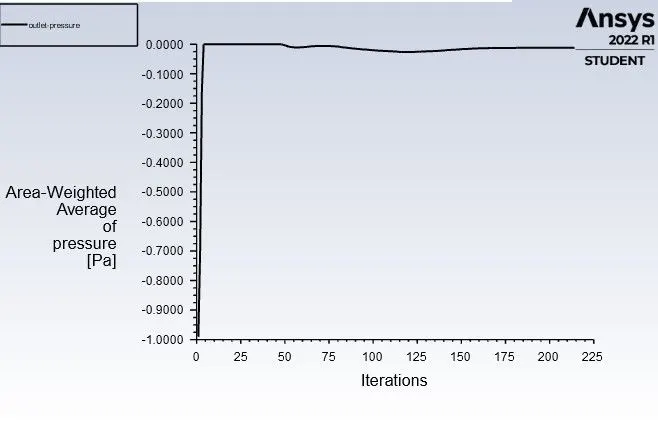
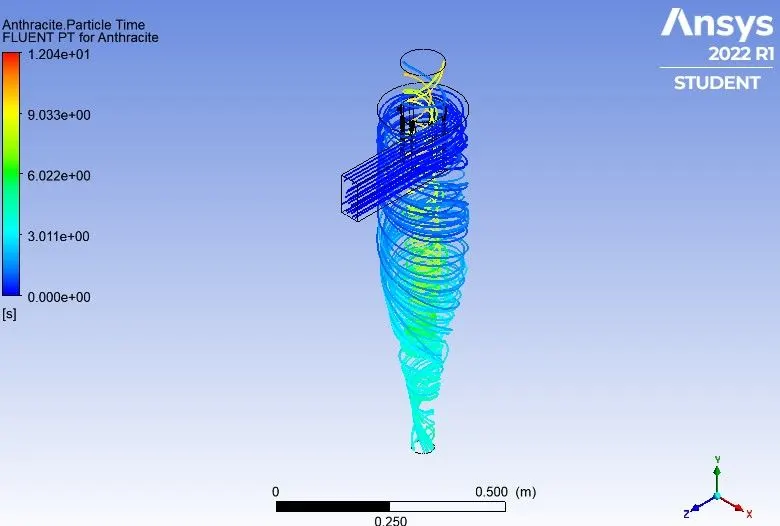
Particle Time
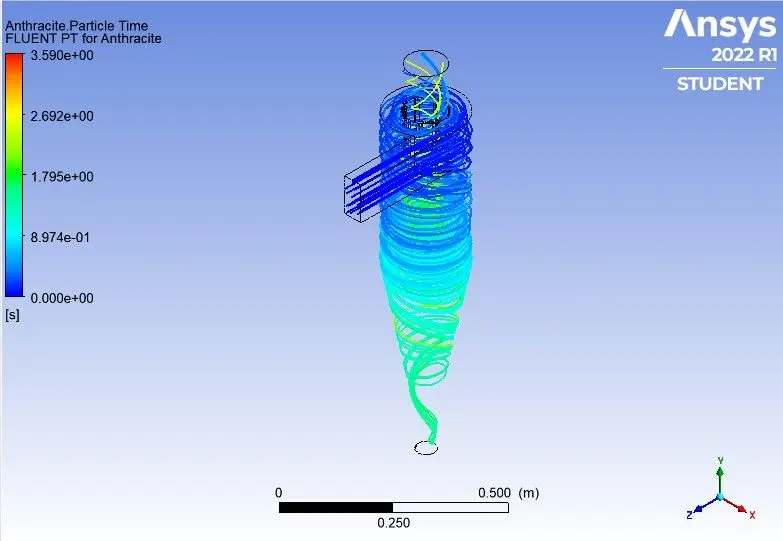
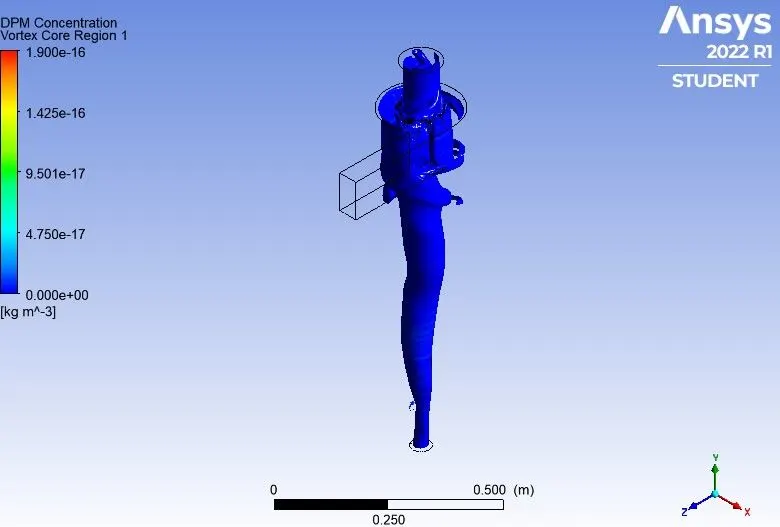
Basic Vortex Region
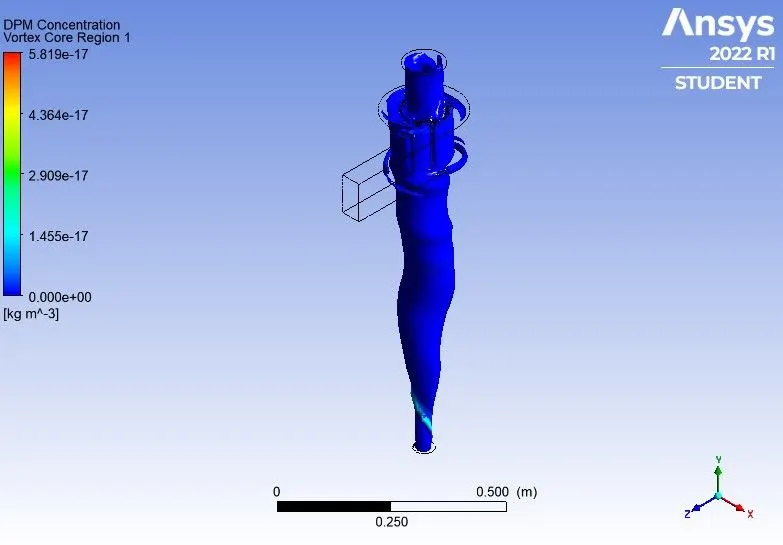
Particle Time
Particle Animation
Separation Efficiency = (Particles Trapped/Particles Tracked) *100
AND
Pressure Drop = [ P(inlet ) - {P(outlet_1) + P(outlet_2)}]
| Particle Diameter | Trapped | Tracked | Efficiency | Pressure Drop(Pa) |
| 1μm
|
334 | 378 | 88.35% | 18.3830 |
| 2μm | 334 | 378 | 88.35% | 18.3830 |
| 3μm | 307 | 378 | 81.21% | 25.7023 |
| 4μm | 292 | 378 | 77.24% | 25.6578 |
| 5μm | 252 | 378 | 66.66% | 25.6923 |
CASE II - Simulation on Velocity from 1 m/s to 5m/s and keep the particle diameter as `5mum` and calculate the separation efficiency for each case.
Mesh Input :
1. Element size = 3.5mm
2. Total Element = 473540
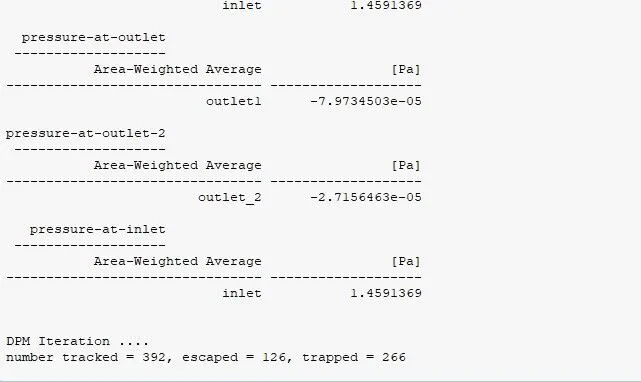
[A]. For Velocity - 1m/s
Outputs -
Residuals
Particular Time
Basic Vortex Region
Particle History
Particle Animation
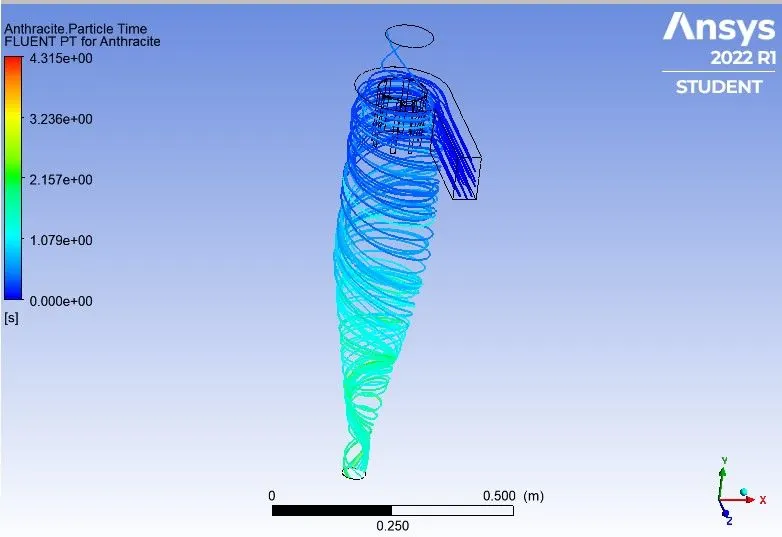
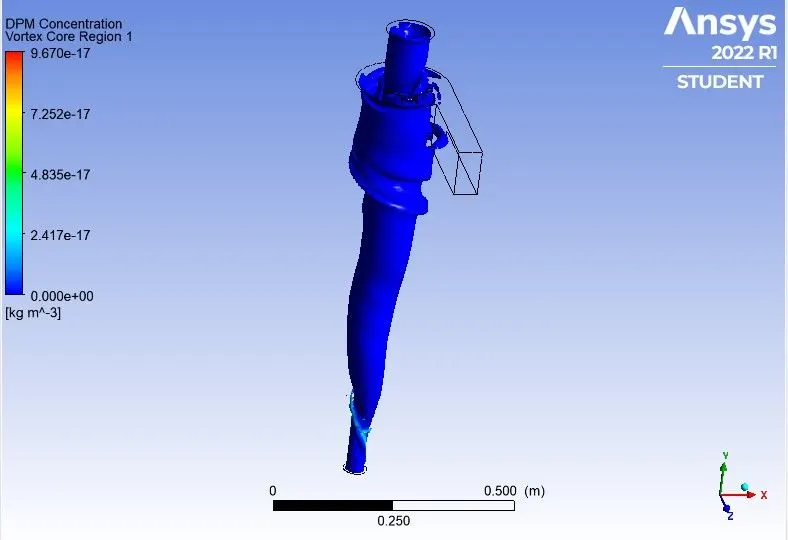
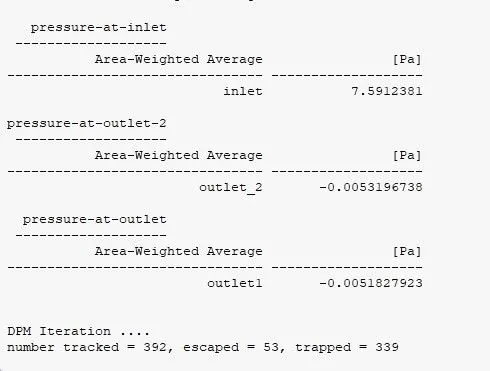
[B]. For Velocity - 2m/s
Residuals
Particle Time
Basic Vortex region
Particle History
Particle Animation
[C]. For Velocity - 3m/s
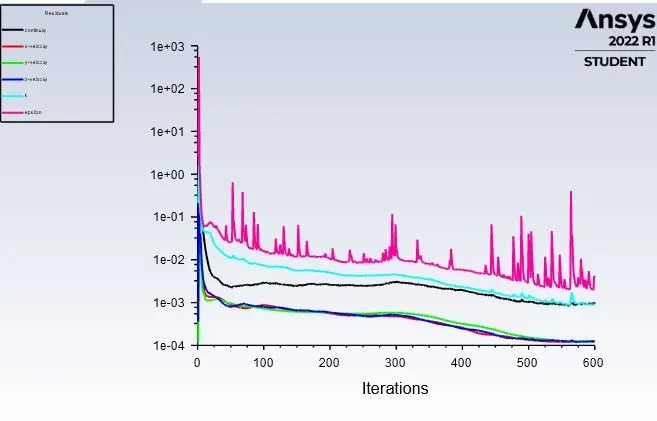
Residuals
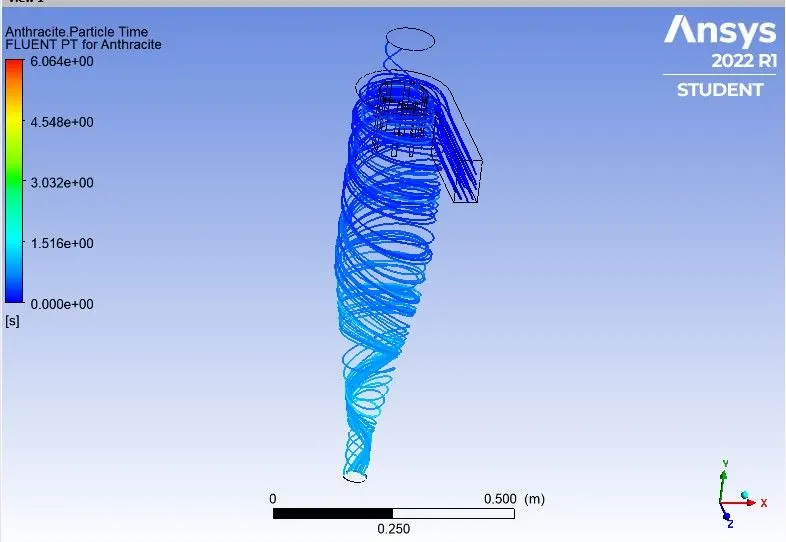
Particle Time
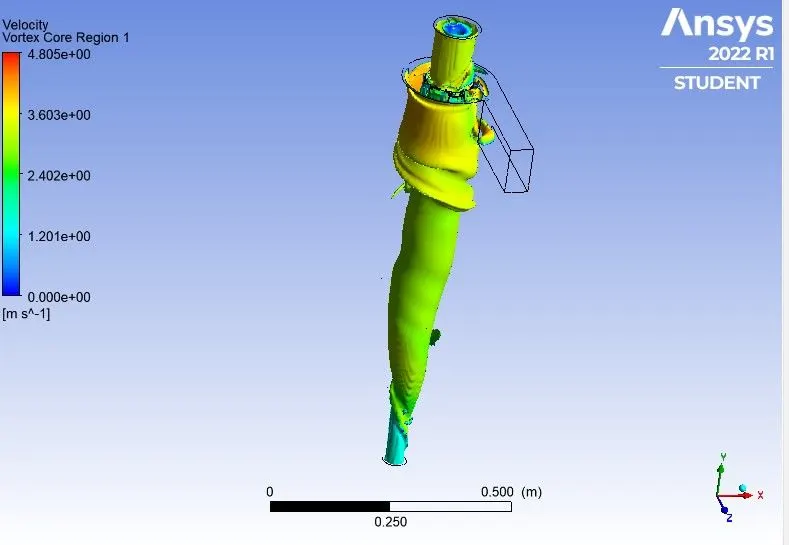
Velocity Vortex Region
Particle History
Particle Animation
[D]. For Velocity - 4m/s
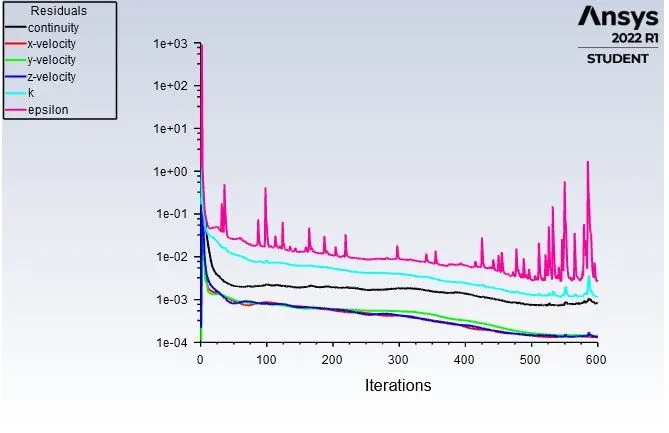
Residuals
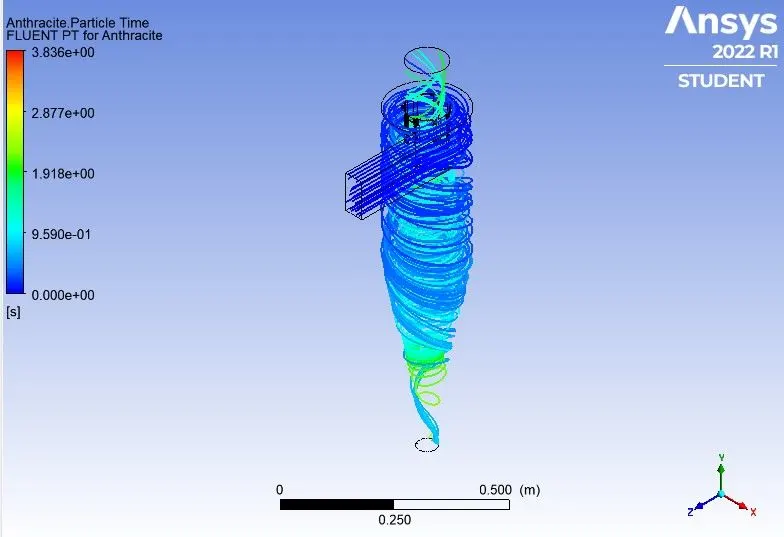
Particle Time
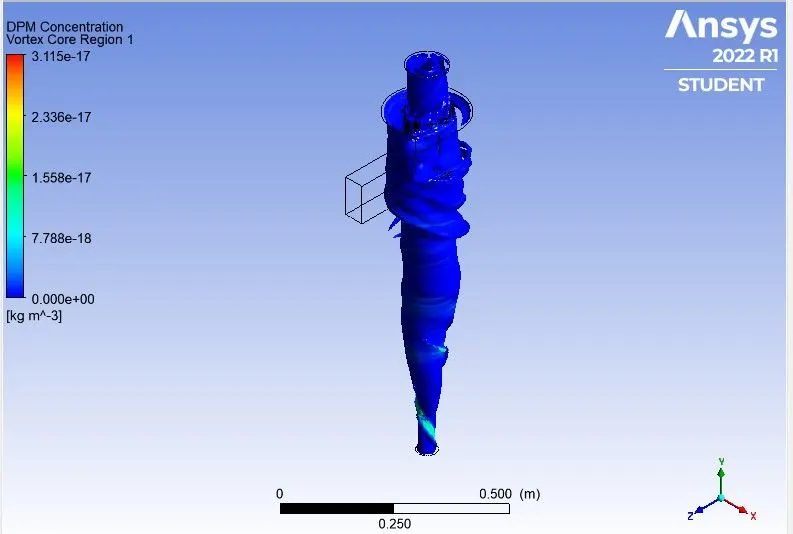
Basic Vortex Region
Particle History
Particle Animation
[E]. For Velocity - 5m/s
Residuals
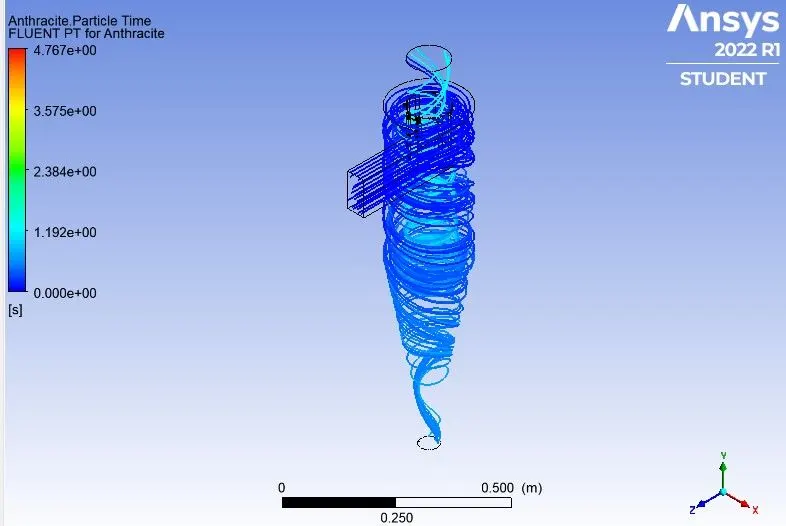
Particle Time
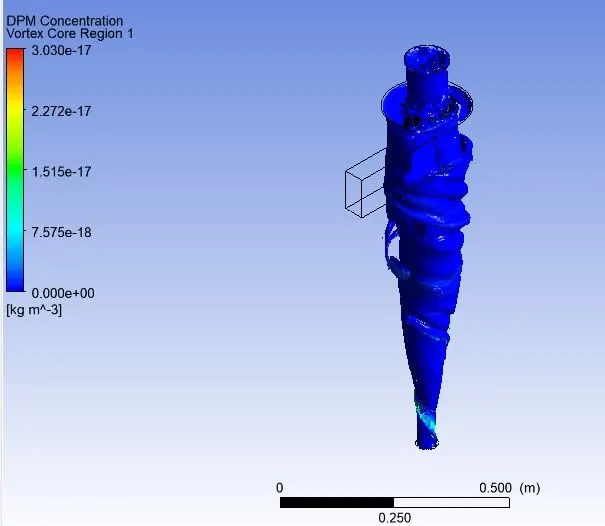
Basic vortex region
Particle History
Particle Animation
https://youtu.be/_CpL5TNH5Y0
Separation Efficiency = (Particles Trapped/Particles Tracked) *100
AND
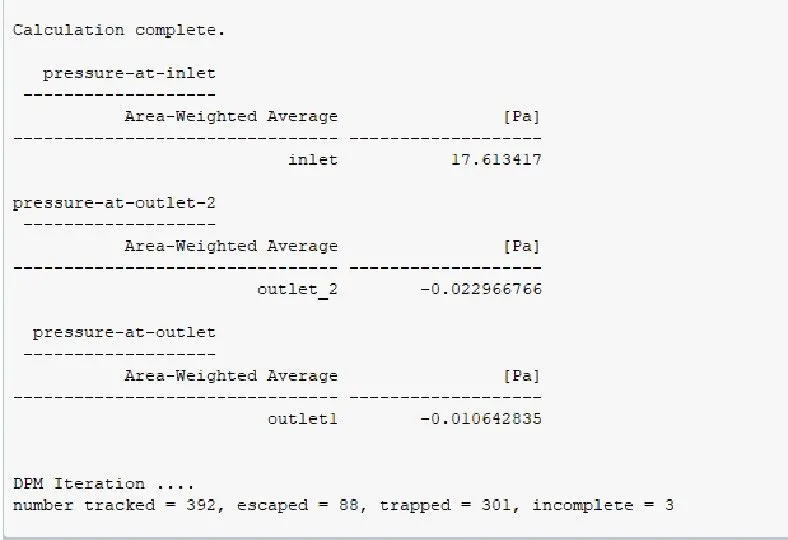
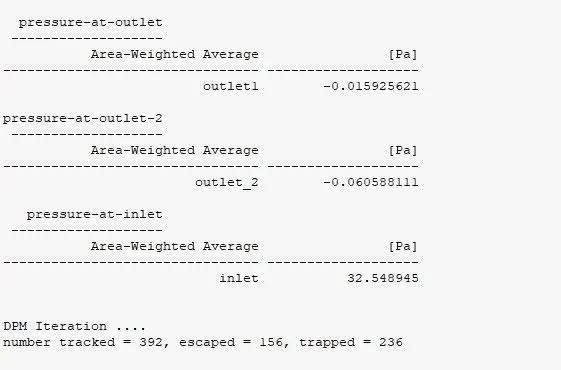
Pressure Drop = [ P(inlet ) - {P(outlet_1) + P(outlet_2)}]
| Particle Velocity | Trapped | Tracked | Efficiency | Pressure Drop(Pa) |
| 1m/s | 266 | 392 | 67.85% | 1.45924 |
| 2m/s | 339 | 392 | 86.47% | 7.60169 |
| 3m/s | 301 | 392 | 76.78% | 17.647 |
| 4m/s | 236 | 392 | 60.20% | 32.62541 |
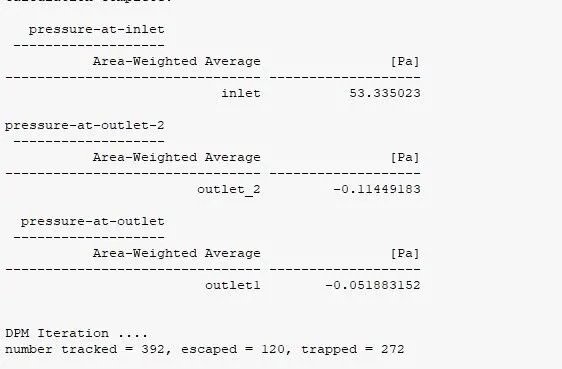
| 5m/s | 272 | 392 | 69.38% | 53.50137 |
- ##OBSERVATION :- Finer mesh gives more no. of tracked particles, so finer mesh more will be the accuracy of simulation as it tracks more particles.
- It can be seen that in CASE I as the particle diameter increases , no. of trapped particles increases too and so does the seperation efficiency.
- Also there is no difference in pressure drop in all sub cases of I as the velocity is same for all sub cases.
- It can also be seen that, in CASE II as the velocity increases, so does the pressure drop also increases.
- More no. of tracking steps results in more accurate and stable results, ultimately resulting in less no. of incomplete particles in critical cases.
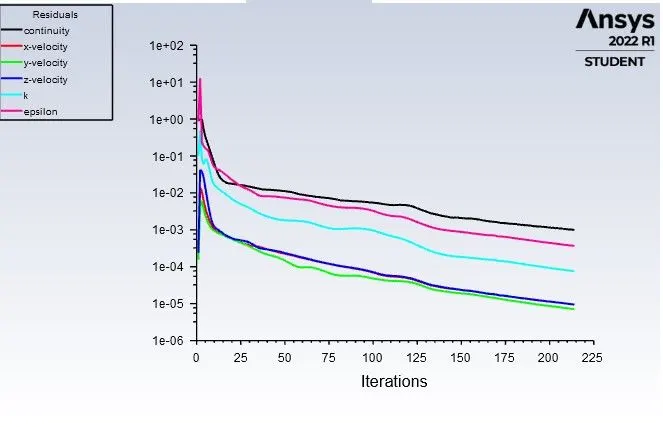
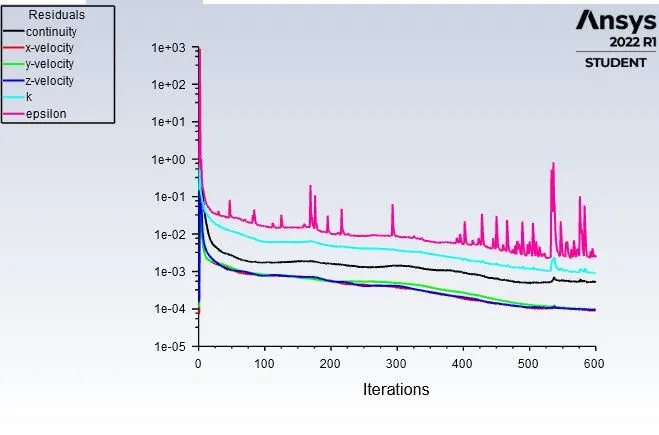
- Also the flow seems to be converged as the residual repeats the same pattern after considerable amount of iterations.