Week 8:- 3D Finishing - Challenges 1
1. What do you understand by the 3D finish process?
3D finish process means to finish the design is being completely and make it ready for final simulation & 2D detailing.
The following are the basic rules to be followed in 3d finishing:
- The nominality of holes is to be checked which ensures the easy assembly of all the units.
- The hole concentricity & holes sizes should be checked which ensures the easy assembly of different parts.
- The gaps between the different units are checked to ensure the proper individual working of different units.
- Fasteners are implemented as per the hole size & the standard color codes as per the customer requirement are applied to differentiate the type of hole wheather its a simple hole, threaded hole or counterbore hole.
- The standard colours used for holes are Violet for Simple Hole, Yellow for Threaded Hole, Cream for Machined area, Cyan for Dowel pin Hole.
- Renaming of the assembly and the parts is to be done to give every part a different identity so everyone can identify in which assembly this part is going to be fit.
- After all the above steps the model is sent for simulation & 2D detailing.
2. What are the points need to be taken care of while finishing the design?
3D finishing is a process where the design is being completely finish and to be ready for the final simulation and 2D detailing. This is basically the finally step and after this the design is freeze.
Following steps are taken care of while finishing the design:
- Hole concentricity and hole size: The parts which are the be fastened together should have concentric clearance holes and threaded holes with corresponding sizes.
- Machining area: The surfaces which are to be machined should be represented with proper coloring.
- Nominality: The coordinates of the units should not be in decimal. All the units should be edited with respect to base in order to get nominal dimension. Pin units are exception for this as the locating hole is input from the company and should not be edited unnecessarily.
- Hole coloring standard: The fastening holes and dowel holes should be given standard colors. Dowel hole is navy blue, clearance hole is aqua and threaded hole is yellow in color.
- Pneumatic lay-outing: Pneumatic channeling should be provided on the base plate for all the connection which would connect pneumatic cylinders and solenoid valve box.
- Gaps checking: There should be proper and minimum gaps between every surface. That is between panel and units, units and units, weld gun and units etc.
- Fastener implementation: Proper fasteners must be installed in the units from the library of the software. Every standard fastener is available in the library.
- Avoiding clash between different parts: In a fixture, every unit and every part must have minimum gap between them and should not clash or hamper the working of the other unit. This applies to the Gun study also. Weld gun position is to be such that the gun does not clash with any of the part. If it clashes, then the position of the gun should be manipulated or the unit should be edited or manipulated.
- Mylar splitting as per panel profile: In case of clamp unit, if we copy a Mylar from one location to other, the Mylar must be split again with the present surface in order to properly cut the Mylar.
- Proper renaming of parts/assemblies as per the standard: The naming of the parts, components and products should be according to the standard so that another designer is able to understand and work on the project.
3. What are rough Locators & what is their use?
A rough locator is a part designed to guide the operator to locate the car panel on to the pins accordingly. A rough locator can be of standard part or make part. They have slot for adjustment and some space so that it starts guiding the panel in advance.
They also help for proper Poka-Yoke. This is a Japanese term which means that the panel can only be placed in one orientation and if other orientations are possible for it, then there is an error.
Uses:
- They are used to guide the panel in correct position and orientation.
- Rough locators are used to help locate work pieces in the automation process. Locating refers to the desired location where we want the work piece to be sitting. when it is getting on either worked on either by a person, team, or a robot.
- Body part rough locators are provided to assist manual part loading to the tool.
- It is used to identify the correct orientation of the panel.
The following are general guidelines for rough locators:
It is not required to finish cold/hot rolled steel for rough locator mounting. Use NAAMS standard rough locators when possible.
If possible, do not place rough locators in positions that force the operator to lift and load, or unload the part over the rough locators.
Rough locators must be designed with slots for ease of adjustment.
Rough locators should have minimal part contact so that the operator can load the part to work location with ease. Excessive part contact may cause difficult part loading and unloading.
Rough locators must never touch the part when it is nested or controlled by the primary tool locators.
If the rough locator requires a unique design, use the design parameters for the standard NAAMS rough locator as a guide.
A rough locators is a part designed to guide the operator, to locate the car panel on to the pins accordingly. A rough locator can be a standard part or make part.
It can be called as fool proofing method also. Because due to the rough locator the part cannot be loaded in incorrect position. The rough locators are set according to the angle of the respective panel hence part can only be loaded in defined orientation.
4. What are the points you need to consider while designing a rough locator?
Following are the points need to be considered while designing the rough locator:
- Rough locators should be placed at the edges of the car panel, which it has to guide.
- Rough locators has to be placed in the same angle of the car part edge with a minimum distance of 2-5 mm from the edge of the car panel.
- Rough locators should guide the panel in pin arresting direction.
- Rough locators should start guiding the panel before 10 to15mm to the start of the pin engagement.
- Rough locators should be designed with entry angle for the car panel. Generally it ranges between 30-45 degree.
- Rough locators should be designed with two slots to mount the easy adjustments.
- The slots should be in the direction of car part guiding.
- Rough locators must be designed with slots for ease of adjustment.
- Rough locators should have minimal part contact so that the operator can load the part to work location with ease. Excessive part contact may cause difficult part loading and unloading.
- Rough locators must never touch the part when it is nested or controlled by the primary tool locators.
5. What is the gun study process?
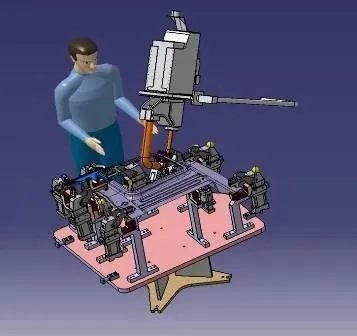
In automotive industry the car panels are predominantly joined by various welding processes. A weld study is performed on the panel to be welded later which includes the required weld spots on the panel. These weld spots are taken into consideration while designing the fixture. Once the design of fixture is completed, the weld gun which we intend to use in actual process is put into the software and the feasibility of the process is checked.
This process of inserting the weld gun in the fixture design to check if the position of any part needs to be modified is called gun study.
- Welding is mostly used in automobile industries and their requirements for fixtures that ease the welding process is a continuous developments task in any industry.
- In weld study process, the major procedure is insert the gun in the tool assembly and place the gun on the weld spots by creating a point on the tip. Adjust the weld the weld gun for not getting any clashes from the 3D concept.
- Once all the weld spots are cleared without any clashes and it will be moved on to next procedure of simulation.
- In simulation, first we have to check with the reach with respect to the weld spots. Because robots are also having some limitions if it exceeds the robot will not work proper with 100 percent. So first we have move with reach check and then try to adjust the weld gun with respect to 3D concept design. If any clashes gets in simulation, we will get cleared with CATIA software.
- Car Body In White (BIW) is a complicated steel structure including 300-500 sheets with complex shape and are assembled by means of welding in a high rhythm through 55-75 robotic work stations.
- The fore most step taken before starting the welding fixture design, we must declare weld spots location for each and every panel. The location and orientation of other critical units of the fixture including clamps, locators., etc are decided based on the weld spot distribution.
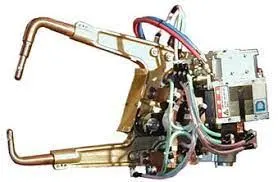
Gun have two different types, they are
- C – Type gun.
- X – Type gun.
C – Type gun:
- In C – type gun one arm side is fixed and another arm is movable in linear direction of perpendicular to other arm (Horizontal direction with respect to other arm).
X – Type gun:
- In X – type gun one arm side is fixed and another arm is movable in angle position like (it moves like an arc).
- It includes the study of the weld matrix & the weld point positions. There are two types in weld point one is Geo weld which ensures the geometry of the assembly & second is Re-spot weld points which adds strength to the welded parts.
- The fixture is designed for the car panel to hold it on the position, so we ensures all the weld spots and weld gun do not across or any clashes with fixture tool.
- If any clashes defined while designing fixture, then we will only move on to redesign the tool. We have no permission to change a weld spot or clamping position without considering clients.
6. What re the points need to consider during the gun study?
Weld gun study is very time consuming process, the entire welding cycle time study depends on the number of weld spots.
Following are the points need to consider during gun study
- The axis of weld spot along welding direction must be normal to the weld surface.
- The no. of weld spots for the panel and the time required to spot the each weld determine the total time required to complete all the weld spots.
- If we have one or more Device models and we want to program; the behavior of each model in the work cell can be simulated over time. Instructions for each device are coded by giving Sequences. The sequence defines the motion, manipulation and action of the devices. Based on the distance of each tag point from home position, motion type, speed and acceleration – one can obtain cycle time for each device assigned with sequences. This way robot cycle time is precisely calculated.
- After sequencing all the devices, a simulation is run with "collision check" ON and made sure that the welding operation is collision free.
- We have only access to rotate the weld gun on Z axis. Because if we rotate the weld gun on X and Y axis the weld spots quality will reduce and the precision will get lost.
- During gun study we have to consider clients cycle time and we have to maintain the cycle time compared to clients requirements. There are two types of weld spots they are,
geo spot and respot and these two spots are having different timings.
1. Geo spot – 3sec.
2. Respot – 2.5sec.
- If we have one or more device models and we want to program, the behavior of each model in the work cell can be simulated over time. Instruction for each device are coded by giving sequence.
- If we have no issue with weld gun and we have to move on to next procedure to run the paths (path ways) to analyse there is any clash while weld gun reach a weld spots and then if we done with that and finally move to Sequence of operation.
- After sequencing all the device and paths, and finally simulation is run with collision check on and make sure all the weld spots and paths are clear from collision which using safe robots.
7. What is pneumatic routing?
Pneumatic systems should be efficient and leak free. Sometimes, they are not, because of improper tube line routing which resulted due to either lack of knowledge, or corners cut on planning time, or both.
Planning tube line routing is a time investment, but it can have a big ROI, especially for complex systems. During system design, routing should be developed as the next step after sizing the tube lines and selecting the appropriate fittings.
There are some guidelines provided for routing as shown below
- Leave fitting joints as accessible as possible. Inaccessible joints are difficult and time-consuming to assemble, tighten and service.
- Use software tools to make labor-intensive calculations such as pressure drop.
- Employ U-bends to allow for line contraction and expansion.
- Include offset bends to allow for motion under load, regardless of how ‘rigid’ the system seems.
- Favor bends rather than straight tube lines, because a straight line tube assembly with no bends, like the example of the test stand mentioned above, can cause joint stain, which may lead to leaking.
- Make sure routing design allows room for assembly of any connections required.
- Minimize pressure drop by getting around obstructions with as few 90° bends as possible. One 90° bend has more pressure loss than two 45° bends.
- Route lines around rather than over areas that require regular access or maintenance.
- Design routing with clamping in mind. Appropriate design leads logically to proper clamping. Often, it’s possible to clamp several lines together.
- Keep troubleshooting and maintenance in mind: focus on logical design and avoid crossed lines.
- Design the tube line routing to reduce likelihood of users standing or climbing on plumbing
8. What is the solenoid valve?
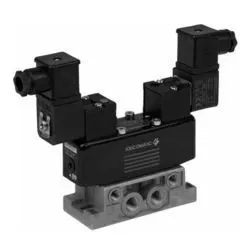
A solenoid valve is an electromechanical valve. Solenoid valves differ in the characteristics of the electric current they use, the strength of the magnetic field they generate, the mechanism they use to regulate the fluid, and the type and characteristics of fluid they control. The mechanism varies from linear action, plunger-type actuators to pivoted-armature actuators and rocker actuators. The valve can use a two-port design to regulate a flow or use a three or more port design to switch flows between ports. Multiple solenoid valves can be placed together on a manifold. Solenoid valves are the most frequently used control elements in fluidics Their tasks are to shut off, release, dose, distribute or mix fluids. They are found in many application areas. Solenoids offer fast and safe switching, high reliability, long service life, good medium compatibility of the materials used, low control power and compact design.
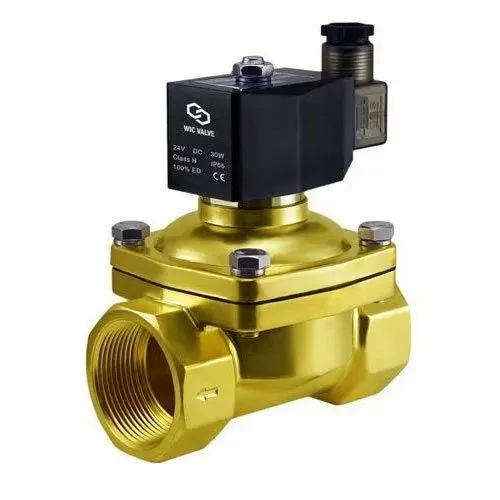
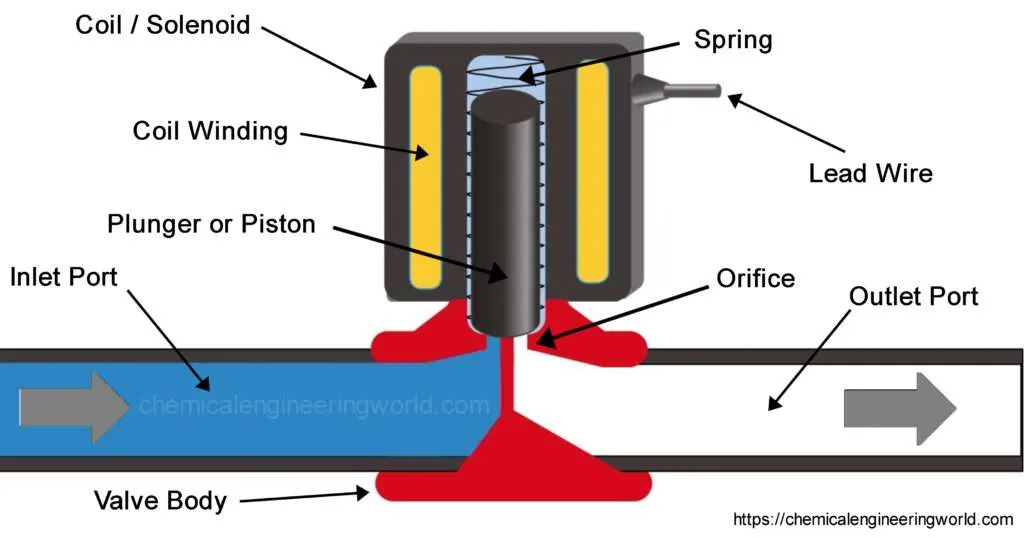
1) Valve body: This is the body of the valve to which the solenoid valve is connected. The valve is usually connected in the process flow pipeline to control the flow of certain fluid like liquid or air. Ordinarily the flow from the valve is controlled by the handle, but in case of the automatic valve the solenoid valve is connected to the valve.
2) Inlet port of the valve: This is the port through which the fluid enters inside the automatic valve and from here it can enter into the final process.
3) Outlet port: The fluid that is allowed to pass through the automatic valve leaves the valve through the outlet port. The solenoid valve controls the flow of the fluid from inlet port to the outlet port. The outlet port is eventually connected to the process where the fluid is required.
4) Coil/ Solenoid: This is body of the solenoid coil. The body of the solenoid coil is cylindrical in shape, and it is hollow from inside. The body is covered with steel covering and it has metallic finish. Inside the solenoid valve there is solenoid coil.
5) Coil windings: The solenoid consists of several turns of the enameled wire wound around the ferromagnetic material like steel or iron. The coil forms the shape of the hollow cylinder. Externally this coil is covered with the steel covering and inside the hollow part there is a plunger or the piston, whose motion inside the hollow space is controlled by the spring.
6) Lead wires: These are external connections of the solenoid valve that are connected to the electrical supply. The current is supplied to the solenoid valve from these wires. When the solenoid valve is energized, the current flows through these wires to the solenoid valve and when the solenoid valve is de-energized the flow of current stops.
7) Plunger or piston: This is the solid round metallic part cylindrical in shape and placed in the hollow portion the solenoid valve. When the electrical current is passed through the solenoid valve, the magnetic field is generated inside the hollow space. Due to this the plunger tends to move vertically in the hollow space. When the electrical current is stopped to the solenoid valve, the magnetic field is stopped and the plunger is remains the existing place due to the force of the spring.
9) Orifice: The orifice is an important part of the valve though which the fluid is flowing. It is the connection between the inlet and the outlet port. The flow of fluid from the inlet port to the outlet port takes place from this port. In the ordinary valves, this port is covered with the valve disc at the bottom of the stem of the valve to which the handle is connected. Thus in ordinary valves, the opening of the orifice are controlled by the handle, but in case of the solenoid valves, the opening of the orifice is controlled by the plunger. The movement of the plunger is in turn controlled by the spring and the current flowing through the solenoid valve.
Basic working of solenoid valve:
Initially the sensor senses the process towards the outlet side of the solenoid valve. When it senses that certain quantity of the flow of the fluid is required, it allows the current to pass through the solenoid valve. Due to this the valve gets energized and the magnetic field is generated which triggers the movement of the plunger against the action of the spring. Due to this the plunger moves in upwards direction, which allows the opening of the orifice. At this instant the flow of the fluid is allowed from the inlet port to the outlet port.
If the current passing through the solenoid valve is constant, the position of the plunger and hence opening of the orifice remains constant. If the sensor senses that more flow of the fluid is required, it allows the increase in current passing through the solenoid valve, which creates more magnetic field and more upwards motion of the plunger. This leads to further opening of the orifice and more flow of the fluid from the inlet port to the outlet. If the required flow of fluid is less, the sensor allows passage of the lesser current to the solenoid valve.
When the sensor senses that the fluid is no more required in the process, it stops the flow of the current to the solenoid valve completely. Due to this the solenoid valve gets de-energized and the plunger reaches the bottom most position and closes the orifice completely thus stopping the flow of fluid from the inlet port to the outlet port.
In this way the solenoid coil operates the valve as if it is being operated by the human being. When the flow of certain quantity of fluid is required it opens the valve to required extent and when the flow is not required it shuts the valve entirely.
9. What is the valve bank?
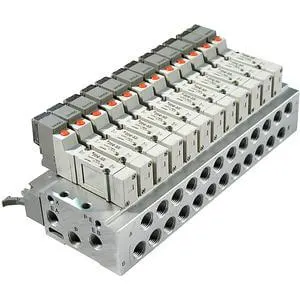
Valve bank is the arrangement of no. of solenoid valves. Valve bank will have common inlet port, a single servo line to each of the pneumatic valves and independent vent passages for each solenoid. On the solenoid bank, each of the solenoid valves separately controls the feed of high pressure servo air to a single pneumatic valve. The valve is actuated by selectively energizing the corresponding solenoid to allow servo air to the servo port of the valve. To return the valve to its fail safe position, the solenoid is de-energized to vent the servo port of the valve to ambient.
The solenoids are two stage pilot valves and are normally open with the solenoid de-energized, allowing high pressure supply air to the servo ports of the downstream pneumatic valves. Energizing the solenoid blocks high pressure air supply and simultaneously vents the pneumatic valve servo chamber to atmosphere, closing the respective pneumatic valve.The two stage solenoid are designed to provide fast response times. The electrical configuration is a dual-coil reductant design providing an isolated circuit topology housed in a single packaged. Each coil is independent and identical in function.
Common features of valve bank.
- These are designed for high vibration levels.
- It uses aluminium alloy manifolds for light weight.
- These are designed for high temperature environments.
- Design architecture allows easy selection of two to six solenoid valves.
10. What is sensor & brief about its application in automation?
Sensor is a device which detects or measures a physical property and records, indicates, or otherwise responds to it. A unit designed to sense car panel using electrical sensors is called sensor unit. The from the sensors is send to the PLC so the next process is executed by this signal. The sensor is very sensitive & easily damagable part so sensor cover is provided to the sensor for safety purpose.
Sensors in Automation:
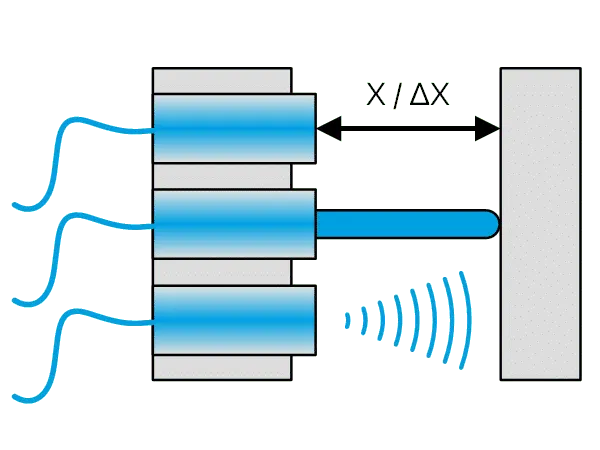
In the industrial automation section, sensors play a very important role to make the products intelligent and highly automatic. These allow one to detect, analyze, measure and process various changes like change in position, length, height, appearance and displacement that occurs in the production sites. These sensors also play an important role in predicting and preventing many future events, thus, catering to the needs of many sensing applications.
The following are the various types of sensors used in industrial automation: Proximity sensors, Vision sensors, Ultrasonic sensors, Position sensors, Photoelectric sensors, Temperature sensors, Inclination sensors, etc. The applications for position sensors as a whole are broad. They can be used in anything from motion control of a robot, tank-level sensing or even in semiconductor process equipment.
For example displacement sensor is used in the precision positioning of objects at the nanometer level and in the measurement of precision thickness of disk drives, assembly line testing and machine tool metrology. It is widely used in machining.
11. What are the types of the sensor?
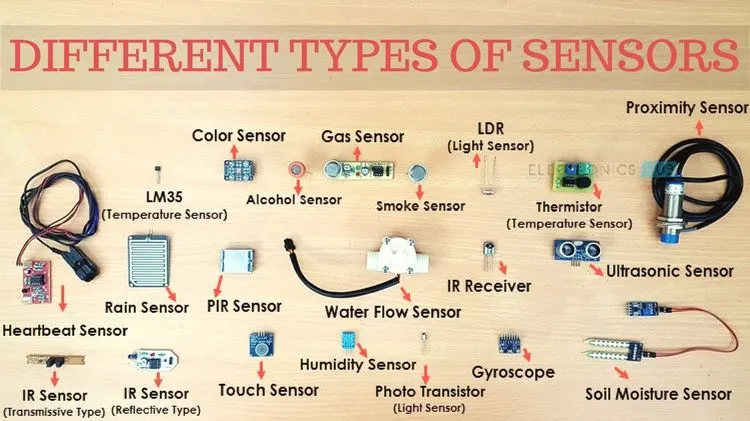
The following is a list of different types of sensors that are commonly used in various applications. All these sensors are used for measuring one of the physical properties like Temperature, Resistance, Capacitance, Conduction, Heat Transfer etc.
- Temperature Sensor
- Proximity Sensor
- Accelerometer
- IR Sensor (Infrared Sensor)
- Pressure Sensor
- Light Sensor
- Ultrasonic Sensor
- Smoke, Gas and Alcohol Sensor
- Touch Sensor
- Color Sensor
- Humidity Sensor
- Tilt Sensor
- Flow and Level Sensor
We will see about few of the above mentioned sensors in brief. More information about the sensors will be added subsequently. A list of projects using the above sensors is given at the end of the page.
Temperature Sensor
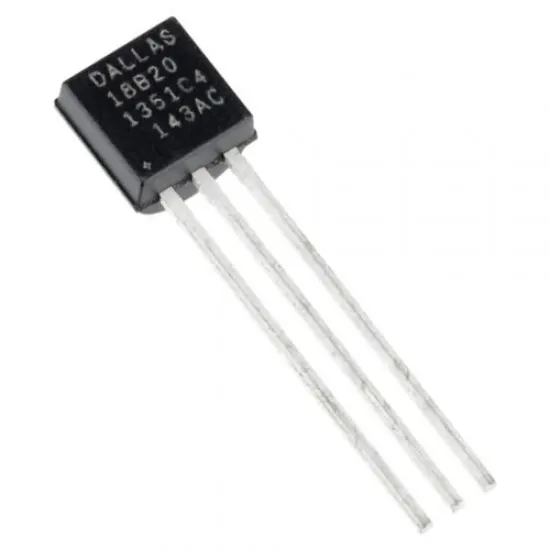
One of the most common and most popular sensor is the Temperature Sensor. A Temperature Sensor, as the name suggests, senses the temperature i.e. it measures the changes in the temperature.
Proximity Sensors
A Proximity Sensor is a non-contact type sensor that detects the presence of an object. Proximity Sensors can be implemented using different techniques like Optical (like Infrared or Laser), Ultrasonic, Hall Effect, Capacitive, etc.
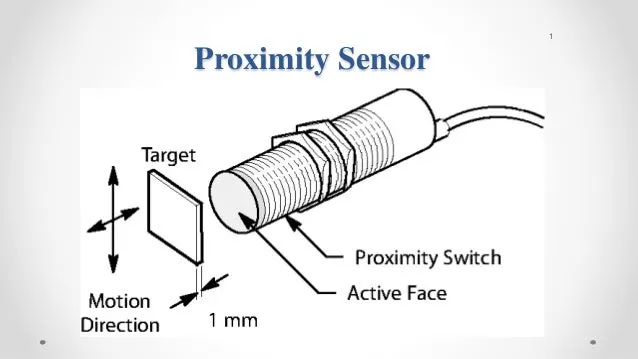
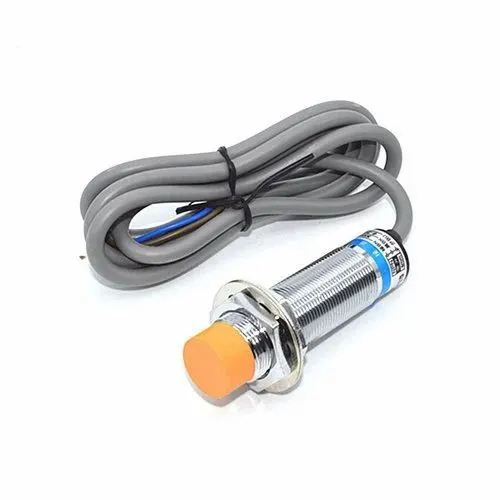
Some of the applications of Proximity Sensors are Mobile Phones, Cars (Parking Sensors), industries (object alignment), Ground Proximity in Aircrafts, etc.
Proximity Sensor in Reverse Parking is implemented in this Project: REVERSE PARKING SENSOR CIRCUIT.
Infrared Sensor (IR Sensor)
IR Sensors or Infrared Sensor are light based sensor that are used in various applications like Proximity and Object Detection. IR Sensors are used as proximity sensors in almost all mobile phones.
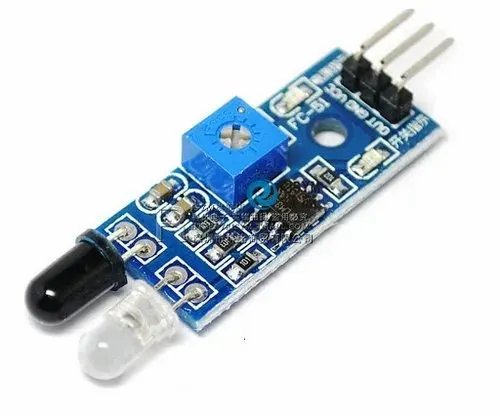
There are two types of Infrared or IR Sensors: Transmissive Type and Reflective Type. In Transmissive Type IR Sensor, the IR Transmitter (usually an IR LED) and the IR Detector (usually a Photo Diode) are positioned facing each other so that when an object passes between them, the sensor detects the object.
The other type of IR Sensor is a Reflective Type IR Sensor. In this, the transmitter and the detector are positioned adjacent to each other facing the object. When an object comes in front of the sensor, the sensor detects the object.
Different applications where IR Sensor is implemented are Mobile Phones, Robots, Industrial assembly, automobiles etc.
A small project, where IR Sensors are used to turn on street lights: STREET LIGHTS USING IR SENSORS.
Ultrasonic Sensor
An Ultrasonic Sensor is a non-contact type device that can be used to measure distance as well as velocity of an object. An Ultrasonic Sensor works based on the properties of the sound waves with frequency greater than that of the human audible range.
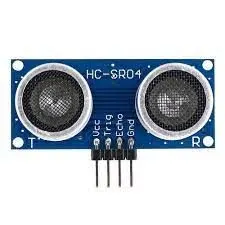
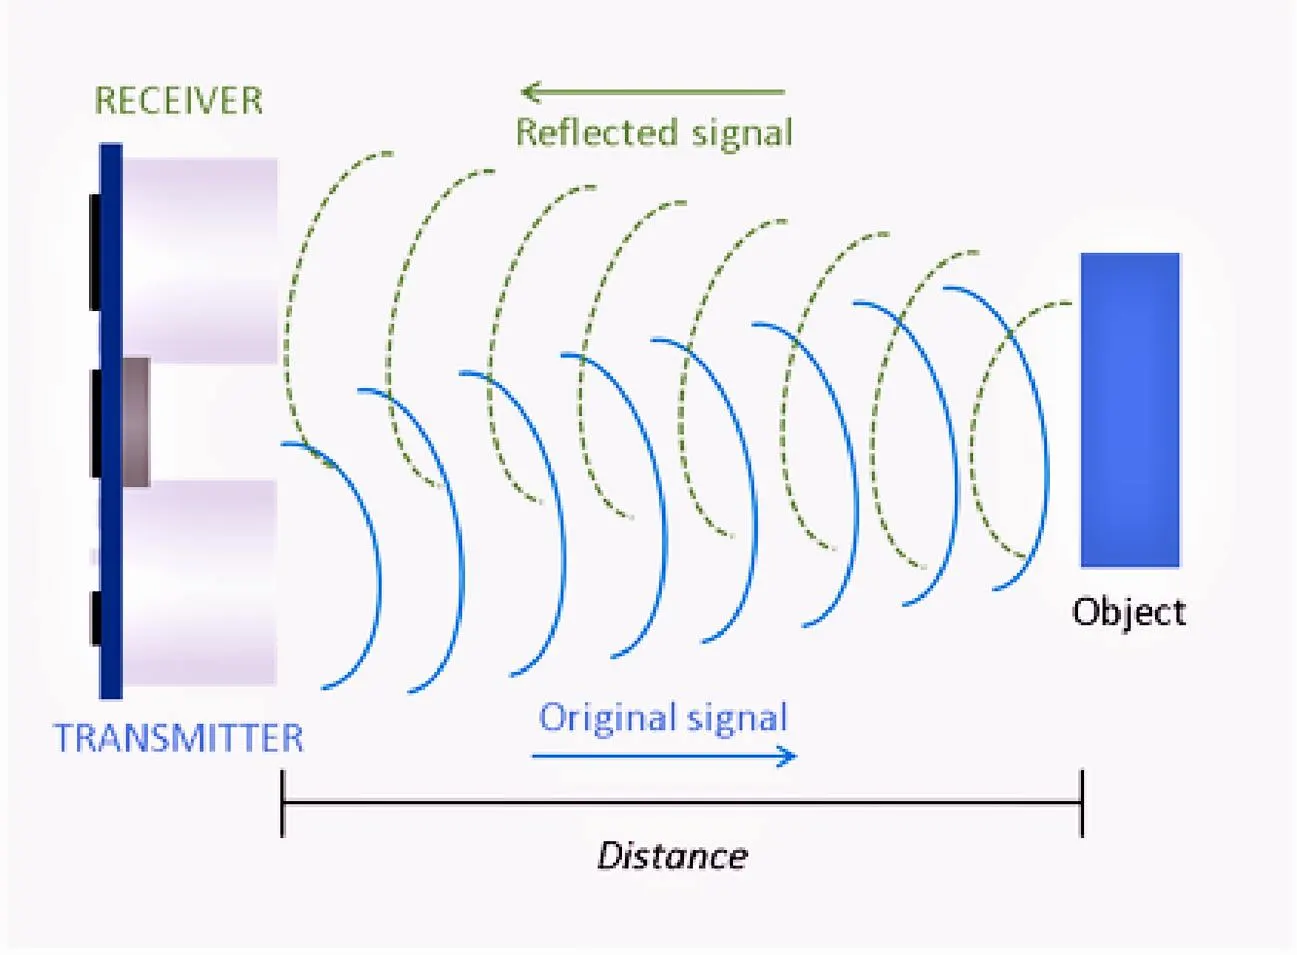
Using the time of flight of the sound wave, an Ultrasonic Sensor can measure the distance of the object (similar to SONAR). The Doppler Shift property of the sound wave is used to measure the velocity of an object.
Arduino based Range Finder is a simple project using Ultrasonic Sensor: portable ultrasonic range meter.
12. What are the fundamental points that need to consider while designing or selection of sensor?
The most common types of sensors used in manufacturing, factory automation, and machine control are proximity sensors, position sensors, inductive sensors, flow sensors, optical sensors, and vision sensors. A signal converter is a critical related technology. Here is my list of the top operating condition requirements:
- Accuracy & Precision.
- Environment
- Signal Conditioning.
- Response speed.
- Sensing range.
- Repetition accuracy.
- Electrical connection.
- Mounting type.
- Temperature range.
- Voltage range.
- Accuracy & Precision –These two terms do not mean the same thing, though they are often related. Accuracy has to do with how close the sensor reading is to the true value while Precision refers to the ability of the sensor to detect small changes. (As an example, a temperature sensor that measures boiling water at 97.53°C has high precision but low accuracy.) Both the accuracy and precision of a given instrumentation system must be appropriate for the requirements of the system. Too high of precision can give a false impression that the reading is also accurate or can result in the system detecting noise rather than the actual desired data. A sensor with more accuracy than necessary will be smore expensive and more difficult to use properly than one more appropriate to the measurement required. Additionally, both accuracy and precision are affected by errors incurred throughout the system. Transducer error, wiring, signal conditioners, and the gauges or converters used to read the value each add their own errors into the system that must be understood in order to select the appropriate sensors.
- Environment –The selection of the proper sensor requires a good understanding of the environment in which the instrument will be operated. Many sensors can be affected by the non-ideal conditions of a production floor (such as temperature variation, vibration, humidity, chemicals, etc.) It is important to take the environment into account when selecting the sensor and its packaging, mounting, and other options.
- Excitation –Many transducers require power to produce an output signal and it is important to provide a power source that will not introduce additional errors.
- Signal Conditioning –Unfortunately, the world is full of non-ideal realities in sensors. Electrical noise is always present, often more so on production floors, and can cause erroneous readings. Signal conditioners and other protection circuits can provide some protection from these effects before conversion. Sometimes these are useful, but other times it is possible or preferred to process the signals after conversion, so the use of conditioners must be evaluated during the instrumentation design process.
- Conversion –In modern systems, it is often preferred that the instrumentation system provides digital data (rather than analog gauges or chart recorders). The analog to digital converters must be evaluated and matched appropriately to the sensors or errors can be introduced, or money wasted by overpaying for precision in one that is not present in the other. Make sure to properly handle ratiometric and non-ratiometric sensors by properly matching with converters that are the same.
- Processing –Even if signal conditioning is performed, the sensor and conversion process is full of various sources of error. Some of these errors are linear (consistent effect across the measurement range), while others are non-linear. There are various methods and algorithms that can be used to compensate for these errors or to extract the best possible signal from the system.
- The data ultimately must be displayed or used by the system and may be stored for later analysis. Whatever is done with the data, remember that a test system can only perform as well as the data that it is provided, so appropriate analysis must be done when selecting and implementing the instrumentation.
- Duo tech Services has extensive experience in using sensors from many different manufacturers for various types of measurement. This experience allows thorough analysis, design, and implementation of instrumentation systems that meet requirements while keeping acquisition and operational costs as low as possible.