Week-7 Challenge: DC Motor Control
AIM:-
`1.A. Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
B. Comment on the armature current shoot-up from the scope results.
C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
2.Explain the working of the same with the relevant results.
3.Explain in a brief about operation of BLDC motor
OBJECTIVE:-
- To run MATLAB demo ‘Speed control of a DC motor using BJT H-bridge’. Modify the model such that armature current doesn’t shoot up when motor changes direction from forward to reverse.
- To understand the Four-Quadrant Chopper DC Drive (DC7) block and compare it with H-bridge model.
- To make a suitable EV model using DC7 block and make result report.
Introduction of DC motor using BJT H-bridge:
The Bipolar Junction Transistor (BJT) when used for power switching applications, operates as an IGBT. When it is conducting (BJT operating in the saturated region), a forward voltage Vf is developed between collector and emitter (in the range of 1 V). Therefore, the IGBT block can be used to model the BJT device.
The IGBT block does not simulate the gate current controlling the BJT or IGBT. The switch is controlled by a Simulink® signal (1/0). The DC motor uses the preset model (5 HP 24V 1750 rpm). It simulates a fan type load (where Load torque is proportional to square of speed).
The armature mean voltage can be varied from 0 to 240 V when the duty cycle (specified in the Pulse Generator block) is varied from 0 to 100%.
The H-bridge consists of four BJT/Diode pairs (BJT simulated by IGBT models). Two transistors are switched simultaneously: Q1 and Q4 or Q2 and Q3. When Q1 and Q4 are fired, a positive voltage is applied to the motor and diodes D2-D3 operate as free-wheeling diodes when Q1 and Q4 are switched off. When Q2 and Q3 are fired, a negative voltage is applied to the motor and diodes D1-D4 operate as free-wheeling diodes when Q2 and Q3 are switched off.
An H-Bridge (Full-Bridge) driver is quite popular in driving loads such as brushed DC motors and it is widely used in robotics and industry. The main advantages of using an H-Bridge driver are: high efficiency, rotation direction change, and braking the motor. In this article/video, I have introduced a complete H-Bridge DC motor driver using four IR3205 power MOSFETs and two IR2104 MOSFET drivers. Theoretically, the above-mentioned MOSFET can handle currents up to 80A, however, in practice we can expect to get currents up to 40A if the MOSFET temp[erature is kept as low as possible, using a big heatsink or even a fan.
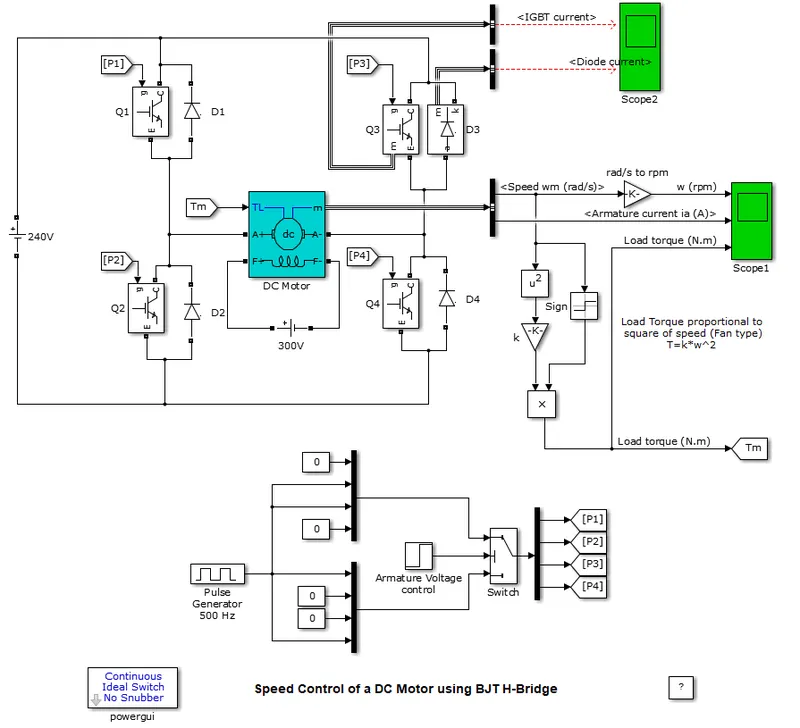
- Initially, we run MATLAB demo ‘Speed control of a DC motor using BJT H-bridge’ with all it’s default values and different pulse width (duty cycle) 75%, 55%, and 45%.
- From this we get following three plot results-
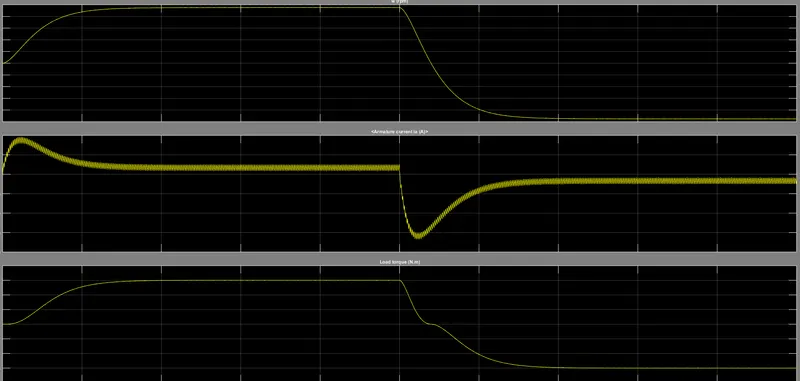
pluse width 75%duty cycle.
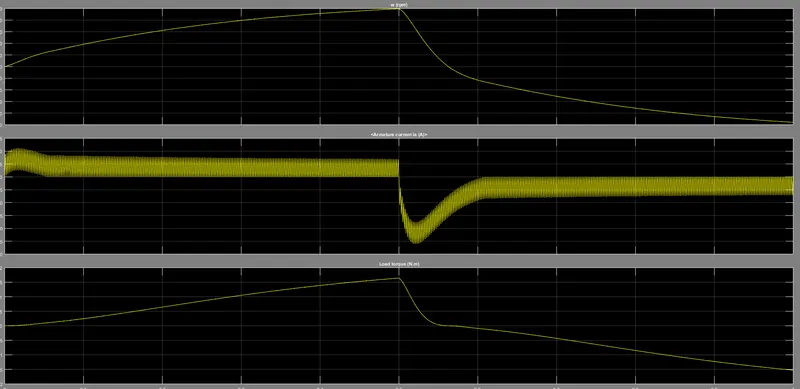
pluses width 55% duty cycle.
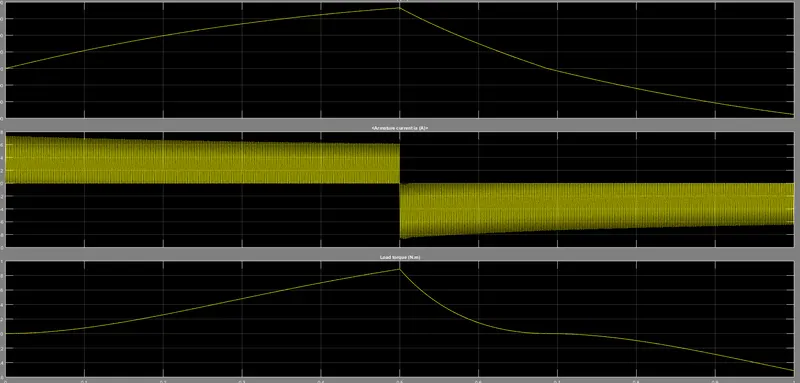
pluses width 45% duty cycle.
Explain The Four-Quadrant Chopper DC Drive (DC7) block’:-
The Four-Quadrant Chopper DC Drive (DC7) block represents a four-quadrant, DC-supplied, chopper (or DC-DC PWM converter) drive for DC motors. This drive features closed-loop speed control with four-quadrant operation. The speed control loop outputs the reference armature current of the machine. Using a PI current controller, the chopper duty cycle corresponding to the commanded armature current is derived. This duty cycle is then compared with a sawtooth carrier signal to obtain the required PWM signals for the chopper.
The main advantage of this drive, compared with other DC drives, is that it can operate in all four quadrants (forward motoring, reverse regeneration, reverse motoring, and forward regeneration). In addition, due to the use of high switching frequency DC-DC converters, a lower armature current ripple (compared with thyristor-based DC drives) is obtained. However, four switching devices are required, which increases the complexity of the drive system.
Comparison:
|
Four-Quadrant Chopper DC Drive |
H-bridge model |
|
To change the motor direction the polarity is changed |
To change the motor direction the current signal has to be interrupted. |
|
It has broader torque and power output ranges |
It uses single pulse generator which gives narrow torque and power output range. |
|
Up to 400v can be achieved. |
Up to 350v can be achieved. |
|
In this the current has chopped values. |
In this the current has continuous values. |
|
Regenerative braking is possible |
Regenerative braking is not possible |
2.explain the working of the same with the relevant results with the help of
https://skill-lync.com/projects/multi-quadrant-operation-of-dc-motor-in-simulink
Discrption Multiquadrant operation:-
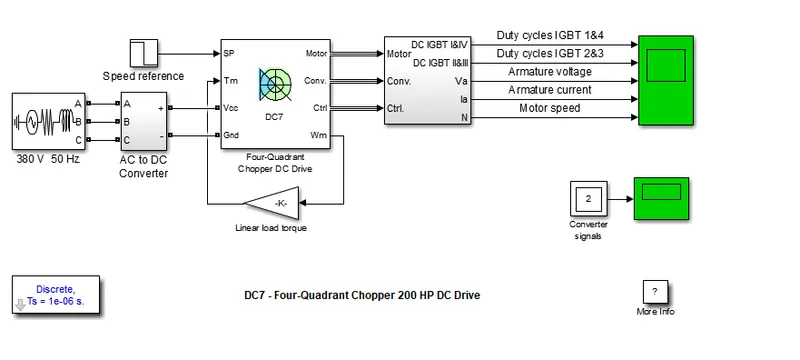
The 200 HP DC motor is separately excited with a constant 150 V DC field voltage source. The armature voltage is provided by an IGBT converter controlled by two PI regulators. The converter is fed by a 515 V DC bus obtained by rectification of a 380 V AC 50 Hz voltage source. In order to limit the DC bus voltage during dynamic braking mode, a braking chopper has been added between the diode rectifier and the DC7 block.
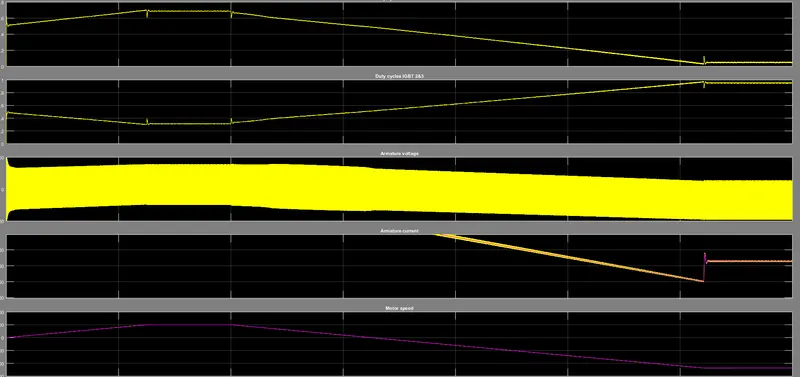
The first regulator is a speed regulator, followed by a current regulator. The speed regulator outputs the armature current reference (in p.u.) used by the current controller in order to obtain the electromagnetic torque needed to reach the desired speed. The speed reference change rate follows acceleration and deceleration ramps in order to avoid sudden reference changes that could cause armature over-current and destabilize the system. The current regulator controls the armature current by computing the appropriate duty ratios of the 5 kHz pulses of the four IGBT devices (Pulse Width Modulation). For proper system behaviour, the instantaneous pulse values of IGBT devices 1 and 4 are opposite to those of IGBT devices 2 and 3. This generates the average armature voltage needed to obtain the desired armature current. In order to limit the amplitude of the current oscillations, a smoothing inductance is placed in series with the armature circuit.
Results:-
3. Explain in a brief about operation of BLDC motor:-
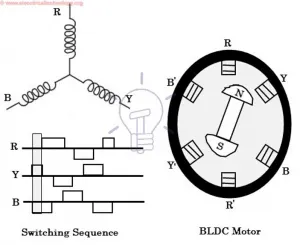
Brushless DC Motors (BLDC motors) are an excellent solution for automated equipment applications where maximum motor life, efficiency, and power density are critical requirements. Since there are no carbon brushes or a copper commutator, the only wear items in the motor are the bearings, making the BLDC motor far superior to its brushed DC motor counterpart when long operating life is required.
We offer a wide range of BLDC motor solutions that are engineered and manufactured to specifically meet or exceed your unique application requirements.
Electrical current is the movement of electrons through a conductor, such as a wire. There are two types of current:
- Alternating current (AC)
- Direct current (DC)
Alternating current means that the electrons periodically change direction. This is caused by an alternator or rotating magnet which alters the direction the electrons travel 60times/second. AC current originates from a generator and is suited for mass production and distribution. Ac power can directly power certain motor types, such as ac induction motors.
Direct current means the electrons only move in one direction. DC power originates from a battery or a power supply connected to ac line power
BLDC BATTER MOTOR :-
Without the carbon brushes and copper commutator, the only wear items in a BLDC motor are the bearings. This makes the BLDC motor far superior when long operating life is required.
Because the windings are stationary and in thermal contact with the outer case, heat is dissipated more easily, allowing for higher power operation in the same package size. Also, with no brushes and commutator, the overall length is shorter.
Without the mechanical contact of the brushes, higher speeds and peak loads are practical.
Conclusion:
Thus, we have studied the comparison between Four-Quadrant Chopper DC Drive and H-bridge model and also run the dc motor simulation using BJT and dc7 block. Studies the results from a EV model using dc7 block.