Week-7 Challenge: DC Motor Control
Question:1
Aim: A. To Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
B. Comment on the armature current shoot-up from the scope results.
C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model
SIMULINK MODEL :
A. To Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
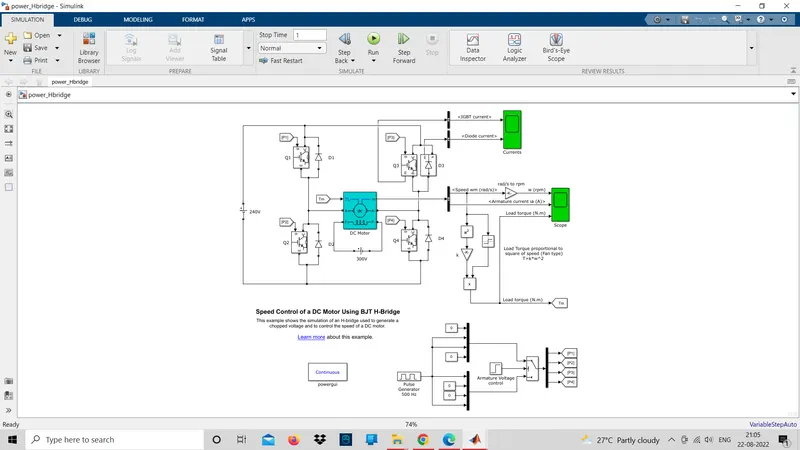
- the above figure shows the speed control of dc motor by using BJT H bridge
- Here the Bipolar Junction Transistor (BJT) is used for power switching applications operates as an IGBT. When it is conducting BJT operating in the saturated region in a forward voltage Vf is developed between collector and emitter . so the IGBT block can be used to model the BJT device.
- For the above circuit the input siginal is generated by using the pluse generator.Here the IGBT block does not simulate the gate current controlling the BJT or IGBT.
- The bridge used in the above circuit is H- Bridge It consists of four BJT/Diode pairs . Two transistors are switched simultaneously: Q1 & Q4 or Q2 &Q3.
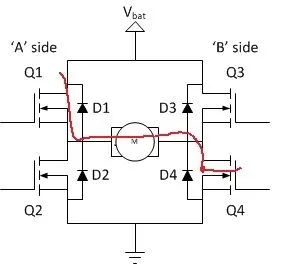
- So it works When Q1 and Q4 is triggered a positive voltage is applied to the motor and diodes D2-D3 operate as free-wheeling diodes .
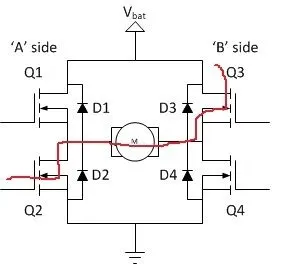
- Similarly when Q1 and Q4 are switched off. then Q2 and Q3 are triggered a negative voltage is applied to the motor and diodes D1-D4 operate as free-wheeling diodes then Q2 and Q3 are switched off.
- Here the Q1&Q4 act as one pair and Q2&Q3 act as one pair. And Q1&Q4 act as forward motoring,Q2&Q3 act as reverse motoring
Q1& Q4 When act as fowardmotoring: Q2& Q3 When act as reverse motoring:
B. Comment on the armature current shoot-up from the scope results.
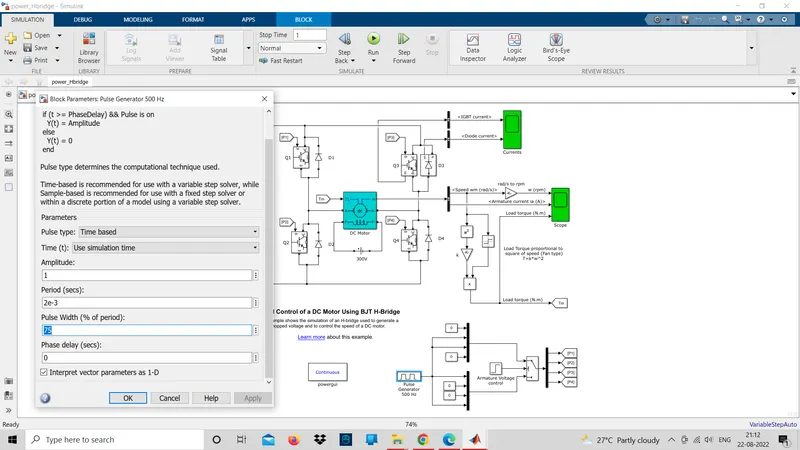
Here the pluse width is set to 75 as show in below figure:
Armature current output results:
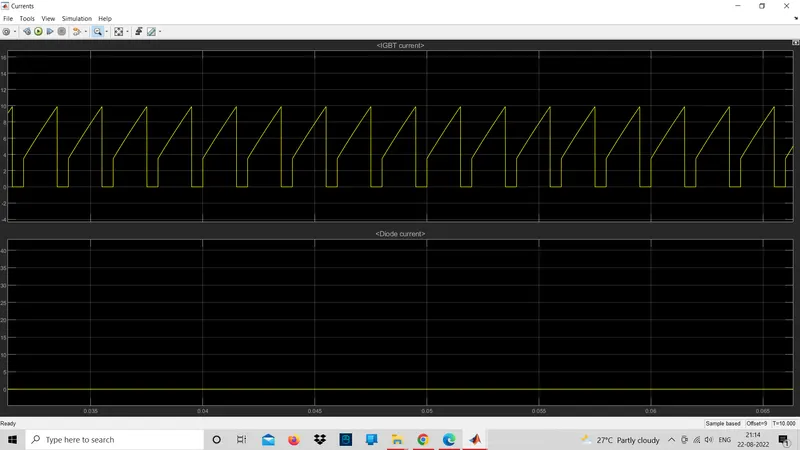
In the above graph it shows that the IGBT current and diode current is obtined when the current passed in the qudrant Q3 and D3.when the Q3 is off the diode current is zero as shown in the above figure.
Scope results :
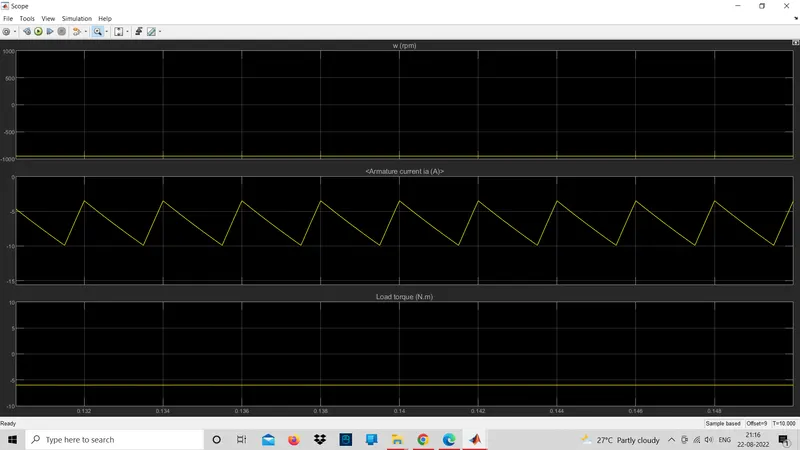
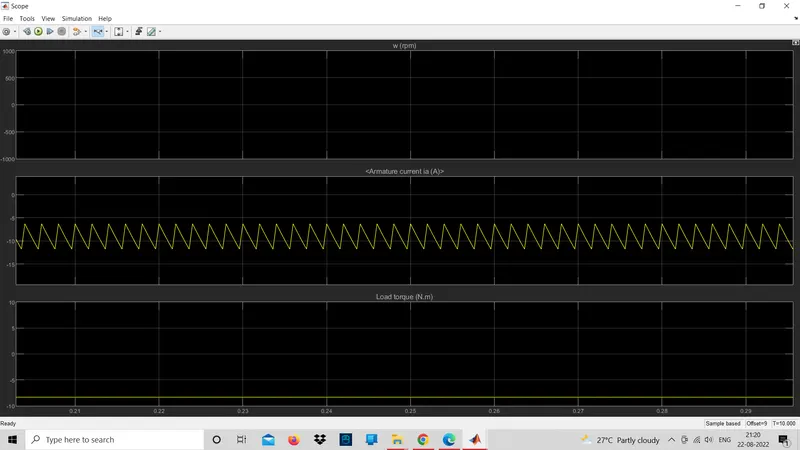
In the starting stage there is sudden shootup in the aramture current and the load torque is aslo changed with the aramture current.
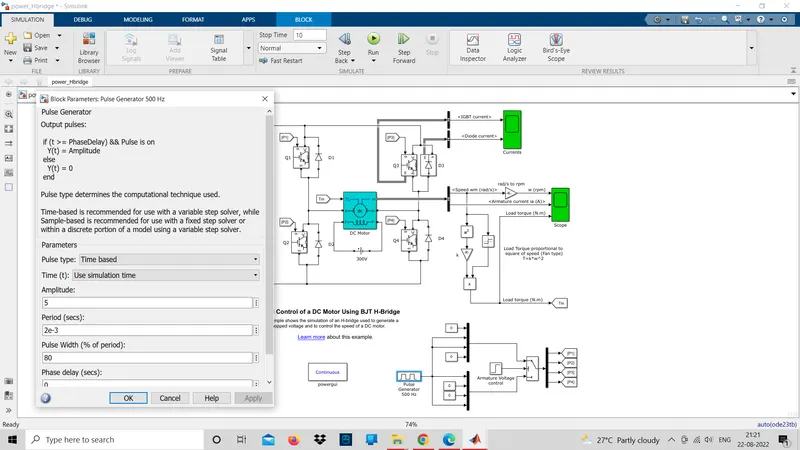
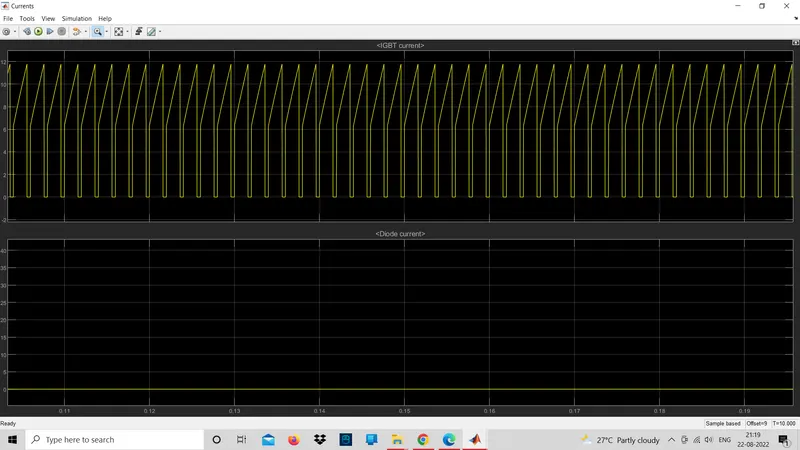
By changing the pluse generator input value:
C.Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
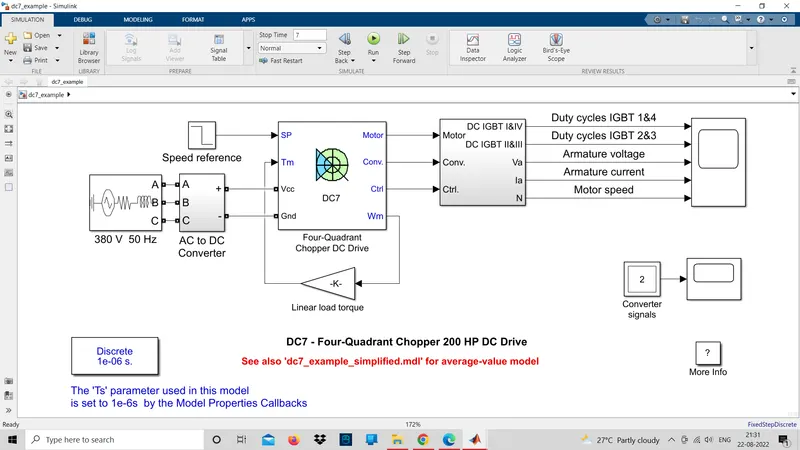
- The above figure shows the DC7 four quadrant chopper 200 HP DC drive here the four quadrant operation means the machine operates in 4 quadrants
- The 200 HP DC motor is separately excited with a constant 150 V DC field voltage source. The armature voltage is provided by an IGBT converter controlled by two PI regulators.
- And the converter is fed by a 515 V DC bus obtained by rectification of a 380 V AC 50 Hz voltage source. to limit the DC bus voltage during dynamic braking mode, a braking chopper has been added between the diode rectifier and the DC7 block.
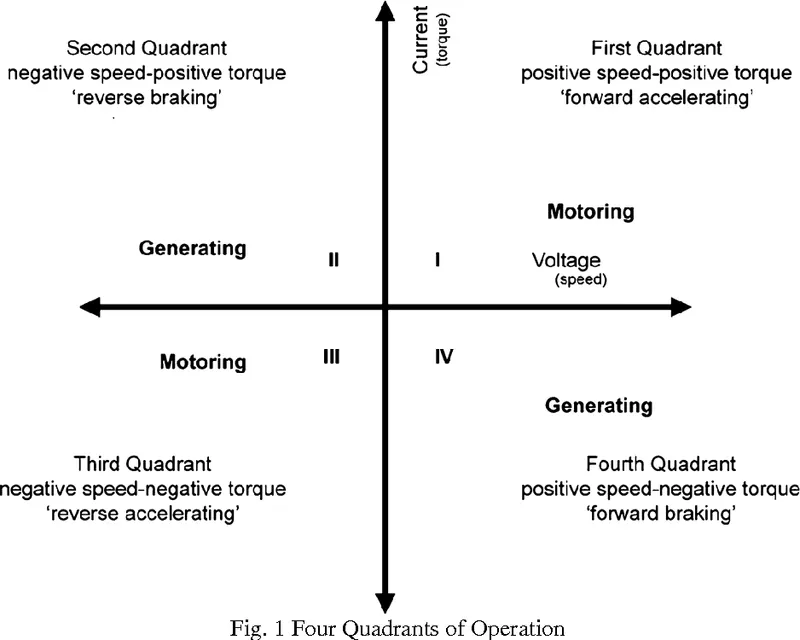
- In the 1st quadrant it gives positive speed and positive torque (i.e forward accelerating),In the 2nd quadrant it gives negative speed and postive torque (i.e reverse braking)
- In the 3rd quadrant it gives negative speed and negative torque (i.e reverse accelerating),In the 4th quadrant it gives postive speed and neagtive torque.
Comprision between Four-Quadrant Chopper DC Drive (DC7) block with the H-bridge.
- In the H- bridge model the forward motoring and reverse motoring operates in 1st amd 3rd qudarants where as in DC-7 drive it operates in all the 4 quadrants.
- Pi controllers are used for the control of pluse width,in dc7 drive we need to provide the fixed value of pluse width for the output results
- feedback circuit is present in h-bridge there in no feedback in the dc7 drive
- H- bridge is closedloop whereas dc7 drive is open loop chopper
- continue calculation is require in h-bridge,dc7 drive it need discreat calculation
- h- bridge operates slowly compare to the dc7 drive model
- armature current osccilations are reduced by smoothing inductance connect in series but in dc7drive need to lower the duty cycle for eliminating armature ripples.
regenerative braking is absent in h-bridge,but in case of dc7drive it is present.
Question 2
Aim : To Develop a 2-quadrant chopper using simulink & explain the working of the same with the relevant results.
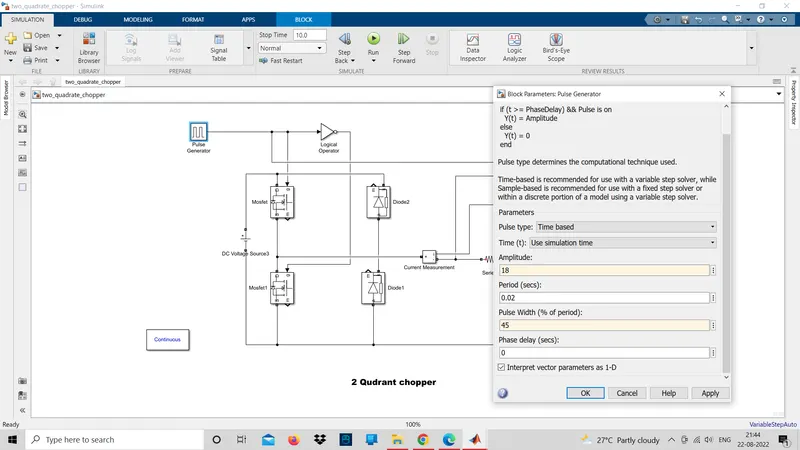
Simulink model to develop 2-quadrant chopper :
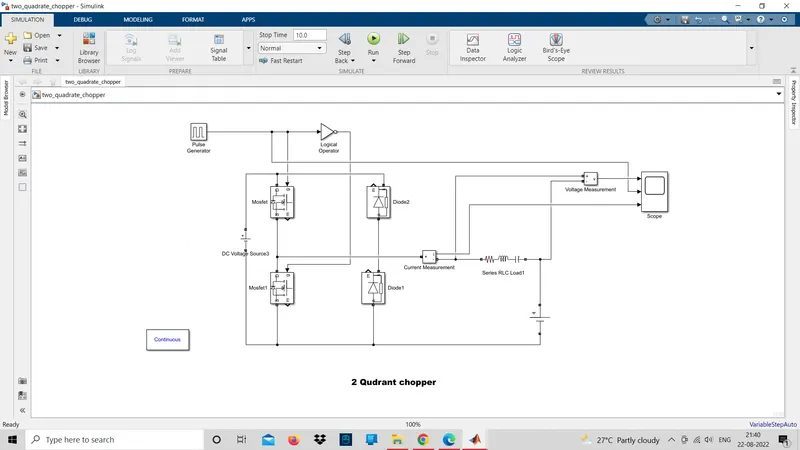
- The above simulink model shows about the model of 2- quadrant chopper, it is also known as the class-c chopper it mainly operates in the 1st & 2nd quadrants.
- Intially we have given the 30v to the dc volatge source and also we have given the pluse generator values is pluse width is 45% and amplitude is 18 duty cycle is 0.02
- During starting stage the two switches should not operate at same time which causes the short circuit among the bridge.
- so in first step we need to switch on the CH1 chopper 1 so that current flows from soucre to the load .at the same time inductors tires to store the energy.
- In the next step i.e when the CH1 is off then the freewheelimg diode comes into the action and starts conducting then ouput voltage euqals source voltage.
- here the the direction of current will be reverse when the inuductor starts discharging then current will goes to the source
- So for the regenerative braking the CH2 chopper will be operated then the complete current onlys flows through the chopper2 to the negtive side of the secound diode
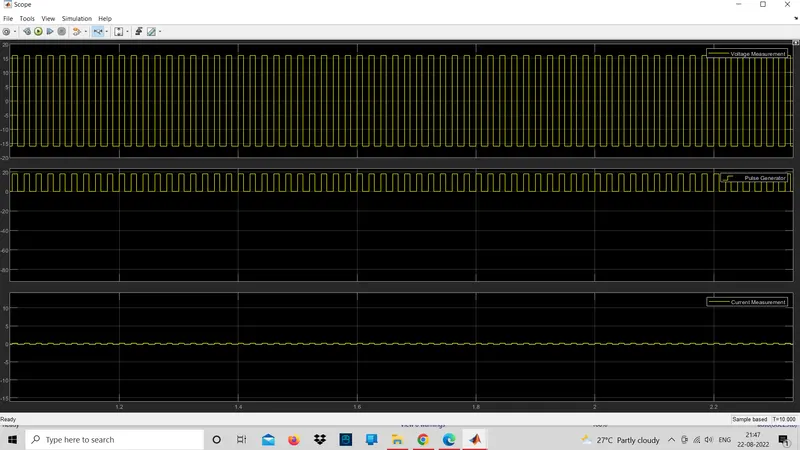
scope results :
Question:3
Aim : To Explain in a brief about operation of BLDC motor.
construction of breshless dc motor :
- In this motor, the permanent magnets attach to the rotor. The current-carrying conductors or armature windings are located on the stator. They use electrical commutation to convert electrical energy into mechanical energy.
- The main design difference between a brushed and brushless motors is the replacement of mechanical commutator with an electric switch circuit.
- A BLDC Motor is a type of synchronous motor in the sense that the magnetic field generated by the stator and the rotor revolve at the same frequency.
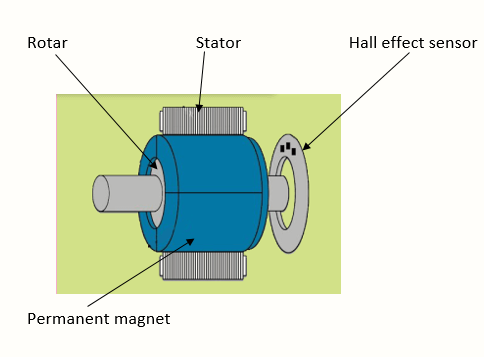
Brushless motor does not have any current carrying commutators. The field inside a brushless motor is switched through an amplifier which is triggered by the commutating device like an optical encoder.
The layout of a DC brushless motor can vary depending on whether it is in “Out runner” style or “Inrunner” style.
-
Outrunner – The field magnet is a drum rotor which rotates around the stator. This style is preferred for applications that require high torque and where high rpm isn’t a requirement.
-
In runner – The stator is a fixed drum in which the field magnet rotates. This motor is known for producing less torque than the out runner style, but is capable of spinning at very high rpm.
working of breshless dc motor :
BLDC motor works on the principle similar to that of a Brushed DC motor. The Lorentz force law which states that whenever a current carrying conductor placed in a magnetic field it experiences a force. As a consequence of reaction force, the magnet will experience an equal and opposite force. In the BLDC motor, the current carrying conductor is stationary and the permanent magnet is moving.
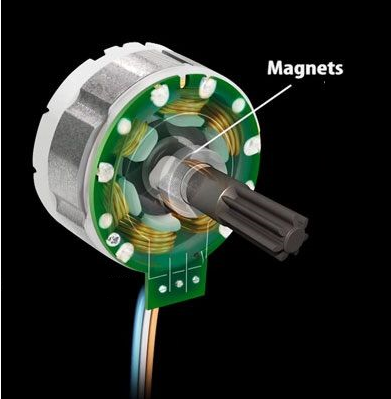
- When the stator coils get a supply from source, it becomes electromagnet and starts producing the uniform field in the air gap.
- Though the source of supply is DC, switching makes to generate an AC voltage waveform with trapezoidal shape. Due to the force of interaction between electromagnet stator and permanent magnet rotor, the rotor continues to rotate.
- With the switching of windings as High and Low signals, corresponding winding energized as North and South poles.
- The permanent magnet rotor with North and South poles align with stator poles which causes the motor to rotate.
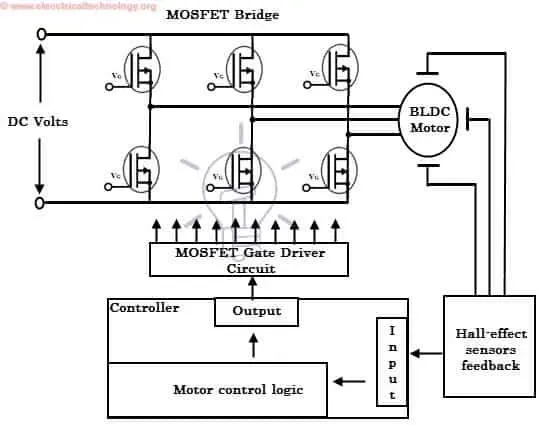
Brush less motor drive:
The figure shown below is the BLDC motor drive circuit which consists of MOSFET bridge electronic controller hall effect sensor and BLDC motor.
advantages of BLDC motor :
- Less overall maintenance due to absence of brushes
- Reduced size with far superior thermal characteristics
- Higher speed range and lower electric noise generation.
- It has no mechanical commutator and associated problems
- High efficiency and high output power to size ratio due to the use of permanent magnet rotor
- High speed of operation even in loaded and unloaded conditions due to the absence of brushes that limits the speed
- Smaller motor geometry and lighter in weight than both brushed type DC and induction AC motors.
- Long life as no inspection and maintenance is required for commutator system
- Higher dynamic response due to low inertia and carrying windings in the stator
- Less electromagnetic interference
- Low noise due to absence of brushes
limitations of BLDC motor :
- These motors are costly
- Electronic controller required control this motor is expensive
- Requires complex drive circuitry
- Need of additional sensors
applications of BLDC motor :
- Brushless DC motors (BLDC) use for a wide variety of application requirements such as varying loads, constant loads and positioning applications in the fields of industrial control, automotive, aviation, automation systems, health care equipments etc.
- Computer hard drives and DVD/CD players
- Electric vehicles, hybrid vehicles, and electric bicycles
- Industrial robots, CNC machine tools, and simple belt driven systems
- Washing machines, compressors and dryers
- Fans, pumps and blowers.
Conclusion:
we have completed the above tasks
In case-1 we have explained the demo of matlab model of speed control of dc motor using BJT
In case-2: we have commented on the aramture current shoot-up results
In case-3: we have explained the brife operation about BLDC motor