Week-7 Challenge: DC Motor Control
1.Run MATLAB demo ‘Speed control of a DC motor using BJT H-bridge’. Modify the model such that armature current doesn’t shoot up when motor changes direction from forward to reverse.
To get the above mentioned model just we have to insert "power_Hbridge" code in a command window and then run in Matlab.
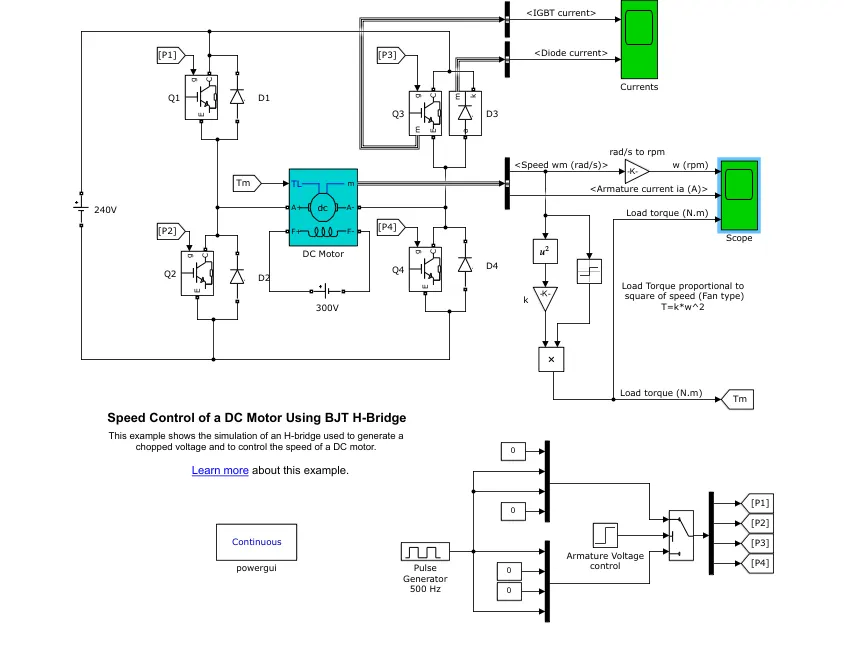
The Bipolar Junction Transistor (BJT) when used for power switching applications, operates as an IGBT. When it is conducting (BJT
operating in the saturated region), a forward voltage Vf is developed between collector and emitter (in the range of 1 V). Therefore, the
IGBT block can be used to model the BJT device.
The IGBT block does not simulate the gate current controlling the BJT or IGBT. The switch is controlled by a Simulink® signal (1/0).
The DC motor uses the preset model (5 HP 24V 1750 rpm). It simulates a fan type load (where Load torque is proportional to square of
speed). The armature mean voltage can be varied from 0 to 240 V when the duty cycle (specified in the Pulse Generator block) is
varied from 0 to 100%.
The H-bridge consists of four BJT/Diode pairs (BJT simulated by IGBT models). Two transistors are switched simultaneously: Q1 and Q4
or Q2 and Q3. When Q1 and Q4 are fired, a positive voltage is applied to the motor and diodes D2-D3 operate as free-wheeling diodes
when Q1 and Q4 are switched off. When Q2 and Q3 are fired, a negative voltage is applied to the motor and diodes D1-D4 operate as
free-wheeling diodes when Q2 and Q3 are switched off.
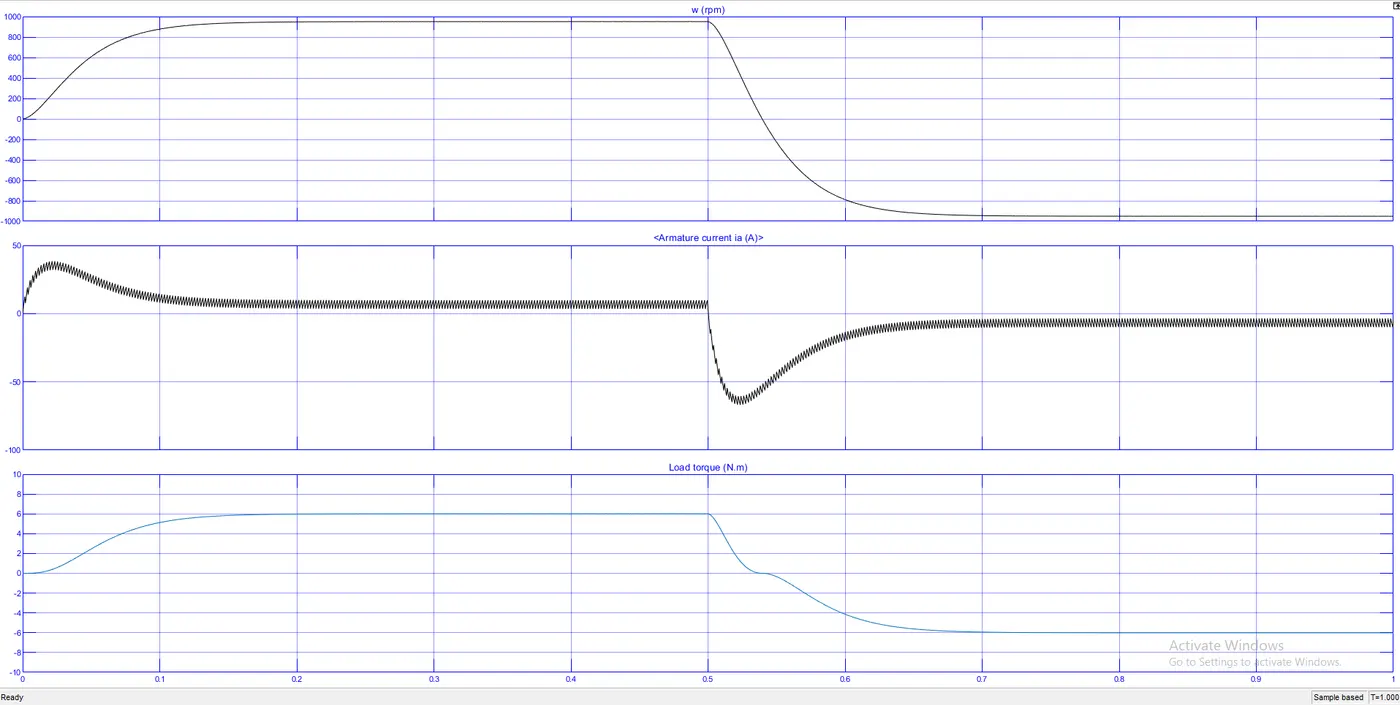
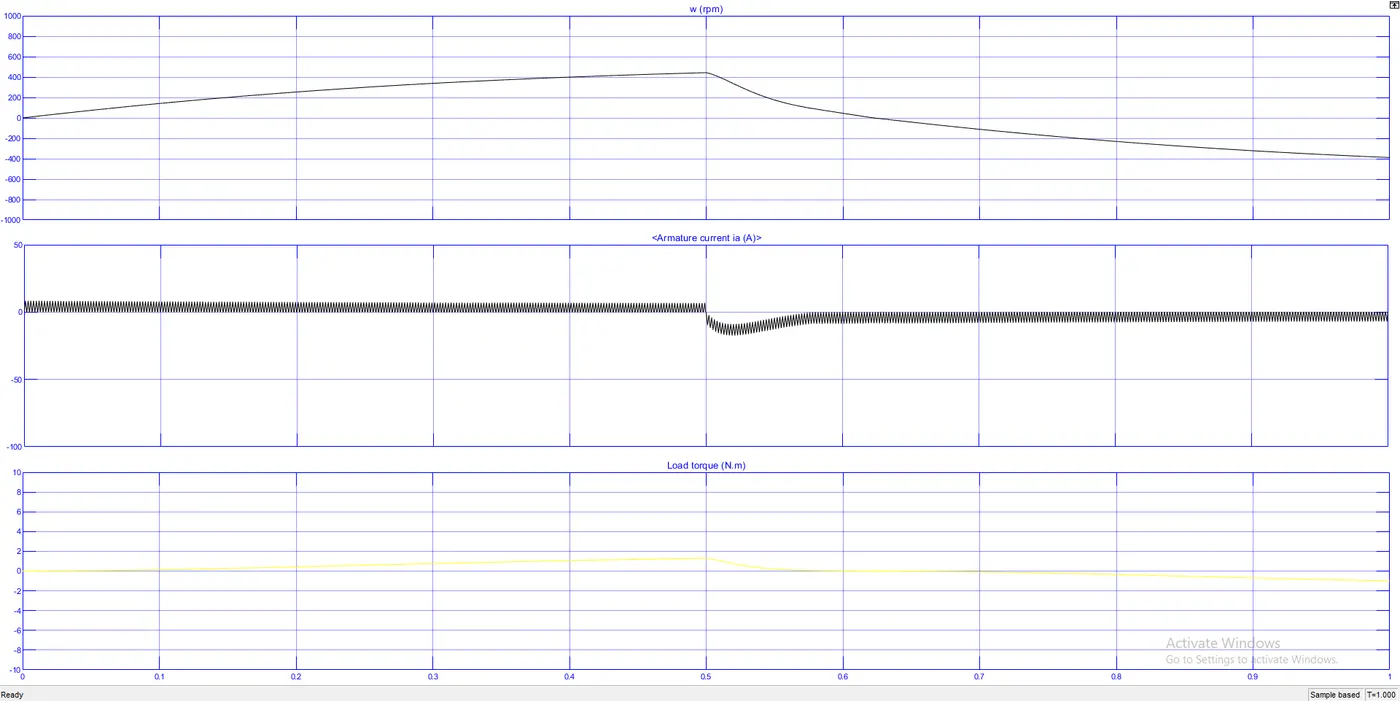
The motor starts in the positive direction with a duty cycle of 75% (mean DC voltage of 180V). At t= 0.5 sec., the armature voltage is
suddenly reversed and the motor runs in the negative direction.
'Scope' shows motor speed, armature current and load torque and 'Currents' shows currents flowing in BJT Q3 and diode D3.
In the armature current scope for the default value the graph shows shoot up in both forward and reverse direction.
Here the challenge is to make less fluctuating of amrmature current i.e doesnt shoot of armature current both in
forward and reverse direction.
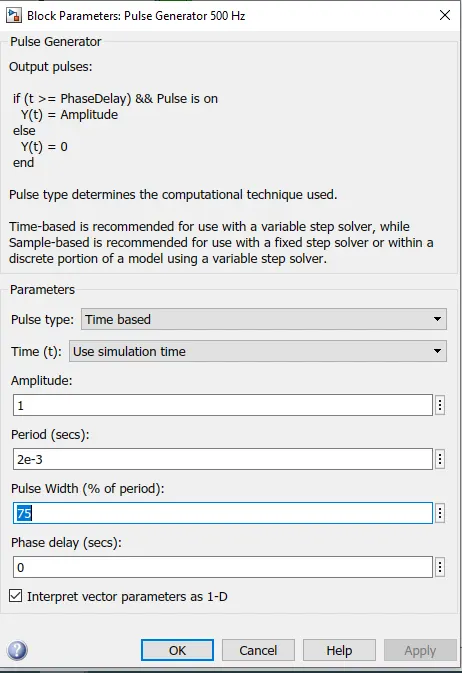
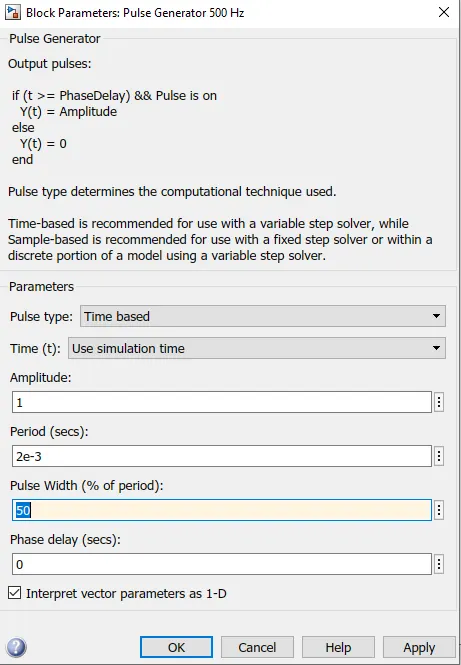
To avoid the shoot up , the duty cycle and the period should vary by using trail and error method. By reducing duty
cycle to 50% we can observe less shoot up both in the reverse and forward direction in the armature current
graph..
When we run with the above changes we can observe that there is no spike in the armature current in the forwaed direction.
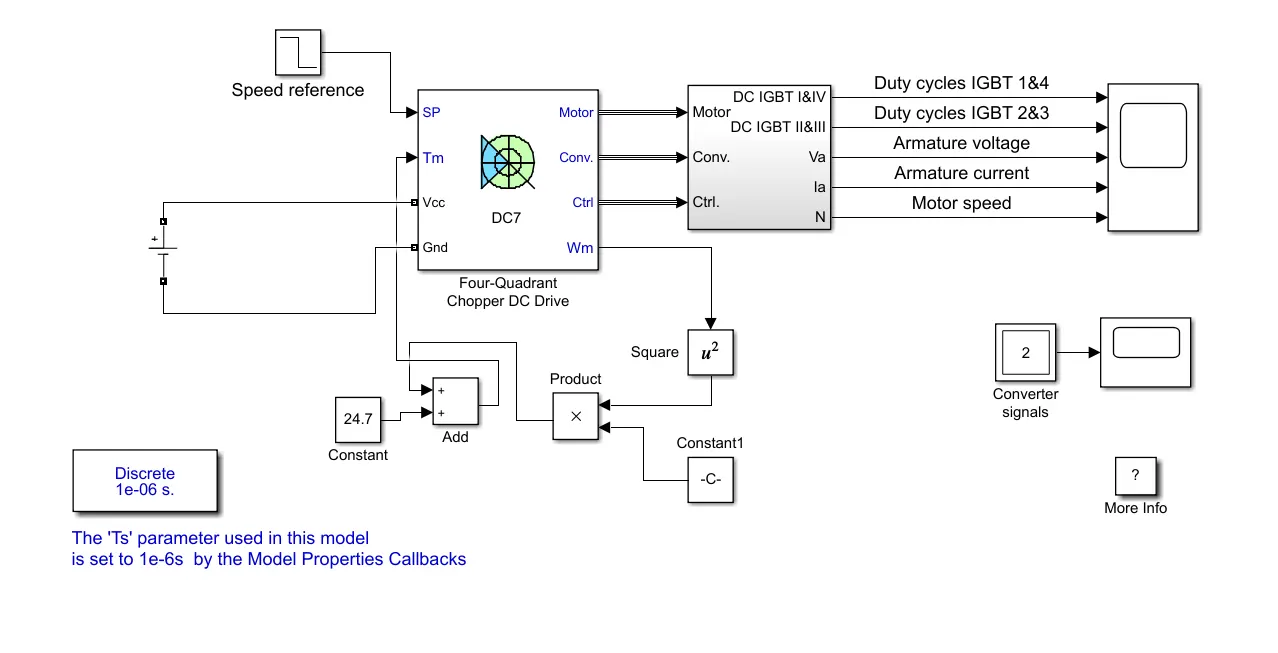
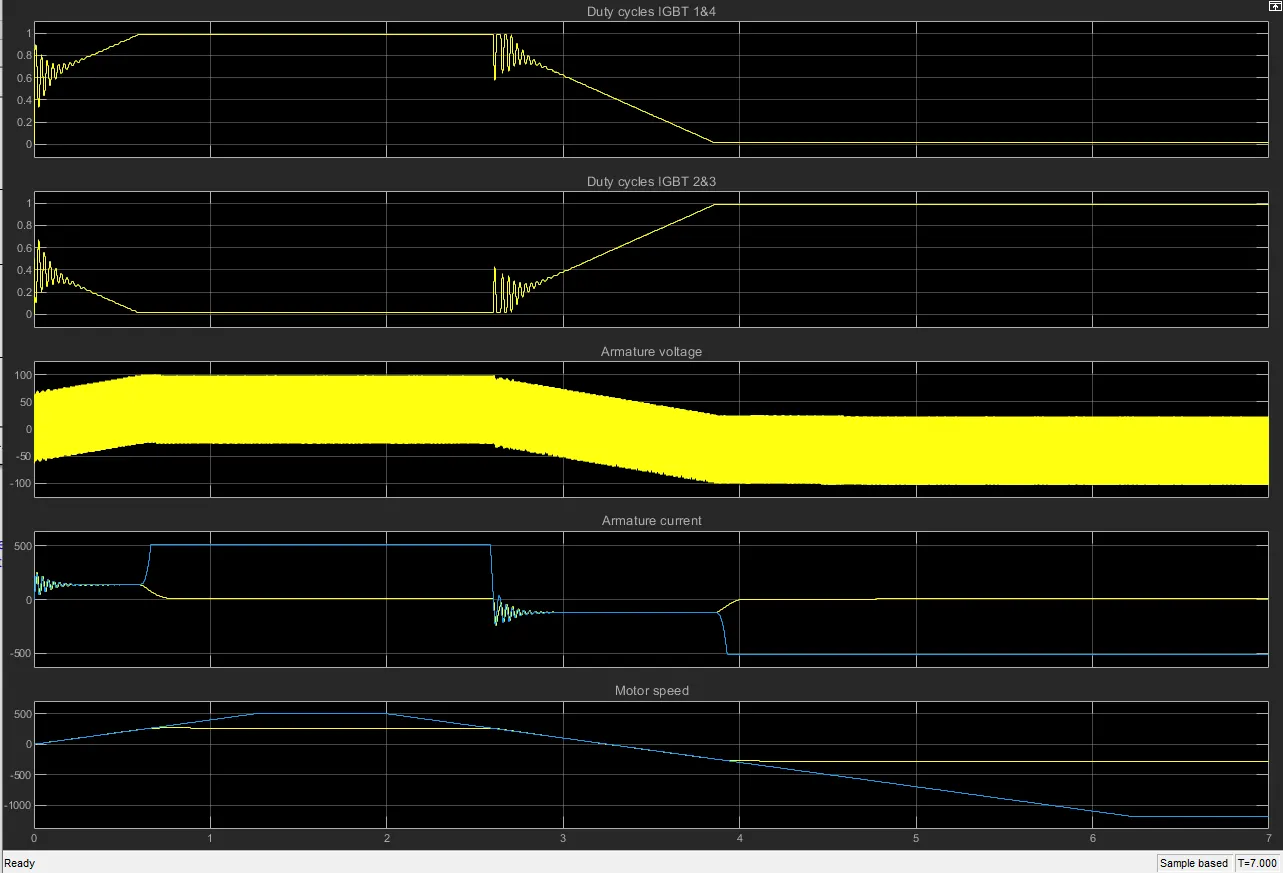
2.Refer to help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with H-bridge model.
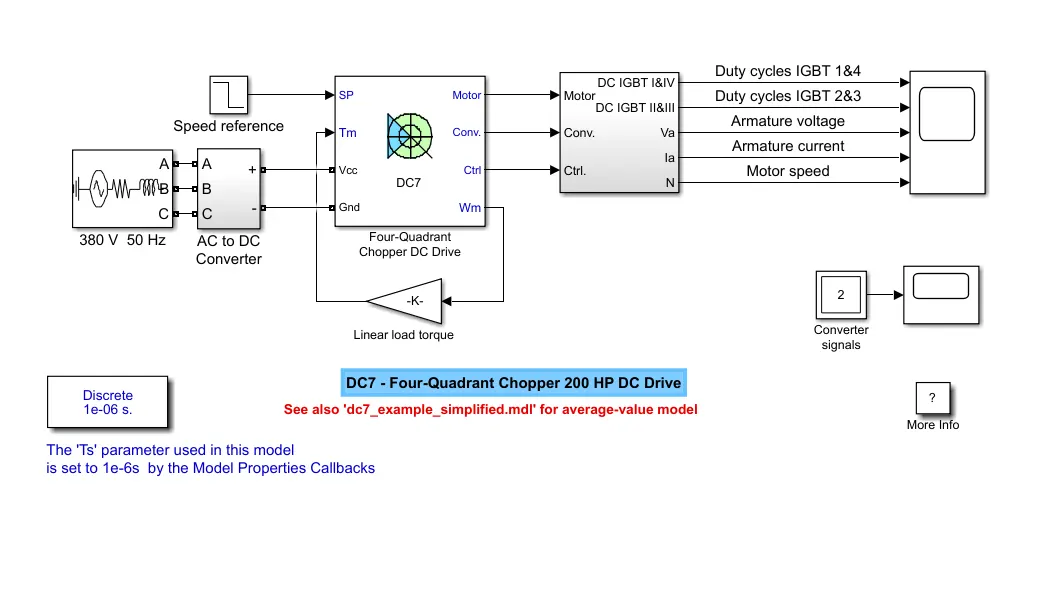
The above model consists of three phase source,AC-DC converter includes rectifier and braking chopper DC motor drive and quadrant
selector.
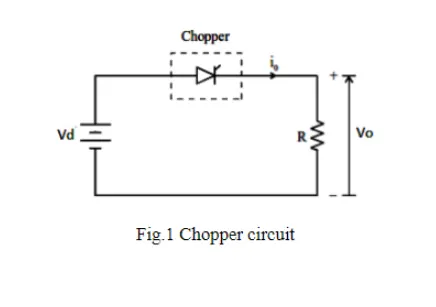
A chopper is a static device that converts fixed DC input to a variable DC output voltage directly.Essentialy, a chopper is an electronic
switch that is used to interrupt one signal under the control of another.Due to this,current and voltage spikes occurs. To avoid this
snubber RC circuit is used.The chopper is widely used in motor control and regenerative braking. A snubber is an electrical device that
prevents voltage spikes due to sudden changes in current.these voltage spikes,or transients can damage the circuit and cause arcing
and sparks.one type of electrical snubber is the RC snubber,which is composed of a resistor in parallel with a capacitor.Transients are
usually caused by switches in the circuit.
The 200 HP DC motor is separately excited with a constant 150 V DC field voltage source. The armature voltage is provided by an IGBT
converter controlled by two PI regulators. The converter is fed by a 515 V DC bus obtained by rectification of a 380 V AC 50 Hz voltage
source. In order to limit the DC bus voltage during dynamic braking mode, a braking chopper has been added between the diode
rectifier and the DC7 block.
The first regulator is a speed regulator, followed by a current regulator. The speed regulator outputs the armature current reference (in
p.u.) used by the current controller in order to obtain the electromagnetic torque needed to reach the desired speed. The speed
reference change rate follows acceleration and deceleration ramps in order to avoid sudden reference changes that could cause
armature over-current and destabilize the system. The current regulator controls the armature current by computing the appropriate
duty ratios of the 5 kHz pulses of the four IGBT devices (Pulse Width Modulation). For proper system behaviour, the instantaneous
pulse values of IGBT devices 1 and 4 are opposite to those of IGBT devices 2 and 3. This generates the average armature voltage
needed to obtain the desired armature current. In order to limit the amplitude of the current oscillations, a smoothing inductance is
placed in series with the armature circuit.
The above figure consists of voltage source 4 pairs of chopper & diode armature resistance inductance and separately excited DC
motor.
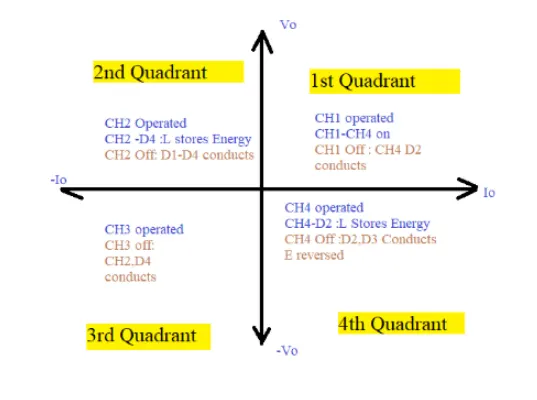
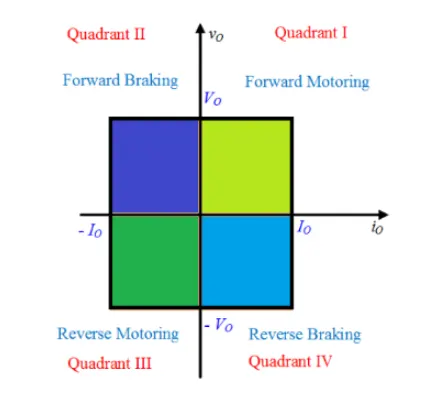
First-Quadrant: forward motoring:
the chopper-1 & chopper-4 are switched ON,in which the current flows from chopper-1 through inductance (which stores energy)the
load current and armature current are same and positive thus the motor rotates in forward direction.if the chopper-1 is swicthed OFF
the energy stores in the inductance flows to chopper-4 which activates the D2 and forms closed loop.
Second-Quadrant:forward regenerative motoring:
the chopper-2 is switched ON D4 is activated,the current flows from D4 to chopper-2 through inductance which is in opposite
direction(negative current)and the voltage is positive thus the motor stops in forward direction.if the chopper-2 is swicted OFF,the D4&
D1 are conduct current.
Third-Quadrant:reverse motoring:
the chopper-2 & chopper-3 are swicted ON,in which the current flows from chopper-3 to chopper-2 through inductance the load current
is negative and armature current and also the voltage is negative which is less than the back emf thus the motor rotates in reverse
direction.if the chopper-3 is switched OFF,the energy stores in the inductance flows to chopper-2 which activates the D4 and forms
closed loop.
Fourth-Quadrant:regenerative braking:
the chopper-4 is swicthed ON D2 is activated,the current flows from chopper-4 to D2 through inductance which is in same direction and
the volatge is negative thus the motor stops in reverse direction.if the chopper-4 is swicthed OFF,the D2 & D3are conduct current.
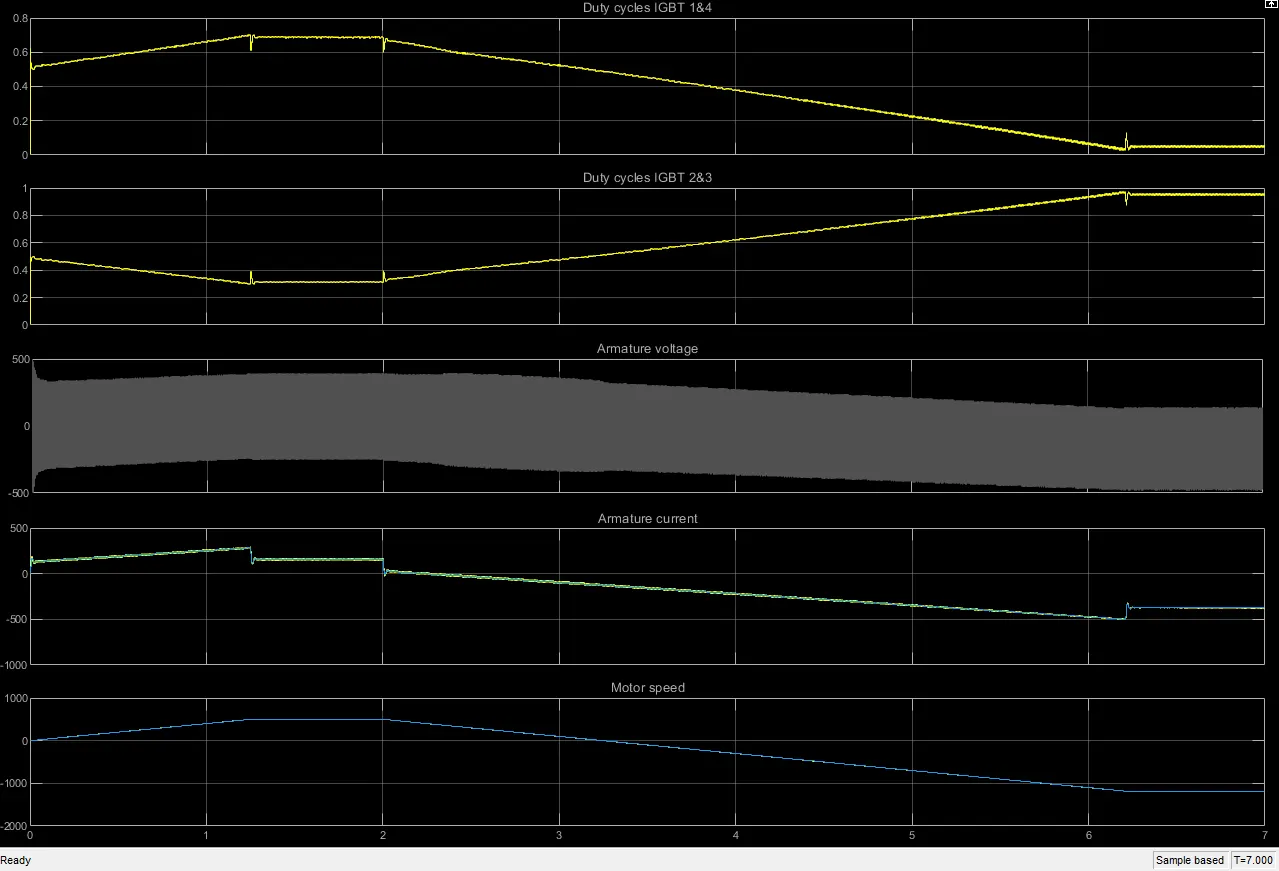
Output: