Week-7 Challenge: DC Motor Control
1. A. Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’
ANSWER:-
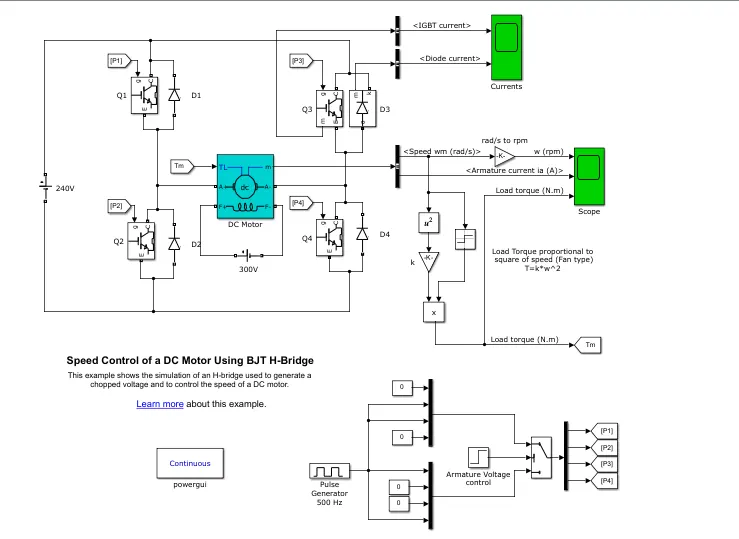
SPEED CONTROL OF DC MOTOR USING BJT H-BRIDGE :-
- The bipolar junction transistor (BJT) when used for power switching applications and operates as an IGBT. when it is conducting BJT operating in saturated region, a forward Voltage Vf is developed between collector and emitter .
- Therefore The IGBT Block can be used to modek the BJT device.
- The iGBT Block does not simulate the gate current controlling the BJT and IGBT.
- The switch is controlled by a simulink signal (1/0).
- The DC motor uses the preset model, It simulates a fan type load .
- The armature voltage can be varied from 0 to 240 v when the duty cycle varied from 0 to 100%.
- The H bridge consists of four BJT / Diode pairs (BJT simulated By IGBT models)
- two transistors are switched simultaniously : Q1 & Q4 or Q2 &Q3 .
- When Q1 and Q4 are fired , a positive vltg is applied to the motor and diodes D2-D3 operates as free wheeling diodes,when Q1 and Q4 are switched off.
- Similarly Q2 and Q3 are fired , anegative vltg is applied to the motor and diodes D1-D4 operates as free wheeling diodes,when Q2 and Q3 are switched off.
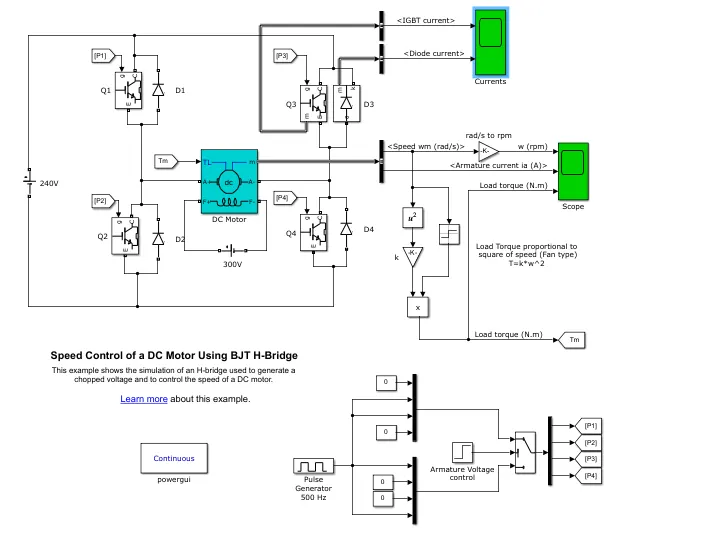
- The pulse generator is used to generate the pulse which are fed into the Four IGBTs .
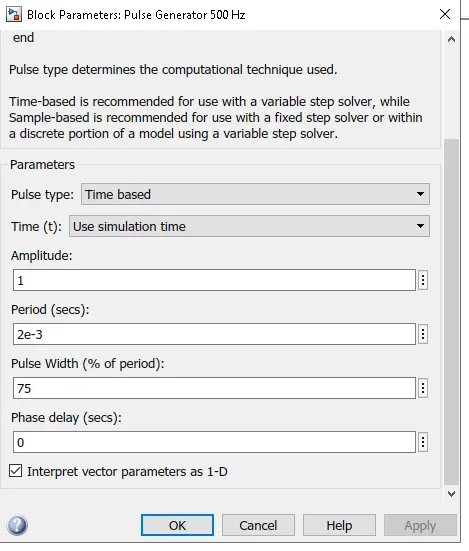
- In this model, th simulation time is such that the motor starts in the positive direction with a duty cycle of 75%.
- The below image gives the pulse generator block parameters
OUTPUT:-
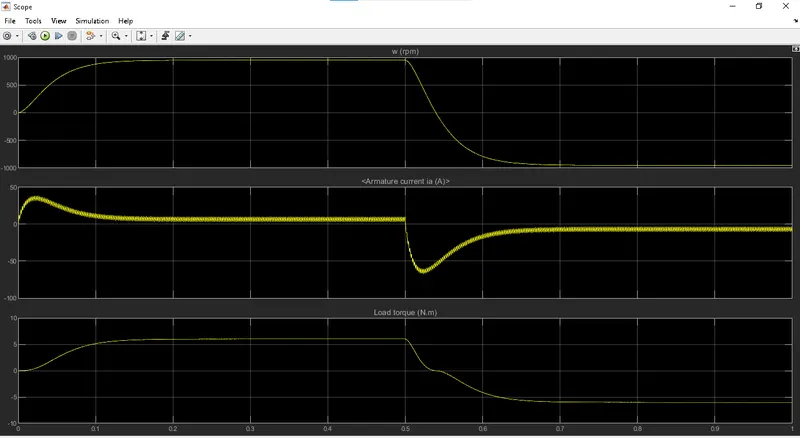
- thus the plot shows the speed, armature current and load torque obtained with respect to the pulse width from the pulse generator and other various blocks.
B. Comment on the armature current shoot-up from the scope results.
SCOPE:-
- At t = 0.5sec, the armature voltage is suddenly reversed and the motor runs in the negative direcction.
- So in the first half cycle, the motor attains the speed of 1000 rpm and a load torque of 6 NM.
- whereas the second half cycle we see that the armature current of dc motor does get shoot up.
- To avoid this we will have to reduce the pulse width from the pulse generator.
After changing pulse width of the pulse generator:-
- we have changed the pulse width from 70% to 40%.
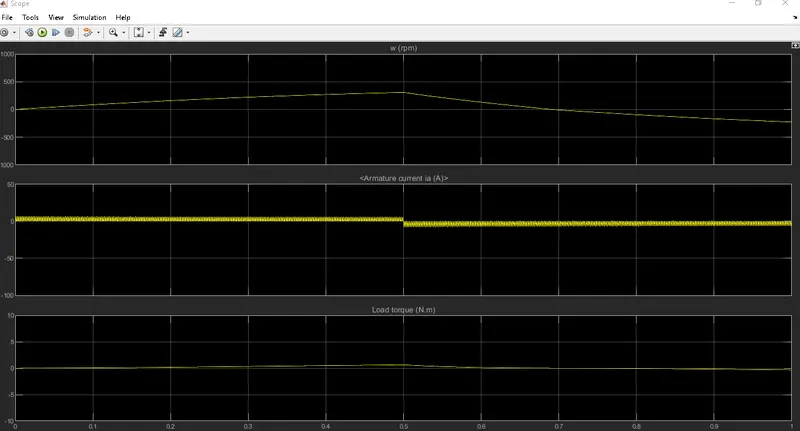
- As we can see clearly from the scope the armature current is almost near to zero i mean 0amps.
- That means armature current doesnt shoots up at 40% pulse width.
- the motor speed and torque is reduced to 30 rpm and 0.6 NM respectively.
- This indicates that as we reduce the pulse width in pulse generator, the motor speed and torque reduces and can attain zero at a certain value.
C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
ANSWER:-
BJT H-BRIDGE :-
The Four-Quadrant Chopper DC Drive (DC7) block:-
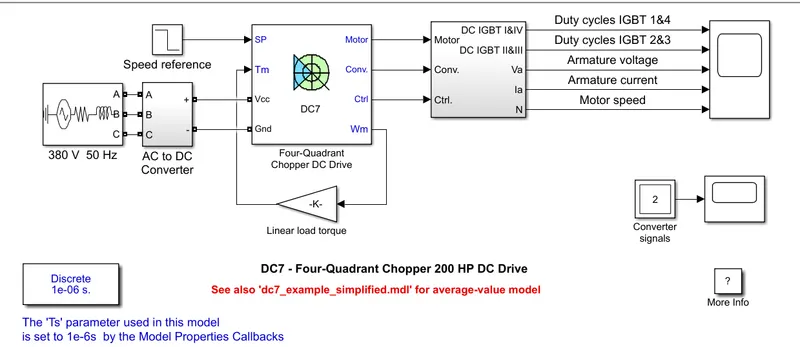
- In four quadrant chopper Dc drive block, the speed reference input is used to change the direction of the motor rotation whereas in the BJT H- bridge model, the polarity is reversed to change the direction of motor rotation.
- In BJT H bridge the motor can be controlled by changing the pulse width of the pulse generator whereas in four quadrant chopper DC drive block, the speed reference values can be changed to control the motor.
- The Four quadrant chopper DC drive operates in four modes forward motoring ,reverse motoring,forward regenerative braking, and reverse regeneraative braking mode, whereas in BJT H bridge model operates only on two modes forward and reverse.
- In DC7 block we use PI controllers , but in H- bridge it is absent.
- The DC7 drive block uses ramps to avoid current shoot up and smotth working stability.
- The disturbances and current shoot up is high in H bridge model because of switching losses.
- Thus we can say the overall performance and stability is good in Four quadrant chopper DC drive comparing to BJT H-bridge model.
3. Explain in a brief about operation of BLDC motor.
ANSWER:-
CONSTRUCTION:-
- A commutator-brushes arrangement helps in achieving unidirectional torque in a typical dc motor Obviously, commutator and brush arrangement is eliminated in a brushless dc motor. Here, an integrated inverter/switching circuit is used to achieve unidirectional torque. That is why these motors are, sometimes, also referred as 'electronically commutated motors'.
- Just like any other electric motor, a BLDC motor also consists of two main parts a stator and a rotor. Permanent magnets are mounted on the rotor of a BLDC motor, and the stator is wound for a specific number of poles. Also, a control circuit is connected to the stator winding. Most of the times, the inverter/control circuit or controller is integrated into the stator assembly. This is the basic constructional difference between a brushless motor and a typical dc motor.
- A typical controller provides a three-phase frequency-controlled supply to the stator winding. The supply is controlled by logical control circuits and energizes specific stator poles at a specific point of time. This can be understood from the below animations about working of BLDC motors.
Types of BLDC Motors:-
There are two types of BLDC motors based on their construction/design: (i) inner rotor design & (ii) outer rotor design. Regardless of these types, note that the permanent magnets are always mounted on the rotor and winding on the stator.
Inner rotor design (inrunner): this is a conventional design, where the rotor is located at the core (center) and stator winding surrounds it.
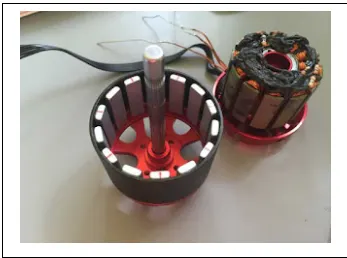
Outer rotor design (outrunner): In this configuration, the rotor is external. i.e. stator windings are located at the core while the rotor, carrying permanent magnets, surrounds the stator.
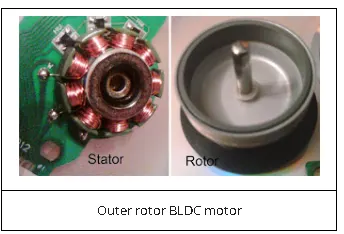
WORKING OF PLDC MOTOR:-
- Stator windings of a BLDC motor are connected to a control circuit (an integrated switching circuit or inverter circuit).
- The control circuit energizes proper winding at the proper time, in a pattern which rotates around the stator.
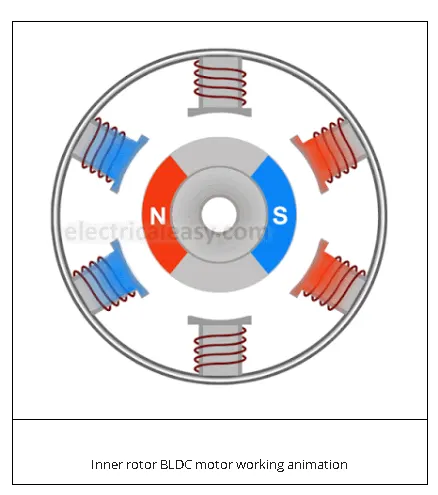
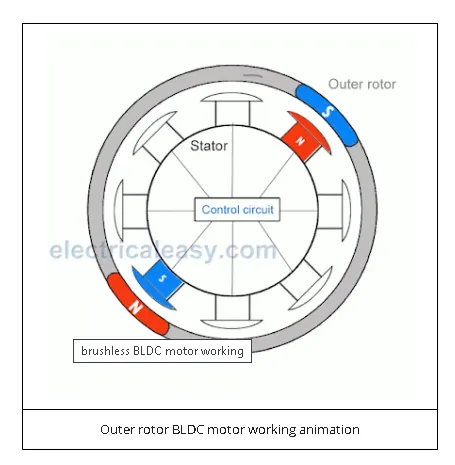
- Permanent magnets on the rotor try to align with the energized electromagnets of the stator, and as soon as it aligns, the next electromagnets are energized.
- Thus, the rotor keeps running.
Comparison between brushless and brushed motors:-
- Brushes require frequent replacement due to mechanical wear hence a brushed DC motor requires periodic maintenance. Also, as brushes transfer current to the commutator, sparking occurs.
- Brushes limit the maximum speed and the number of poles the armature can have. These all drawbacks are removed in a brushless DC motor.
- An electronic control circuit is required in a brushless DC motor for switching stator magnets to keep the motor running. This makes a BLDC motor potentially less rugged.
- Advantages of BLDC motor over brushed motors are increased efficiency, reliability, longer lifetime, no sparking and less noise, more torque per weight, etc.
APPLICATIONS:-
- Consumer electronics – computer hard drives, small cooling fans, cd/dvd players ,washing machines, air conditioners, etc
- Electric Vehicles – many electric vehicles including electric and hybrid cars, electric bikes use BLDC motors.