Week-7 Challenge: DC Motor Control
Study 1 - Run MATLAB demo ‘Speed control of a DC motor using BJT H-bridge’. Modify the model such that armature current doesn’t shoot up when motor changes direction from forward to reverse.
Model description –
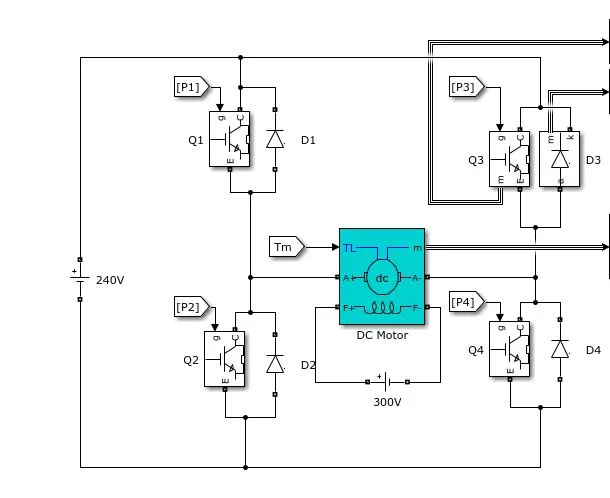
Model has a DC motor, which is controlled by four IGBTs arranged in H shape bridge. The model has catching diode also, which bears back emf and prevents switches from burning. IGBTs are controlled by a signal. When Q1, Q4 is fired, positive voltage is applied to motor and rotor rotates in forward direction and when Q2, Q4 is fired, negative voltage is applied to motor and rotor rotates in reverse direction.
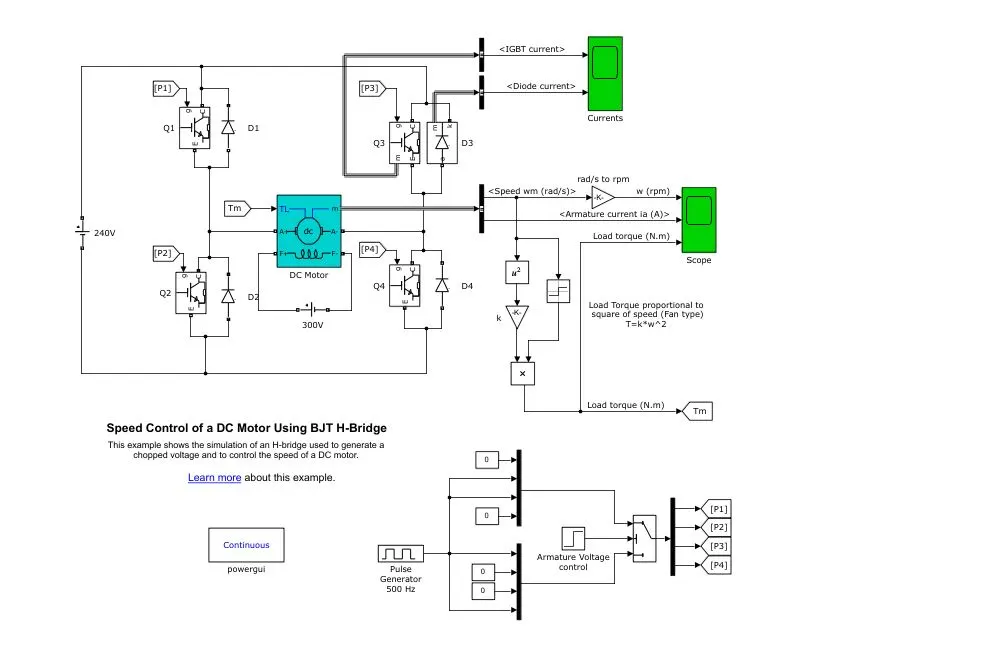
The model is modelled with duty cycle of 75% and simulation time is 1 sec. switch in the model has threshold value 0.5 means after 0.5 sec armature current is reversed and motor runs in negative direction.
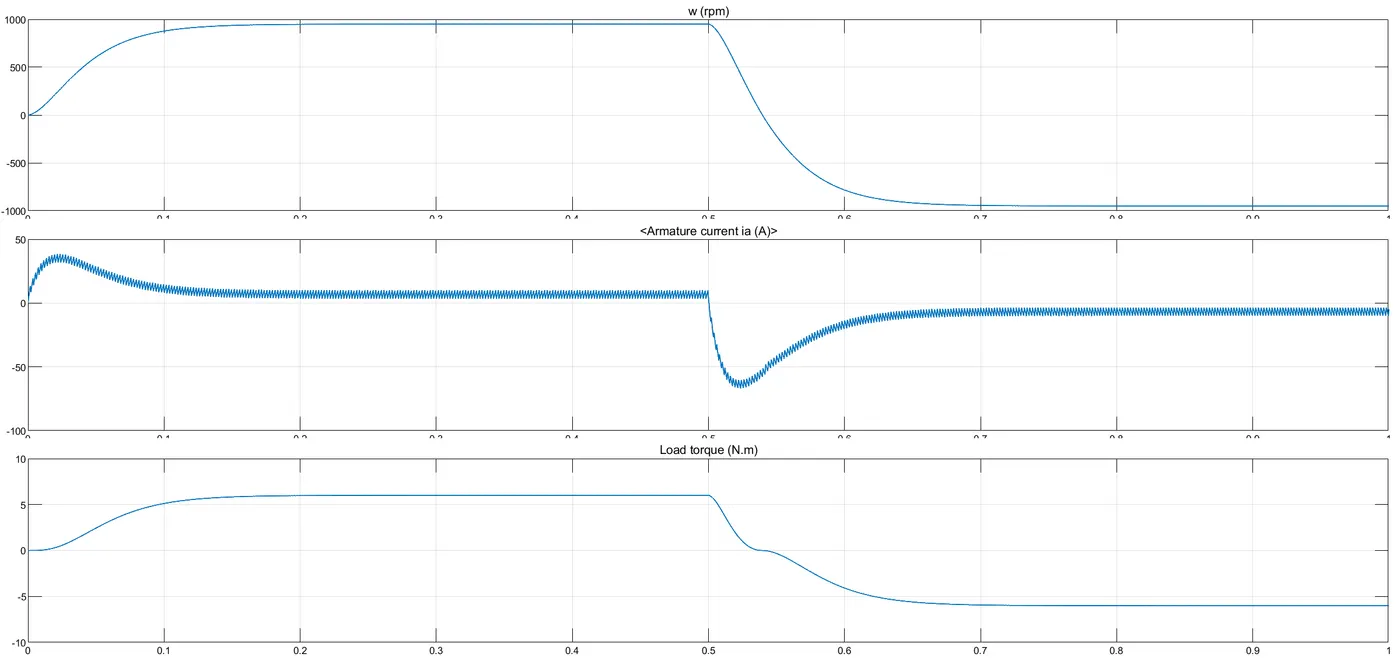
We can see in plot armature current changes its direction after 0.5 sec and gets very high value.to prevent current from shooting we have to change duty cycle which is 75%.
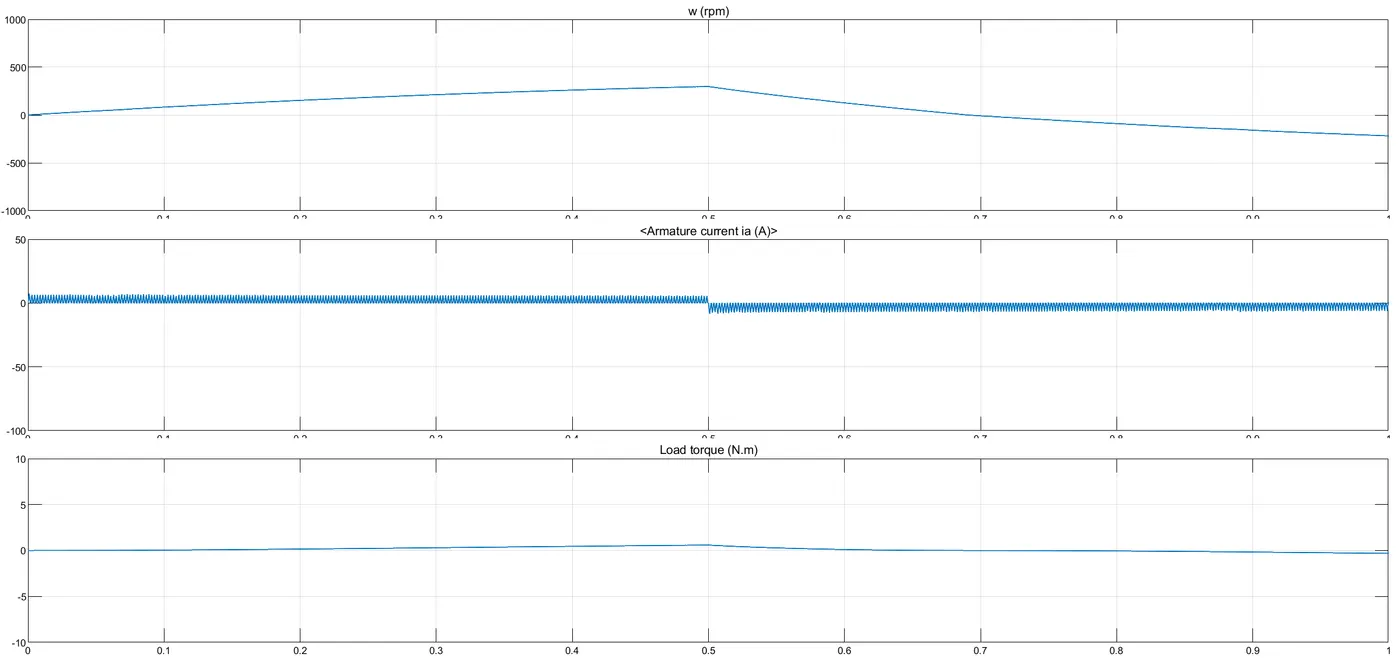
We can observe from graph that current does not shoot up after changing duty cycle from 75 % to 40%.
Study 2 - Refer to help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with H-bridge model.
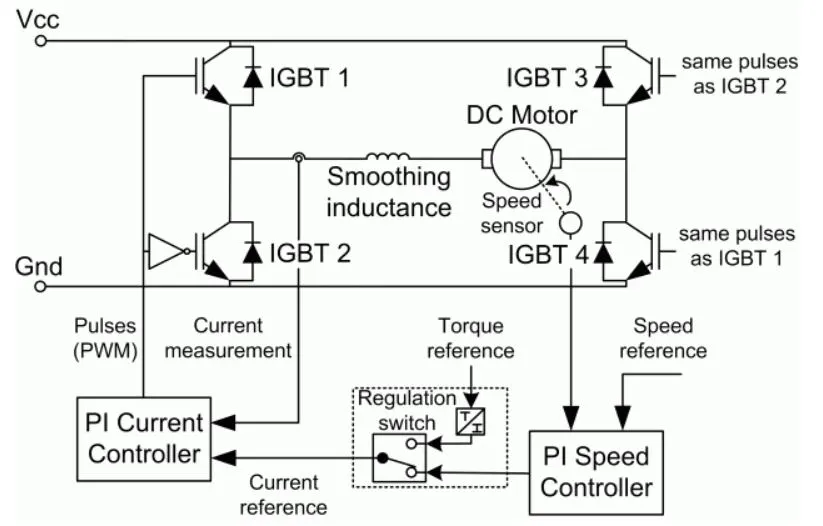
The four quadrant chopper DC drive(DC7) Block – it represents a DC supplied four quadrant chopper for DC drive. It has a PI controller which generates current according to armature demand so it is close loop system which can be operated in any of four quadrant.
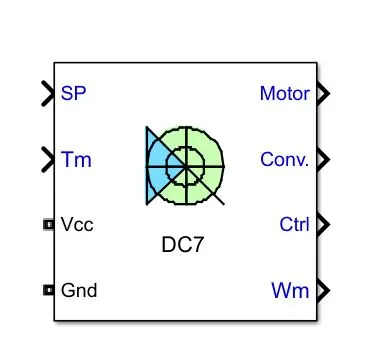
It has four input ports, two of them represents voltage input and output and other two represents torque and speed set points. this block gives multiple outputs which can be distinguished using bus selector.
The four quadrant chopper DC drive(DC7) circuit diagram
BJT H-bridge model
Comparison between four quadrant chopper and BJT H-bridge model–
- H-bridge model works in a open loop, means there is no arrangement of feedback, which demands current according to armature requirement, but DC7 model works in close loop.
- Four quadrant has high switching frequency compare to H- bridge model.
- DC7 model is very complex because it has extra components to work on feedback.
Study 3 - Make a suitable EV model using DC7 block and make result report.
Model description – Motor has a four quadrant Chopper DC drive block, which is working in a close loop system. It takes DC voltage source, reference speed and toque values as input and gives motor parameters as output.
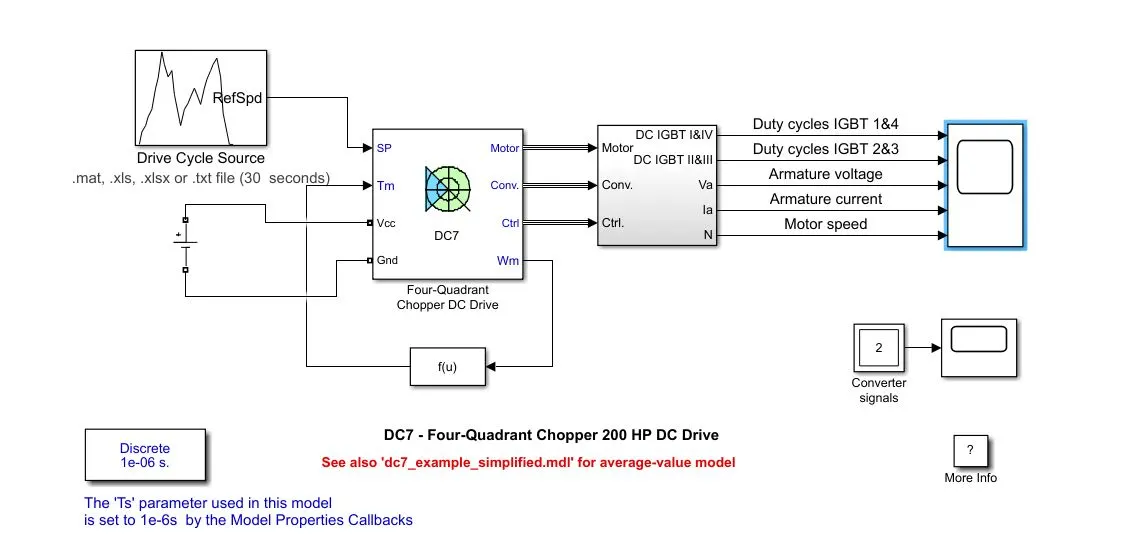
We are going to give driving cycle as reference speed, vehicle characteristic equation Toque = 24.7+0.0051(ω^2)
For torque values and DC voltage to run motor. Chopper will manipulates armature current according to torque values.
Results-
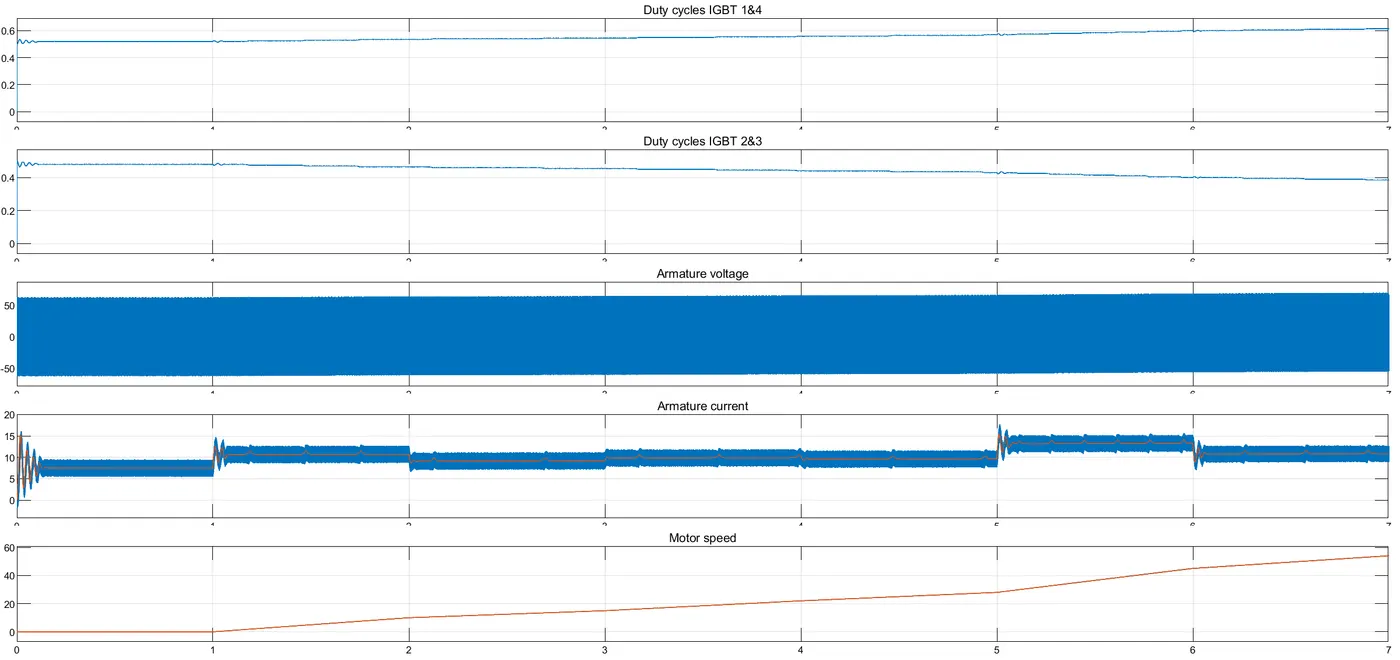
By observing the plot we can say motor current varies according to demand, which is defined by torque equation.