Week-7 Challenge: DC Motor Control
1. Speed Control of DC motor using BJT H-Bridge.
The Bipolar Junction Transistor (BJT) when used for power switching applications, operates as an IGBT. When it is conducting (BJT operating in the saturated region), a forward voltage Vf is developed between collector and emitter (in the range of 1 V). Therefore, the IGBT block can be used to model the BJT device.
The IGBT block does not simulate the gate current controlling the BJT or IGBT. The switch is controlled by a Simulink signal (1/0). The DC motor uses the preset model (5 HP 24V 1750 rpm). It simulates a fan type load (where Load torque is proportional to square speed). The armature mean voltage can be varied from 0 to 240 V when the duty cycle (specied in the Pulse Generator block) is varied from 0 to 100%.
The H-bridge consists of four BJT/Diode pairs (BJT simulated by IGBT models). Two transistors are switched simultaneously: Q1 and Q4 or Q2 and Q3.
When Q1 and Q4 are red, a positive voltage is applied to the motor and diodes D2-D3 operate as free-wheeling diodes when Q1 and Q4 are switched off.
When Q2 and Q3 are red, a negative voltage is applied to the motor and diodes D1-D4 operate as free-wheeling diodes when Q2 and Q3 are switched off.
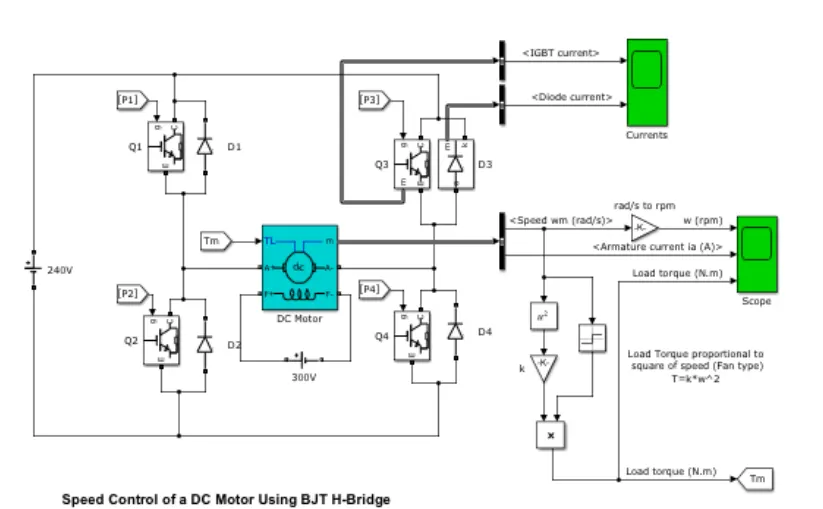
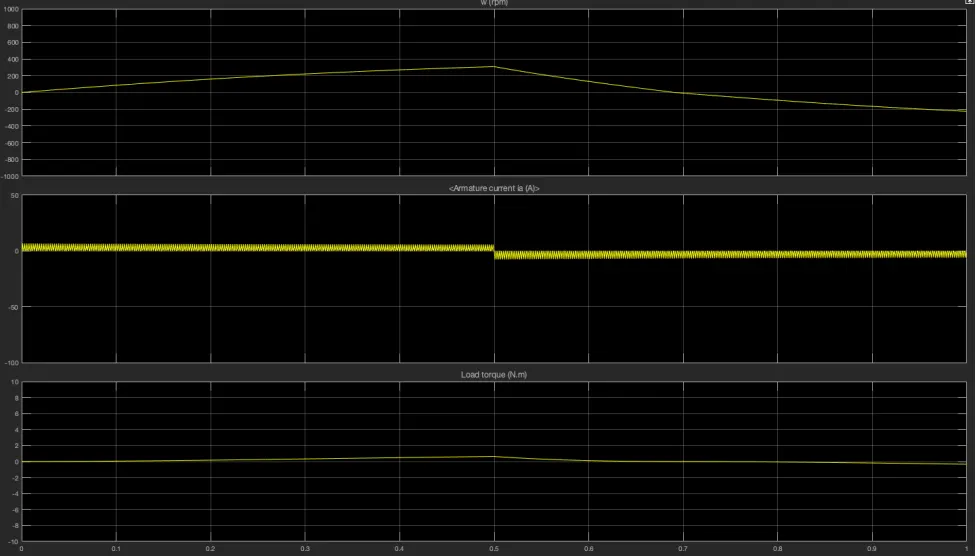
The motor starts in the positive direction with a duty cycle of 75% (mean DC voltage of 180V). At t= 0.5 sec., the armature voltage is suddenly reversed and the motor runs in the negative direction.
'Scope' shows motor speed, armature current and load torque and 'Currents' shows currents owing in BJT Q3 and diode D3.
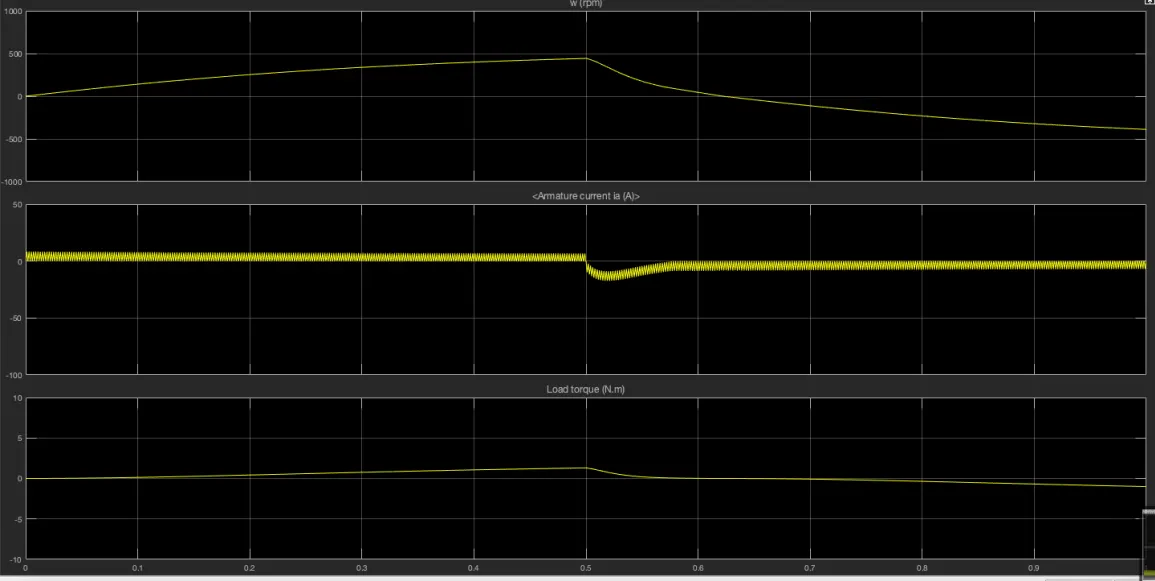
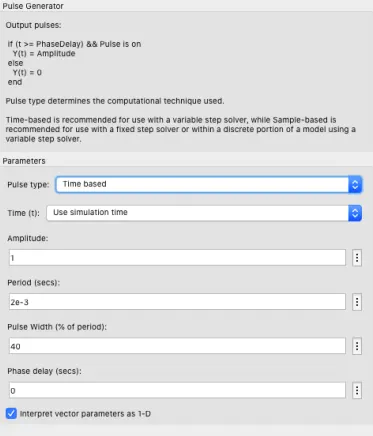
Inorder to avoid the armature current shoot up, we can change the pulse width as follows from 75 to 40 :
The results obtained are as follows :
2. The Four-Quadrant Chopper DC Drive (DC7) block’ and its comparison it with H-bridge model.
The four quadrant model -
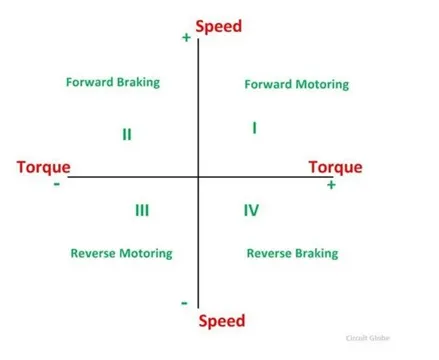
- I quadrant - power developed is positive and the machine is working as a motor supplying mechanical The I (first) quadrant operation is called Forward Motoring.
- II quadrant - In this quadrant the direction of rotation is positive, and the torque is negative, and thus, the machine operates as a generator developing a negative torque, which opposes the motion and it is called Forward
- III quadrant - The motor works, in the reverse Both the speed and the torque have negative values while the power is positive and it is called Reverse Motoring.
- IV quadrant - The torque is positive, and the speed is This quadrant corresponds to braking in the reverse and it is called Reverse Braking.
The Four-Quadrant Chopper DC Drive (DC7) block -
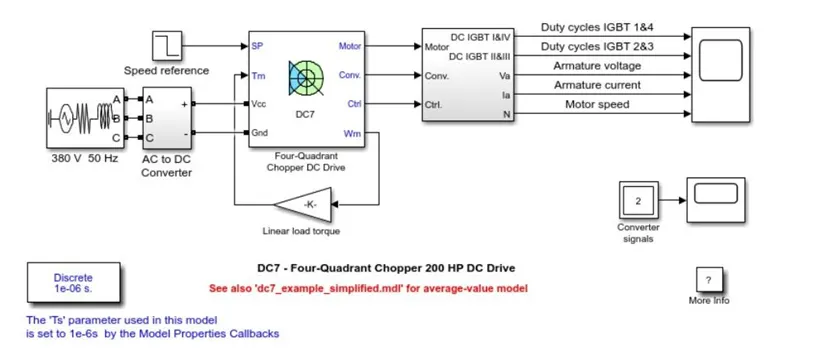
Simulation parameters:
Before starting the simulation, set the initial bus voltage to 515 V via the GUI block ('Initial States Setting' button and 'Cbus' variable).Start the simulation. You can observe the motor armature voltage and current, the four IGBT pulses and the motor speed on the scope. The current and speed references are also shown.The motor is coupled to a linear load, which means that the mechanical torque of the load is proportional to the speed.
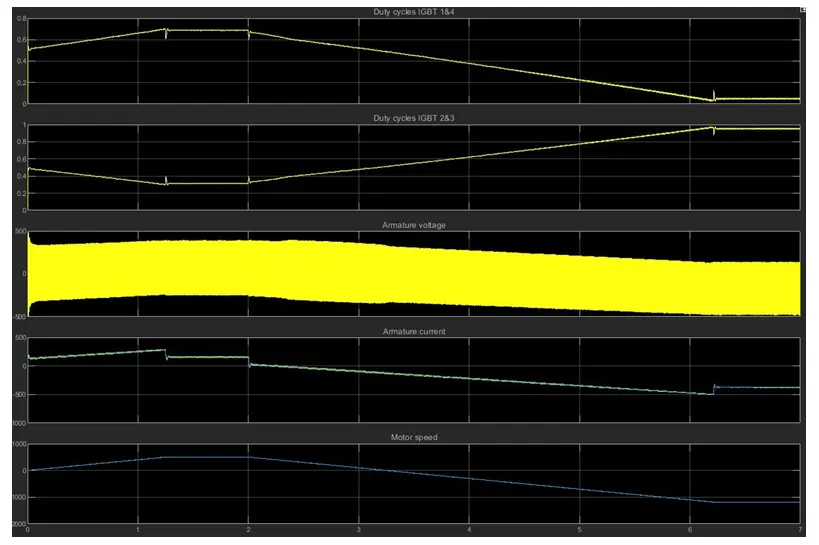
The speed reference is set at 500 rpm at t = 0 s. Observe that the motor speed follows the reference ramp accurately (+400 rpm/s) and reaches steady state around at t=1.3s.
The armature current follows the current reference very well, with fast response time and small ripples. Notice that the current ripple frequency is 5 kHz.
At t = 2 s, speed reference drops to -1184 rpm. The current reference decreases to reduce the electromagnetic torque and causes the motor to decelerate with the help of the load torque.
At t = 2.2 s, the current reverses in order to produce a braking electromagnetic torque (dynamic braking mode). This causes the DC bus voltage to increase.
At t = 3.25 s, the motor reaches 0 rpm and the load torque reverses and becomes negative. The negative current now produces an accelerating electromagnetic torque to allow the motor to follow the negative speed ramp (-400 rpm/s). At t = 6.3 s, the speed reaches -1184 rpm and stabilizes around its reference.
Results:
Comparision between H-bridge and Four Quadrant DC chopper:
- Control strategy -
In H-bridge we need to reverse the polarity to change the direction but in Four quadrant DC drive it uses reference speed to change the direction of motor rotation.
PI Controllers are used for speed and current control in Four quadrant DC drive which is absent in H bridge.
2. Armature current stability -
The current shootup and disturbances are high in H-Bridge because of the switching losses.
3. Operation -
Forward and Reverse motoring are the only two operations that the H-Bridge can perform.
The Four quadrant DC drive operates in four modes forward motoring, reverse motoring,forward braking and reverse braking. Also it can perform regerative braking as well which a H bridge cannot do.
3. Make a suitable EV model using DC7 block and make result report.
An EV model can be simulated using the DC7 example block with an couple of changes. Lets look at the changes that need to be made.
1. Modify energy source at input side -
Since the battery is source of fuel for an electric vehicle, a DC voltage source block is placed on the input with a supply voltage of 300V.
2. Reference speed -
A drive cycle input needs to replace the step signal block. In this case a custom drivecycle saved in excel file is imported unto a drive cycle block.
3. Linear load torque :
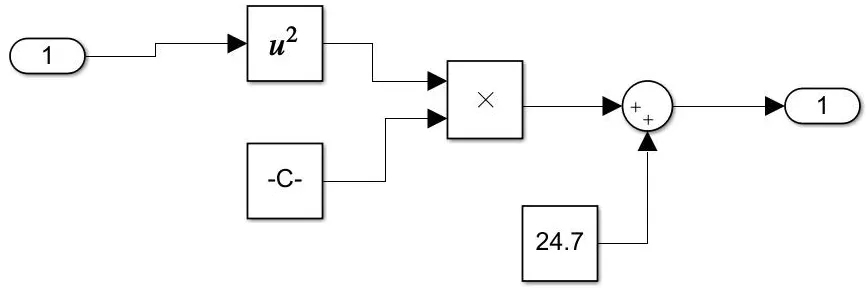
The linear load torque can be replaced by a subsystem model according to the load characteristic given by the equation T = 24.7 + 0.0051 * (w)^2
where w is the angular speed of the motor.