Week-7 Challenge: DC Motor Control
1)
The DC motor speed control using Bipolar junction transistor the BJT is use as a switch and the switch is controlled through pwm signal. There are more switches are available in market but everyone has its own use. Each switch has its own specification based on requirement we use it.we will discuss two switch IGBT and MOSFET.
- MOSFET: metal oxide semiconductor field effect transistor is mostly use for the high frequency application. There are two types of the MOSFET depletion mode and enhancement mode.in depletion mode the gate source voltage is less than the threshold voltage and in enhancement mode the gate source voltage is greater than the threshold voltage. MOSFET is voltage controlled.
- IGBT: insulated gate bipolar junction transistor is the combination of the mosfet and bjt. The voltage is controlled through gate terminal. It is current controlled. That switch is use when the high power switching application. In my simulation I am use the IGBT switch to control the DC motor.
In my simulation of the DC motor controlled through pwm signal. We can change the duty cycle based on our requirements. The pwm signal is applied to controlled switches through that we can control the negative speed of the motor is control through h bridge.
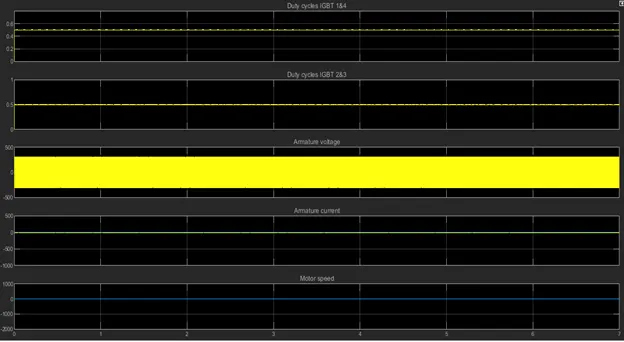
I am change the duty cycle 75% then we get the result display below.
I am change the duty cycle at 45 % then get response asa
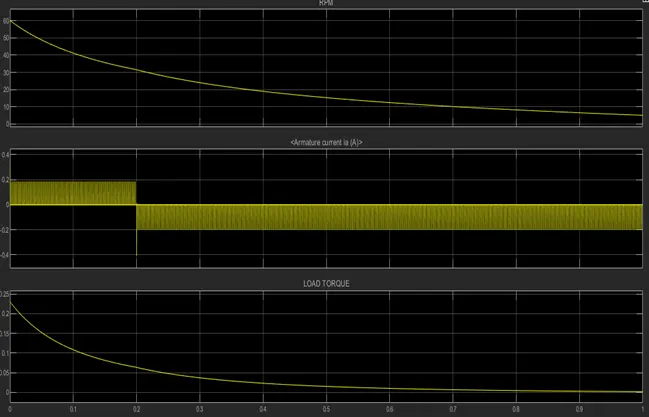
When positive supply apply to the motor then Q1 and Q4 is activate and Q3 and Q2 is active from negative supply voltage then motor is act as a reverse bias then we want to apply H bridge for negative supply is apply then it act as a positive. Means we get the armature current is reverse.
2.
DC 7 model of the four quadrant operator in which we study the four quadrant operation.
- in first quadrant torque and speed is positive then vehicle is accelerating. Then vehicles is moving in forward direction.
- In second quadrant torque is negative and speed is positive then vehicle is operate as a regenerative breaking.
- In third quadrant torque and speed both are negative then reverse moving.
- in fourth quadrant the torque is positive and speed is negative means reverse breaking happen.
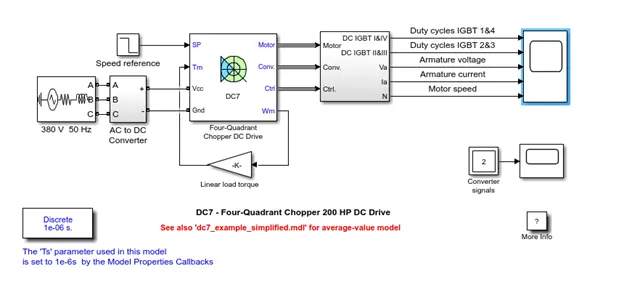
In this system we use the four quadrant chopper DC drive and we use the PI controller to control the speed of the motor and use IGBT switches for rectifier. And we get the results
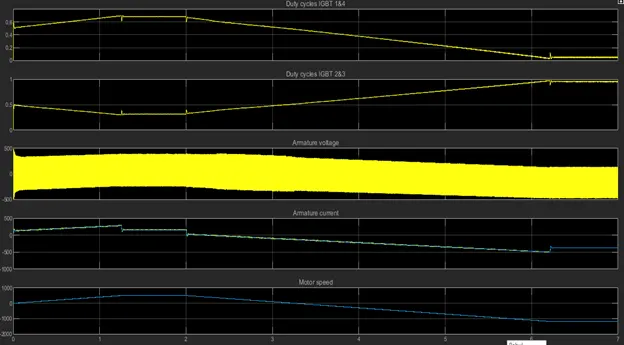
Comparison of h bridge and four quadrant chopper operation
|
Four Quadrant Chopper |
H bridge |
|
Operation in four quadrant |
Operation in two quadrant |
|
Better control of vehicle |
Less control of vehicle |
|
Signals are interrupted to change the direction |
Polarity is change to change the direction of motor |
|
Signal are Discrete |
Signals are Continuous. |
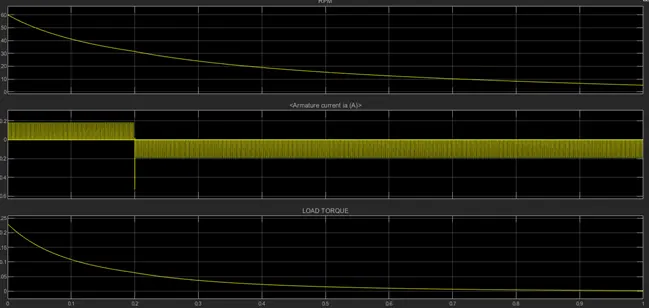
3) I was design the vehicle using four quadrent chopper and get response
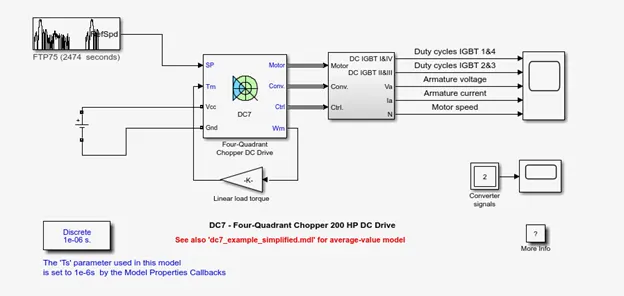
I was design the electric vehicle with DC voltage source and get a response as