Week 7 Challenge - Assembly Workbench
Assembly Workbench
OBJECTIVE:
To create CV Joint and Quick Return Mechanism parts in the part workbench with the help of given 2D Drawings and assemble them following guidelines.
INTRODUCTION:
1. CV Joint:
A constant velocity(CV) joint, also known as a Homokinetic joint, is a mechanical coupling that allows the shafts to rotate freely(without an appreciable increase in friction or backlash) and compensates for the angle between the two shafts, within a certain range, to maintain the same velocity.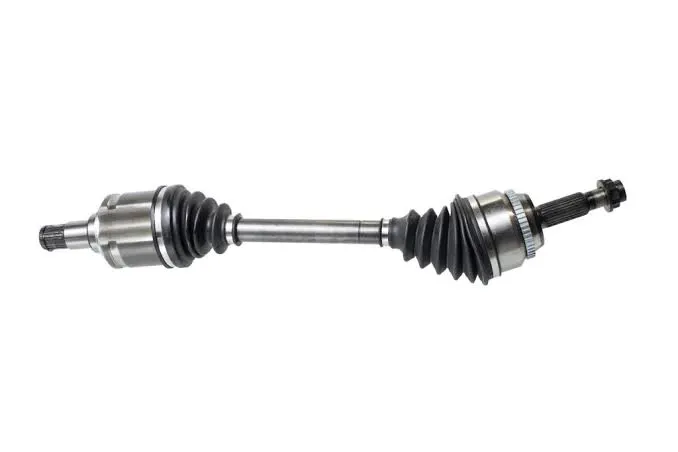
which allows a drive shaft to transmit power through a variable angle, at a constant rotational speed, They are mainly used in front-wheel drive vehicles. Modern rare-wheel drive cars with independent rear suspension typically use CV joints at the ends of the rear axle half shafts and increasingly use them on the drive shaft.
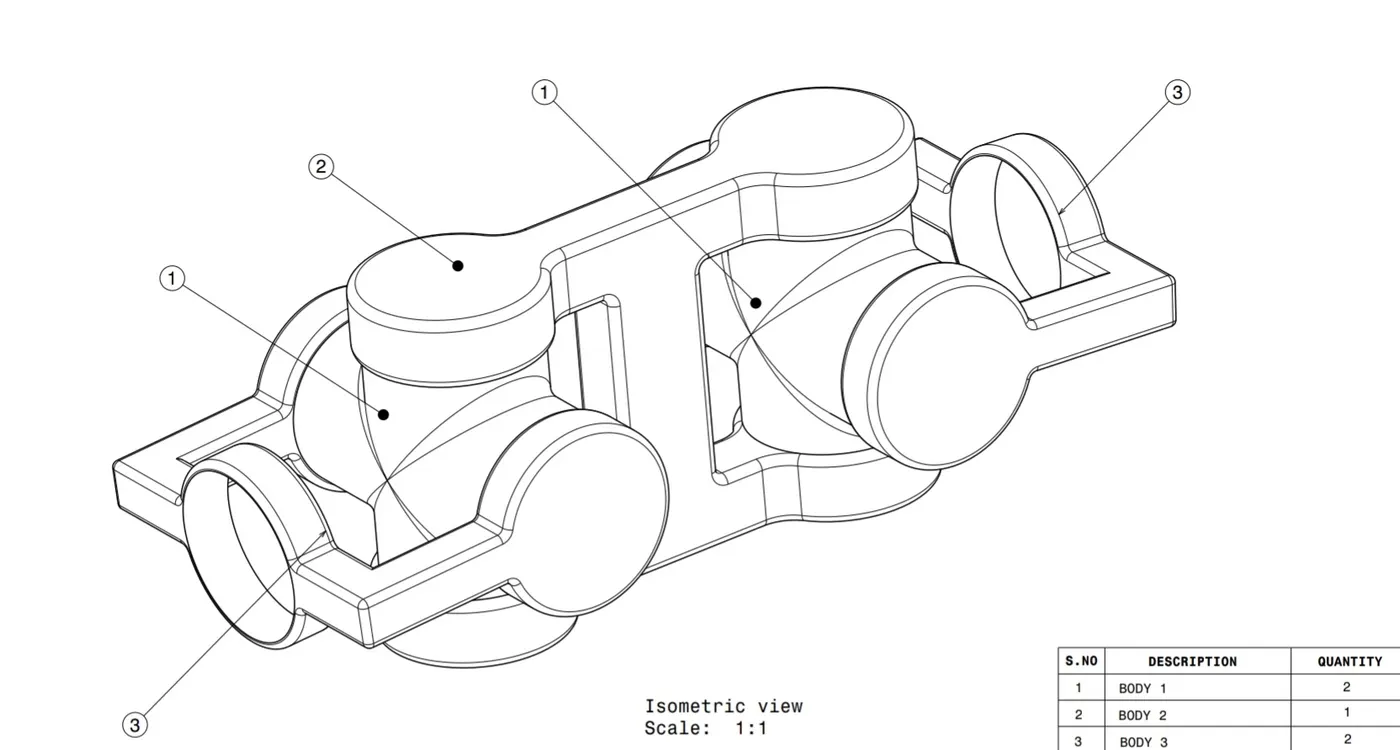
All the parts of the CV joint are created separately with the help of the given 2D drawings. and they are using the Boolean method to make all the parts.
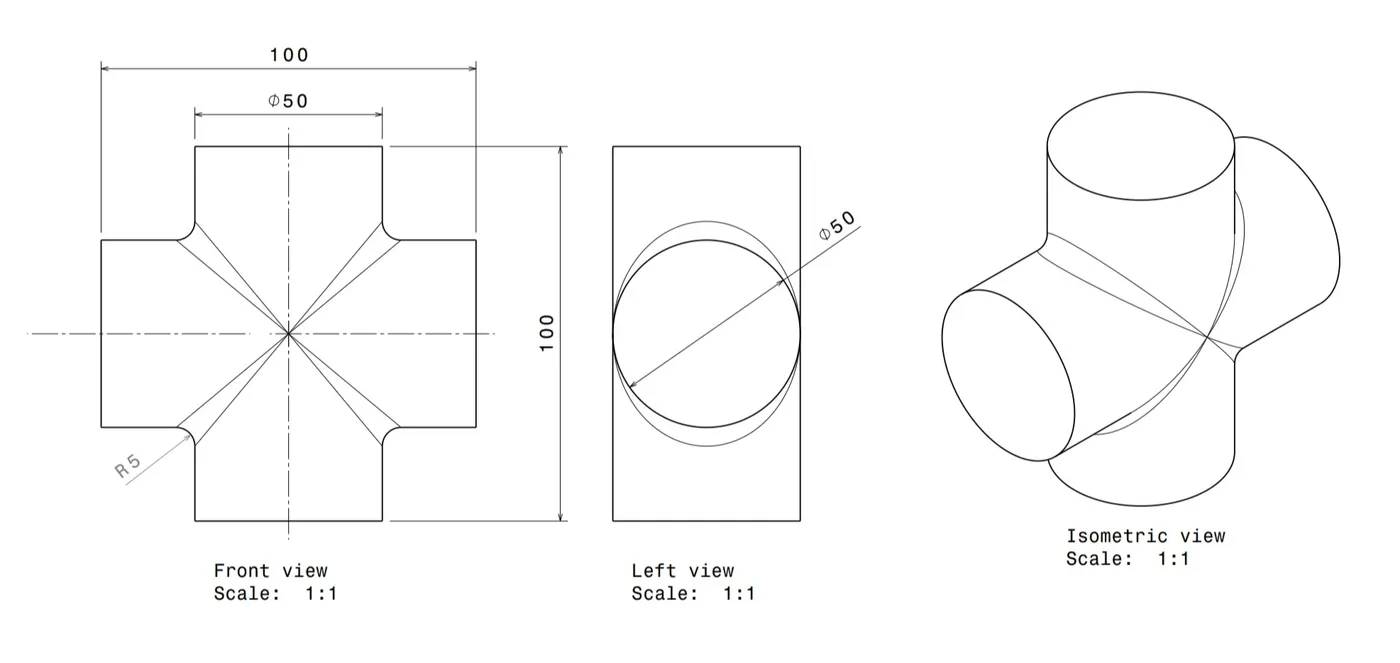
1. BODY-01
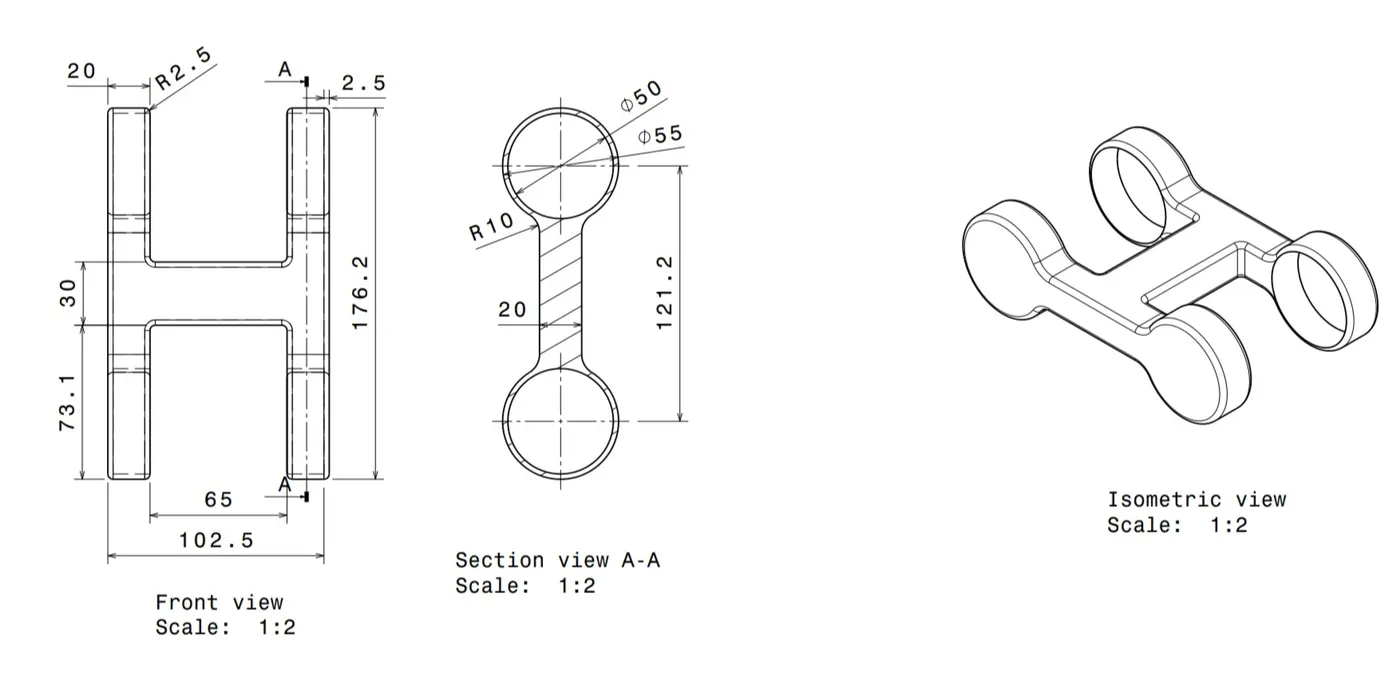
- Given Dimensional 2D Drawing
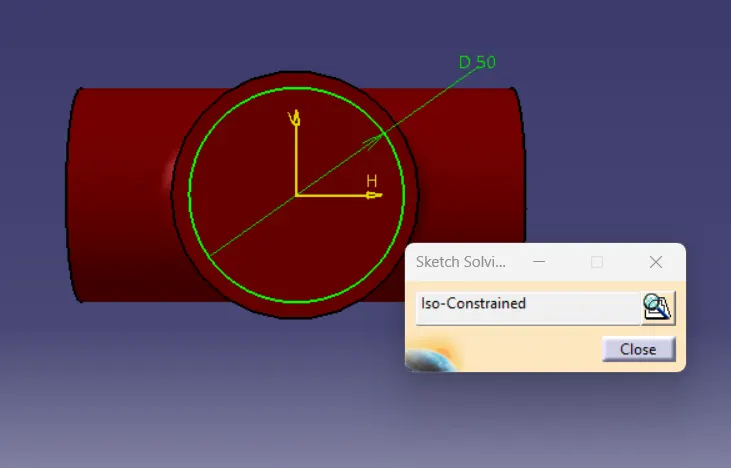
- Sketch
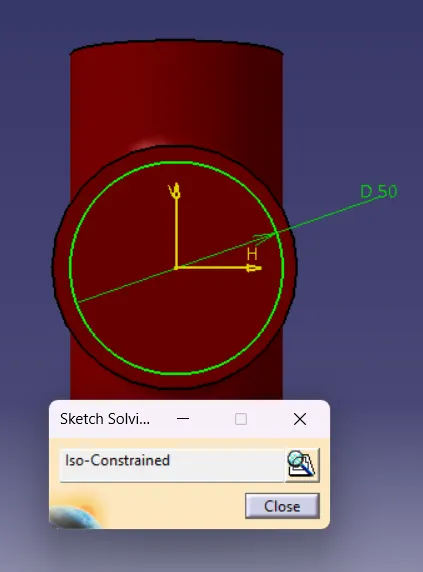
- Final Body with Construction Tree
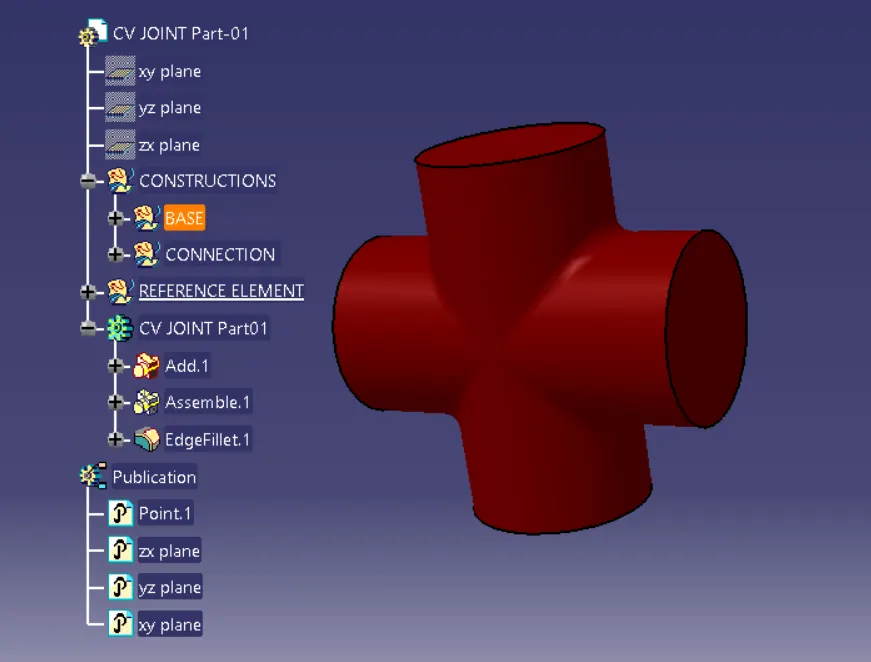
2. BODY-02:
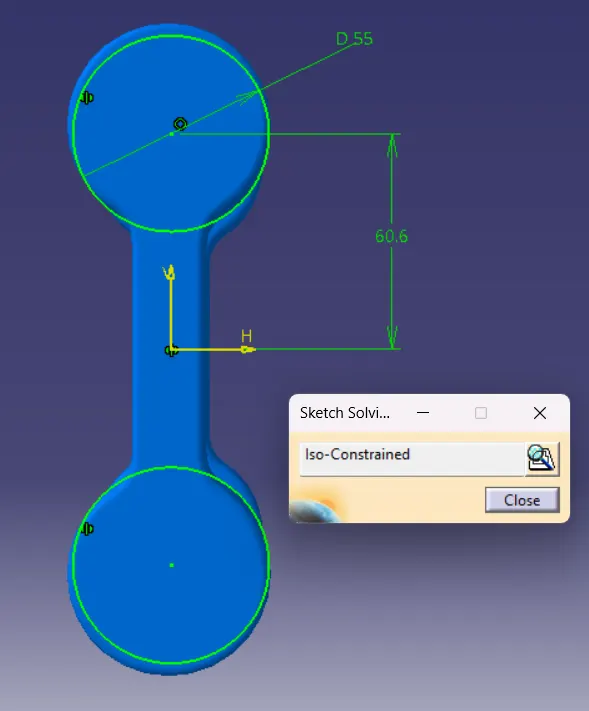
- Sketch
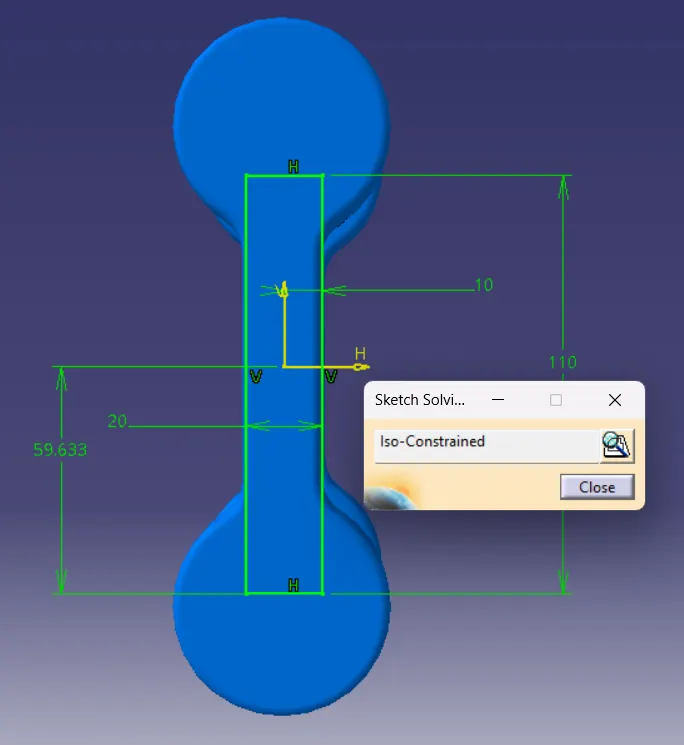
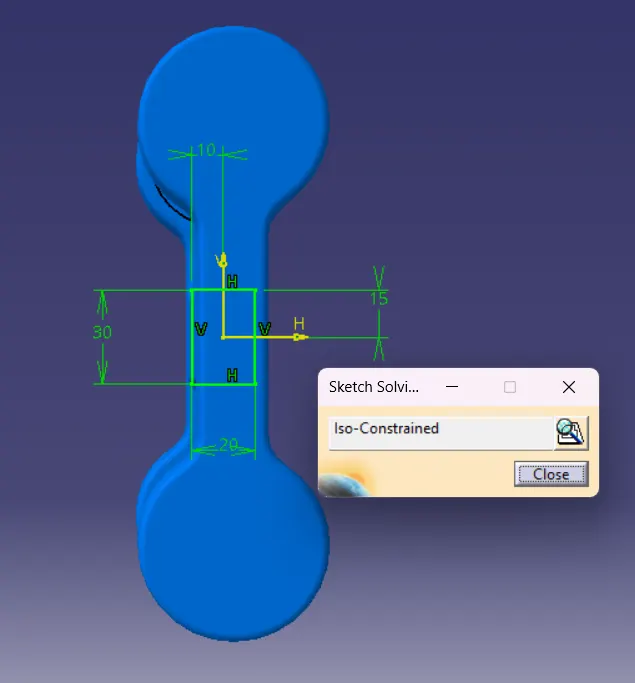
- Final Body with Construction Tree
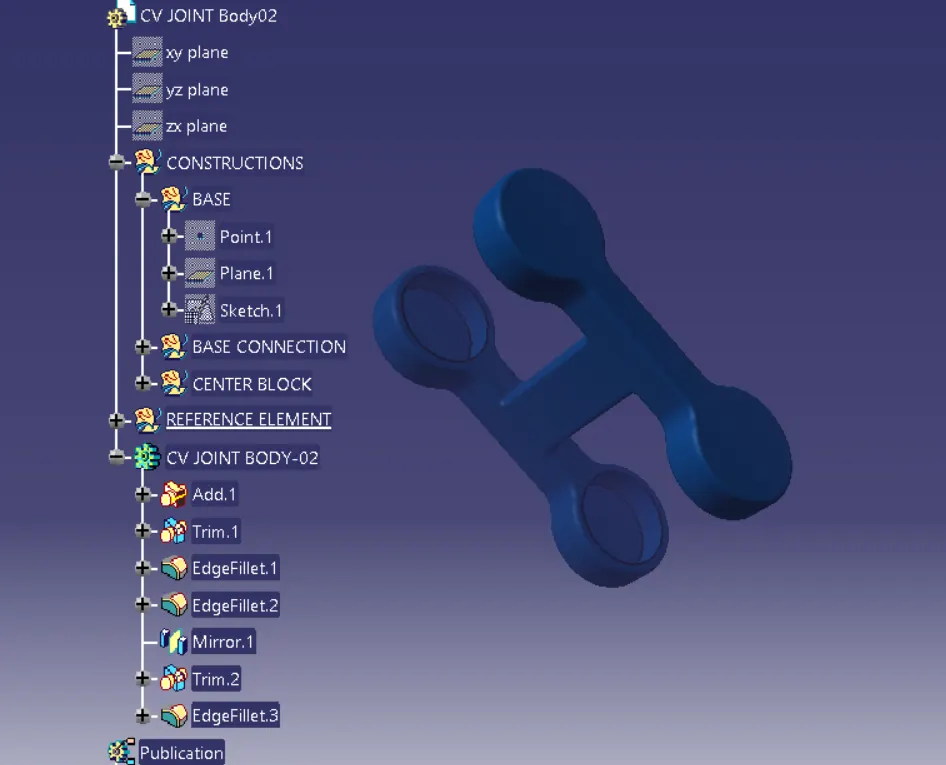
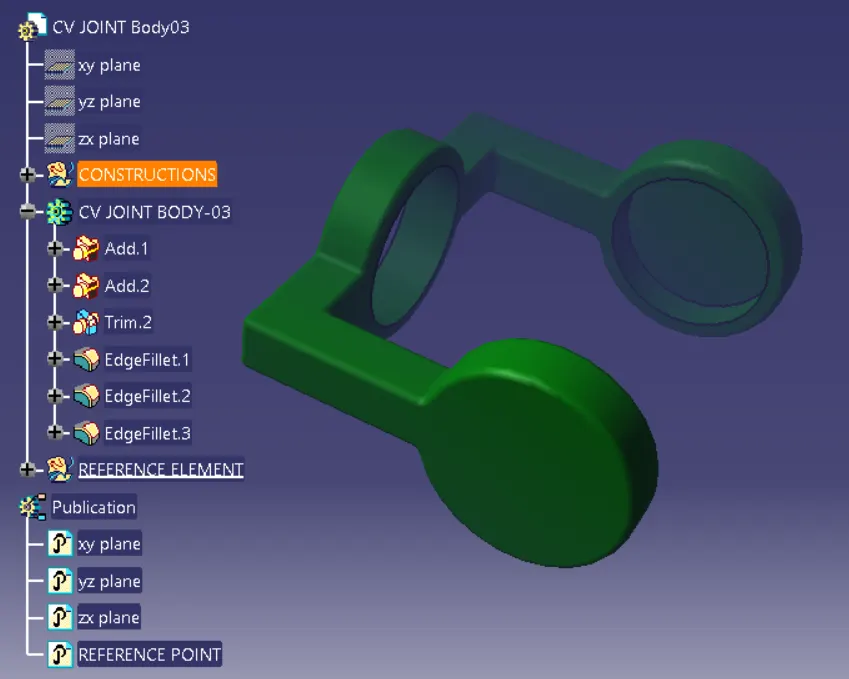
3. BODY-03:
- Given Dimensional 2D Drawing
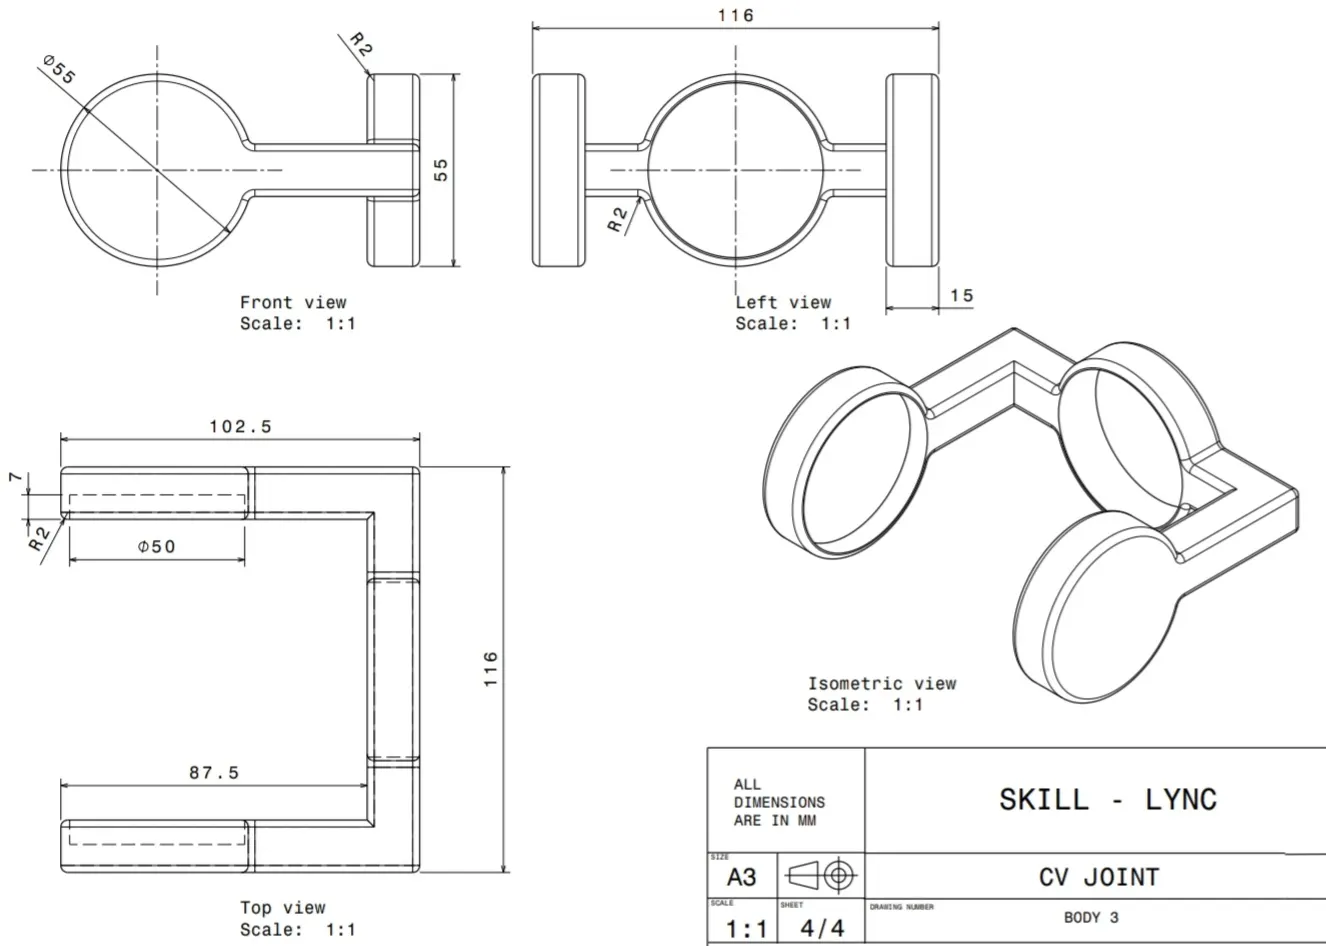
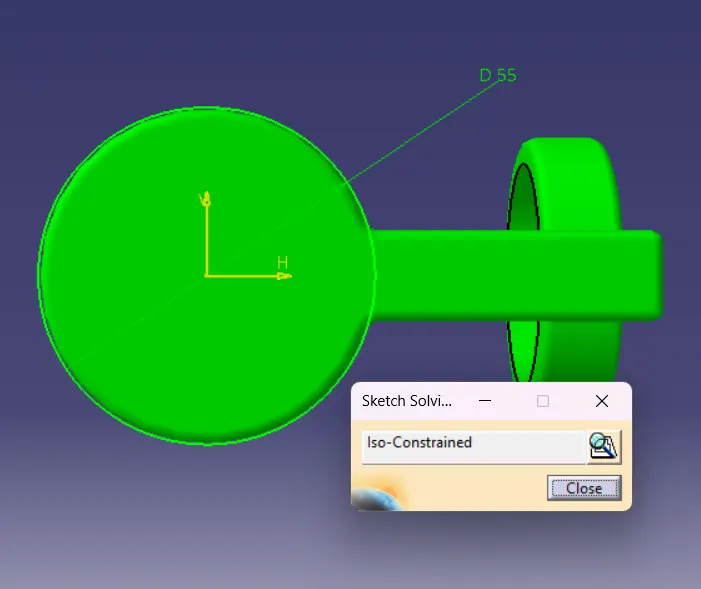
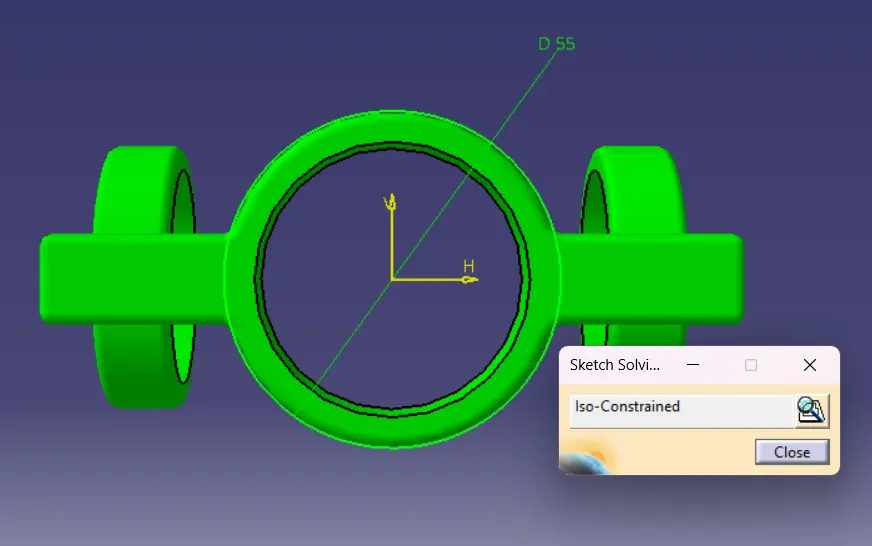
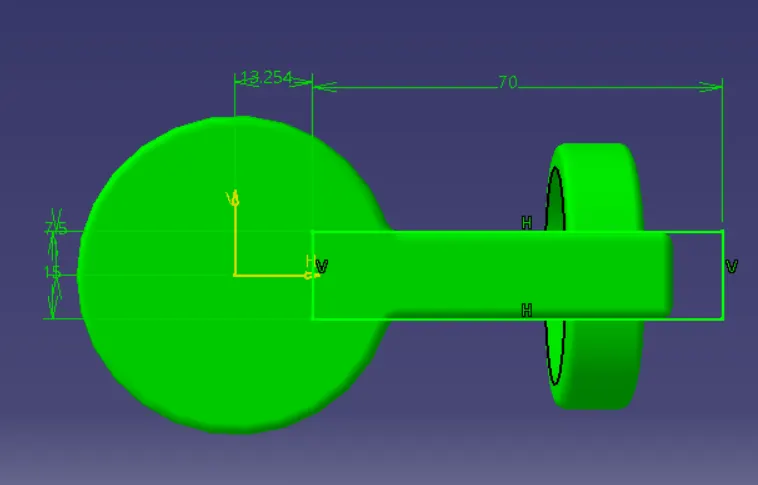
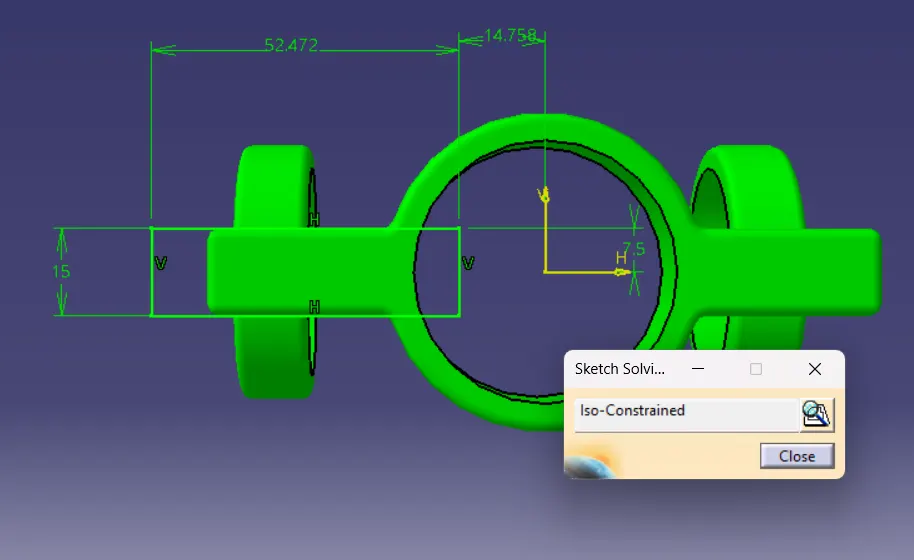
- Sketch
ASSEMBLY:
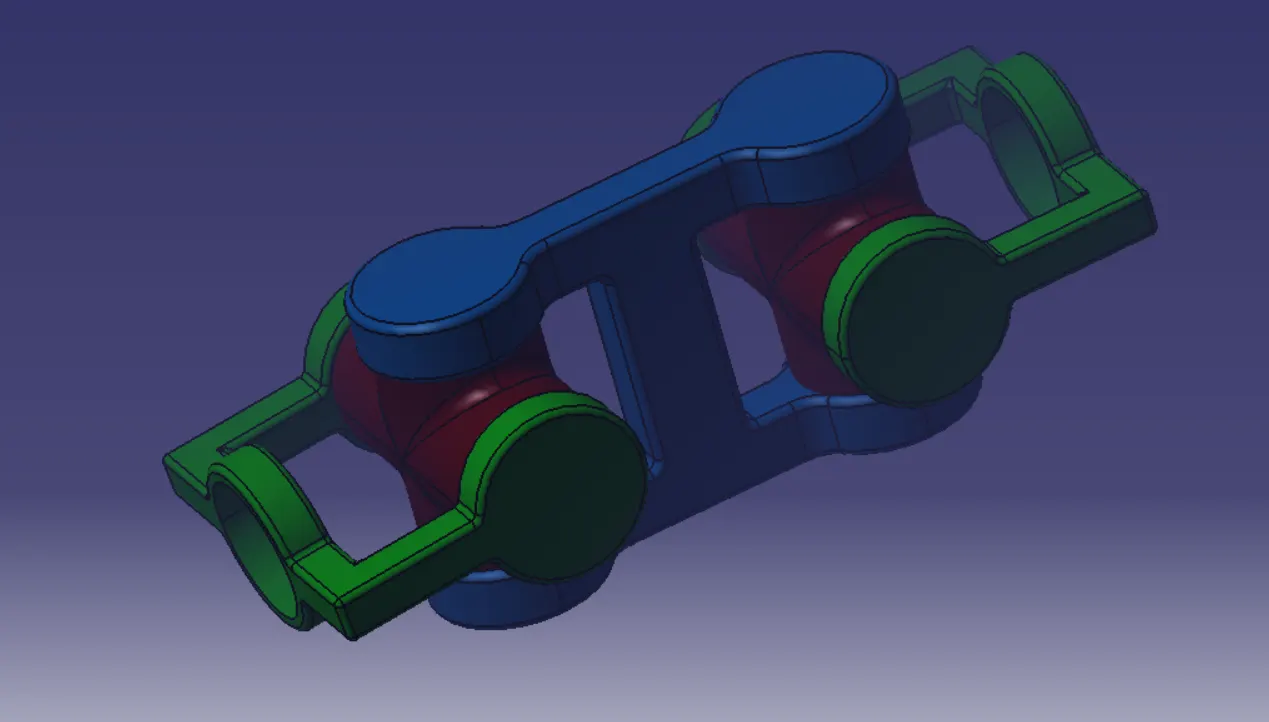
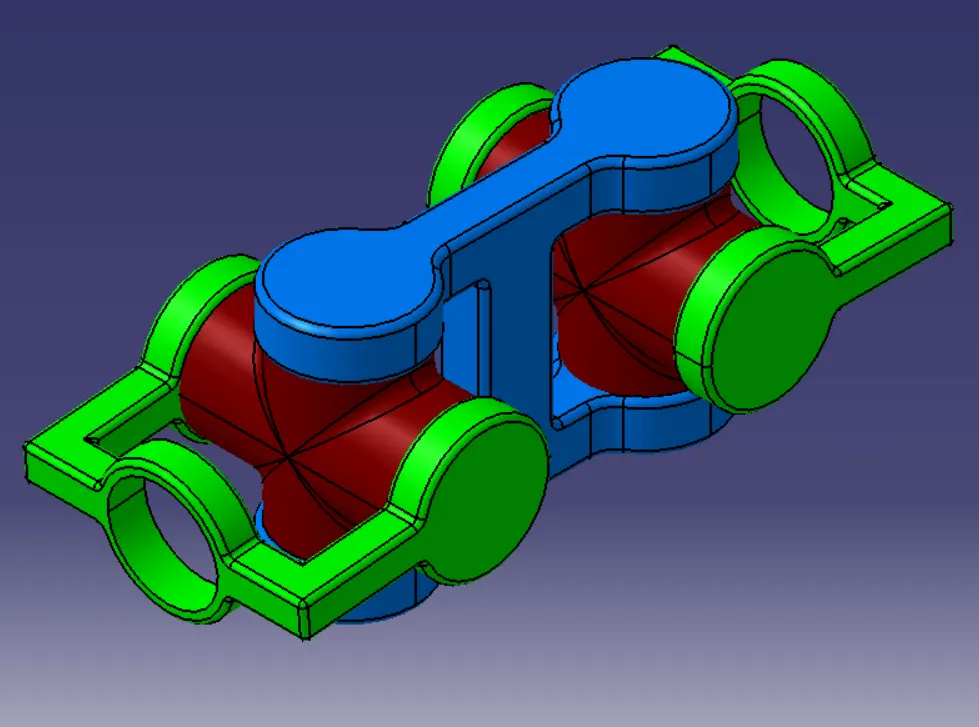
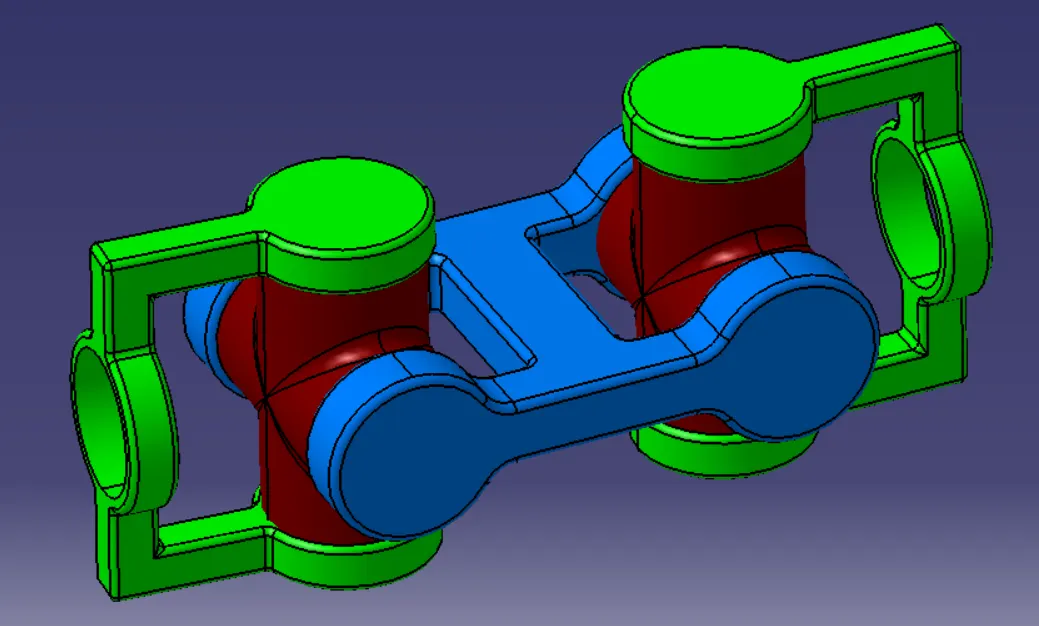
The following steps are involved in the CV Joint assembly.
- The assembly process is carried out in the assembly workbench and the assembly file has CATProduct as its extension.
- The assembly of the CV Joint starts with referencing the reference elements created at the part level.
- The reference points and planes are published at the part level for ease of access in the assembly workbench. Those publications are child feathers, if the parent features are modified in the part level its publications also get modified.
- Previously created parts are opened in the assembly workbench as child product features, and then a new part is created to serve as an assembly reference.
- This assembly reference is fixed to the arrest its all degrees of freedom to hold the parts together.
- After the fixation, the parts are assembled by giving coincident and offset relations to the appropriate planes and points.
2. QUICK RETURN MECHANISM:
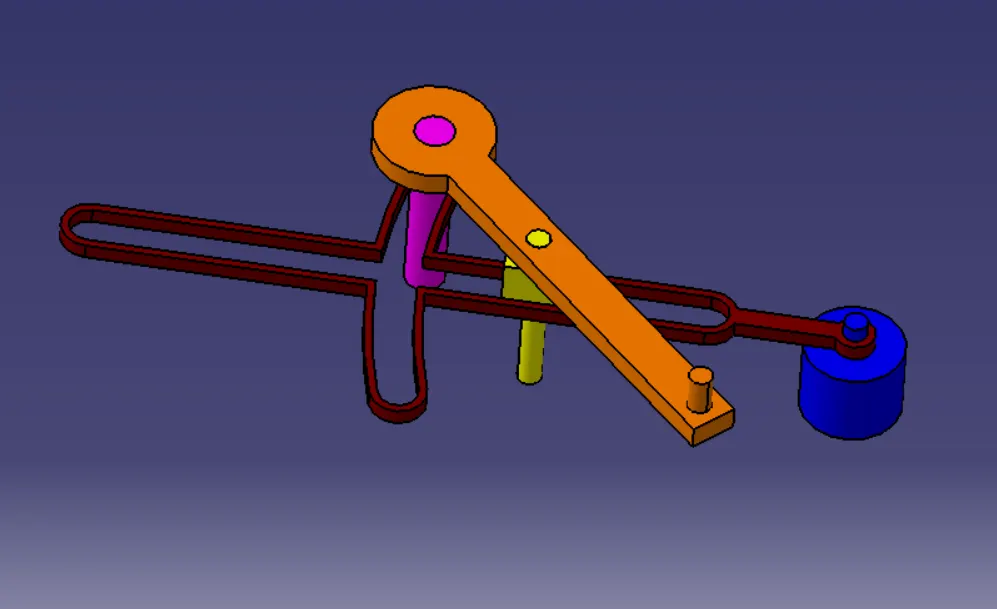
A quick return mechanism is an apparatus to produces a reciprocating motion in which the time taken for travel in the return stroke is less than in the forward stroke. It is driven by a circular motion source(typically a motor of some sort) and uses a system of links with three turning pairs and a sliding pair.
Quick return is a common feature of tools in which the action is performed in only one direction of the stroke, such as shapers and powered saws, because it allows less time to be spent on returning the tool to its initial position.
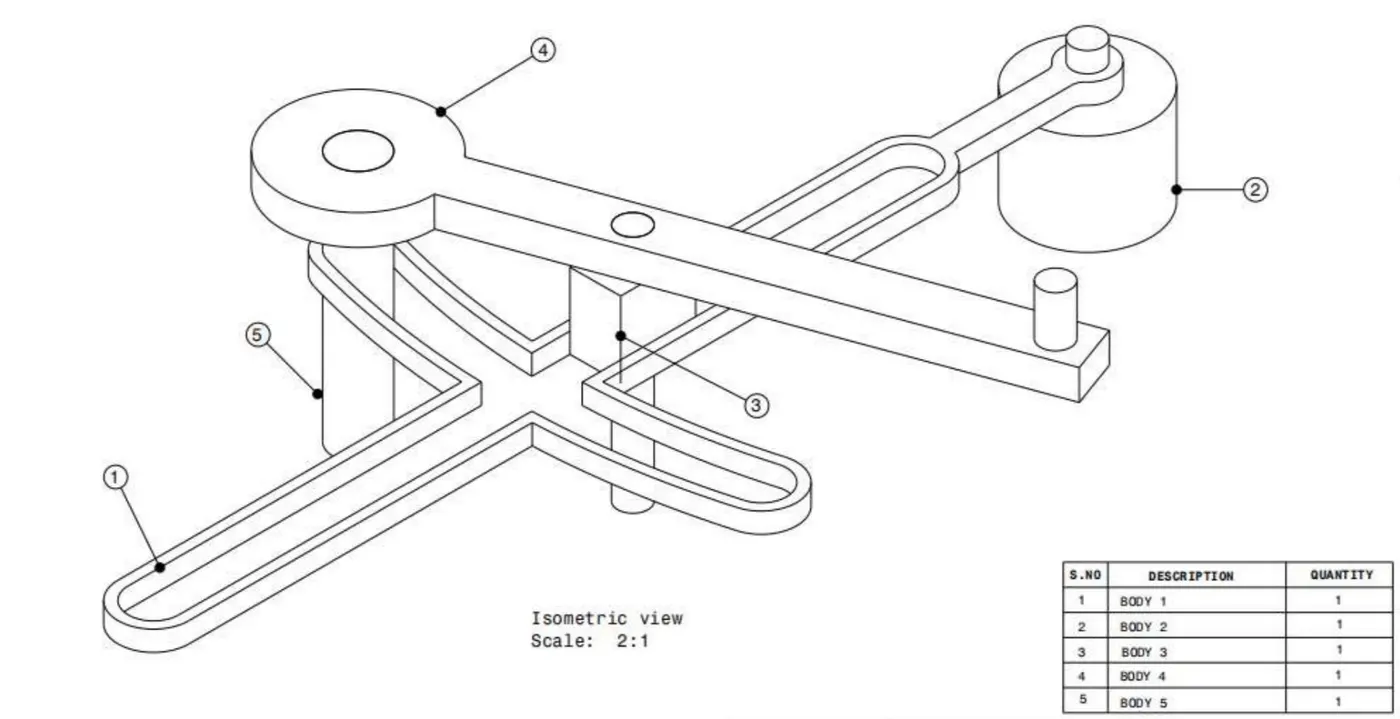
Quick return mechanism parts:
For the given quick return mechanism there are five parts are there.
- Slotted link
- Pivot block
- Sliding block
- Crank
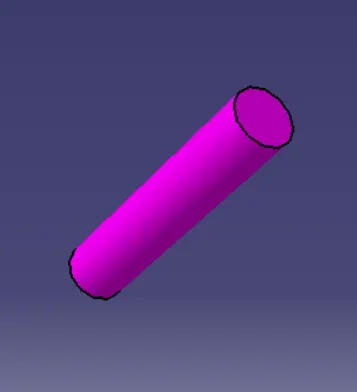
- Pin
All the parts of the quick return mechanism are created separately with the help of the given 2D drawings. and they are using the Boolean method to make all the parts.
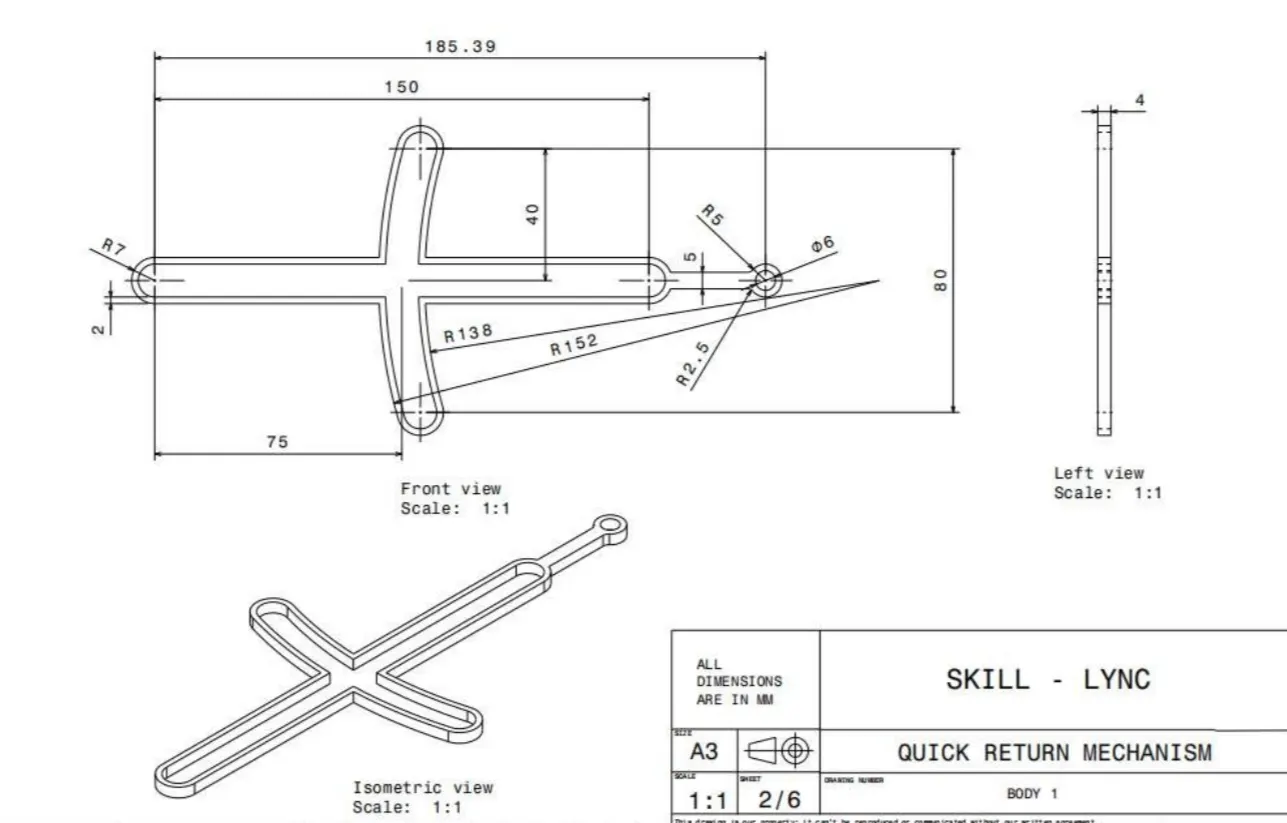
1. BODY-01
- Given 2 Dimensional Drawing
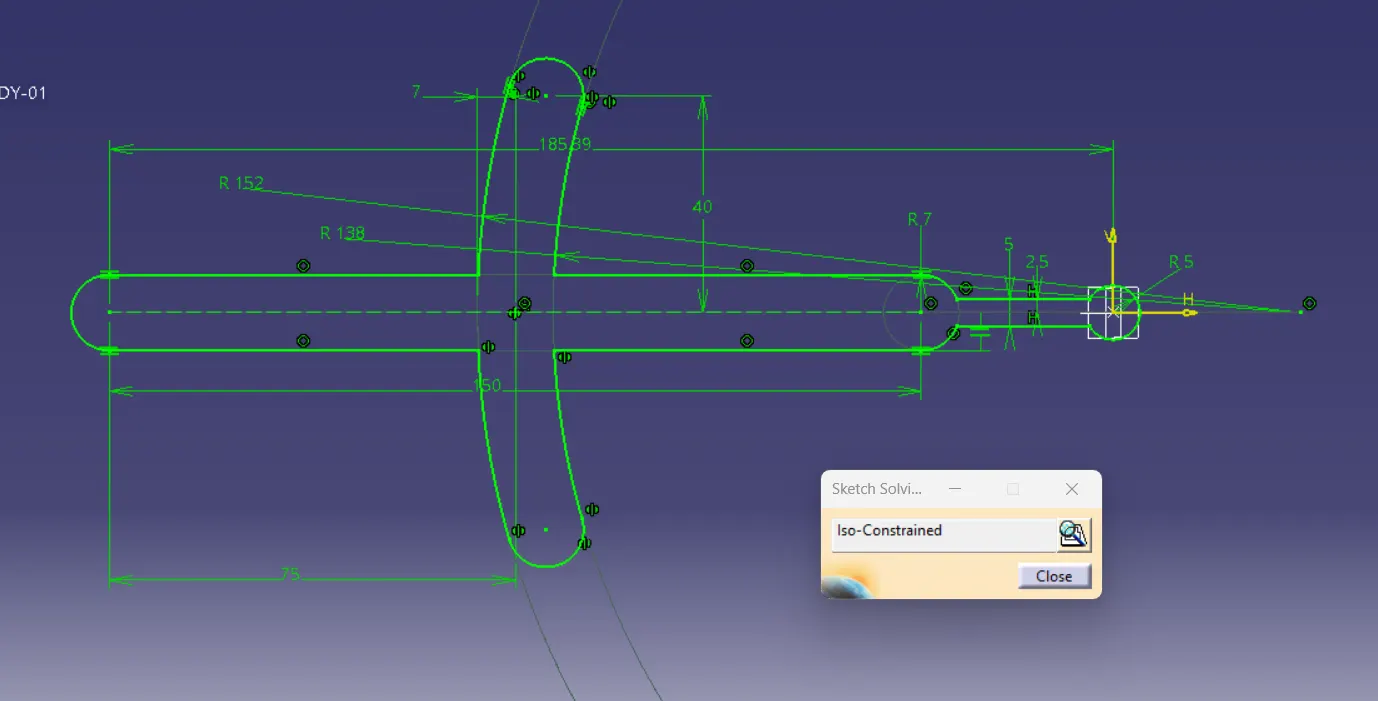
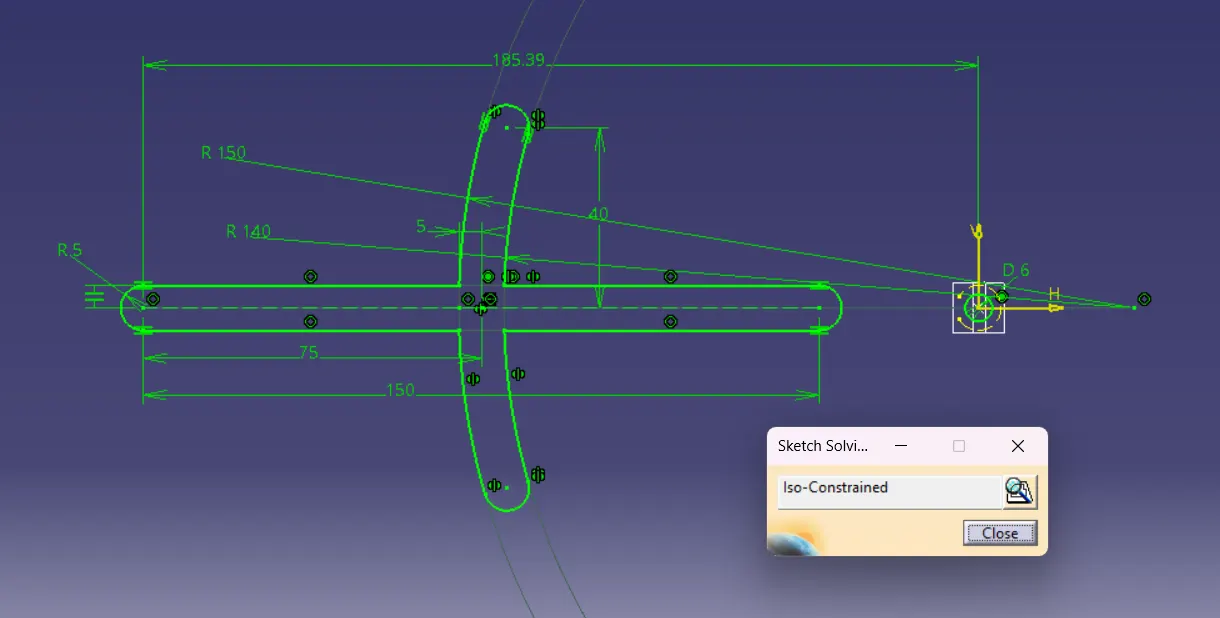
- Sketcher Workbench
- The tree structure of the Slotted link :
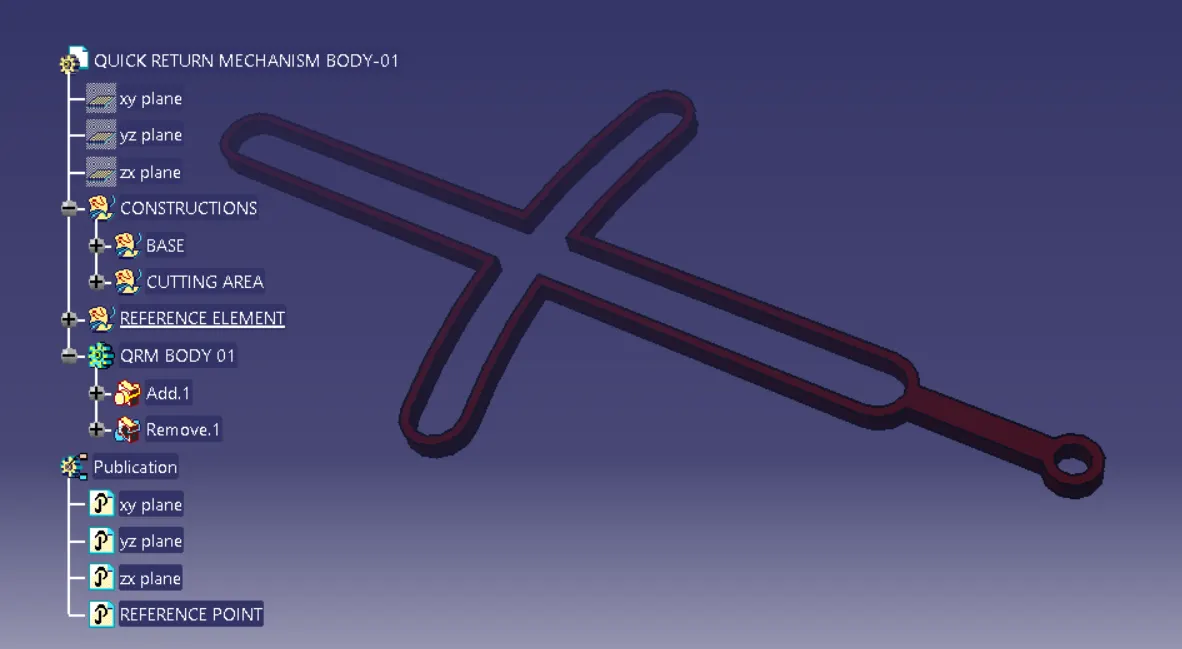
- The final Body of the Slotted link :
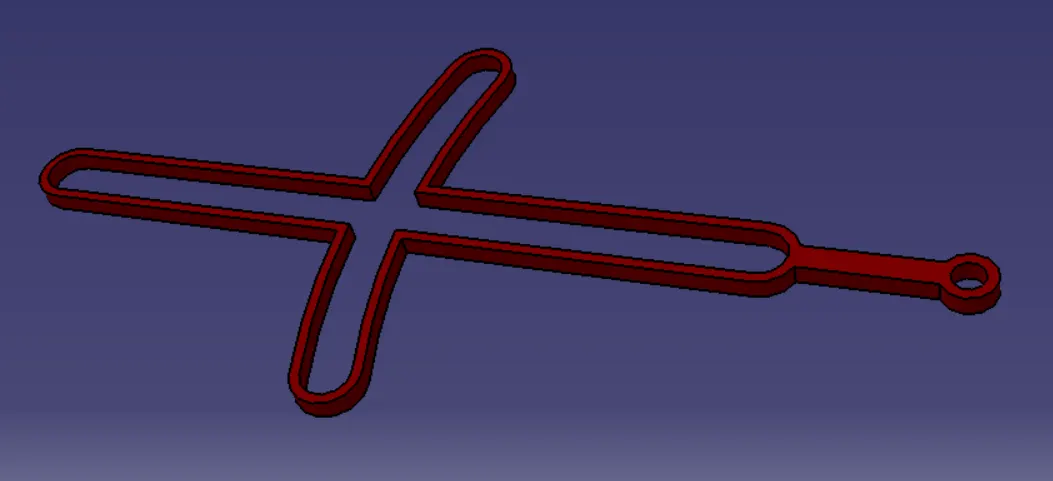
2. BODY-02
- Given 2 Dimensional Drawing
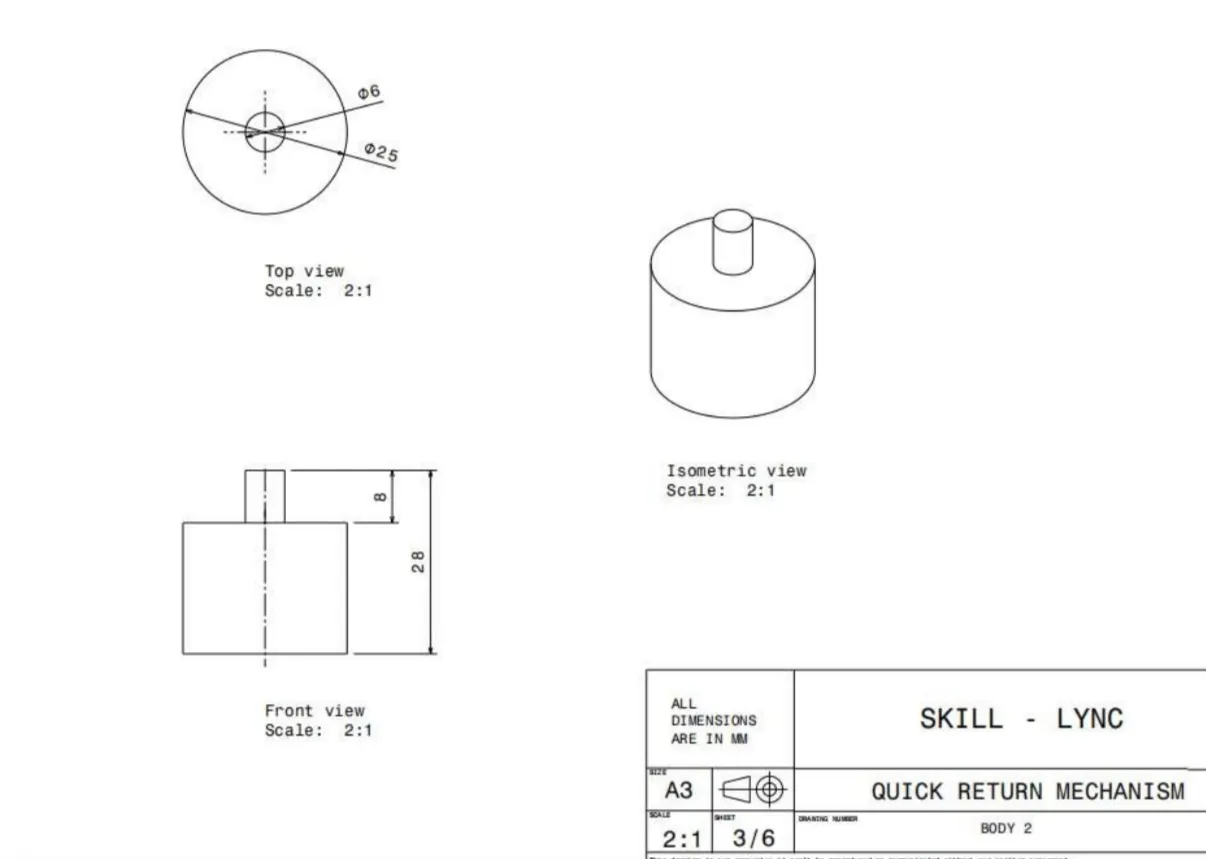
- Sketcher Workbench
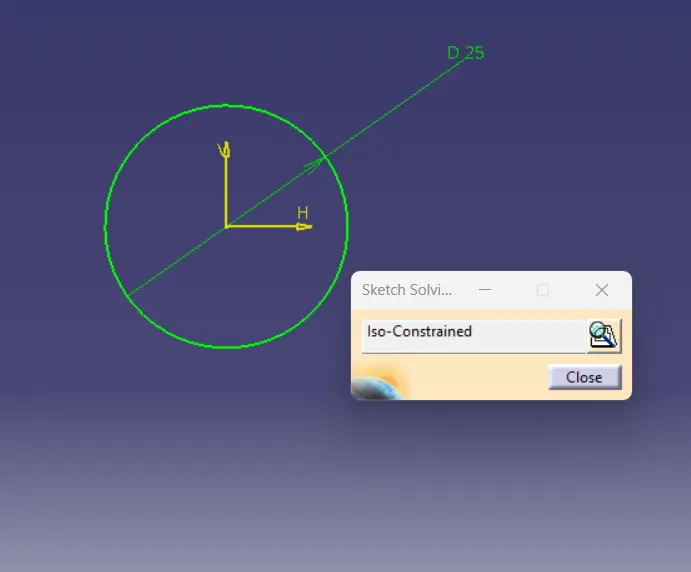
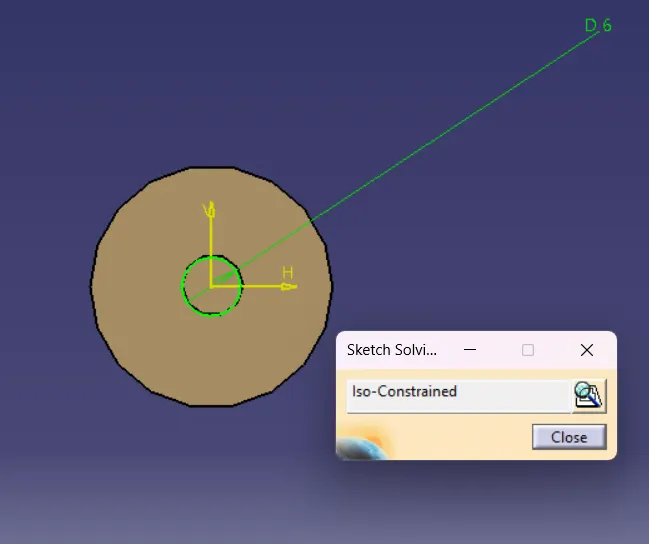
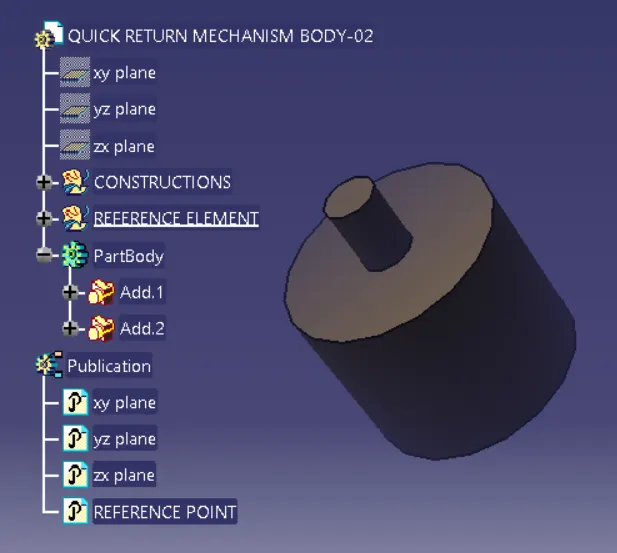
- The tree structure of the Pivot block :
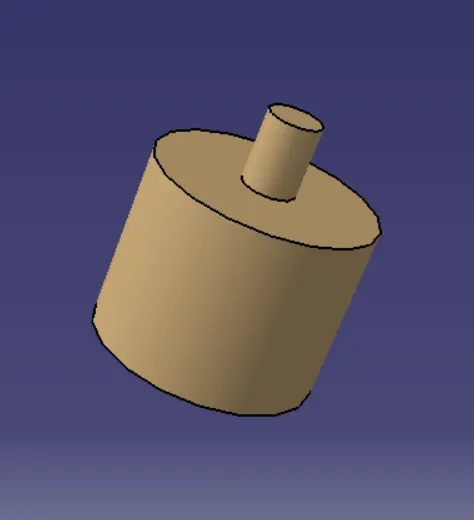
- The final Body of the Pivot block:
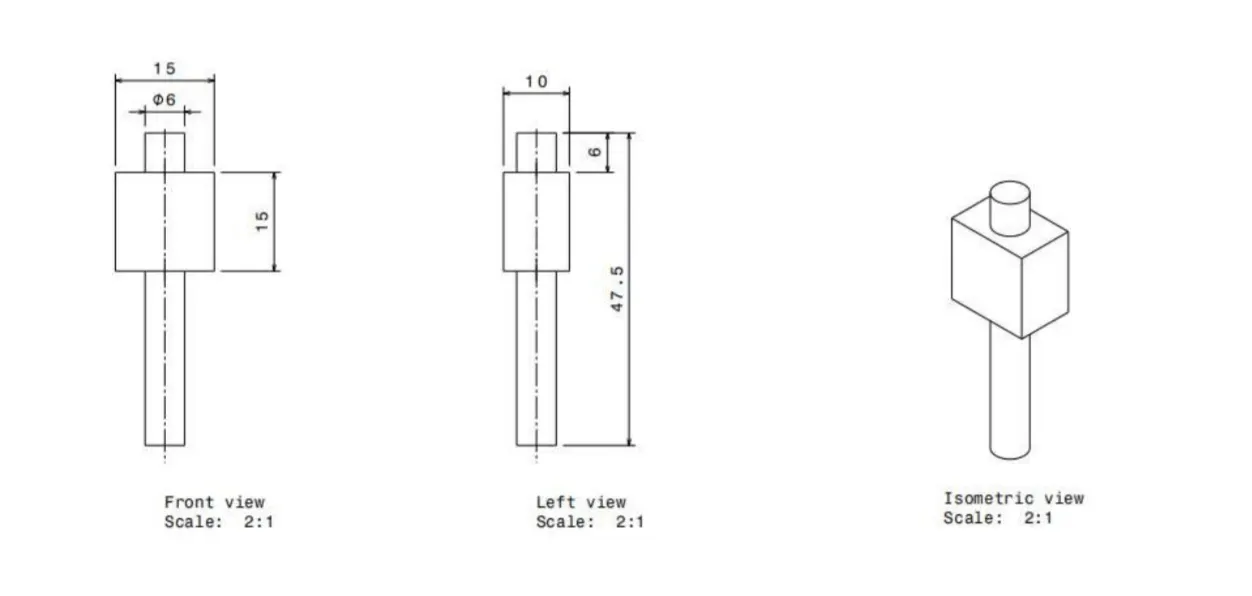
3. BODY-03
- Given 2 Dimensional Drawing
- Sketcher Workbench
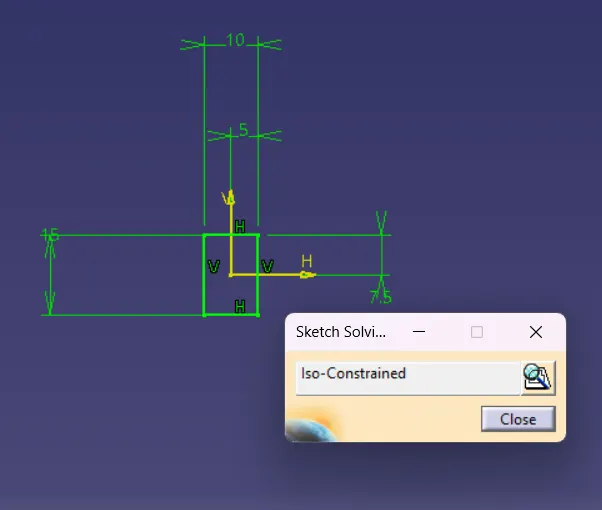
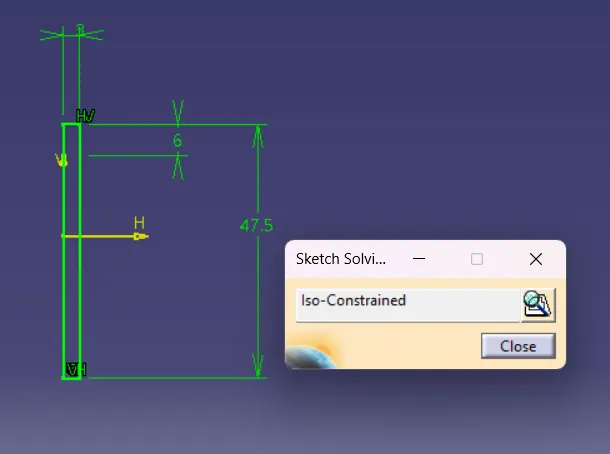
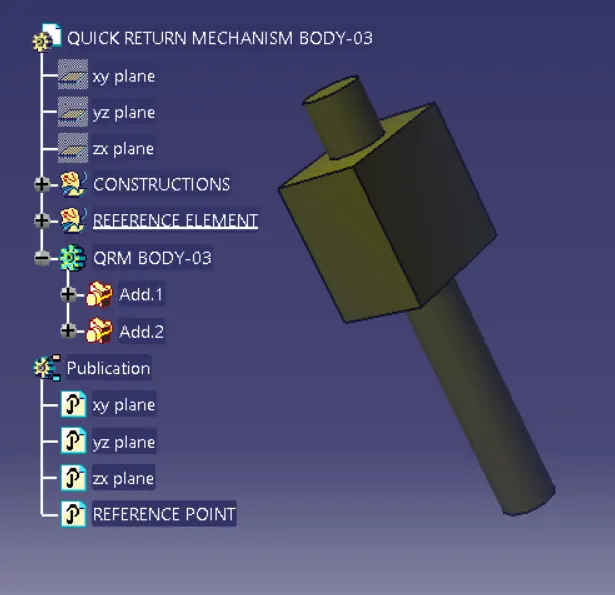
- The tree structure of the Sliding block :
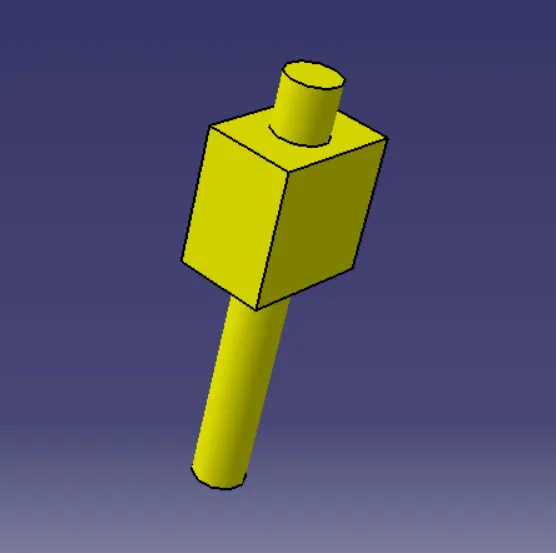
- The final Body of the Sliding block
4. BODY-04
- Given 2 Dimensional Drawing
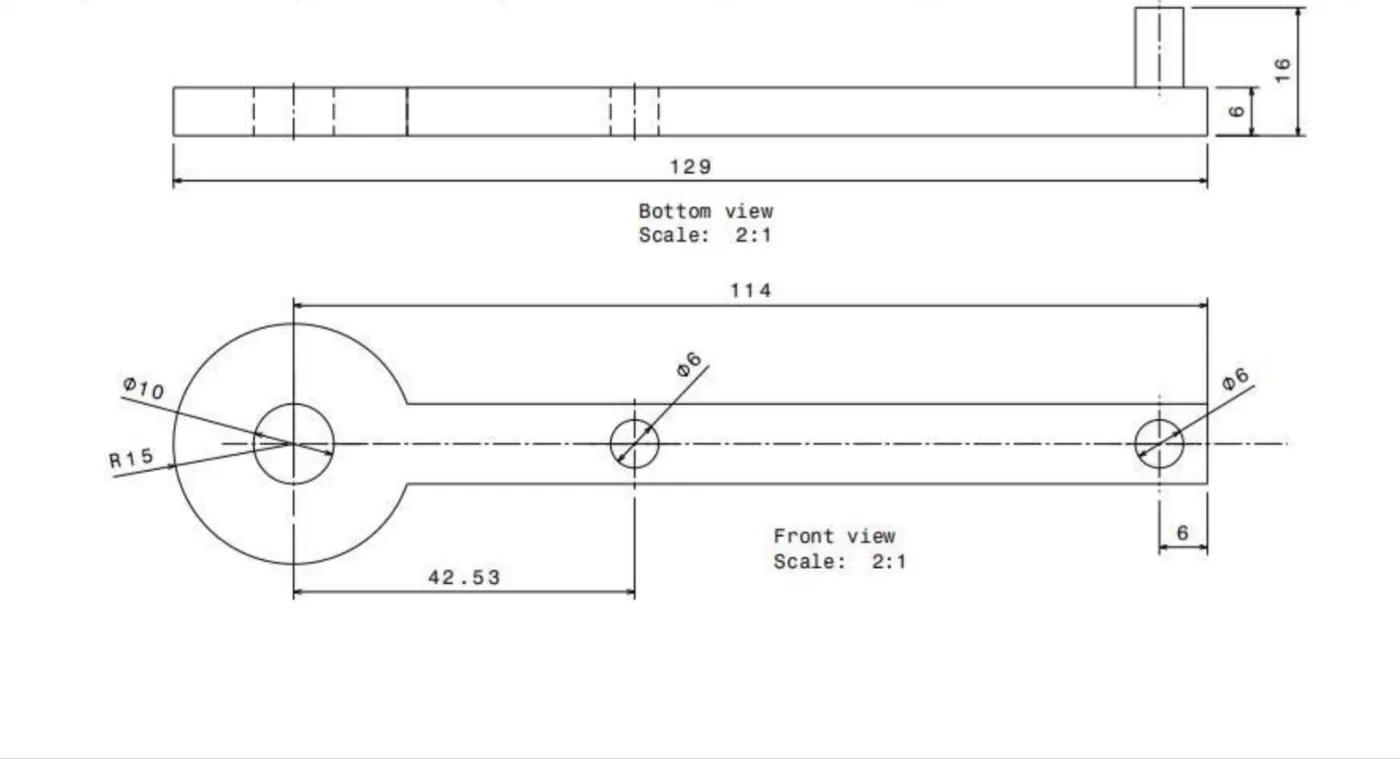
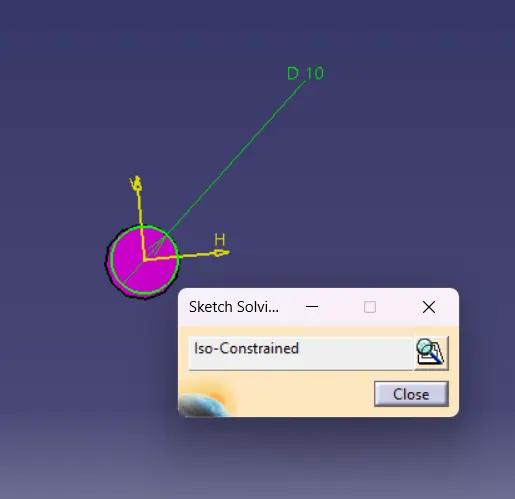
- Sketcher Workbench:
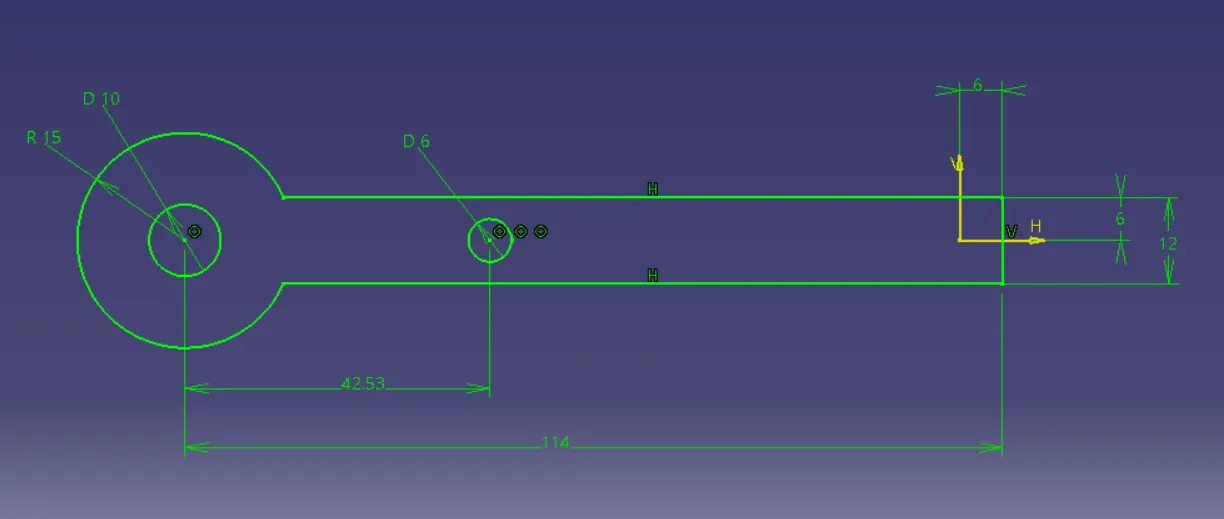
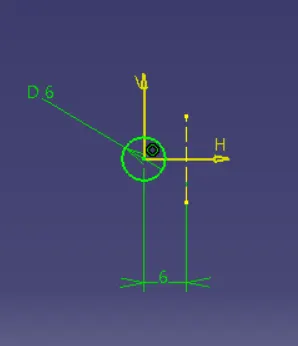
- The tree structure of the Crank :
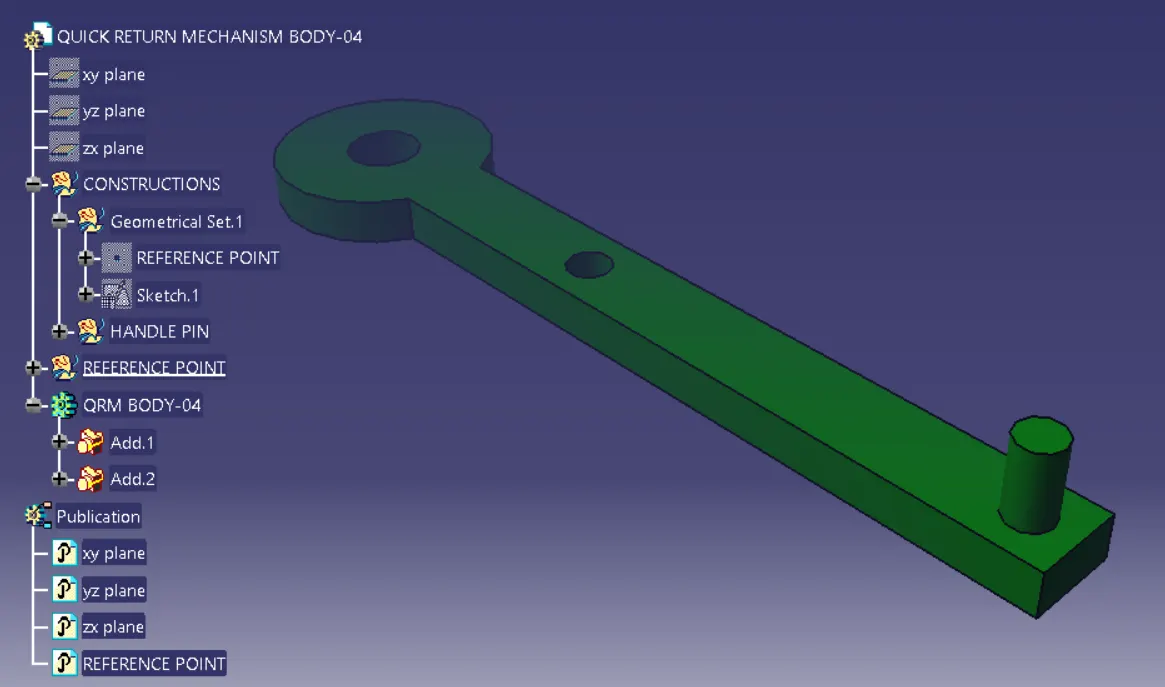
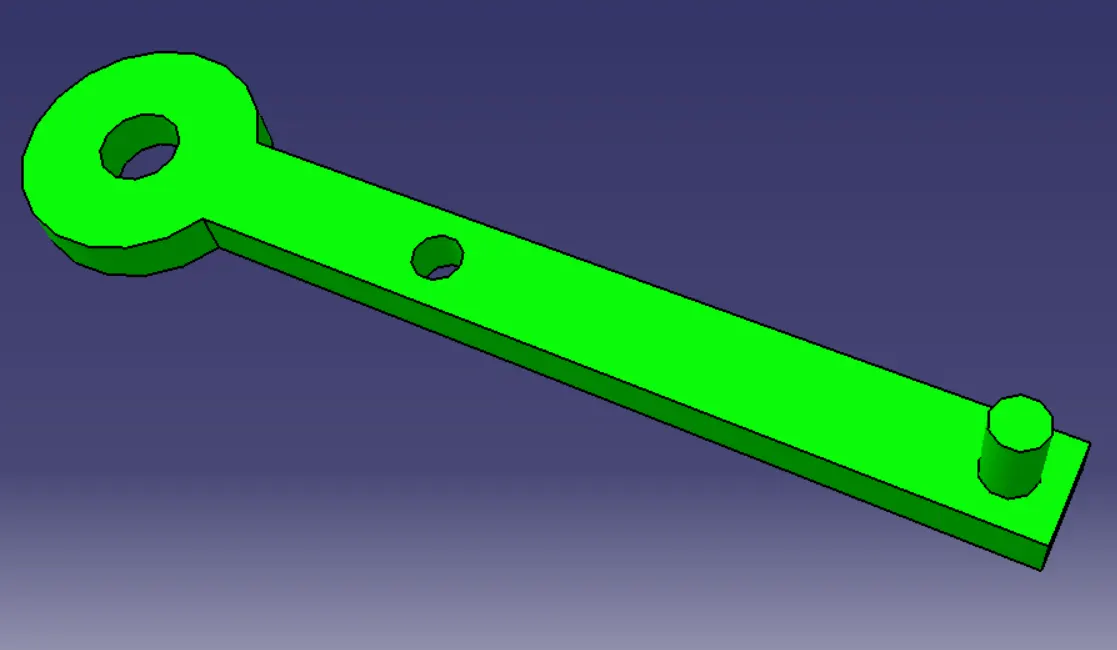
- The final Body of the Crank :
5. BODY-05
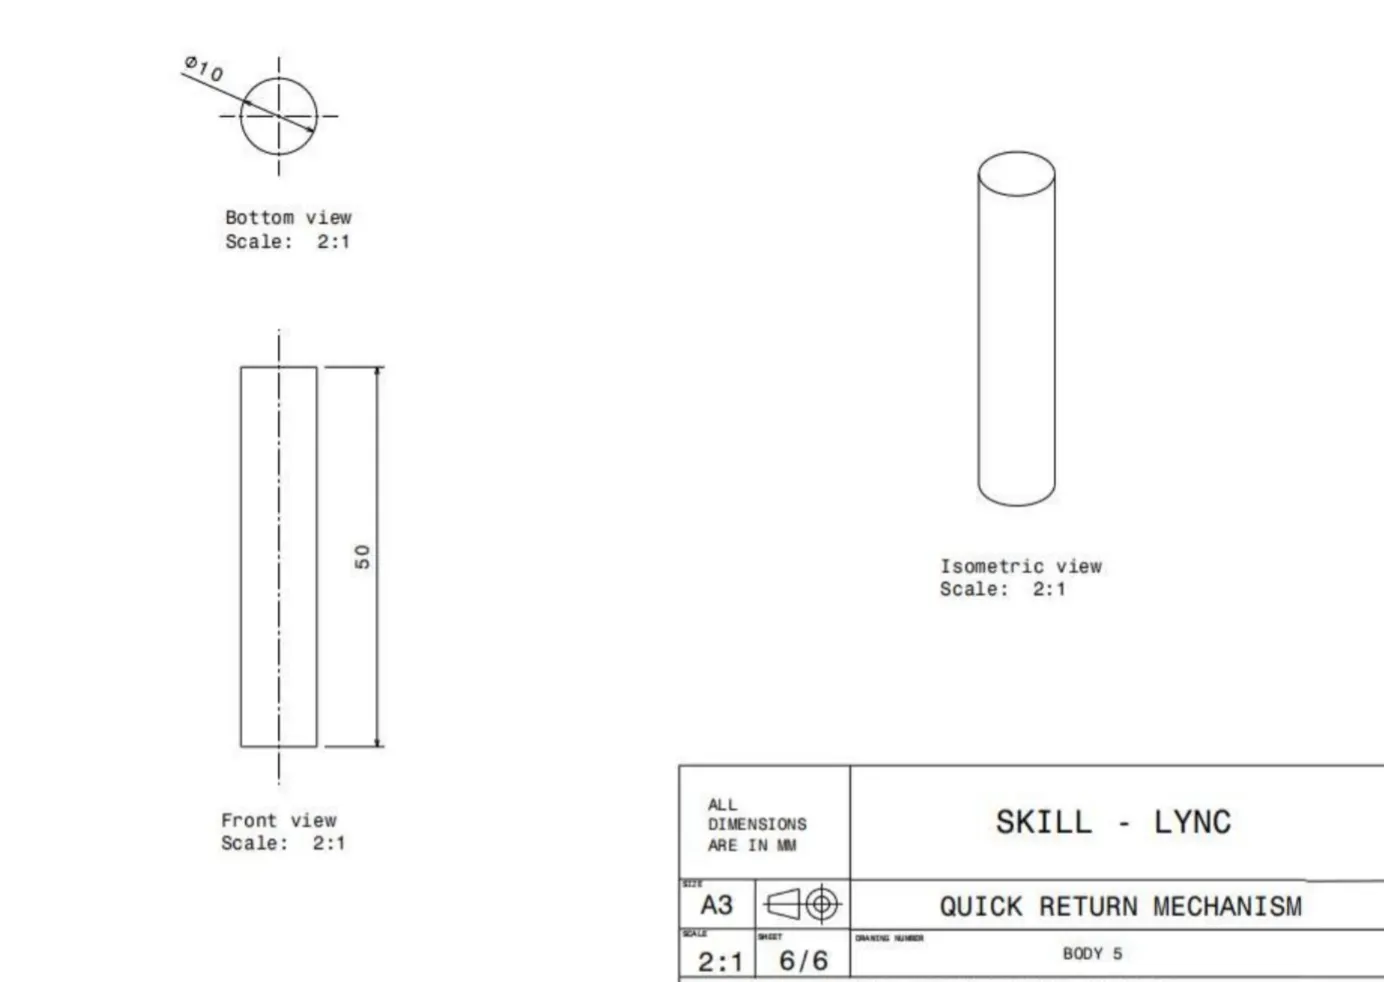
- Given 2 Dimensional Drawing
- Sketcher Workbench
- The tree structure of the Pin :
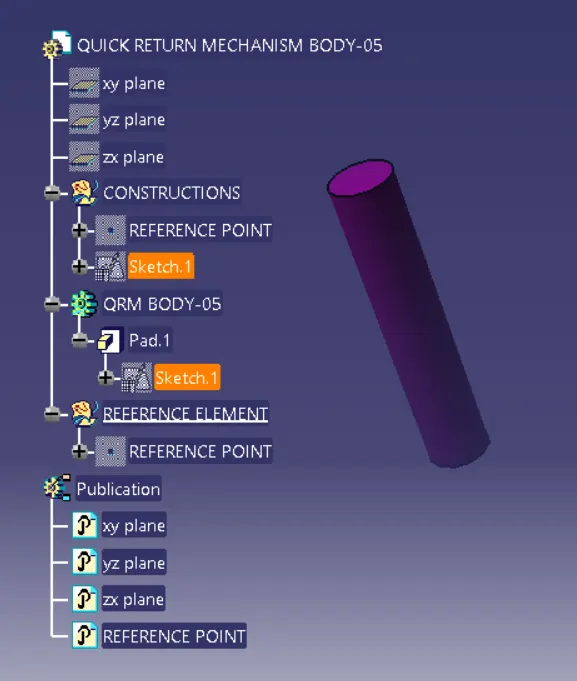
- The final Body of the Pin :
ASSEMBLY:
The following steps are involved in the Quick Return Mechanism assembly.
- The assembly process is carried out in the assembly workbench and the assembly file has CATProduct as its extension.
- The assembly of the Quick Return Mechanism starts with referencing the reference elements created at the part level.
- The reference points and planes are published at the part level for ease of access in the assembly workbench. Those publications are child feathers, if the parent features are modified in the part level its publications also get modified.
- Previously created parts are opened in the assembly workbench as child product features, and then a new part is created to serve as an assembly reference.
- This assembly reference is fixed to the arrest its all degrees of freedom to hold the parts together.
- After the fixation, the parts are assembled by giving coincident and offset relations to the appropriate planes and points.
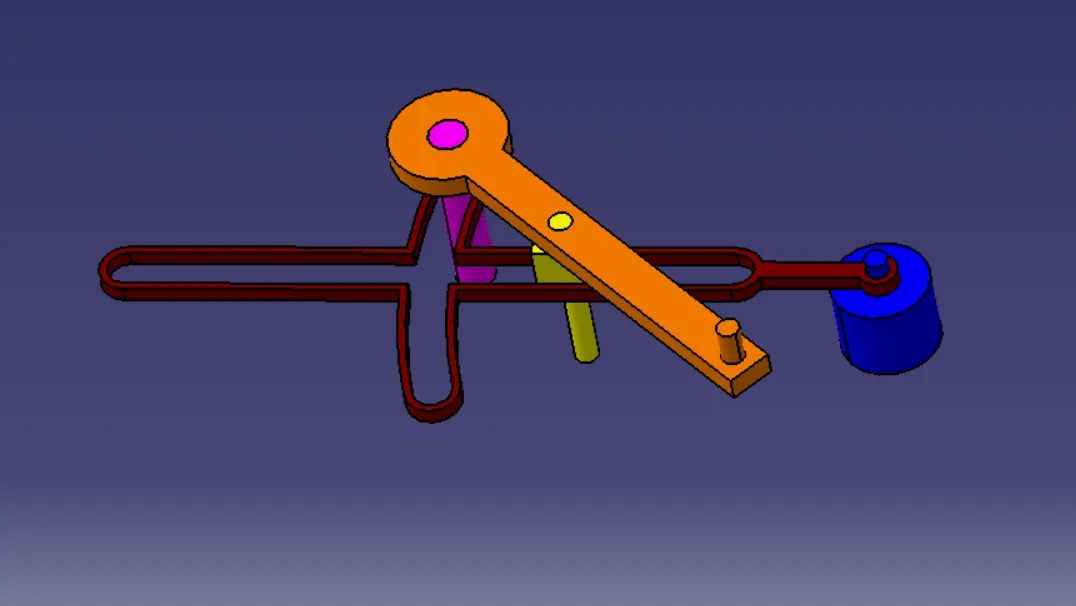
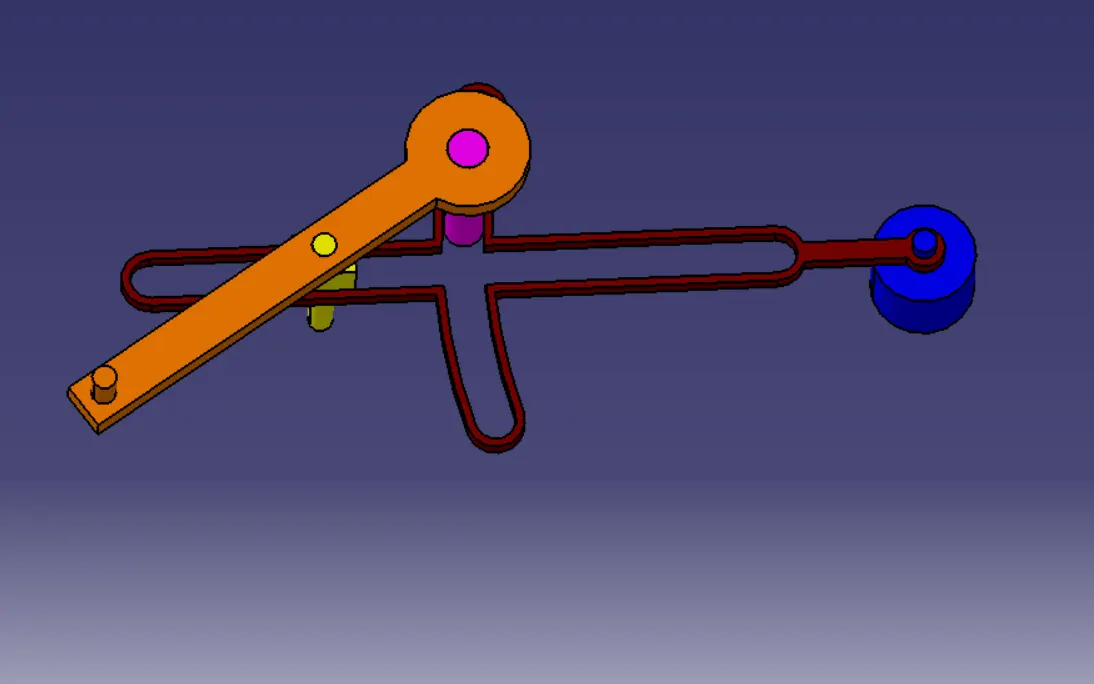
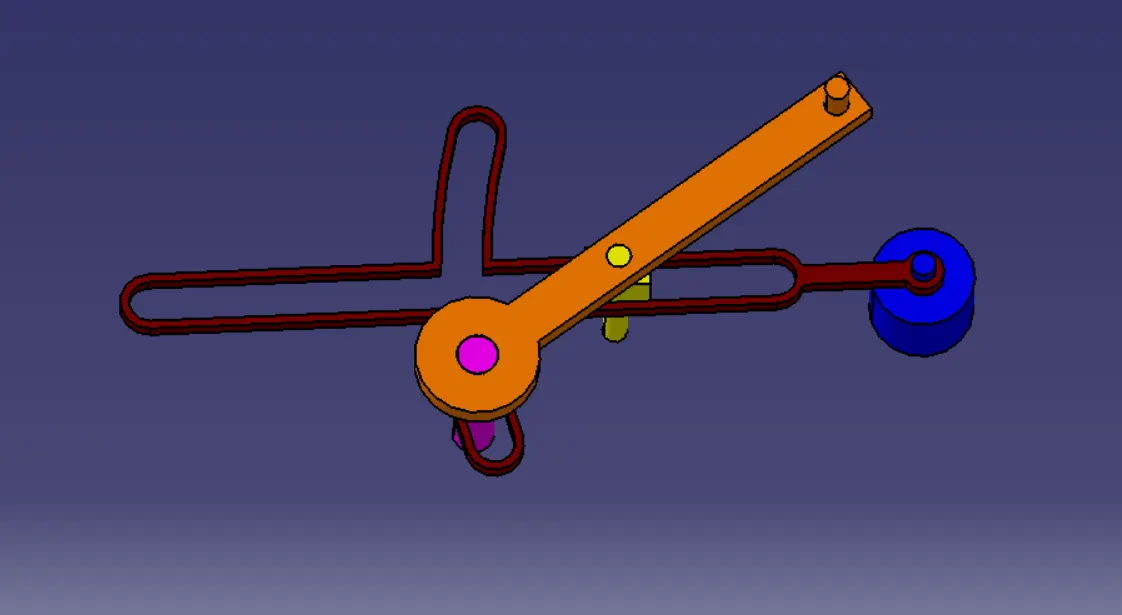
Sliding Orientations of Quick Return Mechanism :
Conclusion:
Thus the assembly design of CV Joint and Quick Return Mechanism has been designed using CATIA V5(Student Version)