Week 7 Challenge
Vehicle Model:
- Here the Vehicle model is the equation of forces which comes under velocity
- If when vehicle moves from its rest position for motorized vehicles such as automobiles aircraft and watercraft vehicle dynamics is the study of vehicle motion.
- For example how a vehicles forward movement changes in response to driver inputs propulsion system outputs ambient conditions air or surface or water conditions etc.
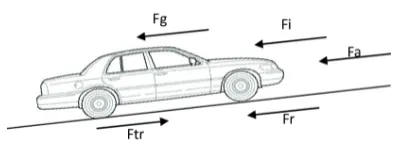
- We can from below image shows the force acting on a vehicle
-
Here
- Ftr = Tactive Force
- Fa = Aerodymanic drag resistant force
- Fg= Gradient Resistance force
- Fr = Rolling resistance force
- Fi = Inertial resistance force
- Here the Tractive force is the force applied produced by the vehicle powertrain we will now see the quations of three main forces and will implement this by matlab Fcn block
Aerodynamic drag :
- Here Aerodyamic Drag is a force which the on coming air applies on a moving body.
- Its is the reistance offered by the air to the movement of the body.
- So when a car is moving it displaces the air However it affects the car's speed and performance
- It is the aerodynamiv drag or the friction offered by the air to a vehicle
Aerodynamic Drag= 1/2*p*Cd*A*V2
Force of aceelration :
- The acceleration force refers to the vehicle resistance to speed varitaions
- This force holds you back when you increase your speed and also moves you forward when you slow down in other words it means that you consume energy to acclerate up to as certain speed but can recover part of that energy when you decelerate allowing you to drive a certain distance without consuming fuel in equations it is simply written as
- F=m*a m is mass and a is acceleration
Simulink model :
- Here above model shows the entrie vehicle model
- It consist of driver block vehicle block only
- Here thw Driver block is used to accleration purpose the value to overcome the integral windup happeneing while converting tractive force into velocity
- So Hence the only vehicle block system is consider as major system block in the vehicle modeling
Subsytem of the Driver Block:
- In this we created a inputs as desired velocity and actual velocity
- And aslo output as Accelerator ,brake ,
- We aslo used the below steps
1)Compute the error
2)Proportional control
3)Integral control reset when velocity is 0
4)Derivative controller
Vehicle model subsystem :
In this we used input as traction force and output as velocity
Working of the above designed model :
- Initially we loaded the excel file into the siginal builder block as shown in below
- Here The input to the vehicle block is tractive force this tractive force is teh force which is applied by the powertrain to the vehicle body
- Here we have given tractive force directly as a input its values are in newton its plot the values as shown in above siginal builder block
Vehicle model subsystem:
- This is the major block which lay key role in vehicle modeling
- So to find velocity let us asume that all the forces acting on vehicle this force of traction which is given as
- F_trac = Force of acceleration+ Rolling Resistance Foce+ Gradient Force+ Aerodynamic Force
- The term force of acceleration will help us to find the velcoity we will first seperate the acceleration term and resistive force terms.
- F_trac-Fr-Fg-Fd=Fa
- F_trac-Fr-Fg-Fd= m*a
- F_trac-Fr-Fg-Fd/m=a
- So we now have to acclerate
- Here The forces other than F_trac in model is calculated by formula implementation using Fcn block
Now we have acceleration with us we know that the accleration is the rate of change of velocity
The derivative of velocity Hence its anti derivation or integration will give us the velocity Which as been discussed theoritically is acytually implemented in simulink using required blocks
-
Here We have taken the integral windup, the integral windup particularly occurs as a limitation of physical system.
-
When we compared with ideal system due to the ideal output being physically impossible For example the position of a valve cannot be any more open than fully open and also cannot be closed any more than fully closed in this case anti windup can actually involve the integrator being turned off for periods of time until the response falls back into an accpetable range as soon as the acc and velocity goes zero the reset button gets active.
-
The vehicle paramertes is loaded using mat files.
-
The parameters value is shown below
-
Parameters value
-
Vehilce mass 1200kg
-
Gravitation force 9.81
-
RR coefficient 1.2
-
Drag Coff 2.5
-
Grade or angle 0
Output results:
- Here we can see that how the vehicle is operated by using the drive cycle source
- we created a vehicle model to obtaine the above results
- Here the vehicle speed can be varied by chaning the acceleration of the driver block
Conclusion :
We have Loaded the vehicle parameters. and Completed the vehicle model by modelling the remaining equations and we Seted the simulation stop time to 598 sec.