Week-6 Challenge: EV Drivetrain
1. Which types of power converter circuits are employed in electric and hybrid electric vehicle?
- DC-DC Converter
- AC-DC Converter (On Board Charger)
- DC-AC converter
DC-DC converters:
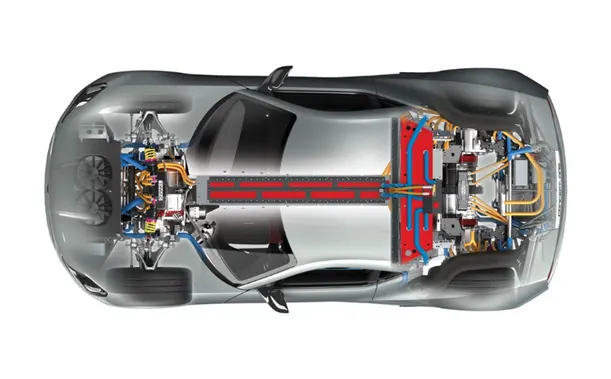
In modern pure electric and hybrid vehicles, battery voltages of 300- 400 V is becoming common, 600 V is gaining ground and 800 V systems are starting to emerge, all to help produce more power yet keep current flows and cabling manageable. However, these voltages do not suit all the electrical loads aboard the vehicle, so a means of converting them to lower or sometimes higher levels efficiently is essential. That is the role of the DC-DC converter.
Also known as auxiliary power modules (APMs), they can be found in every EV or hybrid with a high voltage battery. Fundamentally, this is because direct electronic conversion between voltages is much simpler and more efficient than the indirect alternative of taking a feed from the high-voltage inverter to power a motor and belt drive for a low-voltage alternator. In functional terms there are basically two kinds of DC-DC converter – one to bring high voltages down, the other to convert between different voltages at the low end.
A vehicle’s main DC-DC converter typically takes a battery’s voltage down to 12 V for common car loads such as headlights, window motors, pumps and so on. It also has to be adjustable, as some loads may need outputs in the 12.5 to 15.5 V range, while 42 V might be needed by power steering systems, for example. Power outputs range from 250 W to 3.5 kW, although some onboard chargers (OBCs) handle more than 6 kW; about 7.4 kW is regarded as the practical limit.
Critical loads on the low-voltage side, such as steering, are driving an increase in functional safety requirements for converters, while reliability demands are also growing because vehicle OEMs want to reduce the size of the low voltage battery.
In some applications, APMs also convert a voltage upwards to help start a hybrid vehicle or provide back-up power, which requires a bidirectional capability. This type of arrangement is typically found in mild hybrids, converting between 14 and 48 V.
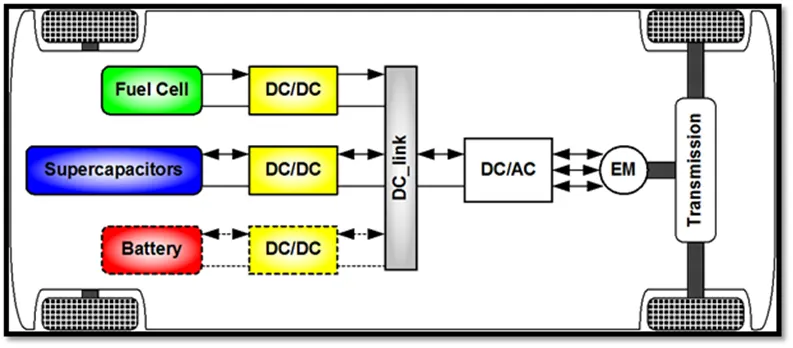
AC – DC Converter (On Board Charger):
AC to DC converters is most commonly used in Plug-in Hybrid Electric Vehicles (PHEV) & Plug-in Electric Vehicles (PEV). These vehicles get their propulsion power from an external electricity source (charging stations) which is alternating current. The battery needs to be charged using a direct current source. For this purpose, AC to DC converter is employed in a PHEV & PEV.
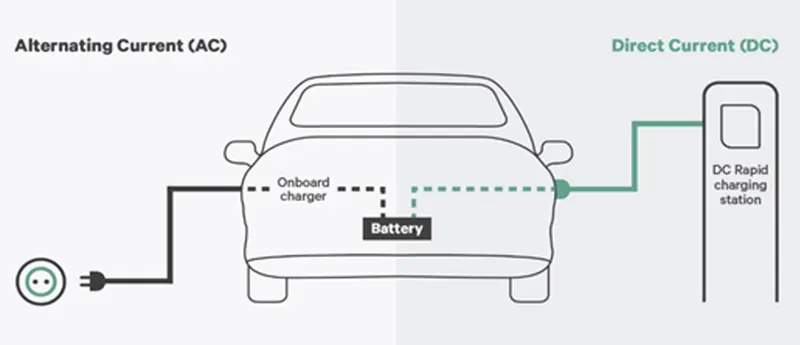
DC – AC Converter (Inverter):
The DC/AC converter is required to convert the DC power to a suitable AC power for the electrical machine. The power output from battery pack (DC current) is converted using inverter to be used in electric motor (AC current).
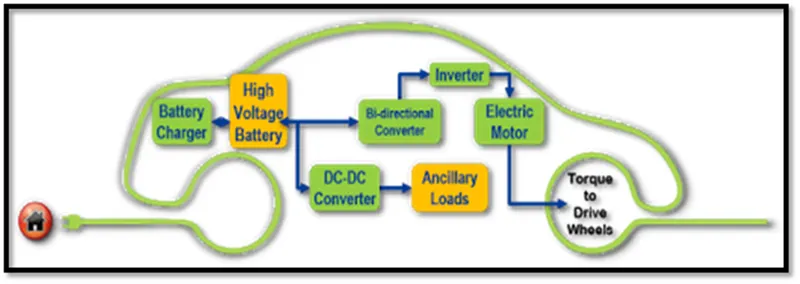
2. An Electric Vehicle's powertrain with 72V battery pack in shown in the diagram below. The duty ratio for acceleration operation is 'd1' and for the braking operation the duty ratio is 'd2'.
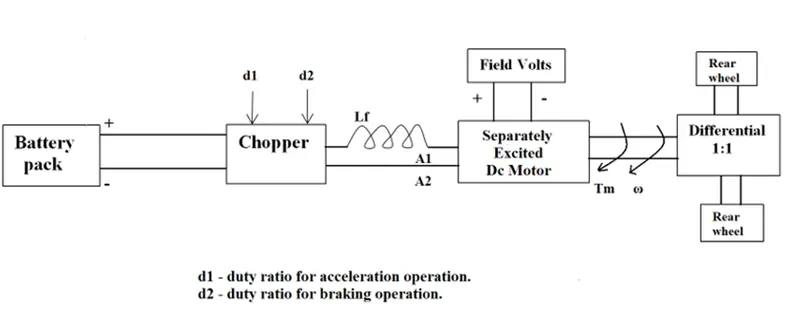
The other parameters of the electric vehicle is given below,
Motor and controller parameters:
Rated Armature voltage = 72V
Rated Armature current = 400A
Ra = 0.5ohm, K = 0.7 volt second
Chopper switching frequency = 400Hz
The vehicle speed – Torque characteristics are given below
Tv = 24.7 + (0.0051) w^2
What is EV steady state speed if duty cycle is 70%?
TO FIND EV STEADY STATE SPEED, USING MATLAB PROGRAM:
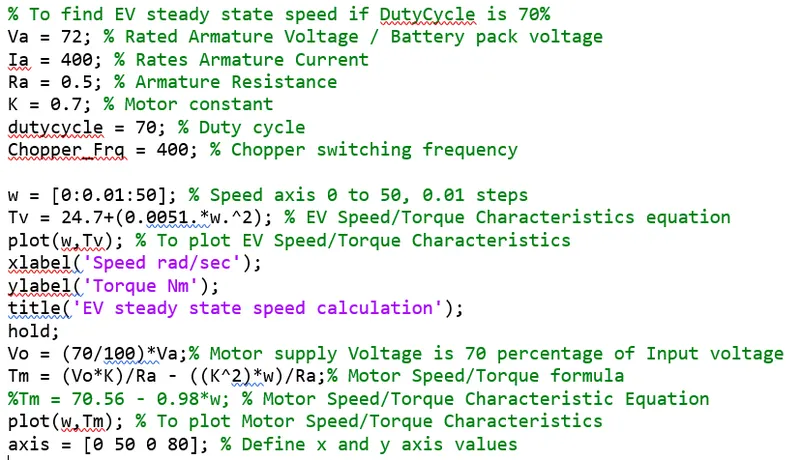
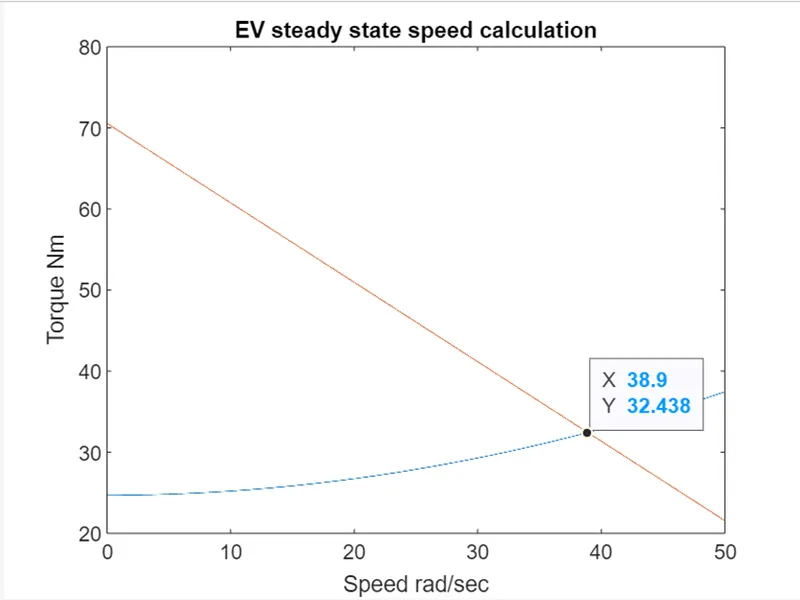
Conclusion:
We obtained EV Steady state speed is: 38.9 rad / sec using MATLAB function.
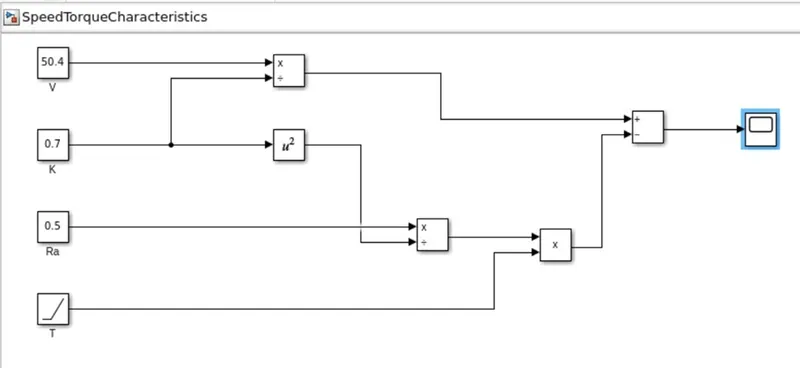
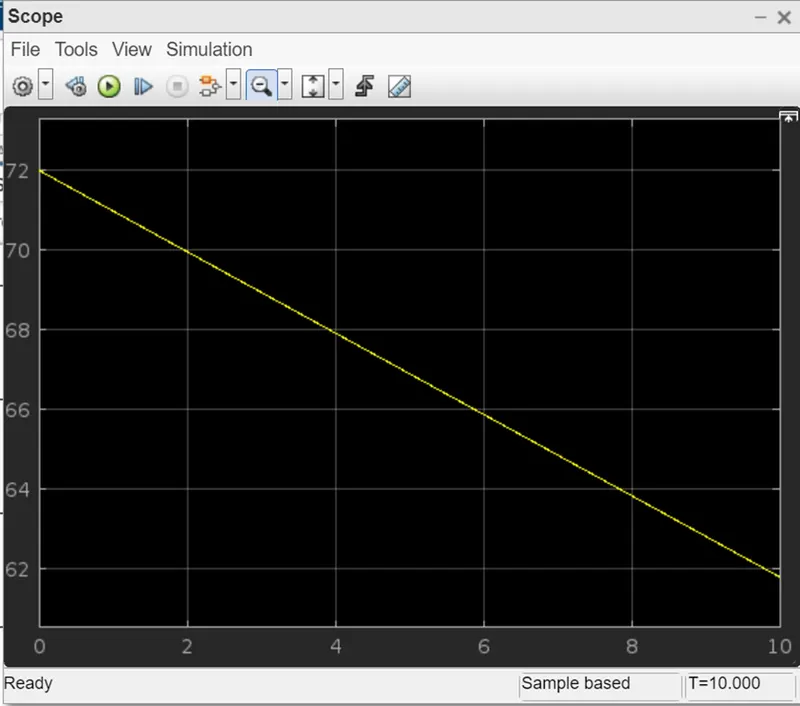
3. Develop a Mathematical model of a DC motor for the below equation using Simulink.
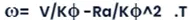
Voltage = 50.4 V;
Motor constant K = 0.7;
Armature Resistance = 0.5 ohm;
Torque T = Ramp Input;
4. Refer to the blog on below topic:
Induction Versus DC brushless motors by Wally Rippel, Tesla
Explain in brief about author’s perspective
DC Brushless Motor:
- DC brushless machine has one or more permanent magnets in the rotor structure, which generates DC magnetic field and these field is linked with the currents carrying windings in stator body. To get output torque must be constant which is taken care by continuously varying magnitude and polarity of stator current.
- Constant torque brings out the application for DC brushless motor and this control is able to achieve by the help of inverter.
- Brushless DC motor produces no starting torque when directly connected to fixed frequency utility power. They really need the aid of an inverter whose “phase” is maintained in step with the angular position of the rotor.
Induction Motor:
- The induction rotor has no magnets – just stacked steel laminations with buried peripheral conductors that form a “shorted structure.” Currents flowing in the stator windings produce a rotating magnetic field that enters the rotor.
- In turn, the frequency of this magnetic field as “seen” by the rotor is equal to the difference between the applied electrical frequency and the rotational “frequency” of the rotor itself.
- Accordingly, an induced voltage exists across the shorted structure that is proportionate to this speed difference between the rotor and electrical frequency. In response to this voltage, currents are produced within the rotor conductors that are approximately proportionate to the voltage, hence the speed difference.
- Finally, these currents interact with the original magnetic field to produce forces – a component of which is the desired rotor torque.
- When a 3-phase induction motor is connected to utility type 3-phase power, torque is produced at the outset; the motor has the ability to start under load. No inverter is needed.
- The fact that induction motors are directly compatible with conventional utility power is the main reason for their success.
- Shaft speed is proportionate to line frequency. Hence, when used with utility power, they are constant speed machines.
- Add an inverter (without any feedback control) and it becomes possible to power an induction machine from a battery or other DC source; variable speed also becomes possible simply by adjusting the inverter frequency. Still, torque performance is low compared with DC machines.
- Add some feedback loops such that the inverter produces the exact frequency that the motor “desires,” and the induction motor is now capable of competing with DC and DC brushless for vehicle applications.
Comparison:
- Both DC brushless and induction drives use motors having similar stators.
- Both drives use 3-phase modulating inverters. The only differences are the rotors and the inverter controls.
- And with digital controllers, the only control differences are with control code. (DC brushless drives require an absolute position sensor, while induction drives require only a speed sensor; these differences are relatively small.)
- much less rotor heat is generated with the DC brushless drive. Rotor cooling is easier and peak point efficiency is generally higher for this drive.
- In Ideal brushless drive, the strength of the magnetic field produced by the permanent magnets would be adjustable. When maximum torque is required, especially at low speeds, the magnetic field strength (B) should be maximum – so that inverter and motor currents are maintained at their lowest possible values. This minimizes the I²R (current² resistance) losses and thereby optimizes efficiency. Likewise, when torque levels are low, the B field should be reduced such that eddy and hysteresis losses due to B are also reduced. Ideally, B should be adjusted such that the sum of the eddy, hysteresis, and I² losses is minimized. Unfortunately, there is no easy way of changing B with permanent magnets.
- Induction machines have no magnets and B fields are “adjustable,” since B is proportionate to V/f (voltage to frequency). This means that at light loads the inverter can reduce voltage such that magnetic losses are reduced and efficiency is maximized. Thus, the induction machine when operated with a smart inverter has an advantage over a DC brushless machine – magnetic and conduction losses can be traded such that efficiency is optimized. This advantage becomes increasingly important as performance is increased.
- With DC brushless, as machine size grows, the magnetic losses increase proportionately and part load efficiency drops.
- With induction, as machine size grows, losses do not necessarily grow. Thus, induction drives may be the favoured approach where high-performance is desired; peak efficiency will be a little less than with DC brushless, but average efficiency may actually be better.
- Permanent magnet (PM) rotors are also difficult to handle due to very large forces that come into play when anything ferromagneticgets close to them.
- Induction motors will likely retain a cost advantage over PM machines. Also, due to the field weakening capabilities of induction machines, inverter ratings and costs appear to be lower, especially for high performance drives.
- Induction machines are more difficult to control. The control laws are more complex and difficult to understand.
- Achieving stability over the entire torque-speed range and over temperature is more difficult with induction than with DC brushless. This means added development costs, but likely little or no recurring costs.
Conclusion:
DC brushless drives will likely continue to dominate in the hybrid and plug-in hybrid
Induction drives will likely maintain dominance for the high-performance pure electrics