Week-6 Challenge: EV Drivetrain
AIM
To identify the types of power converter circuits employed in electric and hybrid electric vehicle.
To calculate the steady state speed of an EV with given inputs if duty cycle is 70%.
Refer to the blog and explain in brief about author’s perspective.
QUESTION1: -
Q1. Which types of power converter circuits are employed in electric and hybrid electric vehicle?
Power Electronic Converters: -
In Electric and Hybrid Electric Vehicles (EV/HEV), the power electronic converters are considered as the key elements that interface their power sources to the drivetrain of the EVs. In order to design highly efficient converters for the EV’s power system, advanced DC/DC and DC/AC converters are required to adapt the output voltage and current levels with high power quality.
The 3 types of converters which are widely used in an Electric Vehicle are:
The 3 types of converters which are widely used in an Electric Vehicle are:
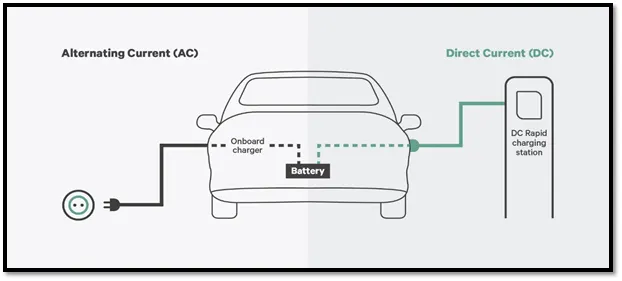
AC – DC Converter (On Board Charger): -
AC to DC converters are most commonly used in Plug-in Hybrid Electric Vehicles (PHEV) & Plug-in Electric Vehicles (PEV). These vehicles get their propulsion power from an external electricity source (charging stations) which is alternating current. The battery needs to be charged using a direct current source. For this purpose, AC to DC converter is employed in a PHEV & PEV.
DC – DC Converter: -
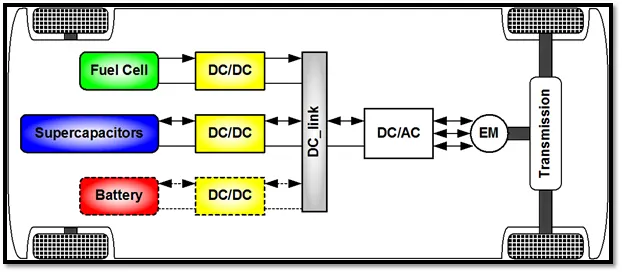
DC-DC converters can be used to interface the elements in the electric power train by boosting or chopping the voltage levels. By introducing DC/DC converters one can choose the voltage variation of the devices and the power of each device can be controlled. The power of the DC/DC converter depends on the characteristics of the vehicle such as top speed, acceleration time from 0 to 100 Km/h, weight, maximum torque, and power profile (peak power, continuous power).
DC – AC Converter (Inverter): -
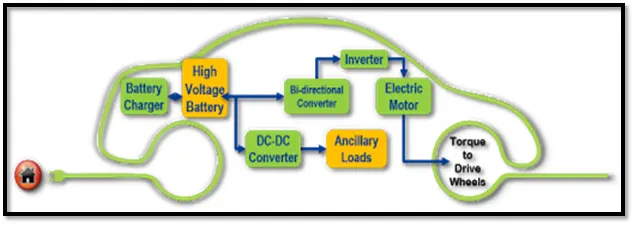
The DC/AC converter is required to convert the dc power to a suitable ac power for the electrical machine. The power output from battery pack (DC current) is converted using inverter to be used in electric motor (AC current).
QUESTION -2
Q2. An Electric Vehicle's powertrain with 72V battery pack in shown in the diagram below. The duty ratio for acceleration operation is 'd1' and for the braking operation the duty ratio is 'd2'.
The other parameters of the electric vehicle is given below,
Motor and Controller Parameters:
Rated Armature voltage= 72 V
Rated armature current= 400 A
Ra= 0.5Ω, KΦ= 0.7 Volt second
Chopper Switching frequency= 400 Hz
The vehicle speed-torque characteristics are given by the below equation
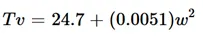
What is EV steady state speed if duty cycle is 70%?
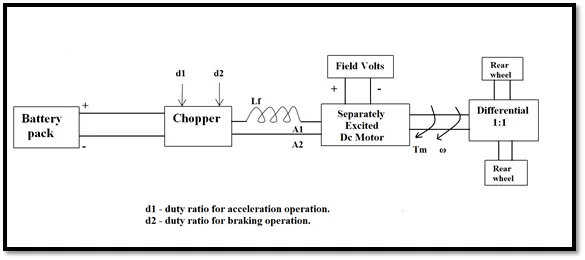
Given: -
The following input parameters are given: -
Battery pack voltage (V) = 72V
Rated armature current = 400 A
Armature Resistance (Ra) = 0.5Ω
Motor constant (KΦ) = 0.7
Chopper Switching frequency= 400 Hz
Duty Cycle = 70%ω
Solution: -
Vehicle Output Voltage (Vv) is given by: -
Vv = Battery Voltage (V) * Duty Cycle
Vv = 72 * 0.70
Thus, Vehicle voltage = 50.4V
Now, Equation for Vehicle torque is given by: -
Tv=(Vv−ω.K∅)⋅K∅Ra
Where;
Tv= Vehicle Torque (N-m)
Vv = Vehicle voltage (Volts)
ω= steady state speed of vehicle (rps)
K∅= Motor constant
Ra= Armature Resistance
Substituting all these values in equation, we get:
Tv=(50.04−0.7⋅ω)⋅0.70.5
Tv=70.56−0.98⋅ω
Tv=24.7+0.0051⋅ω2
Solving these two equations,
70.56−0.98⋅ω=24.7+0.0051⋅ω2
We get a quadratic equation:
0.0051⋅ω2+0.98⋅ω−46.94=0
Since quadratic equation, we get two values of ;
ω= 38.85 rad/s and ω = -230.95 rad/s
We take the positive value;
Steady state speed of vehicle = = 38.85 rad/s
QUESTION -3
Develop a mathematical model of a DC Motor for the below equation using Simulink.
clear all
close all
clc
% Torque Speed Characteristics of DC Machine.
% Array of motor speed in rad/sec
Speed = linspace(0,500,50);
% Input of Speed constant of a motor (rpm/v)
N_s = input('Enter the value of Speed Constant of Motor = ');
% Input the Battery voltage supply value.(volts)
V = input('Enter the value of Voltage Supply = ');
%Input the Armature Resistance. (ohms)
R_a = input('Enter the value of Armature Resistance = ');
% Back E.M.F developed
EMF = 1 ; % back emf is directly proportional to speed constant given in the dat is per unit voltage
%Calculating the constant of proportionality in emf and speed relation
k_phi = (EMF*60)/(N_s*2*3.14);
% the DC motor Speed torque charateristics
% T = ((V*k_phi/R_a) - ((k_phi)^2/R_a)*omega)
% Calculation of Torque
T = ((V*k_phi/R_a) - (((k_phi)^2/R_a).*Speed));
% To calculate Total Current in Ampere
TC = (V - EMF)/R_a;
% To Calculate the maximum Torque
T_max = k_phi*TC ;
%Convert Speed value in rpm from rad/sec
Speed = Speed*60/(2*3.14);
% Plotting the D.C.Machine charateristics w.r.t Speed Vs Torque
plot(Speed,T,'color','r','linewidth',3);
xlabel('Speed (RPM)');
ylabel('Torque (Nm)');
title('D.C.Machine Charateristics
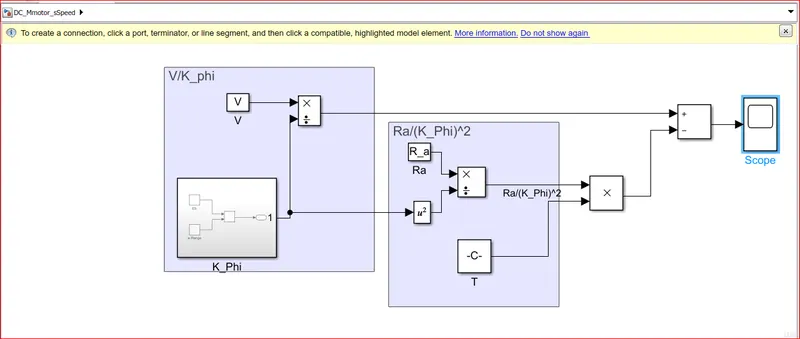
SIMULINK MODEL:
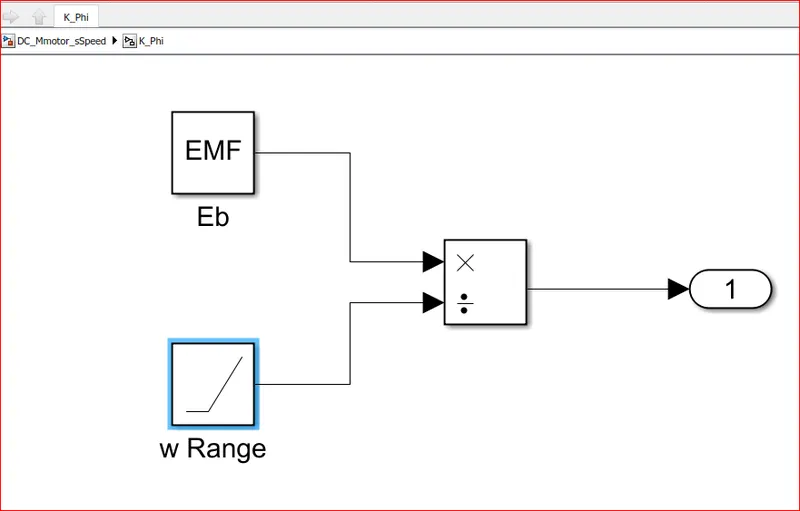
SUBSYSTEM:
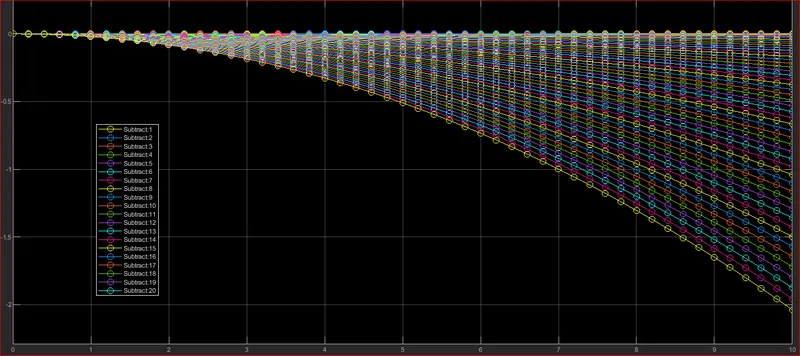
RESULTS:
EXPLANATION:
- The speed is determined with a help of mathematical model in simulink, By preparing the model which governs the above Speed formula.
- New model in Simulink is opened and saved with name DC_Mmotor_sSpeed,then in that model we take constant block it’s input is “V“ from the workspace.
- “K” is Eb/speed so we take “Eb” in constant block and it’s input as ”EMF” from the workspace.
- Further we take divide block and connect multiplication port to EB as it is directly proportional and divide port to Speed from workspace, and create a Subset of it with asking for output port block.
- In Similar way Subset is created for Ra/K^2*T as shown in Model diagram
QUESTION -4
Explain in brief about author’s perspective.
The following points can be concluded from the above topic:
- In the beginning, author describes the dominance of Internal Combustion Engines (ICE) in the world of automobile industry and also discuss different types of engines. He explains that all engines were similar and it was up to the user to select according to their requirement. He also speaks about induction motor and brushless DC motors and presents his view that these two technologies will be widely used for the coming years.
- Then he explains the working of both 3-phase induction motor and a brushless DC motor.
- Now the author has done comparison between these two technologies and stated some advantages and disadvantages of each.
- Induction motor have some advantages like: it has no magnets. The motor has the ability to start under load. No inverter is needed. Some disadvantages of Induction motors are: They cannot operate from DC; AC is a must. Shaft speed is proportionate to line frequency. Hence, when used with utility power, they are constant speed machines. When operated from utility power, they have limited starting torque and somewhat limited running peak torque capabilities, when compared to DC type machines.
- Brushless DC motor have some advantages like: much less rotor heat is generated with the DC brushless drive. The peak point energy efficiency for a DC brushless drive will typically be a few percentage points higher than for an induction drive. Some disadvantages of Brushless DC motor are: as machine size grows, the magnetic losses increase proportionately and part load efficiency drops. Permanent magnets are expensive and difficult to handle due to very large forces that come into play when anything ferromagnetic gets close to them.
- Finally the author couldn’t choose which drive is better than the other but makes it clear that DC brushless drives will likely continue to dominate in the hybrid and coming plug-in hybrid markets, and that induction drives will likely maintain dominance for the high-performance pure electrics.