Week-6 Challenge: EV Drivetrain
1).Which types of power converter circuits are employed in electric and hybrid
electric vehicles?
THEORY:
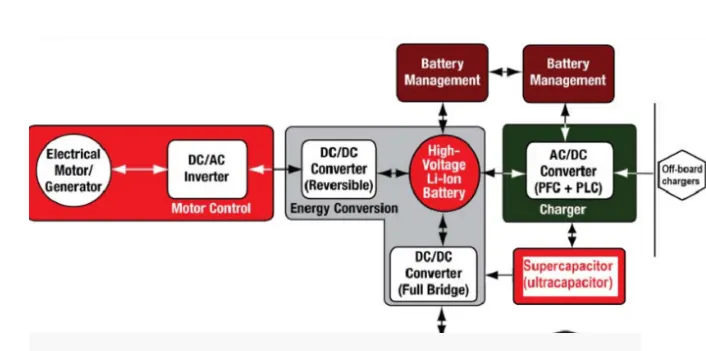
An Electric Vehicle is a vehicle that uses a combination of different energy sources,
Fuel Cells (FCs), Batteries and Supercapacitors (SCs) to power an electric drive system
as shown in fig 1. In EV the main energy source is assisted by one or more energy
storage devices. Thereby the system cost, mass, and volume can be decreased, and a
significantly better performance can be obtained. Two often-used energy storage
devices are batteries and SC S . They can be connected to the fuel cell stack in many
ways. A simple configuration is to directly connect two devices in parallel, (FC/battery,
FC/SC, or battery/SC). However, in this way, the power drawn from each device cannot
be controlled but is passively determined by the impedance of the devices. The
impedance depends on many parameters, e.g. temperature, state-of-charge, health,
and point of operation. Each device might therefore be operated in an inappropriate
condition, e.g. health and efficiency. The voltage characteristics also have to match
perfectly of the two devices, and only a fraction of the range of operation of the devices
can be utilized, e.g. in a fuel cell battery configuration the fuel cell must provide almost
the same power all the time due to the fixed voltage of the battery, and in a
battery/supercapacitor configuration only a fraction of the energy exchange capability of
the supercapacitor can be used. This is again due to the nearly constant voltage of the
battery. By introducing DC/DC converters one can choose the voltage variation of the
devices and the power of each device can be controlled.
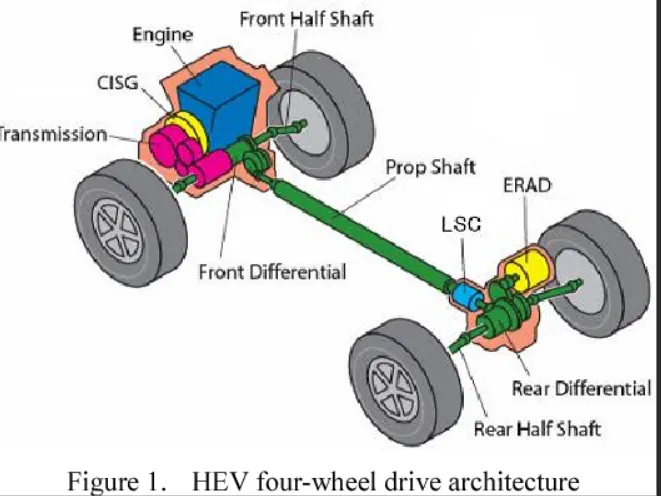
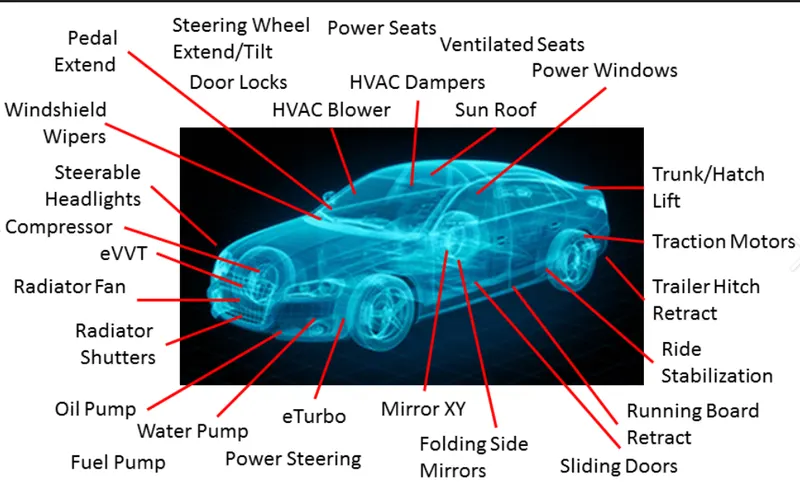
Figure 1. Electric vehicle drive system.
In reference, 10 cases of combining the fuel cell with the battery, SCs, or both are
investigated. The system volume, mass, efficiency, and battery lifetime were compared.
It is concluded that when SCs are the only energy storage device the system becomes
too big and heavy. A fuel cell/battery/supercapacitors hybrid provides the longest
lifetime of the batteries. It can be noticed that the use of high power DC/DC converters
is necessary for EV power supply systems. The power of the DC/DC converter depends
on the characteristics of the vehicle such as top speed, acceleration time from 0 to 100
Km/h, weight, maximum torque, and power profile (peak power, continuous power).
Generally, for passenger cars, the power of the converter is more than 20 KW and it can
go up to 100 KW.
i. AC TO DC CONVERTER
ii. DC TO DC CONVERTER
iii. DC TO AC CONVERTER
1. AC TO DC CONVERTER
AC to DC Converters are one of the most important in power electronics because there
are a lot of real applications are based on these conversions. The AC current to dc
current conversion process is known as rectification. This rectifier converts the AC
supply into the DC supply at the load end connection. Normally Transformers are used
to adjust the AC source to get a step-down transformer to reduce the voltage level to
have a better operation range for DC supply. Normally this AC to DC converter converts
low voltage values.
Uncontrolled converter converts fixed DC voltage, which means the value of output for a
given value of AC voltage. A fully controlled converter convert adjustable DC voltage
when the adjustable range can adjust in both the positive and negative sides. Semi-
controlled converter also produce an adjustable DC voltage which positive side power.
All three converters have unidirectional power flow from the AC side to the DC side.
PWN converter can produce adjustable both positive importantly it allows power flow in
either direction. Making it ideal application motor drives and power system
interconnection with the power system.
All three converters have unidirectional power flow from the AC side to the DC side.
PWN converter can produce adjustable both positive importantly it allows power flow in
either direction. Uncontrolled rectifiers can also subdivide into several subcategories
such as
• Single phase half-wave rectifier.
• Single-phase full-wave bridge rectifier
• Single-phase centre tapped full wave
• Three phases half-wave diode rectifier
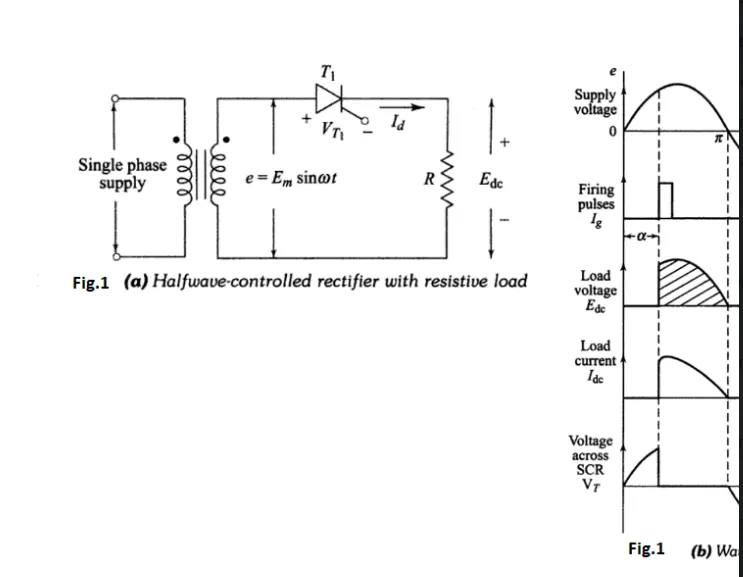
a). Single-phase half-wave rectifier:-
Single-phase half-wave rectifier simplest controlled rectifier uses for single devices. To
produce variable de voltage from fixed current thyristors are used. Following are the
circuit arrangement of the Single-phase half-wave rectifiers. In here diode or thyristors
are used. Where the application needs to fix dc Voltage, the diode is used as a
switching element. When the application needs variable voltage thyristors are used.
Single-phase converters can mainly classify as Bridge Converter and Center Tapped
Converter. This type of uncontrolled converter is mainly used for building supply only in
Patrice. In power supply by applying a capacitor filter on the output in other cases which
inductive load causes we use this directly or inductive filters.
b). Single-phase full-wave bridge rectifier:-
Another type of circuit that produces the same output waveform as the full-wave rectifier
circuit above, is that of the Full Wave Bridge Rectifier. This type of single-phase
rectifier uses four individual rectifying diodes connected in a closed-loop “bridge”
configuration to produce the desired output.
The main advantage of this bridge circuit is that it does not require a special centre
tapped transformer, thereby reducing its size and cost. The single secondary winding is
connected to one side of the diode bridge network and the load to the other side as
shown below.
The Diode Bridge Rectifier
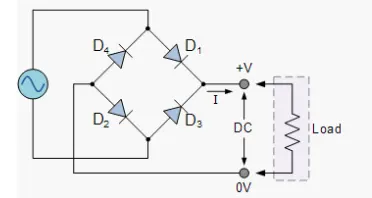
The four diodes labelled D 1 to D 4 are arranged in “series pairs” with only two diodes
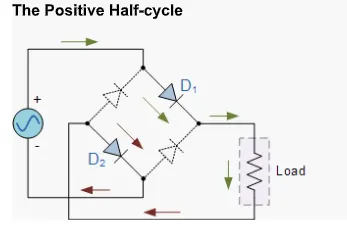
conducting current during each half cycle. During the positive half cycle of the supply,
diodes D1 and D2 conduct in series while diodes D3 and D4 are reverse biased and the
current flows through the load as shown below.
The Positive Half-cycle.
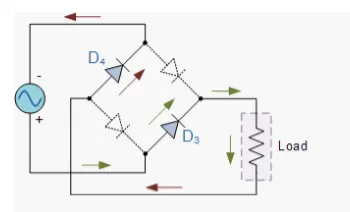
During the negative half cycle of the supply, diodes D3 and D4 conduct in series, but
diodes D1 and D2 switch “OFF” as they are now reverse biased. The current flowing
through the load is in the same direction as before.
The Negative Half-cycle.
As the current flowing through the load is unidirectional, so the voltage developed
across the load is also unidirectional the same as for the previous two diodes full-wave
rectifier, therefore the average DC voltage across the load is 0.637V max . However in
reality, during each half-cycle, the current flows through two diodes instead of just one
so the amplitude of the output voltage is two voltage drops ( 2*0.7 = 1.4V ) less than the
input V MAX amplitude. The ripple frequency is now twice the supply frequency (e.g. 100Hz
for a 50Hz supply or 120Hz for a 60Hz supply.)
Although we can use four individual power diodes to make a full-wave bridge rectifier,
pre-made bridge rectifier components are available “off-the-shelf” in a range of different
voltage and current sizes that can be soldered directly into a PCB circuit board or be
connected by spade connectors.
The image to the right shows a typical single-phase bridge rectifier with one corner cut
off. This cut-off corner indicates that the terminal nearest to the corner is the positive
or +ve output terminal or lead with the opposite (diagonal) lead being the negative or -
ve output lead. The other two connecting leads are for the input alternating voltage from
a transformer secondary winding.
c). Single-phase centre tapped full-wave diode rectifier:-
We have already discussed the Full Wave Bridge Rectifier, which uses four diodes,
arranged as a bridge, to convert the input alternating current (AC) in both half-cycles to
direct current (DC). In the case of a centre-tap full-wave rectifier, only two diodes are
used and are connected to the opposite ends of a centre-tapped secondary transformer
as shown in the figure below. The centre tap is usually considered as the ground point
or the zero voltage reference point.
Working of Centre-Tap Full Wave Rectifier
As shown in the figure, an ac input is applied to the primary coils of the transformer.
This input makes the secondary ends P1 and P2 become positive and negative
alternately. For the positive half of the ac signal, the secondary point D1 is positive, the
GND point will have zero volts and the P2 will be negative. At this instant diode, D1 will
be forward biased and diode D2 will be reverse biased. As explained in the Theory
Behind P-N Junction and Characteristics of P-N Junction Diode, the diode D1 will
conduct and D2 will not conduct during the positive half cycle. Thus the current flow will
be in the direction P1-D1-C-A-B-GND. Thus, the positive half cycle appears across the
load resistance RLOAD. During the negative half-cycle, the secondary ends P1
becomes negative and P2 becomes positive. At this instant, the diode D1 will be
negative and D2 will be positive with the zero reference point being the ground, GND.
Thus, the diode D2 will be forward biased and D1 will be reverse biased. The diode D2
will conduct and D1 will not conduct during the negative half cycle. The current flow will
be in the direction P2-D2-C-A-B-GND.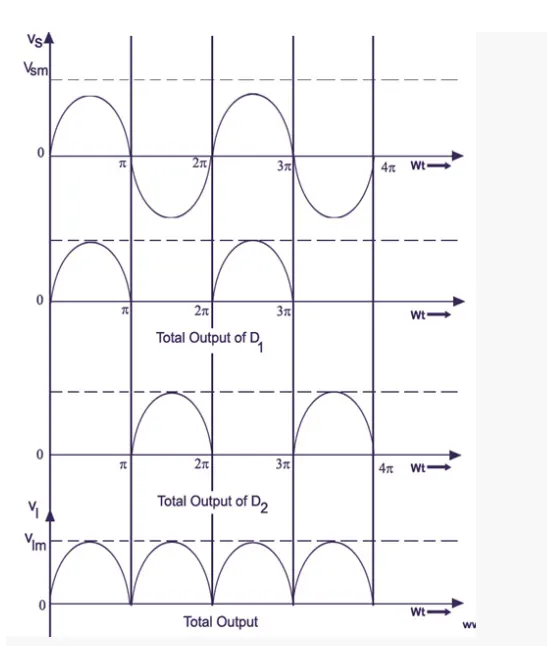
When comparing the current flow in the positive and negative half-cycles, we can
conclude that the direction of the current flow is the same (through load resistance
RLOAD). When compared to the Half-Wave Rectifier, both the half cycles are used to
produce the corresponding output. The frequency of the rectified output voltage is twice
the input frequency. The output that is rectified, consists of a dc component and a lot of
ac components of minute amplitudes.
d). Three-phase half-wave diode rectifier:-
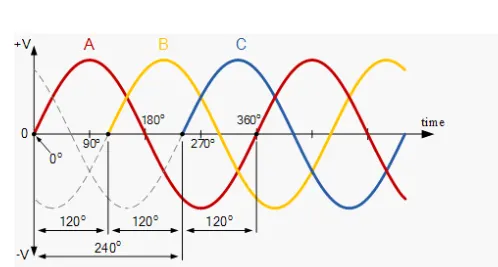
Three-phase Waveform
The advantage here is that a three-phase alternating current (AC) supply can be used
to provide electrical power directly to balanced loads and rectifiers. Since a 3-phase
supply has a fixed voltage and frequency it can be used by a rectification circuit to
produce a fixed voltage DC power which can then be filtered resulting in an output DC
voltage with less ripple compared to a single-phase rectifying circuit.
Three-phase Rectification
Having seen that a 3-phase supply is just simply three single-phases combined
together, we can use this multi-phase property to create 3-phase rectifier circuits.
As with single-phase rectification, three-phase rectification uses diodes, thyristors,
transistors, or converters to create half-wave, full-wave, uncontrolled and fully-controlled
rectifier circuits transforming a given three-phase supply into a constant DC output level.
In most applications, a three-phase rectifier is supplied directly from the mains utility
power grid or from a three-phase transformer if a different DC output level is required by
the connected load.
As with the previous single-phase rectifier, the most basic three-phase rectifier circuit is
that of an uncontrolled half-wave rectifier circuit which uses three semiconductor diodes,
one diode per phase as shown.
Half-wave Three-phase Rectification:
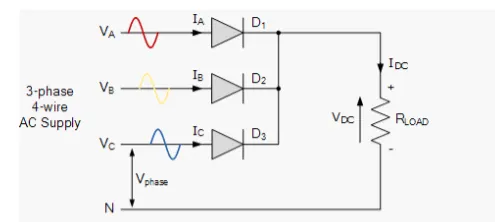
So how does this three-phase half-wave rectifier circuit work? The anode of each diode
is connected to one phase of the voltage supply with the cathodes of all three diodes
connected together to the same positive point, effectively creating a diode-“OR” type
arrangement. This common point becomes the positive (+) terminal for the load while
the negative (-) terminal of the load is connected to the neutral (N) of the supply.
Assuming a phase rotation of Red-Yellow-Blue (V A – V B – V C ) and the red phase (V A )
starts at 0 o . The first diode to conduct will be diode 1 (D 1 ) as it will have a more positive
voltage at its anode than diodes D 2 or D 3 . Thus diode D 1 conducts for the positive half-
cycle of V A while D 2 and D 3 are in their reverse-biased state. The neutral wire provides a
return path for the load current back to the supply.
120 electrical degrees later, diode 2 (D 2 ) starts to conduct for the positive half-cycle of
V B (yellow phase). Now its anode becomes more positive than diodes D 1 and D 3 which
are both “Of” because they are reversed-biased. Similarly, 120 o later V C (blue phase)
starts to increase turning “ON” diode 3 (D 3 ) as its anode becomes more positive, thus
turning “OFF” diodes D 1 and D 2 .
Then we can see that for three-phase rectification, whichever diode has a more positive
voltage at its anode compared to the other two diodes it will automatically start to
conduct, thereby giving a conduction pattern of D 1 D 2 D 3 as shown.
Half-wave Three-phase Rectifier Conduction Waveform
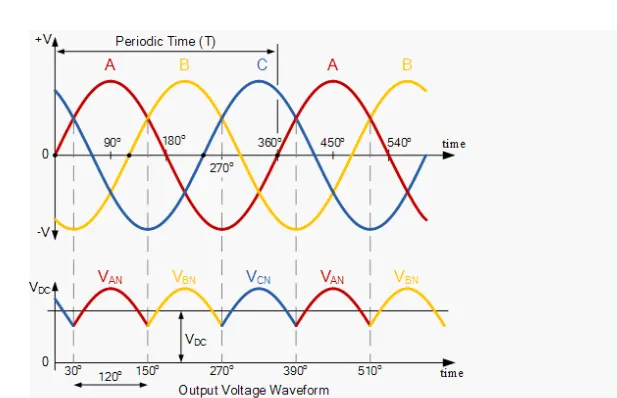
From the above waveforms for a resistive load, we can see that for a half-wave rectifier
each diode passes current for one-third of each cycle, with the output waveform being
three times the input frequency of the AC supply. Therefore there are three voltage
peaks in a given cycle, so by increasing the number of phases from a single-phase to a
three-phase supply, the rectification of the supply is improved, that is the output DC
voltage is smoother.
For a three-phase half-wave rectifier, the supply voltages V A V B and V C are balanced but
with a phase difference of 120 o giving:
V A = V P *sin(ωt – 0 o )
V B = V P *sin(ωt – 120 o )
V C = V P *sin(ωt – 240 o )
Thus the average DC value of the output voltage waveform from a 3-phase half-wave
rectifier is given as: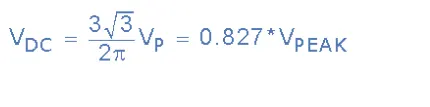
As the voltage supplies peak voltage, V P is equal to V RMS *1.414, it follows that V P is equal
to V P /1.414 giving 0.707*V P , so the average DC output voltage of the rectifier can be
expressed in terms of the RMS (root-mean-squared) phase voltage giving:
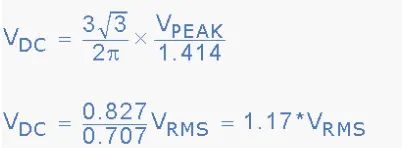
2. DC TO DC CONVERTER
DC-DC converters in an electric vehicle may be classified into unidirectional and
bidirectional converters Unidirectional DC-DC converters cater to various onboard loads
such as sensors, controls, entertainment, utility, and safety equipment. They are also
used in DC motor drives and electric traction. Bidirectional DC-DC converters find
applications in places where battery charging, regenerative braking, and backup power
are required. The power flow in a bidirectional converter is usually from a low voltage
end such as a battery or a supercapacitor to a high voltage side and is referred to as
boost operation.
During regenerative braking, power flows back to the low voltage bus to recharge the
battery (buck mode). As a backup power system. the bidirectional DC-DC converter
facilitates the safe operation of the vehicle when ICES or electric drives fail to drive the
motor. Due to the aforementioned reasons, high power bidirectional DC-DC converters
have gained a lot of importance in the recent past
The converter topologies are classified as
Buck Converters
Boost Converters
Buck-boost Converters
1.Buck Converter
Buck Converters
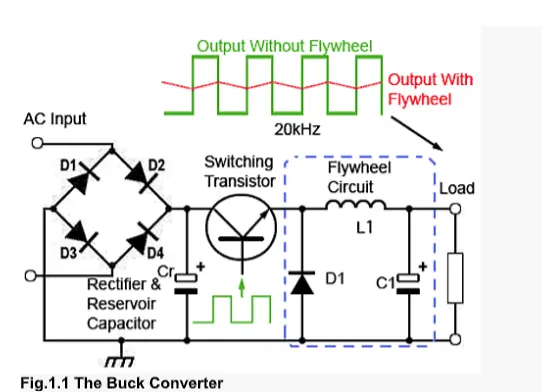
Fig.1.1 The Buck Converter
The Buck Converter
The Buck Converter is used in SMPS circuits where the DC output voltage needs to be
lower than the DC input voltage. The DC input can be derived from rectified AC or from
any DC supply. It is useful where electrical isolation is not needed between the
switching circuit and the output, but where the input is from a rectified AC source,
isolation between the AC source and the rectifier could be provided by the
mains isolating transformer.
The switching transistor between the input and output of the Buck Converter continually
switches on and off at high frequency. To maintain a continuous output, the circuit uses
the energy stored in the inductor L, during the on periods of the switching transistor, to
continue supplying the load during the off periods. The circuit operation depends on
what is sometimes also called a Flywheel Circuit. This is because the circuit acts rather
like a mechanical flywheel that, given regularly spaced pulses of energy keeps spinning
smoothly (outputting energy) at a steady rate.
AC or DC Input
A buck converter is a form of DC to DC converter that can take input directly from a DC
source, such as a battery. The input could also be DC derived from the AC mains (line)
as shown in Fig. 3.1.1 via a rectifier/reservoir capacitor circuit. The AC input to the
rectifier circuit could be AC at high voltage directly from the AC mains supply, or
alternatively at a lower voltage via a step-down transformer. However the DC applied to
the Buck Converter is obtained, it is then converted to a high-frequency AC, using a
switching or ‘chopper’ transistor, driven by a (usually pulse width modulated) square
wave. This results in a high-frequency AC wave, which can then be re-converted to DC
in a much more efficient manner than would be possible in the circuits described
in Power Supplies Module 1.
Buck Converter Operation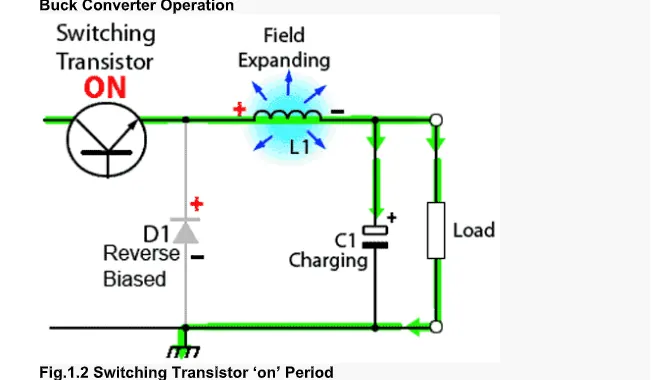
Fig.1.2 Switching Transistor ‘on’ Period
As shown in Fig. 3.1.1 the buck Converter circuit consists of the switching transistor,
together with the flywheel circuit (Dl, L1 and C1). While the transistor is on, the current
is flowing through the load via the inductor L1. The action of any inductor opposes
changes in current flow and also acts as a store of energy. In this case, the switching
transistor output is prevented from increasing immediately to its peak value as
the inductor stores energy taken from the increasing output; this stored energy is later
released back into the circuit as a back e.m.f. as current from the switching transistor is
rapidly switched off.
Transistor Switch ‘on’ Period
In Fig. 3.1.2 therefore, when the switching transistor is switched on, it is supplying the
load with the current. Initially, current flow to the load is restricted as energy is also
being stored in L1, therefore the current in the load and the charge on C1 builds up
gradually during the ‘on’ period. Notice that throughout the on period, there will be a
large positive voltage on the D1 cathode and so the diode will be reverse biassed and
therefore play no part in the action.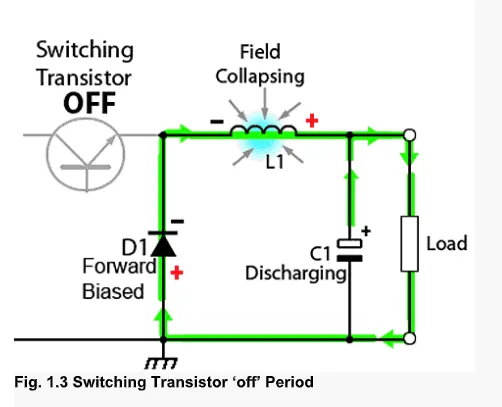
Fig. 1.3 Switching Transistor ‘off’ Period
2.Boost Converter
Switched-mode supplies can be used for many purposes including DC to DC
converters. Often, although a DC supply, such as a battery may be available, its
available voltage is not suitable for the system being supplied. For example, the motors
used in driving electric automobiles require much higher voltages, in the region of 500V,
than could be supplied by a battery alone. Even if banks of batteries were used, the
extra weight and space taken up would be too great to be practical. The answer to this
problem is to use fewer batteries and to boost the available DC voltage to the required
level by using a boost converter. Another problem with batteries, large or small, is that
their output voltage varies as the available charge is used up, and at some point, the
battery voltage becomes too low to power the circuit is supplied. However, if this low
output level can be boosted back up to a useful level again, by using a boost converter,
the life of the battery can be extended.
The DC input to a boost converter can be from many sources as well as batteries, such
as rectified AC from the mains supply, or DC from solar panels, fuel cells, dynamos and
DC generators. The boost converter is different to the boost converter in that its output
voltage is equal to, or greater than its input voltage. However, it is important to
remember that, as power (P) = voltage (V) x current (I), if the output voltage is
increased, the available output current must decrease.
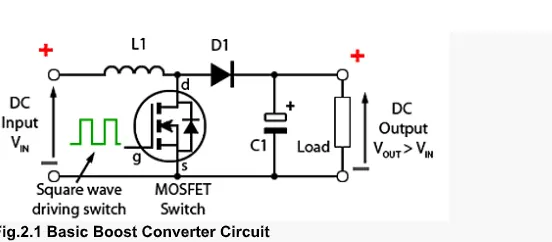
Fig.2.1 Basic Boost Converter Circuit
Fig. 3.2.1 illustrates the basic circuit of a Boost converter. However, in this example the
switching transistor is a control MOSFET both bipolar power transistors and MOSFETs
are used in power switching, the choice being determined by the current, voltage,
switching speed and cost considerations. The rest of the components are the same as
those used in the buck converter illustrated in Fig. 3.1.2, except that their positions have
been rearranged.
Boost converter Operation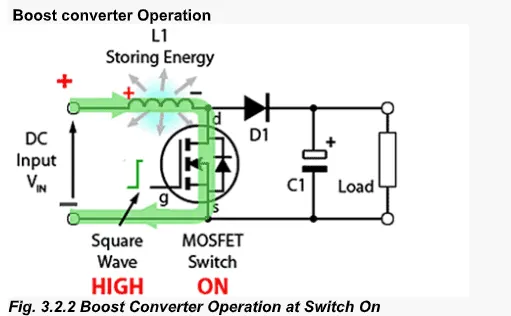
Fig. 3.2.2 Boost Converter Operation at Switch On
Fig 3.2.2 illustrates the circuit action during the initial high period of the high-frequency
square wave applied to the MOSFET gate at startup. During this time MOSFET
conducts, placing a short circuit from the right-hand side of L1 to the negative input
supply terminal. Therefore a current flow between the positive and negative supply
terminals through L1, which stores energy in its magnetic field. There is virtually no
current flowing in the remainder of the circuit as the combination of D1, C1 and the load
represent a much higher impedance than the path directly through the heavily
conducting MOSFET.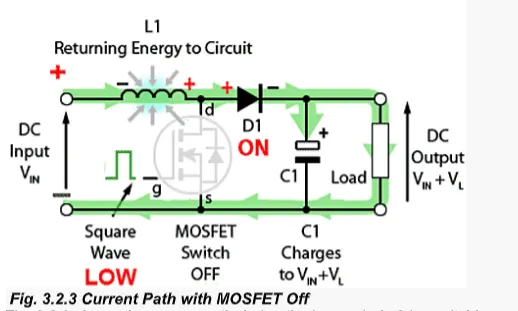
Fig. 3.2.3 Current Path with MOSFET Off
Fig. 3.2.3 shows the current path during the low period of the switching square wave
cycle. As the MOSFET is rapidly turned off the sudden drop in current causes L1 to
produce a back e.m.f in the opposite polarity to the voltage across L1 during the on
period, to keep the current flowing. This results in two voltages, the supply voltage
V IN and the back e.m.f.(V L ) across L1 in series with each other.
This higher voltage (V IN +V L ), now that there is no current path through the MOSFET,
forward biases D1. The resulting current through D1 charges up C1 to V IN +V L minus the
small forward voltage drop across D1, and also supplies the load.
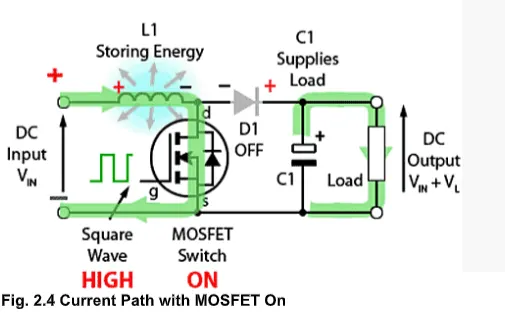
Fig. 2.4 Current Path with MOSFET On
Fig..2.4 shows the circuit action during MOSFET on periods after the initial start-up.
Each time the MOSFET conducts, the cathode of D1 is more positive than its anode,
due to the charge on C1. D1 is therefore turned off so the output of the circuit is isolated
from the input, however, the load continues to be supplied with V IN +V L from the charge
on C1. Although the charge C1 drains away through the load during this period, C1 is
recharged each time the MOSFET switches off, so maintaining an almost steady output
voltage across the load.
The theoretical DC output voltage is determined by the input voltage (V IN ) divided by 1
minus the duty cycle (D) of the switching waveform, which will be some figure between
0 and 1 (corresponding to 0 to 100%) and therefore can be determined using the
following formula:
3.Buck-Boost Converter
A Buck-Boost converter is a type of switched-mode power supply that combines the
principles of the Buck Converter and the Boost converter in a single circuit. Like other
SMPS designs, it provides a regulated DC output voltage from either an AC or a DC
input.
The Buck converter described in Power Supplies Module 3.1 produces a DC output in a
range from 0V to just less than the input voltage. The boost converter will produce an
output voltage ranging from the same voltage as the input to a level much higher than
the input.
There are many applications, however, such as battery-powered systems, where the
input voltage can vary widely, starting at full charge and gradually decreasing as the
battery charge is used up. At full charge, where the battery voltage may be higher than
actually needed by the circuit being powered, a buck regulator would be ideal to keep
the supply voltage steady. However, as the charge diminishes the input voltage falls
below the level required by the circuit, and either the battery must be discarded or re-
charged; at this point, the ideal alternative would be the boost regulator described in
Power Supplies Module 3.2
By combining these two regulator designs it is possible to have a regulator circuit that
can cope with a wide range of input voltages both higher or lower than that needed by
the circuit. Fortunately, both buck and boost converters use very similar components;
they just need to be re-arranged, depending on the level of the input voltage.
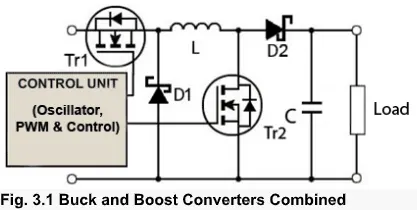
Fig. 3.1 Buck and Boost Converters Combined
In Fig. 3.3.1 the common components of the buck and boost circuits are combined. A
control unit is added, which senses the level of input voltage, then selects the
appropriate circuit action. (Note that in the examples in this section the transistors are
shown as MOSFETs, commonly used in high-frequency power converters, and the
diodes shown as Schottky types. These diodes have a low forward junction voltage
when conducting, and are able to switch at high speeds).
Operation as a Buck Converter
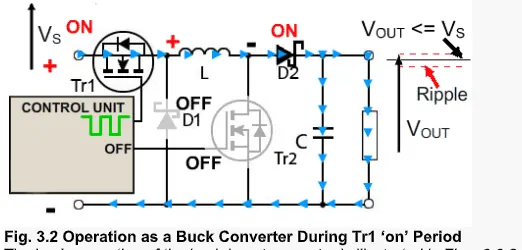
Fig. 3.2 Operation as a Buck Converter During Tr1 ‘on’ Period
The basic operation of the buck-boost converter is illustrated in Figs. 3.3.2 to 3.3.5
Fig. 3.3.2 shows the circuit operating as a Buck Converter. In this mode, Tr2 is turned
off, and Tr1 is switched on and off by a high-frequency square wave from the control
unit. When the gate of Tr1 is high, current flows through L, charging its magnetic field,
charging C and supplying the load. The Schottky diode D1 is turned off due to the
positive voltage on its cathode.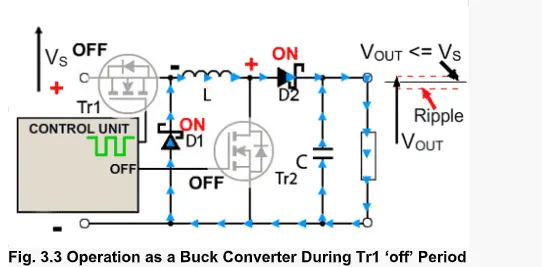
Fig. 3.3 Operation as a Buck Converter During Tr1 ‘off’ Period
Fig .3.3 shows the current flow during the buck operation of the circuit when the control
unit switches Tr1 off. The initial source of current is now the inductor L. Its magnetic
field is collapsing, the back e.m.f. generated by the collapsing field reverses the polarity
of the voltage across L, which turns on D1 and current flows through D2 and the load.
As the current due to the discharge of L decreases, the charge accumulated in C during
the period of Tr1 now also adds to the current flowing through the load, keeping
V OUT reasonably constant during the off period. This helps keep the ripple amplitude to a
minimum and V OUT close to the value of V S .
Operation as a Boost Converter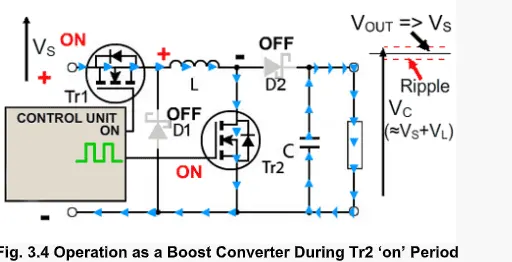
Fig. 3.4 Operation as a Boost Converter During Tr2 ‘on’ Period
In Boost Converter mode, Tr1 is turned on continually and the high-frequency square
wave is applied to the Tr2 gate. During the on periods when Tr2 is conducting, the input
current flows through the inductor L and via Tr2, directly back to the supply negative
terminal charging up the magnetic field around L. Whilst this is happening D2 cannot
conduct as its anode is being held at ground potential by the heavily conducting Tr2. For
the duration of the on period, the load is being supplied entirely by the charge on the
capacitor C, built upon previous oscillator cycles. The gradual discharge of C during the
on a period (and its subsequent recharging) accounts for the amount of high-frequency
ripple on the output voltage, which is at a potential of approximately V S + V L .
The Off Period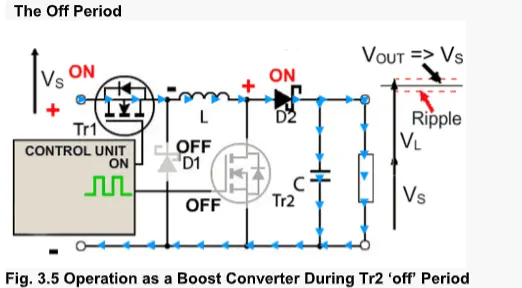
Fig. 3.5 Operation as a Boost Converter During Tr2 ‘off’ Period
At the start of the off period of Tr2, L is charged and C is partially discharged. The
inductor L now generates a back e.m.f. and its value that depends on the rate of change
of current as Tr2 switches of and on the amount of inductance the coil possesses;
therefore the back e.m.f can be any voltage over a wide range, depending on the design
of the circuit. Notice particularly that the polarity of the voltage across L has now
reversed, and so adds to the input voltage V S giving an output voltage that is at least
equal to or greater than the input voltage. D2 is now forward biased and so the circuit
current supplies the load current, and at the same time re-charges the capacitor to V S
3)DC TO AC CONVERTER
An inverter is a device that converts DC power from the battery to AC power used in an
electric vehicle motor. The inverter can change the speed at which the motor rotates by
adjusting the frequency of the alternating current.
The use of Inverters can increase or decrease the power or torque of the Engine the
motor by adjusting the amplitude of the signal. It plays a significant role in capturing
energy from regenerative braking and feeding it back to the battery. The output voltage
waveform of ideal inverters should be sinusoidal, However, the waveform of practical
inverters are non-sinusoidal and contain certain harmonics
1) AC T0 DC CONVERTER RECTIFIER-USED IN EV CHARGER
2) DC TO DE CONVERTER (CHOPPER-ED TO SUPPLY DC POMEN 10 AUSARY
LEAD AND CAR HEADLIGHTS
3) DC T0 AC CONVERTER INVERTERS-SED TO SUPPLY POWER TO MASTER
2).
An Electric Vehicle's powertrain with 72V battery pack in shown in the diagram below. The duty ratio for acceleration operation is 'd1' and for the braking operation the duty ratio is 'd2'.
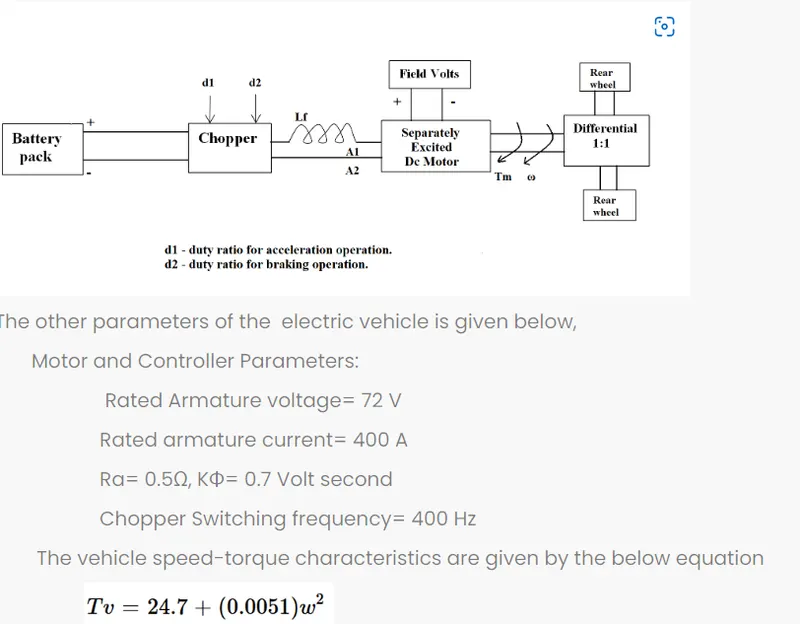
The other parameters of the electric vehicle are given below,
Motor and Controller Parameters:
Rated Armature voltage= 72 V
Rated armature current= 400 A
Ra= 0.5Ω,
KΦ= 0.7 Volt second
Chopper Switching frequency= 400 Hz
The vehicle speed-torque characteristics are given by the below equation
What is EV steady-state speed if the duty cycle is 70%?
Solution:-
vehicle output voltage (Vv) is given by:_
Vv=Battery voltage (V)*Duty cycle
Vv=72*0.70
Thus vehicle voltage =50.04
Now Equation for vehicle torque is given by
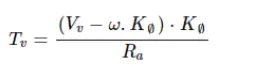
T= Vehicle Torque (N-m)
V= Vehicle voltage (Volts)
ω =steady-state speed of the vehicle (rps)
K=Motor constant
Ra=Armature Resistance
Substituting all these values in the equation, we get:
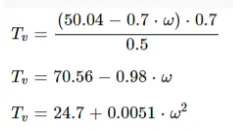
Solving these two equations.
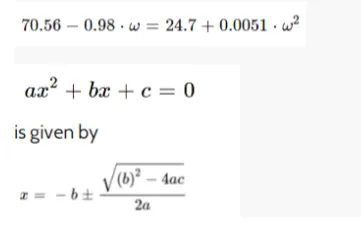
We get a quadratic equation
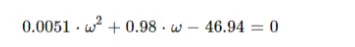
since the quadratic equation, we get two values
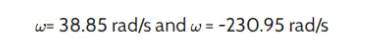
we have taken positive value
steady-state speed of the vehicle (rps)=38.85 rps
3).Develop a mathematical model of a DC Motor for the below equation using
Simulink.
ω= V/Kϕ -Ra/Kϕ^2.T
let us draw a model for the above equation as shown below.
let
V=50.4 volts
Kϕ=0.7
Ra=0.5 ohms
let us consider torque as a linearly increasing signalled that is equal to the ram block of
the following Simulink model:
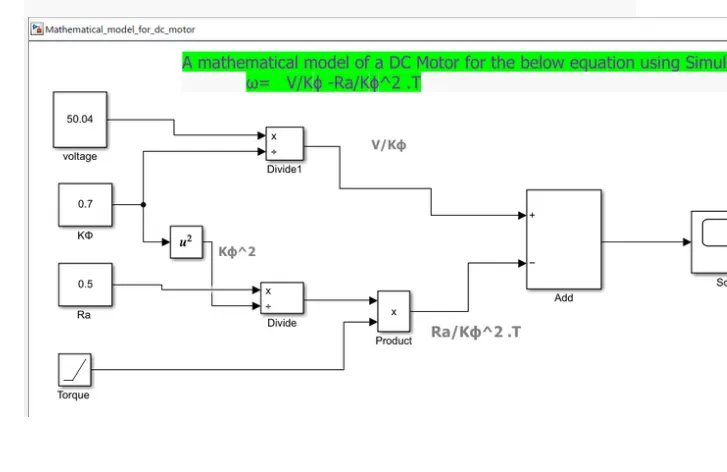
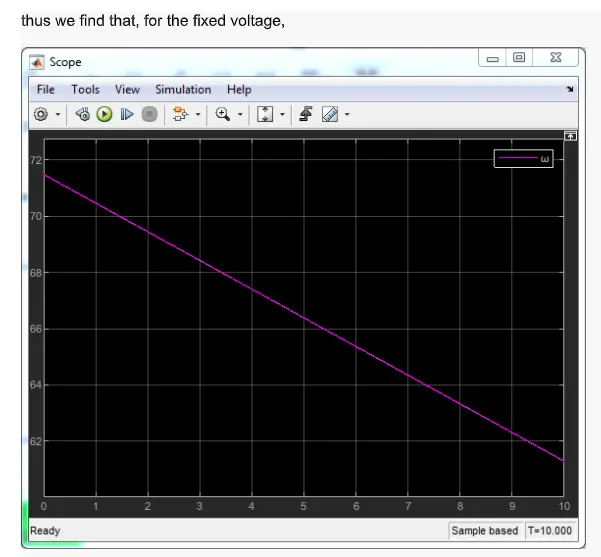
the speed of the motor is inversely proportional to load this means that increase in load
torque will result in a decrease in speed.
4. Refer to the blog on the below topic Induction Versus DC brushless motors by
Wally Rippel, Tesla Explain in brief about author's perspective. The following
points can be concluded from the above topic:
• In the first place, the creator portrays the predominance of Internal Combustion
Engines (ICE) in the realm of the auto business and furthermore examine various sorts
of motors. He clarifies that all motors were comparative and it was dependent upon the
client to choose as indicated by their necessity. He additionally talks about enlistment
engines and brushless DC engines and presents his view that these two innovations will
be broadly utilized in the coming years.
• Then he clarifies the working of both a 3-stage enlistment engine and a brushless DC
engine. . Presently the creator has done a correlation between these two innovations
and expressed a few benefits and burdens of each.
• Induction engine enjoys a few benefits like it has no magnets The engine can turn over
under load. No inverter is required. A few disservices of Induction engines are: They
can't work from DC: AC is an absolute necessity. Shaft speed is proportionate to line
recurrence. Consequently, when utilized with utility force, they are steady speed
machines. When worked from utility force, they have restricted beginning force and
fairly restricted running pinnacle force abilities, when contrasted with DC type machines
• Brushless DC engine enjoys a few benefits like considerably less rotor heat is
produced with the DC brushless drive. The pinnacle point energy productivity for a DC
brushless drive will normally be a couple of rate focuses higher than for an acceptance
drive. A few drawbacks of a Brushless DC engine are: as machine size develops. the
attractive misfortunes increment proportionately and part load proficiency drops.
Perpetual magnets are costly and hard to deal with because of extremely enormous
powers that become an integral factor when anything ferromagnetic draws near to them.
• Finally, the creator couldn't pick which drive is superior to the next however clarifies
that DC brushless drives will probably keep on overwhelming in the crossbreed and
coming module half breed markets, and that enlistment drives will probably keep up with
strength for the elite unadulterated electrics.