Week-4 Challenge WOT Condition Part-2
Week-4
Challenge WOT Condition
Sir, Please find attached and pasted explanation along with necessary matlab files
<!-- [if !supportLists]-->1. What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type?
Mapped models are basically steady state models which are time invariant, where the variables like speed and torque are predefined. Here we need to have complete knowledge on past and future demands to derive the preset values.(heuristic operation rules)
Runs faster
Dynamic models are based on real time feedback values and they are optimized based on system components
Open EvReference Model from the power train blockset and Follow the steps
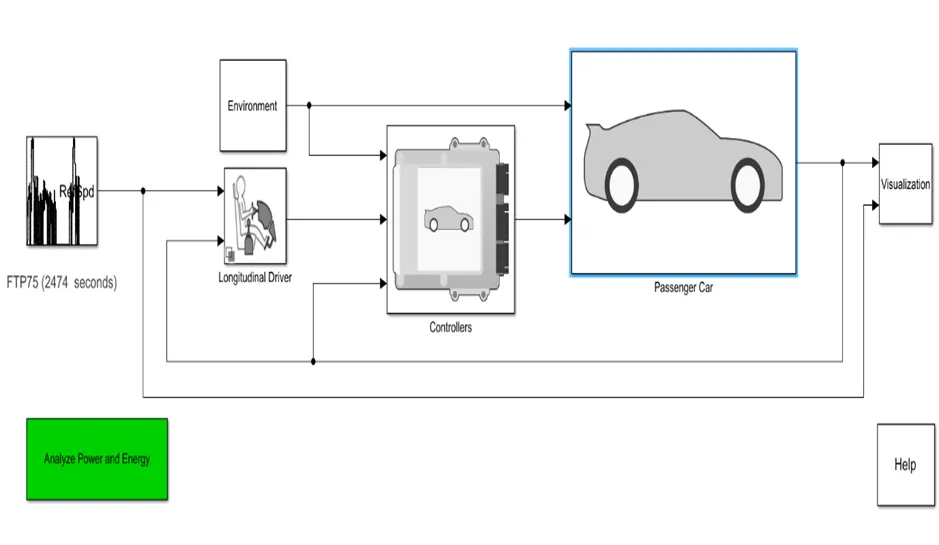
Passenger caràElectric Plant àGenMapped/MotMappedàGenMapped/GenDynamic & MotMapped/MotDynamic
Motor:
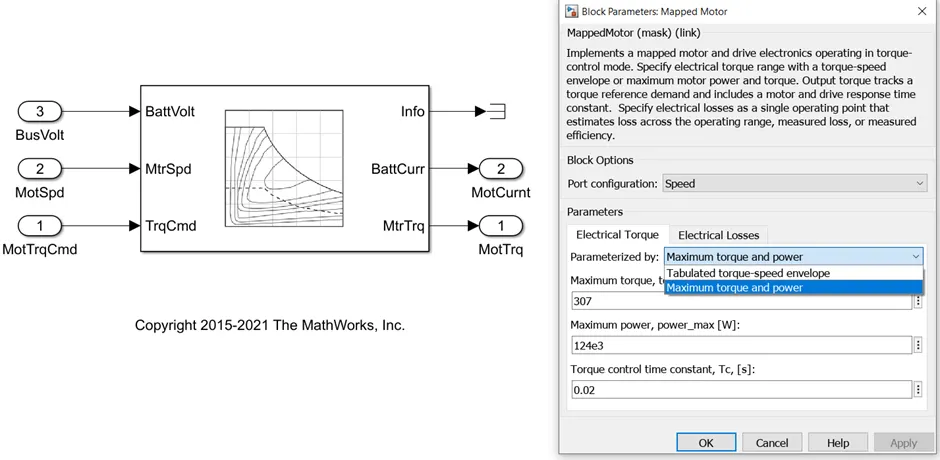
Motor Mapped:
Inside the mapped motor we can see from the block, Maximum Torque, Maximum Power, Torque control time constant are fixed and they can not be changed dynamically according to situation and such type of models are called Mapped models.
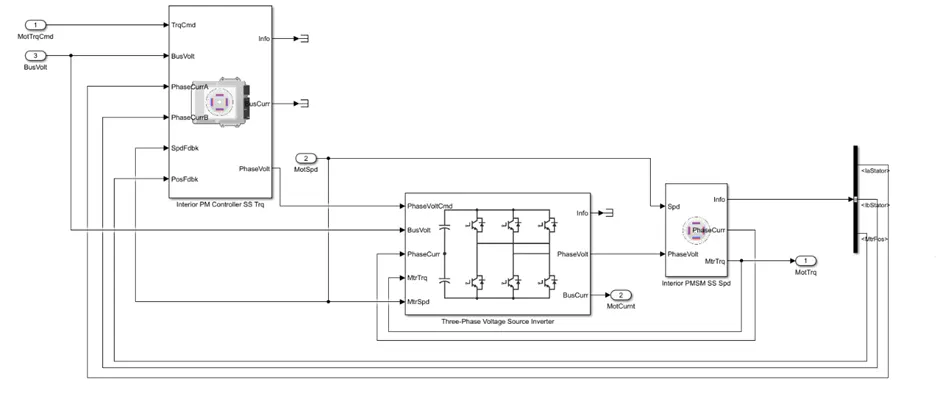
Motor Dynamic:
In the motor dynamic block there is optional PMSM controller where the speed and basic information are used as feedback for the dynamic control
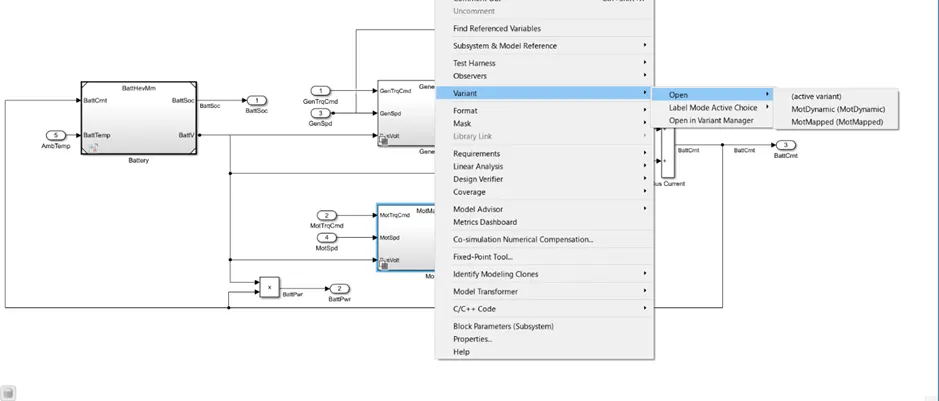
To enable motor mapped to motor dynamic
Right click on motor modelàClick variantàOpenà Choose the variant we need
To label the variant we chose,
Right click on model àVariantàLabel Mode active choiceàChoose to rename
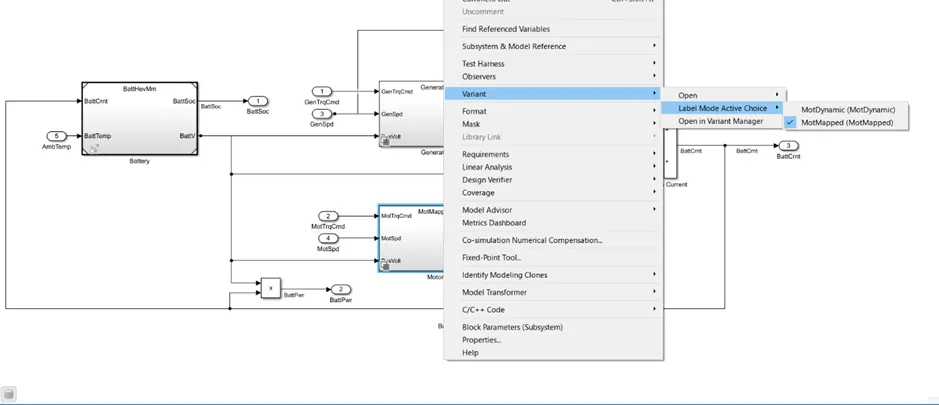
Model type can be removed by right click on the subsystem we want to change and then click on subsystem and model reference and then convert to variant system
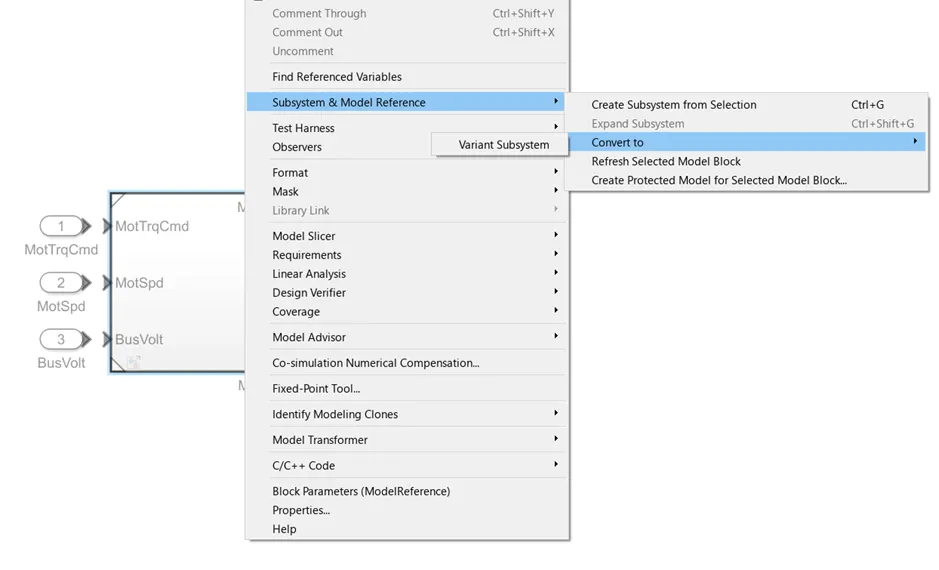
Like motor, Generator and Engine also have mapped and Dynamic type. It is our priority to keep the model mapped or dynamic using the variant system
<!-- [if !supportLists]-->2. <!--[endif]-->How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
In the HEV reference model, Calculation of Miles per gallon is available in Visualization block as it comes under performance evaluation
Visualizationà Performance calculation
Miles/gallon is Equivalent to Kilometer/Litre or miles/Litre.
1 Litre = 0.26412 gallon as referred in google.
For instance:
KilometerPerLitre/MilesPerGallon = Total distance travelled(Km/Miles) /
Amount of Fuel used ( Gallon/Litre)
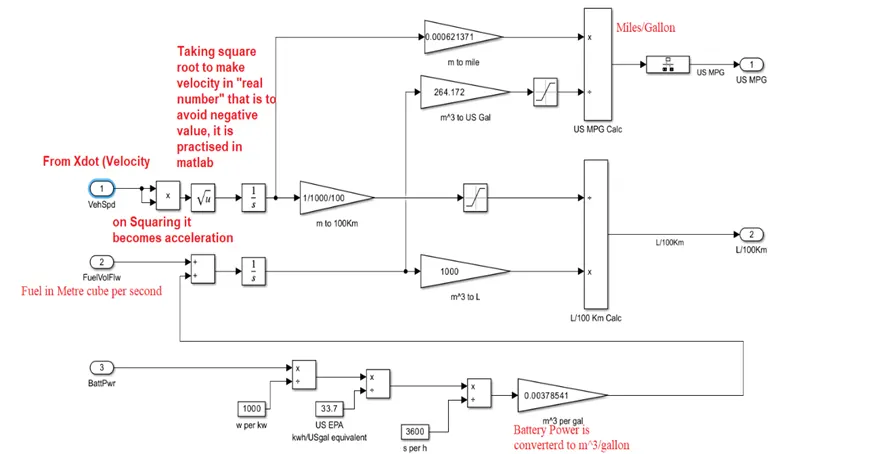
From the above diagram we can see that flow rate is measured in metre cube per second and it is added with battety equivalent of metre cube value and is converted to gallon by the gain of 264.172
Also, we see that vehicle speed is received from earlier block xdot, which is velocity reference which is squared and taken square root to convert the value to real number, sometimes there is possibility of getting negative value, hance to avoid we take squareroot and then through integrator to convert it back to meter
AccelerationàVelocityàSpeed
<!-- [if !supportLists]-->3. <!--[endif]-->Run the HEV Reference Application with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
Search in Matlab documentation “ HEV reference application” and open Multimode model
Click on the drive cycle and select WOT and change parameters according to need
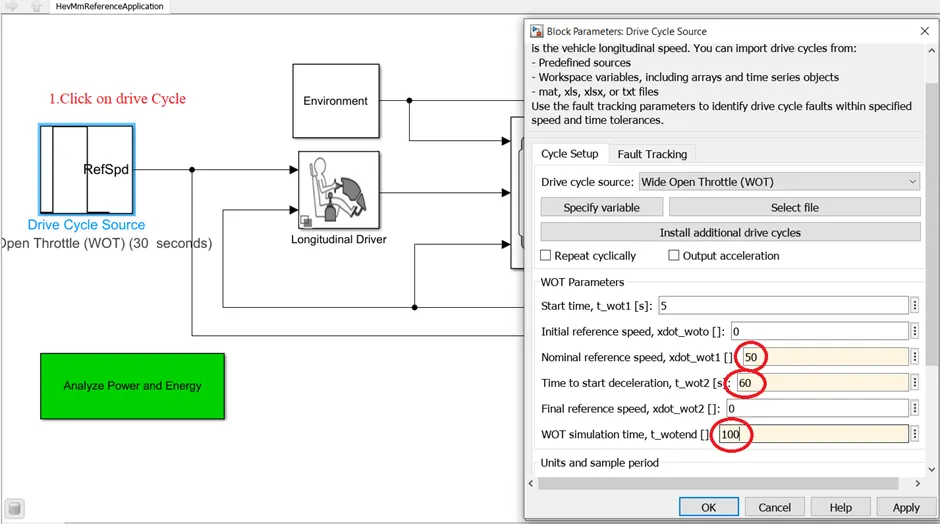
After Entering the drive cycle WOT value and keeping all the other parameters same and run the simulation for 100s.
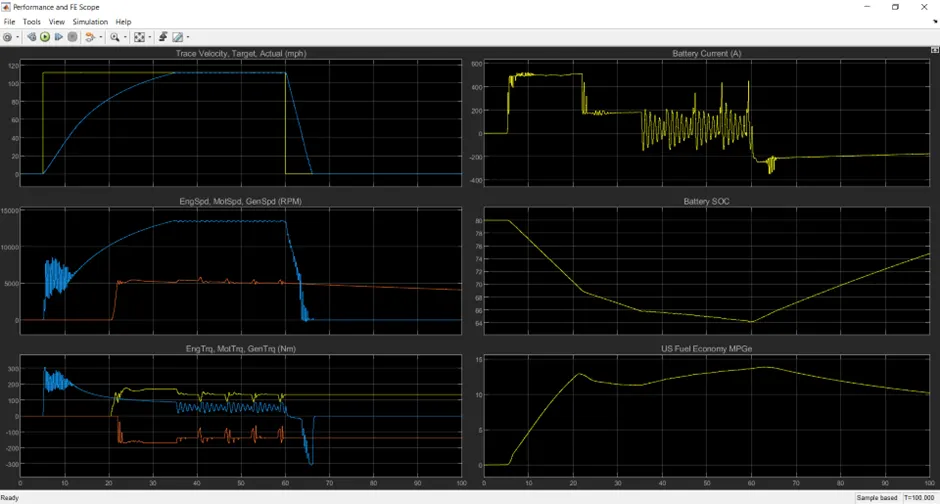
For the first 5 seconds, the input speed is zero and the initial speed of the vehicle is zero.
From t=6 to t=60 the vehicle is given full throttle to obtain a speed of 100m/s.
From t=61 to t=100 the vehicle is set to decelerate from 100m/s to 0m/s
Scope can be viewed by following visualizationà Performance and FE scope
Case 1: WOT parameters set with out changing Grade=0 and Wind velocity=0
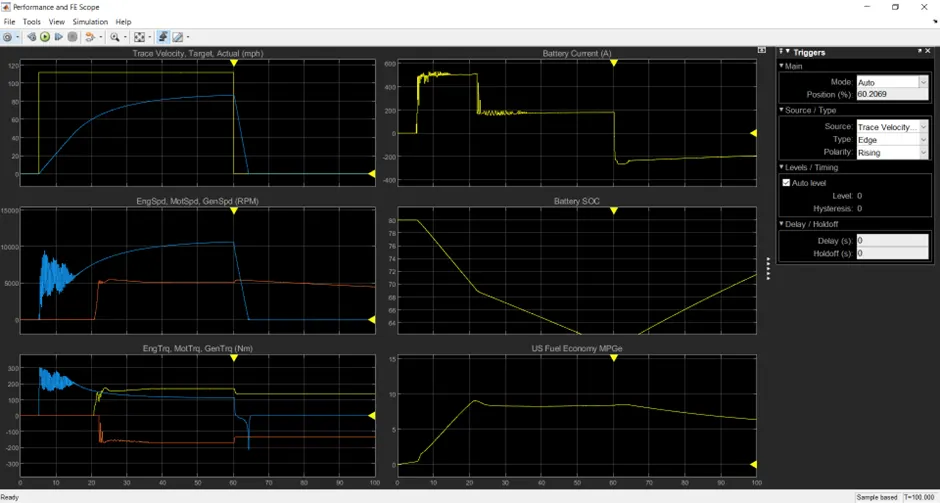
Case 2: WOT parameters set changing Grade=7 and Wind velocity=0
Case 2: WOT parameters set changing Grade=7 and Wind velocity=10
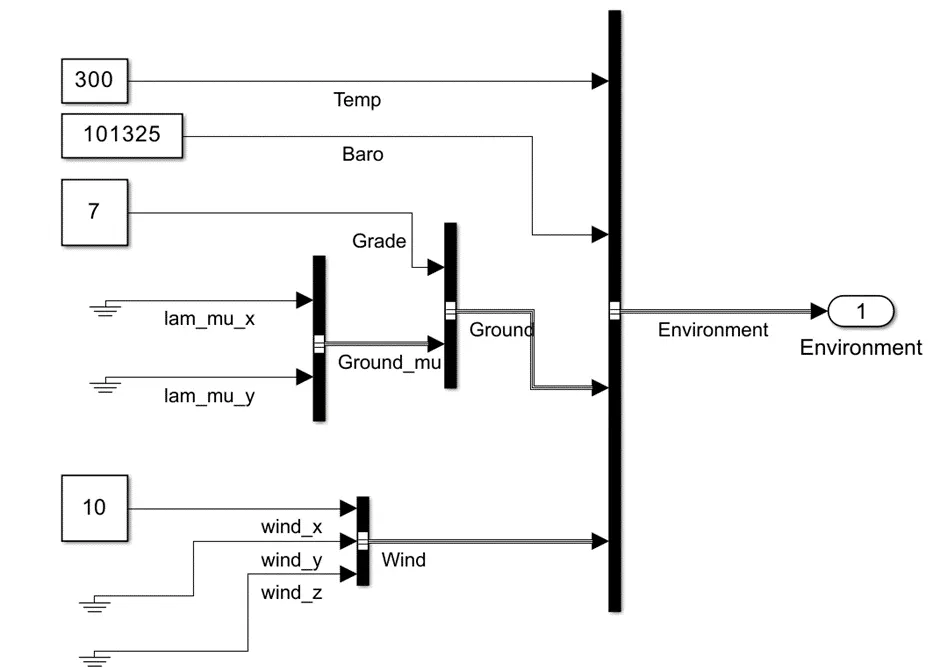
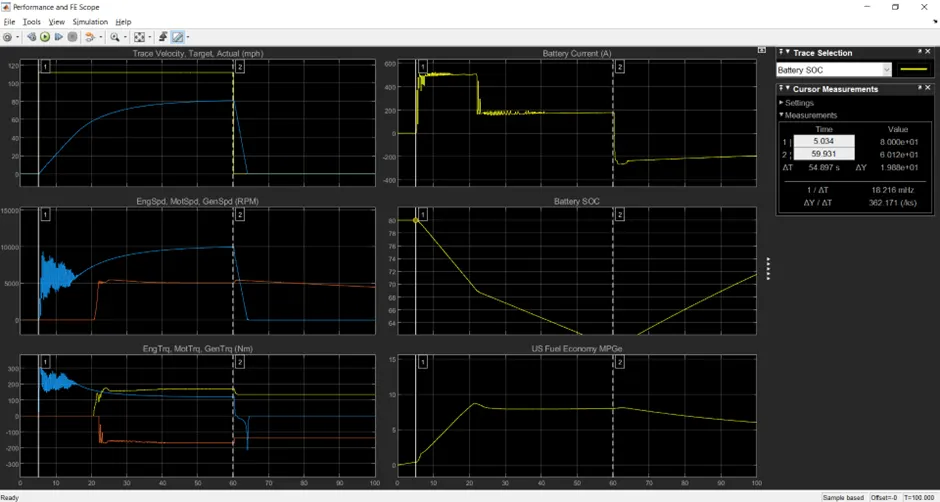
Increasing gradeability and wind velocity delays the vehicle from achieving expected speed
<!-- [if !supportLists]-->4. <!--[endif]-->Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
In EV Reference application model , we set WOT parameters set changing Grade=7 and Wind velocity=10
<!-- [if gte mso 9]><xml>
|
Parameters |
HEV |
EV |
|
Trace Velocity |
Slower |
Faster and smoother |
|
Battery Current |
Peak varies |
Constant Peak current |
|
Battery SOC |
Much reduced |
Not much |
|
Motor Speed |
Less RPM |
More RPM |
|
Motor Torque |
Higher than EV |
Lesser than HEV |
|
MPG |
19.88 lower |
14.36 higher |