Week-4 Challenge WOT Condition Part-2
AIM:
The aim of this challenge is to understand the basics of the powertrain blockset in MATLAB.
Theory:
What is a Powertrain blockset?
A powertrain is an assembly of every component that pushes your vehicle forward. Your car's powertrain creates power from the engine and delivers it to the wheels on the ground. Powertrain Blockset provides fully assembled reference application models of automotive powertrains, including gasoline, diesel, hybrid, and electric systems.
It includes a component library for simulating engine subsystems, transmission assemblies, traction motors, battery packs, and controller models.
Question 1:
What is the difference between the mapped and dynamic models of engine, motor, and generator? How can you change the model type.
The major difference between the mapped and dynamic models are explained below in terms of an engine.
Mapped type - (CiMappedEngine, SiMappedEngine)
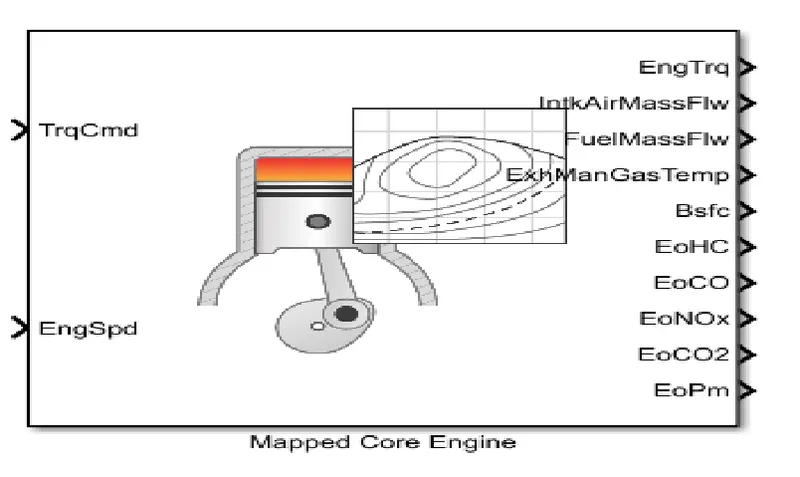
We use this block if we have engine data from a dynamometer or a design tool like GT-POWER, and also for quasi-steady-state engine simulations.
Dynamic type - (CiEngine, SiEngine)
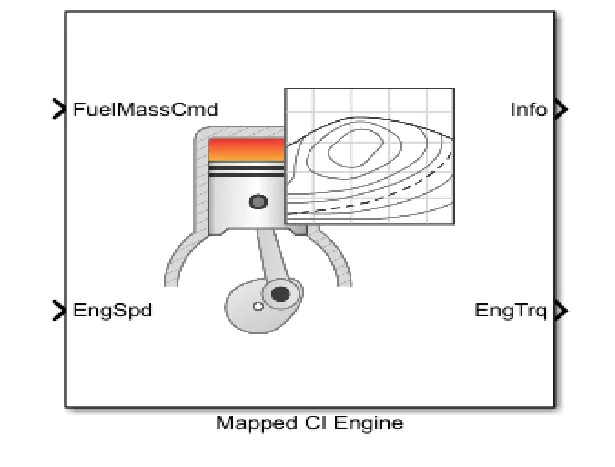
We use it when we need a more detailed dynamic model and have component-level data and also to analyze the impact of individual engine components on the overall performance
Further to summarize the differences ;
- If we need a more detailed and accurate dynamic analysis, we need to use the dynamic variant and if we need to have a faster execution of the model, we need to use the mapped variant.
- The mapped variant is used for a system-level simulation where we do not know the detailed parameters of the engine, motor, or generator. Whereas, a dynamic variant is used for a component-level simulation where we know all the detailed parameters of the engine, motor, or generator.
- The mapped variant uses a look-up table to calculate the values and obtain results whereas the dynamic variant uses the input data we provide for the calculations.
Now in the example model of the powertrain blockset, we have the option of using both the mapped and dynamic models for obtaining the results as per requirement.
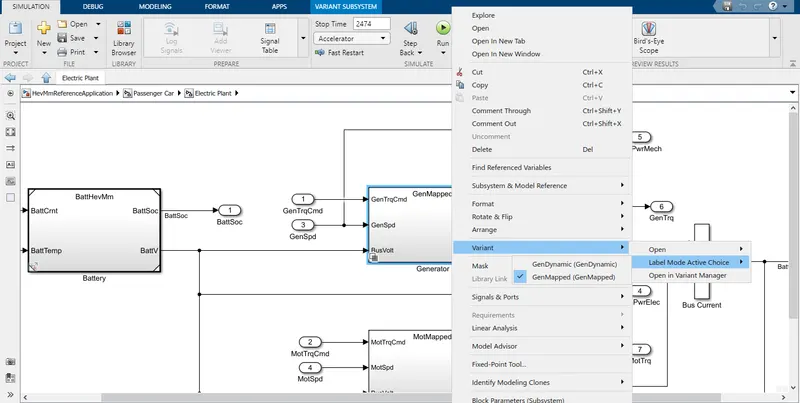
Steps to change the model type:
- Right-click on the model.
- Navigate to Variant.
- Navigate to Label mode active choice.
- Select between the mapped or dynamic model.
Question 2:
How does the model calculate miles per gallon? Which factors are considered to model fuel flow
The three variables that are taken as inputs to calculate miles per gallon are:
- Vehicle Speed(from drive cycle)
- Fuel Volume Flow(from engine output)
- Battery(from the state of charge output)
The vehicle speed is used to calculate the total distance of the drive cycle, by integrating the root mean square over the total time
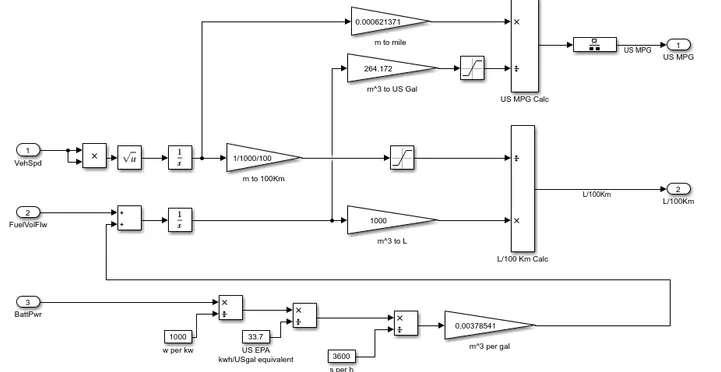
Used blocks explained:
The vehicle speed is multiplied by itself using the product block and then the square root of the value is taken using the sqrt block
The next step is to integrate the vehicle speed to get the distance covered by the vehicle i.e., converting the value from m/s to m. The integration is done using the integrator block
Now, we need to convert meters to miles. We know that 1m = 0.000621371 miles. Hence we use the gain block
The battery power which is converted to m^3/gallon is added with the value of fuel flow and then will be integrated using the 'integrate' blocks.
Now the value of the sum of fuel flow and battery power in the m^3 units will be converted into US gal using the gain block and multiplying the same with the conversion value is 264.172.
This value will be limited to its upper and lower limits using the 'saturation' block. The upper limit being infinity and the lower limit being '1e-3'.
Now the distance covered by the vehicle which is in miles and the sum of fuel flow and battery power which is in US gal will be divided to obtain the result as required by us. A rate transition block
Question 3:
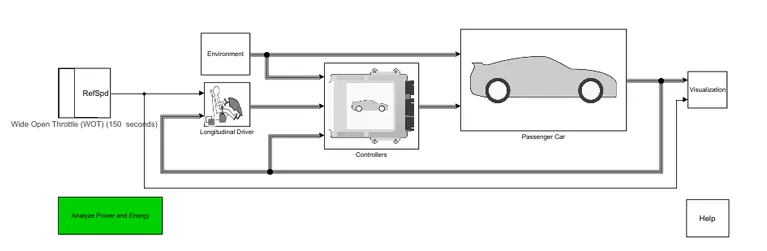
The HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
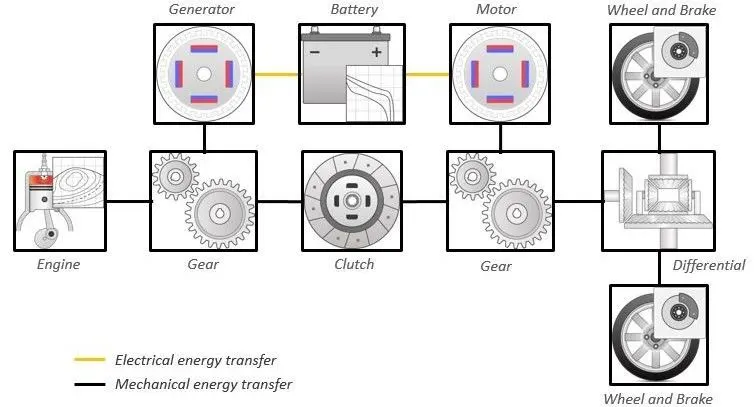
An make the default, the drive cycle that is selected would be 'FTP75'. There are many subsystems included in this model, the environment subsystem, the longitudinal driver, the controllers, the passenger car subsystem,
Simulink model;
Now drive cycle parameters are,
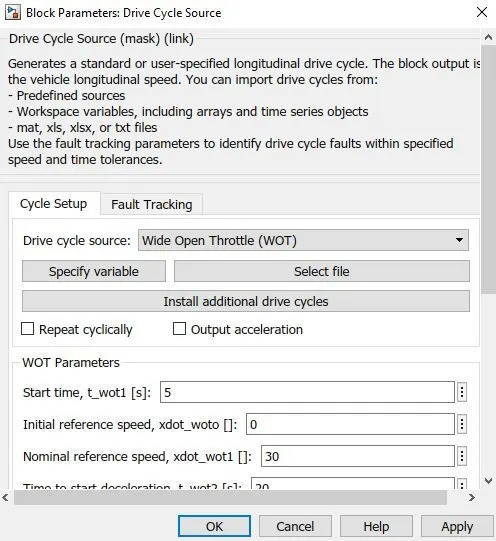
The value of selction is select the WOT condition and decide on the parameters, we have to change the grade and wind velocity values. We can do that by going into the environment subsystem.
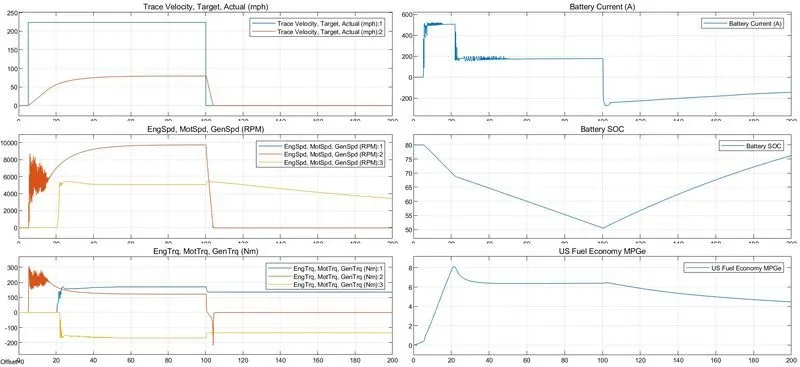
The below images shows the environment subsystem and we have changed the grade value from 0 to 6%, and the wind velocity from 0 to 10 mph
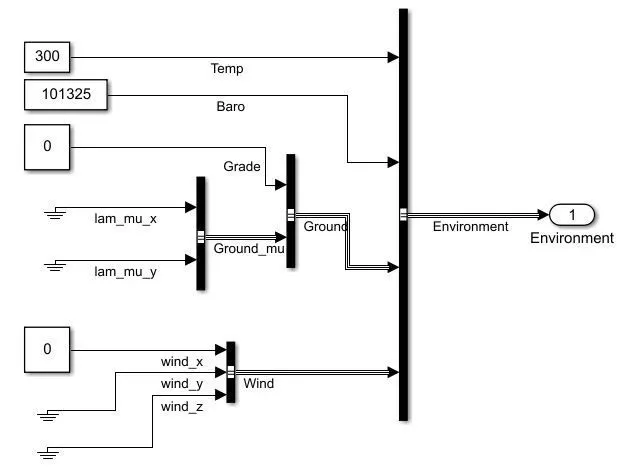
- An the value are top speed of the cycle being 100 m/s, cycle time being 200 sec,
- start deceleration being 100 sec, grade being 6% and wind velocity being 8m/s
Plot 1
The velocity of the vehicle concerning driving cycle data with the time scale on the x-axis. The vehicle reaches a maximum of 80 m/s as there are other forces acting on it.
Plot 2
The changes in the speed of the engine, motor, and generator in RPM throughout the time scale in the x-axis.
Plot 3
An torque characteristics and its changes of the engine, motor, and generator in Nm throughout the drive cycle.
Plot 4
The battery current values (A) and their changes for various acceleration inputs as per the drive cycle. The peak current discharge is at 500 Amps and the peak current charge is at -200 Amps.
Plot 5
An finally battery state of charge SOC(%) and its changes corresponding to the driving inputs. The battery SOC dropped from 80% to 50% in 100 seconds at the provided conditions.
Plot 6
The fuel economy as a mile per gallon for the corresponding input driving conditions.
Question 4:
Keeping all other parameters the same, compare the simulated results of hybrid and pure electric powertrains
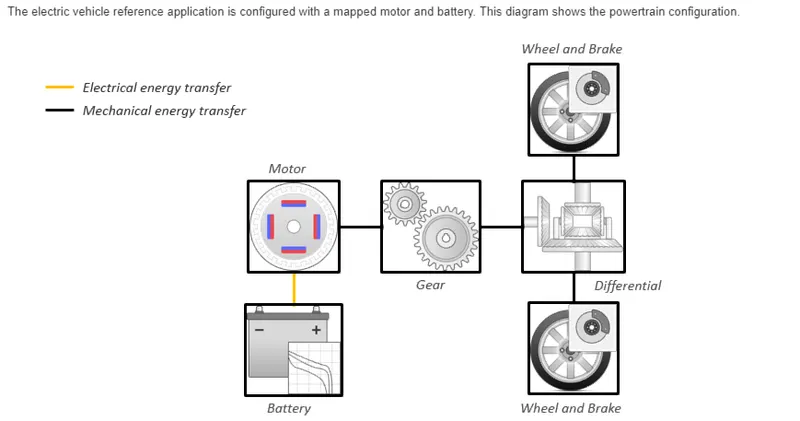
Simulink model;
Output result:
Plot 1
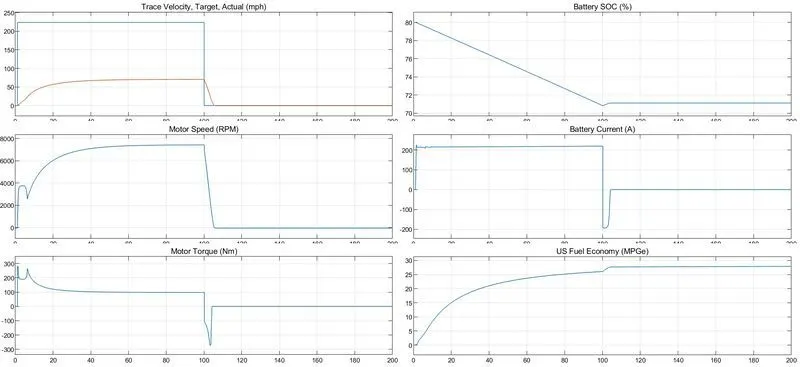
The velocity of the vehicle with respect to the drive cycle data with the time scale on the x-axis. The top speed achieved is approximately around 75 m/s as there are other forces acting on it.
Plot 2
The changes in the speed of the motor in RPM throughout the drive cycle.
Plot 3
The torque characteristics and its changes of the motor in Nm throughout the drive cycle.
Plot 4
The battery state of charge SOC (%) and its changes corresponding to the driving inputs. The battery drops from 80% to 71% in 100 sec for the given driving conditions.
Plot 5
An the battery current and its changes for various acceleration inputs as per the drive cycle. The maximum current discharged is 200 Amps and the maximum current charged is -200 Amps.
Plot 6
shows the equivalent fuel economy as a mile per gallon for the corresponding input driving conditions
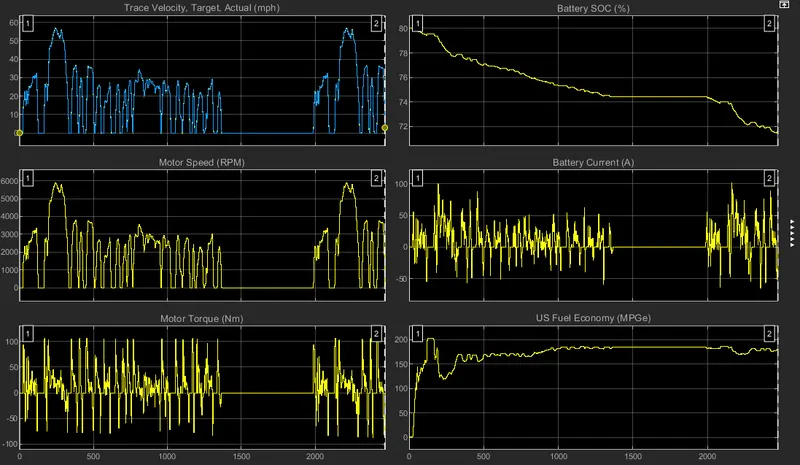
Full electric vehicle:
simulink output:
Conclusion:
Studied the powertrain blockset and determined simulated result for the condition given
an WOT condition is successfully verified.
Drive link:
https://drive.google.com/file/d/19WuP8i__Fz2yCO1ITdgUtfi0h3kZEG9W/view?usp=sharing