Week-4 Challenge WOT Condition Part-2
EV batch-21
here given that question 1
What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type
Ans: In order to aee the difference between mapped model and dynamic model of engine, motor and generator we have to open Ev reference Application from the help menu of MATLAB window. which looks like given the below options to proceed your self
1. open matlab version 2022A after that go to tool bar we need help section we search in EV REFENCE APPLICATION see the below figure we can understand
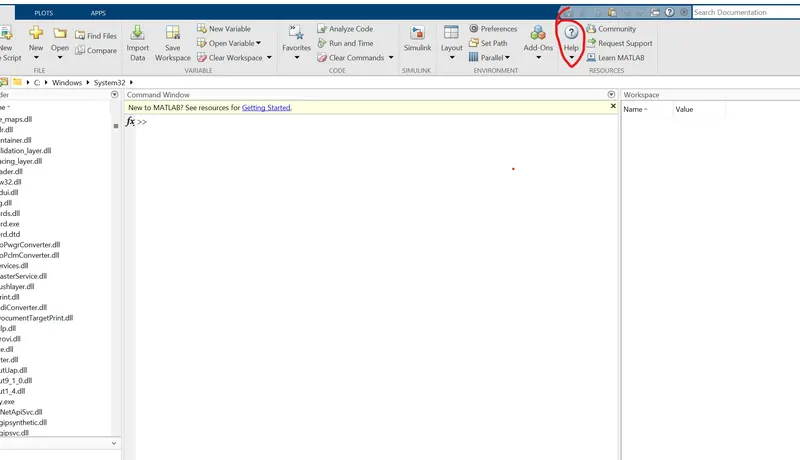
the Ev refence model tab is open like this see the below
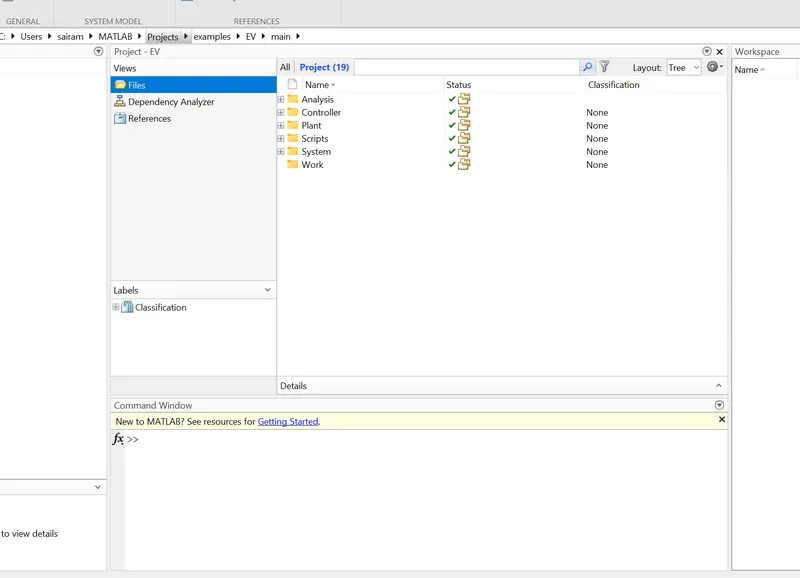
After that the main model is open a new window
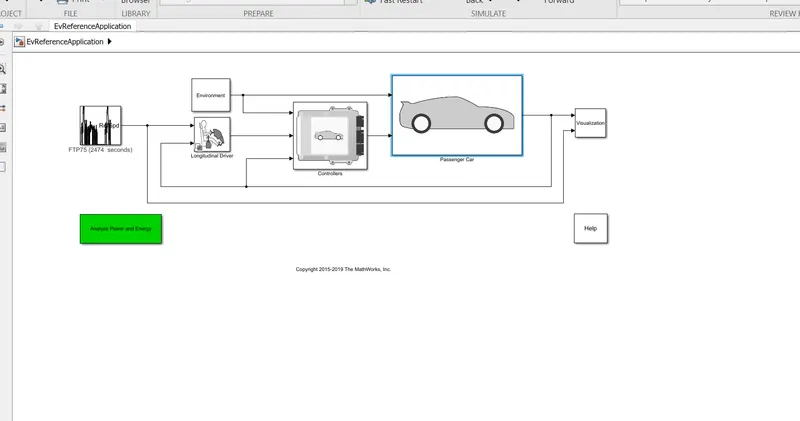
here above the figure we have that some power train block systems are used as
- FTP75 drive cycle
- Longitudinal driver
- environmental subsystem
- controller block
- passenger car system
- visualization block
in order to discuss about the mapped model and dynamic model of motors and generator we have open the passed car subsystem in this
see the below figure highlated block Electric plant we can understand
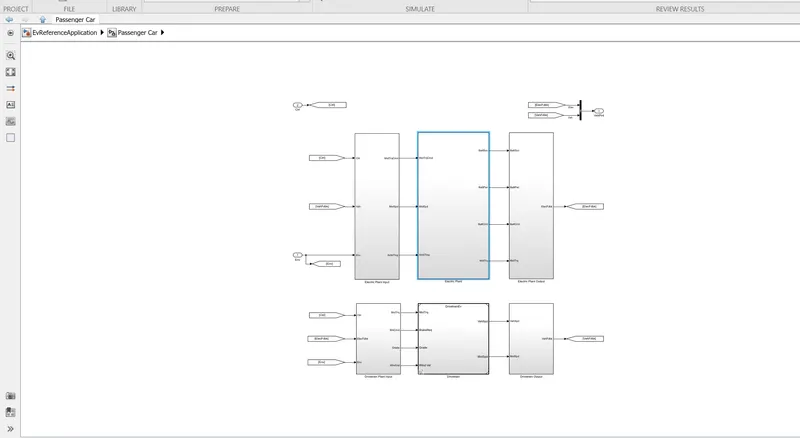
see the below we go to an another subsystem of electric plant there is a motor see the below its shows highlated one
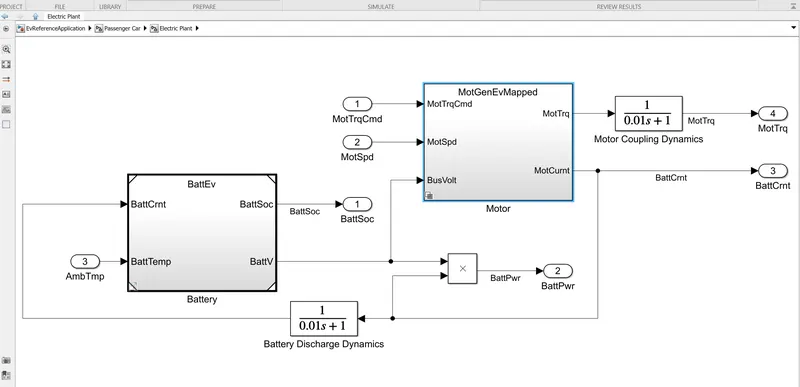
in this motor has an another system is there see the below figure
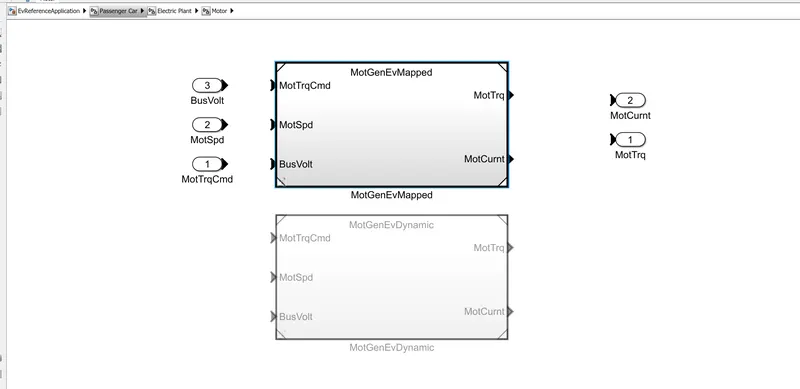
here we can see the motor inside subsystem both mapped model and dynamic model are available . here we can simulate one model at a particular time it means if mapped model is a activated in that time the dynamic model will remain deactivated vice versa
MotGenEv Mapped open model:
IN that Motor generated ev mapped model they have a sub system is shown in below
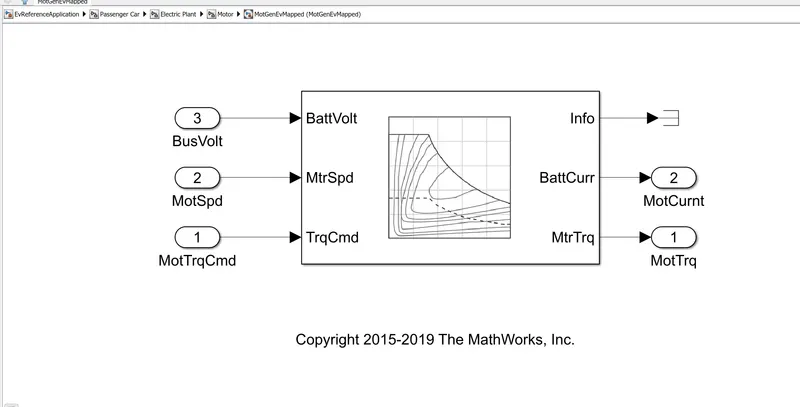
- mapped models are such type of models in which the data or values required parameters (inputs) are pre signed in an look up table
- The output values are stored for the corresponmding given input values of the engine motor and generator
- Accuracy of mapped model is not very high
- this type of model requires very less time to simulate
- as the inputs are presigned in look up table there the output
per the look up table information which means that outputs are stored every single inputs
so calculation are very fast
here inputs parameters such as brake torque ,fuuel flow , air mass flow be exhaust temperature efficiency and emissions
MAPPED models:
Mapped models are used when the behavior of a particular model is not of our interest and can be modeled with predefined values in the form of lookup tables.
eg: mapped motor:
in the below model values are taken from experiments or old data
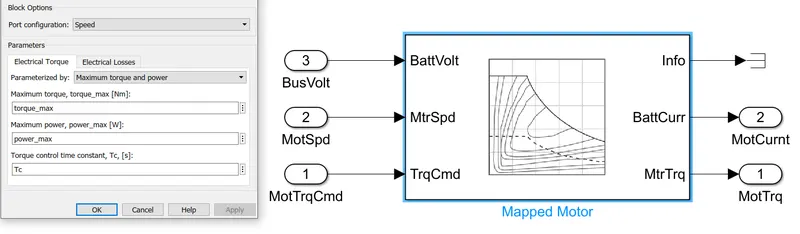
Implements a mapped motor and drive electronics operating in torque control mode. we have to specify electrical torque range with a torque-speed envelope or maximum motor power and torque. Output torque tracks a torque reference demand and includes a motor and drive response time constant. Also have to Specify electrical losses as a single operating point that estimates loss across the operating range, measured loss, or measured efficiency.
DYNAMIC model:
Dynamic models are used when the internal response to a model with respect to its components is needed.
eg. motor model:
in the below model, motor components such as inverter, phase controller, feedback circuits are also modeled.
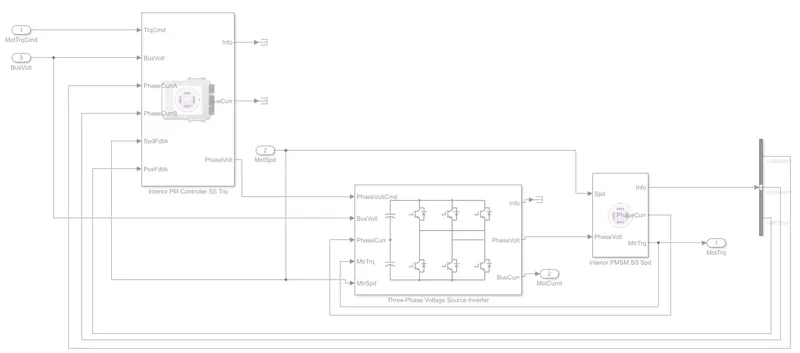
here we changing that motor generator Ev dynamic see the below figure we can understand
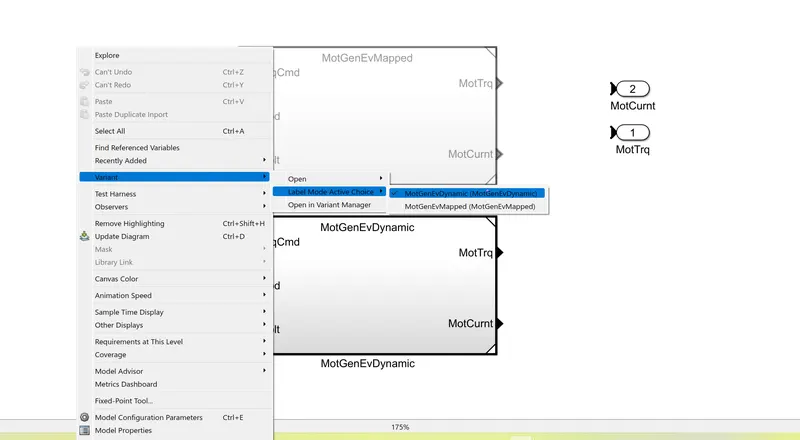
here also see as instructions we can apply the highlated this can be visible like this only
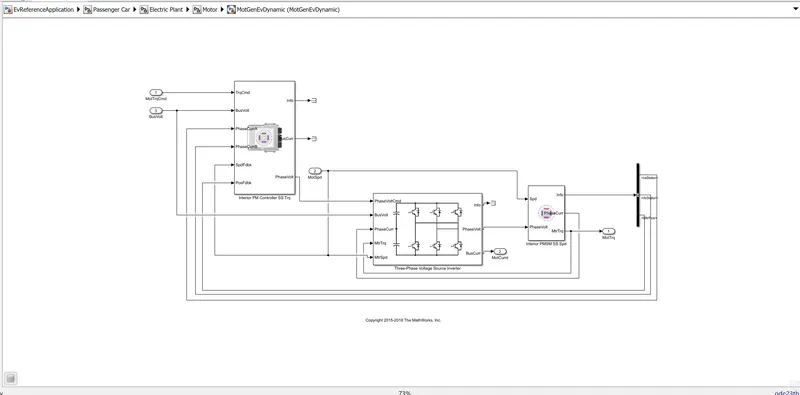
CHANGING the model type in EV powertrain blocks:
we can use the variant manager in the modeling tab to find the variant systems we have.
right-click on the model you want and use set as Label mode active choice.
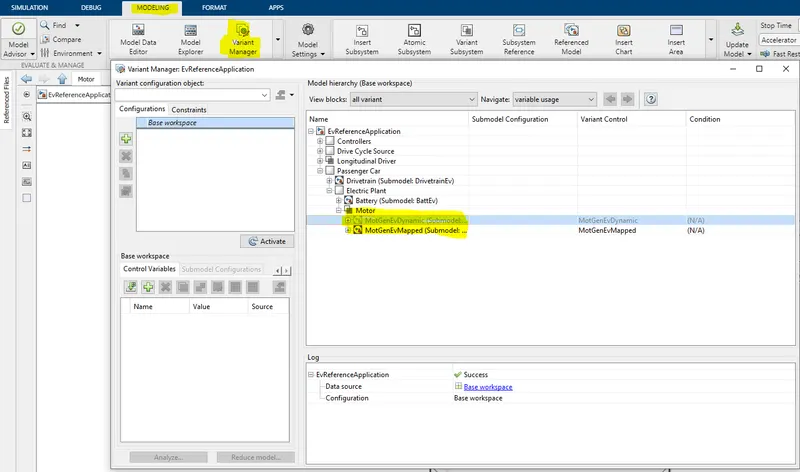
Steps to select the Model Type:
i. In the powertrain blockset module we first need to select the vehicle type first wheather it is full electric , full engine or the type of hybrid vehicle.
ii. After that the Simulink model appears by showing the work flow blocks of the model.
iii. In that we need to go to Passenger Block Electric plant* EV Motor/Generator block.
iv. After this just right click and go to Variance Label mode Active choice MotorGenEV Mapped or Dyanamic.